COMING NOVEMBER 2, 2026
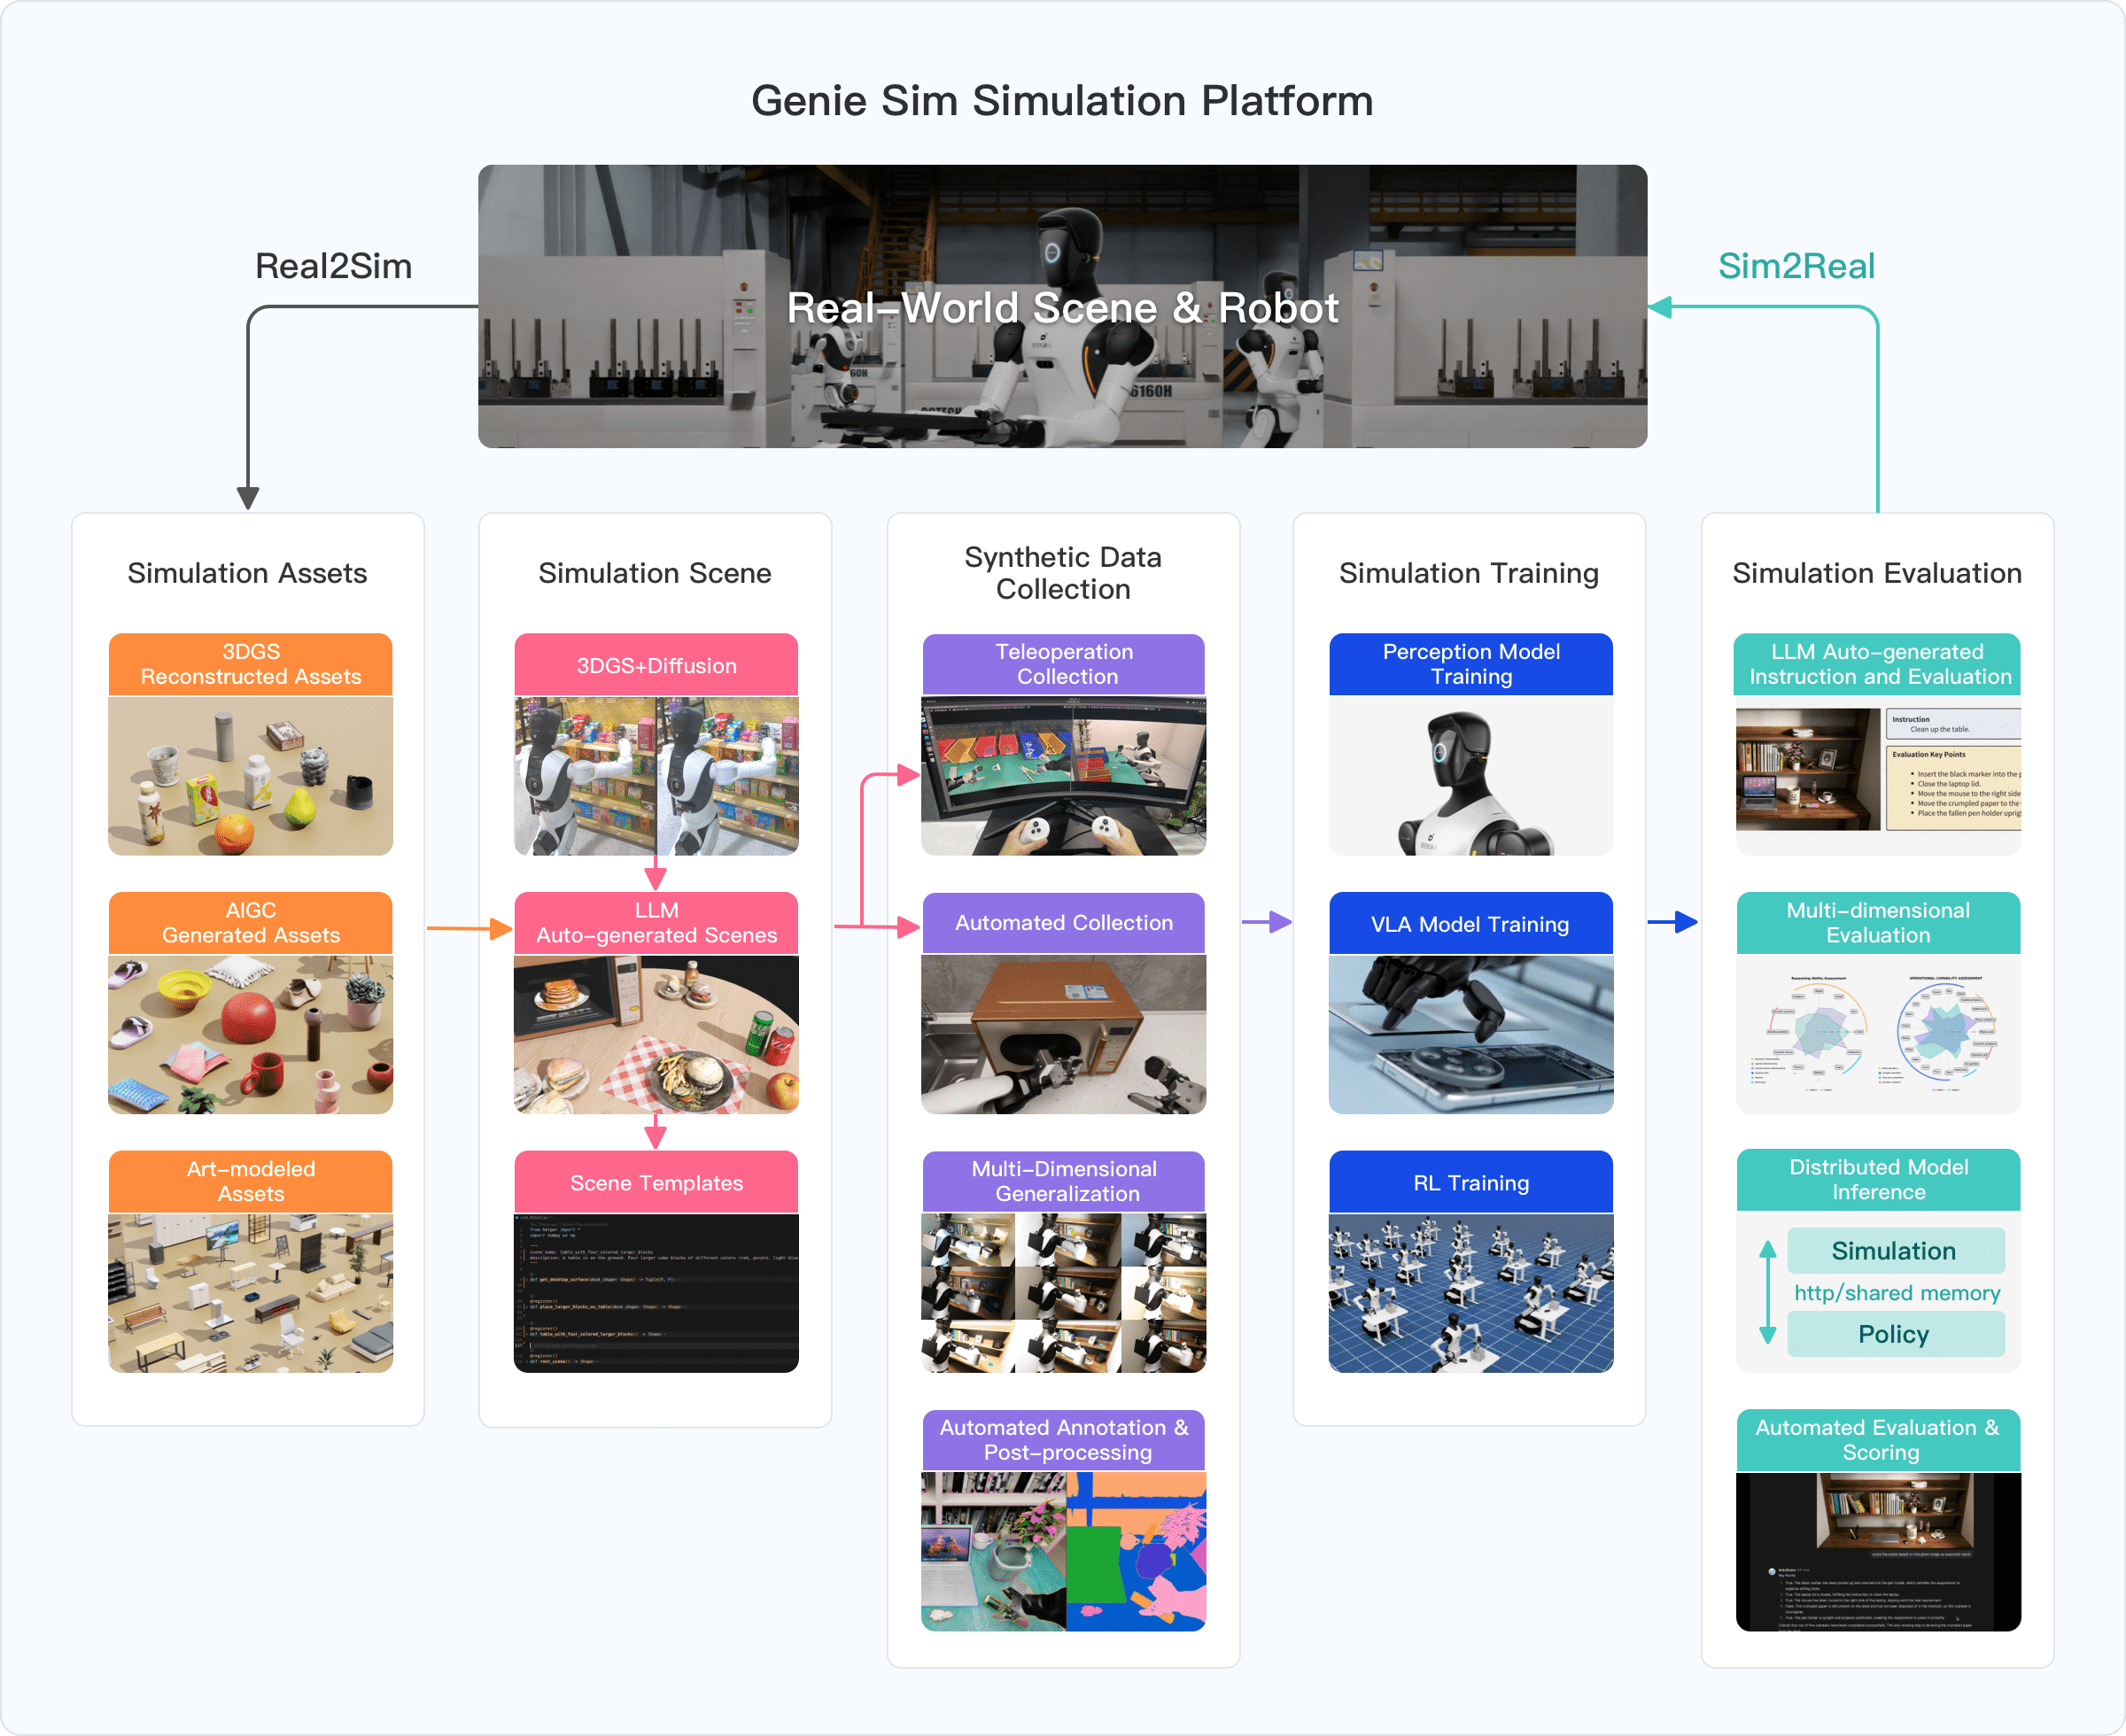
 # 1. ๐ Genie Sim **Genie Sim is the simulation platform from AgiBot.** It provides developers with a complete toolchain for *environment reconstruction*, *scene generalization*, *data collection*, and *automated evaluation*. Its core module, **Genie Sim Benchmark** is a standardized tool dedicated to establishing the most accurate and authoritative evaluation for embodied intelligence. The platform integrates **3D reconstruction** with **visual generation** to create a high-fidelity simulation environment. It pioneers **LLM-driven technology** to generate vast simulation scenes and evaluation configurations in minutes. The evaluation system covers **200+ tasks** across **100,000+ scenarios** to establish a comprehensive capability profile for models. Genie Sim also opens over **10,000 hours of synthetic data** including real-world robot operation scenarios. The platform will significantly accelerate model development, reduce reliance on physical hardware, and empower innovation in embodied intelligence. Simulation assets, dataset, and code are **fully open source**. # 2. โจ Features - ๐ง **`geniesim` CLI**: one command-line entry point for the entire platform โ docker lifecycle, ROS 2 workspace builds, health diagnosis (`doctor`), pure-Python wheel deploy, asset / scene bootstrap. Packaged as a standalone PEP 517 / PEP 621 wheel. - ๐ค **Agent-ready SKILLs**: packaged `SKILL.md` recipes for benchmarking, inference checks, scene generation, asset search, and teleop โ invokable directly by Claude Code / agentic coding agents, so the simulator can be driven without a human first reading the docs. - โก **Genie Sim RT Engine (realtime, interactive)**: `geniesim_ros` brings physics, render, and the robot into ROS 2 natively โ teleop, MoveIt, and ros2_control close the loop on one shared `sim_time`. Multiple physics backends (Isaac Sim PhysX, Newton-standalone) selectable per scene, with cloth + soft-body support on the Newton path. - ๐จ **High-Fidelity Sim-Ready Assets**: 5,140 validated 3D assets covering five real-world operation fields: retail, industry, catering, home and office. [ModelScope](https://modelscope.cn/datasets/agibot_world/GenieSimAssets). - ๐ฐ๏ธ **3DGS-based Reconstruction Pipeline**: Integrate 3DGS-based reconstruction process with visual generative model to synthesize realistic simulation environment with high-precision meshes. [ModelScope](https://modelscope.cn/datasets/agibot_world/GenieSim3.0-Dataset). - ๐ Genie Sim World: A multimodal spatial world model which generates photorealistic 3D world from diverse input types in minutes. [GitHub](source/geniesim_world). - ๐ฌ **LLM-Driven Scene Generation**: Natural language-driven generation and generalization which instantly generates diverse simulation scenes through conversational interaction. - ๐ฆ **Large-Scale Synthetic Dataset**: Over 10,000 hours open-source synthetic data across 200+ loco-manipulation tasks with multi-sensor streams, alongside multi-dimensional variations. - ๐ ๏ธ **Synthetic Data Generation**: Efficient toolkit for data collection with error-recovery mechanism, supporting both low-latency teleoperation and automated data programming. [ModelScope](https://modelscope.cn/datasets/agibot_world/GenieSim3.0-Dataset). - ๐งช **Robust and Diverse Benchmark**: Provide 100,000+ simulation scenarios and use LLM to autonomously generate task instructions and evaluation configurations. Discrepancy between simulation and real-world test results is less than 10%. - ๐ **VLM-based Auto-Evaluation System**: Full-spectrum evaluation criteria to provide model's capability profile covering manipulation skills, cognitive comprehension and task complexity. - ๐ **Zero-Shot Sim-to-Real Transfer**: Model trained with our synthetic data exhibits zero-shot sim-to-real transfer capability with superior task success rate compared to model trained with real data. # 3. ๐ Quick start ### 3.1 ๐ง CLI & ๐ค SKILLs โ install, build the container, get a shell ```mermaid flowchart LR pip(["๐ฆ pip install| ### GenieSim-Instruction | Tasks | π0.5 | ACoT-VLA | GR00T-N1.7 | π0 | | :------------------- | :----------------: | :------: | :--------: | :--------------: | | pick_billiards_color | 0.83 | **0.91** | 0.73 | 0.50 | | pick_block_color | 0.87 | **0.96** | 0.80 | 0.49 | | pick_block_number | **0.82** | 0.76 | 0.61 | 0.40 | | pick_block_shape | **0.55** | 0.52 | 0.44 | 0.20 | | pick_block_size | 0.79 | **0.83** | 0.62 | 0.34 | | pick_common_sense | 0.59 | 0.66 | **0.68** | 0.19 | | pick_follow_logic_or | **0.81** | 0.79 | 0.72 | 0.39 | | pick_object_type | **0.80** | **0.80** | 0.72 | 0.42 | | pick_specific_object | 0.81 | **0.83** | 0.69 | 0.37 | | straighten_object | **0.59** | 0.51 | 0.45 | 0.38 | | **Avg.** | 0.75 | **0.76** | 0.65 | 0.37 | | ### GenieSim-Robust | Perturbation | π0.5 | ACoT-VLA | GR00T-N1.7 | π0 | | :-------------- | :----------------: | :-------: | :--------: | :--------------: | | Instruction | 0.689 | **0.739** | 0.678 | 0.332 | | Robot Pose | 0.492 | **0.543** | 0.429 | 0.240 | | Background | 0.709 | **0.737** | 0.646 | 0.381 | | Image Quality | **0.599** | 0.589 | 0.489 | 0.307 | | Camera Position | **0.575** | 0.504 | 0.449 | 0.303 | | **Avg.** | 0.613 | **0.622** | 0.538 | 0.313 | |
## 5.4 ๐ License and Citation
All the data and code within `source/geniesim_*` and `source/data_collection` are under `Mozilla Public License 2.0` unless licensed specifically. The `source/scene_reconstruction` project contains code under multiple licenses, for complete and updated licensing details, please see the LICENSE files
Please consider citing our work either way below if it helps your research.
```
@misc{yin2026geniesim30,
title={Genie Sim 3.0 : A High-Fidelity Comprehensive Simulation Platform for Humanoid Robot},
author={Chenghao Yin and Da Huang and Di Yang and Jichao Wang and Nanshu Zhao and Chen Xu and Wenjun Sun and Linjie Hou and Zhijun Li and Junhui Wu and Zhaobo Liu and Zhen Xiao and Sheng Zhang and Lei Bao and Rui Feng and Zhenquan Pang and Jiayu Li and Qian Wang and Maoqing Yao},
year={2026},
eprint={2601.02078},
archivePrefix={arXiv},
primaryClass={cs.RO},
url={https://arxiv.org/abs/2601.02078},
}
```
## 5.5 ๐ References
1. PDDL Parser (2020). Version 1.1. [Source code]. https://github.com/pucrs-automated-planning/pddl-parser.
2. BDDL. Version 1.x.x [Source code]. https://github.com/StanfordVL/bddl
3. CUROBO [Source code]. https://github.com/NVlabs/curobo
4. Isaac Lab [Source code]. https://github.com/isaac-sim/IsaacLab
5. Omni Gibson [Source code]. https://github.com/StanfordVL/OmniGibson
6. The Scene Language [Source code]. https://github.com/zzyunzhi/scene-language
7. COAL [Source code]. https://github.com/coal-library/coal
8. OCTOMAP [Source code]. https://github.com/OctoMap/octomap
9. PINOCCHIO [Source code]. https://github.com/stack-of-tasks/pinocchio
10. URDFDOM [Source code]. https://github.com/ros/urdfdom
11. LIBCCD [Source code]. https://github.com/danfis/libccd
12. LIBMINIZIP [Source code]. https://github.com/switch-st/libminizip
13. LIBODE [Source code]. https://github.com/markmbaum/libode
14. LIBURING [Source code]. https://github.com/axboe/liburing
15. MuJoCo [Source code]. https://github.com/google-deepmind/mujoco