# Robot Models Repository
This repository contains 3D models for eight Deep Robotics robots: **Lite3**, **M20**, **M20S**, **X30**, **M20_Piper**, **DR02 Pro**, **DR02 Standard**, and **S10**. Models are provided in MJCF, URDF, and, where available, USD formats. To visualize a model and take measurements, we recommend using this [viewer tool]([https://viewer.robotsfan.com/](https://developer.deeprobotics.cn/viewer/)) — just drag the model folder onto the web page.
High-resolution models are available on [Google Drive](https://drive.google.com/drive/folders/1EOELXUYSBPEJeD0rUIkJxnlLMDr6IHBV?usp=sharing) and are intended for use with modern simulators such as Isaac Lab and Isaac Sim. The low-resolution models bundled in this repository are provided for broad compatibility with older simulators.
Lite3 sensor frames were corrected on 2026-10-27: the D435i and MID360 mounting frames tilt downward by 20° and 15°, respectively. The URDF and USD define mounting frames; the USD also supplies optical frame transforms without active camera or lidar prims. The MJCF aligns its camera and single-ray rangefinder axes with these mounts.
## Model Overview
| Robot Model | High-Resolution Render | Low-Resolution Render |
|:-----------:|:----------------------:|:---------------------:|
| **Lite3** | 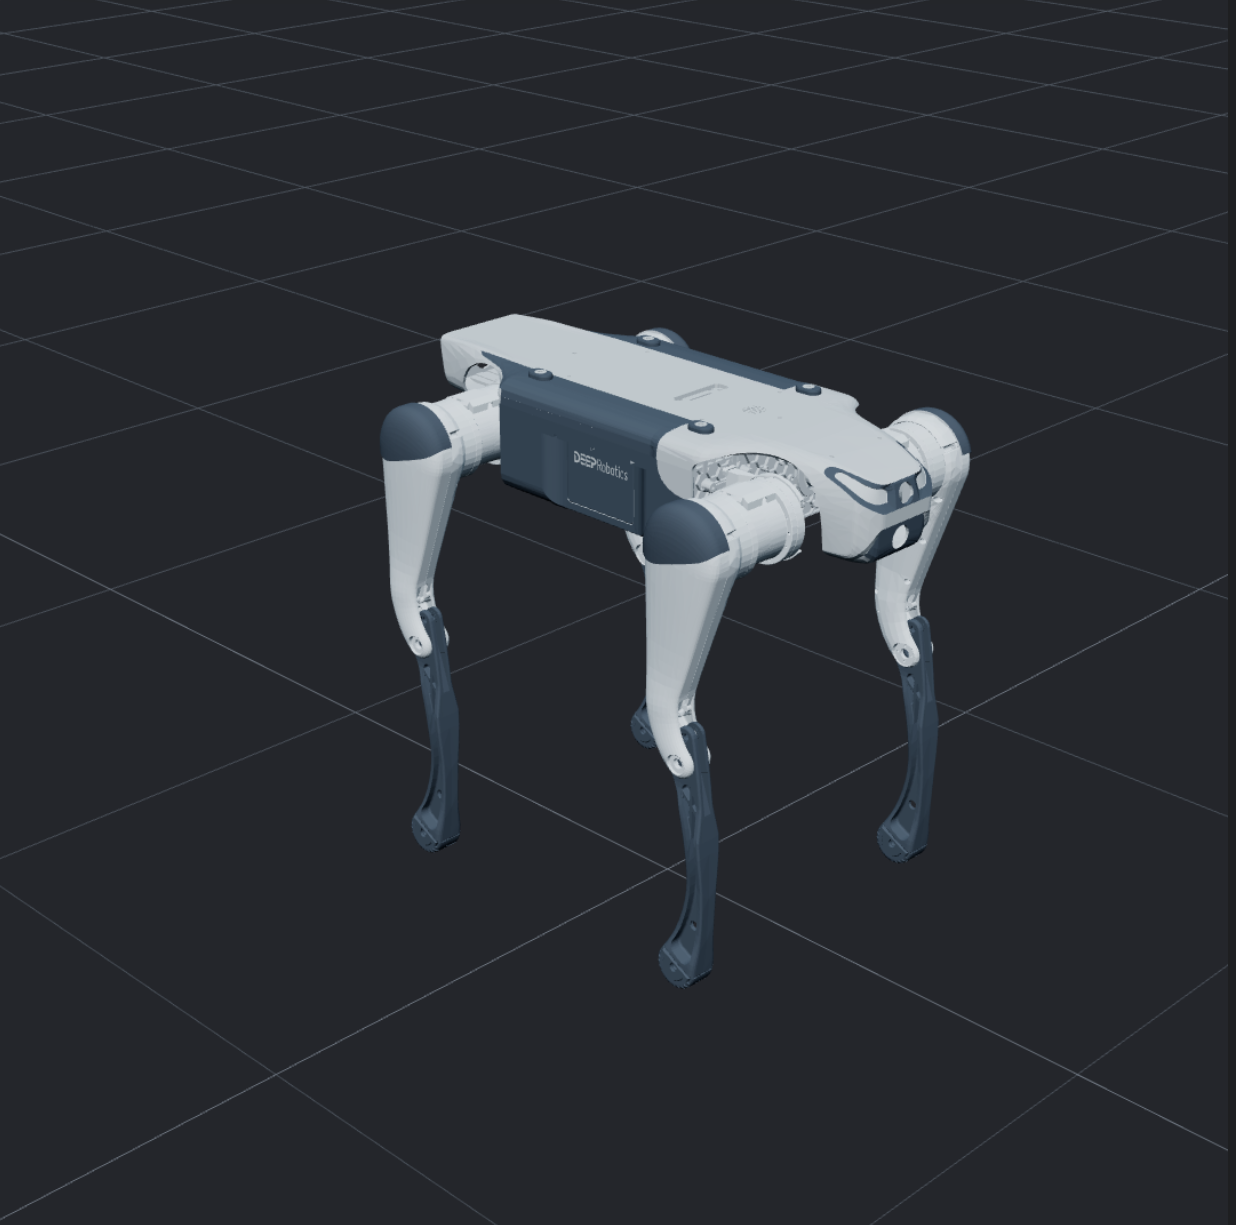 |
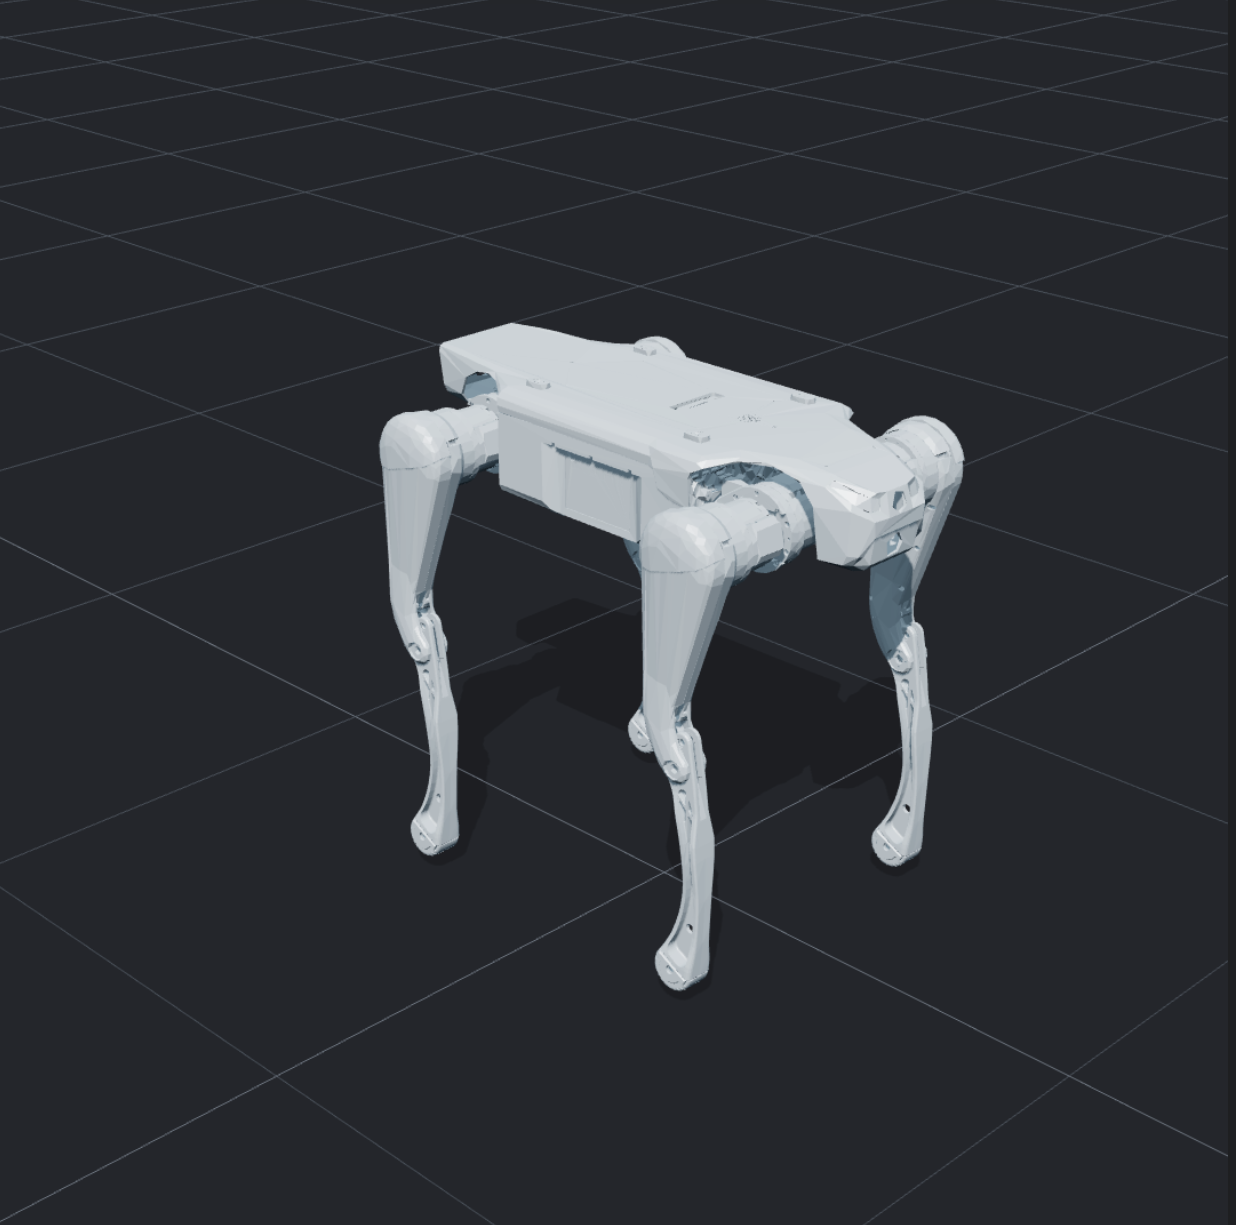 |
| **M20** |
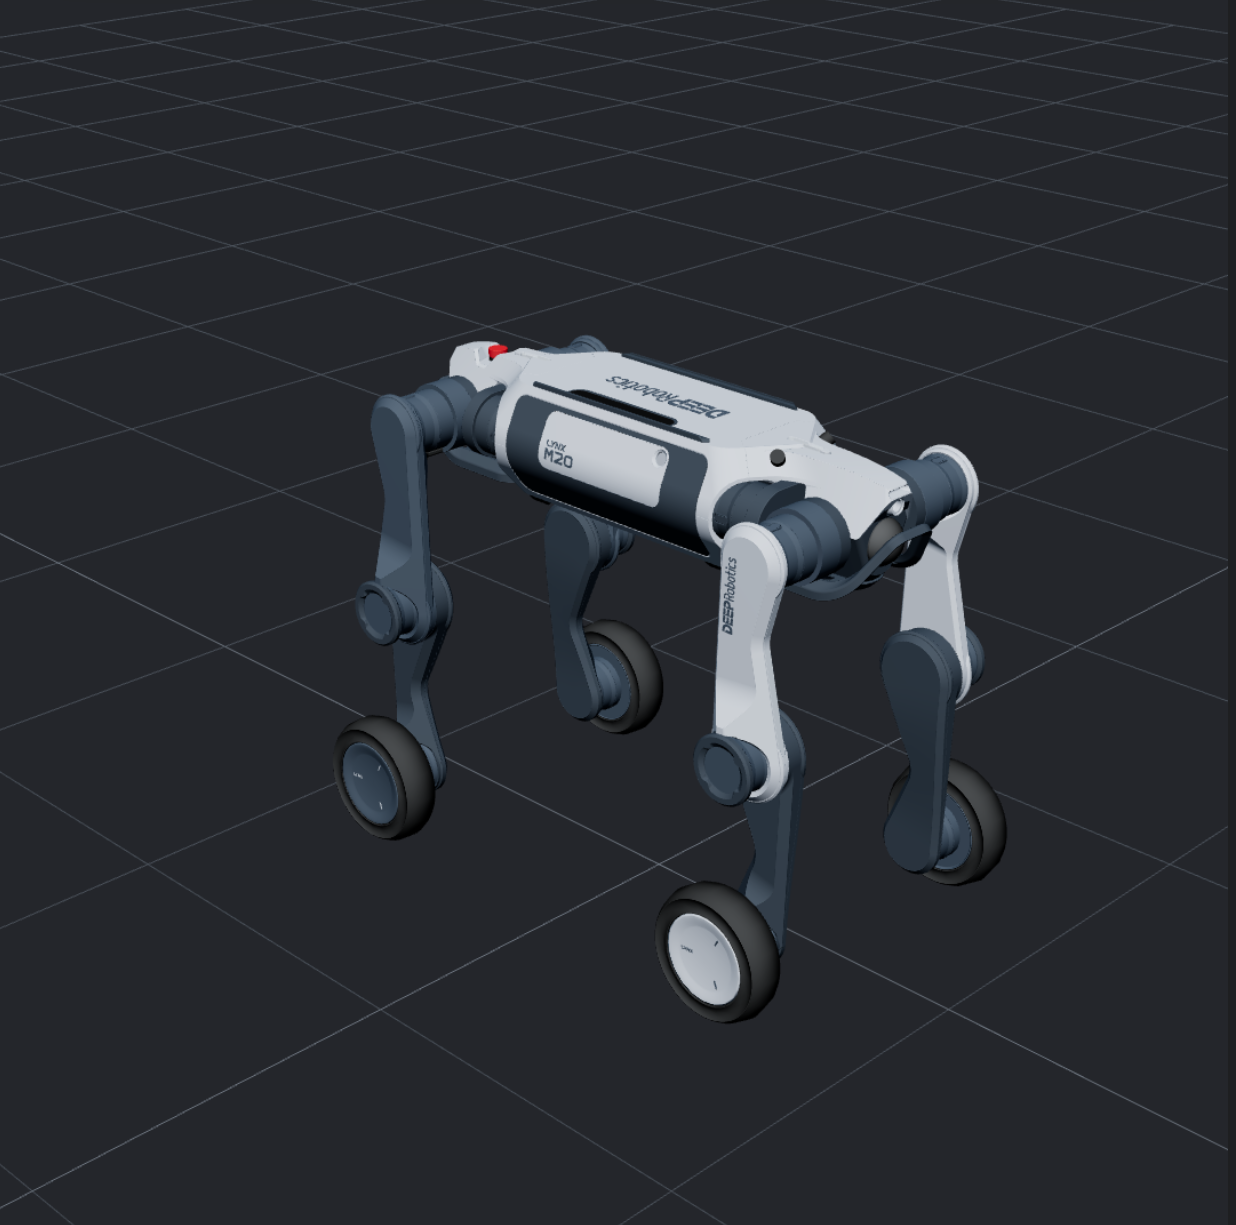 |
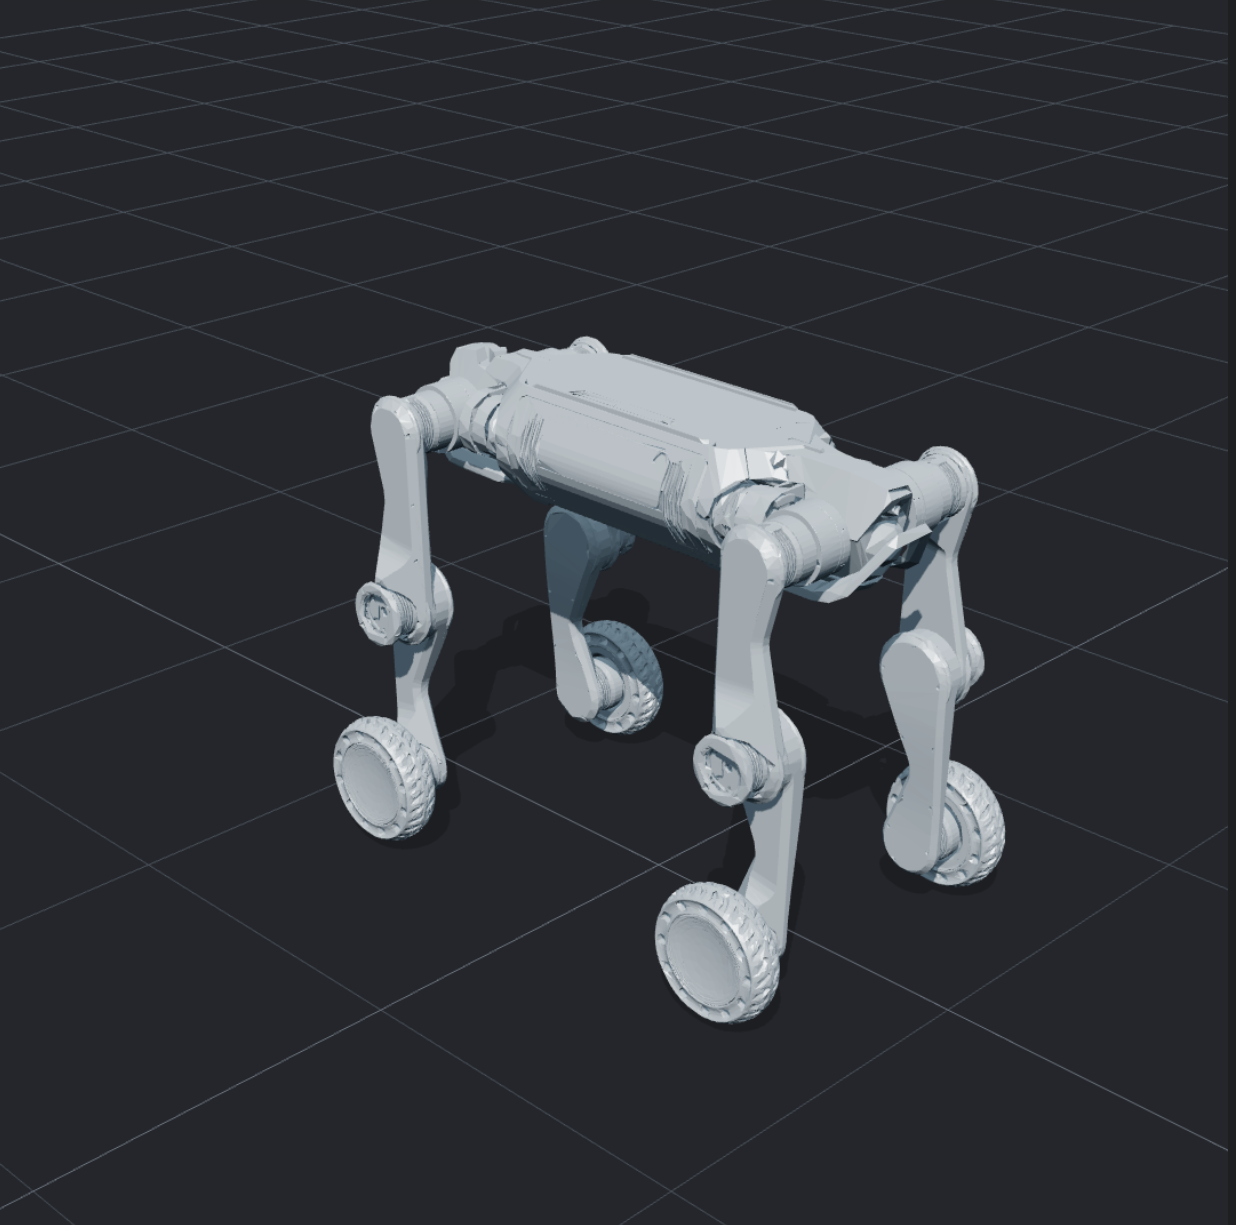 |
| **M20S** | — |
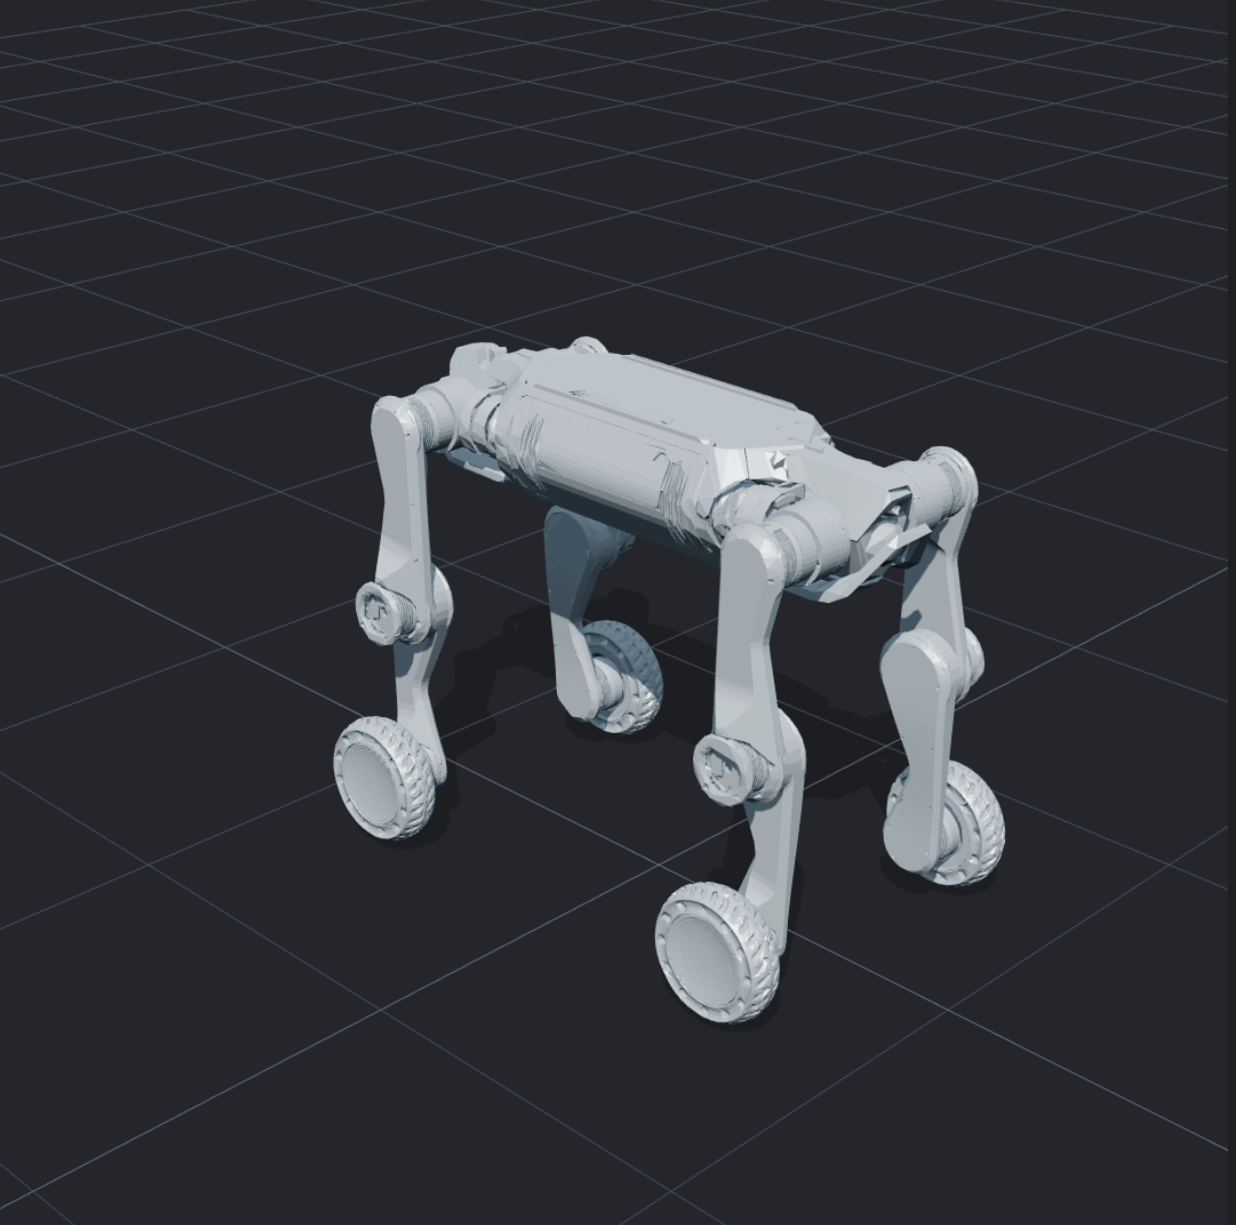 |
| **M20_Piper** | — |
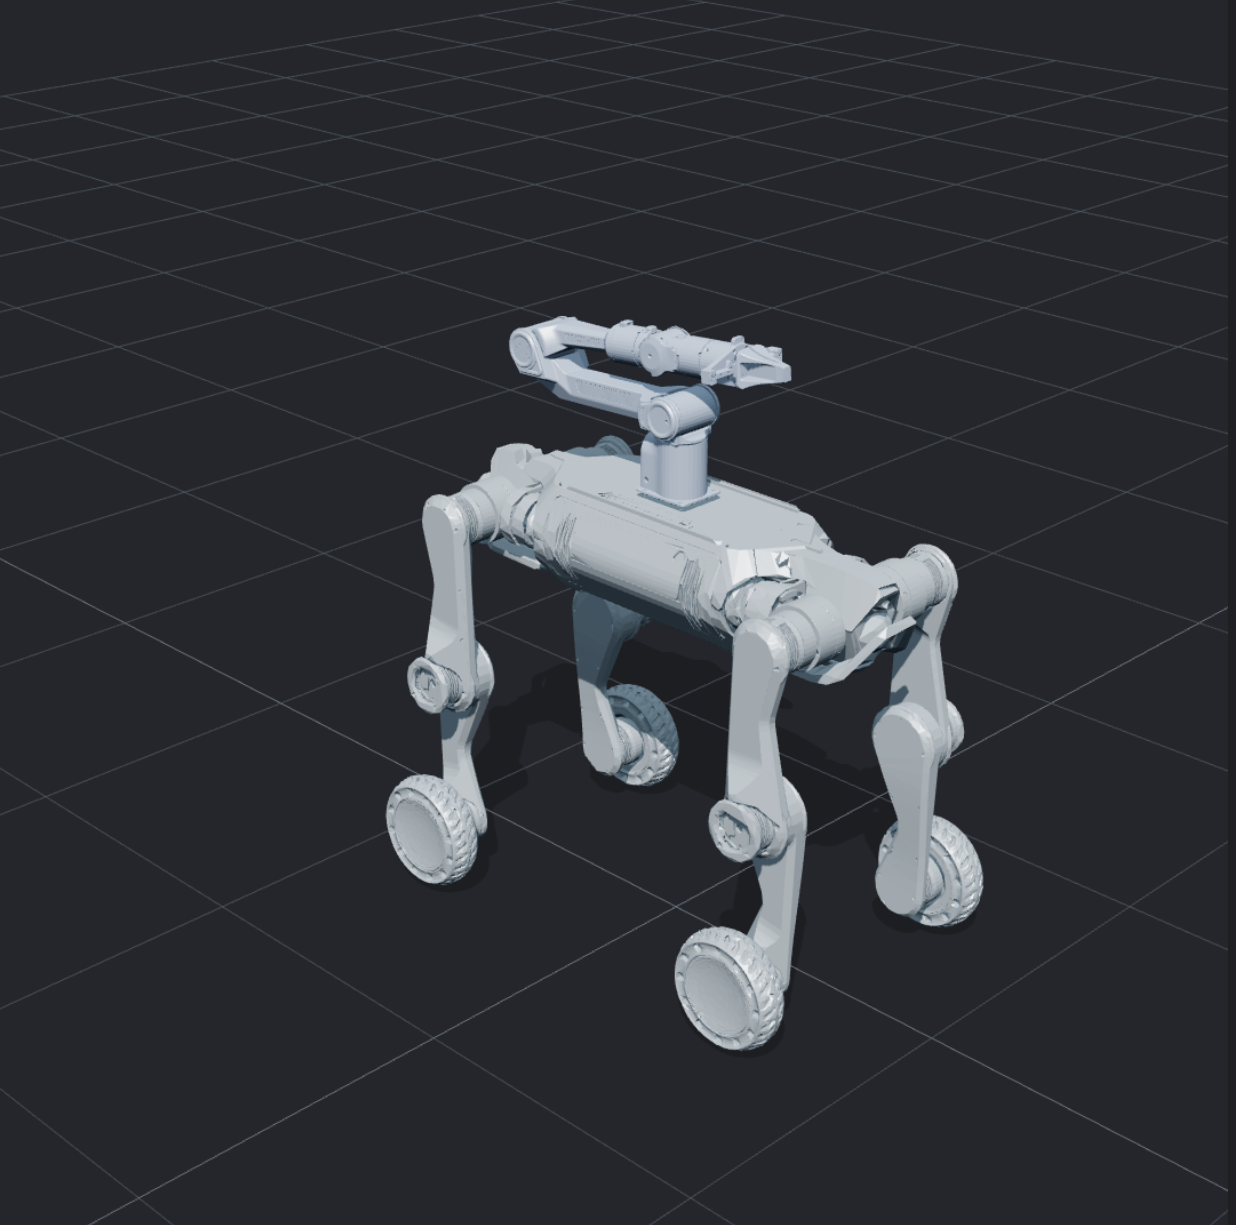 |
| **X30** |
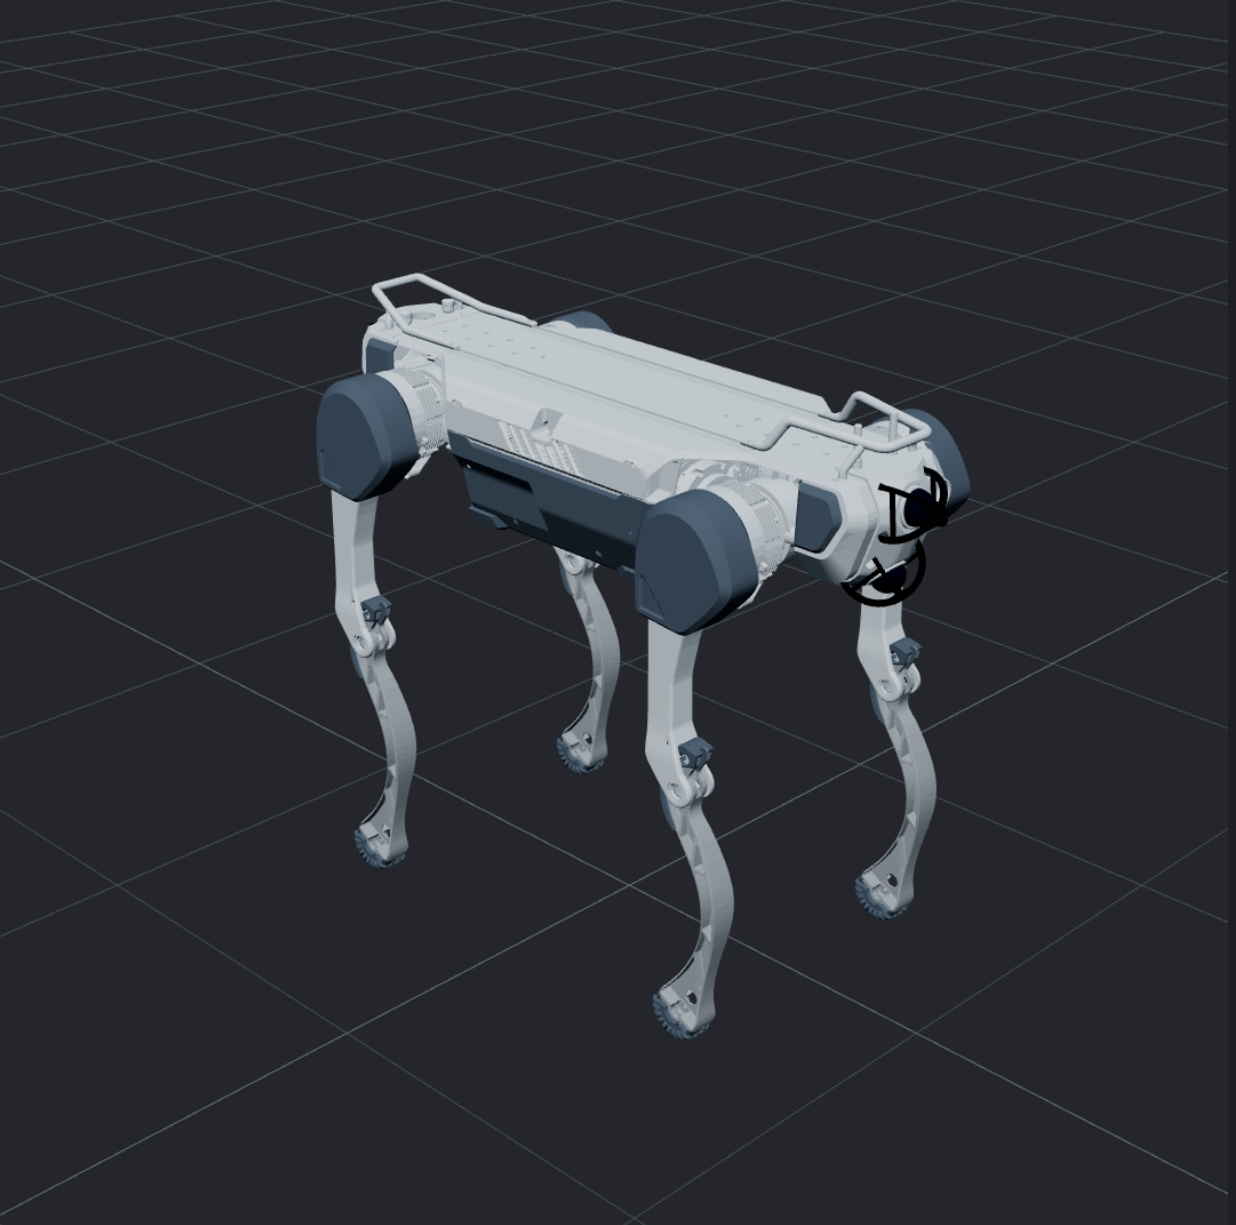 |
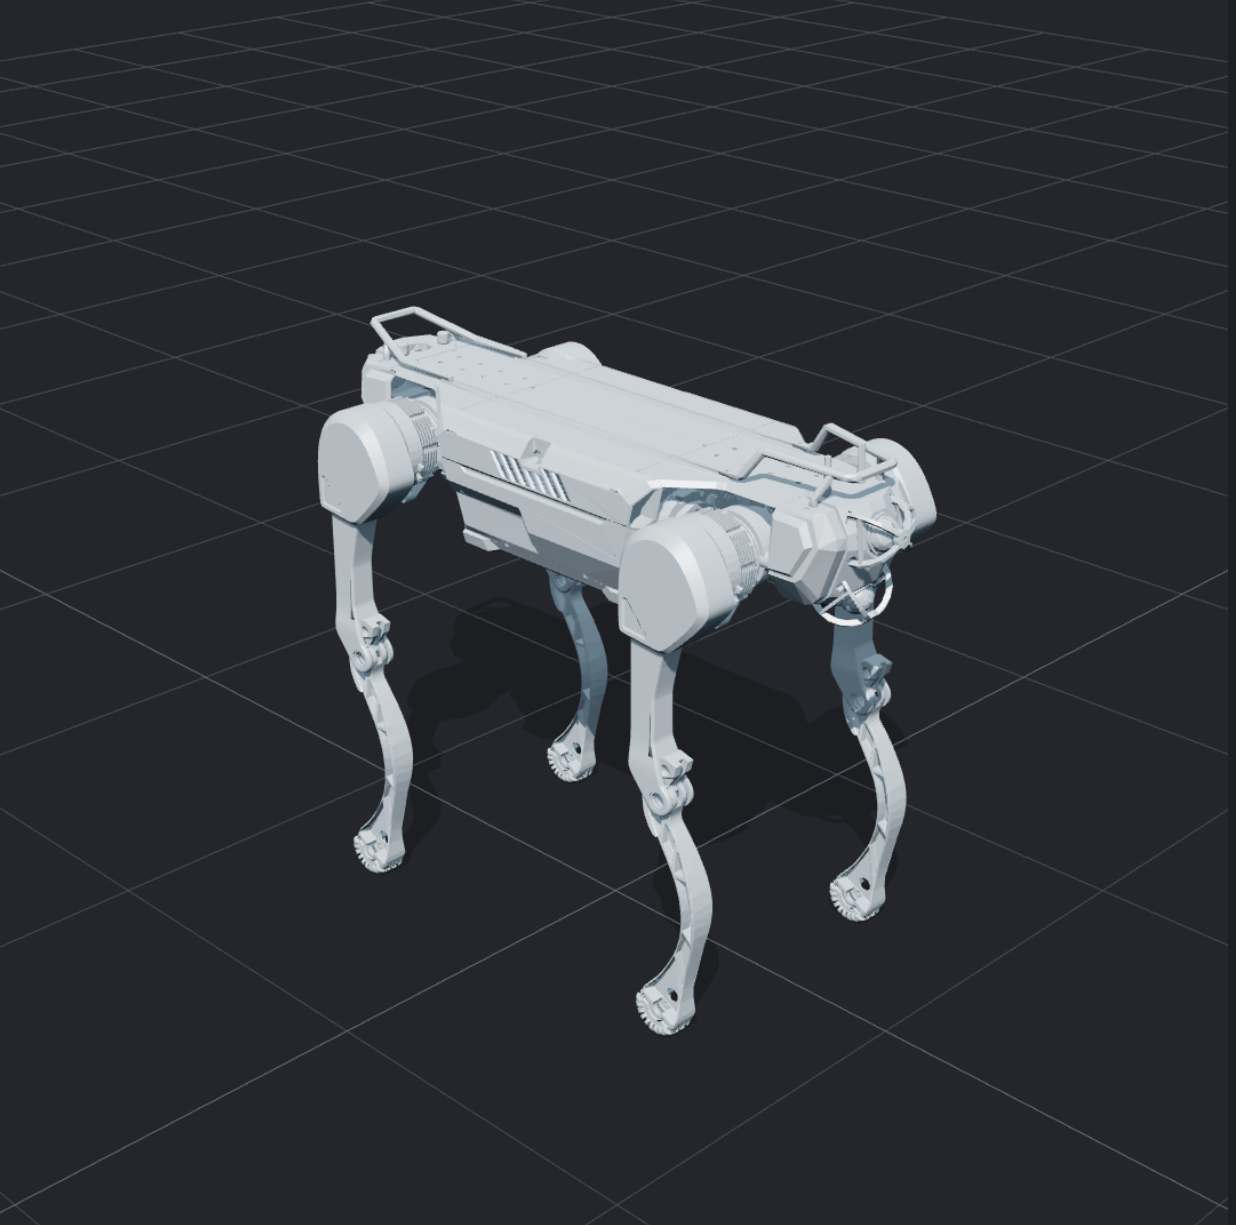 |
| **DR02 Pro** |
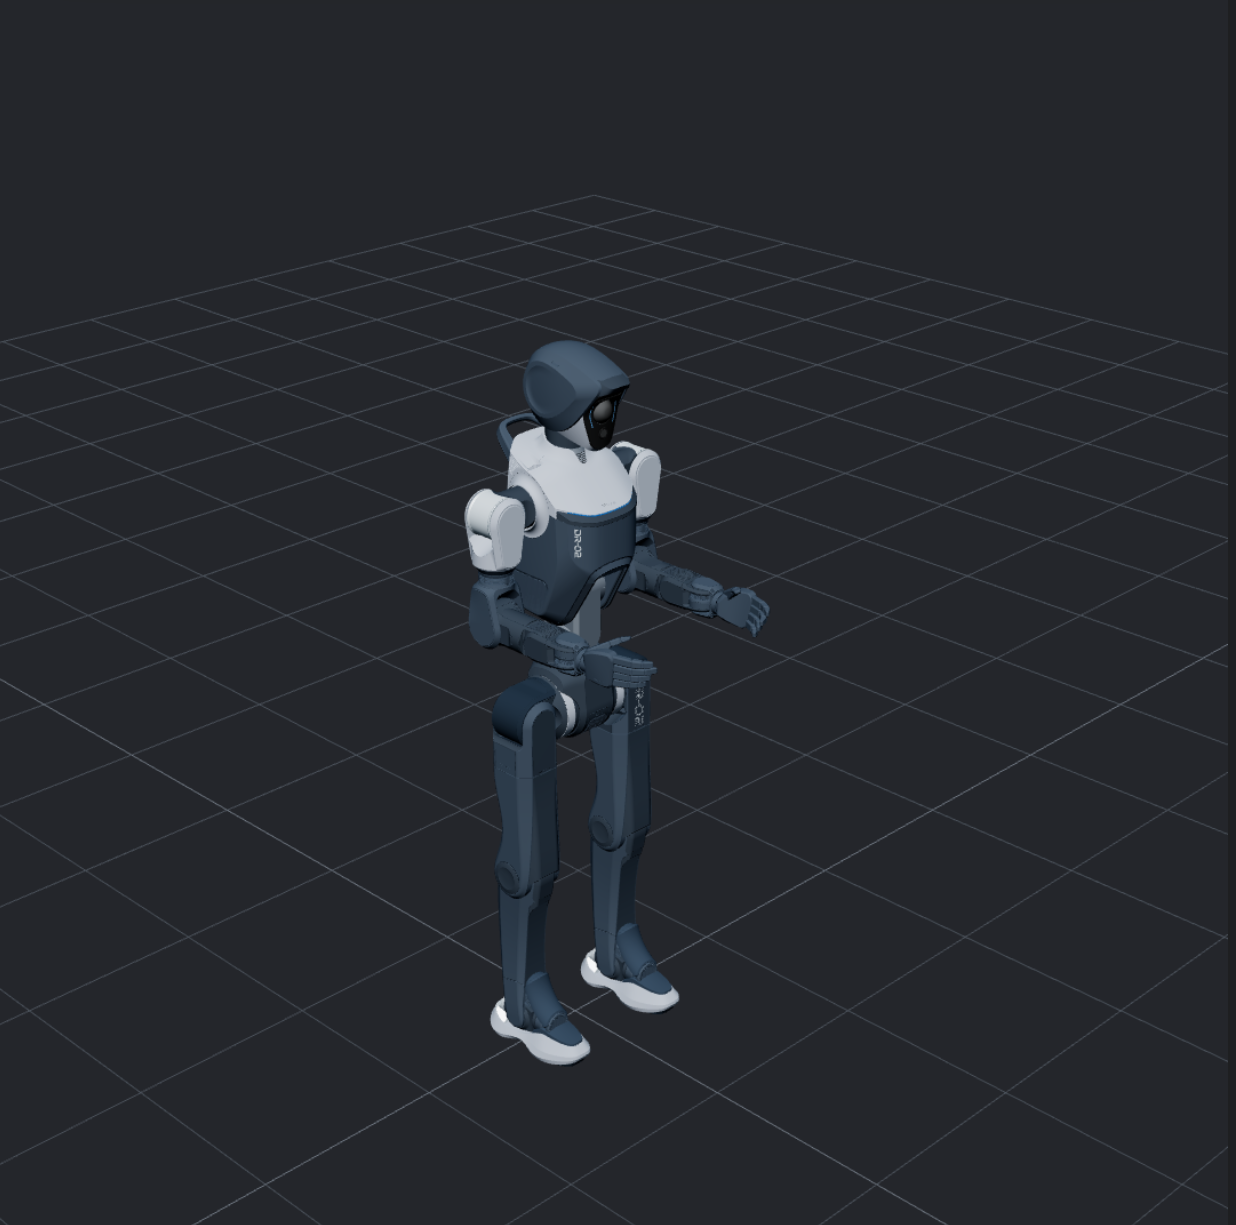 |
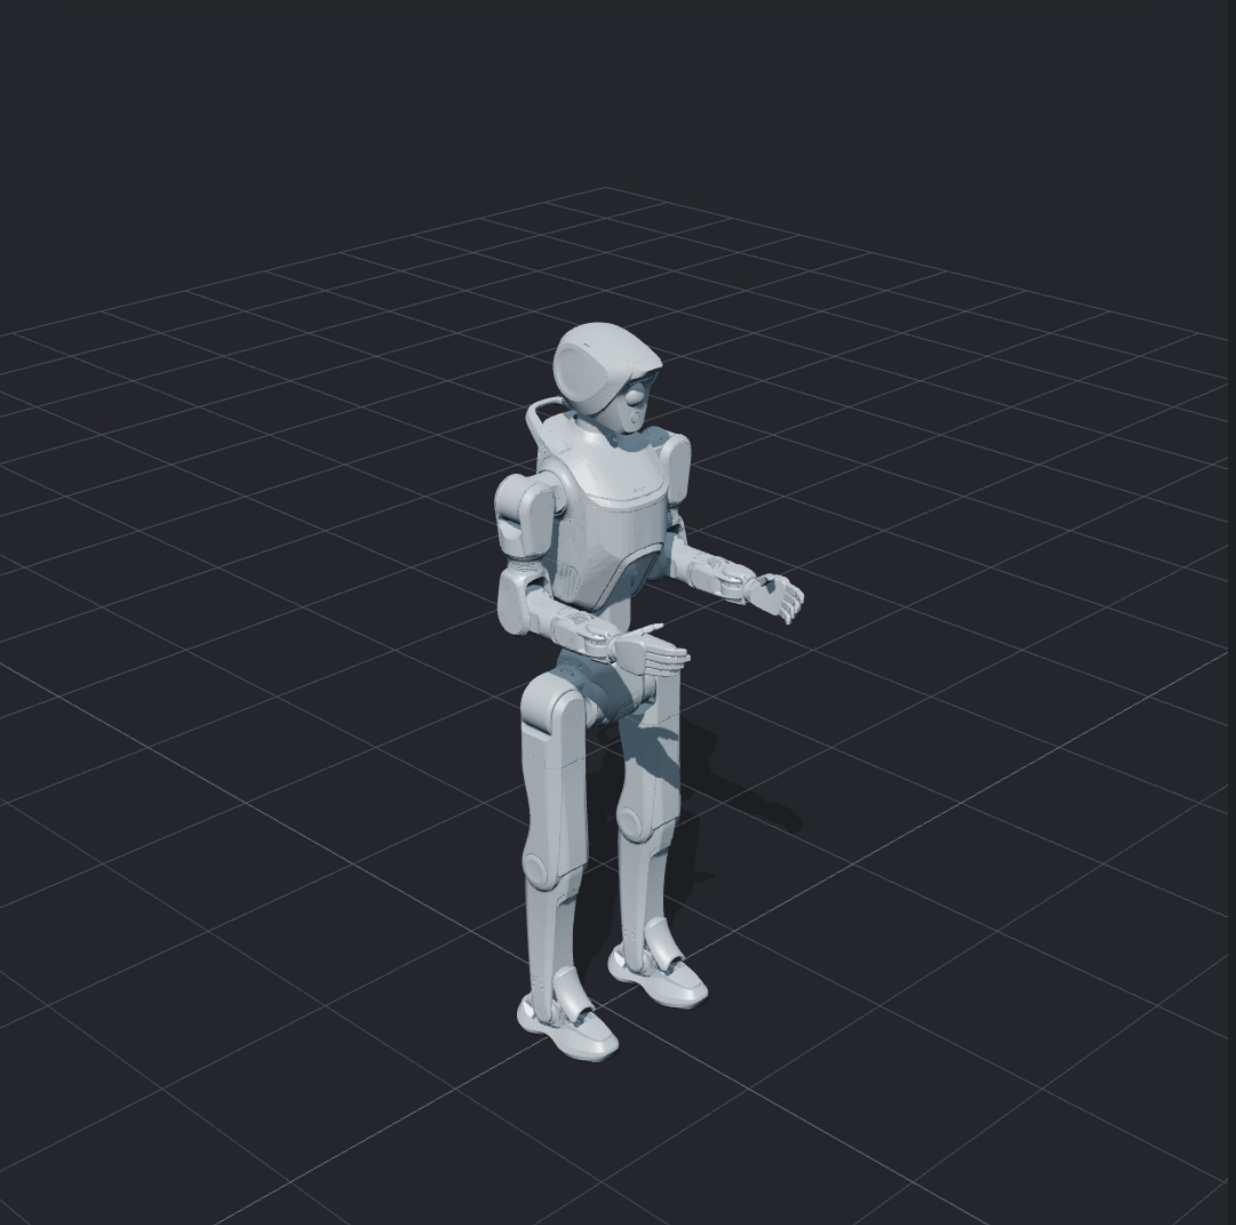 |
| **DR02 Standard** |
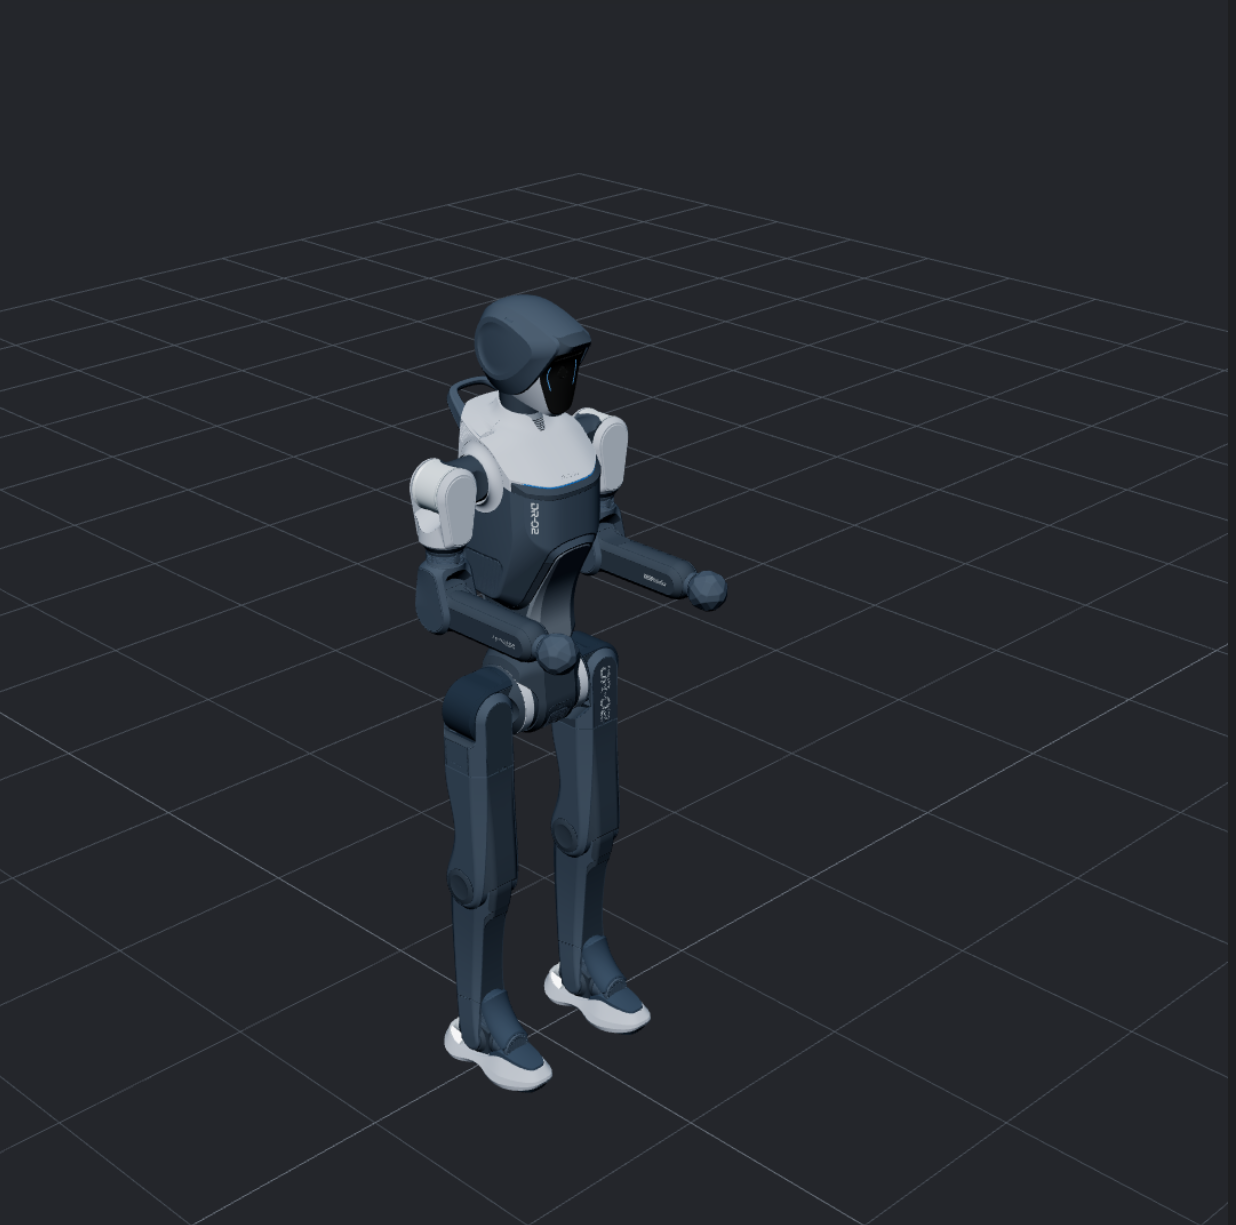 |
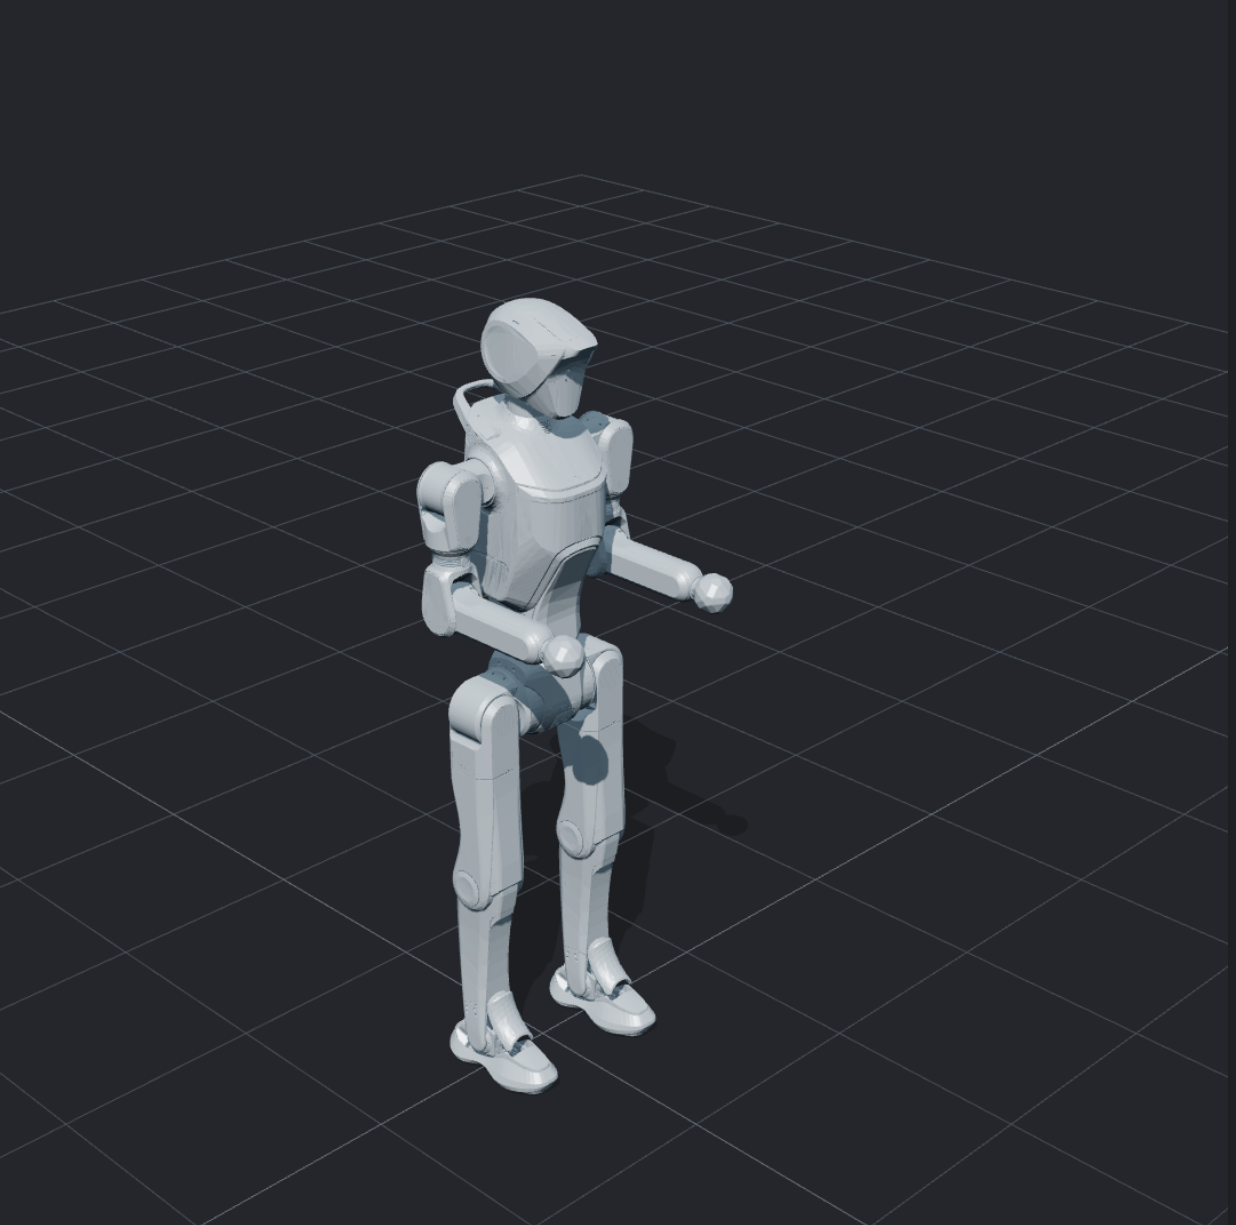 |
| **S10** | — |
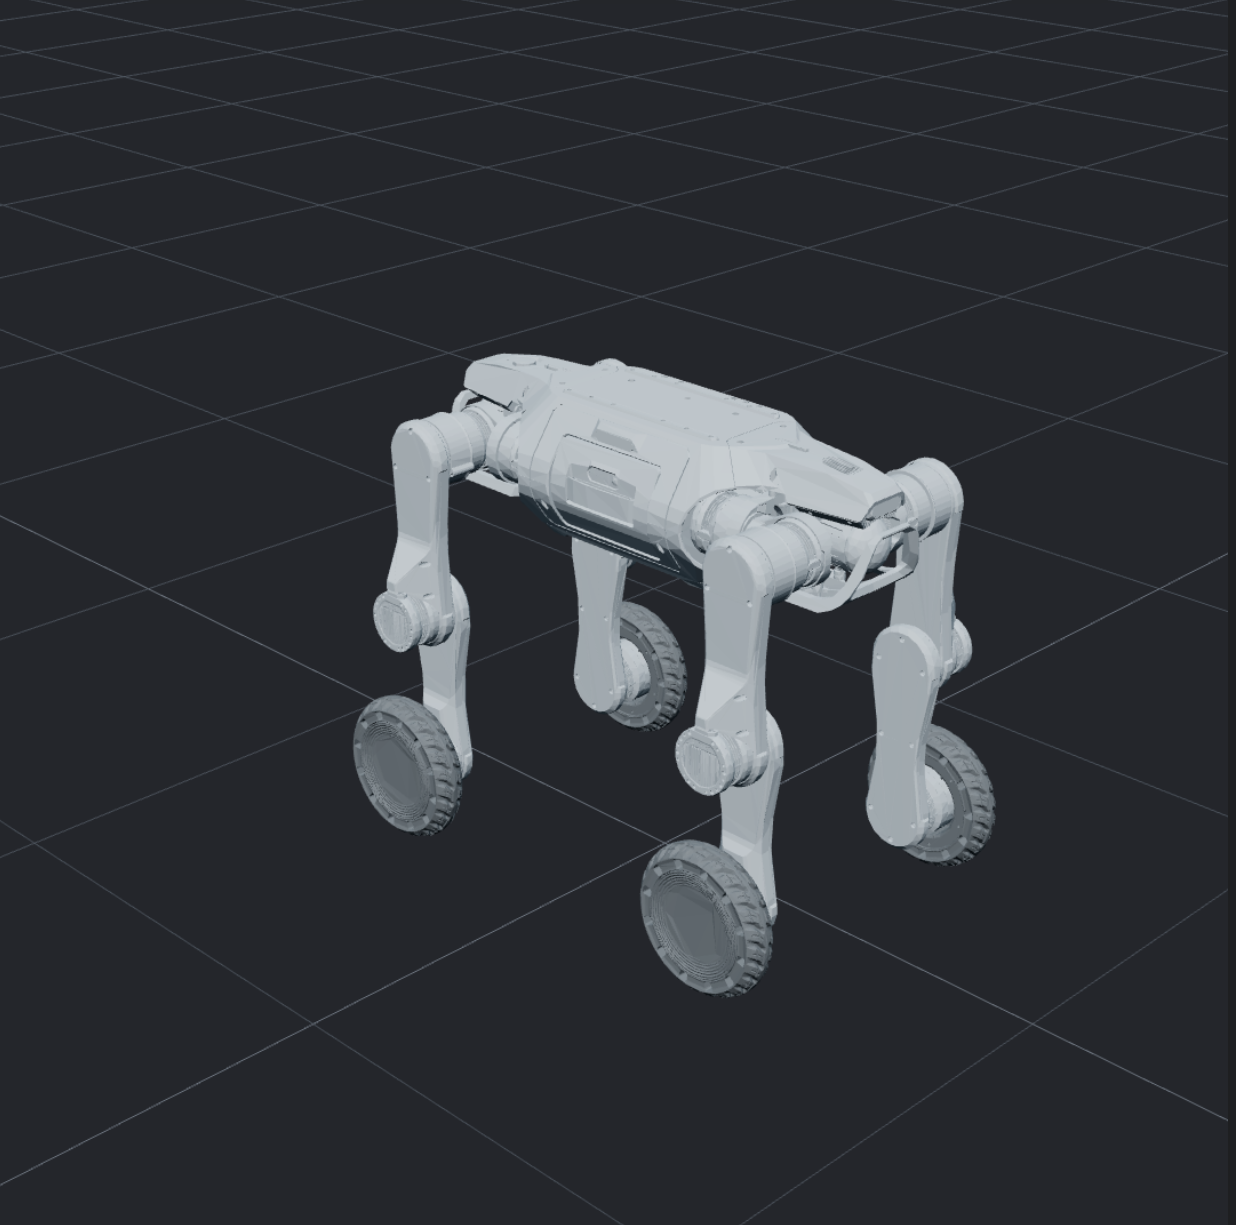 |
## Contributors
See the [Contributors](Contributors.md) page for a list of contributors.