# GenManip: LLM-driven Simulation for Generalizable Instruction-Following Manipulation
๐Ÿ“„ **Official Project Page for CVPR 2025 Paper** ๐ŸŽฅ Watch the demo video below to see **GenManip** in action!
GenManip Video

[![Paper](https://img.shields.io/badge/Paper-arXiv%20\(CVPR%202025\)-blue)](https://arxiv.org/abs/2506.10966) [![Project Page](https://img.shields.io/badge/Website-genmanip.axi404.top-%231877F2)](https://genmanip.axi404.top/) [![Docs](https://img.shields.io/badge/Docs-Available-brightgreen)](https://genmanip.axi404.top/overview)
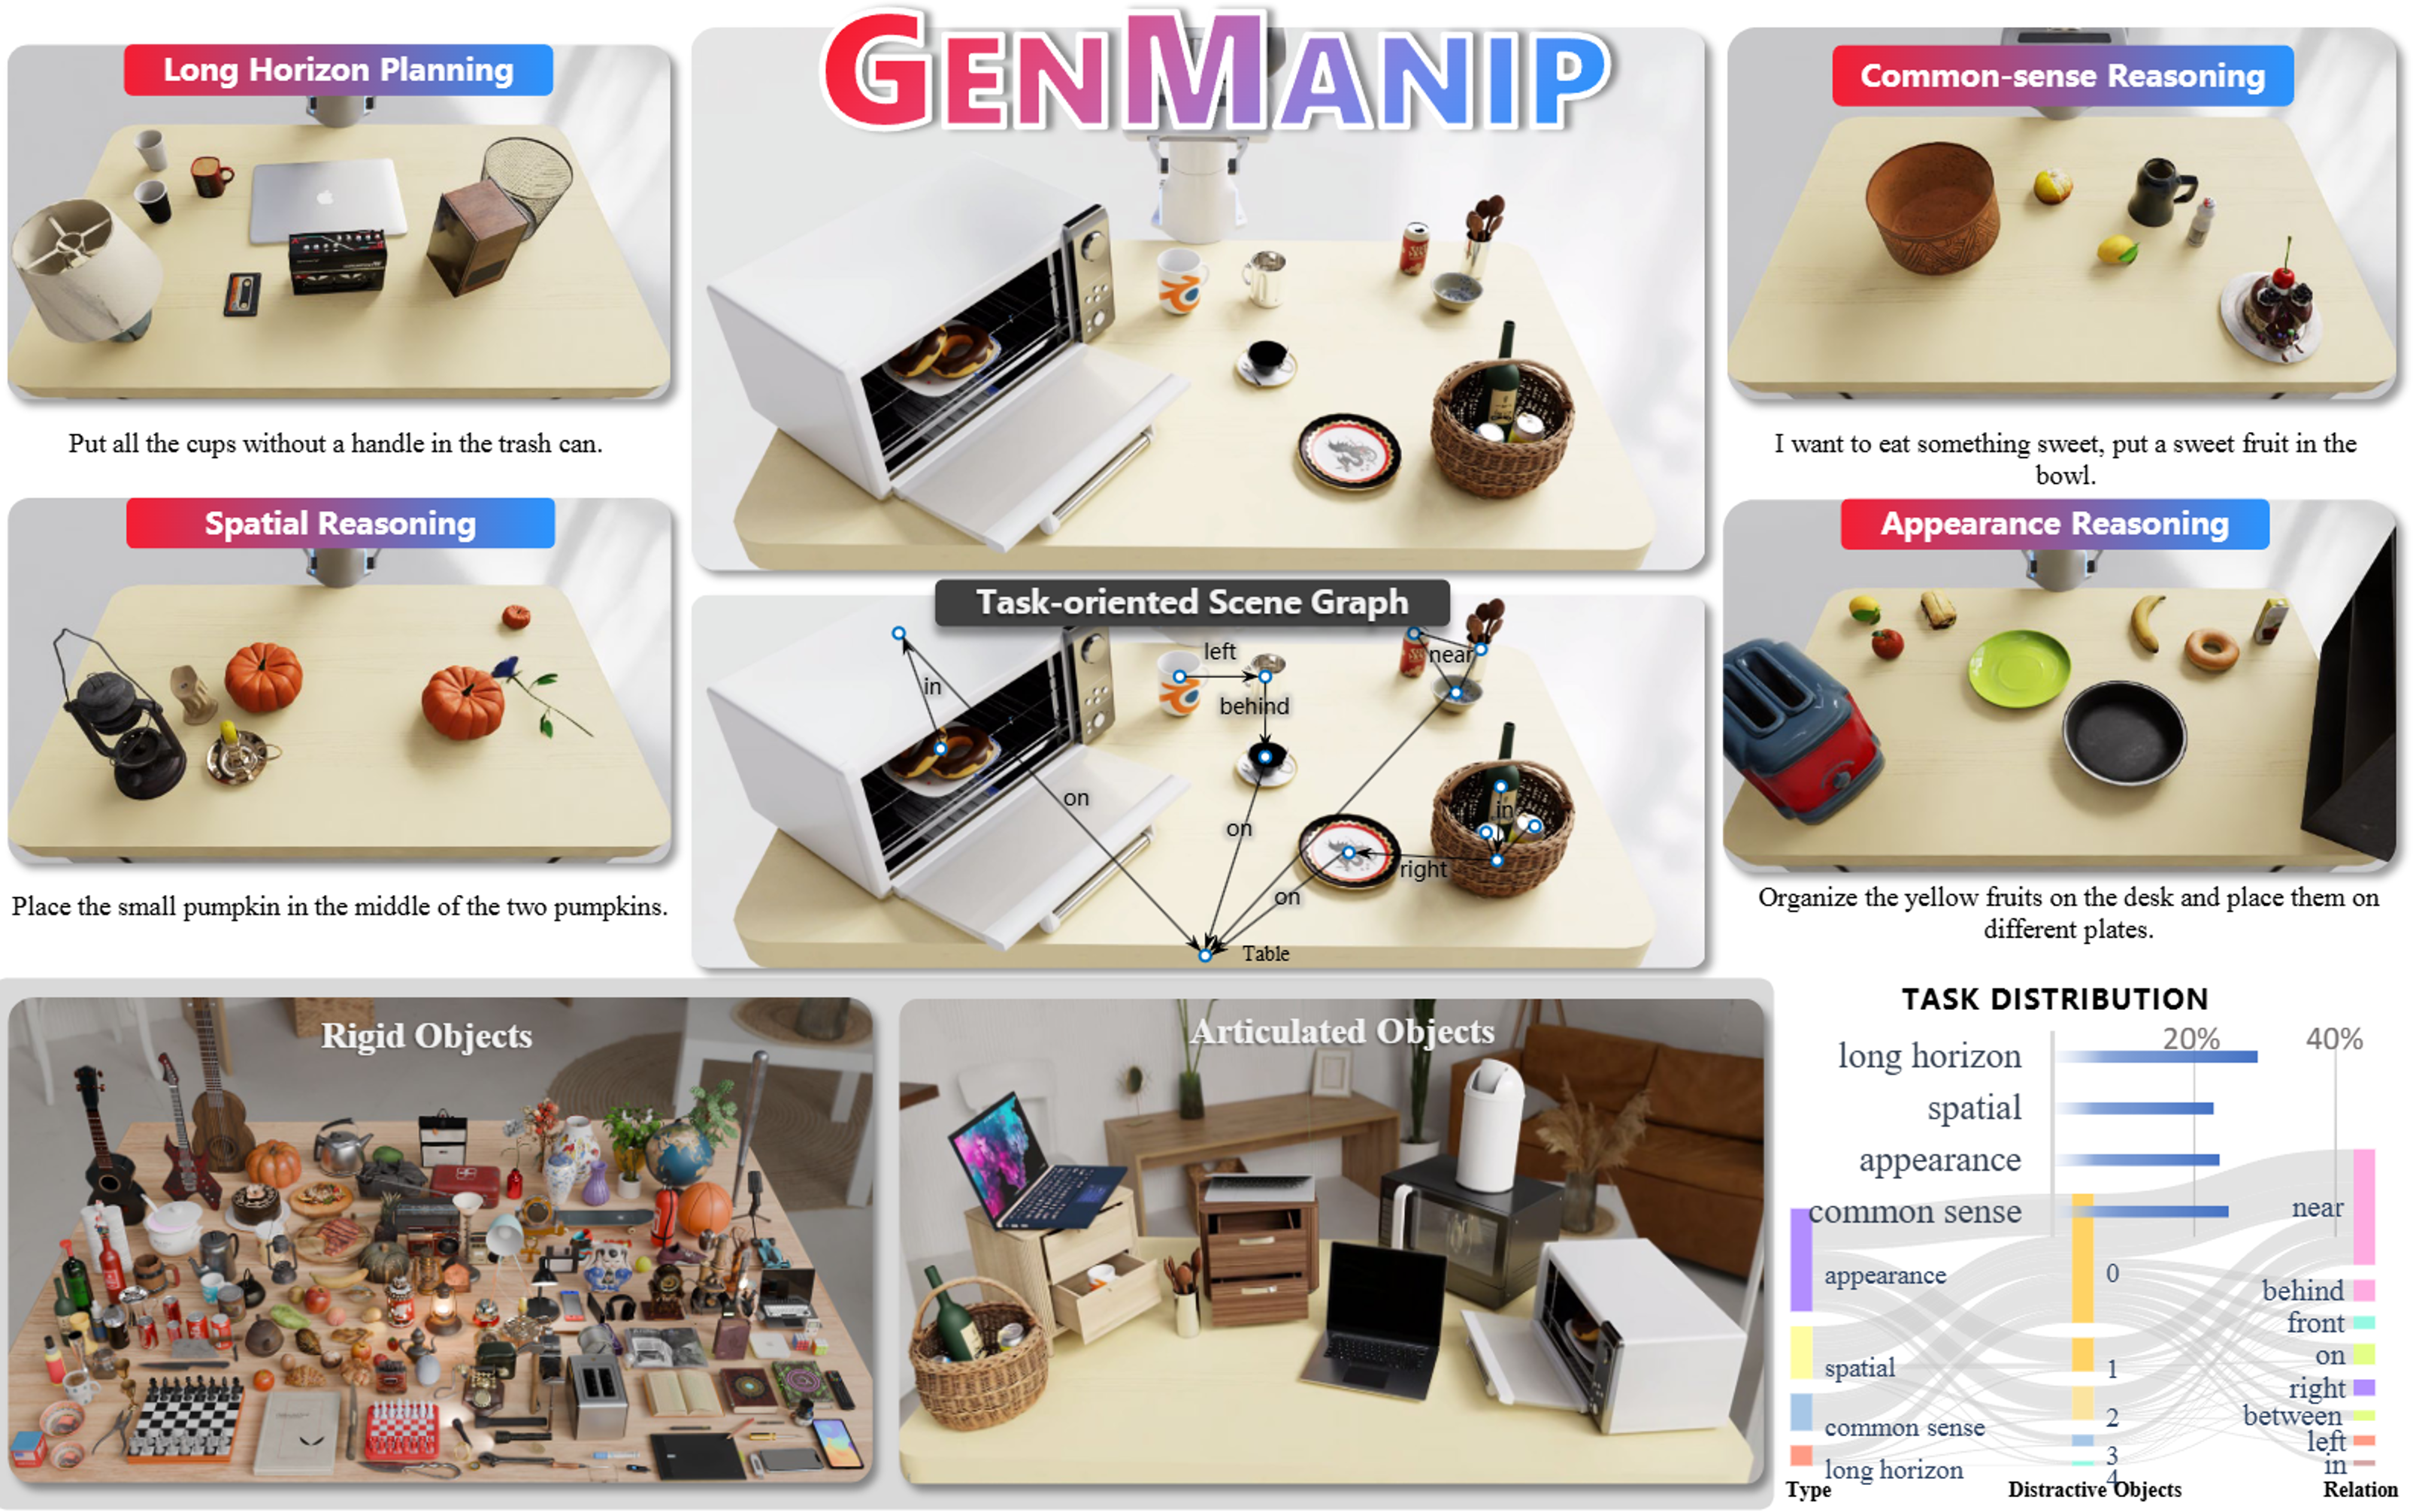
--- ## ๐Ÿง  Overview **GenManip** is a large-scale simulation and evaluation platform for **generalist robotic manipulation policies** under diverse and realistic **instruction-following scenarios**. Built on [NVIDIA Isaac Sim](https://developer.nvidia.com/isaac-sim), **GenManip** enables: - ๐Ÿง  **LLM-driven task generation** via a novel **Task-oriented Scene Graph (ToSG)** - ๐Ÿ”ฌ **200 curated evaluation scenarios** for both modular and end-to-end policy benchmarking - ๐Ÿงฑ A scalable asset pool with **10,000+ rigid** and **100+ articulated** objects with multimodal annotations - ๐Ÿงญ Evaluation of **spatial**, **appearance**, **commonsense**, and **long-horizon reasoning** abilities --- ## ๐Ÿš€ Recent Highlights ### ๐Ÿ”น Oct 2025 โ€” Data & Evaluation Release The **data synthesis pipeline** and **evaluation toolkit** for generalizable pick-and-place tasks are now available. ### ๐Ÿ”น Aug 2025 โ€” IROS 2025 Challenge Integration GenManip serves as the **core simulation backbone** for the **IROS 2025 Challenge: Vision-Language Manipulation in Open Tabletop Environments**. - Generated **55K+ generalizable pick-and-place tasks** across ~14K objects using the ALOHA platform - Released **10 expert-designed post-training tasks** for dual-arm manipulation - Provided diverse **pre-training data** with randomized objects, scenes, and language instructions to promote **cross-domain generalization** ๐Ÿ“Œ **Challenge Registration:** [https://eval.ai/web/challenges/challenge-page/2626/overview](https://eval.ai/web/challenges/challenge-page/2626/overview)

IROS 2025 Teaser

--- ## ๐Ÿ“‚ Dataset Access | Type | Description | Link | |------|--------------|------| | **Pre-training Data** | Dual-arm generalizable pick-and-place (55K+ samples) | [Hugging Face](https://huggingface.co/datasets/InternRobotics/IROS-2025-Challenge-Manip/tree/main) | | **Post-training Data** | Dual-arm manipulation, 10 benchmark tasks | [Hugging Face](https://huggingface.co/datasets/InternRobotics/IROS-2025-Challenge-Manip/tree/main) | **Additional Resources** - The **GenManip Benchmark** will be merged into [InternManip](https://github.com/InternRobotics/InternManip) - Datasets are also included in **[InternData-M1](https://huggingface.co/datasets/InternRobotics/InternData-M1)** โ€” a large-scale embodied robotics dataset with ~250K demonstrations and rich annotations (2D/3D boxes, trajectories, grasps, masks) - Conversion to **LeRobot** format is ongoing; all data has been generated and will be fully available soon - Scaling data for **long-horizon, multi-stage manipulation** is in progress ๐Ÿš€ --- ## โœจ Key Features | Feature | Description | | -------- | ------------ | | ๐ŸŽฏ **ToSG-based Task Synthesis** | Graph-based semantic representation for generating compositional tasks | | ๐Ÿ–ผ๏ธ **Photorealistic Simulation** | RTX ray-traced rendering with physically accurate dynamics | | ๐Ÿ“Š **Benchmark Suite** | 200+ diverse tasks with human-in-the-loop annotation refinement | | ๐Ÿงช **Evaluation Toolkit** | Supports SR, SPL, ablation studies, and generalization diagnostics | --- ## ๐Ÿงฉ TODO List - [x] Website, documentation, and leaderboard - [x] Code release for task synthesis, rendering, and evaluation - [ ] Full GenManip asset pack (10K+ objects) - [ ] Baseline model implementations (ACT, Seer, InternVLA-M1, etc.) - [ ] Objaverse scaling pipeline --- ## ๐Ÿ“š Citation If you find our work useful, please cite: ```bibtex @inproceedings{gao2025genmanip, title={GenManip: LLM-driven Simulation for Generalizable Instruction-Following Manipulation}, author={Gao, Ning and Chen, Yilun and Yang, Shuai and Chen, Xinyi and Tian, Yang and Li, Hao and Huang, Haifeng and Wang, Hanqing and Wang, Tai and Pang, Jiangmiao}, booktitle={CVPR}, year={2025} }