
[](https://travis-ci.com/Jean-Romain/lidRplugins)
[](https://codecov.io/gh/Jean-Romain/lidRplugins?branch=master)

This package contains functions and algorithms to extend the [lidR](https://github.com/r-lidar/lidR) package (versions >= 4.0.0). These functions or algorithms are not yet or will not be included in the `lidR` package either because they are:
- :microscope: **Experimental** and not supported by a peer-reviewed and accessible publications.
- :zap: **Non suitable for `lidR`** usually because they are not sufficiently efficient.
- :warning: **Not tested enought** and I'm not sure they are sufficiently robust.
- :octocat: **Require extra packages** available on github but not on CRAN
This package will NOT be submitted on CRAN and must be installed from github. It depends on `lidR (>= 4.0.0)` and should be seen as a laboratory with more or less interesting content inside.
## Features
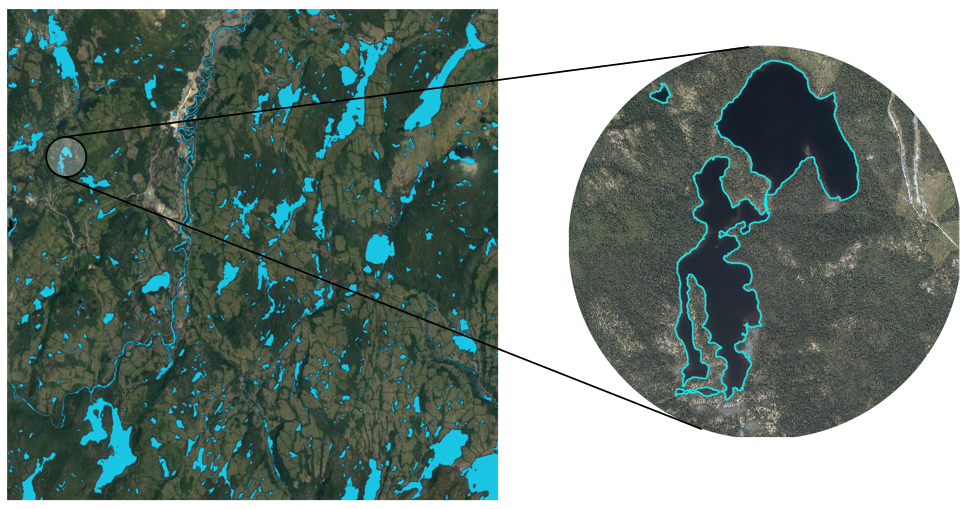
### Lake delineation :microscope:
Lake delineation from point cloud using `delineate_lakes()`
 ### Powerline segmentation :microscope: :warning:
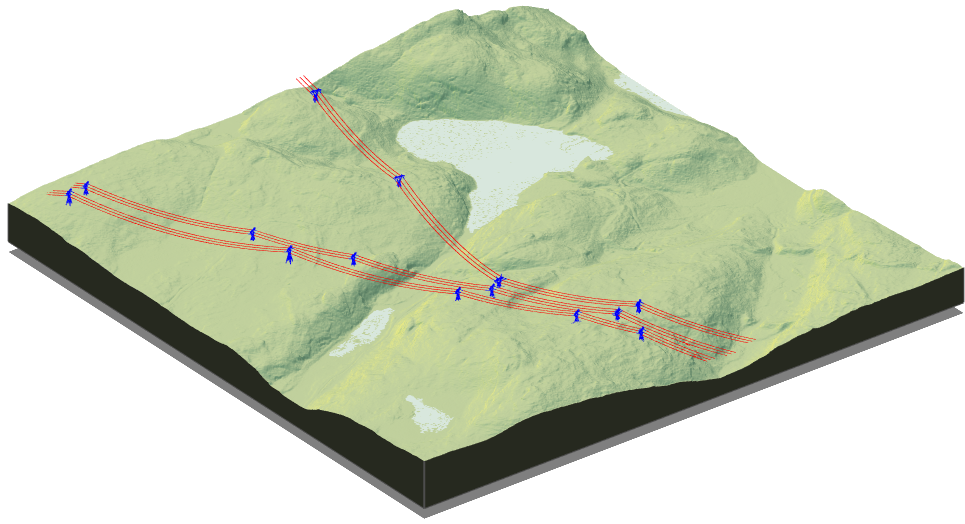
Powerline segmentation from point cloud using `find_transmissiontowers()`, `classify_transmissiontowers()`, `classify_wires()`, `track_wires()`
 ### Various tree detection/segmentation from peer-reviewed papers :zap:
- `ptree()`: Vega, C., Hamrouni, a., El Mokhtari, S., Morel, J., Bock, J., Renaud, J.-P., … Durrieu, S. (2014). PTrees: A point-based approach to forest tree extraction from lidar data. International Journal of Applied Earth Observation and Geoinformation, 33, 98–108. https://doi.org/10.1016/j.jag.2014.05.001
- `hamraz2016()`: Hamraz, H., Contreras, M. A., & Zhang, J. (2016). A robust approach for tree segmentation in deciduous forests using small-footprint airborne LiDAR data. International Journal of Applied Earth Observation and Geoinformation, 52, 532–541. https://doi.org/10.1016/j.cageo.2017.02.017
- `LayerStacking()`: Ayrey, E., Fraver, S., Kershaw, J. A., Kenefic, L. S., Hayes, D., Weiskittel, A. R., & Roth, B. E. (2017). Layer Stacking: A Novel Algorithm for Individual Forest Tree Segmentation from LiDAR Point Clouds. Canadian Journal of Remote Sensing, 43(1), 16–27. https://doi.org/10.1080/07038992.2017.1252907
- `multichm()`: Eysn, L., Hollaus, M., Lindberg, E., Berger, F., Monnet, J. M., Dalponte, M., … Pfeifer, N. (2015). A benchmark of lidar-based single tree detection methods using heterogeneous forest data from the Alpine Space. Forests, 6(5), 1721–1747. https://doi.org/10.3390/f6051721
### Parameter free tree detection :microscope:
`lmfauto()` is a fast algorithm for individual tree detection with 0 parameters designed to process thousands of square kilometres without supervision.
## Installation
```r
remotes::install_github("Jean-Romain/lidRplugins")
```
To install the package from github make sure you have a working development environment.
* **Windows**: Install [Rtools.exe](https://cran.r-project.org/bin/windows/Rtools/).
* **Mac**: Install `Xcode` from the Mac App Store.
* **Linux**: Install the R development package, usually called `r-devel` or `r-base-dev`