AI agents build real hardware. Gates prove it.
A method, a Claude Code skill and a tested project skeleton for letting agents design PCBs, CAD and firmware
without losing work, wrecking the PC, or burning the budget silently.
---
## What this is
> **A starting point, not an all-in-one product.** Pull it, run the examples, then shape it into the harness
> YOUR project needs: your boards, your plant models, your scenarios, your gates. The templates are tested
> skeletons and a method, distilled from a larger private workflow that cannot be published; expect to add
> checks, models and tools of your own, and to replace the examples entirely.
> **Before you order anything real:** work through the harness, open the CAD and the board yourself, ask the agent
> *why* for every part and every number, and have it run an adversarial review pass over the schematic, the
> layout, the BOM, the CAD and the firmware (a fresh agent with the files, not the conclusions). Green gates mean
> the checks that exist passed; they are not a substitute for an engineer looking. Then order with confidence.
Hardware described by code. Boards are Python scripts that one shared pipeline turns into a KiCad schematic, a routed
board, a fab set and a STEP model. Enclosures and assemblies are CadQuery builders that export geometry with mass and
centre of gravity. Firmware keeps its control core free of vendor headers, so the same code that runs on the target
runs on the PC against a digital twin.
Every claim is checked by a gate that runs on the machine: ERC and DRC at KiCad's default severities, a live
distributor check of every purchased part, a no-shortcut audit that fails on stubs and admitted guesses, a CI matrix
with regression compare, host test suites, twin scenarios over seed sweeps. Agents do the engineering inside that cage.
`main` moves only when the whole matrix is green.
It comes from a private multi-board hardware project where agents designed the PCBs, the CAD and the firmware under
these gates for weeks. Everything project-specific has been removed. What is left is the method, the scripts, and the
templates, all of them run and tested on the way out.
## Why it is not a gimmick
Agents that "design a PCB" usually produce a picture of a schematic. This produces files you can order from, and it
refuses to produce them when anything is wrong.
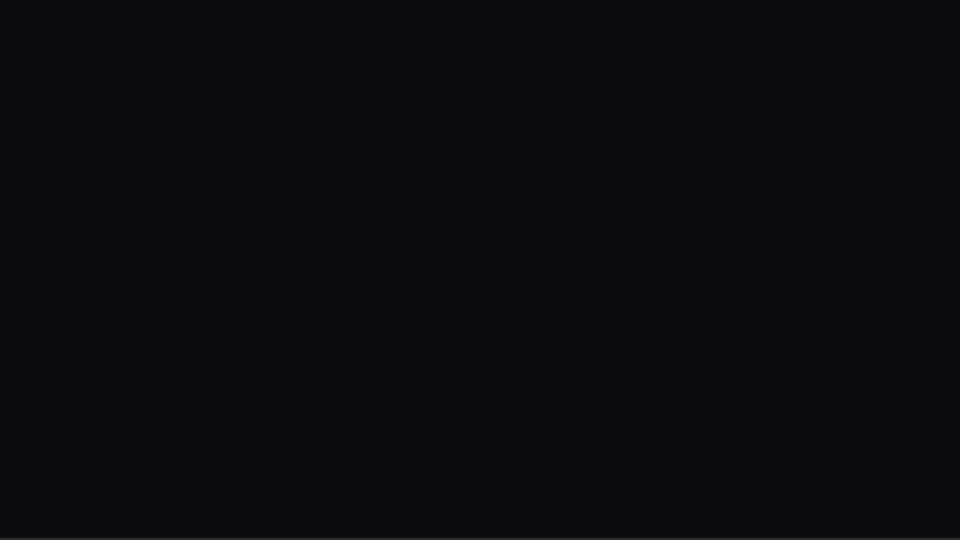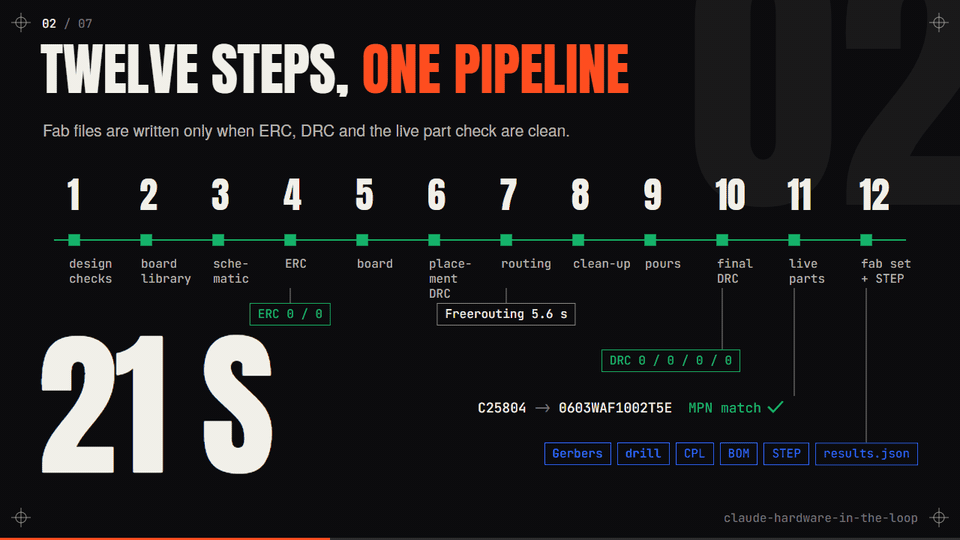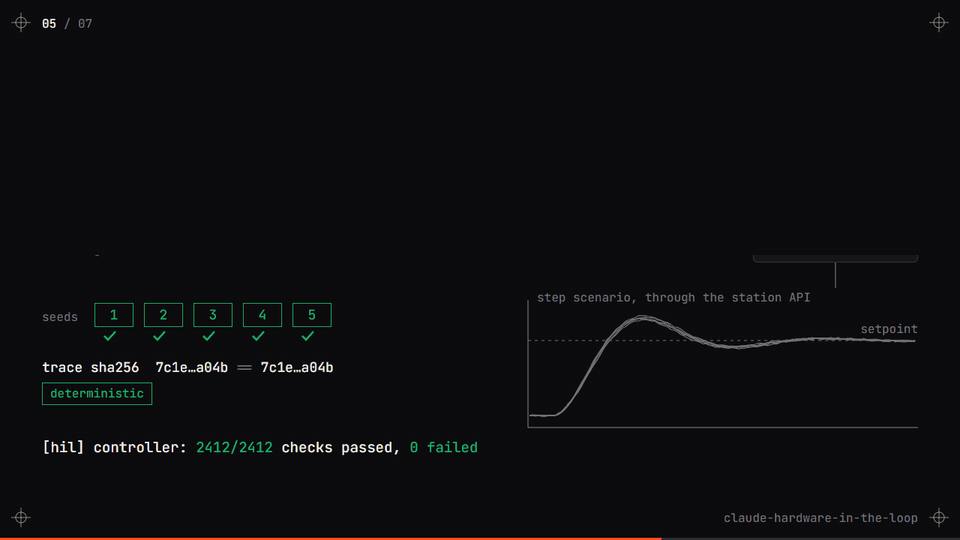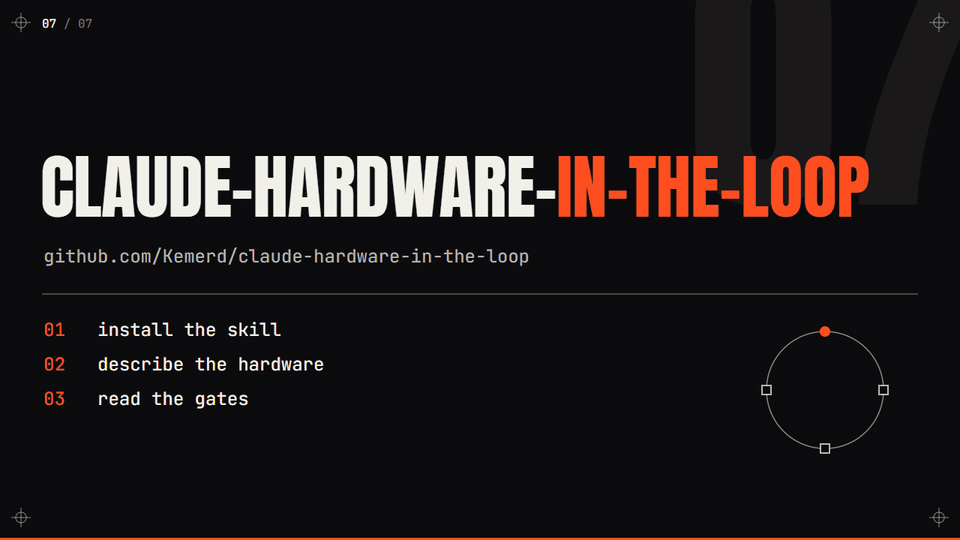
- **A board that passes is a board you can order.** The pipeline writes fab files only when ERC is 0 / 0, the final DRC
is 0 violations / 0 unconnected / 0 parity items at KiCad's default severities, and every purchased line resolves
live to the MPN the schematic names. The example board runs all twelve steps in 21 seconds.
- **The checks caught real mistakes.** A distributor code that looked right resolved to an 0603 part instead of the
0402 it was assumed to be; the live check failed the build and the board got the right part. Forty such
lessons, each one an afternoon, are in [docs/LESSONS.md](docs/LESSONS.md).
- **Nothing is hand-copied.** Mass, CG, inertia and joints flow from the CAD export into the twin, the simulators and
the viewer. A CAD change regenerates every tier's inputs.
- **Agents cannot lower the bar.** DRC severities are never demoted; a relaxed rule needs a cited basis; a test that
exits 0 without its summary line is a failure; an empty suite is a failure; the audit fails on new stubs, canned
success and admitted guesses.
- **The cost is stated up front.** One swarm day burned 4-5 million tokens. The skill says so before it does anything
and recommends the cheaper mode. See [Two modes, one honest cost](#two-modes-one-honest-cost).
## What you can do with it
Anything you can describe in code and prove with a gate. In practice:
| You want | The method gives you |
|---|---|
| A board, from a breakout to a dense multi-layer | a generator, the shared pipeline, Freerouting, ERC / DRC gates, live part verification, a JLCPCB fab set, STEP and a fit JSON for the CAD |
| An enclosure or an assembly | a CadQuery builder with plug-in parts, interference and keep-out checks, a mass / CG table on every change, decision renders with clashes in red |
| Firmware you can trust before the board exists | out-of-tree builds, host suites with thousands of checks, a native twin that runs the real control code through the real station protocol, seed sweeps, determinism hashes |
| A system of several boards and parts | one pipeline for every board, one source of truth for every tier, a bench register for the constants only a bench can settle |
| Agents working while you sleep | detached night chains with a slot and a timeout per step, watchers that wake the agent on failure, morning questions with the default already taken |
| A way to look at the result | a three.js viewer with section planes, x-ray, live mass / CG, PCB and harness overlays, and review notes the next agent reads |
## How it works
### Boards: a board is a Python script
The script declares data: parts with their datasheet pin tables, nets, outline, holes, placement, net classes, pours.
One pipeline does the rest and stops at the first thing that is wrong. Nobody edits a `.kicad_pcb` by hand; the
generator is the design, and a fix to the pipeline fixes every board.
Same inputs, same files: hashed string order, uuid5 schematic UUIDs, seeded board KIIDs, and a frozen route (the
router itself is not repeatable) give a byte-identical `.kicad_pcb` across runs. Details, flags and the hard lessons
are in [docs/PCB.md](docs/PCB.md).
### CAD, firmware and simulation: one source of truth
A CadQuery builder exports STEP, STL and a `parts.json` with mass and CG per part. The native twin, the Isaac Sim and
Unreal tiers and the web viewer all read those exports; the PCB pipeline's STEP and fit JSON flow back into the
builder. Firmware's control core is compiled twice from the same sources: once for the target, once for the twin.
[docs/CAD.md](docs/CAD.md) has the builder and plug-in contract, [docs/FIRMWARE.md](docs/FIRMWARE.md) the host suites
and the twin rules, [docs/SIM.md](docs/SIM.md) the C twin and its Unreal and Isaac Sim hosts.
### The cage: agents inside, everything else outside
Agents work in git worktrees and land every lane on `dev`, red gates included, so nothing is lost and conflicts show
up the same day. `main` is promoted only when the CI report for that exact commit is green with zero regressions.
Heavy jobs take a slot that gates RAM and CPU; long chains run detached with a watcher that wakes the agent on success
and on failure. Uncommitted work is snapshotted every twenty minutes. A usage tripwire makes every agent stop, push,
and write a resume document before the limit cuts it off.
The whole method on one page: [docs/METHOD.md](docs/METHOD.md).
### Two modes, one honest cost
> Running this method as a **swarm** (a lead agent plus parallel lane agents) is expensive. On the project it comes
> from, **one swarm day burned 4-5 million tokens**, and most of that was not the work: it was waking lane agents that
> each carried **300-800k tokens of context** to read a message or check a log. The default is now a **chain**: one long
> lead session (Fable or Opus) hands bounded cards to one or two subagents at a time (Opus or Sonnet) and checks each report,
> so logs and trial and error stay out of the lead's context. The skill also offers a single session with no subagents,
> and the swarm. Choose the swarm on purpose.
Roles, waves, briefs, skeptics and the integrator are in [docs/SWARM.md](docs/SWARM.md).
## Quick start
1. Install the skill (Claude Code reads skills from a project's `.claude/skills/` or your user skills folder):
```
git clone https://github.com/Kemerd/claude-hardware-in-the-loop
# per project:
mkdir -p /.claude/skills && cp -r claude-hardware-in-the-loop/skills/hardware-in-the-loop /.claude/skills/
# or for every project: copy the same folder into the skills folder of your Claude Code user config
```
2. In your project, ask Claude Code: *"set up a hardware project with the hardware-in-the-loop method"*. The skill
states the token cost, asks which mode you want, runs the onboarding interview (goals, budget, quantities, printed
material, fastening, enclosure sealing, fab vendor, MCU, simulation tiers and GPU, machine limits), then writes the
skeleton with `scripts/scaffold.py`, sets up `main` and `dev`, and verifies or installs the tools.
3. Or do it by hand:
```
python -I skills/hardware-in-the-loop/scripts/scaffold.py --answers answers.json --dest --with-examples
pwsh -File skills/hardware-in-the-loop/scripts/setup_tools.ps1 -ToolsRoot D:\hiltools -VerifyOnly
cd && pwsh -File windows/ci.ps1
```
The answers format is in `skills/hardware-in-the-loop/references/interview.md`. Tools, pinned versions and hashes
are in [docs/TOOLS.md](docs/TOOLS.md).
4. Make it yours: swap the example board, enclosure, firmware core and twin plant for your project's, add the checks
your domain needs, and keep reviewing the CAD and the boards with the agent (ask why, ask for an adversarial pass)
before anything goes to a fab.
5. Stay current without giving up your changes. The skeleton is a starting point you are meant to rewrite, so it
carries its own updater. See [Update checks](#update-checks-what-they-do-and-how-to-turn-them-off) below.
## Update checks: what they do and how to turn them off
A scaffolded project checks this repository for a newer version when a Claude Code session starts. It is there so
that improvements (a better board-layout prompt, a faster viewer, a fixed tool) reach projects that long ago
customised every template. Leaving it on is a good idea: the tooling here is actively improved, by the maintainer and
by community pull requests, and a check costs you nothing.
What it does, in full:
- **The check** (`tools/hil_update.py check`, run by a `SessionStart` hook) reads two small text files,
`VERSION` and `CHANGELOG.md`, from `raw.githubusercontent.com/Kemerd/claude-hardware-in-the-loop/main/`. It sends
nothing about you or your project, downloads no code, runs nothing it fetched, and happens at most once a day. If
you are offline it says nothing.
- **If a newer version exists,** the agent tells you what is new in plain words and asks whether to pull it in. No
answer, or no, means nothing changes (and `ignore` stops that version being announced again).
- **Only after you say yes** does `plan` download the repository's `main` archive from GitHub into the project's
`.tmp/` and compare it with your files. Nothing is installed or executed from it. `apply` copies in new template
files and refreshes files you never touched. A file you customised is **never overwritten**: you get a diff and the
agent merges it with you. The whole update lands as one git commit on its own branch, so you can read it and revert it.
- The updater is one readable Python file with only the standard library: `tools/hil_update.py`. Read it before you trust it.
To turn it off, any one of these:
- set the environment variable `HIL_NO_UPDATE_CHECK=1` (the check exits at once, no network);
- delete the `SessionStart` block from `.claude/settings.local.json`;
- delete `tools/hil_update.py` and `harness/TEMPLATE_VERSION.json`.
You can still update by hand at any time with `python -I tools/hil_update.py check --force`.
## What is in here
```
README.md, LICENSE, NOTICE
docs/
METHOD.md the whole method: storage tiers, branching (dev / main), gates, machine safety, handoffs, overnight
PCB.md generator-first boards: the 12 pipeline steps, determinism, Freerouting, hard lessons, protection rules
CAD.md CadQuery builders, the plug-in contract, mass / CG tables, decision images, material decisions
FIRMWARE.md out-of-tree builds, host test suites, firmware in the loop against a native twin, bench rigs
SIM.md the C digital twin, its models and scenarios, the Unreal and Isaac Sim hosts, CUDA Monte Carlo
SWARM.md the chain (default), lead / subagent models, waves, briefs, skeptics, integrator, locks, handoffs, single-session mode
TOOLS.md what to install, pinned versions and hashes, where it lives, home-directory isolation
LESSONS.md 40 lessons: one sentence of symptom, one of rule
skills/hardware-in-the-loop/
SKILL.md the skill: cost warning, mode choice, interview, scaffold, tools, branches, harness, both modes
references/ interview + answers.json schema, plan templates (swarm and single session), brief, structured
report, resume document, overnight chain + morning questions, wave checklist, agent-rules guide,
twin-setup (native / Unreal / Isaac / CUDA), firmware-host (C first; ESP32, ESP32-P4, ARM),
research-citations (how to find, verify and cite sources; a verified reading list)
scripts/ scaffold.py (writes the skeleton), setup_tools.ps1 / setup_tools.sh (pinned toolchain),
check_twin_tools.ps1 (finds CMake, compilers, Unreal >= 5.8.4, Isaac Sim, CUDA)
templates/ the project skeleton (see below)
(the three.js CAD viewer is a template too: templates/tools/cad_viewer, copied by the scaffold)
media/out/ the README graphics and the explainer video
```
The project skeleton (skills/hardware-in-the-loop/templates/), file by file
| Path | What it is | State |
|---|---|---|
| `README.md`, `README_AGENT.md`, `PROJECT_STRUCTURE.md`, `REQUIREMENTS.md`, `CODING_RULES.md` | root documents, filled from the interview | ready |
| `DECISIONS.md`, `QUESTIONS.md`, `CITATION.md` | numbered owner decisions (never edited, superseded by new rows); open questions with the recommended default and a deadline; every model's verified source (16 rows, checked against Crossref / arXiv / publishers) | ready |
| `sim/twin/` | the C digital twin: rigid body + contact, brushed DC, PMSM + FOC drive, geared joint, thermal network, battery, IMU / baro / range / NTC / ADC models; the example actuator rig running the firmware core; the `hil_twin_api` C ABI; the scenario runner; 9 scenario rows; CUDA Monte Carlo with a CPU reference; CAD-to-twin and ctypes tools | implemented, tested (165 host checks, 20 scenario runs, determinism, ABI from Python) |
| `firmware/core/` | example portable control core in C11 (homing, cascaded joint control, winding-temperature observer, derating, faults) behind a function-pointer HAL, plus a CRC-framed link codec | implemented, tested |
| `sim/unreal/` | UE 5.8 plugin (Kinematic and ChaosTorque coupling, scenario player, console commands) and a host project | built with UE 5.8.4, automation tests pass headless (trace hash equals the native runner's); ChaosTorque compiled, its acceptance run is the project's first Unreal step |
| `sim/isaac/` | fail-closed GPU gate, USD rig authored from the twin's properties, the PhysX harness | gate and USD authoring tested on CPU; the harness is written against the Isaac Sim 6.2 API and not run here |
| `windows/ci/twin.ps1`, `tools/check_citations.py`, `tools/archive_tmp.py` | CI group `twin`; the citation gate (suite `citations`); the hash-checked `.tmp` to `.archive` mover | implemented, tested |
| `gitignore.template`, `gitattributes.template` | become `.gitignore` / `.gitattributes` (scratch, harness, KiCad per-user files, fab files as binary) | ready |
| `windows/ci.ps1`, `windows/ci/ci_common.psm1`, `windows/ci/audit.ps1`, `windows/ci/pcb.ps1` | CI matrix: group registry, parallel pwsh processes, `ci_report.json`, `-Compare -FailOn regressions`; groups `audit` and `pcb` | implemented, tested |
| `tools/audit_placeholders.py` + baseline / waivers JSON | no-shortcut audit: open-work markers, admitted guesses, Python stubs, hardware functions returning canned success, CAD stand-in names and bare primitives, default credentials; tracked baseline, signed waivers, `--changed-since` | implemented, tested |
| `tools/check_portability.py` | interpreter line, UTF-8 console, path anchoring, no user-profile paths | implemented, tested |
| `pcb/tools/kicad_env.py`, `board_pipeline.py`, `distributor_verify.py` | generator-first KiCad 10 pipeline: schematic from data, own footprint library, ERC, placement DRC, Freerouting, clean-up, pours, final DRC with parity, JLCPCB fab set, live LCSC verification, STEP, fit JSON, results JSON with SHA-256s | implemented, tested end to end |
| `pcb/tools/route_board.py`, `pf_route.py`, `astar.c` | negotiated-congestion router for the dense boards Freerouting leaves open: reads pads, nets, rules, zones and keep-outs from the board, routes around copper already there, reports what stays open | implemented, tested on real boards stripped of their copper |
| `pcb/example_board/gen_example_board.py` | a real 2-layer 3.3 V LDO breakout (TVS, PTC with sense line, redundant power / ground pins, every part behind the TVS rated above its clamp) | runs green in about 15 s |
| `pcb/DESIGN_STANDARDS.md` | rule book skeleton with rule ids and a project decision table | ready (a machine checker for the rule ids is roadmap) |
| `cad/cad_plugins.py`, `cad/render.py`, `cad/mass_cg_table.py` | plug-in loader, decision renders (clash in red, dimensions), weight-and-balance table | implemented, tested |
| `cad/examples/enclosure/` | sealed enclosure builder + gasket and gland-access plug-ins | runs, checks pass |
| `firmware/host_tests/hil_check.h` | header-only check library with a parseable summary line, plus its self-test | implemented, tested (C99 and C++11) |
| `harness/swarm/locks/slot.sh` | machine gate: RAM reserve, CPU cap, start gap, fairness queue, starvation guard, per-kind capacity, stale reclaim | implemented, tested |
| `harness/swarm/detach.sh`, `watch.sh` | detached chains with done / FAILED markers; watcher for success, failure, hang, crash | implemented, tested |
| `harness/swarm/merge_lock.sh`, `merge_to_dev.sh`, `promote_dev.sh`, `wip_backup.sh` | dev / main model: every lane lands on dev, promotion only when green with 0 regressions; WIP snapshots without force-push | implemented, tested on a local remote |
| `harness/swarm/usage_statusline.py`, `handoff_hook.sh`, `handoff_hook.json` | usage tripwire and the stop-and-write-a-resume-document hook | implemented, tested |
| `harness/swarm/AGENT_RULES.md`, `claude/settings.local.json.example` | binding rules for agents; hook and status-line wiring | ready |
| `docs/bench/BENCH_REGISTER.md`, `docs/data/README.md` | bench parameter register, tracked results index | ready |
### The viewer (`tools/cad_viewer/` in a scaffolded project)
The scaffold copies it from `templates/tools/cad_viewer/` with `windows/cad_viewer.ps1`; the interview offers it. `pack_mesh.py` packs a builder export into a compact payload, `serve.py` serves it locally with a review-notes API
(notes pinned on parts land in a JSONL file the next agent reads), `index.html` is a single-page three.js viewer:
section planes with a stepper (0.1 mm, Shift 1 mm, Alt 0.01 mm), x-ray, PCB X-ray (boards solid with their KiCad render), Wire X-ray, parts list by mass, a live mass / CG panel of the visible parts with a CG marker, a materials
panel, a PCB overlay from `pcb_to_json.py` (outline, courtyards per side, mounting holes), and a harness overlay (wire
runs as tubes with zip-tie points and run lengths). Project facts live in one `viewer.config.json`; KiCad and Pillow are optional, a mesh-only build comes up without them. See the [viewer README](skills/hardware-in-the-loop/templates/tools/cad_viewer/README.md).
## Implemented vs roadmap
Nothing here is sold as done that is not. The right column is designed and written up, not built.
| Area | Implemented | Roadmap |
|---|---|---|
| Gates | CI matrix, audit, portability, ERC / DRC re-check, regression compare | a standards checker that implements the DESIGN_STANDARDS rule ids |
| PCB | full generator pipeline with Freerouting or the negotiated router, live part verification, fab set, STEP | BGA fan-out helpers, length matching, panelization |
| CAD | plug-in contract, renders, mass / CG tables, example builder | interference check with exact contact areas, STEP-based catalogue part import |
| Firmware | host check library, a C firmware core behind a HAL, the twin pattern, ESP32 / ESP32-P4 / ARM guidance | register-level device models and a lockstep RTOS shim for unmodified `main.c` (described in firmware-host.md) |
| Simulation | native C twin with models, scenarios, seeds, determinism, Monte Carlo (CPU + CUDA); Unreal plugin with hash parity; Isaac Sim harness | ChaosTorque and Isaac runs validated on a project's own rig; rendered sensor models (cameras, depth); bench-versus-twin comparison tooling |
| Viewer | parts, sections, notes, mass / CG, materials, PCB and harness overlays | copper layers, harness clearance and bend-radius checks, measurements, exploded view, build-to-build diff |
| Orchestration | slots, detached jobs, watchers, merge lock, dev / main, WIP backup, usage tripwire, templates for plans, briefs, reports, resume documents, overnight chains | |
## Licence
Source-available under the Hardware-in-the-Loop Attribution and Share-Alike Tooling License 1.0 (HIL-ASA-1.0), see
[LICENSE](LICENSE). It is **not** an OSI-approved open-source licence: it adds a restriction on selling the tooling
itself. Use it, commercially too, to design, build and sell your own boards, firmware and products on any terms you
like; all you owe is credit. Fork it, change it and share it for free, as long as the notice and the licence stay
intact. Selling the tooling itself, bundling it into a paid product, or running it as a paid service is allowed only if
that product's full source is published under HIL-ASA-1.0. The credit line to use (also in [NOTICE](NOTICE)):
```
Based on claude-hardware-in-the-loop by Kemerd (https://github.com/Kemerd/claude-hardware-in-the-loop)
```