VVS Ballers: RoboCupJunior Soccer
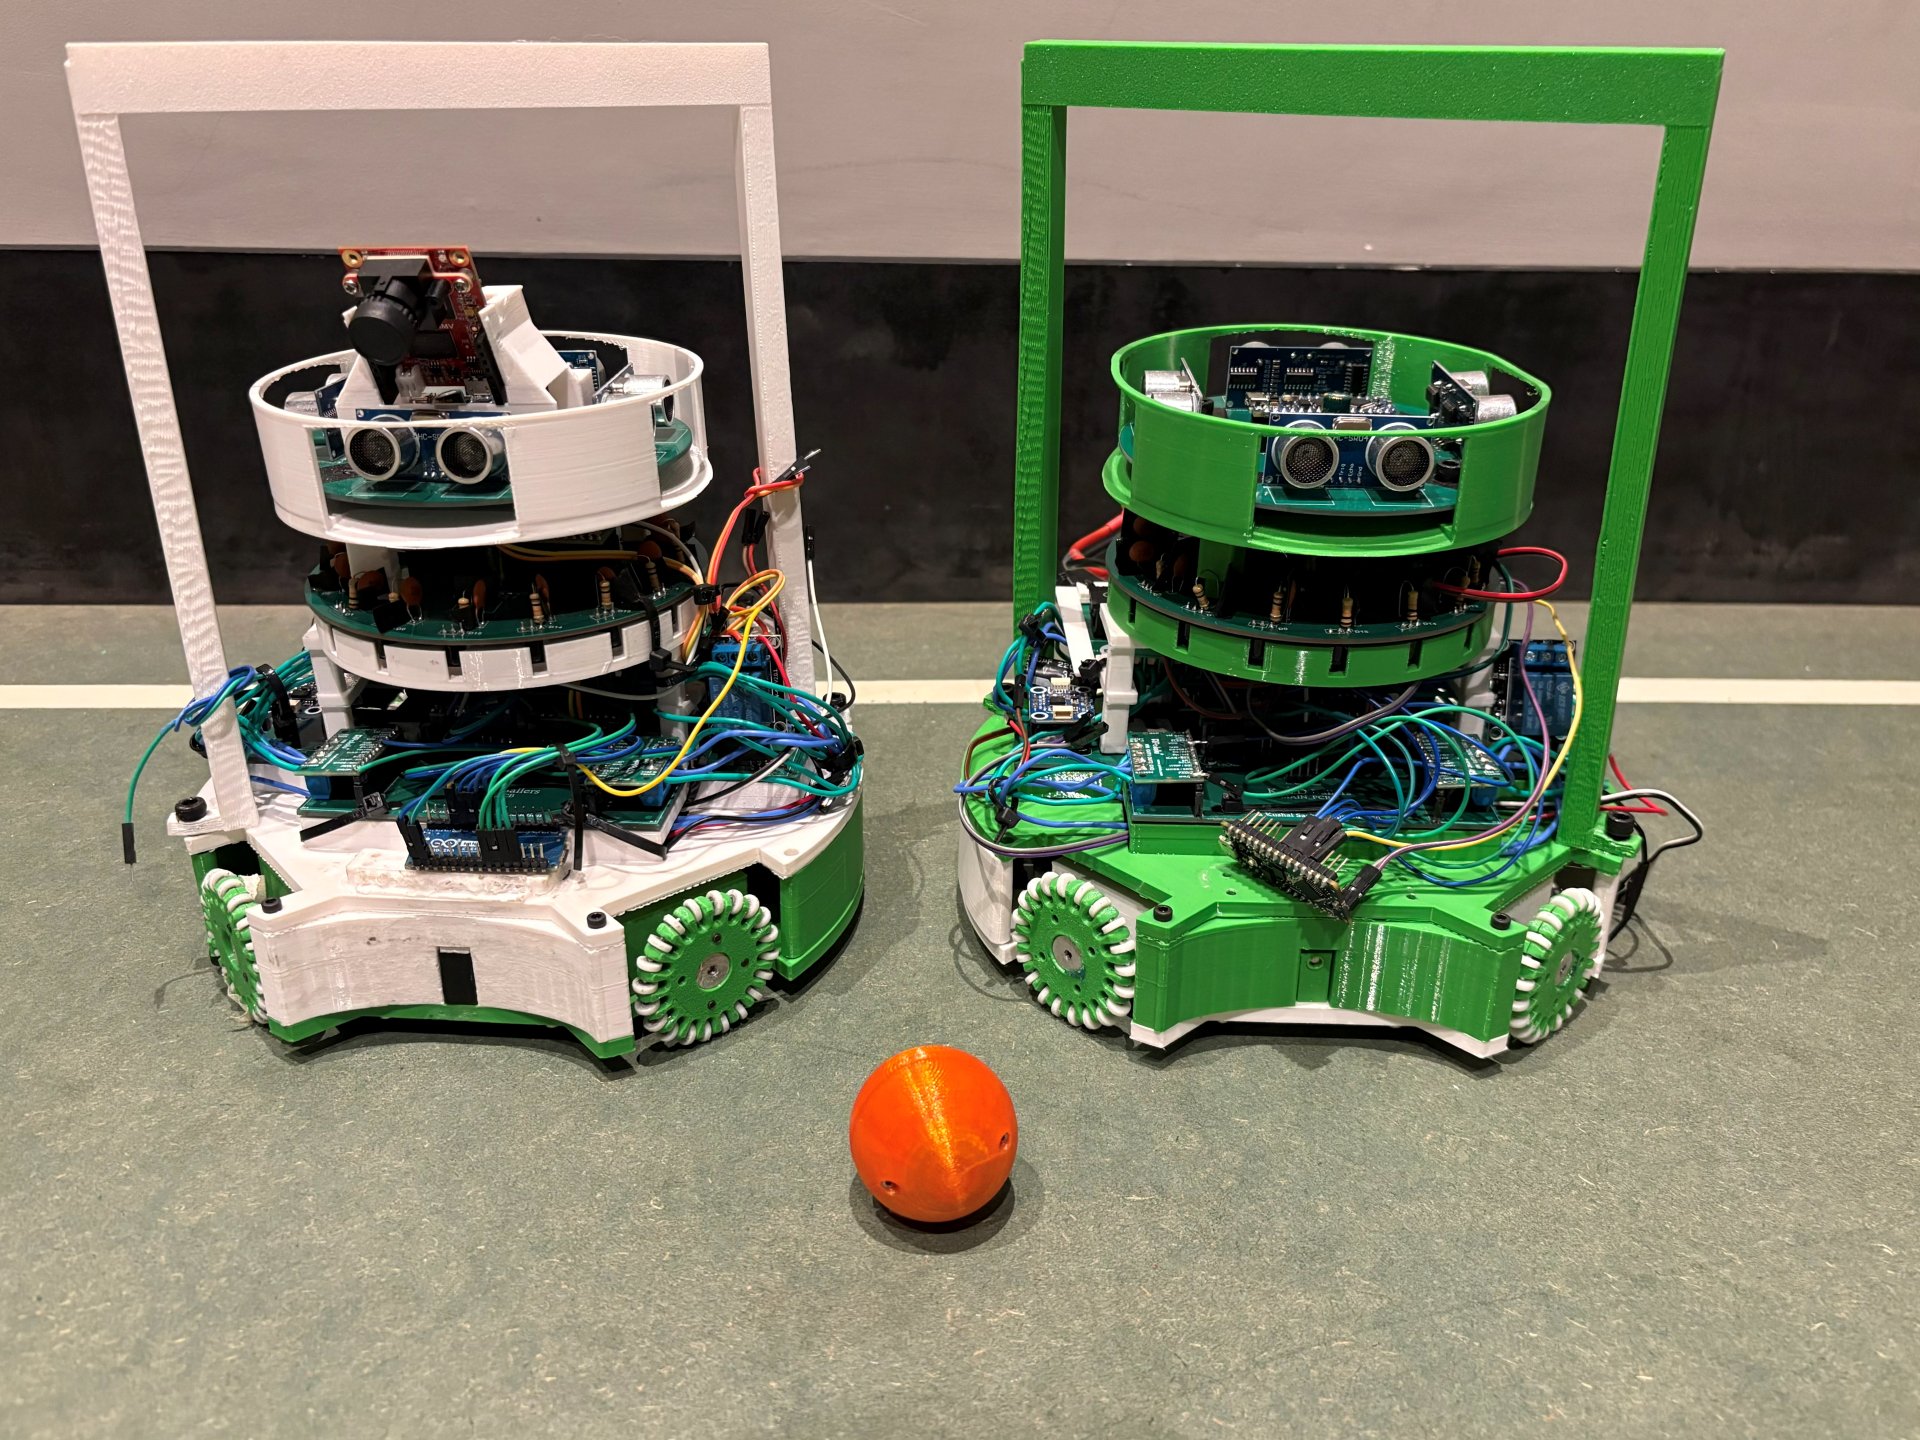
Autonomous RoboCupJunior Soccer robots by Team VVS Ballers, designed and iterated
across multiple seasons, from EV3 regional robots to a custom Teensy-based
international platform.
Firmware (C++) · multi-board electronics (KiCad) · mechanical design (Fusion 360).
---
## Results
- **RoboCup 2026, Incheon, South Korea (International): 9th place, RoboCupJunior Soccer (IR League).** Two self-built robots, designed, wired, and programmed by a team of two.
- **RoboCupJunior India, 2025-26 season**: came up through the Indian regional and national rounds to qualify for RoboCup 2026. The trophy and finals footage from the national event are in the [Nationals gallery](RoboCup%20Nationals%202025-26/Gallery).
## Press and media
- [Two Students, Two Self-Built Robots, And A 9th-Place Finish At The Robot "World Cup"](https://www.republicworld.com/sports/two-students-two-self-built-robots-and-a-ninth-place-finish-at-the-robot-world-cup-2026-07-14-132303) (Republic World, July 2026)
- [Team Instagram](https://www.instagram.com/vvs_ballers) - Robot builds, competition footage, and event coverage
---
## Seasons
| Season | What's inside |
|---|---|
| **[RoboCup Internationals 2025-26](RoboCup%20Internationals%202025-26/)** ⭐ *current* | Two autonomous Soccer-Infrared robots (attacker + defender): a Teensy 4.1 multi-board stack with an IR ball ring, line ring, ultrasonic, OpenMV goal camera, and 48 V solenoid kicker. Firmware + KiCad PCBs + Fusion CAD. |
| **[RoboCup Nationals 2025-26](RoboCup%20Nationals%202025-26/)** | Nationals build: EV3 robot program (HiTechnic IR seeker and compass), an Arduino relay-driven solenoid kicker, 3D-printed chassis parts, the season poster, and the trophy and finals gallery. |
| **[RoboCup Regionals 2025-26](RoboCup%20Regionals%202025-26/)** | EV3 holonomic robot (diamond omni drive, dual underside colour sensors, side IR distance, IR seeker, compass heading hold) + an Arduino ultrasonic-triggered kicker + printable parts + poster. |
| **[RoboCup 2024-25](RoboCup%202024-25/)** | Prior season: international Team Description Paper, posters, and earlier EV3 reference designs. |
> The **Internationals 2025-26** robots are the current flagship, and the rest of this
> page focuses on them. The full detail lives in that folder's
> **[detailed README](RoboCup%20Internationals%202025-26/README.md)** and a complete
> **[technical deep-dive](RoboCup%20Internationals%202025-26/Docs/HOW_IT_WORKS.md)**.
> Competition media: **[TDP](RoboCup%20Internationals%202025-26/Docs/TDP.md)** ·
> **[poster](RoboCup%20Internationals%202025-26/Docs/RoboCup_Internationals_Poster.png)** ·
> **[TDP video](https://github.com/Kushal-Sachdeva78/VVS-Ballers-RoboCup/releases/download/internationals-2025-26-media/VVS_Ballers_TDP_Video.mp4)** ·
> **[photo gallery](RoboCup%20Internationals%202025-26/Docs/Images)**.
>
> Code-span paths below (e.g. `Firmware/Attacker`) are relative to
> [`RoboCup Internationals 2025-26/`](RoboCup%20Internationals%202025-26/).
### Earlier-season highlights
- **Regionals 2025-26 (EV3):** EV3 motors driving omni wheels in a **diamond** layout;
underside colour sensors for white-line and goal-area avoidance; side IR sensors for
walls; an IR seeker for ball tracking; and a compass for heading correction. An
external Arduino kicker (TB6612FNG H-bridge + gearmotor, ultrasonic ball detect)
steps through kick, hold, retract, and cooldown phases.
- **Nationals 2025-26 (EV3):** the same EV3 sensing platform, upgraded with a
relay-driven solenoid kicker triggered by an ultrasonic capture sensor. The custom
Teensy and KiCad electronics stack was developed next, for the Internationals robots.
---
## Internationals 2025-26: the robots at a glance
Both robots share one electronics stack and one chassis; only the role firmware on
the main board differs.
| | Attacker | Defender (goalkeeper) |
|---|---|---|
| Job | Win the ball, aim, and shoot the open corner | Hold the goal mouth and clear the ball |
| Main firmware | `Firmware/Attacker/Attacker_Chase_Aim_Kick_Line` | `Firmware/Defender/Defender_Full` |
| Ball | IR ring (16 sensors) | IR ring |
| Staying in bounds | **Line ring + ultrasonic fused** boundary escape | **Line** keeps it on the goal-area ("D") line; ultrasonic cross-check |
| Goal / aim | OpenMV camera to open-corner bearing | (camera optional) |
| Kicker | 48 V solenoid, camera-gated | Short clearing kick |
## Electronics: the boards
A **multi-board design**: each subsystem has its own microcontroller, and the boards
talk to the main board over compact **UART links** (CRC-8-framed, bar the plain-ASCII
IR link), keeping the fast sensor loops off the main control CPU.
| Board | MCU | Does | KiCad | Firmware |
|---|---|---|---|---|
| **Main** | Teensy 4.1 | Drive (4x DRV8263H), BNO055 IMU, capture sensor, kicker relay, all links | `PCB/Main` | `Firmware/Attacker`, `Firmware/Defender` |
| **IR ring** | Teensy 4.1 | 16x TSSP58038 for ball bearing and distance | `PCB/IR` | `Firmware/IR_Ball_Sensor` |
| **Line ring** | Teensy 4.1 | 4x QTR-MD-05A (18 ch) for white-line detection | `PCB/Line` | `Firmware/Line_Sensor` |
| **Ultrasonic** | Arduino Nano Every | 4x HC-SR04 for wall distances | `PCB/Ultrasonic` | `Firmware/Ultrasonic` |
| **Camera** | OpenMV H7 | Goal / keeper / open-corner vision | - | `Firmware/Camera` |
| **Power** | - | 12 V / 5 V / 3.3 V rails + 48 V solenoid boost | `PCB/Power` | - |
| **Motor-current** (optional) | Arduino Nano Every | DRV8263H stall / over-current watchdog | - | `Firmware/Motor_Current` |
Human-readable wiring PDFs for the Main, Power, IR, and Line boards are in
**[`PCB/Wiring/`](RoboCup%20Internationals%202025-26/PCB/Wiring)**.
## How it plays: design choices vs. the game
Everything is built around what actually wins (and loses) a RoboCupJunior Soccer
match. (A goal counts when the ball touches the **back wall of the goal**; touching a
wall or driving fully into the marked penalty area is an **out-of-bounds penalty**.)
- **Score in the goal.** The IR ring gives the ball's bearing; the main board chases
it with an omni-wheel drive held straight by a BNO055 heading PID. Once the ball is
captured, the OpenMV camera finds the goal, picks the **open corner** (dodging the
keeper), and the chassis turns in place until that corner is dead ahead before the
solenoid fires. Aiming for the open corner instead of the goal centre is how you
beat a keeper.
- **Never cross the line (the expensive mistake).** The attacker treats a side as the
field boundary **only when the line ring and the ultrasonics agree** (white line
seen *and* wall within 300 mm), then flees away from it. Two independent sensors
must concur, so one noisy reading can't make the robot dart out of bounds.
- **Keep the keeper on its line, not inside the box.** No robot may be *fully* inside
the penalty area, so the defender uses the line ring to ride the **edge of the goal
area ("the D")** while tracking the ball laterally and clearing it on contact.
- **Stay legal in the Infrared league.** IR-emitting rangefinders (ToF, LiDAR, IR
distance sensors) are **banned** because they'd swamp other robots' IR ball
sensors. That is why walls are ranged with **ultrasonic** HC-SR04s here, not IR.
- **Power within the rules.** The rules cap robot power at **48 V DC**; the solenoid
kicker runs from a 48 V boost converter (right at the legal ceiling, for the hardest
legal kick) while logic and motors run from 3.3 V / 5 V / 12 V rails.
- **Referee start/stop.** The main board pins out the RoboCupJunior **Communication
Module** GO/STOP inputs, with firmware support toggled via `USE_COMMS` in the
defender build.
The binary inter-board links (ultrasonic, line, camera to main) are short frames, each
guarded by an identical **CRC-8 (poly 0x07)**; the IR link is plain delimited ASCII.
Full byte-level layouts are in the
[technical deep-dive](RoboCup%20Internationals%202025-26/Docs/HOW_IT_WORKS.md).
## Team
| Member | Roles |
|---|---|
| **Kushal Sachdeva** (Team Leader) | Electrical, Software & CAD |
| **Darsh Goel** | Mechanical & CAD |
Region: **India** · League: **RoboCupJunior Soccer Infrared**
## Sponsors
Our thanks to **Amazon · DLF · Havells · OpenMV · Magnum Ventures · Budtree
Management**, and to our mentors, school, and the RoboCup Junior community for their
support.
## Related projects
- [K.A.D-Ballers-Genius-Olympiad](https://github.com/Kushal-Sachdeva78/K.A.D-Ballers-Genius-Olympiad): our mecanum-drive robot for the GENIUS Olympiad robotics competition
- More at [github.com/Kushal-Sachdeva78](https://github.com/Kushal-Sachdeva78)
## License
Released under the **MIT License**; see [`LICENSE`](LICENSE).
© 2026 VVS Ballers (Kushal Sachdeva, Darsh Goel). You're welcome to learn from and
build on this work; please keep the attribution.