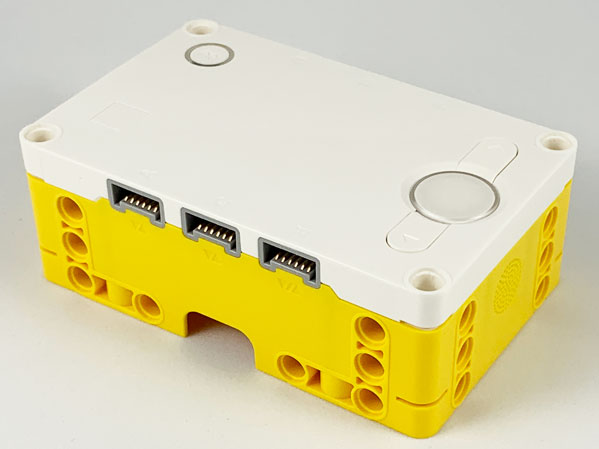
 Lego Spike Prime Hub |
Placed at the back of THE MACHINE atop the differential, it's the heart of our MACHINE.
|
|
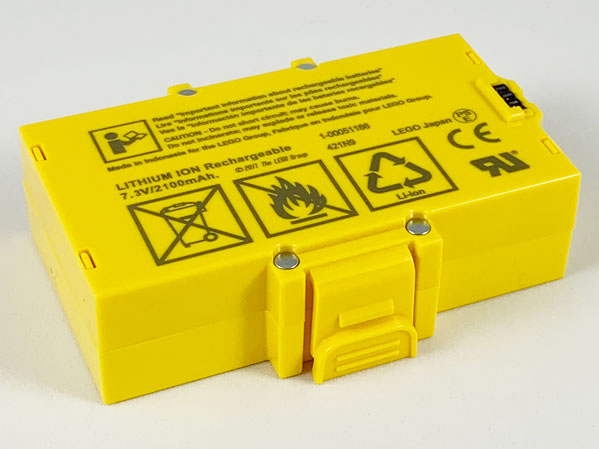 Lego Spike Prime Hub Battery |
A lithium ion recharable battery that powers the entire robot at 7.3v for 2100mAh or 15.4Wh which we have found as enough for now
|
|
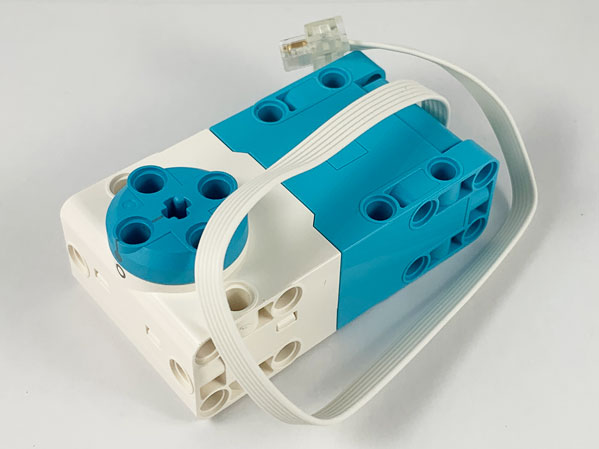 Lego Spike Prime Large Motor |
Placed in the middle of THE MACHINE to drive it via a technic axle connected to the differential, according to Lego, it generates 8 Ncm of torque at 135 RPM and consumes 430 mA at "maximum efficiency", thanks to the 20 tooth gear at the end of the Technic axle and the 28 tooth gear on the differential, this create an increase in torque at the expense of speed which results in the wheels getting 11.2 Ncm of torque at 96.42 RPM.
|
|
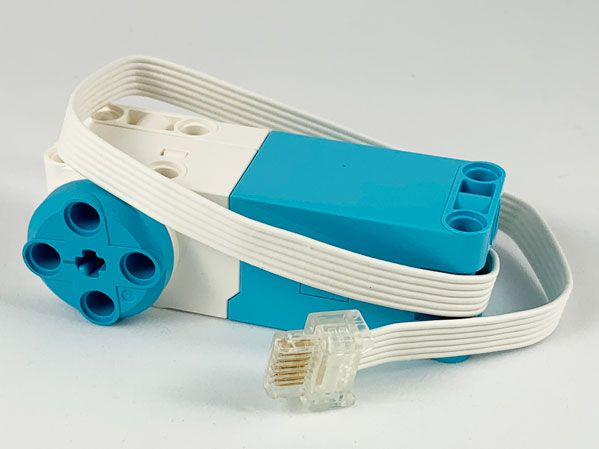 Lego Spike Prime Medium Motor |
This motor is placed at the front of THE MACHINE, atop the steering arms and is used for steering, it generates 3.5 Ncm of torque at 135 RPM and consumes 280mA according to Lego
|
|
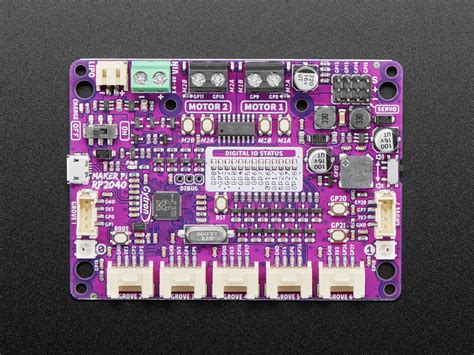 Maker Pi RP2040 |
This is the microcontroller we have placed under the Lego Spike Prime Hub, used to interface between any non Lego sensors we might use
|
|
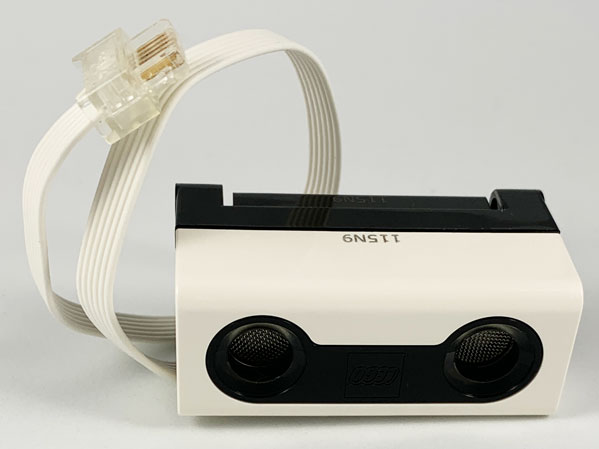 Lego Spike Prime Ultrasonic Distance Sensor |
One placed at the front and one at both left and right sides for wall detection and obstacle avoiding, it can detect objects for 200 cm and has a sample rate of 100 Hz
|
|
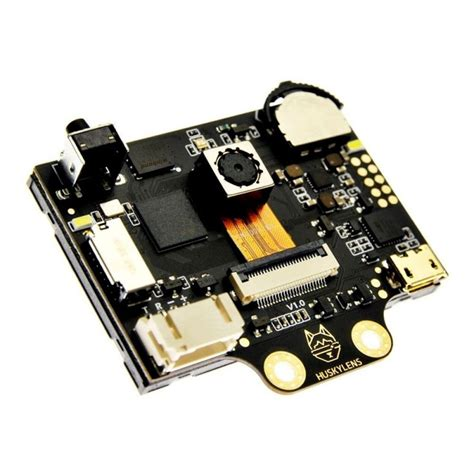 HuskyLens 1 |
This is our newest addition to V.Chew, placed atop the steering motor for accuracy when it comes to obstacle detection and hopefully will even assist us when it come to parking.
|
We also have some pics of him in the sun:
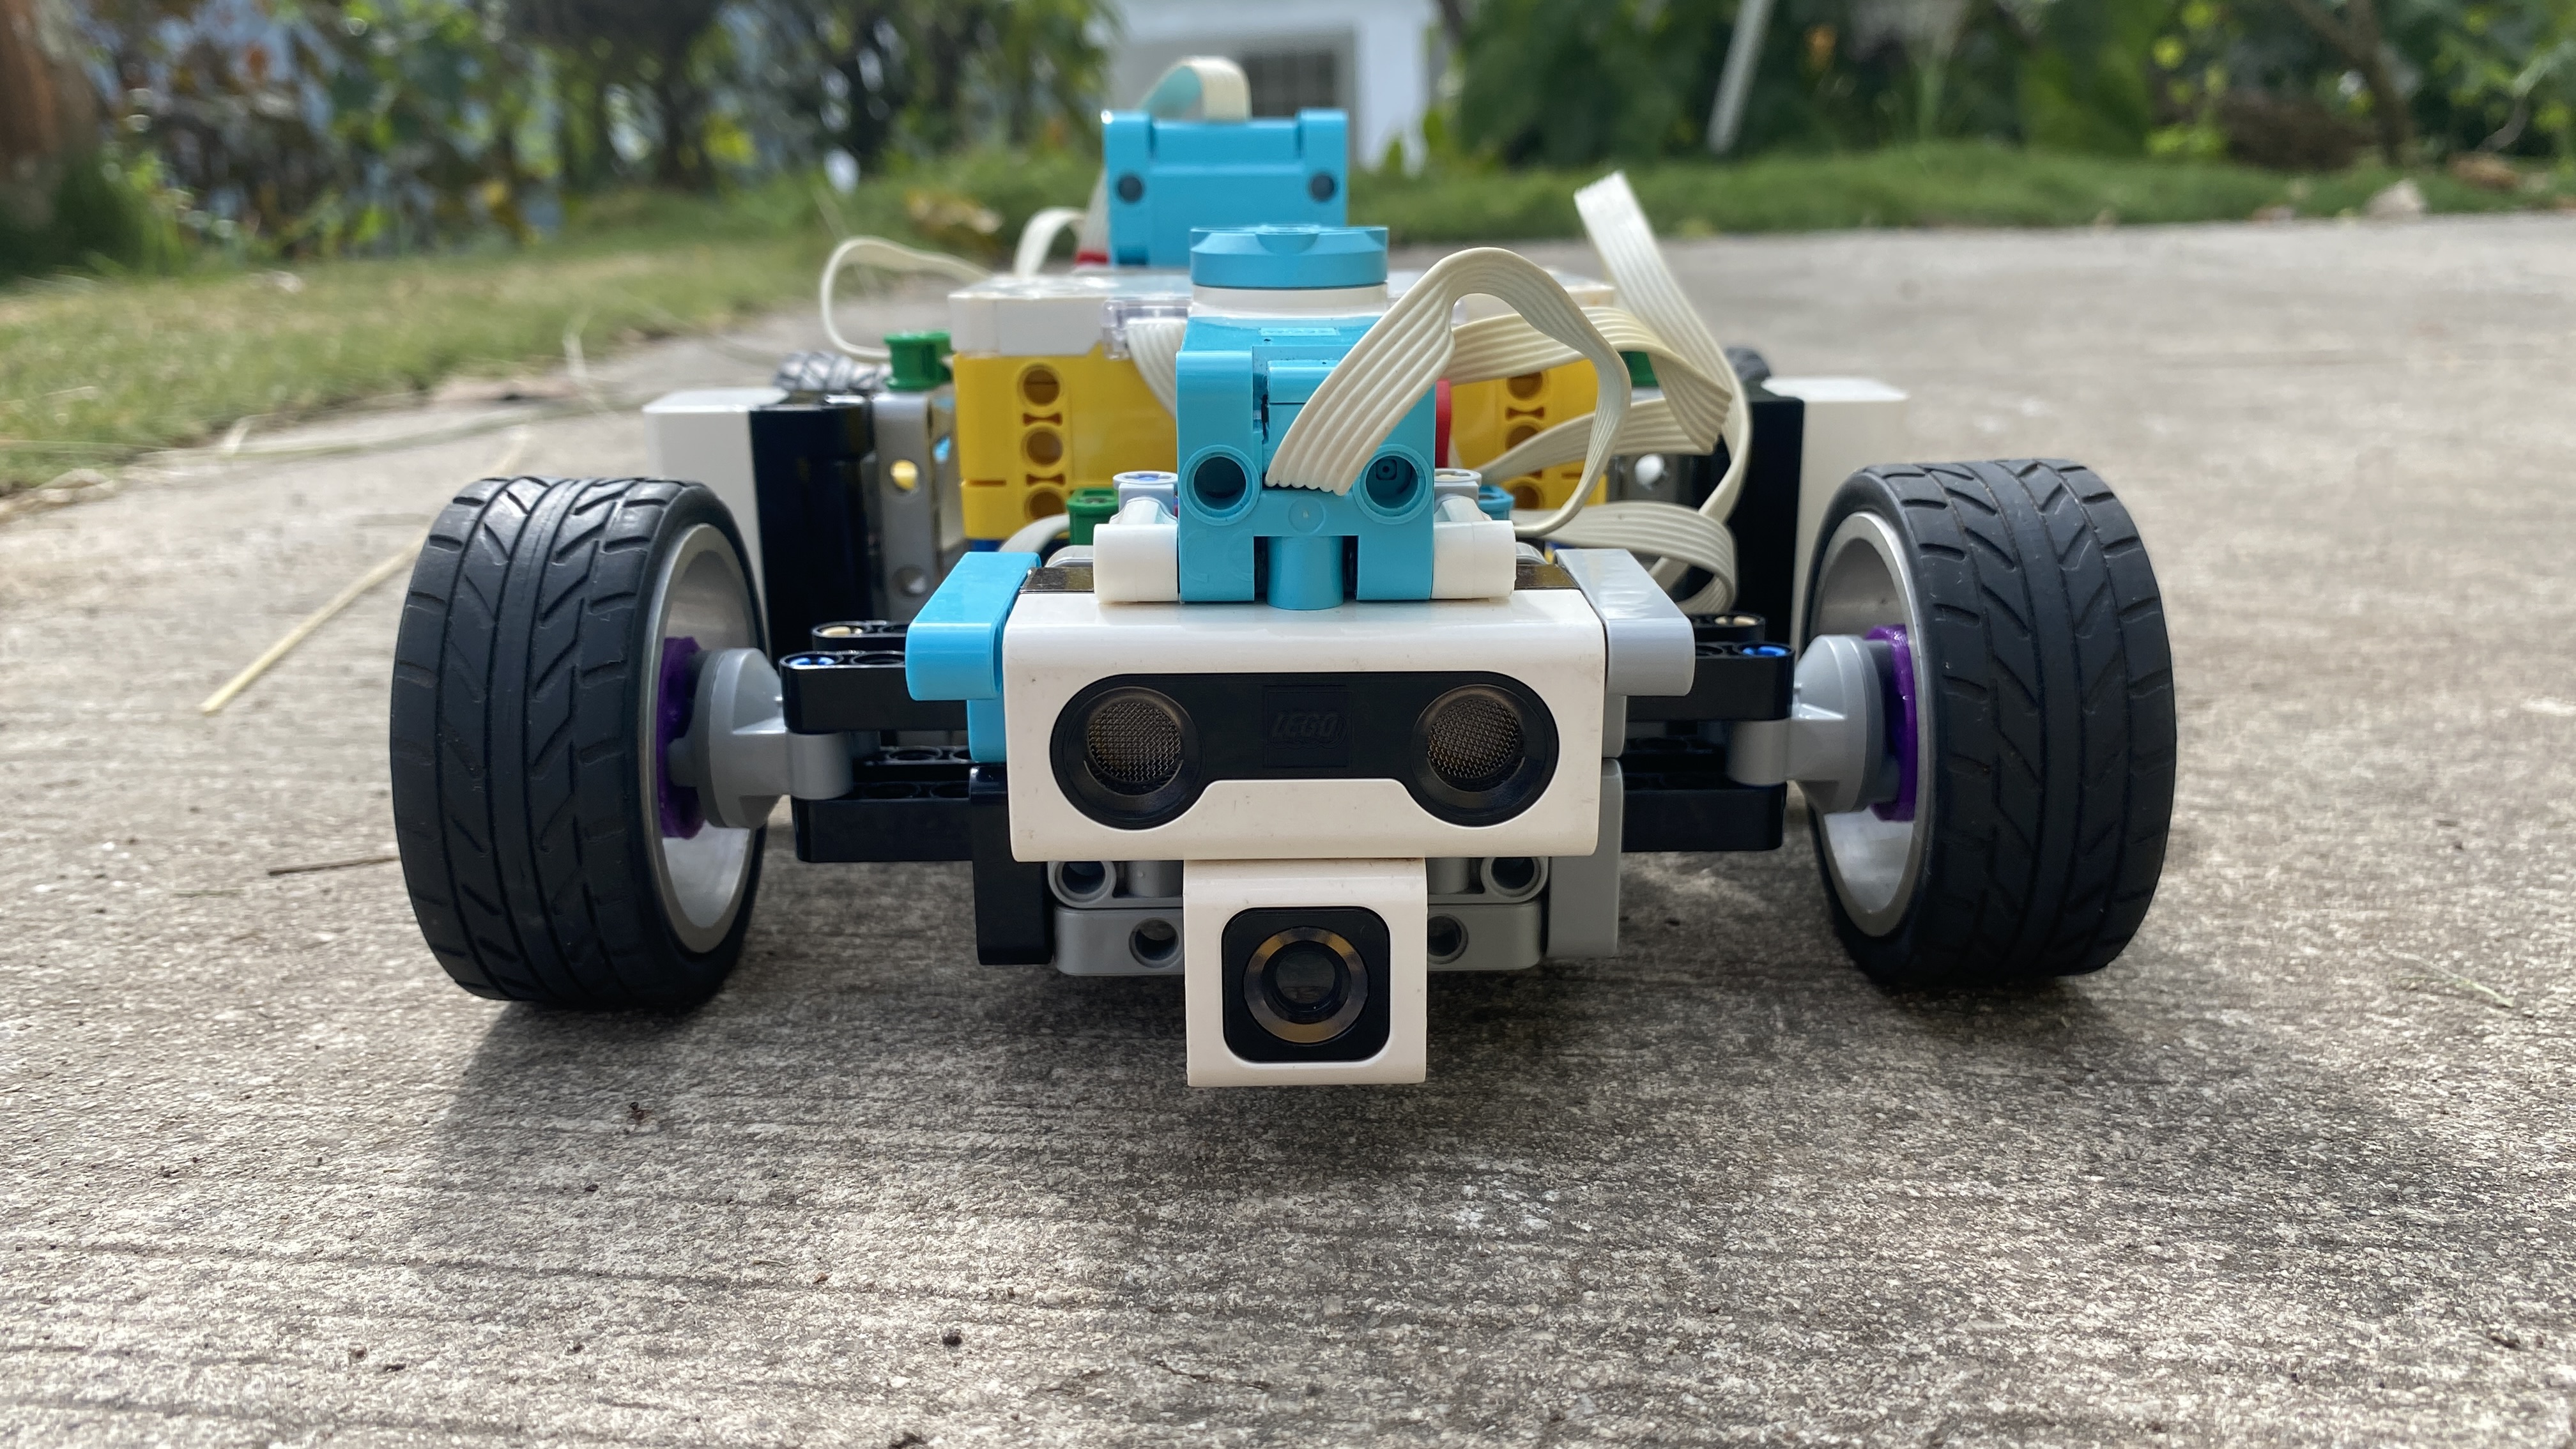 Front
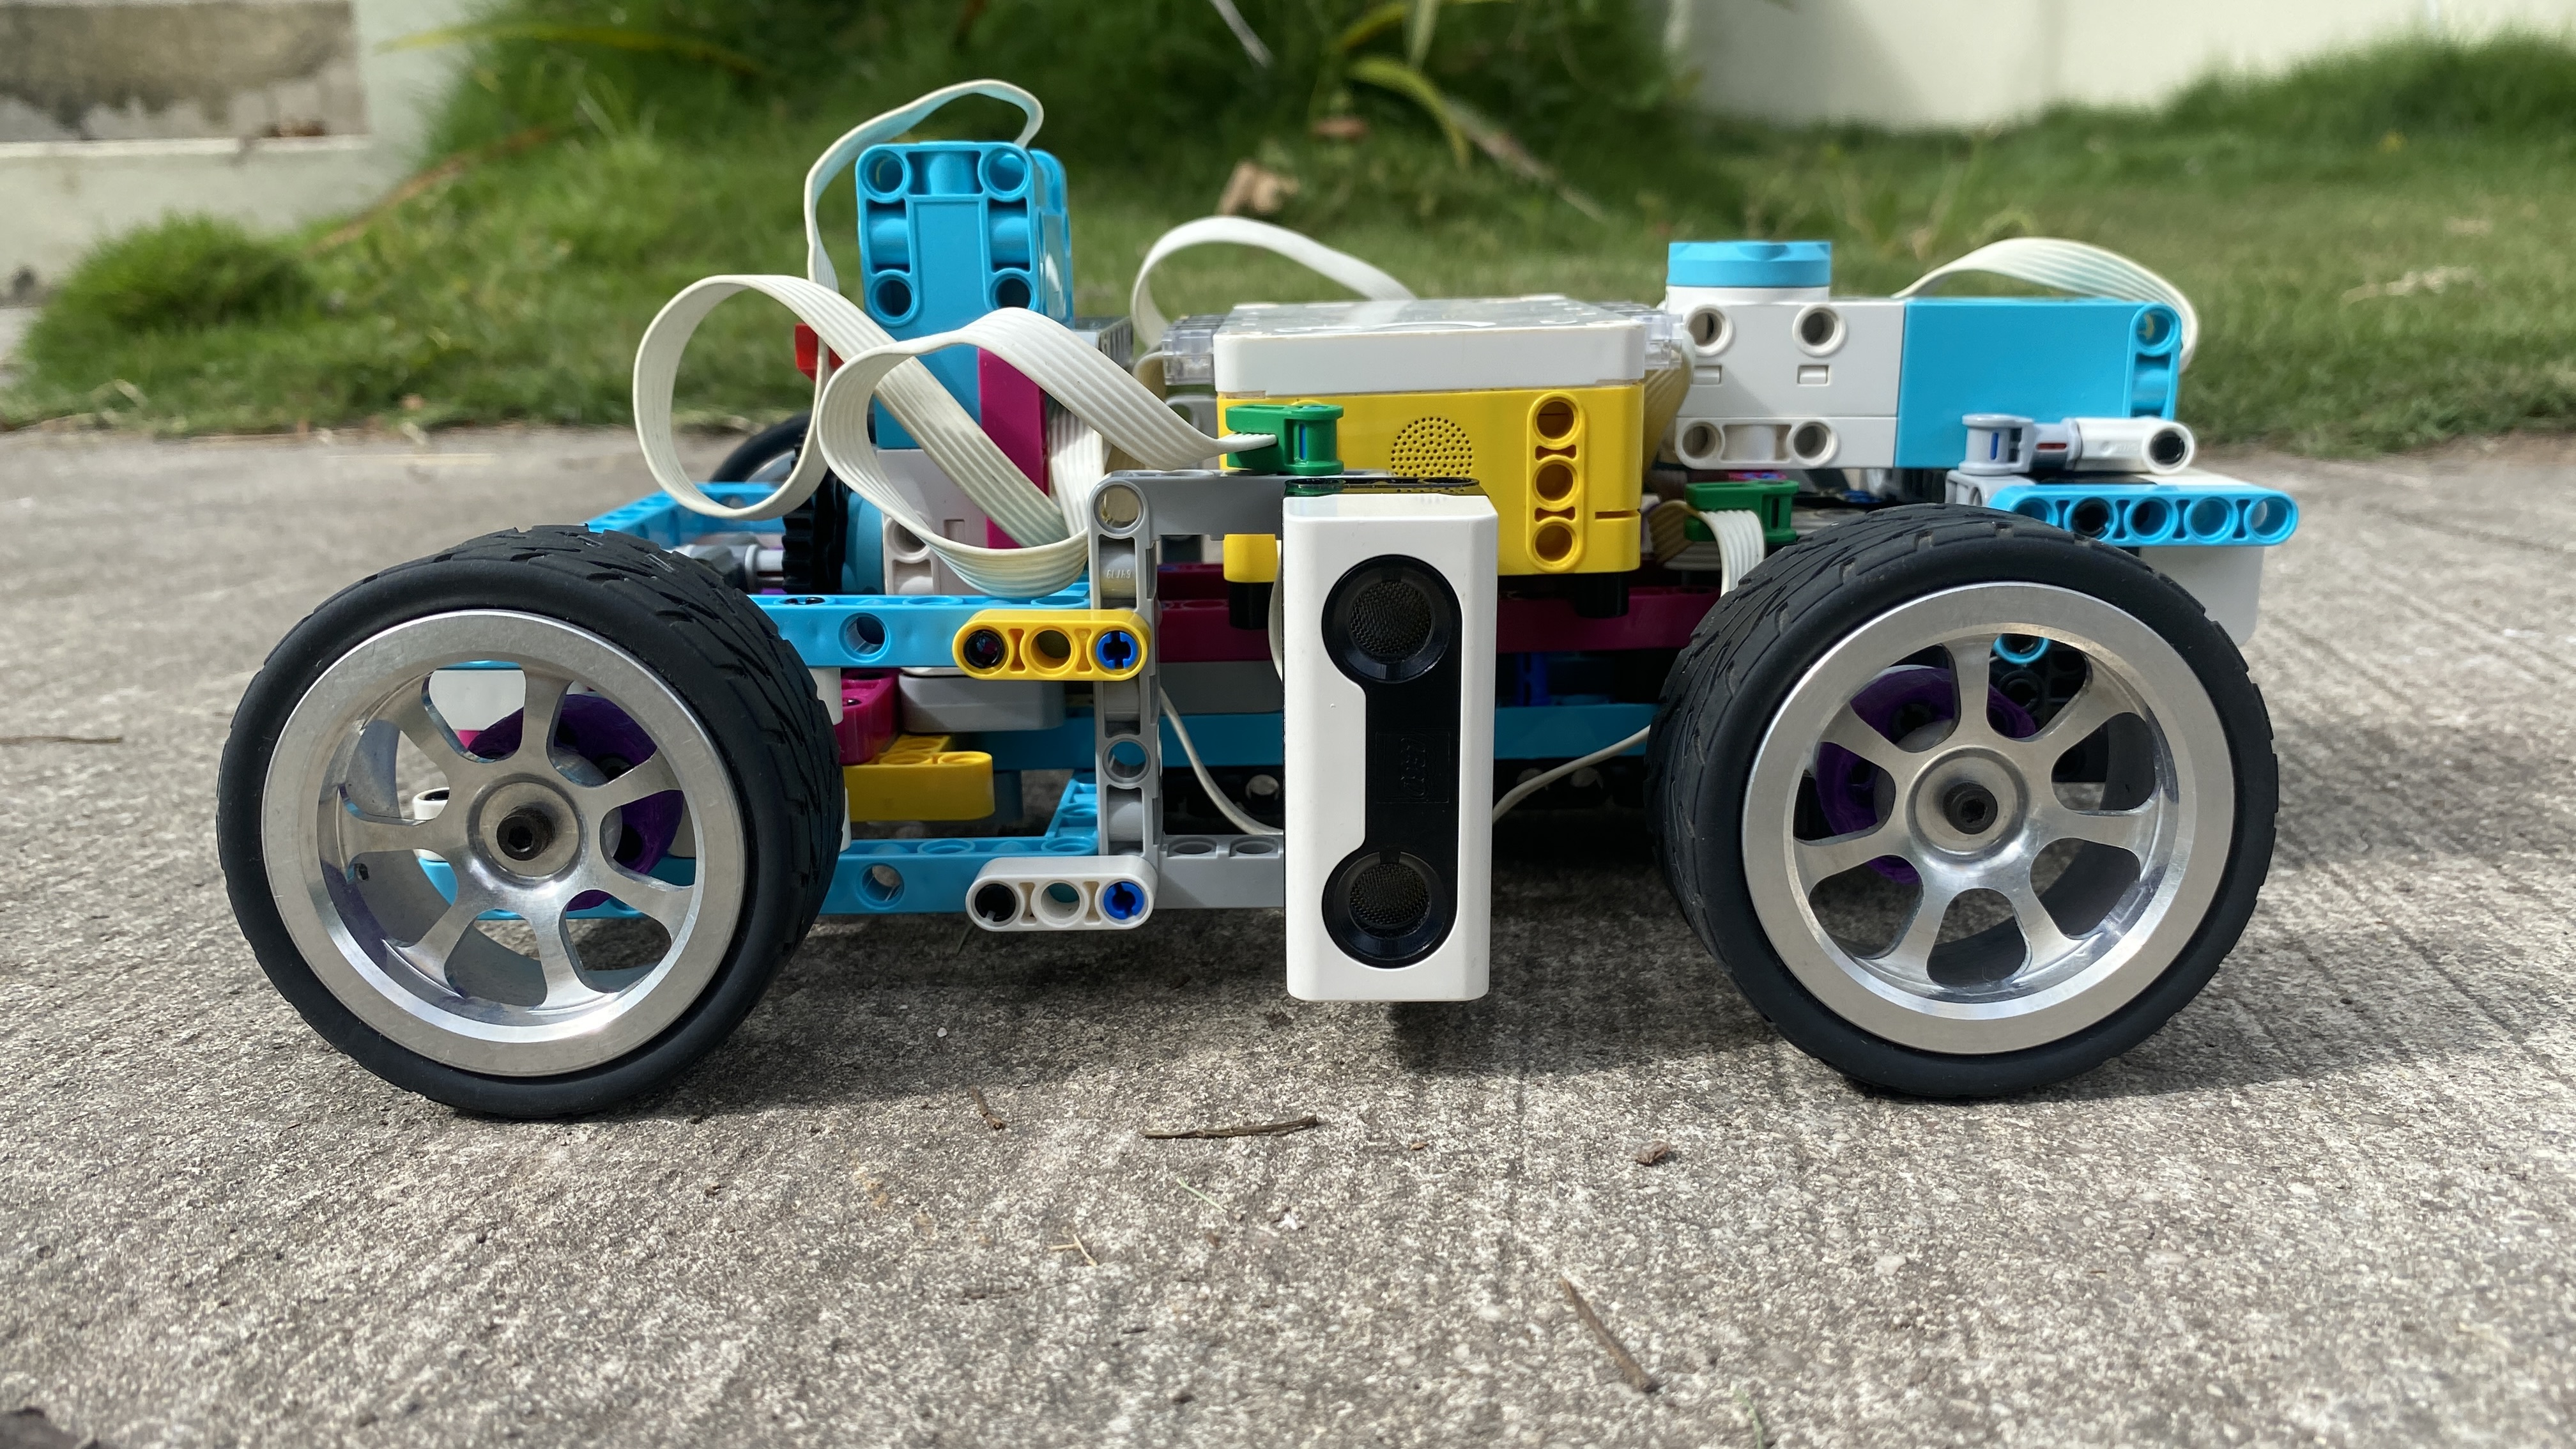 Right Side
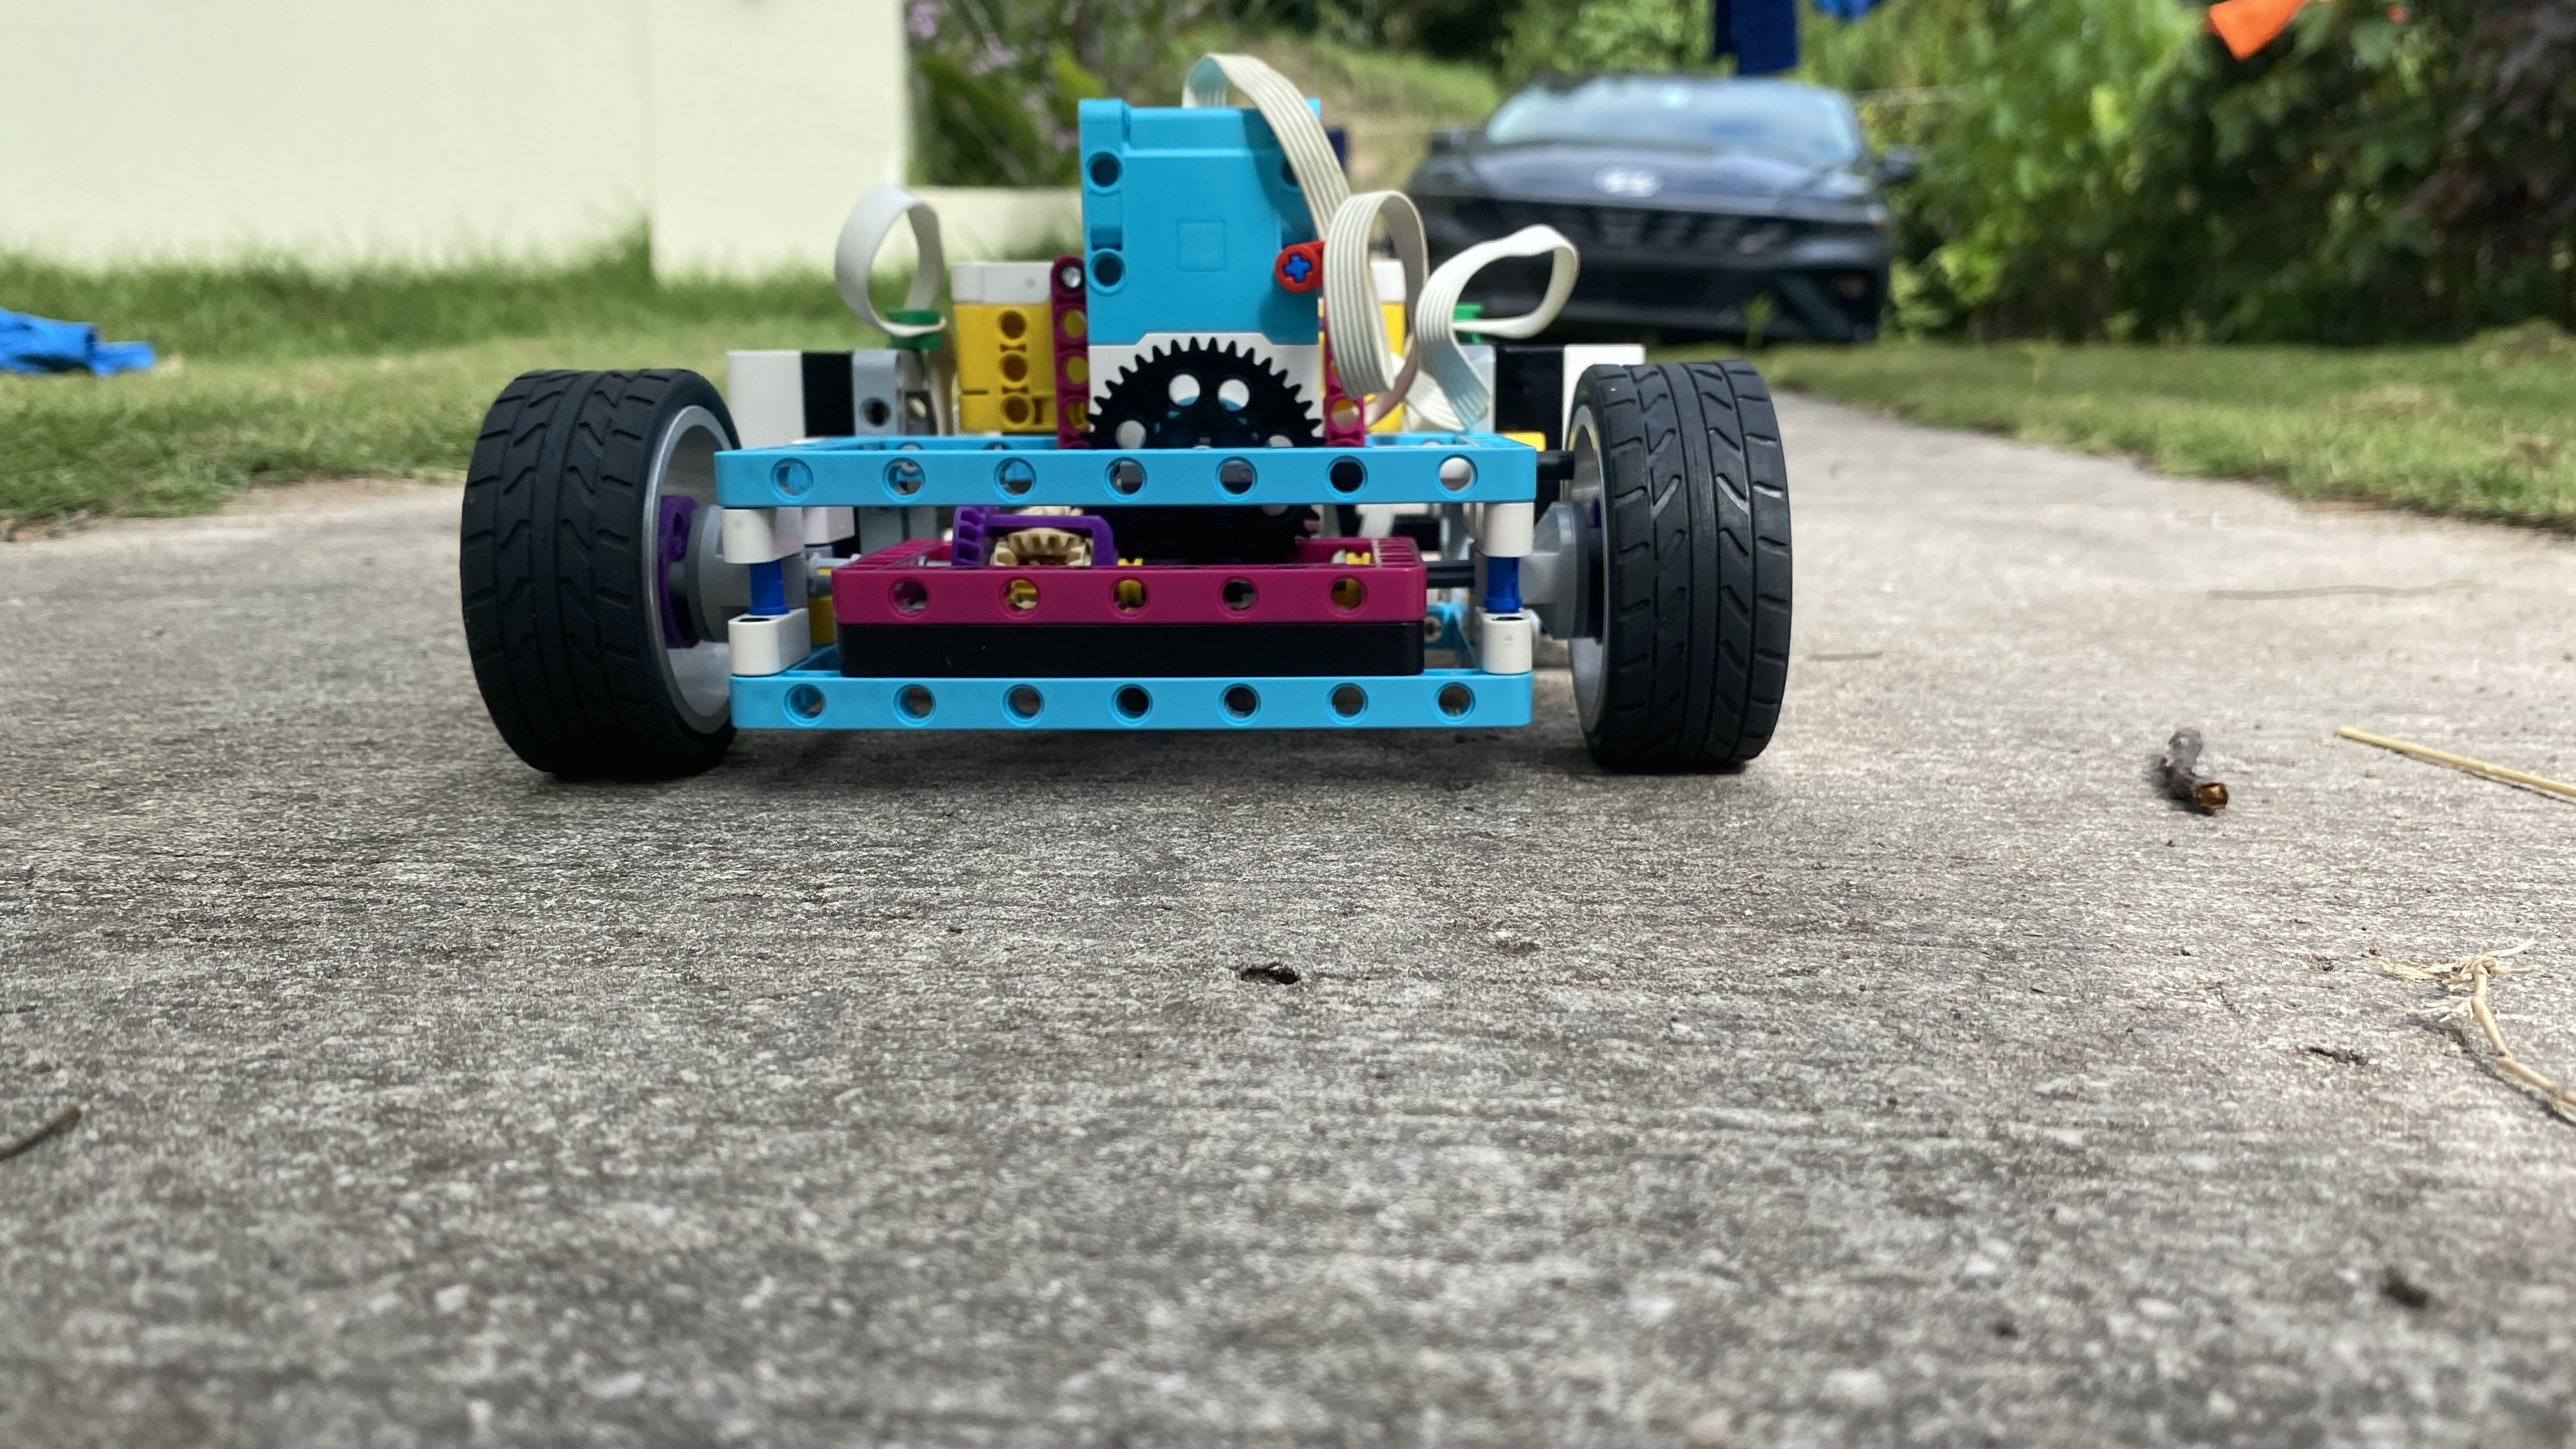 Rear
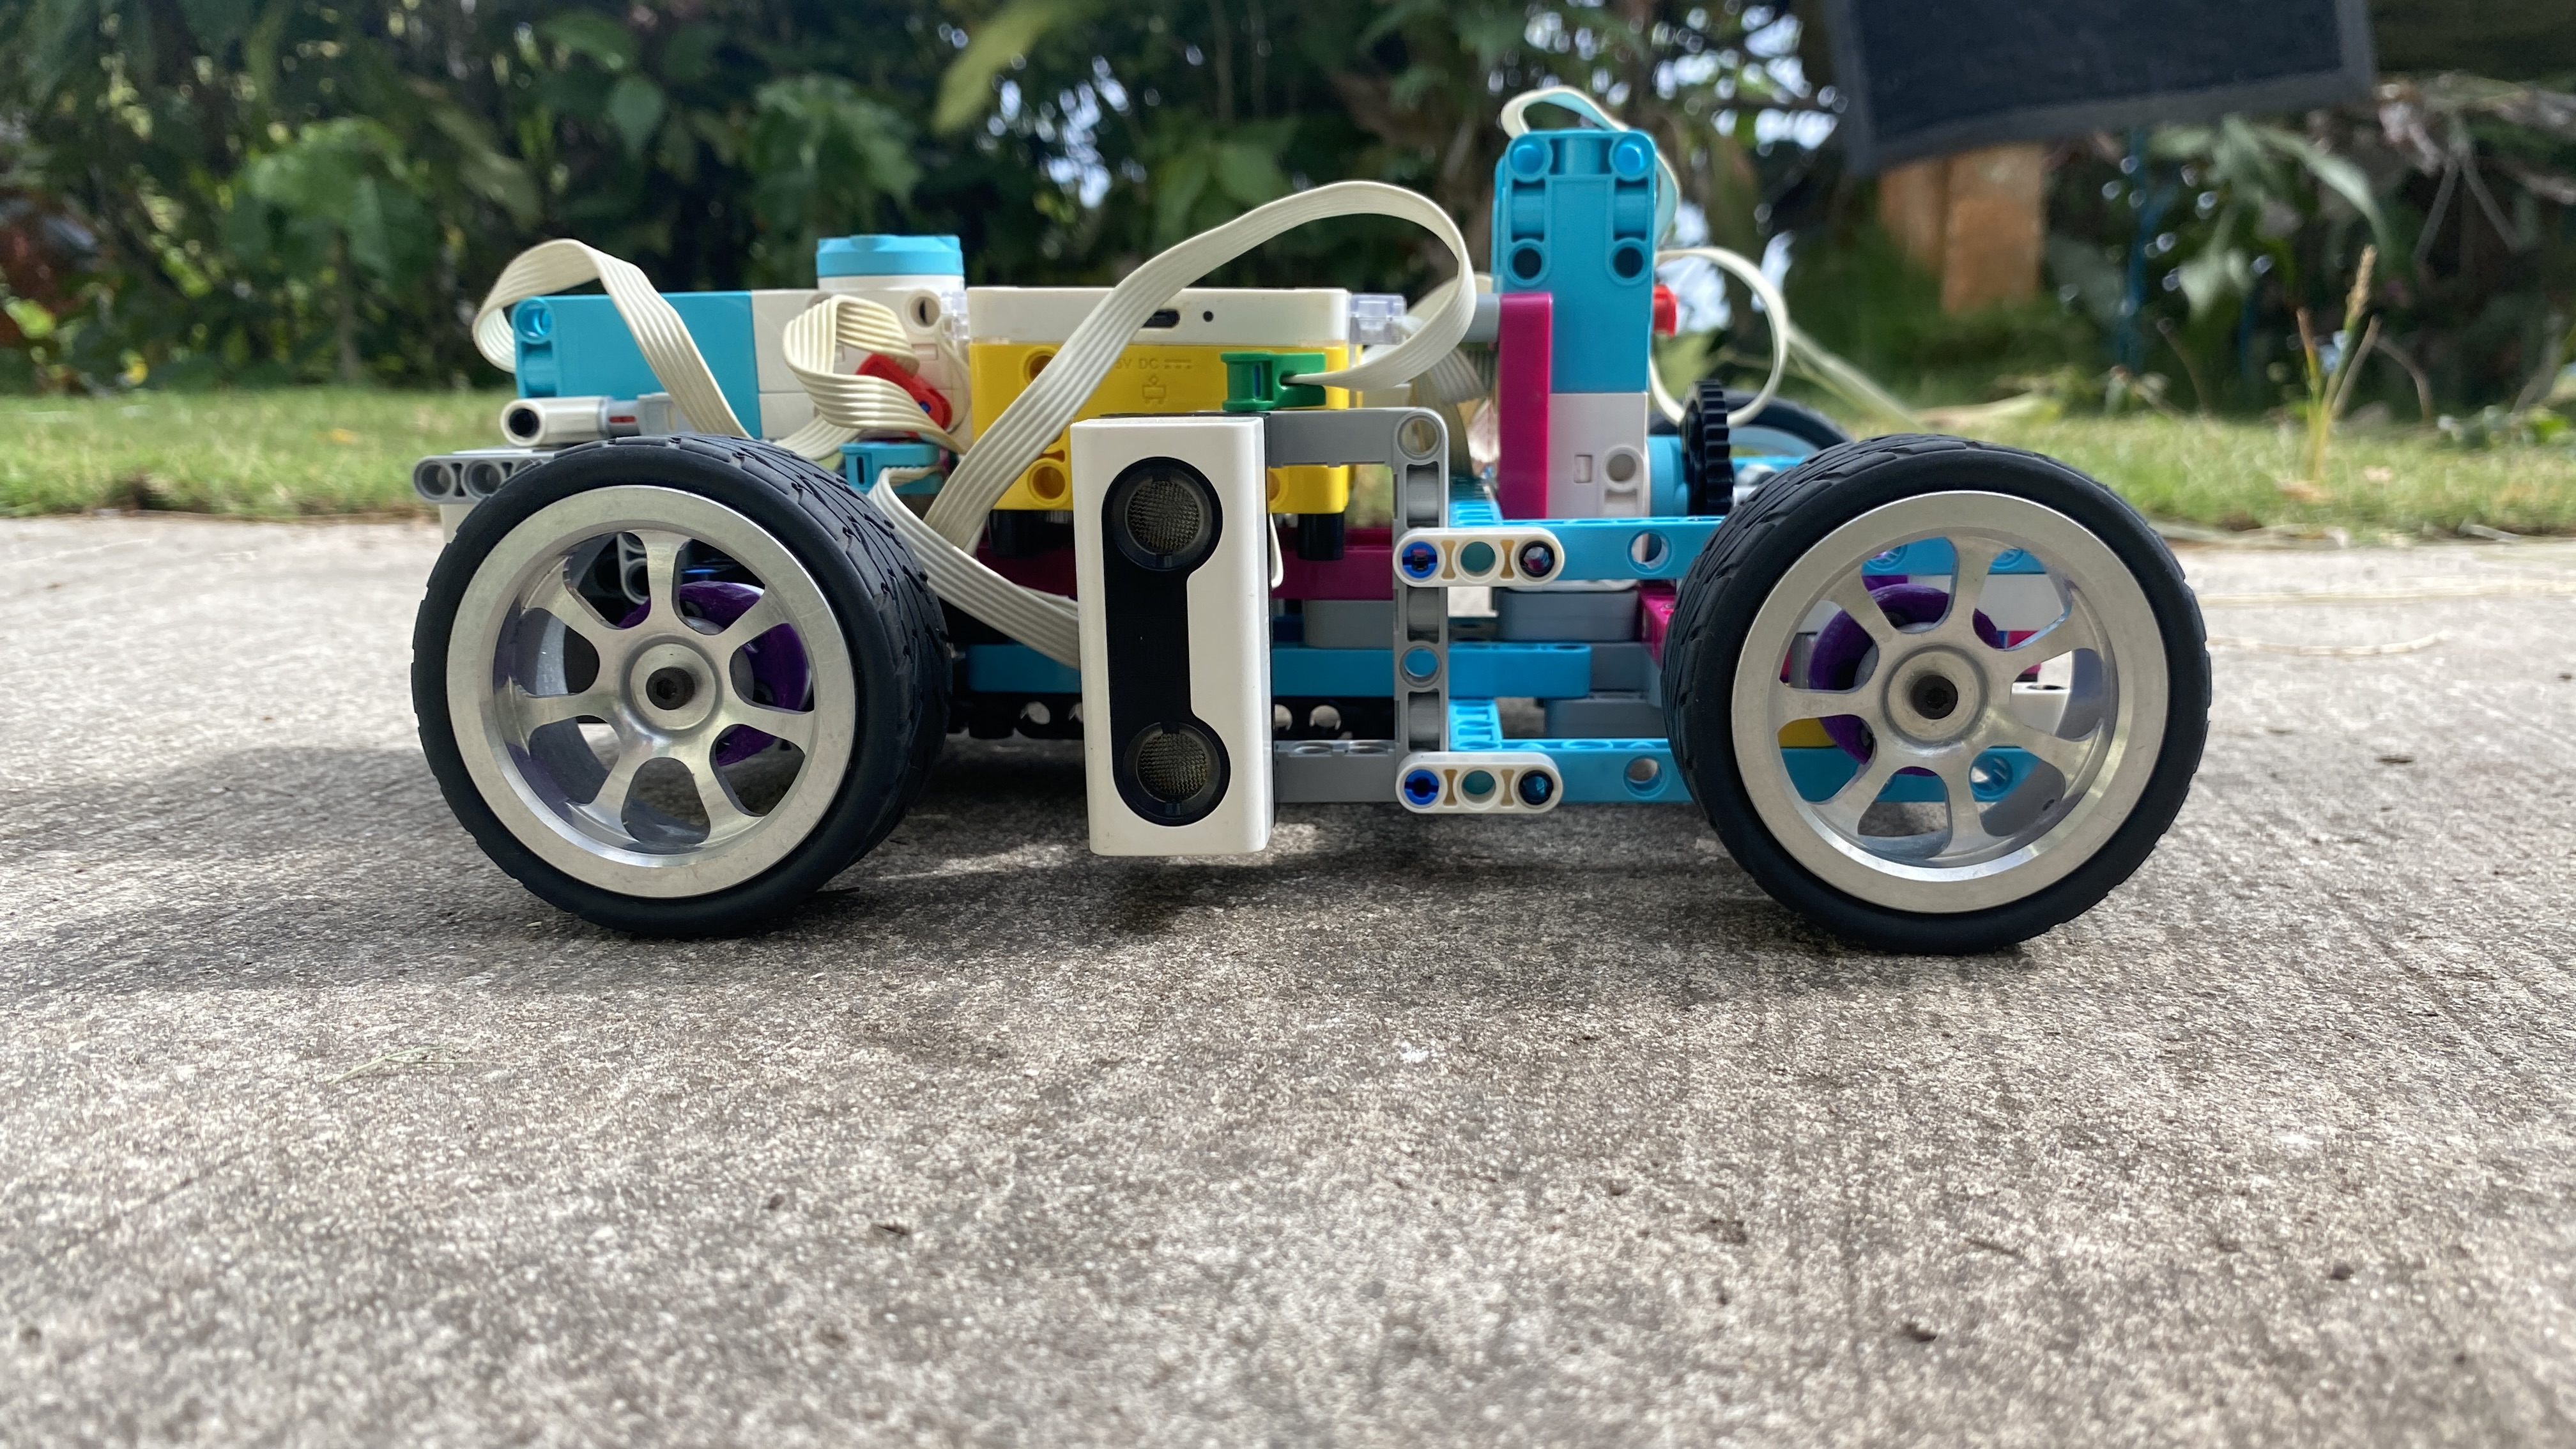 Left Side
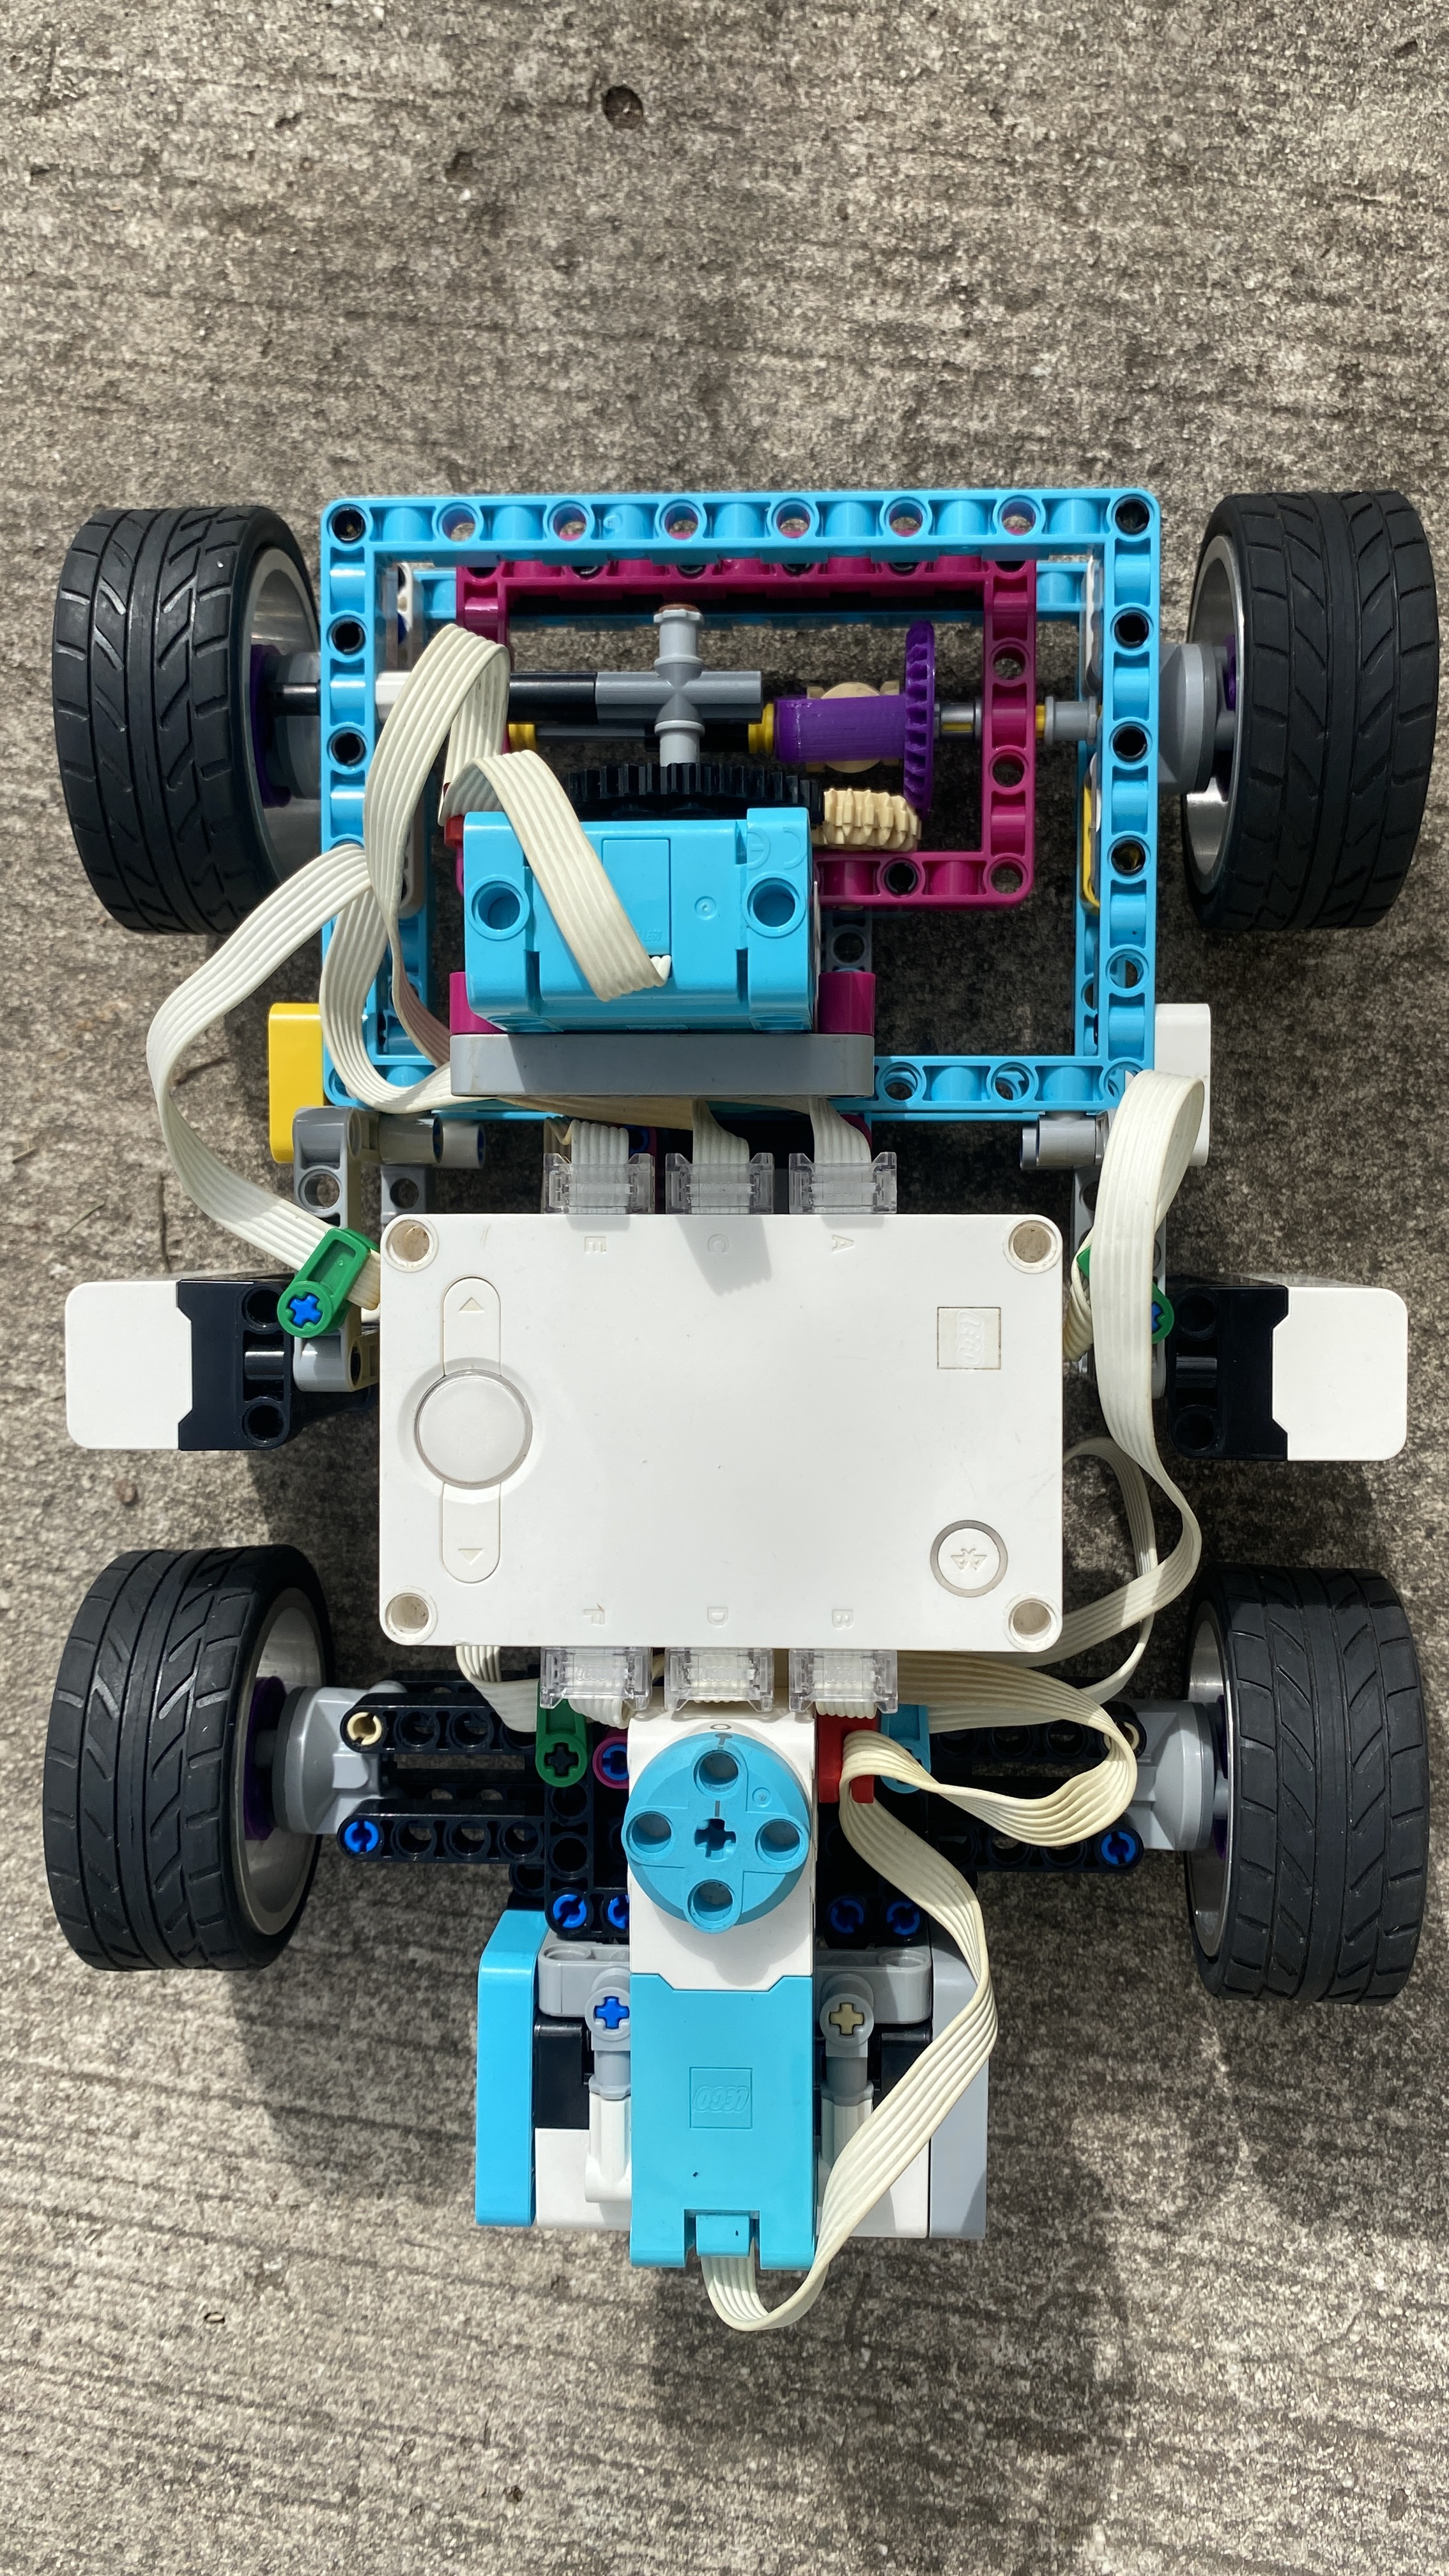 Top Down
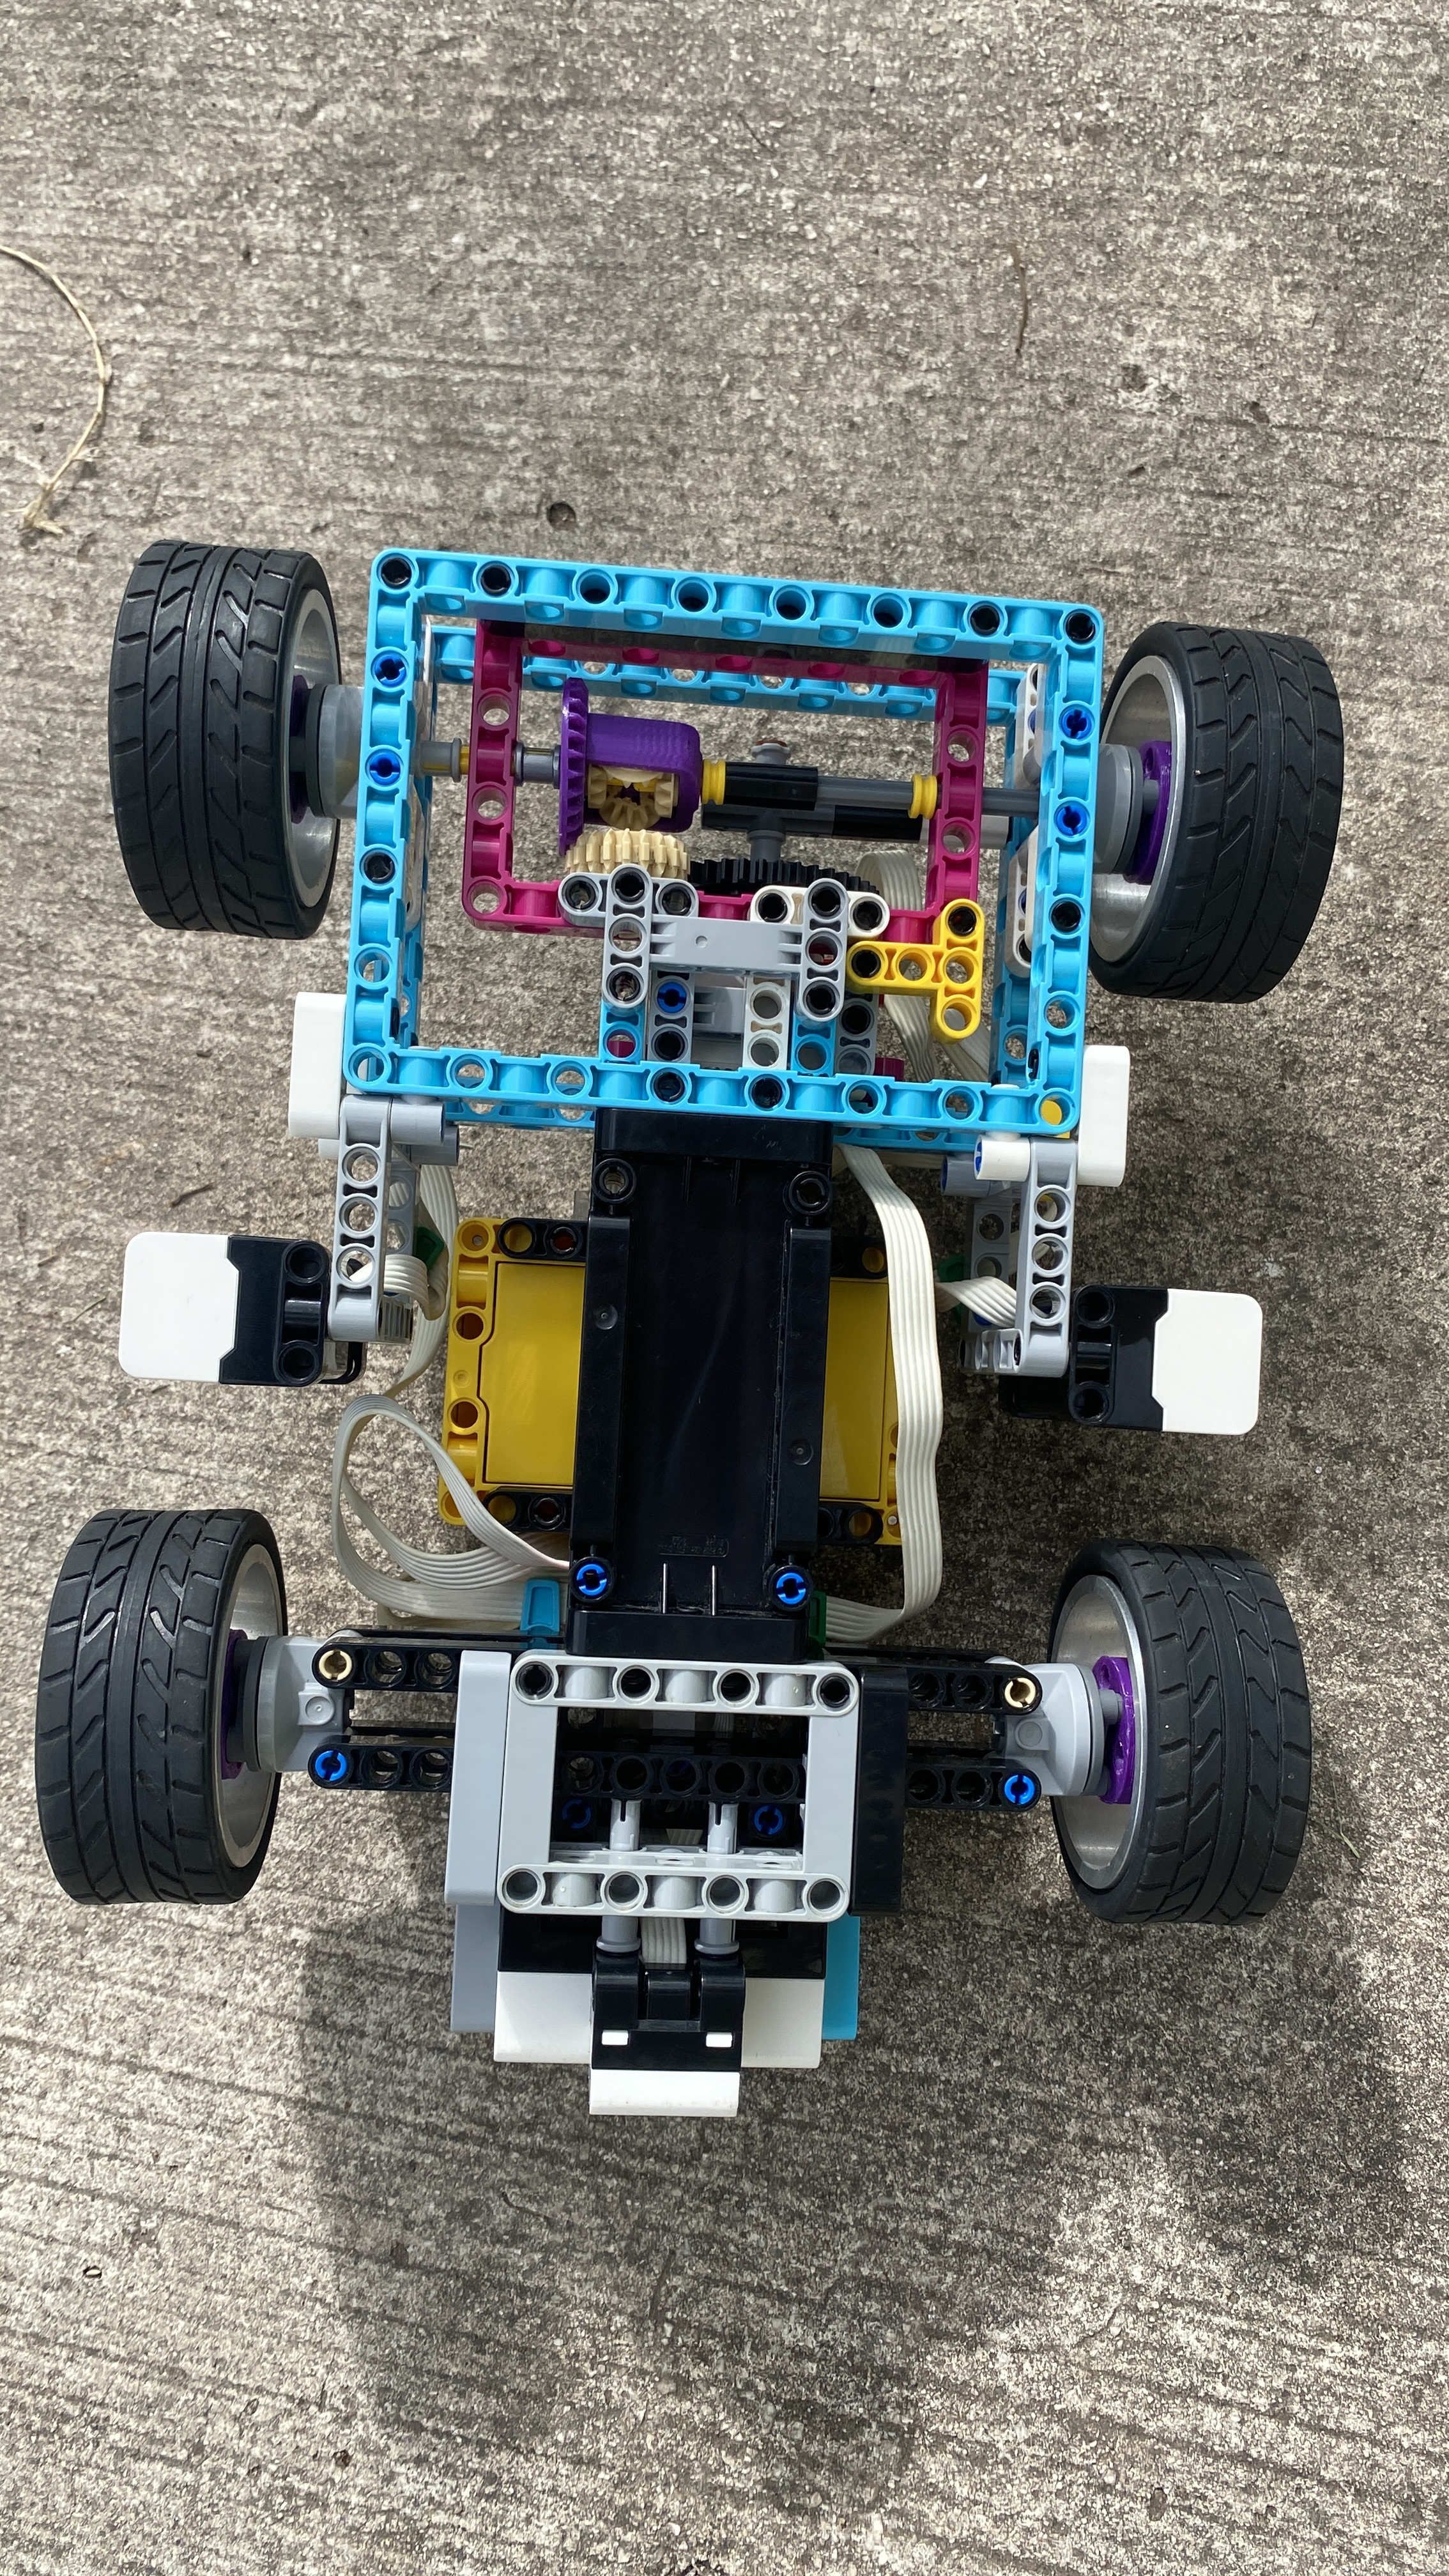 Bottom Up
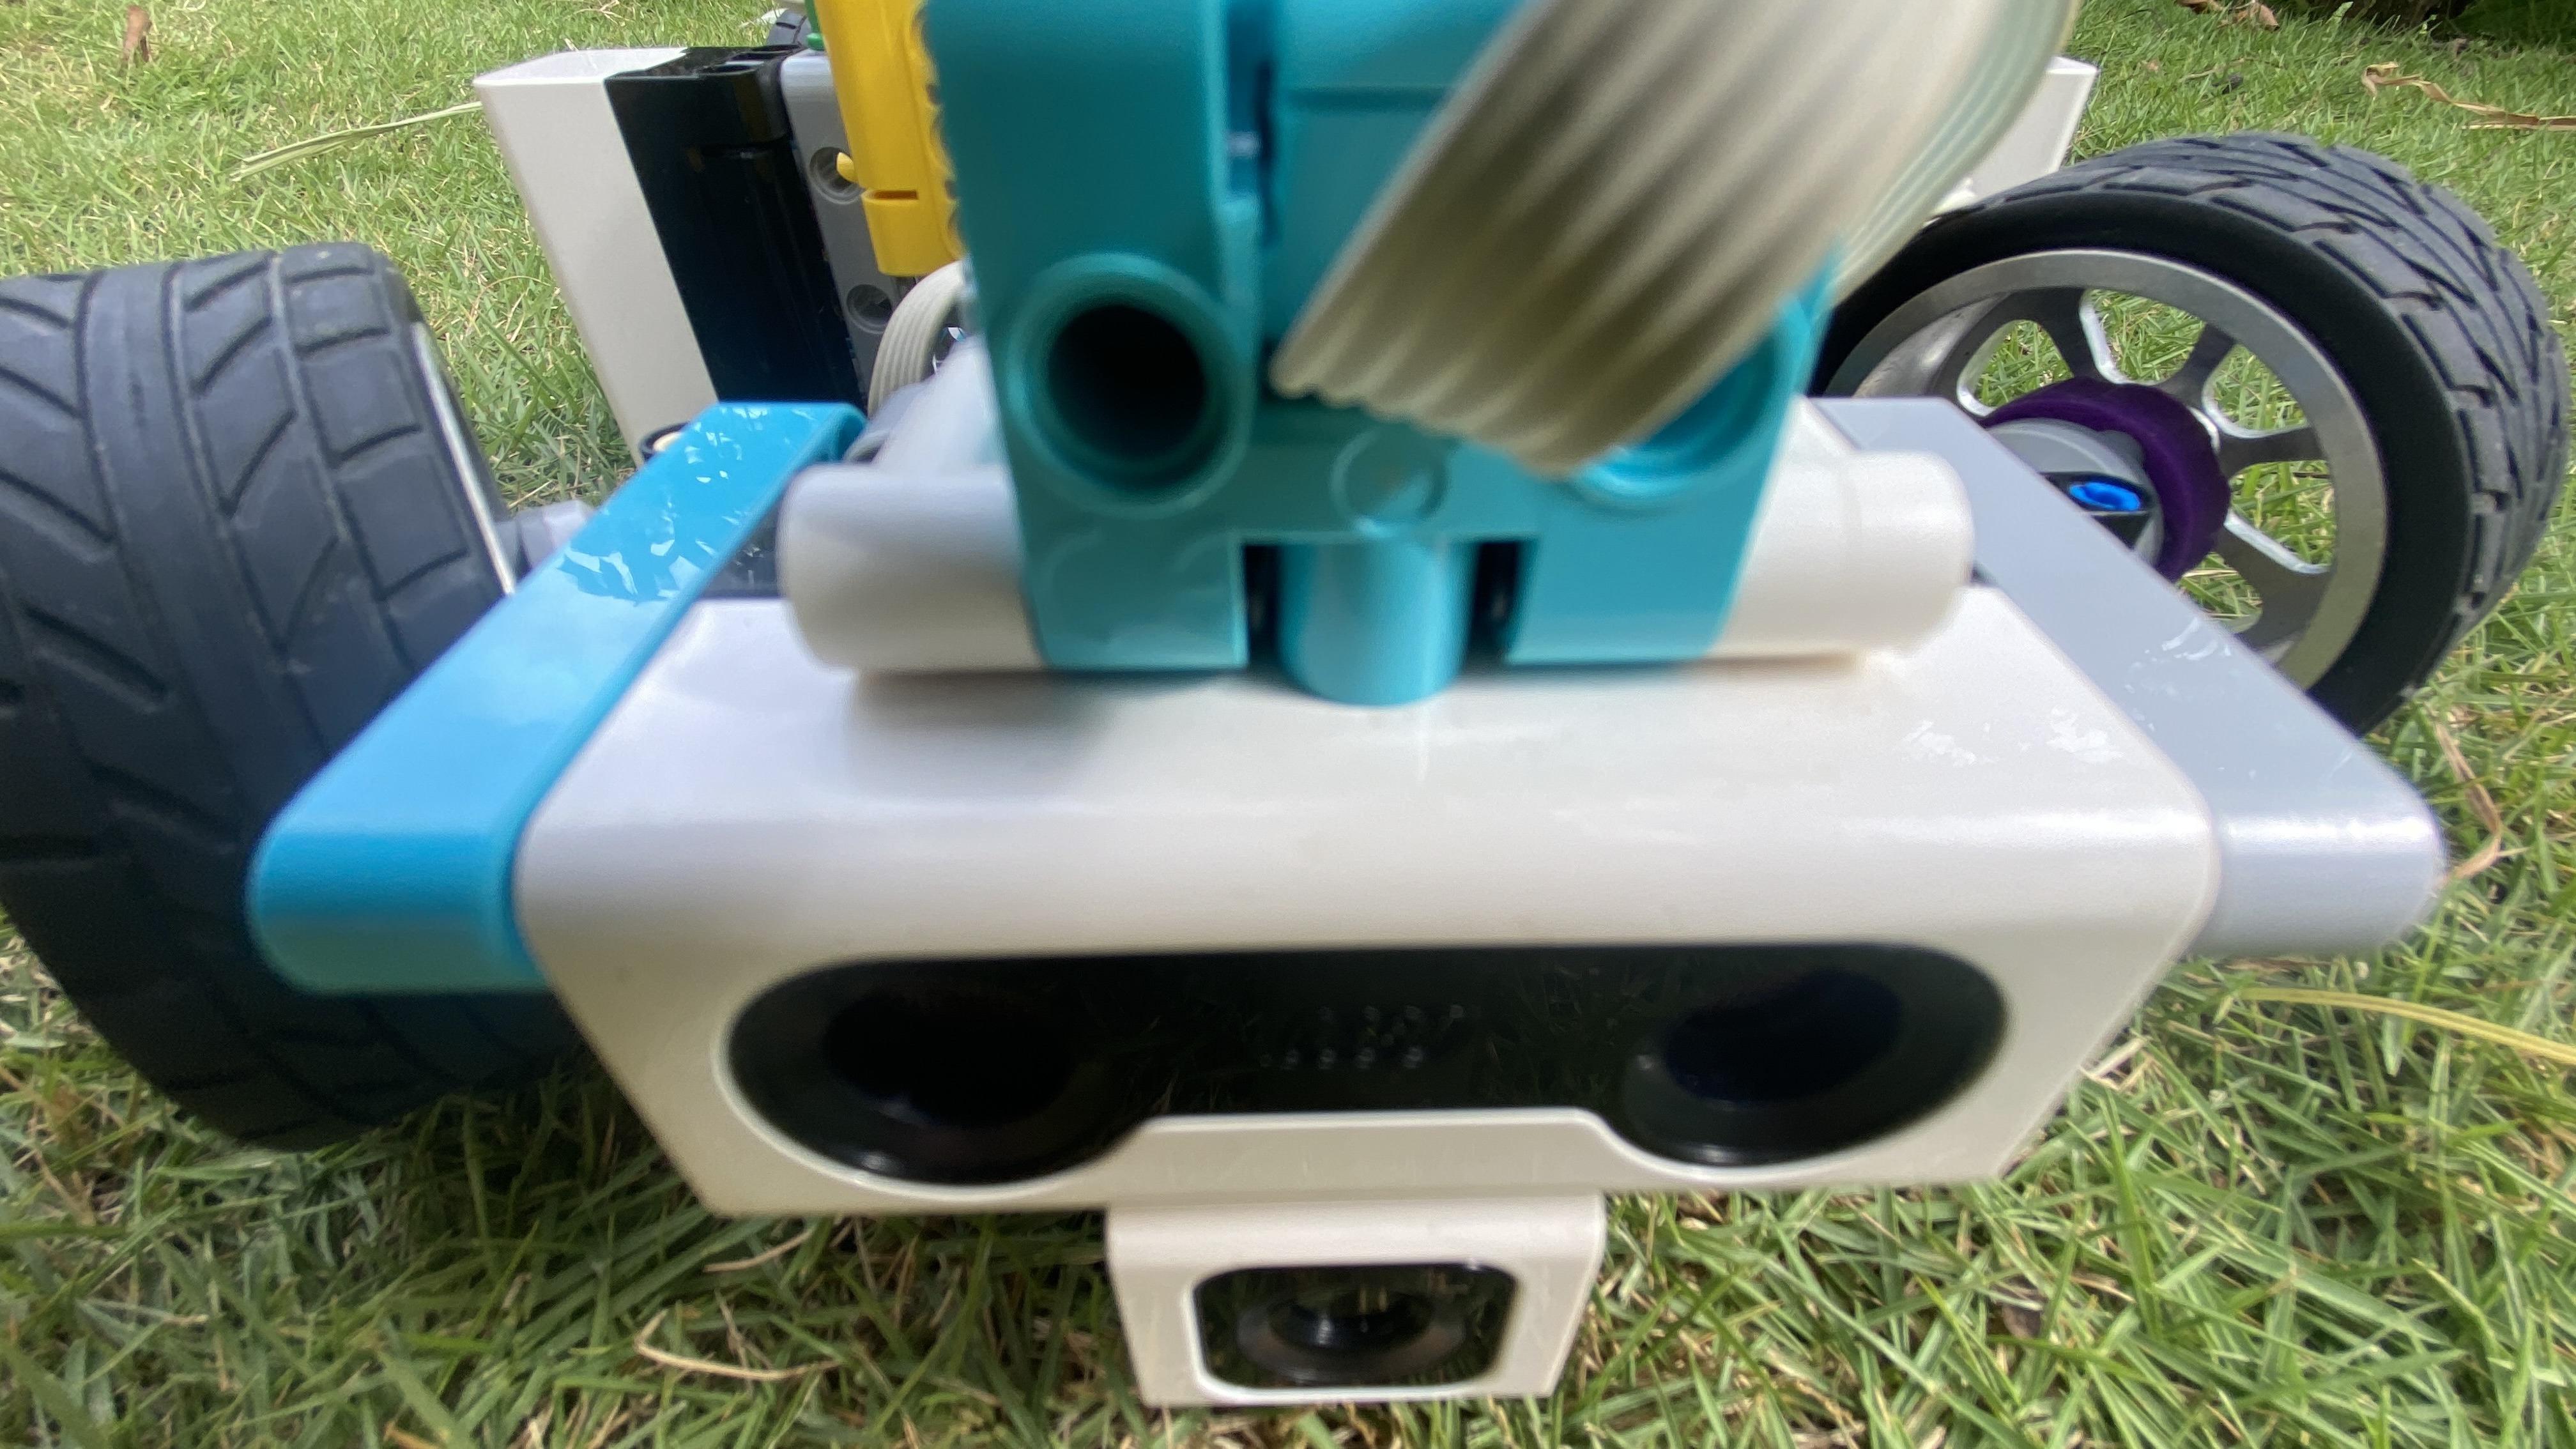 He measures in at 24.5 cm long, 19.5 cm wide and 10.5 cm tall he's equiped with the same wheels and electronic components as V. Juan, so they aren't that different from one another.
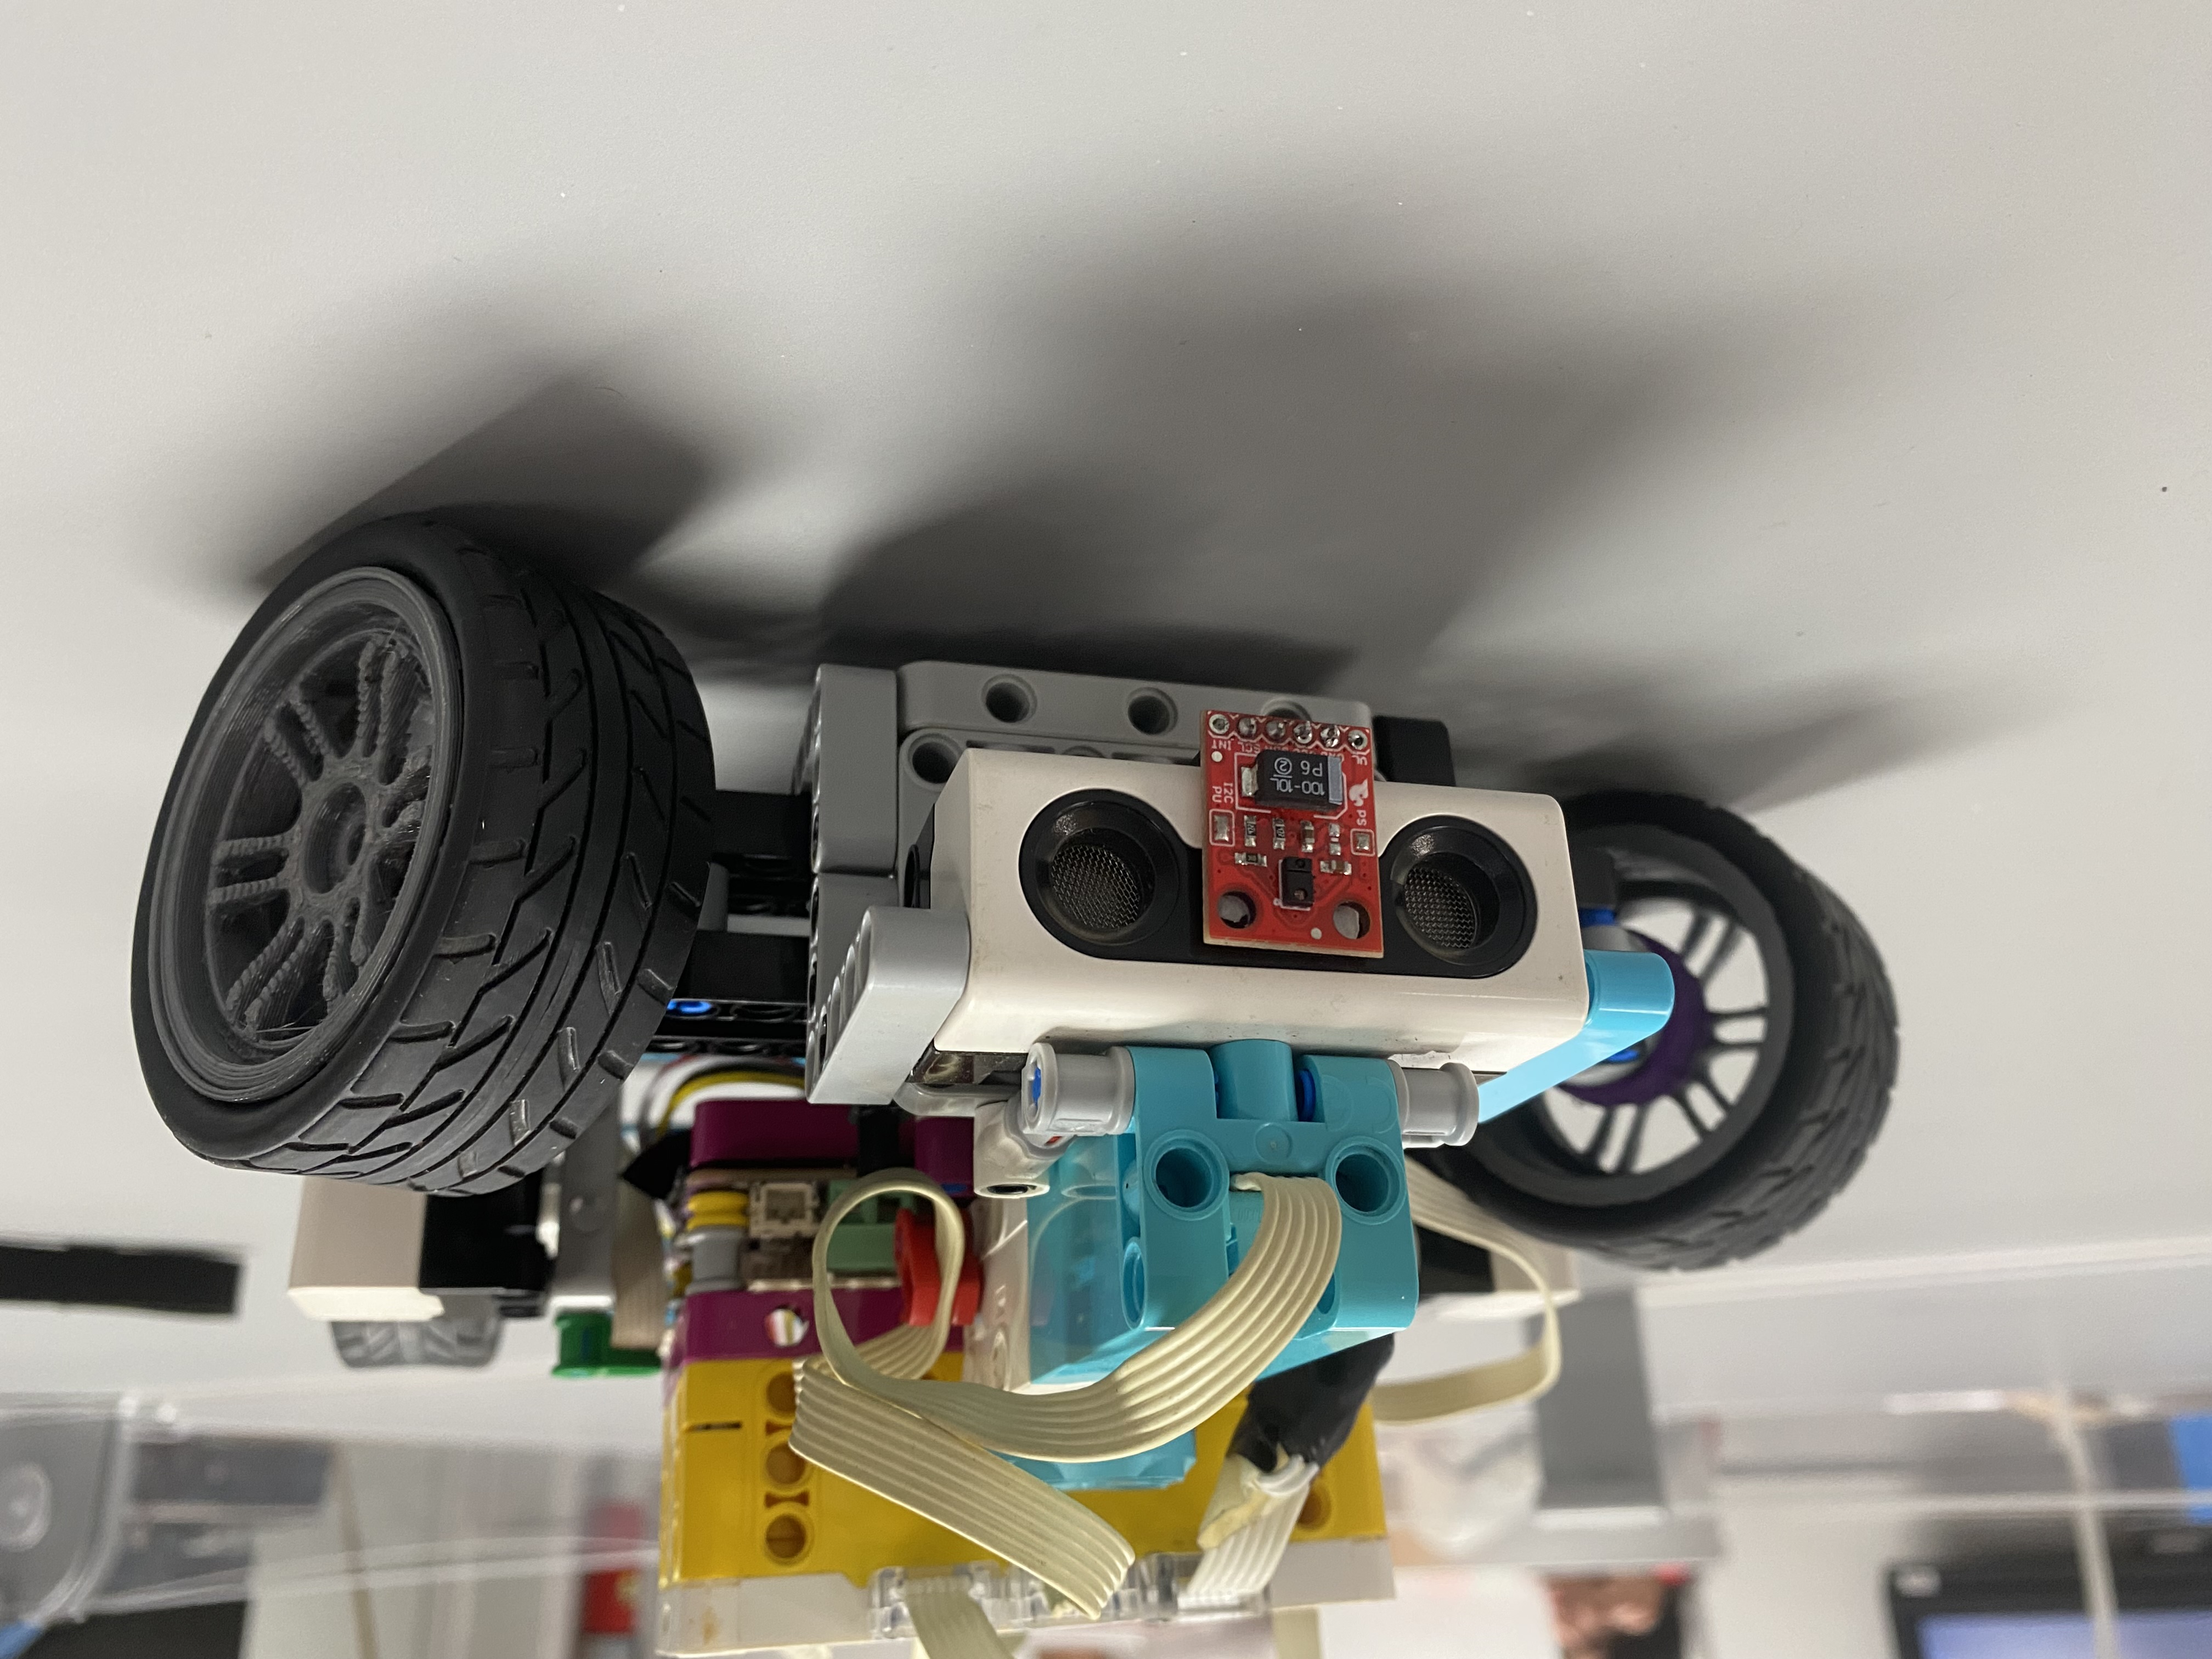 # Current state of V. Chew:
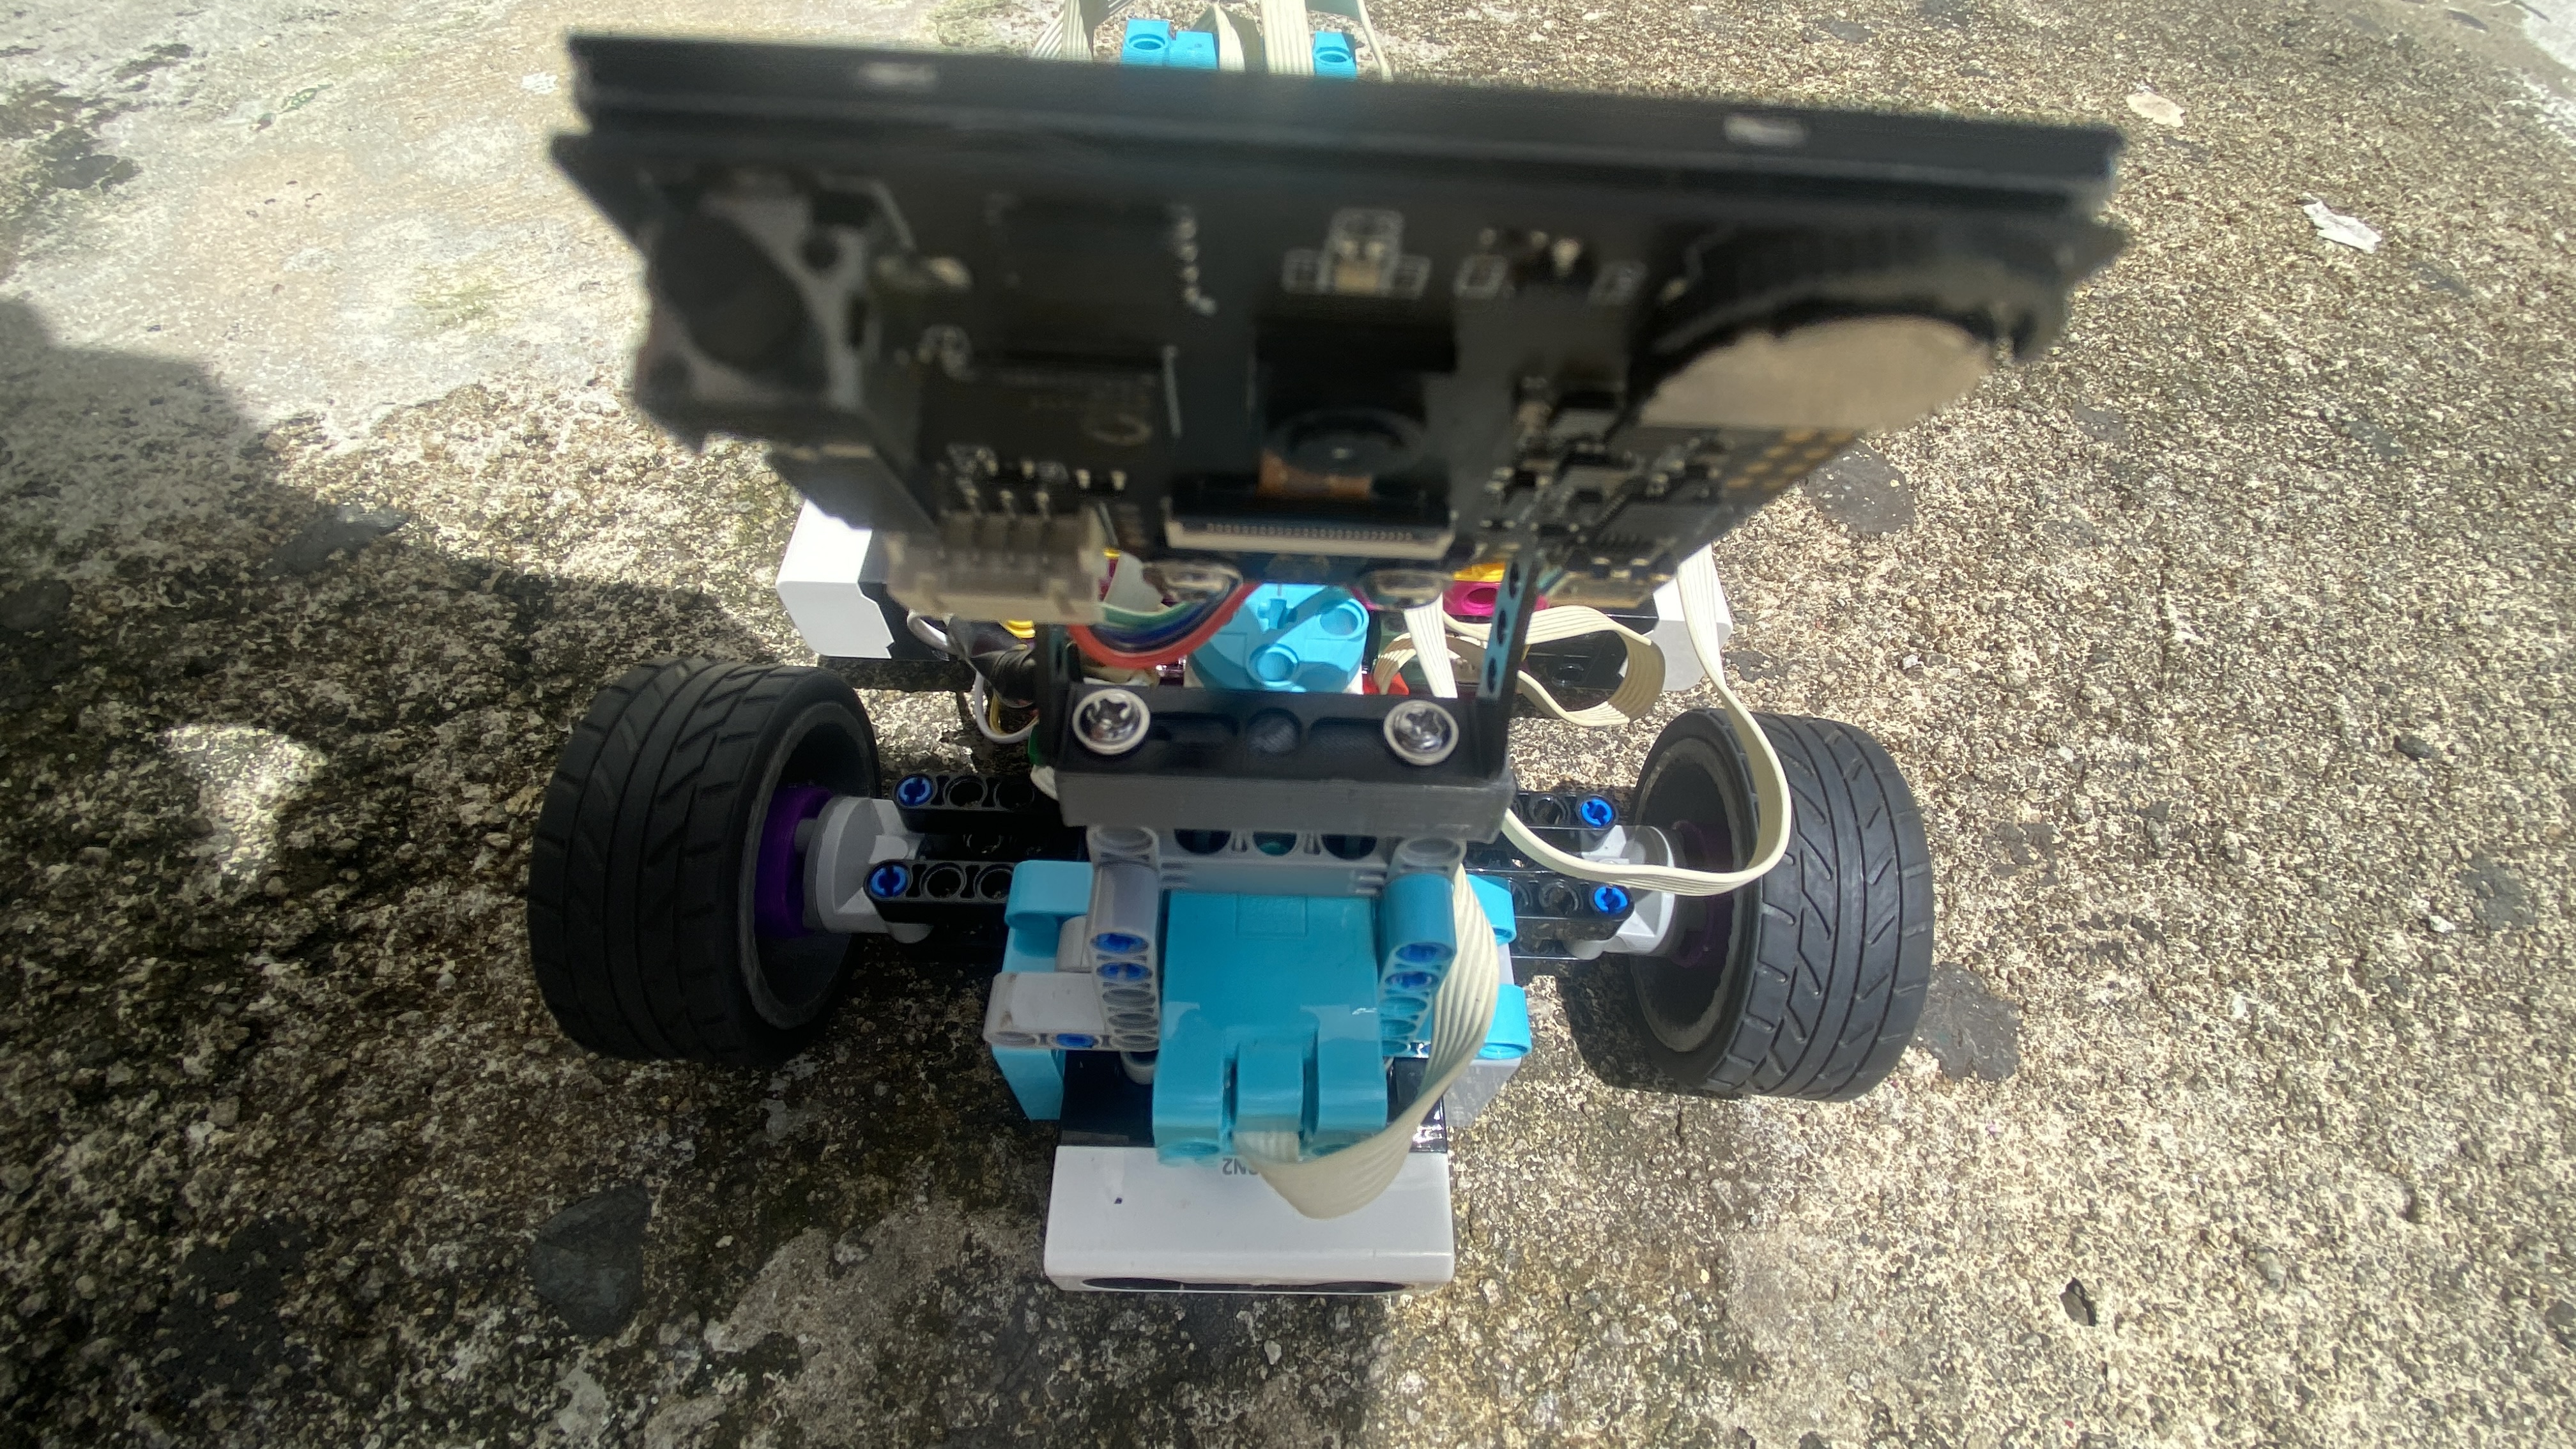 As of right now, we have decided to ditch the APDS 9960 for a [Huskylens 1 camera](https://wiki.dfrobot.com/sen0305) for more accuracy at longer distances.
Last weigh in of V. Chew he weighed 819 grams, he's still 24.5 cm long and 19.5 cm wide, but due to where the camera is mounted he's now 19 cm tall. All in, these are all the electronics we have on V. Chew:
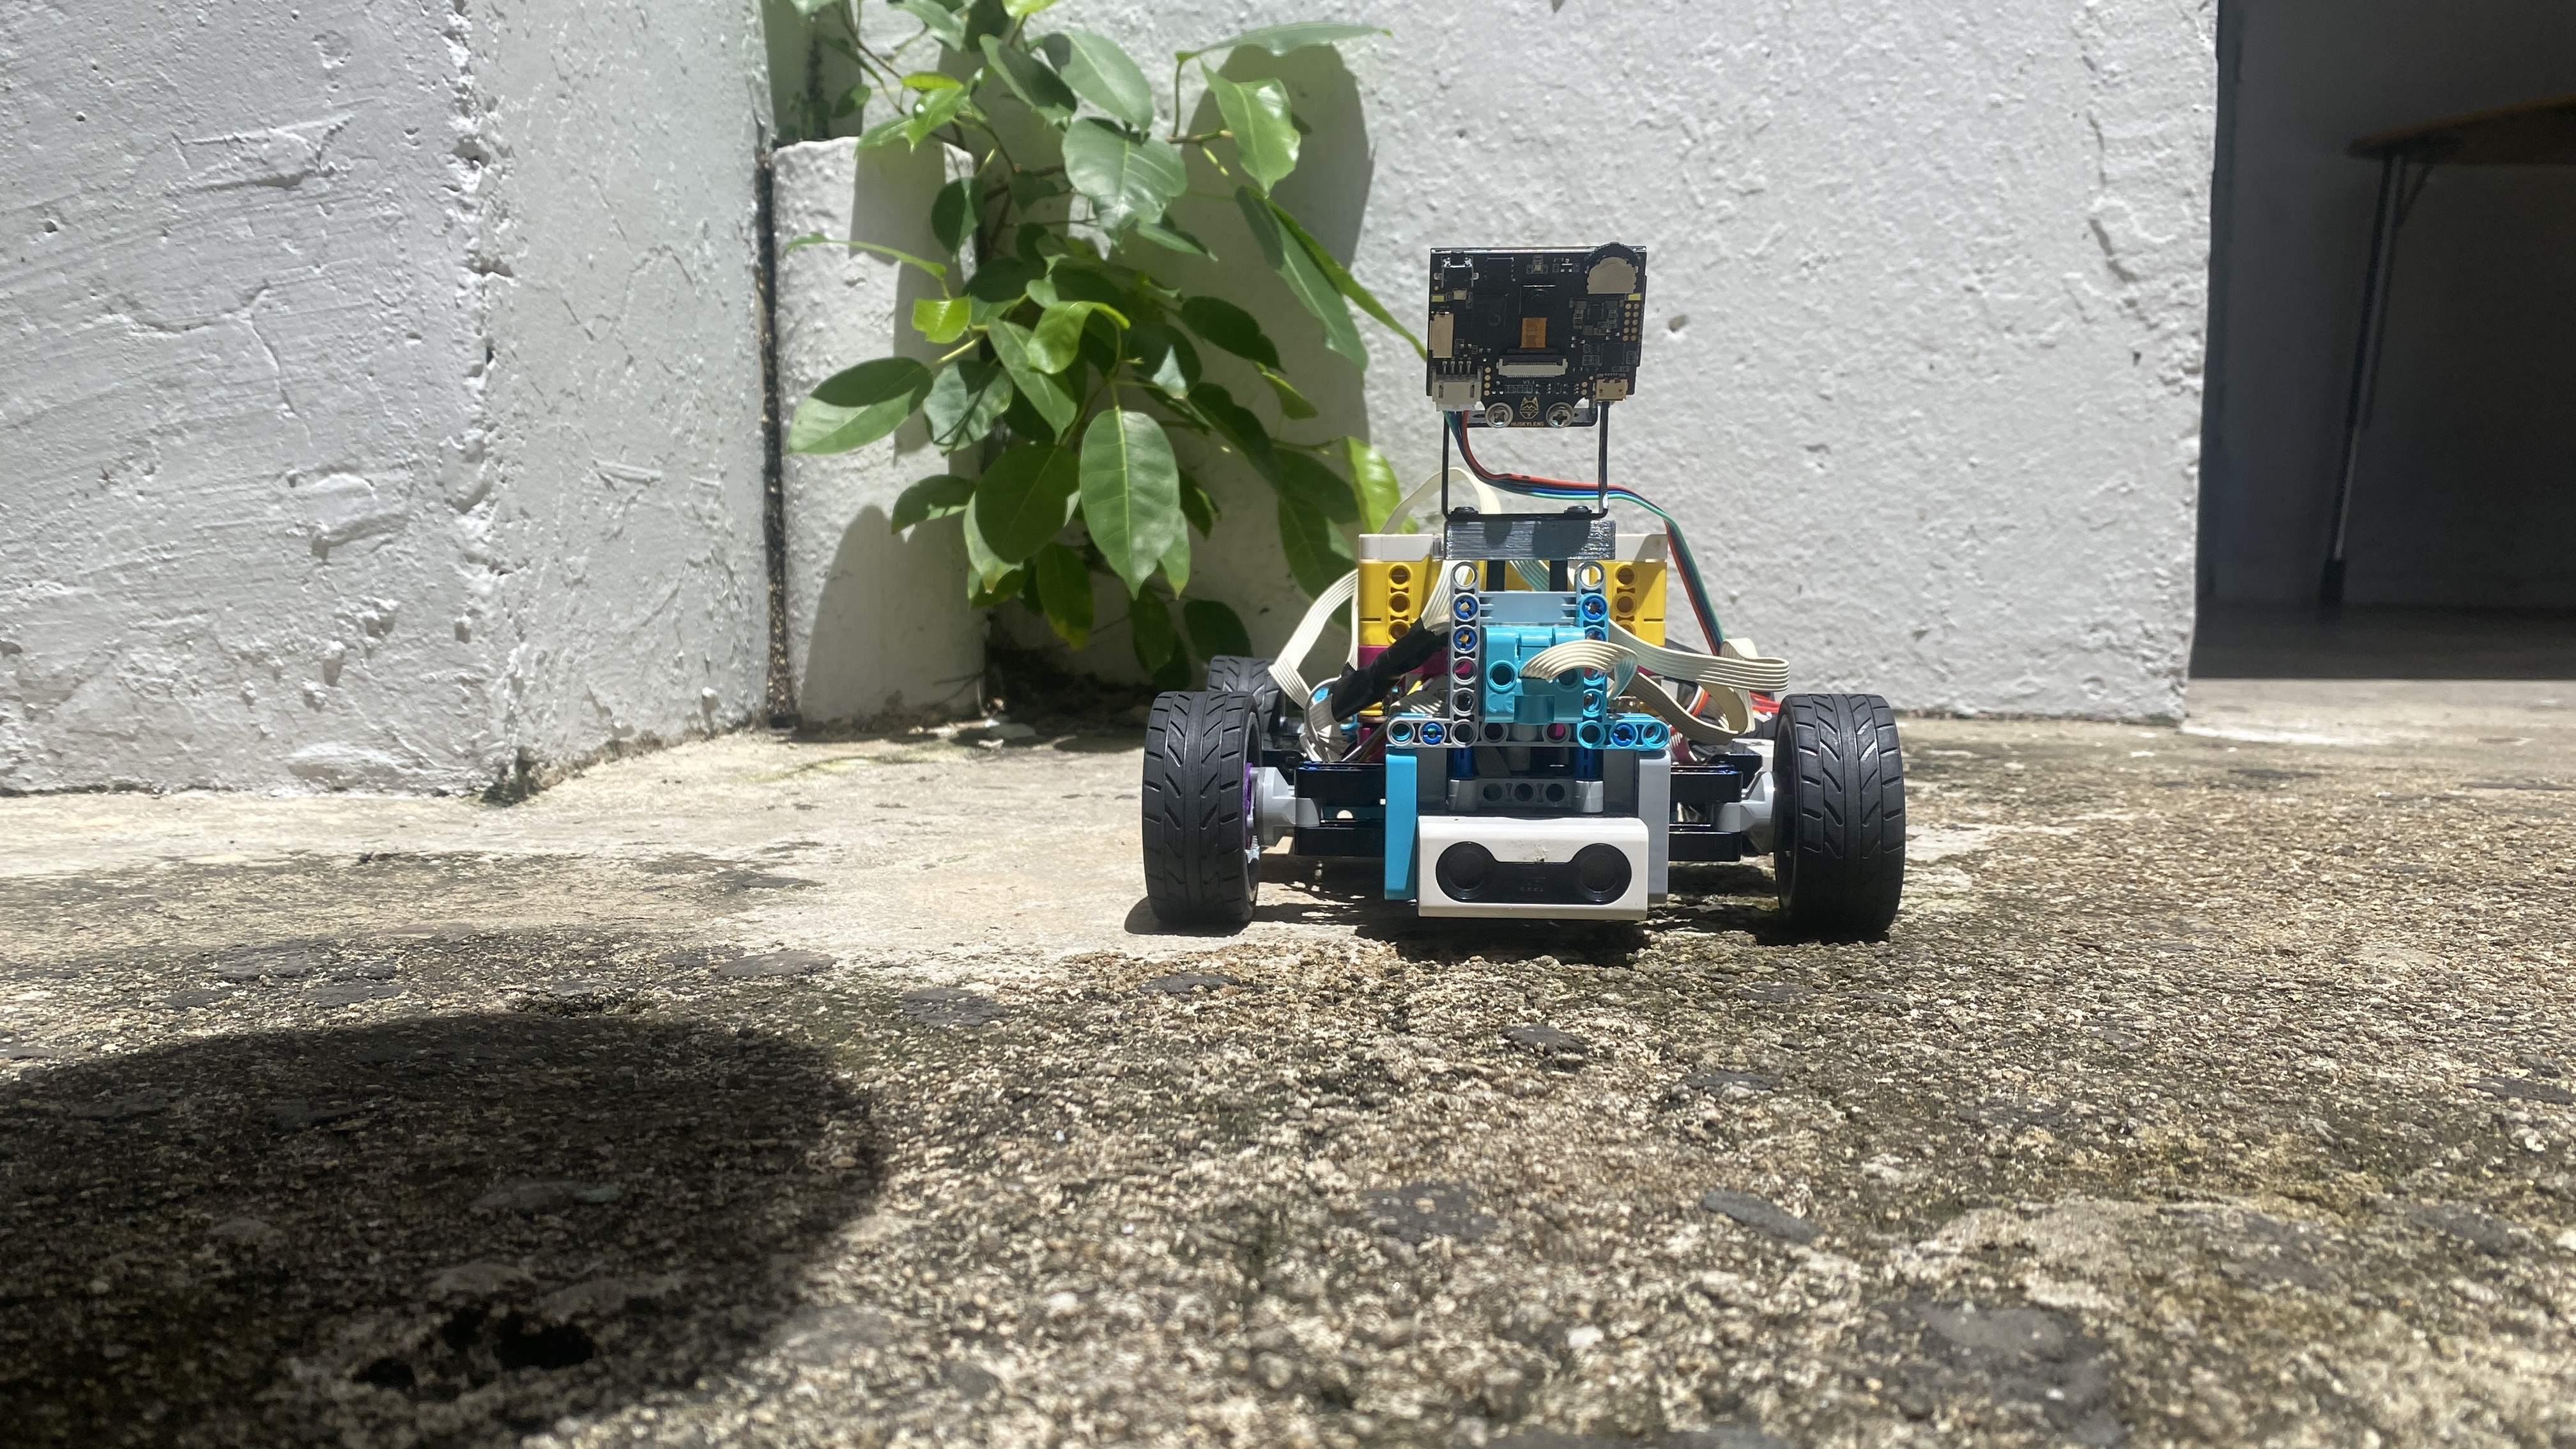 Front
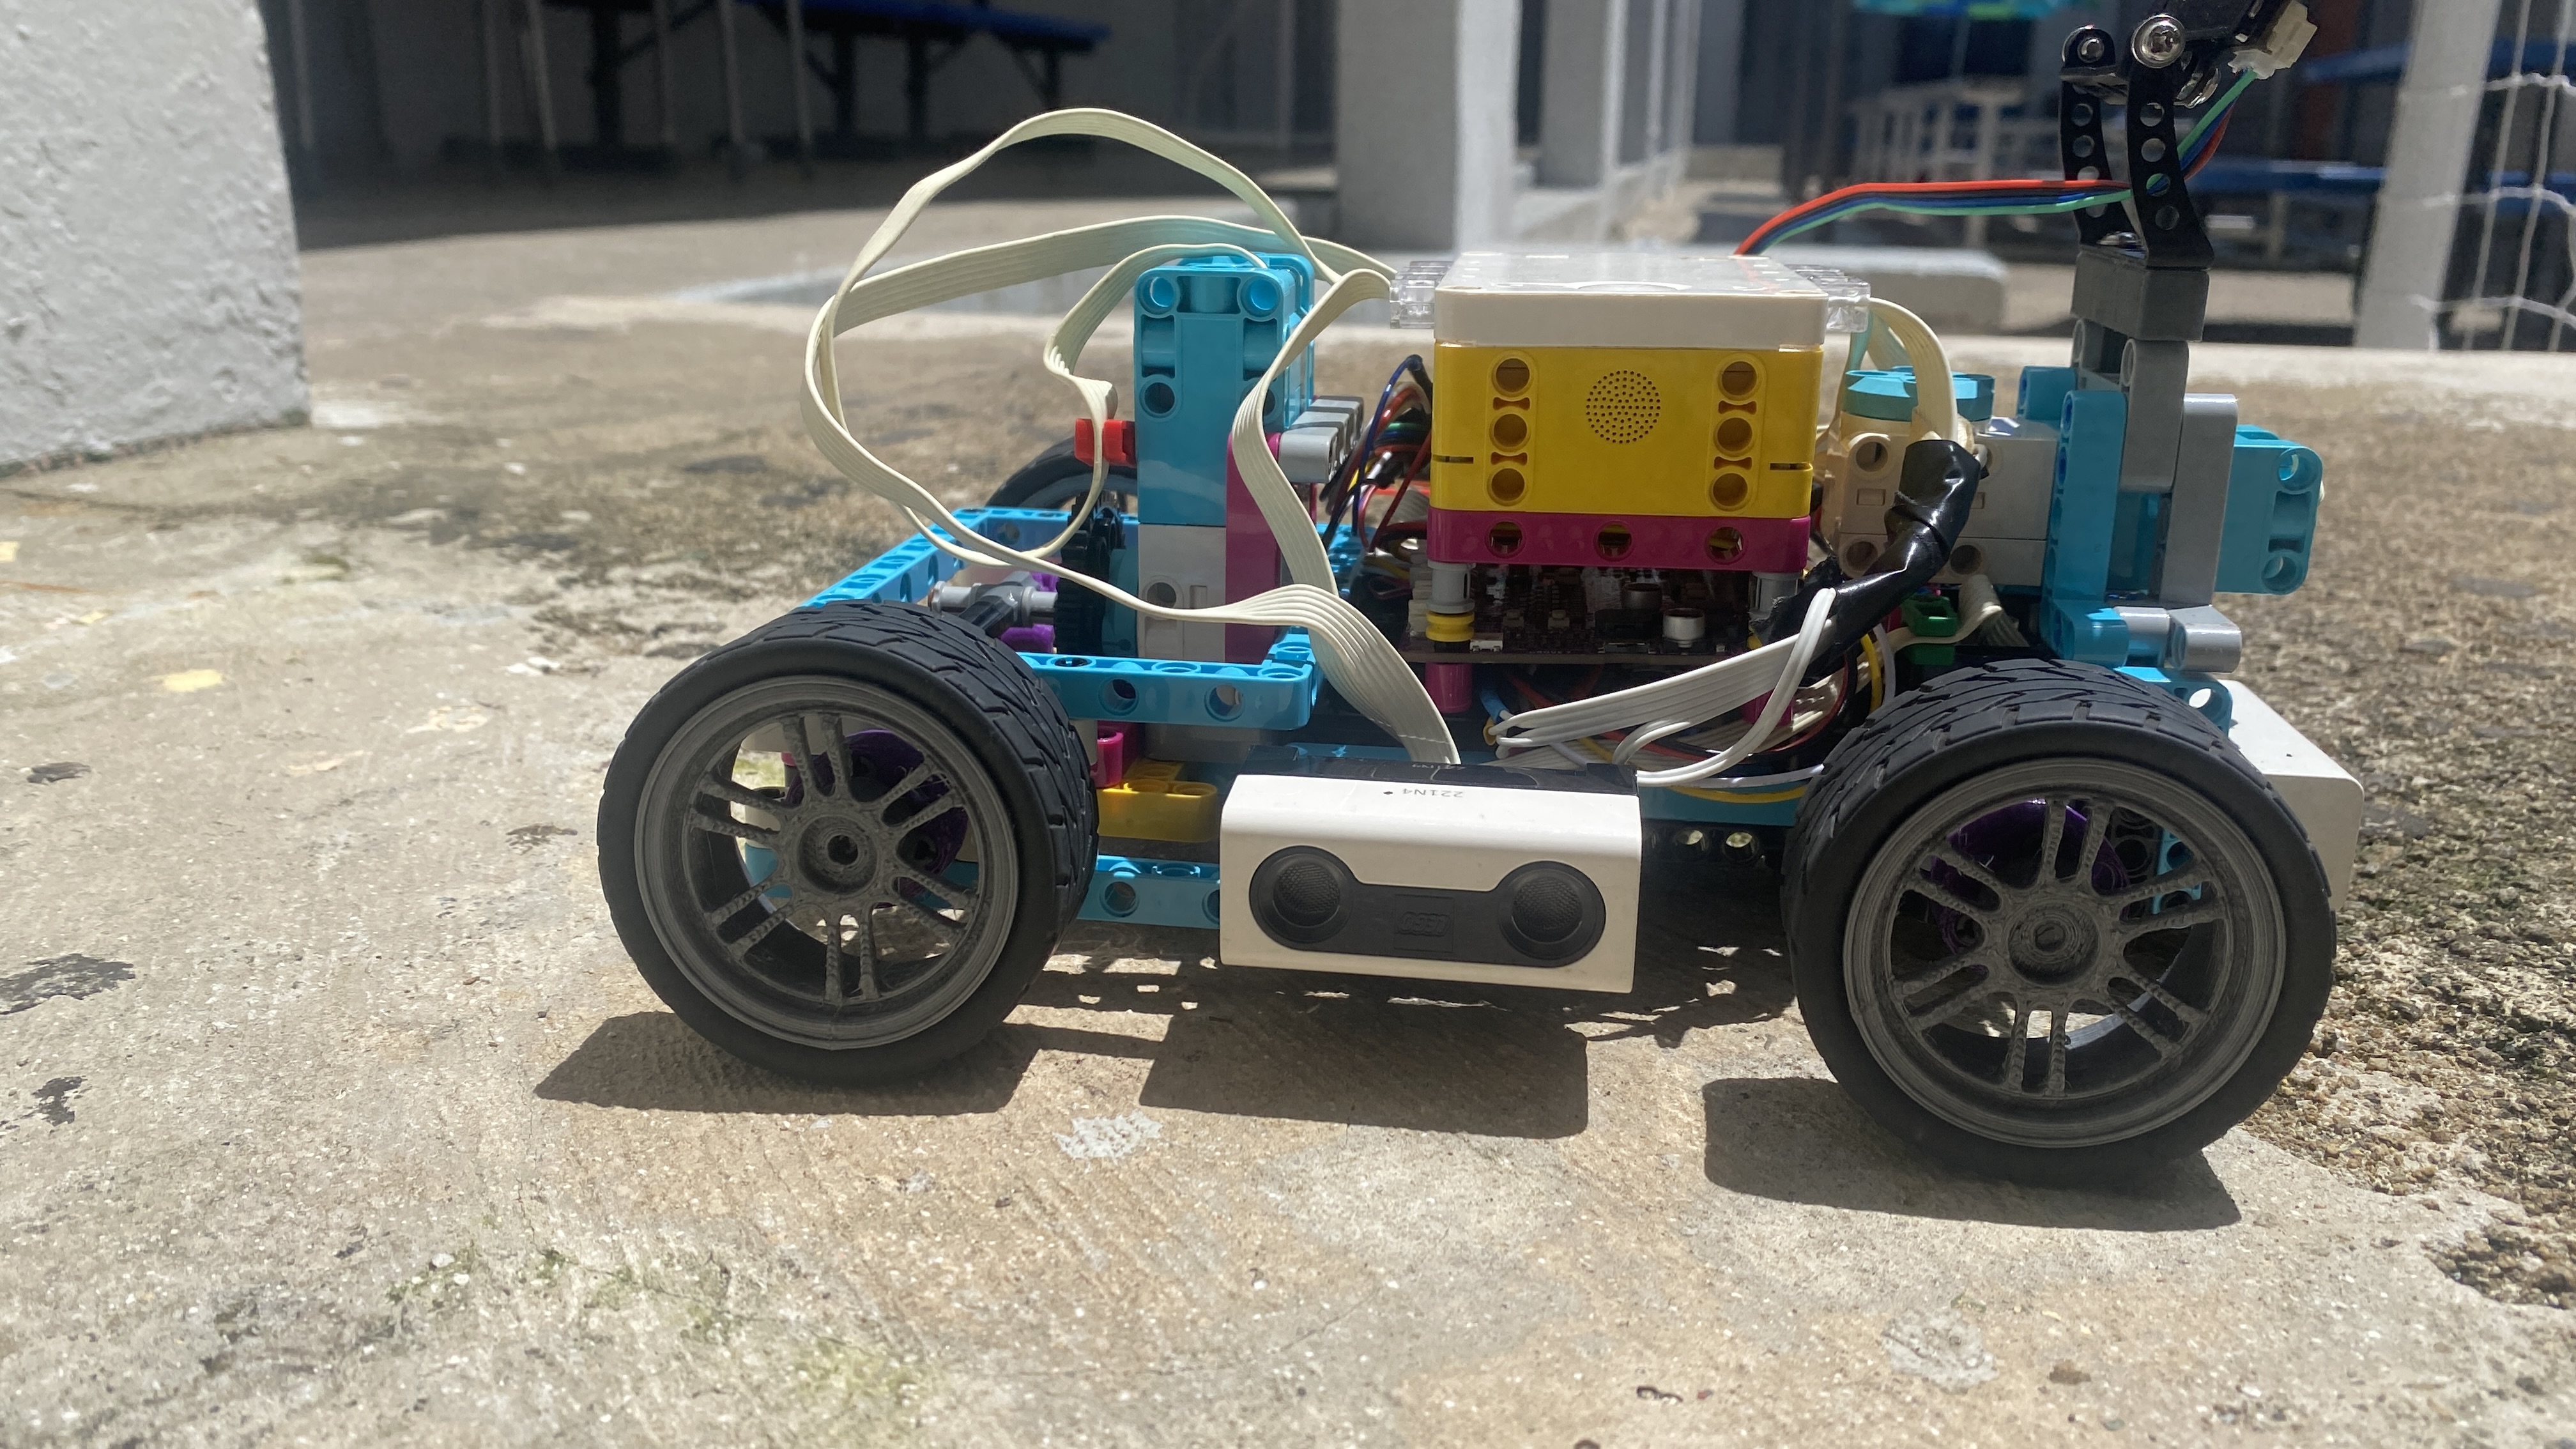 Right Side
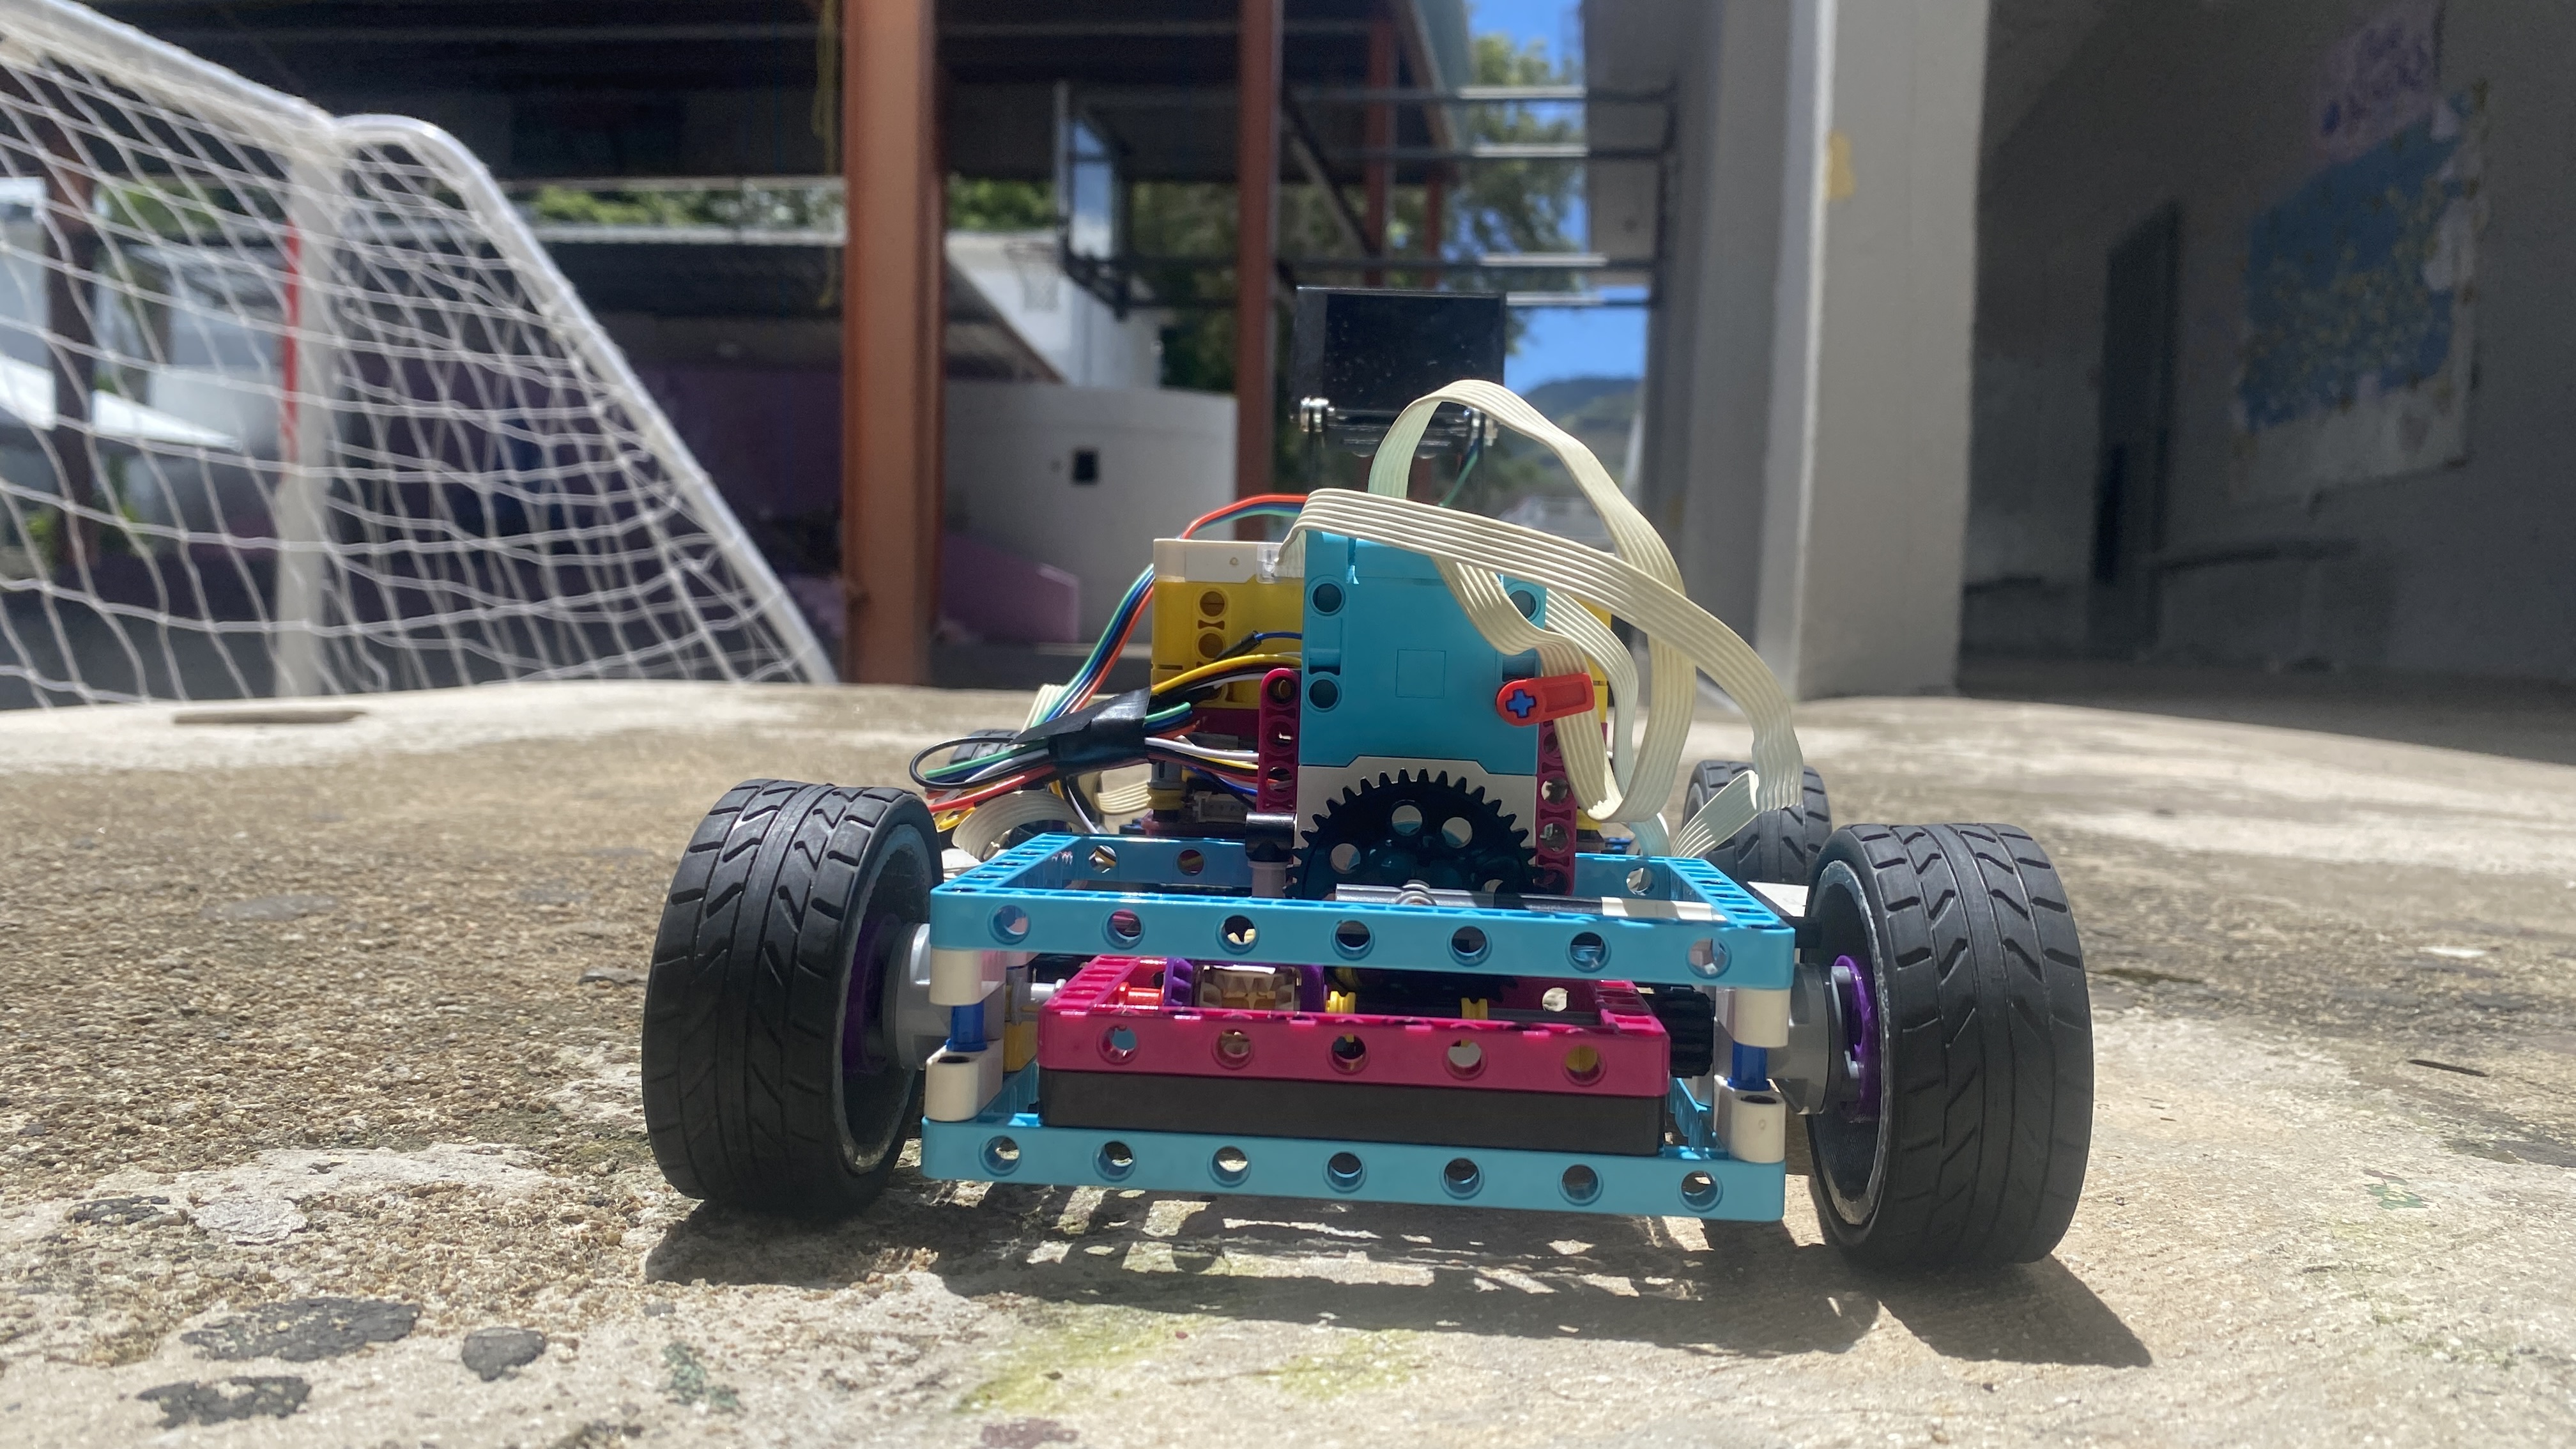 Rear
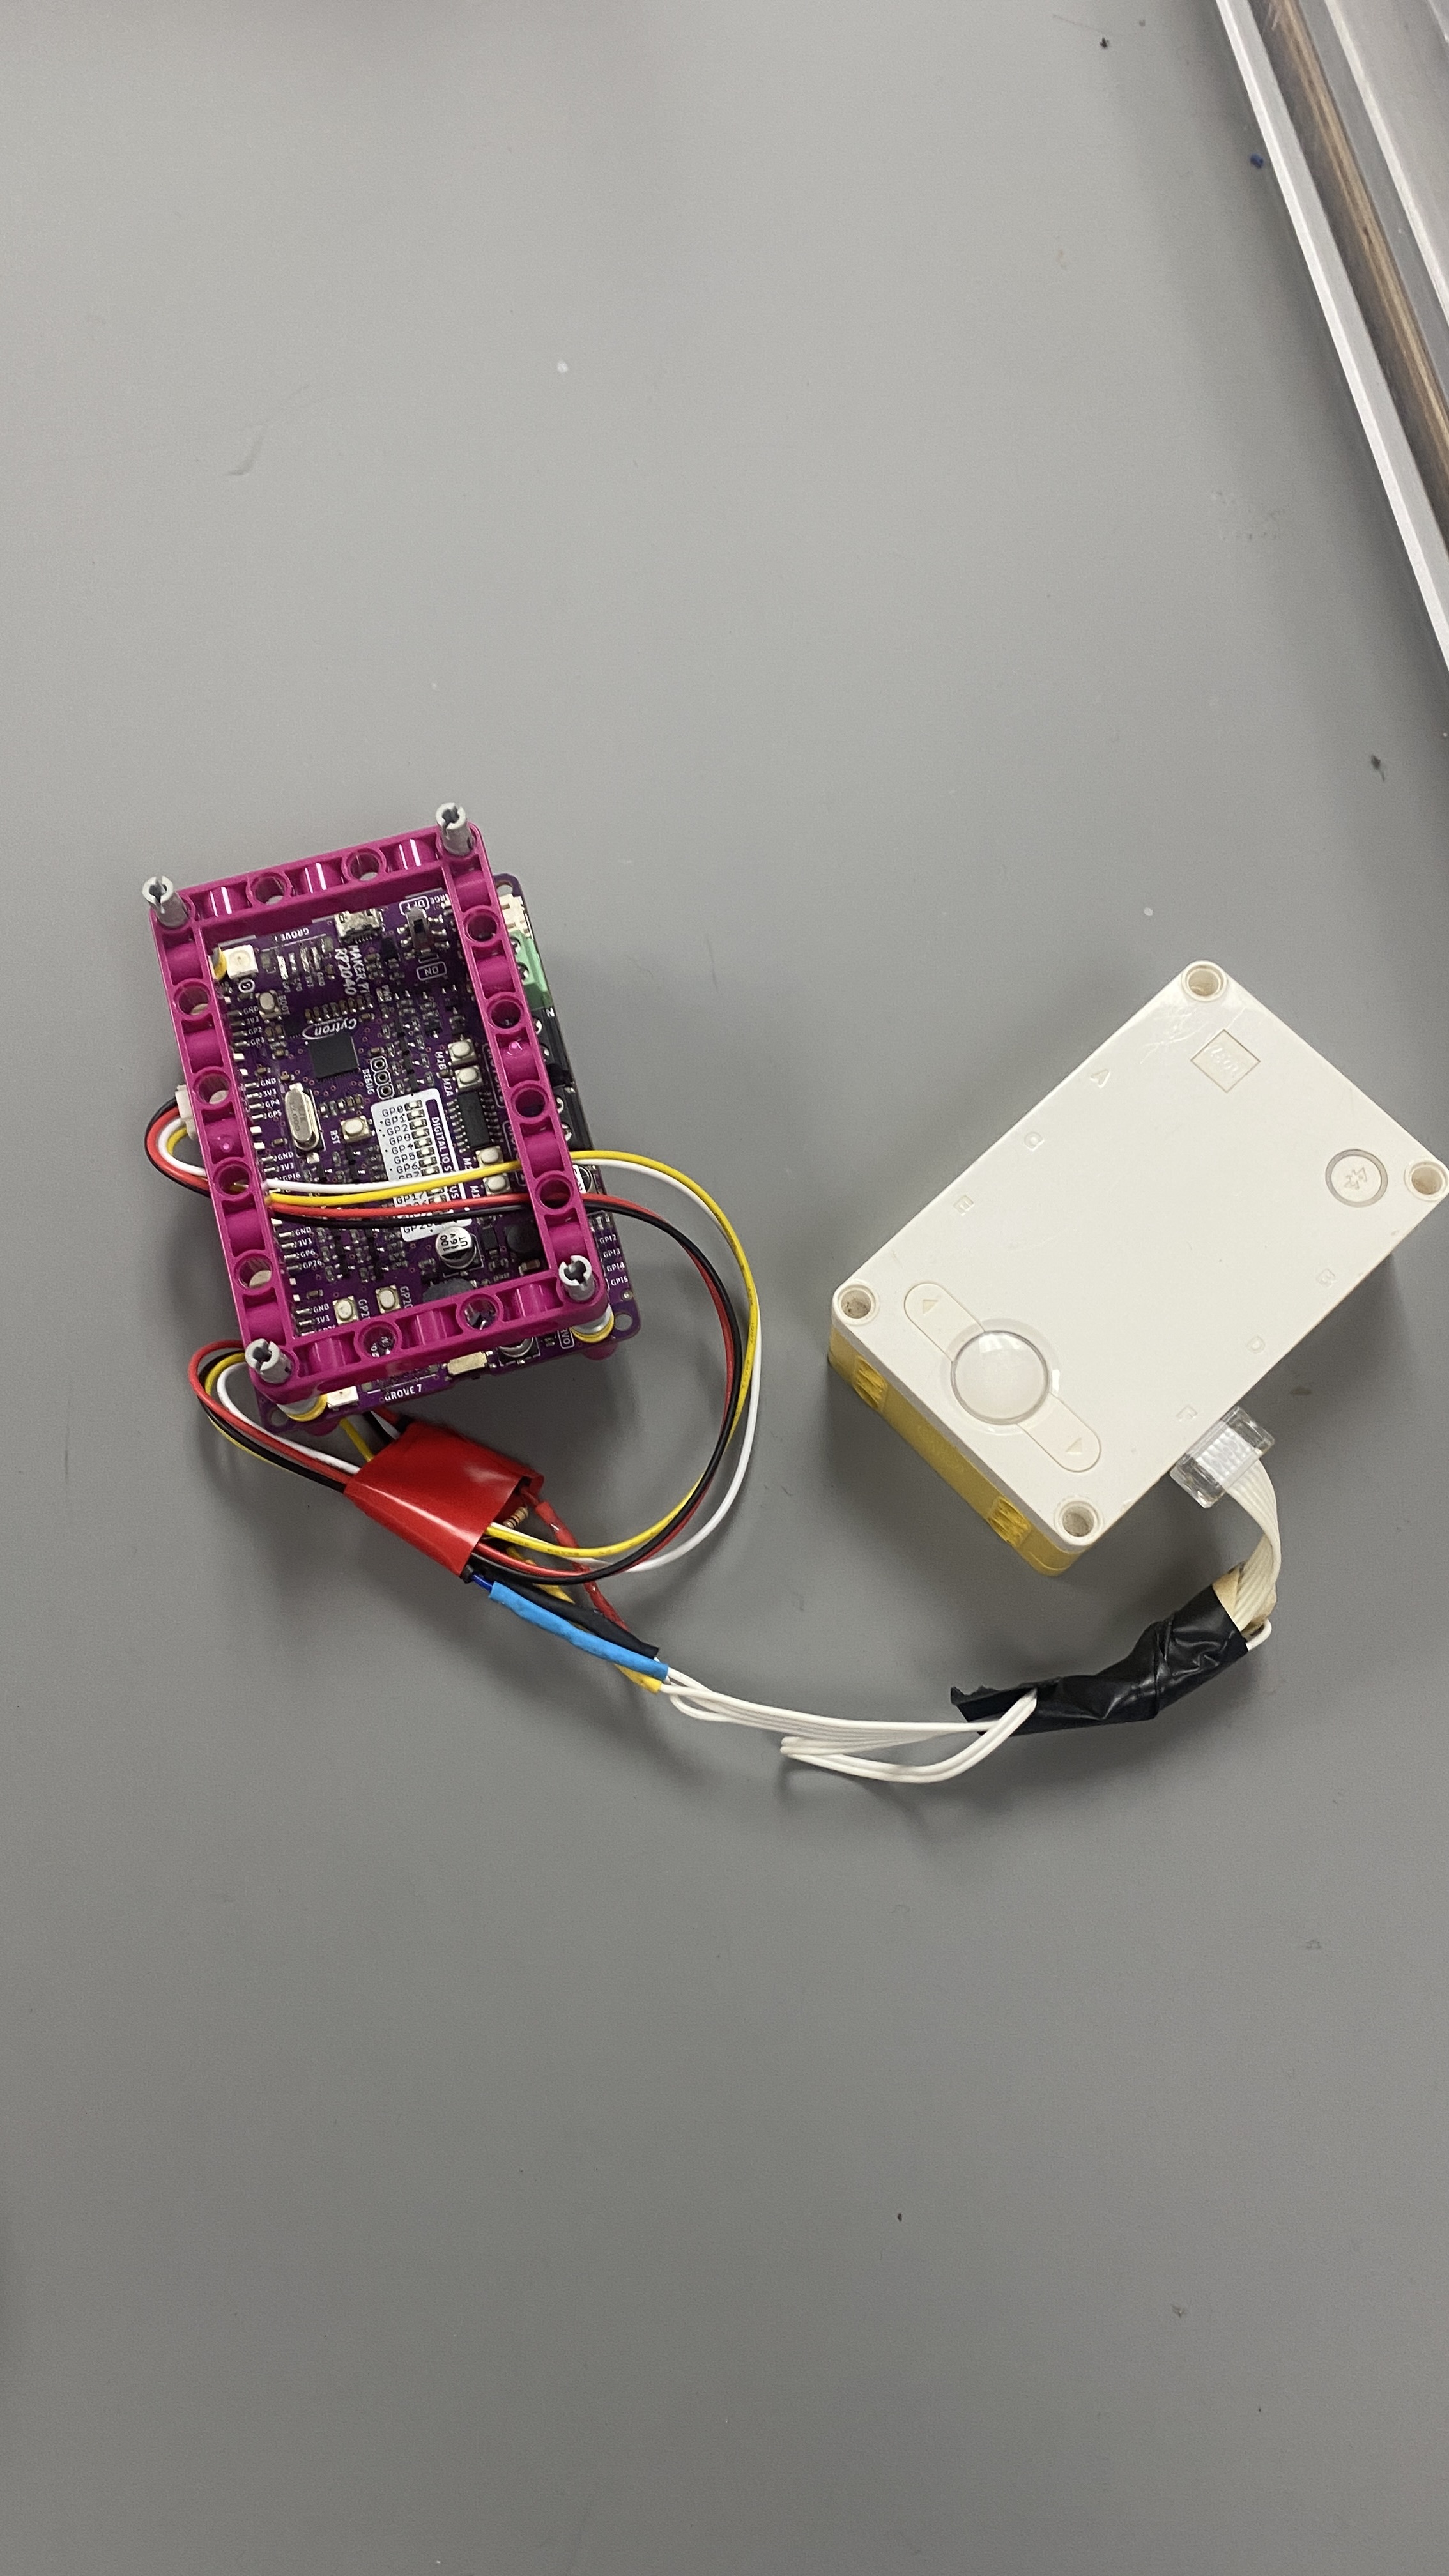 The Hub and RP2040
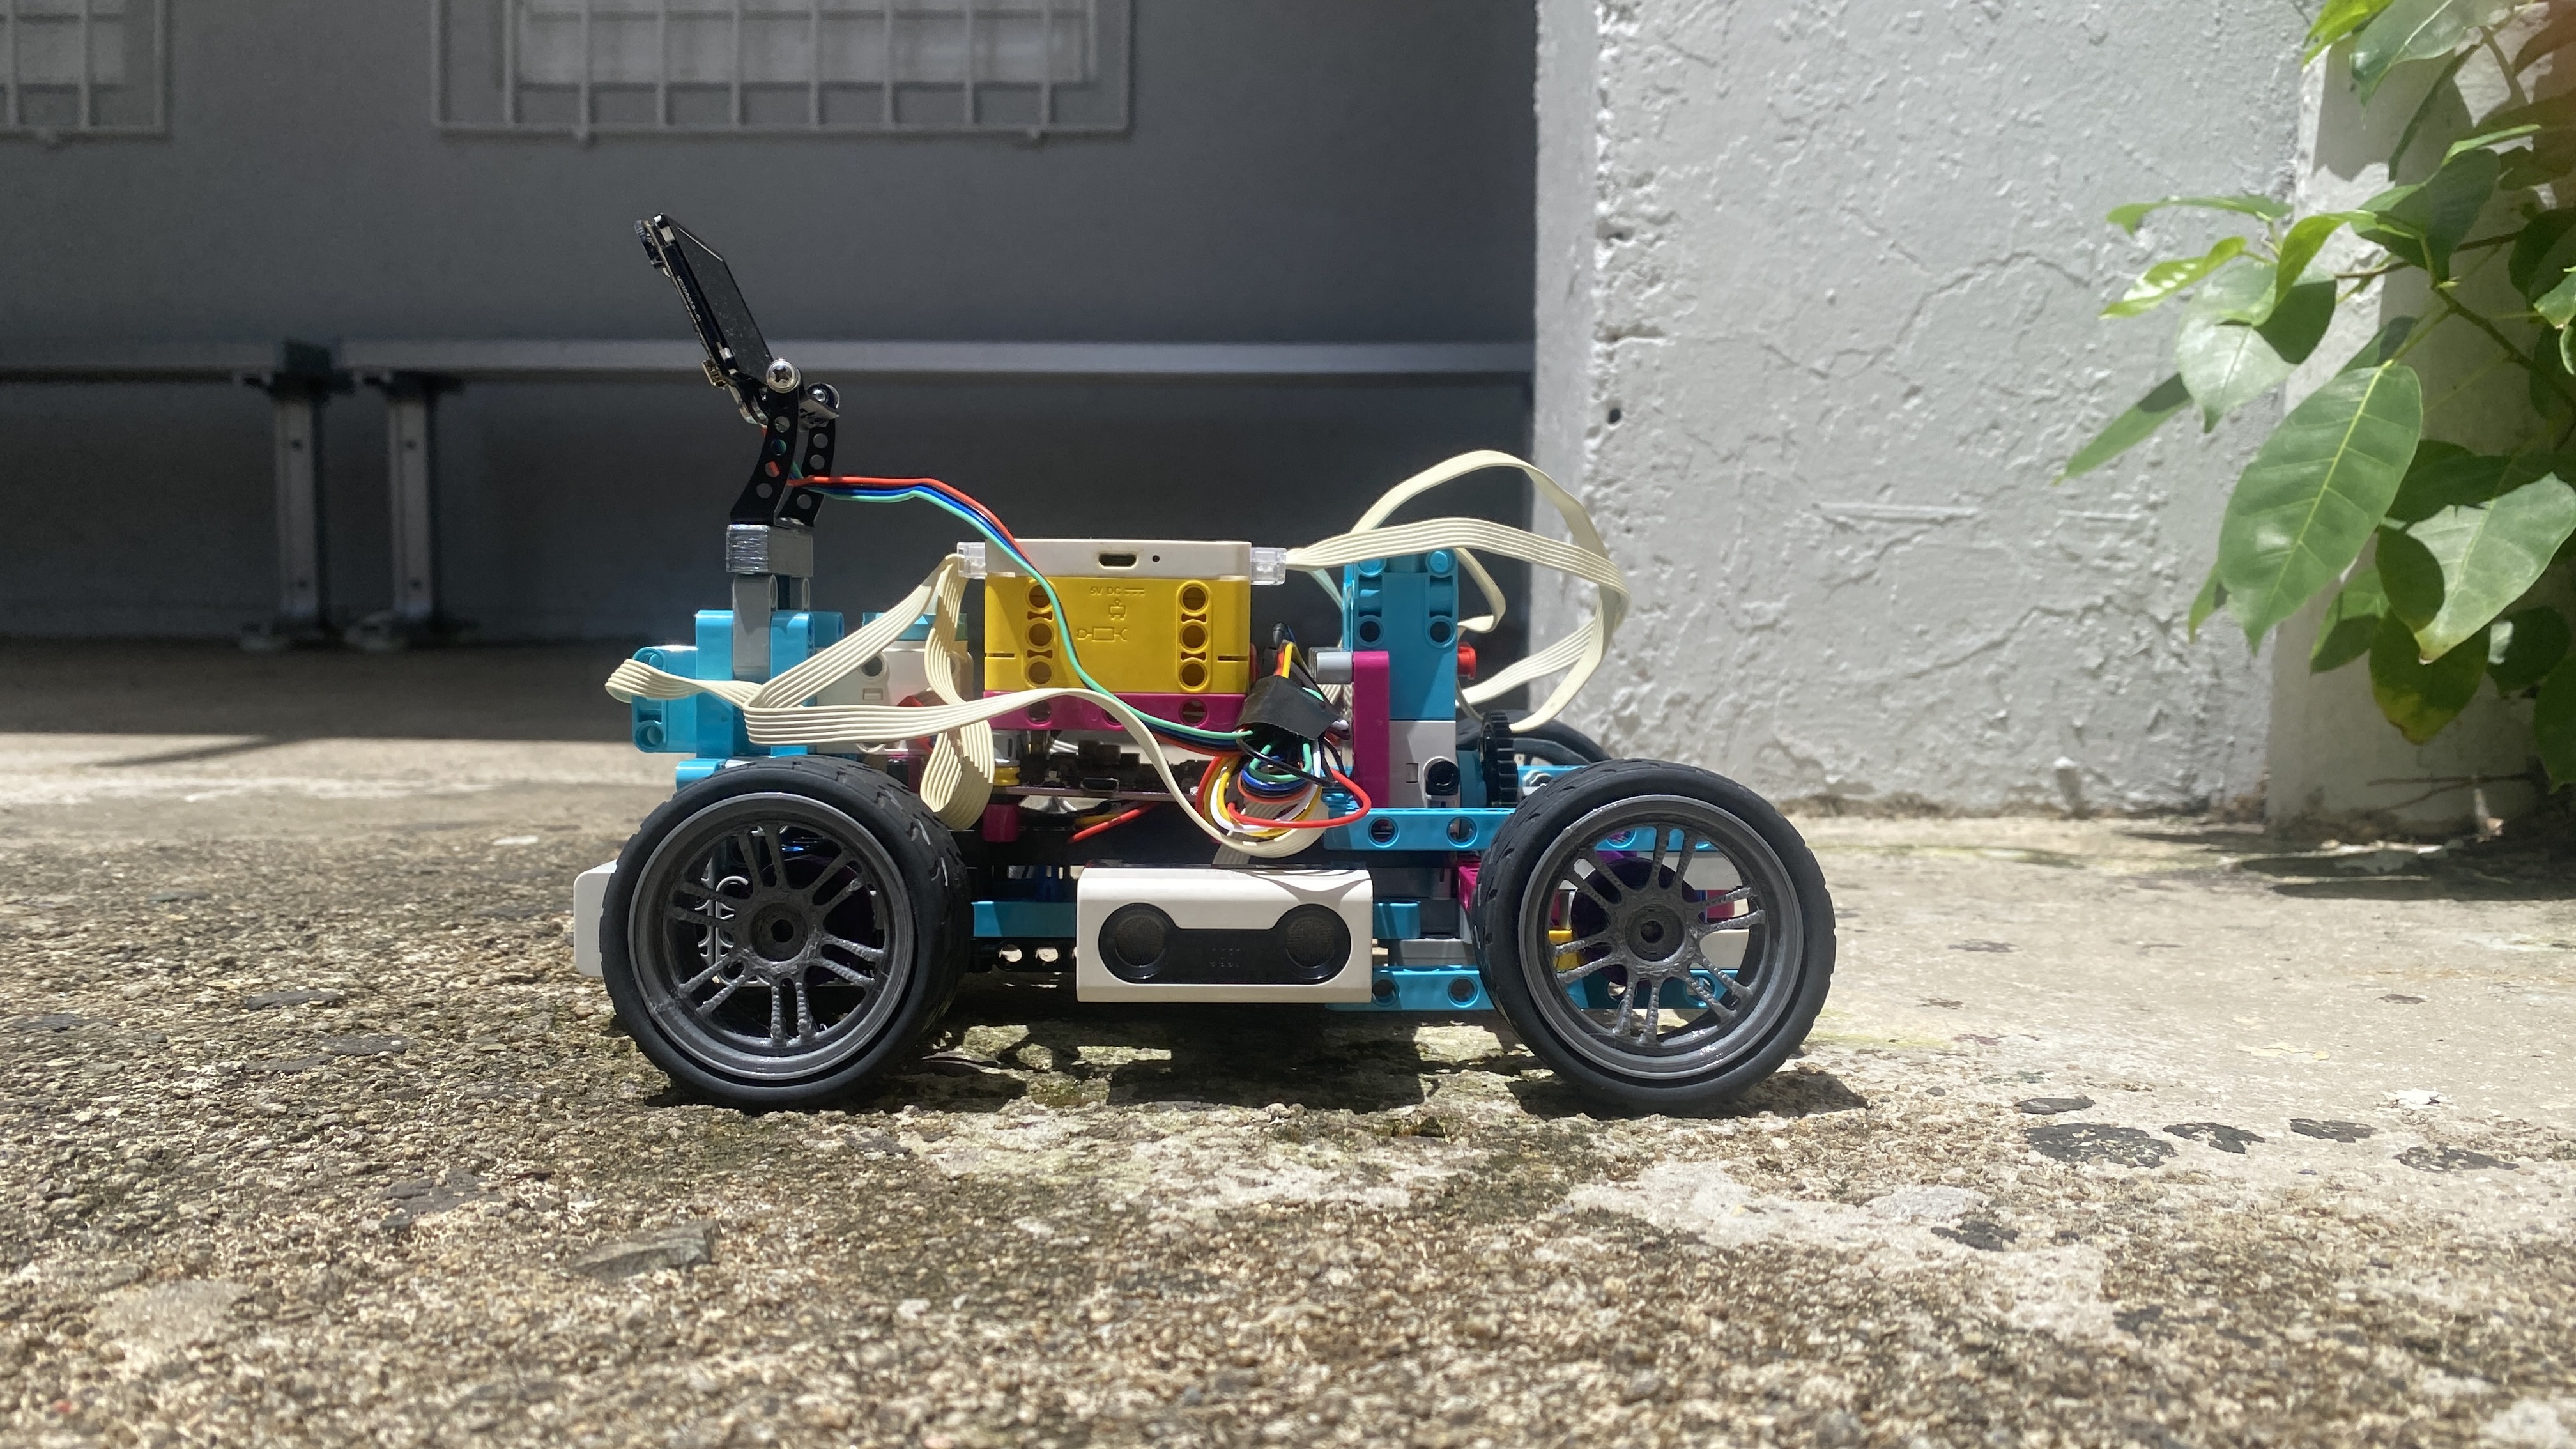 Left Side
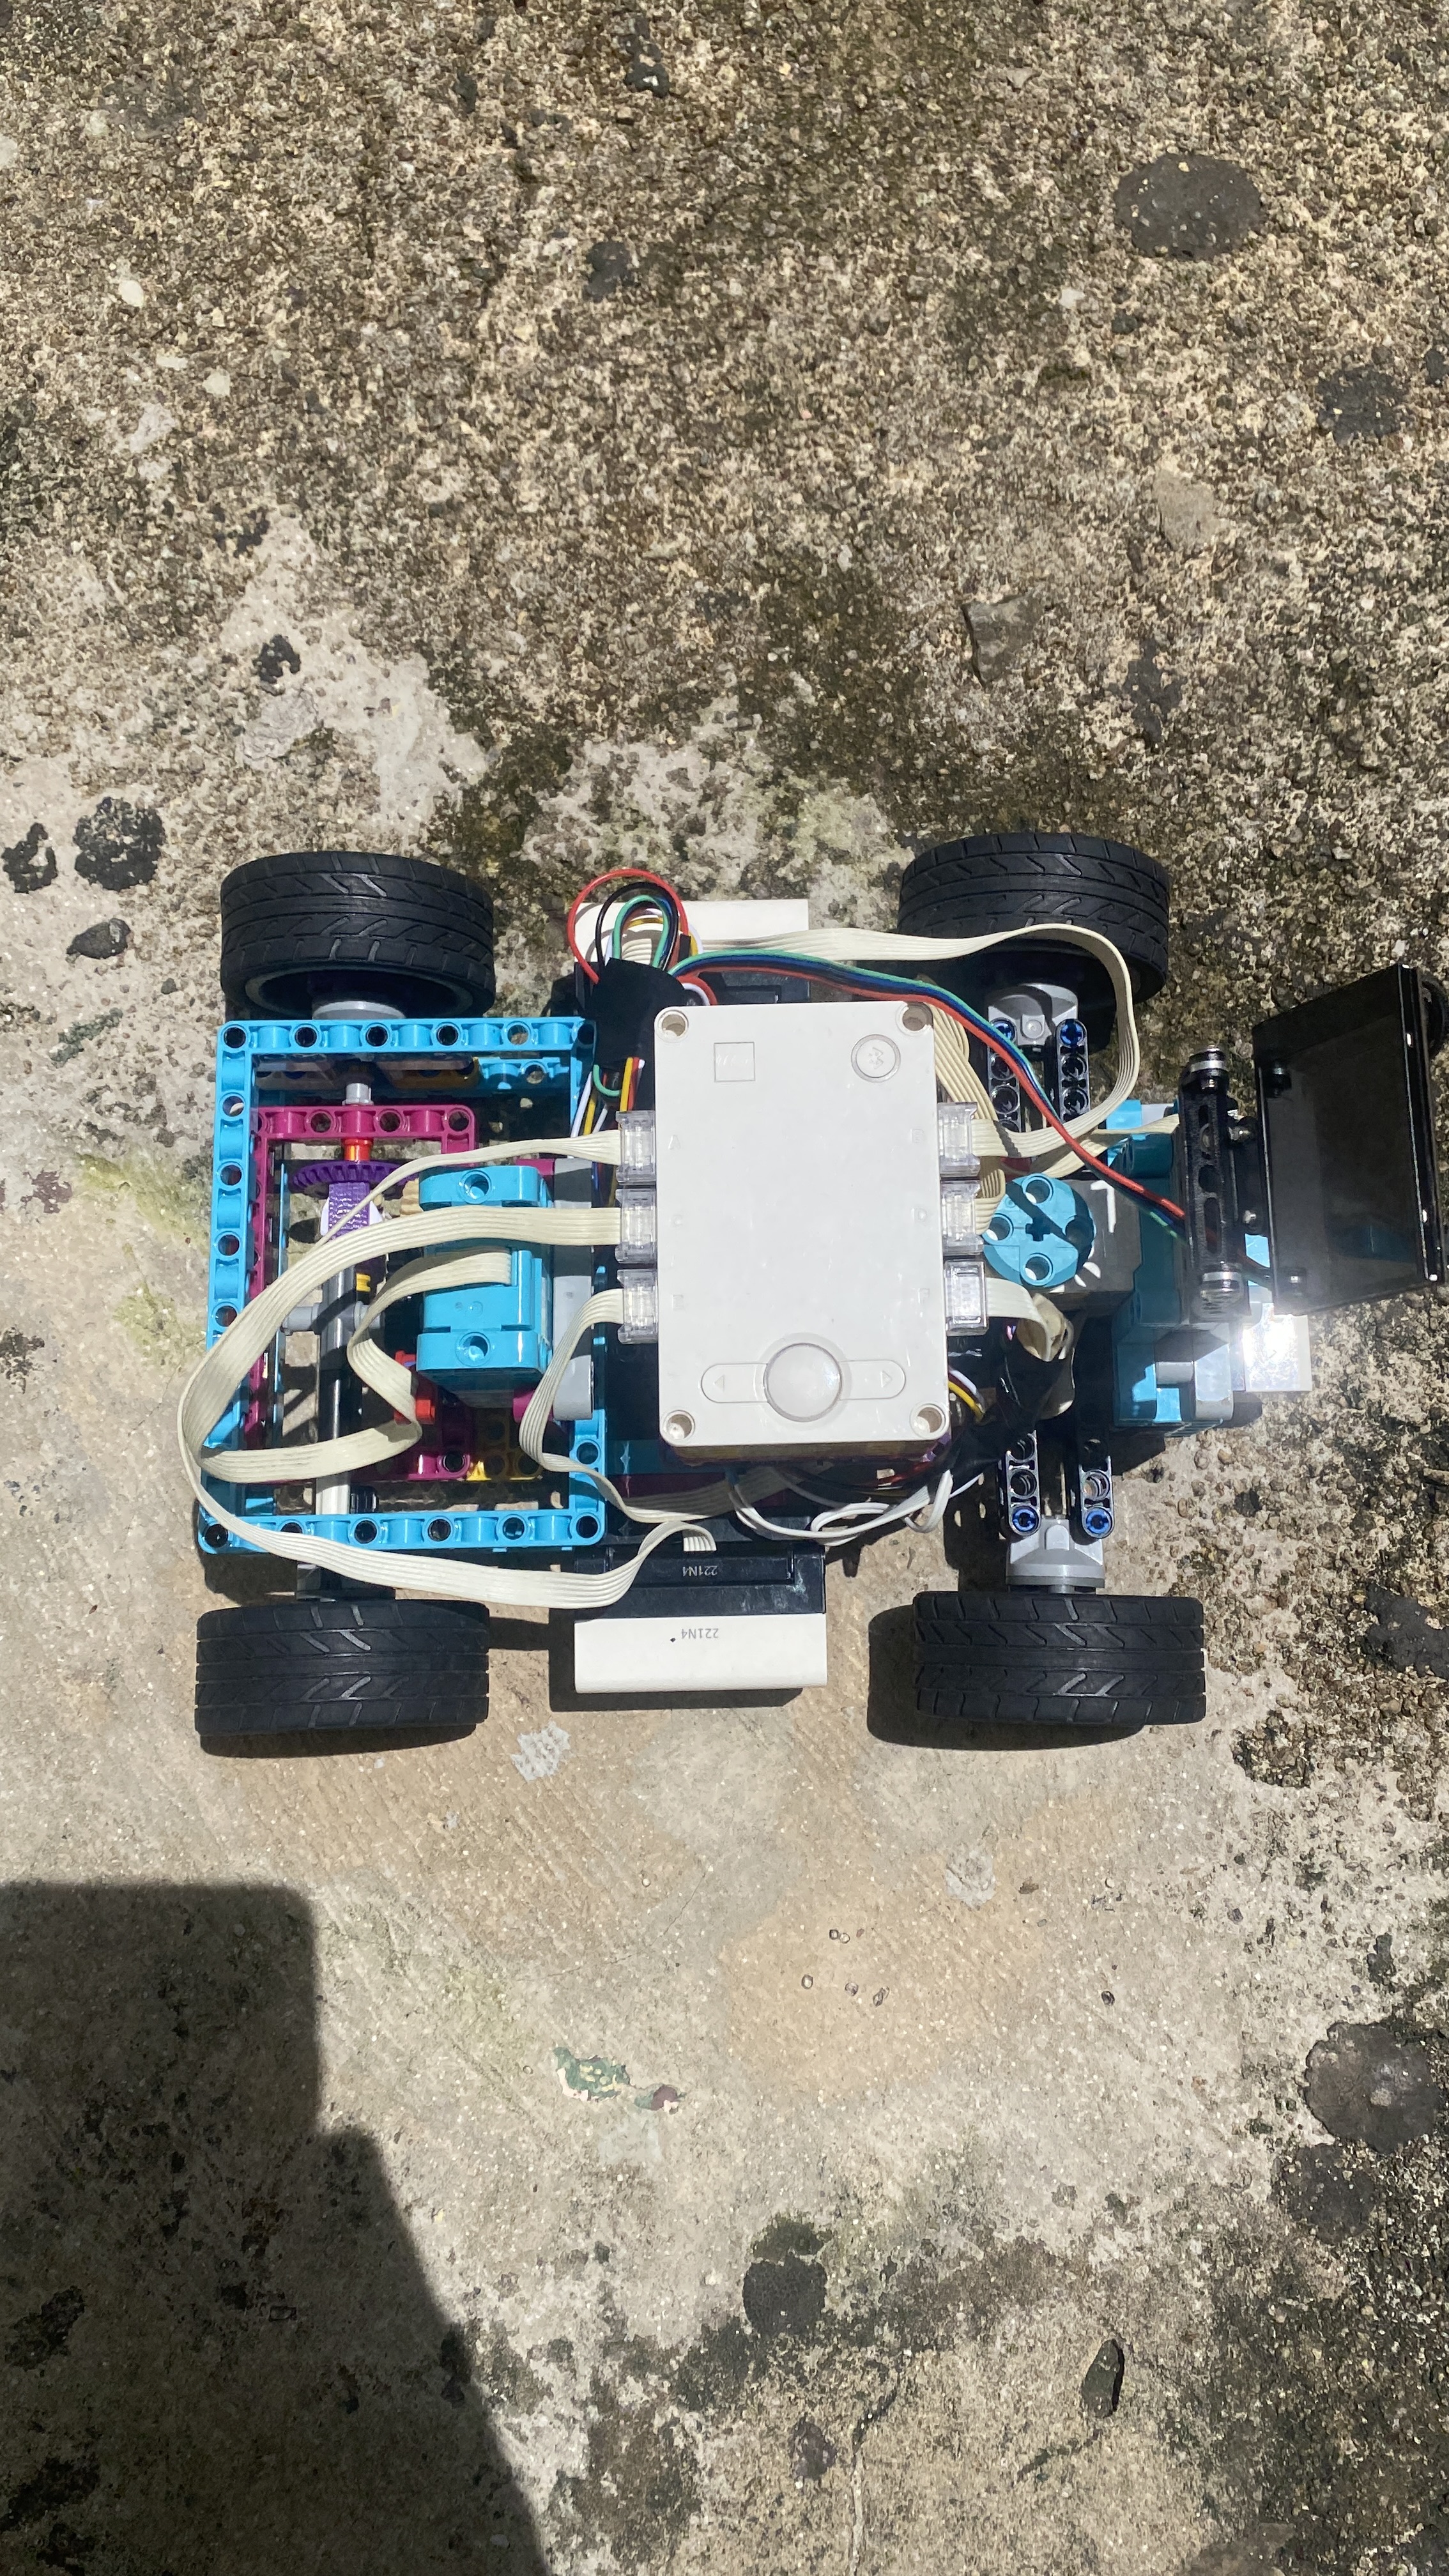 Top Down
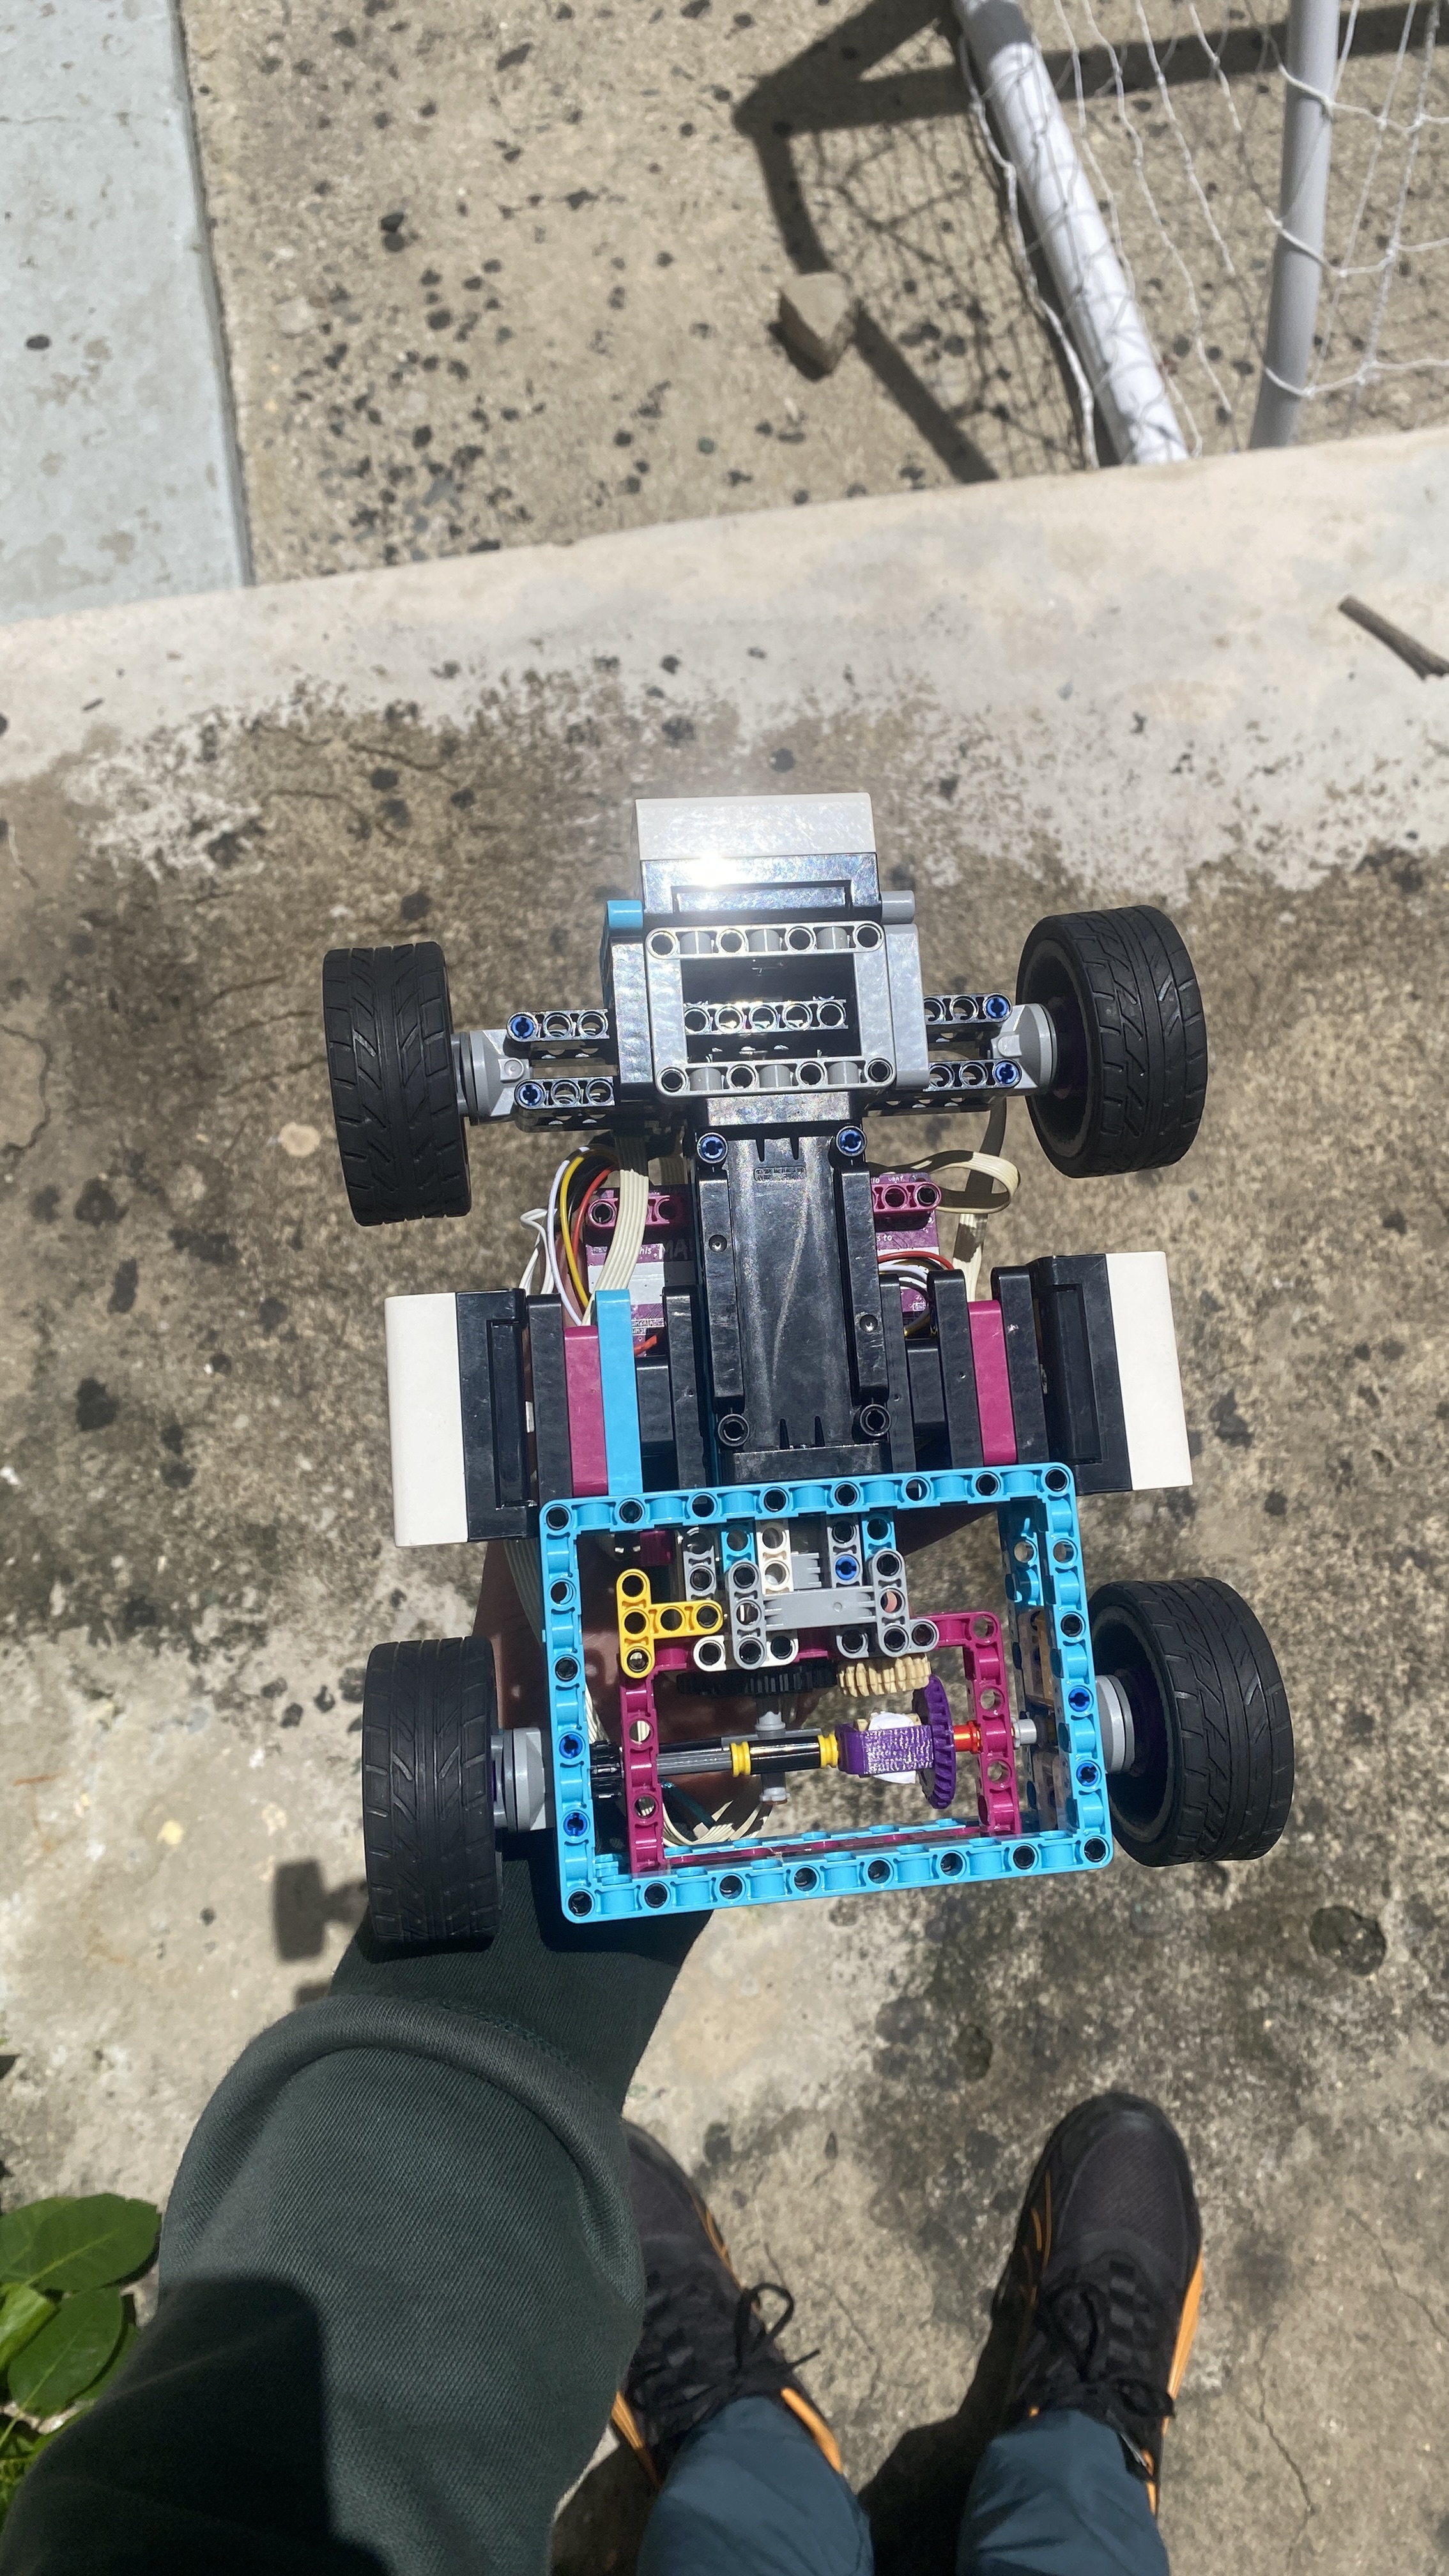 Bottom Up
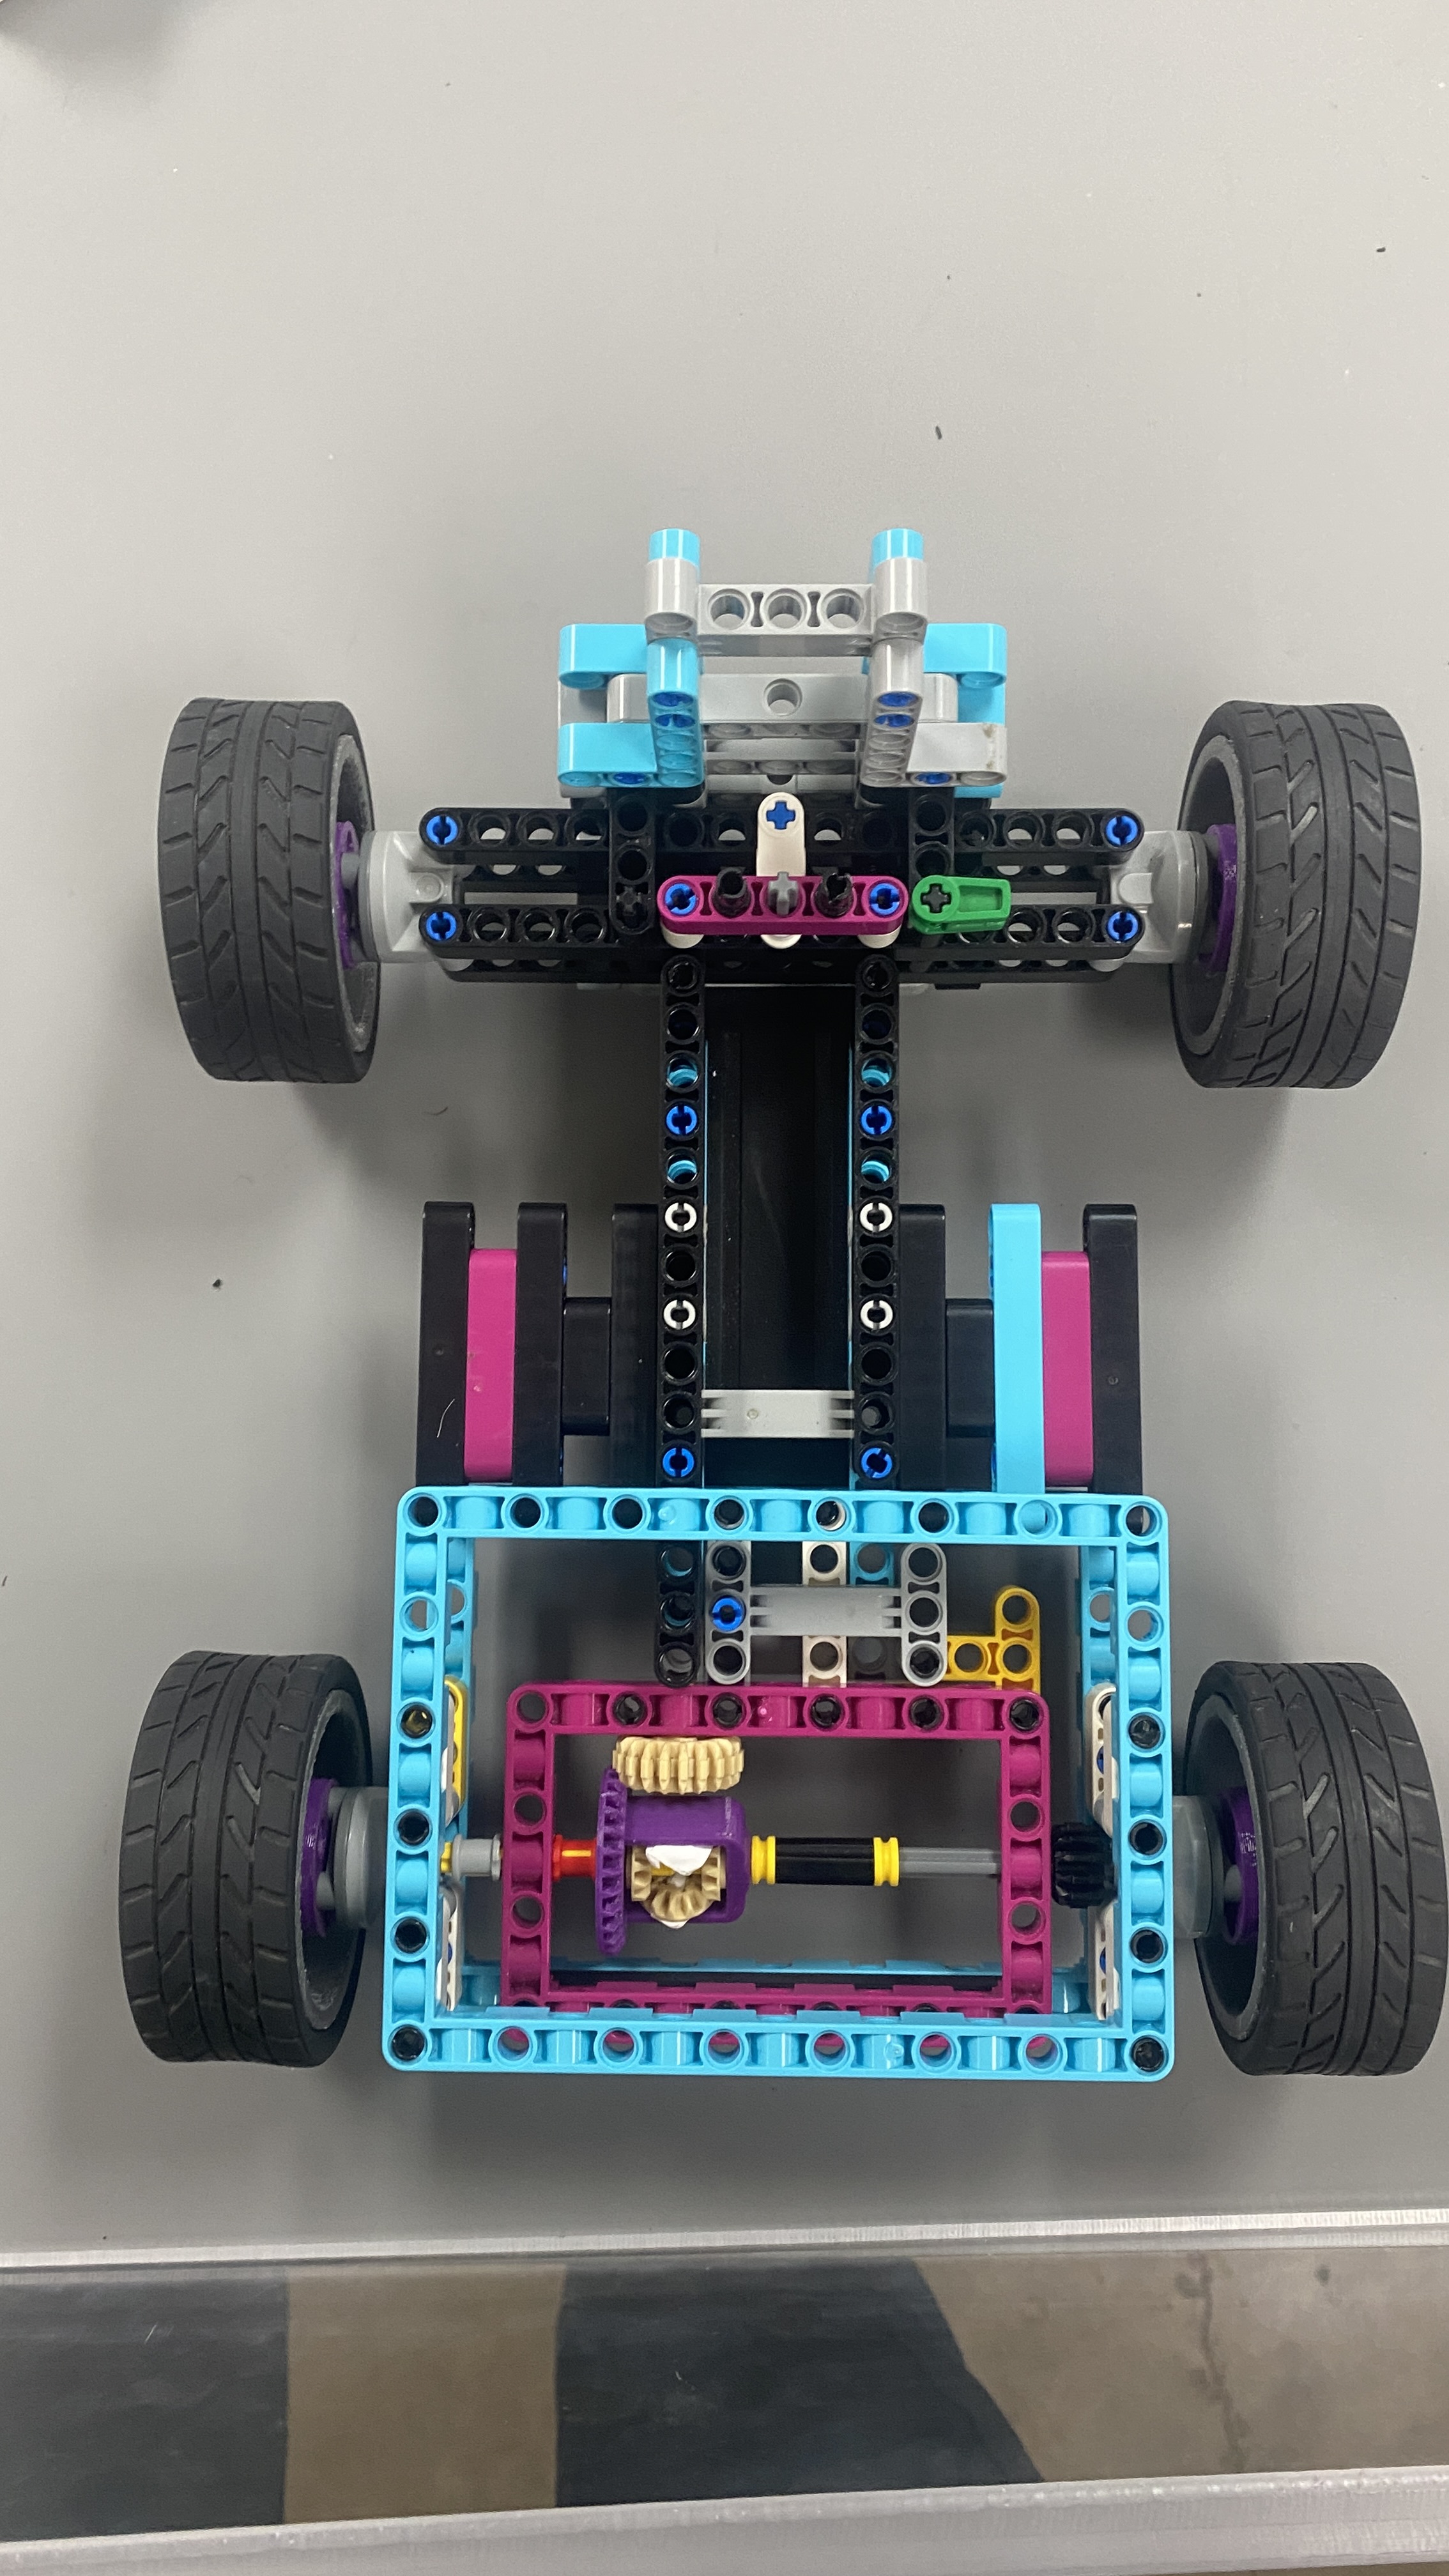 Chasis without electronic components