# Galaxea Open-World Dataset & G0 Dual-System VLA Model
[](https://opengalaxea.github.io/GalaxeaVLA/)
[](https://arxiv.org/abs/2509.00576v1)
[](https://opengalaxea.github.io/GalaxeaVLA/)
[](https://opengalaxea.github.io/GalaxeaVLA/visualizer/index.html)
[](https://huggingface.co/datasets/OpenGalaxea/Galaxea-Open-World-Dataset)
[](https://www.modelscope.cn/datasets/Galaxea/Galaxea-Open-World-Dataset)
[](https://x.com/Galaxea_x)
[](https://www.linkedin.com/company/galaxeadynamics/posts/?feedView=all&viewAsMember=true)
[](https://discord.gg/hB6BuUWZZA)
## 📢 News
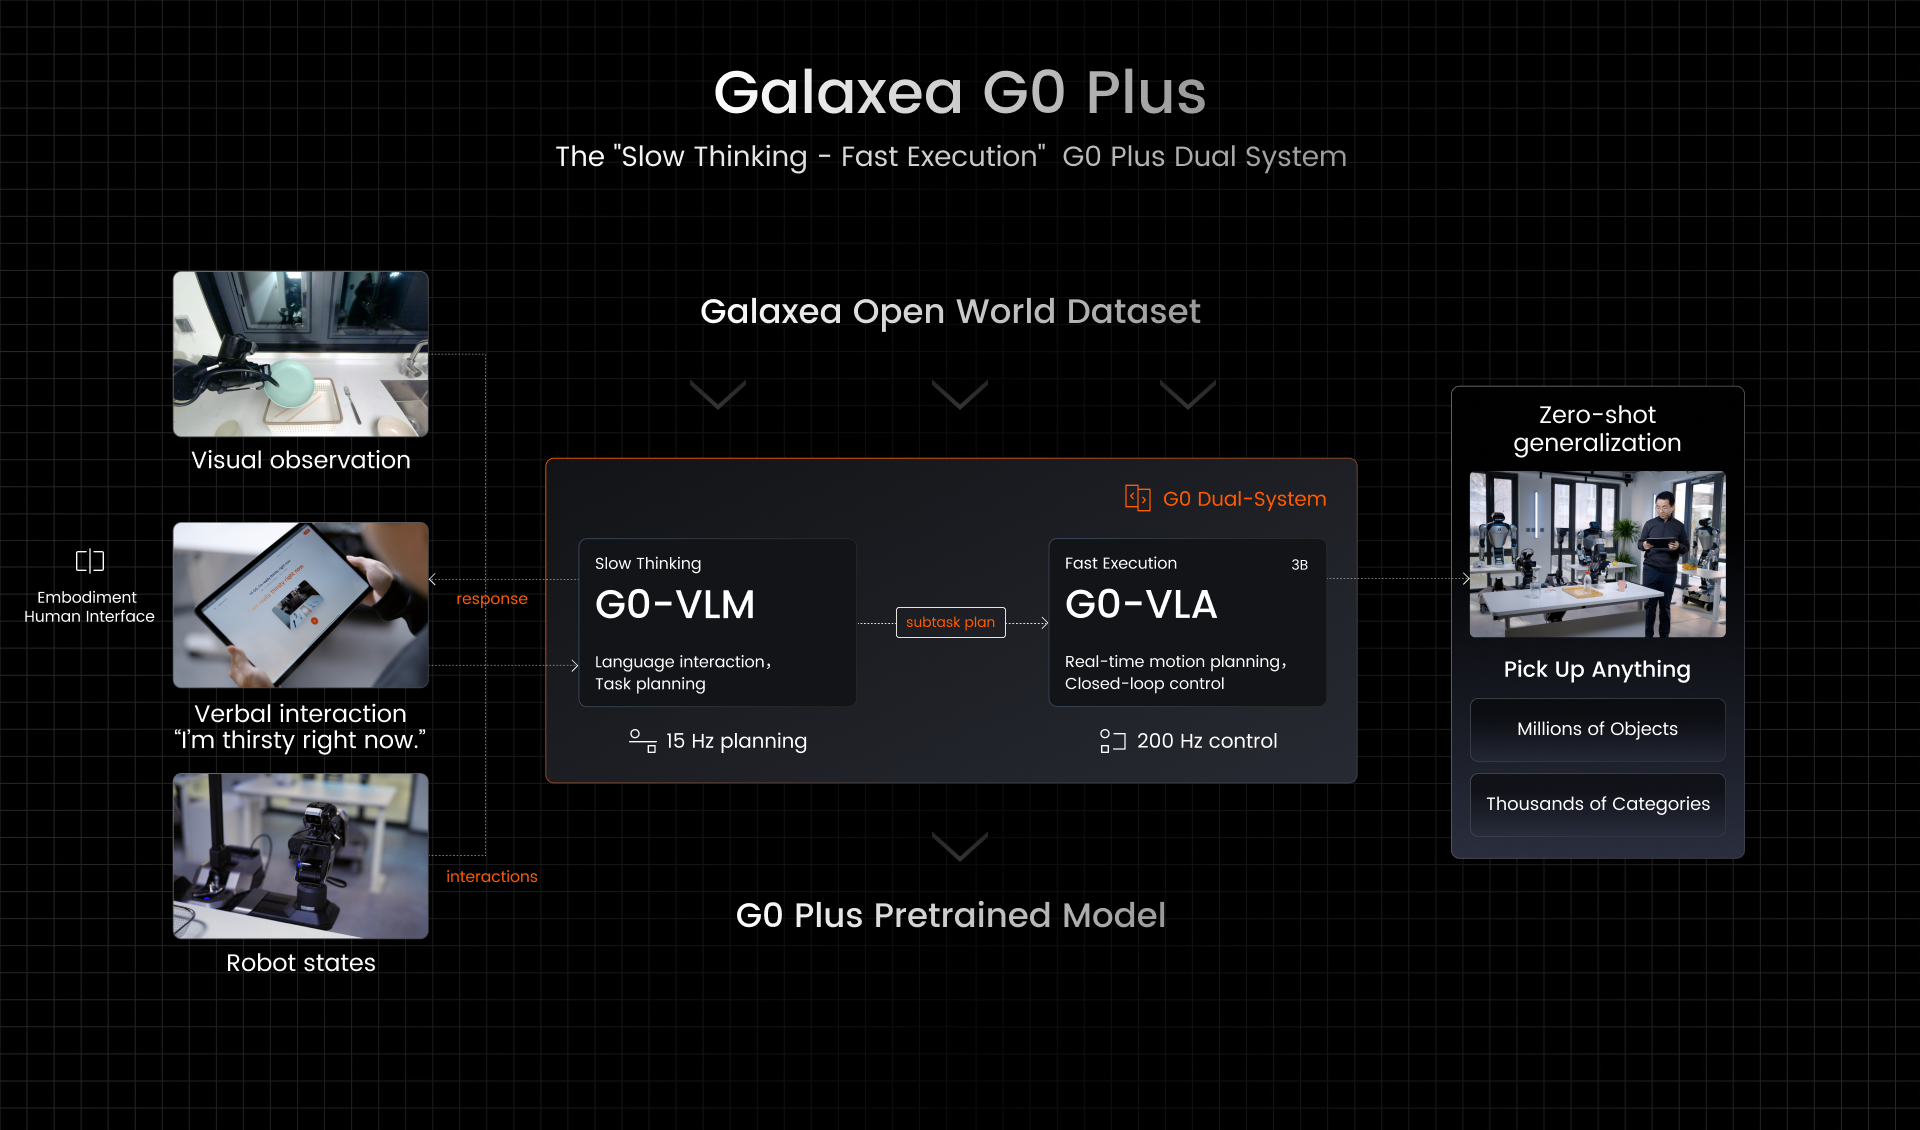
[Feb 12, 2026] Update **G0Plus** pre-trained weights trained on larger-scale teleoperation and web data. Release **G0Tiny** (250M, SmolVLM2 backbone) for R1 Pro Orin edge deployment. New out-of-the-box demos: **Fold Towels** and **Handover Gift** (on-device G0Tiny inference via TensorRT at up to 10 Hz). Add [openpi](https://github.com/Physical-Intelligence/openpi)-based **pi0/pi0fast** fine-tuning support.
[Jan 4, 2026] We are releasing **G0Plus**, our latest pre-trained VLA model for multi-task robot manipulation.
[Oct 7, 2025] Now Lerobot Format Galaxea Open-World Dataset is available at [Huggingface](https://huggingface.co/datasets/OpenGalaxea/Galaxea-Open-World-Dataset)!
[Sep 17, 2025] Release G0-VLA fine-tuning and real-robot inference code.
[Sep 9, 2025] Release G0-VLA pretrained model weights. [Huggingface](https://huggingface.co/OpenGalaxea/G0-VLA) and [Modelscope](https://www.modelscope.cn/models/Galaxea/G0-VLA)!
[Sep 9, 2025] Release Galaxea Open-World Dataset. [Huggingface](https://huggingface.co/datasets/OpenGalaxea/Galaxea-Open-World-Dataset) and [Modelscope](https://www.modelscope.cn/datasets/Galaxea/Galaxea-Open-World-Dataset)!
## 📌 Overview
**GalaxeaVLA** is an open-source project dedicated to advancing real-world, long-horizon, and few-shot robot manipulation.
1. **Galaxea Open-World Dataset**
- **500+ hours** of real-world mobile manipulation data.
- All data collected using **one uniform robotic embodiment** for consistency.
- Fine-grained **subtask language annotations**.
- Covers **residential**, **kitchen**, **retail**, and **office** settings.
- Dataset in **RLDS/LeRobot** format.
2. **Easy-to-Use Fine-Tuning Framework**
- Fully compatible with the [LeRobot](https://github.com/huggingface/lerobot) dataset format and scalable to large, real-world datasets.
- Modular design enables easy extension and adaptation for new tasks and environments.
3. **Model Checkpoints & An Out-of-the-Box Demo!**
- **G0Plus_3B_base**: A powerful pre-trained model with **2k hours+** real-world robot data for fine-tuning on custom tasks.
- **G0Tiny_250M_base**: A lightweight pre-trained model with **1k hours** of R1 Pro VR teleoperation data, with only **250M** parameters for on-device deployment on the R1 Pro Orin platform.
- **G0Plus_3B_base-pick_and_place**: A deployment-ready checkpoint, post-trained for robust pick-and-place performance in the wild.
- **Out-of-the-Box Pick Up Anything Demo**: a Dockerfile and step-by-step guides for quick setup and reproducible experiments.
- **Out-of-the-Box Fold Towels Demo**: a Dockerfile and step-by-step guides for quick setup and reproducible experiments.
- **Out-of-the-Box Handover Gift Demo**: a step-by-step guide for on-device G0Tiny VLA inference on R1 Pro Orin.
## 🚀 Galaxea Open-World Dataset
### **Key features**
- **500+ hours** of real-world mobile manipulation data.
- All data collected using **one uniform robotic embodiment** for consistency.
- Fine-grained **subtask language annotations**.
- Covers **residential**, **kitchen**, **retail**, and **office** settings.
- Dataset in **RLDS** and **LeRobot** format.
See more dataset (formats and examples) details [here](docs/dataset.md).
## ⚙️ GalaxeaVLA Getting Started
### GPU Requirements
To run our pretrained models in this repository, you will need an NVIDIA GPU with at least the following specifications. These estimations assume a single GPU, but you can also use multiple GPUs with model parallelism to reduce per-GPU memory requirements by configuring `--nnodes` and`--nproc-per-node` in the fine-tune start shell script.
| Mode | Memory Required | Example GPU |
| ------------------ | --------------- | ------------------------ |
| Inference | > 8 GB | RTX 3090 / **RTX 4090 (Recommended)** |
| Fine-Tuning (Full) | > 70 GB | A100 (80GB) / H20 (96GB) |
### Installation
```bash
git clone https://github.com/OpenGalaxea/GalaxeaVLA
cd GalaxeaVLA
uv sync --index-strategy unsafe-best-match
source .venv/bin/activate
uv pip install -e .
uv pip install -e .[dev]
```
Note that before you run the installation:
1. Recommend to [install uv](https://docs.astral.sh/uv/getting-started/installation/) without using a conda environment.
2. Recommend to add env variables at the beginning of your terminal, if you are in the country:
```bash
export UV_DEFAULT_INDEX=https://mirrors.aliyun.com/pypi/simple/
export UV_PYTHON_INSTALL_MIRROR=https://gh-proxy.com/https://github.com/astral-sh/python-build-standalone/releases/download
```
### Model Checkpoints
| Model | Use Case | Description | Checkpoint Path |
| ---------------------- | ----------- | --------------------------------- | ------------------------------------------------------------ |
| G0_3B_base | Fine-Tuning | Base G0-VLA Model for fine-tuning | https://huggingface.co/OpenGalaxea/G0-VLA/blob/main/G0_3B_base.pt |
| G0Plus_3B_base | Fine-Tuning | Base G0Plus-VLA Model for fine-tuning | https://huggingface.co/OpenGalaxea/G0-VLA/tree/main/G0Plus_3B_base |
| G0Tiny_250M_base | Fine-Tuning | Lightweight G0Tiny-VLA Model (250M) for edge deployment on R1 Pro Orin | https://huggingface.co/OpenGalaxea/G0-VLA/tree/main/G0Tiny_260120 |
| G0Plus_3B_base-pick_and_place | Deployment | Pick-and-Place Demo in the Wild | https://huggingface.co/OpenGalaxea/G0-VLA/tree/main/G0Plus_PP_CKPT |
### Inference on Real Robot
To run inference on a real Galaxea R1Lite robot using our pre-trained G0Plus model:
1. Make sure to finish the above installation steps first.
2. Then, follow steps and refer more details in our accompanying repo [EFMNode](https://github.com/OpenGalaxea/EFMNode).
### 🔥 Fine-Tuning Base Models on Galaxea Robots
To fine-tune our models with your own data, you should follow three steps:
1. Create your own task configs in `configs/tasks/real/`. You can adapt it from our configs demos: [G0Plus on R1Lite](configs/task/real/g0plus_r1lite_finetune.yaml) or [G0Tiny on R1Pro](configs/task/real/g0tiny_r1pro_finetune.yaml).
2. Install the required packages
```bash
sudo apt install ffmpeg
```
3. Set your environment variables
- `HF_DATASETS_CACHE`: An empty directory for HF-related caches.
- `GALAXEA_FM_OUTPUT_DIR`: An empty directory for checkpoints and logs output.
- `GALAXEA_FM_DATASET_STATS_CACHE_DIR`: A directory for caching dataset normalization statistics.
- `SWANLAB_API_KEY`: Your SwanLab API key.
```bash
export HF_ENDPOINT=https://hf-mirror.com
export HF_DATASETS_CACHE=
export GALAXEA_FM_OUTPUT_DIR=
export GALAXEA_FM_DATASET_STATS_CACHE_DIR=
export SWANLAB_API_KEY=
```
4. Running fine-tuning
```bash
bash scripts/run/finetune.sh
# examples:
bash scripts/run/finetune.sh 8 real/g0plus_r1lite_finetune
bash scripts/run/finetune.sh 8 real/g0tiny_r1pro_finetune
bash scripts/run/finetune.sh 8 real/pi0_r1lite_finetune
bash scripts/run/finetune.sh 8 real/pi0fast_r1lite_finetune
```
#### FAQs of Fine-tuning
1. Q: How to convert my data to a [LeRobot](https://github.com/huggingface/lerobot) dataset?
A: The [demo datasets](https://huggingface.co/OpenGalaxea/G0-VLA/tree/main/G0Plus_Finetune_LeRobot_Datasets_Demo) are provided on HuggingFace for easy trying.
2. Q: Cannot view the training logs in the SwanLab?
A: Make sure you set your own swanlab `workspace` in [train.yaml](configs/train.yaml).
3. Q: Cannot find the pre-trained model?
A: We use `google/paligemma-3b-pt-224` and `HuggingFaceTB/SmolVLM2-500M-Video-Instruct` as the pre-trained models, you should modify them twice in [g0plus.yaml](configs/model/vla/g0plus.yaml) and [g0tiny](configs/model/vla/g0tiny.yaml) the same as your actual paths (default: `/To/Your/Path/google/paligemma-3b-pt-224` and `/To/Your/Path/HuggingFaceTB/SmolVLM2-500M-Video-Instruct`).
4. Q: Out of Memory (OOM) error?
A: Make sure you have enough GPU memory as mentioned above. Or, reduce the `batch_size` in [g0plus.yaml](configs/model/vla/g0plus.yaml) (default: `4`).
### 🔥🔥 Out-of-the-Box Demos
1. [Pick Up Anything](docs/pick_up_anything_user_guideline.md)
2. [Fold Towels](docs/fold_towels_user_guideline.md)
3. [Handover Gift](docs/handover_gift_user_guideline.md)
Feel free to raise an issue if you have any questions.
## Acknowledgement
This project builds upon prior work from the open-source community. The implementation was inspired by [open-pi-zero](https://github.com/allenzren/open-pi-zero), [OpenVLA](https://github.com/openvla/openvla), [Octo](https://github.com/octo-models/octo), and [Openpi](https://github.com/Physical-Intelligence/openpi), and the experiments make use of datasets including [OXE](https://github.com/google-deepmind/open_x_embodiment), [RDT](https://github.com/thu-ml/RoboticsDiffusionTransformer), [BridgeV2](https://github.com/rail-berkeley/bridge_data_v2), and [DROID](https://github.com/droid-dataset/droid). We sincerely thank the authors of these projects for making their code and data publicly available.
## 📜 Citation
If you use our dataset or models, please cite:
```bibtex
@article{galaxea2025,
title={Galaxea G0: Open-World Dataset and Dual-System VLA Model},
author={Galaxea Team},
journal={arXiv preprint arXiv:2509.00576v1},
year={2025}
}
```
## License
This repository contains materials released under different licenses depending on the commit date:
- **Apache-2.0 (Legacy)**: All content committed **before 2026-01-04** is licensed under the Apache License 2.0.
- **G0 PLUS Community License Agreement (Current)**: All content **committed on or after 2026-01-04** is licensed under the **G0 PLUS Community License (Non-Commercial + Limited Patent License)**. See [G0 Plus Community License Agreement](./LICENSE-G0-PLUS).
For avoidance of doubt, the licensing boundary is the first commit that introduced the G0 PLUS license switch:
- Boundary commit (first under G0 PLUS license): `318207fe6d994d0ecaf8f7d7ebb9b96fec5ebf56`.
### What you can do under the G0 Plus Community License
You may use, reproduce, modify, and distribute the G0 Plus materials **only for non-commercial purposes**, such as academic research, personal use, education, and evaluation. Commercial use (including production deployment, providing services to third parties, or productization) requires a separate commercial license from us.
### Notices and attribution
If you redistribute any part of the G0 Plus materials, you must include:
- a copy/link of G0 Plus Community License Agreement, and
- the NOTICE file in this repository, and
- prominent notices on modified files indicating changes.
## Star History
[](https://www.star-history.com/#OpenGalaxea/GalaxeaVLA&type=date&legend=top-left)