---
## 🎯 Project Overview
An **autonomous maze-solving robot** built from scratch using an ATmega328P microcontroller (Arduino Nano). This MicroMouse navigates through unknown mazes using the **left-hand rule algorithm**, combining ultrasonic sensor feedback with motor encoder data for precise movement control.
The robot features a **dual feedback control system** that fuses:
- **PID-based wall following** using 3 HC-SR04 ultrasonic sensors
- **Encoder-based dead reckoning** for accurate turns and straight-line tracking
**Goal:** Design and build a fully autonomous robot capable of navigating and solving standard maze configurations without human intervention.
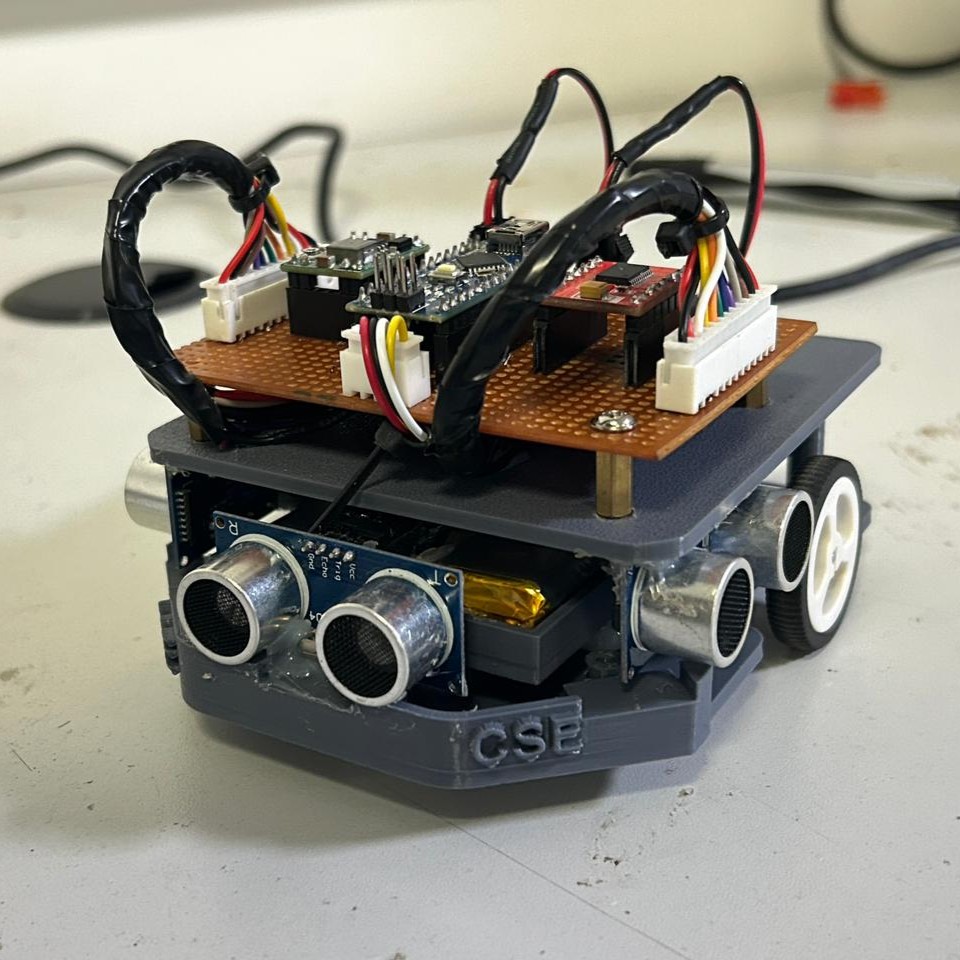 🎬 Final assembled MicroMouse robot ready for maze navigation
---
## 🎬 Demo Video
[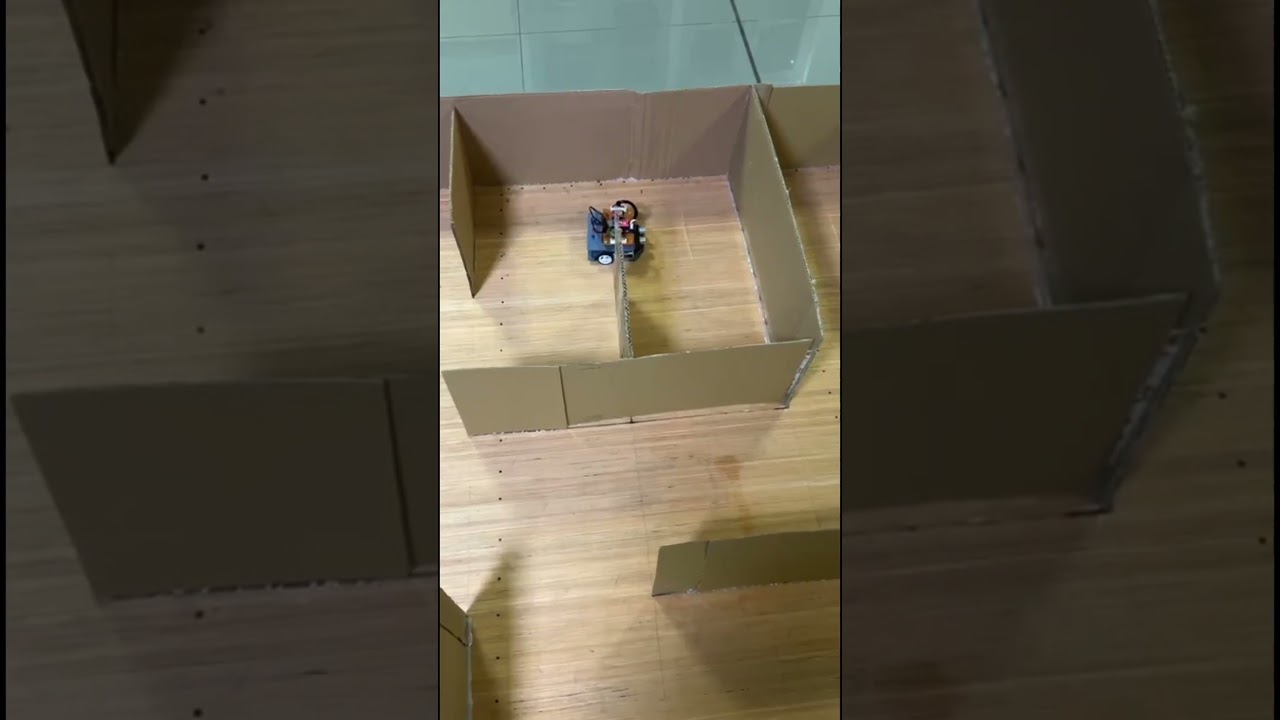](https://youtube.com/shorts/mDKhOKRyAyE)
**[▶️ Watch on YouTube](https://youtube.com/shorts/mDKhOKRyAyE)**
*Click the image above or watch the MicroMouse autonomously navigate through a maze using the left-hand rule algorithm*
---
## 🚀 Getting Started
### Quick Start Guide
Follow these steps to build and run your own MicroMouse:
```mermaid
flowchart LR
A[1️⃣ Clone Repo] --> B[2️⃣ Assemble Hardware]
B --> C[3️⃣ Print Chassis]
C --> D[4️⃣ Wire Components]
D --> E[5️⃣ Flash Code]
E --> F[6️⃣ Calibrate]
F --> G[🎉 Run!]
```
### Step 1: Clone the Repository
```bash
git clone https://github.com/Ravinx001/MicroMouse.git
cd MicroMouse
```
### Step 2: Gather Components
Ensure you have all components from the [Bill of Materials](#-bill-of-materials-bom):
- Arduino Nano (ATmega328P)
- TB6612FNG motor driver
- 2× N20 gear motors with encoders
- 3× HC-SR04 ultrasonic sensors
- 7.4V LiPo battery
- Wheels and caster
### Step 3: Print the Chassis
1. Download [`body_3D_design/micromouse_body_3d_design.stl`](body_3D_design/micromouse_body_3d_design.stl)
2. Print with **PLA/PETG**, 0.2mm layer height, 25% infill
3. Allow 4+ hours for printing
### Step 4: Wire the Electronics
Connect components according to the [Pin Configuration](#-pin-configuration) table:
| **Connection** | **Arduino Pin** |
|----------------|-----------------|
| Left Motor PWM | D5 |
| Right Motor PWM | D3 |
| Motor Driver STBY | D8 |
| Left Ultrasonic TRIG/ECHO | A4/A5 |
| Front Ultrasonic TRIG/ECHO | D9/D10 |
| Right Ultrasonic TRIG/ECHO | D11/D12 |
| Left Encoder A/B | A0/A1 |
| Right Encoder A/B | A2/A3 |
### Step 5: Install Toolchain & Flash
**Windows:**
```bash
# Install WinAVR or AVR Toolchain
# Download from: https://www.microchip.com/mplab/avr-support/avr-and-arm-toolchains-c-compilers
# Update COM port in Makefile
notepad Makefile # Change PORT = COM3 to your port
# Build and flash
make build
make flash
```
**Linux/macOS:**
```bash
# Install AVR toolchain
sudo apt install gcc-avr avr-libc avrdude # Debian/Ubuntu
brew install avr-gcc avrdude # macOS
# Update port and flash
# Linux: PORT = /dev/ttyUSB0
# macOS: PORT = /dev/cu.usbserial-*
make build
make flash
```
### Step 6: Calibrate Encoders
```bash
# Flash calibration program
make calibrate
# Open Serial Monitor at 9600 baud
# Manually rotate each wheel one full revolution
# Note the tick count displayed
# Update TICKS_PER_REVOLUTION in include/config.h
```
### Step 7: Test & Run!
1. Place robot at maze entrance
2. Power on - wait for 3-second countdown
3. Watch it solve the maze autonomously!
### 🔧 First-Time Tuning Checklist
| **Check** | **Action** |
|-----------|------------|
| ☐ Motors spin correctly | Both wheels forward when expected |
| ☐ Sensors read distances | Open Serial Monitor, verify L/F/R readings |
| ☐ 90° turns are accurate | Adjust `TURN_90_COMPENSATION` if needed |
| ☐ Wall following is smooth | Tune PID gains if oscillating |
> 💡 **Tip:** Start with the robot in a simple straight corridor before testing in a full maze!
---
## ✨ Key Features & Capabilities
### 🧭 **Left-Hand Rule Maze Solving**
Implements the classic wall-following algorithm with priority-based decision making:
- **Priority 1:** Turn LEFT if left wall is absent
- **Priority 2:** Go FORWARD if path is clear
- **Priority 3:** Turn RIGHT if right wall is absent
- **Priority 4:** Turn AROUND (180°) at dead ends
### 🎛️ **Dual Feedback Control System**
Advanced sensor fusion combining two independent control mechanisms:
- **Encoder Feedback (40%):** Quadrature encoders for precise positioning
- **Wall PID Control (60%):** Real-time distance regulation from walls
### 📡 **Triple Ultrasonic Sensing**
Three HC-SR04 sensors provide 180° environmental awareness:
- Left, Front, and Right wall detection
- Range: 2cm to 400cm with ±3mm accuracy
- 100ms update rate with exponential smoothing filter
### ⚡ **High-Performance Motor Control**
TB6612FNG dual H-bridge driver with PWM speed control:
- Independent speed control for differential steering
- Active braking capability for precise stops
- Hardware timer-based PWM generation
---
## 🛠️ Hardware Architecture
| **Component** | **Part Number** | **Function** |
|---------------|-----------------|--------------|
| **Microcontroller** | ATmega328P (Arduino Nano) | Main processing unit @ 16MHz |
| **Motor Driver** | TB6612FNG | Dual H-bridge motor control |
| **Motors** | N20 DC Gear Motors (x2) | Differential drive propulsion |
| **Ultrasonic Sensors** | HC-SR04 (x3) | Wall distance measurement |
| **Encoders** | Quadrature Encoders (x2) | Wheel position feedback |
| **Power** | 7.4V LiPo Battery | Portable power source |
| **Voltage Regulator** | AMS1117-5V | 5V logic level regulation |
### 📊 System Block Diagram
```mermaid
flowchart TB
subgraph POWER["⚡ Power Supply"]
BAT[🔋 7.4V LiPo Battery]
REG[AMS1117 5V Regulator]
BAT --> REG
end
subgraph SENSING["📡 Sensor Array"]
LEFT[HC-SR04 Left]
FRONT[HC-SR04 Front]
RIGHT[HC-SR04 Right]
ENCL[Left Encoder]
ENCR[Right Encoder]
end
subgraph PROCESSING["🧠 Processing Unit"]
MCU[ATmega328P
16MHz]
PID[PID Controller]
MAZE[Maze Solver
Left-Hand Rule]
FUSION[Sensor Fusion
40% Enc + 60% Wall]
end
subgraph ACTUATION["⚙️ Motor Control"]
DRIVER[TB6612FNG
Motor Driver]
MOTORL[Left Motor]
MOTORR[Right Motor]
end
REG -->|5V| MCU
LEFT --> MCU
FRONT --> MCU
RIGHT --> MCU
ENCL --> MCU
ENCR --> MCU
MCU --> PID
MCU --> MAZE
PID --> FUSION
FUSION --> DRIVER
MAZE --> DRIVER
DRIVER --> MOTORL
DRIVER --> MOTORR
BAT -->|7.4V Direct| DRIVER
```
---
## 🧠 Software Architecture
### Control Flow Diagram
```mermaid
flowchart TD
START([🚀 System Start]) --> INIT[Initialize Peripherals
UART, Timers, GPIO, PWM]
INIT --> SENSORS[Initialize Sensors
& Encoders]
SENSORS --> DELAY[3 Second Countdown]
DELAY --> LOOP{Main Control Loop}
LOOP --> READ_SENS[Read Ultrasonic
Sensors @ 100ms]
READ_SENS --> READ_ENC[Read Encoder
Counts]
READ_ENC --> WALL_STATE{Determine
Wall State}
WALL_STATE -->|Both Walls| CENTER[Center Between
Walls PID]
WALL_STATE -->|Left Only| FOLLOW_L[Follow Left
Wall PID]
WALL_STATE -->|Right Only| FOLLOW_R[Follow Right
Wall PID]
WALL_STATE -->|No Walls| STRAIGHT[Encoder-Only
Straight Drive]
WALL_STATE -->|Front Wall| DECISION[Maze Decision
Required]
CENTER --> FUSION[Sensor Fusion
Enc 40% + Wall 60%]
FOLLOW_L --> FUSION
FOLLOW_R --> FUSION
STRAIGHT --> ENC_ONLY[Encoder
Correction Only]
FUSION --> MOTORS[Apply Motor
Speeds]
ENC_ONLY --> MOTORS
DECISION --> CHECK{Check
Openings}
CHECK -->|Left Open| TURN_L[Turn Left 90°]
CHECK -->|Front Clear| FWD[Continue Forward]
CHECK -->|Right Open| TURN_R[Turn Right 90°]
CHECK -->|Dead End| TURN_180[Turn Around 180°]
TURN_L --> MOTORS
FWD --> MOTORS
TURN_R --> MOTORS
TURN_180 --> MOTORS
MOTORS --> LOOP
```
### Maze Solving State Machine
```mermaid
stateDiagram-v2
[*] --> FORWARD: Start
FORWARD --> LEFT_OPEN: Left sensor > threshold
FORWARD --> FRONT_BLOCKED: Front sensor < threshold
FORWARD --> FORWARD: Continue straight
LEFT_OPEN --> WAIT_DELAY: Debounce 500ms
WAIT_DELAY --> TURN_LEFT: Opening confirmed
WAIT_DELAY --> FORWARD: False positive
TURN_LEFT --> FORWARD: Turn complete
FRONT_BLOCKED --> CHECK_LEFT: Stop & sense
CHECK_LEFT --> TURN_LEFT: Left open
CHECK_LEFT --> CHECK_RIGHT: Left blocked
CHECK_RIGHT --> TURN_RIGHT: Right open
CHECK_RIGHT --> TURN_180: Dead end
TURN_RIGHT --> FORWARD: Turn complete
TURN_180 --> FORWARD: Turn complete
note right of WAIT_DELAY
MAZE_OPENING_DELAY
prevents false triggers
end note
```
---
## 📌 Pin Configuration
### Motor Driver (TB6612FNG)
| **Arduino Pin** | **ATmega328P** | **TB6612FNG** | **Function** |
|-----------------|----------------|---------------|--------------|
| D7 | PD7 | AIN1 | Left Motor Direction 1 |
| D6 | PD6 | AIN2 | Left Motor Direction 2 |
| D5 | PD5 (OC0B) | PWMA | Left Motor PWM Speed |
| D4 | PD4 | BIN1 | Right Motor Direction 1 |
| D2 | PD2 | BIN2 | Right Motor Direction 2 |
| D3 | PD3 (OC2B) | PWMB | Right Motor PWM Speed |
| D8 | PB0 | STBY | Standby (Active HIGH) |
### Ultrasonic Sensors (HC-SR04)
| **Sensor** | **TRIG Pin** | **ECHO Pin** |
|------------|--------------|--------------|
| Left | A4 (PC4) | A5 (PC5) |
| Front | D9 (PB1) | D10 (PB2) |
| Right | D11 (PB3) | D12 (PB4) |
### Quadrature Encoders
| **Encoder** | **Phase A** | **Phase B** |
|-------------|-------------|-------------|
| Left Motor | A0 (PC0) | A1 (PC1) |
| Right Motor | A2 (PC2) | A3 (PC3) |
---
## 📦 3D Printed Body
A custom chassis was designed in **Autodesk Fusion 360** to house all components securely.
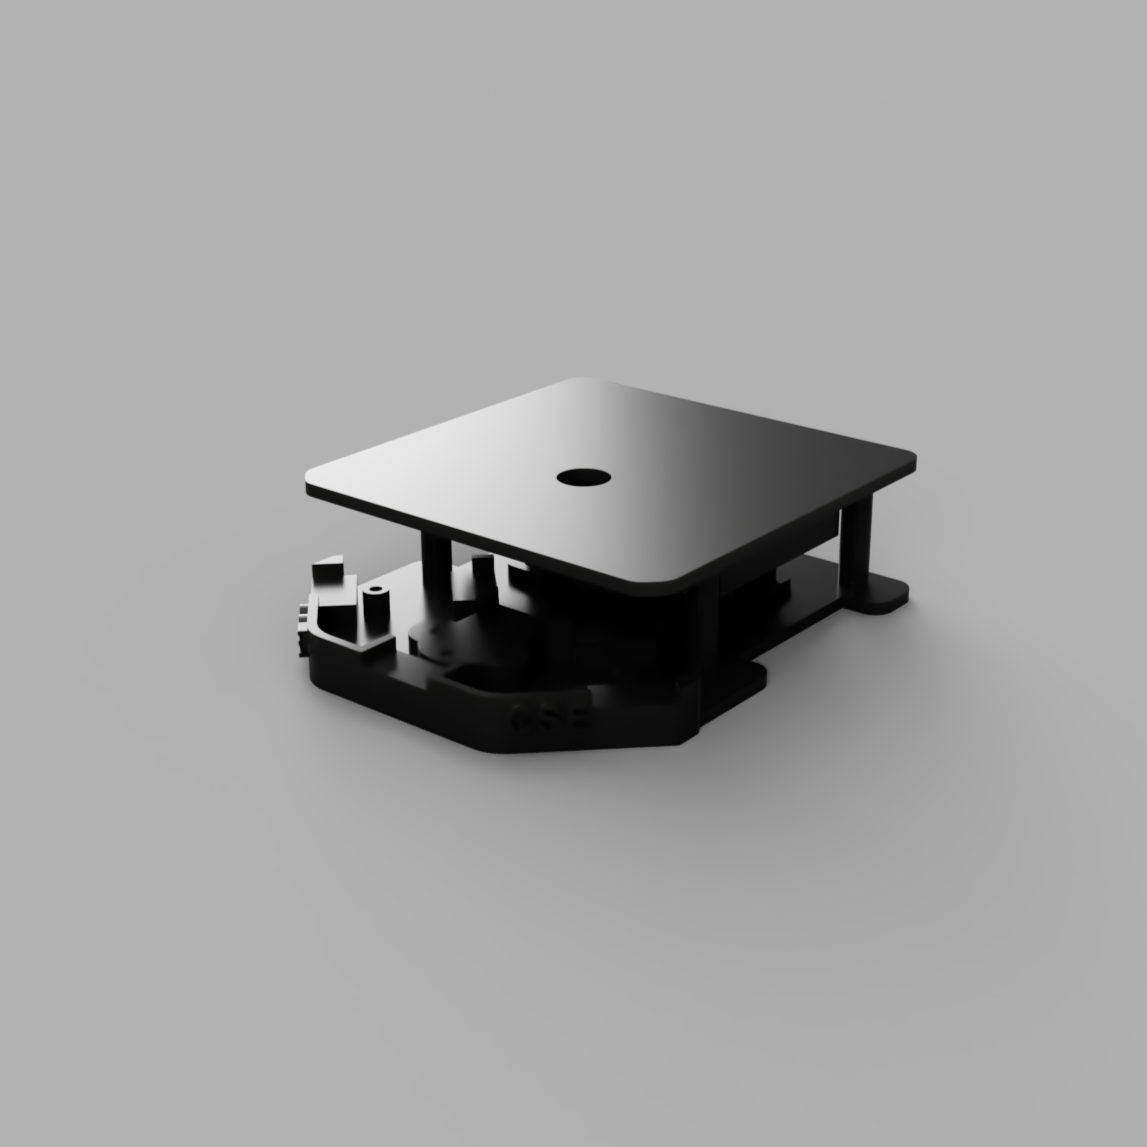 Custom 3D-printed chassis design in Fusion 360
### Design Features:
- ✅ Integrated motor mounts with vibration dampening
- ✅ Precise sensor mounting angles for optimal detection
- ✅ Battery compartment with secure fit
- ✅ Easy access for programming and debugging
- ✅ Ventilation slots for electronics cooling
### Printing Specifications:
| **Parameter** | **Value** |
|---------------|-----------|
| Material | PLA or PETG |
| Layer Height | 0.2mm |
| Infill | 25% |
| Supports | Yes (for motor mounts) |
| Print Time | ~4 hours |
**[📥 Download STL File](body_3D_design/micromouse_body_3d_design.stl)**
**[📥 Download Fusion 360 Source](body_3D_design/micromouse_body_3d_design.f3d)**
---
## ⚙️ Build & Flash Instructions
### Prerequisites
- **AVR-GCC Toolchain** (avr-gcc, avr-objcopy, avrdude)
- **Arduino Nano** or compatible ATmega328P board
- **USB-to-Serial driver** (CH340 for clone Nanos)
### Build Commands
```bash
# Clone the repository
git clone https://github.com/Ravinx001/MicroMouse.git
cd MicroMouse
# Build the project
make build
# Check memory usage (critical - RAM near capacity!)
make size
# Flash to Arduino Nano (update COM port in Makefile first)
make flash
# Clean build artifacts
make clean
# Run encoder calibration tool
make calibrate
```
### ⚠️ Important: COM Port Configuration
Before flashing, update the `PORT` variable in [Makefile](Makefile):
```makefile
# Windows: COM3, COM4, etc.
# Linux: /dev/ttyUSB0, /dev/ttyACM0
# Mac: /dev/cu.usbserial-*
PORT = COM3
```
### Memory Usage
| **Memory** | **Used** | **Available** | **Usage** |
|------------|----------|---------------|-----------|
| Flash | ~12KB | 32KB | ~37% |
| RAM | ~1.8KB | 2KB | ~90% ⚠️ |
> ⚠️ **Warning:** RAM usage is near capacity. Avoid adding large buffers or arrays.
---
## 🔧 Configuration & Tuning
All tunable parameters are centralized in [`include/config.h`](include/config.h).
### Key Parameters
```c
// Motor Speeds
#define MOTOR_SPEED 110 // Base forward speed (0-255)
#define TURN_SPEED 80 // Turning speed (0-255)
// PID Gains
#define PID_KP 1.2f // Proportional gain
#define PID_KI 0.03f // Integral gain
#define PID_KD 0.6f // Derivative gain
// Wall Following
#define TARGET_WALL_DISTANCE 8 // Target distance from walls (cm)
#define FRONT_STOP_DISTANCE 15 // Stop when front wall closer (cm)
// Maze Detection
#define MAZE_LEFT_THRESHOLD 20 // Opening detection threshold (cm)
#define MAZE_OPENING_DELAY 500 // Debounce delay (ms)
// Control Fusion Weights
#define ENCODER_WEIGHT 0.4f // Encoder contribution
#define WALL_WEIGHT 0.6f // Wall PID contribution
```
### Tuning Guide
| **Problem** | **Solution** |
|-------------|--------------|
| Robot oscillates/wobbles | Reduce `PID_KP` or increase `PID_KD` |
| Drifts on straight paths | Increase `ENCODER_CORRECTION_GAIN` |
| Turns overshoot | Increase `TURN_90_COMPENSATION` |
| Turns undershoot | Decrease `TURN_90_COMPENSATION` |
| False turn triggers | Increase `MAZE_OPENING_DELAY` |
| Too slow reaction | Decrease `CONTROL_PERIOD_MS` |
📚 **Detailed tuning guide:** See [CONFIG_PARAMETERS_GUIDE.md](CONFIG_PARAMETERS_GUIDE.md)
---
## 📊 Technical Specifications
| **Specification** | **Value** | **Notes** |
|-------------------|-----------|-----------|
| **Microcontroller** | ATmega328P | 16MHz, 32KB Flash, 2KB RAM |
| **Operating Voltage** | 5V Logic | 7.4V battery input |
| **Motor Voltage** | 6-7.4V | Direct from battery |
| **Sensor Range** | 2-400cm | HC-SR04 ultrasonic |
| **Encoder Resolution** | 356 ticks/rev | Quadrature decoding |
| **Control Loop Rate** | 20Hz | 50ms period |
| **Sensor Update Rate** | 10Hz | 100ms period |
| **Turn Accuracy** | ±5° | Encoder-controlled |
| **Max Speed** | ~30cm/s | At MOTOR_SPEED=110 |
| **Dimensions** | ~12×10×8cm | LxWxH approximate |
| **Weight** | ~200g | Including battery |
---
## 📁 Project Structure
```
MicroMouse/
├── 📄 README.md # This file
├── 📄 LICENSE # MIT License
├── 📄 Makefile # Build system
├── 📄 CONFIG_PARAMETERS_GUIDE.md # Detailed tuning guide
├── 📄 TURN_CONFIG_SIMPLIFIED.md # Turn calibration guide
│
├── 📂 src/ # Source files
│ ├── main.c # Main control loop & maze logic
│ ├── motors.c # TB6612FNG motor driver
│ ├── sensors.c # HC-SR04 ultrasonic sensors
│ ├── uart.c # Serial communication
│ └── utils.c # Timing utilities (millis, micros)
│
├── 📂 include/ # Header files
│ ├── config.h # ⚙️ ALL tunable parameters
│ ├── motors.h # Motor driver interface
│ ├── sensors.h # Sensor interface
│ ├── uart.h # UART interface
│ └── utils.h # Utility functions
│
├── 📂 samples/ # Example implementations
│ ├── 90_turning_and_wall_following/ # Turn + wall follow demo
│ └── optimized_wall_following_with_ultrasonic/ # PID tuning demo
│
├── 📂 arduino_codes/ # Arduino IDE versions
│ └── wall_following_tune.ino # Wall following tuning sketch
│
├── 📂 body_3D_design/ # Chassis design files
│ ├── micromouse_body_3d_design.f3d # Fusion 360 source
│ ├── micromouse_body_3d_design.stl # 3D printable STL
│ └── micromouse_body_3d_design.PNG # Design preview
│
├── 📂 photos/ # Build documentation
│ └── final_view_of_micro_mouse.jpeg # Finished robot photo
│
├── 📂 video/ # Demo videos
│ └── Micro Mouse Full Video.mp4 # Full operation demo
│
├── 📂 build/ # Compiled output (generated)
│
└── 📂 .github/ # GitHub configuration
└── copilot-instructions.md # AI coding assistant guide
```
---
## 🔄 Control Algorithm Deep Dive
### PID Wall Following
```mermaid
flowchart LR
subgraph INPUT
SP[Setpoint
8cm target]
PV[Process Variable
Actual distance]
end
subgraph PID["PID Controller"]
E[Error
SP - PV]
P[P Term
Kp × error]
I[I Term
Ki × ∫error]
D[D Term
Kd × d/dt error]
SUM((Σ))
end
subgraph OUTPUT
CORR[Correction
-40 to +40]
ML[Left Motor
Speed ± correction]
MR[Right Motor
Speed ∓ correction]
end
SP --> E
PV --> E
E --> P
E --> I
E --> D
P --> SUM
I --> SUM
D --> SUM
SUM --> CORR
CORR --> ML
CORR --> MR
```
### Sensor Fusion Algorithm
```mermaid
flowchart TD
subgraph ENCODERS["Encoder Feedback"]
EL[Left Encoder
Ticks]
ER[Right Encoder
Ticks]
DIFF[Tick Difference
L - R]
ENC_CORR[Encoder Correction
diff × gain]
end
subgraph WALLS["Wall PID Feedback"]
SENS[Ultrasonic
Sensors]
FILTER[Low-Pass
Filter α=0.6]
PID_CALC[PID
Calculation]
WALL_CORR[Wall Correction]
end
subgraph FUSION["Sensor Fusion"]
WEIGHT[Weighted Sum
40% Enc + 60% Wall]
TOTAL[Total Correction]
end
EL --> DIFF
ER --> DIFF
DIFF --> ENC_CORR
SENS --> FILTER
FILTER --> PID_CALC
PID_CALC --> WALL_CORR
ENC_CORR -->|× 0.4| WEIGHT
WALL_CORR -->|× 0.6| WEIGHT
WEIGHT --> TOTAL
TOTAL --> MOTORS[Motor Speeds]
```
---
## 🐛 Troubleshooting
| **Problem** | **Possible Cause** | **Solution** |
|-------------|--------------------|--------------|
| Robot doesn't move | STBY pin LOW | Check D8 is HIGH after `motors_enable()` |
| Erratic sensor readings | Electrical noise | Add 0.1µF caps near sensor VCC pins |
| Turns are inaccurate | Wrong encoder count | Run `make calibrate` and update `TICKS_PER_REVOLUTION` |
| Robot drifts left/right | Encoder polarity | Check encoder wiring or swap A/B phases |
| Oscillates in corridor | PID gains too high | Reduce `PID_KP` or increase `PID_KD` |
| Misses wall openings | Threshold too low | Increase `MAZE_LEFT_THRESHOLD` |
| False opening detection | Delay too short | Increase `MAZE_OPENING_DELAY` |
| Won't compile | Missing toolchain | Install avr-gcc and avr-libc |
| Flash fails | Wrong COM port | Update `PORT` in Makefile |
| RAM overflow | Too many variables | Remove debug strings, optimize buffers |
### Serial Debug Output
Connect at **9600 baud** to view real-time status:
```
ENC L:1234 R:1230 D:4 | BOTH L:7cm R:8cm
ENC L:1280 R:1278 D:2 | LEFT L:6cm
>>> TURNING LEFT 90° <<<
Turn complete! Ticks: 287 (Target: 282)
```
---
## 🛒 Bill of Materials (BOM)
| **Qty** | **Component** | **Specification** | **Notes** |
|---------|---------------|-------------------|-----------|
| 1 | Arduino Nano | ATmega328P, CH340 | Or compatible clone |
| 1 | TB6612FNG Module | Dual H-Bridge | Handles 1.2A/channel |
| 2 | N20 Gear Motors | 6V, 100-300 RPM | With encoder mount |
| 2 | Quadrature Encoders | ~360 PPR | Magnetic or optical |
| 3 | HC-SR04 | Ultrasonic sensor | 2-400cm range |
| 1 | 7.4V LiPo Battery | 300-500mAh | 2S configuration |
| 1 | AMS1117-5V | Voltage regulator | Or LM7805 |
| 2 | Wheels | 42mm diameter | Fits N20 shaft |
| 1 | Caster Wheel | Ball or swivel | Rear support |
| - | Jumper Wires | Various | For connections |
| - | 3D Printed Chassis | PLA/PETG | See design files |
---
## 📚 Learning Outcomes
This project demonstrates proficiency in:
- ✅ **Embedded C Programming** - Direct register manipulation, ISRs, hardware timers
- ✅ **Control Systems** - PID implementation, sensor fusion, state machines
- ✅ **Algorithm Design** - Left-hand rule maze solving, decision trees
- ✅ **Electronics Integration** - Motor drivers, sensor interfaces, power management
- ✅ **3D CAD Design** - Fusion 360 parametric modeling
- ✅ **Build Systems** - Makefile-based compilation and flashing
- ✅ **Technical Documentation** - Comprehensive project documentation
---
## 🤝 Contributing
Contributions are welcome! Areas for improvement:
- [ ] Flood-fill algorithm implementation
- [ ] Speed run optimization after maze learning
- [ ] IR sensor alternative to ultrasonic
- [ ] Bluetooth/WiFi telemetry
- [ ] PCB design for cleaner integration
- [ ] OLED display for status
### How to Contribute
1. Fork the repository
2. Create a feature branch (`git checkout -b feature/FloodFill`)
3. Commit changes (`git commit -m 'Add flood-fill algorithm'`)
4. Push to branch (`git push origin feature/FloodFill`)
5. Open a Pull Request
---
## 📄 License
This project is licensed under the **MIT License** - see the [LICENSE](LICENSE) file for details.
---
## 📞 Contact & Support
**Project Maintainer**
📧 Email: [rav.business.lak@gmail.com](mailto:rav.business.lak@gmail.com)
🐙 GitHub: [@Ravinx001](https://github.com/Ravinx001)
💼 LinkedIn: [Ravindu Amarasekara](https://www.linkedin.com/in/ravindu-amarasekara/)
**Community**
💬 Discussions: Use GitHub Discussions for questions
🐛 Issues: Report bugs via GitHub Issues
---
### 🐭 **From Code to Maze Mastery** 🐭
### 🌟 **Where Algorithms Meet Real-World Robotics** 🌟
⭐ **Star this repository if you found it helpful!** ⭐
**Built with ❤️ for the Robotics & Maker Community**