Open Source Project:
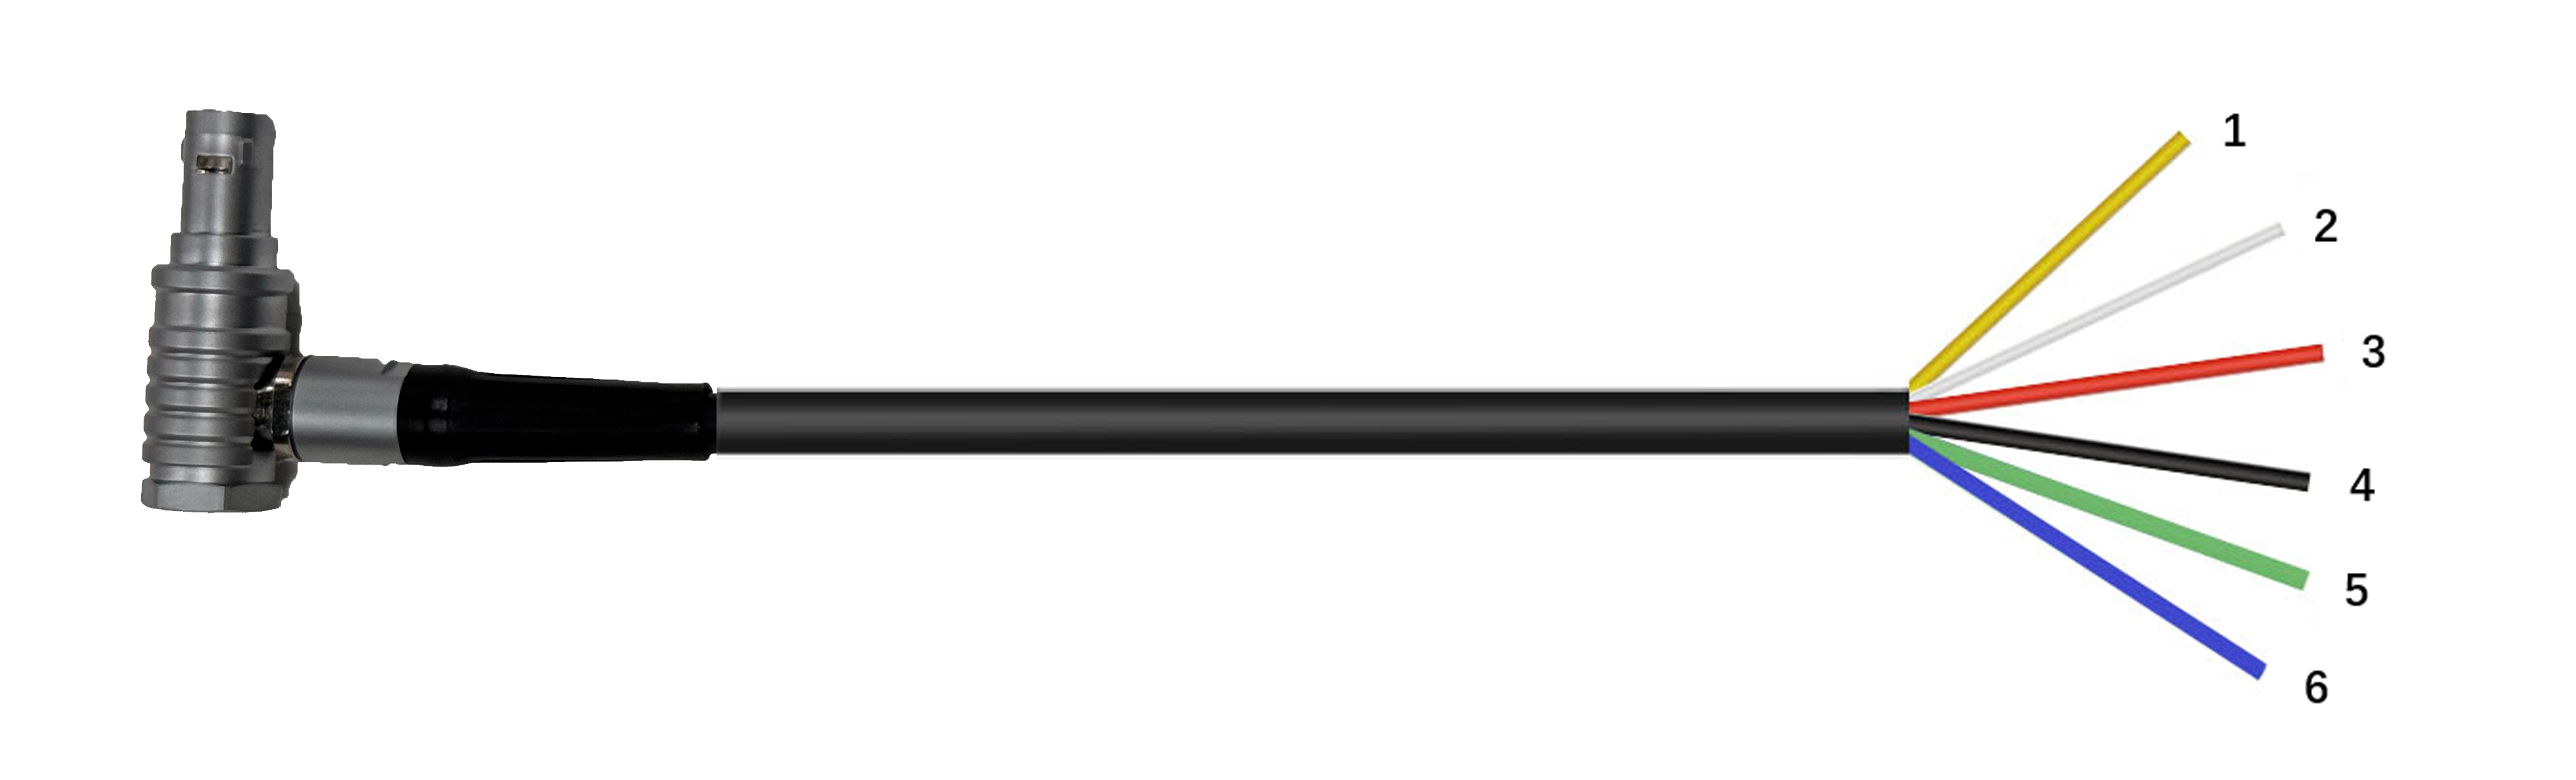
Two-Finger Parallel Gripper ## Copyright and License Agreement The hardware source information and related materials of this project are licensed under the [OpenAtom Open Hardware License, Version 1.0](License) . ## Introduction The Realman Two-Finger Parallel Gripper is designed to provide users with easy-to-use and high-quality operational capabilities. The gripper is developed with the self-developed WHJ03 integrated joint as the core component, featuring high dynamic response, high load capacity, compact size, strong versatility, easy installation, and simple maintenance. According to task requirements, the gripper can be flexibly and conveniently deployed on complex robots, at the end of mechanical arms, or on PLC production lines, to address grasping, sorting, and handling needs in industrial, commercial, domestic, and educational scenarios. The robot uses a standard RS485 communication interface, supporting serial port protocol and Modbus RTU protocol. The simple and efficient interface and control commands allow users to quickly achieve control of the gripper. 
| No. | Name | Download Address | Description |
|---|---|---|---|
| 1 | Software | Download Address | Including gripper_app, gripper_boot, gripper_tool, and the two-finger parallel gripper host computer software v1.0.3, used for setting and debugging the two-finger parallel gripper. |
| 2 | Hardware | Including 3D structure diagrams, BOM lists, schematic diagrams, PCB Layout, Placement diagrams, as well as BOT and TOP diagrams of the PCB, supporting the production and overall assembly of the hardware control board and structural components. | |
| 3 | Related Files | Including product manuals, product design specifications, and test cases, explaining the application scenarios, features, communication protocols, functional parameters, and acceptance test case guidance of the two-finger parallel gripper. |