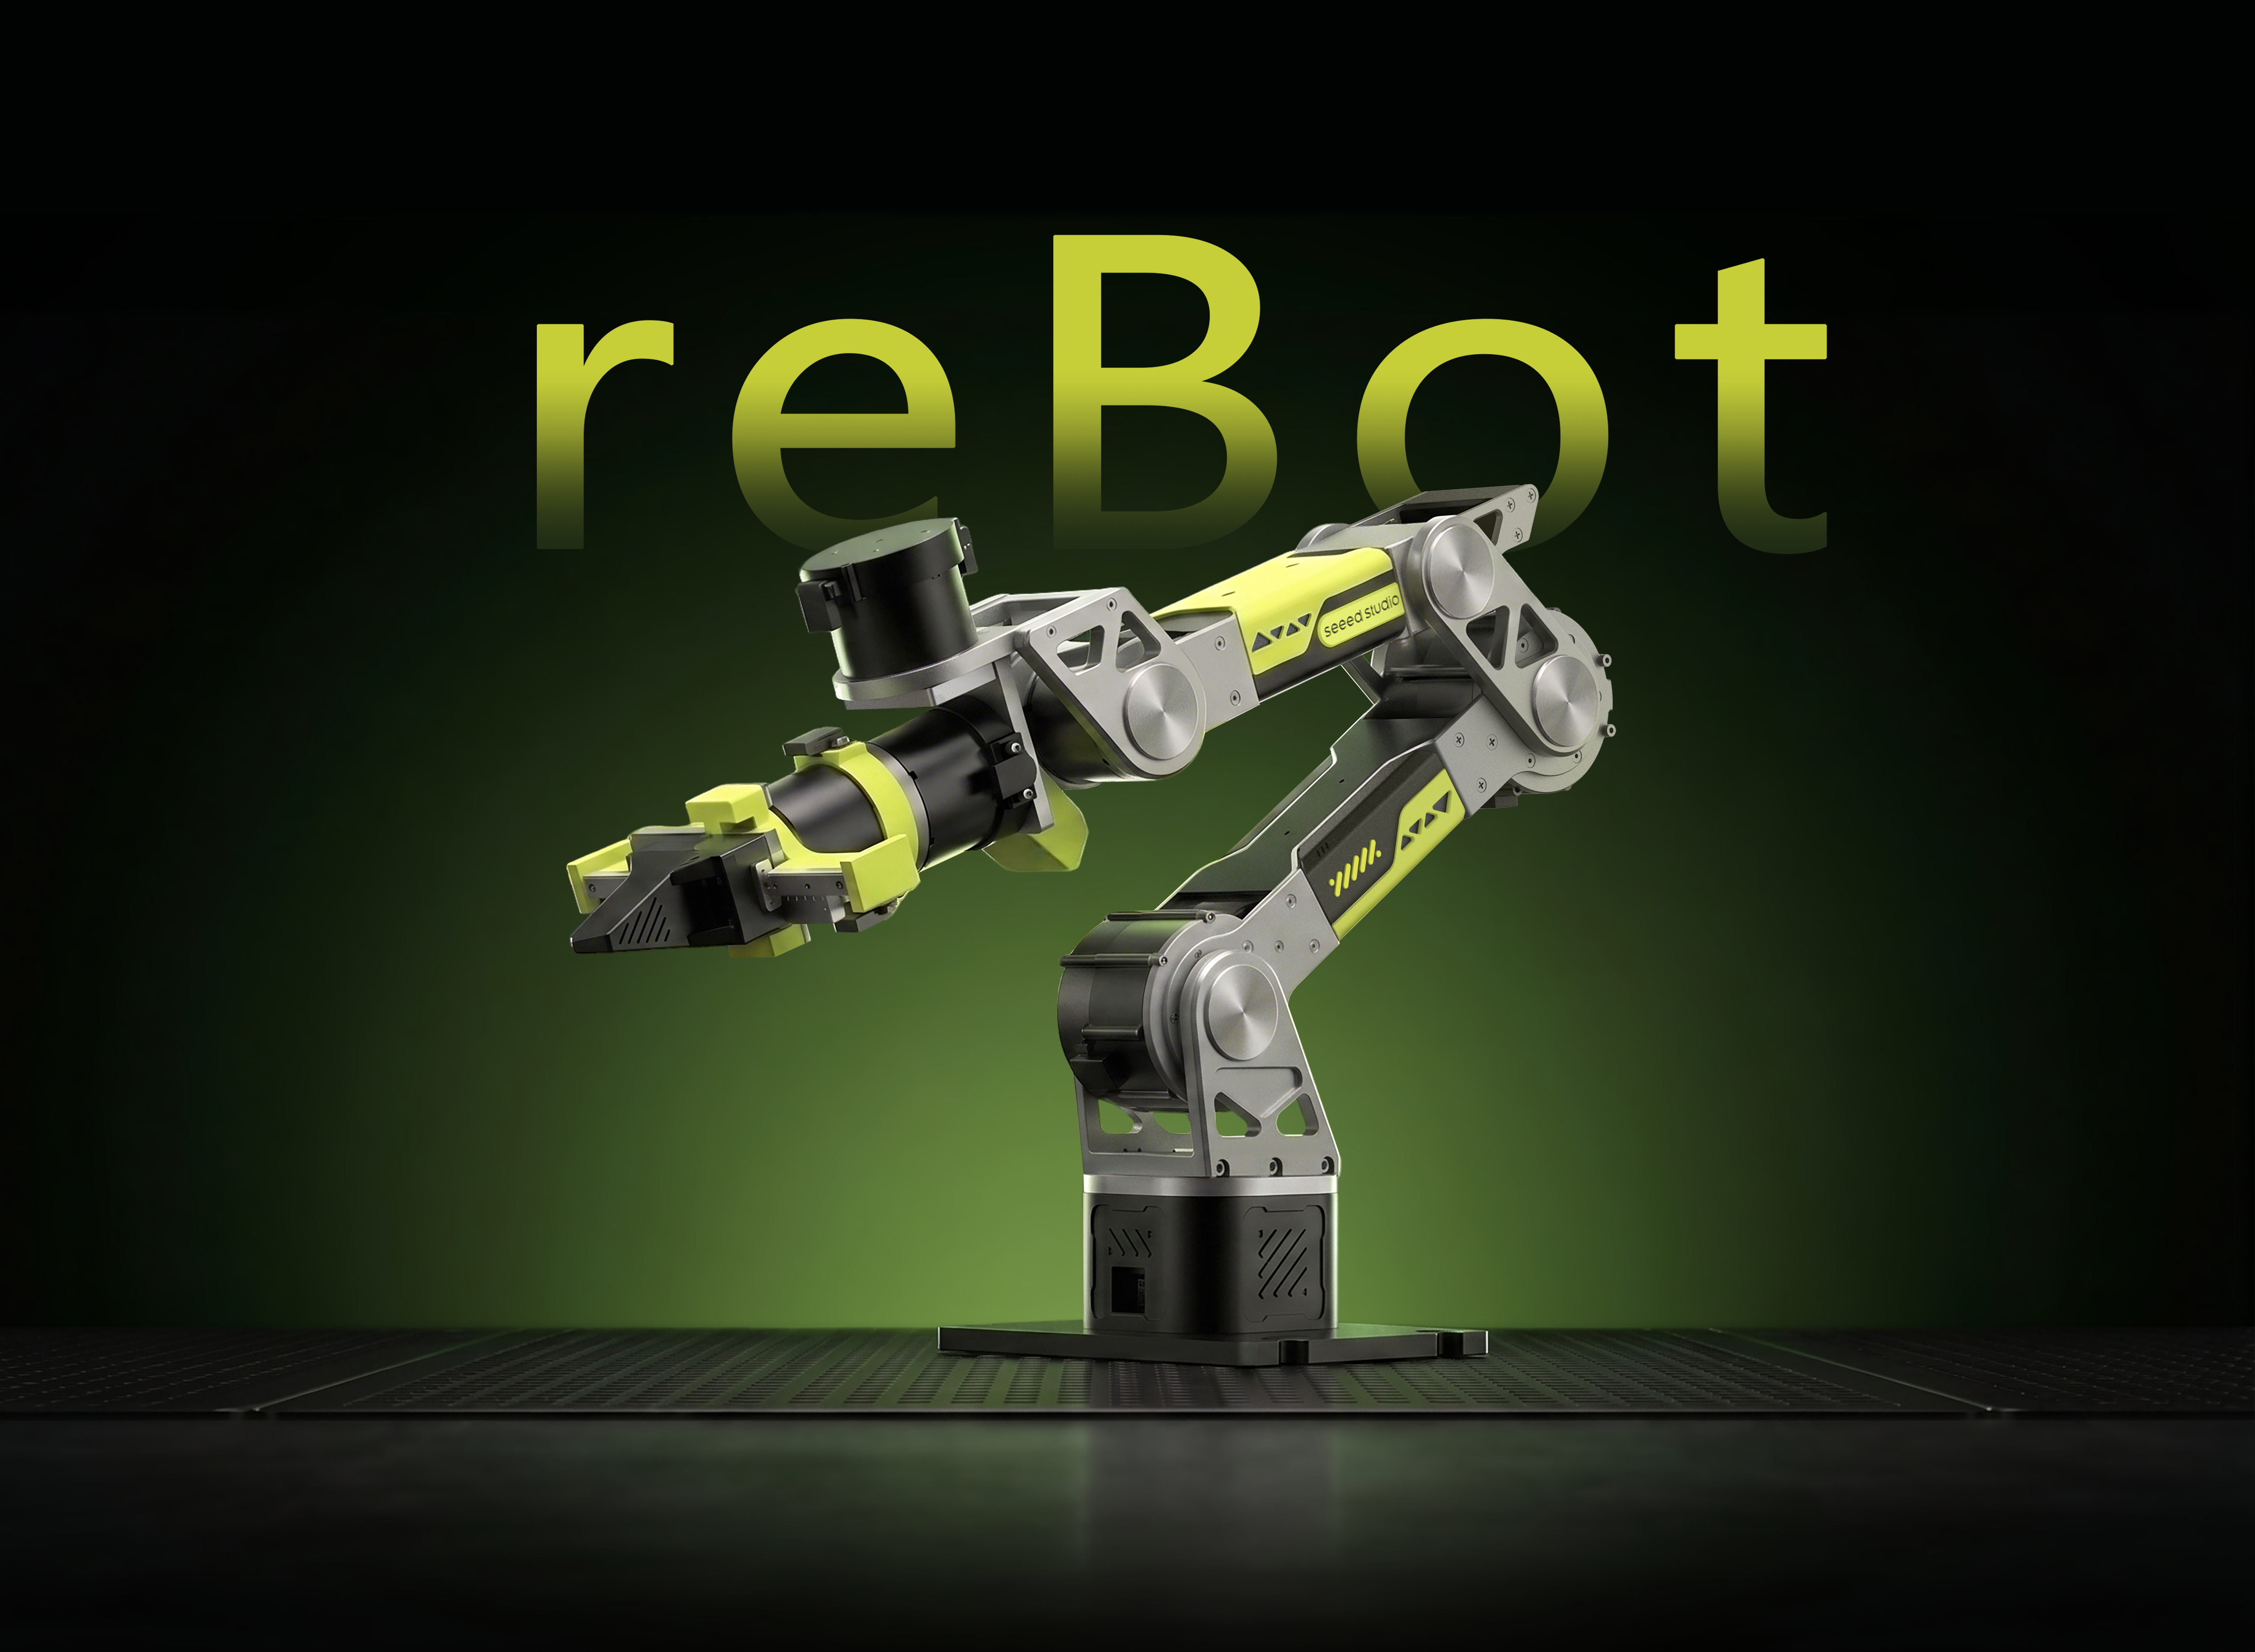
# ๐Ÿฆพ reBot-DevArm **The Open-Source Robotic Arm for Every Developer** reBot-DevArm Banner OSHWA Certified [![Hardware License: CERN-OHL-W-2.0](https://img.shields.io/badge/License-CERN--OHL--W--2.0--Hardware-green.svg)](./LICENSE) [![Software License: Apache-2.0](https://img.shields.io/badge/License-Apache--2.0--Software-pink.svg)](./LICENSE) [![ROS](https://img.shields.io/badge/ROS-Noetic%20%7C%20Humble-orange.svg)](#roadmap-and-status) [![LeRobot](https://img.shields.io/badge/Framework-LeRobot-yellow.svg)](#roadmap-and-status) [![Isaac Sim](https://img.shields.io/badge/Framework-Isaac%20Sim-yellow.svg)](#roadmap-and-status) [![Commercial](https://img.shields.io/badge/Commercial-Contact%20Us-red.svg)](mailto:yaohui.zhu@seeed.cc) **100% Open Source ยท Embodied AI ยท Full Hardware + Software Stack** ๐ŸŒ [Landing Page](https://279070161-sketch.github.io/reBot/) ยท ๐Ÿ“š [Tutorial Center](https://wiki.seeedstudio.com/robotics_page/) ยท โ–ถ [Online Demo](https://yang-ci.github.io/Rebot_Arm_AGV/) [![Discord](https://img.shields.io/discord/1409155673572249672?color=7289DA&label=Discord&logo=discord&logoColor=white)](https://discord.gg/AbGuqJhDpQ) [![Documentation](https://img.shields.io/badge/Documentation-%F0%9F%93%95-blue)](https://wiki.seeedstudio.com/robotics_page/) [็ฎ€ไฝ“ไธญๆ–‡](README_zh.md) ยท [English](README.md) ยท [ๆ—ฅๆœฌ่ชž](README_JP.md) ยท [franรงais](README_Fr.md) ยท [Espaรฑol](README_es.md)
--- ## ๐Ÿ“‘ Contents - [๐Ÿ“– Introduction](#introduction) - [๐Ÿ›’ Get Your reBot Arm](#get-your-rebot-arm) - [๐Ÿš€ Try the Online Simulation](#try-the-online-simulation) - [๐Ÿ—บ๏ธ Roadmap and Status](#roadmap-and-status) - [โš™๏ธ Hardware Specifications](#hardware-specifications) - [๐ŸŒŸ Community Showcase](#community-showcase) - [๐Ÿงน Optional Hardware](#optional-hardware) - [๐ŸŽ“ Full-Stack Robotics Ecosystem](#full-stack-robotics-ecosystem) - [๐Ÿ™Œ Acknowledgments and Contributors](#acknowledgments-and-contributors) - [๐Ÿ“„ License](#license) - [โ˜Ž Contact Us](#contact-us) --- ## ๐Ÿ“– Introduction **reBot-DevArm** โ€” the **reBot Arm B601-DM** and **reBot Arm B601-RS** โ€” is a robotic arm project dedicated to lowering the barrier to learning Embodied AI. We believe in **true open source**: not just the code, but everything, released without reservation. - ๐Ÿฆพ **Two arm models** โ€” All design files for the **B601-DM (Damiao)** and **B601-RS (Robstride)**, two arms sharing the same appearance. - ๐Ÿ› ๏ธ **Hardware blueprints** โ€” Source files for sheet-metal and 3D-printed parts. - ๐Ÿ”ฉ **BOM list** โ€” Detailed down to the spec and purchase link of every single screw. - ๐Ÿ’ป **Software & algorithms** โ€” Python SDK, ROS1/2, Isaac Sim, LeRobot, and more. ## ๐Ÿ›’ Get Your reBot Arm | Model | Official Store | Other Channels | | :--- | :--- | :--- | | **reBot Arm B601-DM** | [SeeedStudio Bazaar](https://www.seeedstudio.com/reBot-Arm-B601-DM-Assembled-Kit-with-Power-Supply-Bundle.html) | [Amazon](https://www.amazon.com/dp/B0H2TWVFSW) ยท [AliExpress](https://de.aliexpress.com/item/1005012108314029.html) | | **reBot Arm B601-RS** | [SeeedStudio Bazaar](https://www.seeedstudio.com/reBot-Arm-B601-RS-Bundle-p-6898.html) | [AliExpress](https://www.aliexpress.us/item/3256812343811970.html?gatewayAdapt=deu2usa4itemAdapt) | ### B601-DM Kit Options Five kit options are available at [SeeedStudio.com](https://www.seeedstudio.com/reBot-Arm-B601-DM-Bundle.html): - **Arm Body Motor Kit** โ€” Motors and wiring harnesses only. - **Arm Body Structural Kit** โ€” Mechanical structural components only. - **Gripper Complete Kit** โ€” Motors, wiring, and structure for the gripper. - **Full Kit** โ€” Complete arm body and gripper. - **Pre-assembled Robotic Arm** โ€” Fully assembled, ready to use. > ๐Ÿ’ก The kit does not include a power adapter or C-clamps as standard, since you may power it with batteries or mount it on a custom DIY base. Purchase a [power supply](https://www.seeedstudio.com/AC-DC-Power-Adapter-IEC-60320-C14-XT30-Female-24V-4-5A-1200mm-L190-W92-5-H36mm-p-6764.html) and [power cord](https://www.seeedstudio.com/reServer-AC-US-p-5052.html) separately, or see the Mean Well solution at the bottom of the [BOM](./hardware/reBot_B601_DM/readme.md#about-power-supply). ### B601-RS Kit Options Two kit options are available at [SeeedStudio.com](https://www.seeedstudio.com/reBot-Arm-B601-RS-Assembled-Kit-with-Gripper-p-6865.html): - **Full Kit** โ€” Unassembled complete arm body and gripper. - **Pre-assembled Robotic Arm** โ€” Fully assembled, ready to use. > ๐Ÿ’ก We recommend the [Mean Well 48V 12.5A](https://www.amazon.com/sspa/click?ie=UTF8&spc=MTo0NzgzODk2NzUxNTQ0NzEyOjE3ODE2MTA2NTU6c3BfYXRmOjIwMDExNjA5NjQwMTc5ODo6MDo6&url=%2FLRS-350-48-Price-Switching-Supply-MeanWell%2Fdp%2FB0BP6S5DYR%2Fref%3Dsr_1_1_sspa%3Fcrid%3D27VPQOWNPN9UG%26dib%3DeyJ2IjoiMSJ9.qK84sGJa4-74kbCEX11MOFBju8sSQUdFsbHw6PNvmaEHnhzjX2T7dyhRNJY01mXxpWk8lccGOwnezxmqLKUjqglX_FI26mrxlvZf0KNiLdJ8QnhKsber4KDoyyLHNxWGV451uHCzZbCDXxM0iYXVnubuVourRaRURlyMorRavuLd2a32kABx-BKqyF5Dfr7dV453ecE6QULFqG-UVLBaBRijbxQGTJ2YiNyXAqn3bkM.Bt5mAPOJNAWGnXCC2mwvjdDdccZd1_0-WRXZpP4mR4M%26dib_tag%3Dse%26keywords%3DLRS-350-48%26qid%3D1781610655%26sprefix%3Dlrs-350-%252Caps%252C331%26sr%3D8-1-spons%26sp_csd%3Dd2lkZ2V0TmFtZT1zcF9hdGY%26psc%3D1) power supply for the RS model. For full performance, opt for a 48V 25A adapter. ### Leader Arm (Optional) Purchase the [Leader Arm](https://www.seeedstudio.com/Star-Arm-102-p-6765.html?qid=P2U7IG_yskyak5m_1776415593315) and a [12V 10A power supply](https://www.seeedstudio.com/FY1209900-12V-10A-Power-Adapter-12V-10A-p-6496.html); the 12V DC adapter of the SO-ARM101 also works. ## ๐Ÿš€ Try the Online Simulation Experience the reBot Arm B601-RS MuJoCo digital twin directly in your browser โ€” no installation required. Switch between the standard arm and AGV configurations, control joints and TCP, view the overhead and D405 wrist cameras, and run the automated put-away and stacking demos. The initial model download may take a moment; Chrome or Edge is recommended.
โ–ถ Launch the reBot Arm Interactive Demo

## ๐Ÿ—บ๏ธ Roadmap and Status We continuously maintain and adapt to mainstream robot development ecosystems. Below is our current progress and release plan. ### reBot Arm B601-DM | Ecosystem | Status | Description | Documentation | | :--- | :---: | :--- | :--- | | Basic Motor Usage | โœ… Done | Motion control and API encapsulation | [Damiao Technology](https://wiki.seeedstudio.com/cn/damiao_series/) | | STEP 3D Parts & BOM | โœ… Done | STEP files, parts BOM, and reference prices | [reBot Arm B601-DM BOM](./hardware/reBot_B601_DM/readme.md) | | Real-Machine Performance Testing | โœ… Done | Performance under normal and extreme conditions | [Performance Testing](./hardware/reBot_B601_DM/performance_testing/Performance_Testing.md) | | Assembly Video | โœ… Done | Ultra-detailed assembly steps and video | [Getting Started](https://wiki.seeedstudio.com/rebot_b601_dm_getting_started/) | | Python SDK | โœ… Done | One-stop motor read/write & control (Robstride, Damiao, Mota, Gaoqing, Hexfellowโ€ฆ) | [Motorbridge](https://motorbridge.seeedstudio.com) ยท [Web UI](https://rebot-devarm.w0x7ce.eu/) | | ROS2 Integration | โœ… Done | Kinematics, trajectory planning, gravity compensation | [ROS2 Guide](https://wiki.seeedstudio.com/rebot_arm_b601_dm_ros2_integration/) | | Pinocchio Integration | โœ… Done | Forward/inverse kinematics and gravity compensation | [Pinocchio Guide](https://wiki.seeedstudio.com/rebot_arm_b601_dm_pinocchio_meshcat/) ยท [Repo](https://github.com/Seeed-Projects/reBotArm_control_py) | | Isaac Sim Simulation | โœ… Done | USD models and simulated teleoperation | [Wiki](https://wiki.seeedstudio.com/rebot_arm_b601_dm_isaacsim/) | | LeRobot Integration | โœ… Done | Hugging Face LeRobot training framework | [LeRobot Guide](https://wiki.seeedstudio.com/rebot_arm_b601_dm_lerobot/) | | Depth Camera Integration | โœ… Done | YOLO + depth camera visual grasping demo | [Grasping Demo](https://wiki.seeedstudio.com/rebot_arm_b601_dm_grasping_demo/) | | reSpeaker Voice Integration | โœ… Done | reSpeaker Flex 4-mic array, voice-driven control with spatial awareness | [Voice Control](https://wiki.seeedstudio.com/control_rebot_arm_using_voice_with_respeaker_flex/) | | Latest Algorithms | โณ Planned | Mainstream algorithms updated progressively | Ongoing | | Free Course Series | โณ Planned | A series of completely free courses | Ongoing | #### Community Contributions | Ecosystem | Author | Description | Repository | | :--- | :---: | :--- | :--- | | ROS2 (Humble), third-party integration, URDF / rebotarm_bringup | [@danieldoradotalaveron-rb](https://github.com/danieldoradotalaveron-rb) | 1. **Passive diagnostics monitor** (`rebotarm_monitor_ros2`) โ€” `/diagnostics` overlay for `rqt_robot_monitor`, serial/CAN-aware aggregator;
2. **Safe park & shutdown** โ€” capture rest pose on connect, slow return on shutdown or `/rebotarm/park`;
3. **Gravity compensation (smooth stop)** โ€” MIT ramp-out to eliminate clack and jerk during pos/vel handoff;
4. **Gamepad teleop with IK/FK & safety** โ€” end-effector control via IK, live RViz visualization (simulation-only test);
5. **D405 eye-in-hand TF** โ€” Xacro under `end_link` for RViz visualization & TF only. | [rebotarm_monitor_ros2](https://github.com/danieldoradotalaveron-rb/rebotarm_monitor_ros2) ยท [reBotArmController_ROS2](https://github.com/danieldoradotalaveron-rb/reBotArmController_ROS2) | ### reBot Arm B601-RS | Ecosystem | Status | Description | Documentation | | :--- | :---: | :--- | :--- | | Basic Motor Usage | โœ… Done | Motion control and API encapsulation | [Robstride](https://wiki.seeedstudio.com/cn/robstride_control/) | | STEP 3D Parts & BOM | โœ… Done | STEP files, parts BOM, and reference prices | [reBot Arm B601-RS BOM](./hardware/reBot_B601_RS/README.md) | | Getting Started | โœ… Done | Quick start for the B601-RS | [Getting Started](https://wiki.seeedstudio.com/rebot_b601_rs_getting_started/) | | Assembly Video | โœ… Done | Ultra-detailed assembly steps and video | [Assembly Video](https://wiki.seeedstudio.com/rebot_b601_rs_getting_started/) | | ROS2 (Humble) | โœ… Done | Kinematics, trajectory planning, gravity compensation, MoveIt2 | [ROS2 Guide](https://wiki.seeedstudio.com/rebot_arm_b601_rs_ros2_integration/) | | LeRobot Integration | โœ… Done | Hugging Face LeRobot training framework | [LeRobot Guide](https://wiki.seeedstudio.com/rebot_arm_b601_rs_lerobot/) | | Pinocchio Integration | โœ… Done | Forward/inverse kinematics and gravity compensation | [Pinocchio Guide](https://wiki.seeedstudio.com/rebot_arm_b601_rs_pinocchio_meshcat/) ยท [Repo](https://github.com/Seeed-Projects/reBotArm_control_py) | | Depth Camera Integration | โœ… Done | YOLO + depth camera visual grasping demo | [Grasping Demo](https://wiki.seeedstudio.com/rebot_arm_b601_rs_grasping_demo/) | | Embodied Agent Architecture | โœ… Done | Accepts natural-language commands (e.g. "pick up the red block"), auto-plans and executes grasping | [Design](https://wiki.seeedstudio.com/wrc_demo_tutorial/) ยท [Source](https://github.com/TheMoonAstronaut/wrc.git) | | Isaac Sim Simulation | โœ… Done | USD models and simulated teleoperation | [DLI Course](https://www.seeedstudio.com/sim-to-real-with-seeed-rebot-and-nvidia-isaac) ยท [Repo](https://github.com/Seeed-Projects/reBot-Isaacsim) | | Latest Algorithms | โณ Planned | Mainstream algorithms updated progressively | Ongoing | | Free Course Series | โณ Planned | A series of completely free courses | Ongoing | ## โš™๏ธ Hardware Specifications Designed for desktop Embodied AI applications, balancing payload and flexibility. | Parameter | reBot Arm B601-DM | reBot Arm B601-RS | | :--- | :--- | :--- | | Payload | 1.5 kg | **2.5 kg** | | Recommended Workspace | 70% of arm reach | 70% of arm reach | | Max Reach | 767 mm | **754 mm** | | Weight | **โ‰ˆ 4.5 kg** | โ‰ˆ 6.7 kg | | Repeatability | < 0.2 mm | < 0.2 mm | | Degrees of Freedom | 6 DOF + 1 Gripper | 6 DOF + 1 Gripper | | Supported Ecosystems | ROS1, ROS2, LeRobot, Pinocchio, Isaac Sim, Python SDK | ROS1, ROS2, LeRobot, Pinocchio, Isaac Sim, Python SDK | | Supply Voltage | DC 24V | DC 48V | ## ๐ŸŒŸ Community Showcase | | | | | | | :---: | :---: | :---: | :---: | :---: | | GEM-4
[GEM-4](https://www.kaggle.com/competitions/gemma-4-good-hackathon/writeups/new-writeup-1778618527713) | Linyan Fu
[Linyan Fu](https://x.com/Linyan_Fu/status/2056383947341525180) ยท [Apheth D Almeida](https://x.com/Apheth_DAlmeida/status/2053503164507476096) | Dhruv Diddi
[Dhruv Diddi](https://x.com/DhruvDiddi/status/2046605015008383284) | Ed Henderson
[Ed Henderson](https://x.com/ed0henderson/status/2055076839002095743) | Sameer
Sameer | | Binh Pham
[Binh Pham](https://x.com/pham_blnh/status/2061994096374505710) | FangTianChongHui
[FangTianChongHui](https://www.instagram.com/reel/DY7Ny8OPjVu/?utm_source=ig_web_copy_link&igsh=NTc4MTIwNjQ2YQ==) | Xense YaoLin Dong
[Xense YaoLin Dong](https://x.com/dong1505lin) | Ed Henderson
[Ed Henderson](https://x.com/ed0henderson/status/2055076839002095743) | yoshikai_man
[yoshikai_man](https://x.com/yoshikai_man/status/2079938975398244705) | | hei-rebot-lift
[hei-rebot-lift](https://github.com/lipengdong/hei-rebot-lift) | Martin Kemka
[Martin Kemka](https://www.linkedin.com/posts/activity-7484390995862781952-TX4m?utm_source=share&utm_medium=member_desktop&rcm=ACoAAE6WUL4BWkFeyUj0TJ5JlGf6IG4iRHAicUo) | Kamil Buczyล„ski
[Kamil Buczyล„ski](https://www.linkedin.com/posts/kamil-buczy%C5%84ski-102843301_seeedstudio-rebotarm-seeedprojectofthemonth-ugcPost-7485297094715461633-RV_6/?utm_source=share&utm_medium=member_desktop&rcm=ACoAAE6WUL4BWkFeyUj0TJ5JlGf6IG4iRHAicUo) | Daniel Dorado
[Daniel Dorado](https://www.linkedin.com/posts/doradodaniel_computervision-spatialai-sim2real-share-7474727487374184448-NhwX/?utm_source=share&utm_medium=member_desktop&rcm=ACoAAE6WUL4BWkFeyUj0TJ5JlGf6IG4iRHAicUo) | Asier
[Asier](https://www.linkedin.com/posts/asierarranz_nvidia-physicalai-isaaclab-ugcPost-7480271721942417408-YNwu/?utm_source=share&utm_medium=member_desktop&rcm=ACoAAE6WUL4BWkFeyUj0TJ5JlGf6IG4iRHAicUo) | | H
[H](https://x.com/thermalpastor/status/2103842737032458567) | alpha_rover
[alpha_rover](https://x.com/Alpha10six/status/2103860758559994216) | Dilum Sanjaya
[Dilum Sanjaya](https://x.com/DilumSanjaya/status/2102806161728885145) | Binh
[Binh](https://x.com/pham_blnh/status/2101003855731593544) | LeRobot
[LeRobot](https://x.com/LeRobotHF/status/2104519372333048112) | | Raghav Kumar
[Raghav Kumar](https://x.com/raghav2956/status/2104659668375339475) | Kamil Buczyล„ski
[Kamil Buczyล„ski](https://www.linkedin.com/posts/kamil-buczy%C5%84ski-102843301_seeedstudio-ai-agent-ugcPost-7510738285707776000-1SMQ/?utm_source=social_share_send&utm_medium=android_app&rcm=ACoAAE6WUL4BWkFeyUj0TJ5JlGf6IG4iRHAicUo) | Fictionlab
[Fictionlab](https://www.linkedin.com/feed/update/urn:li:activity:7510701008885309440/) | box2bridge
[box2bridge](https://x.com/seeedstudio/status/2101965998954107303) | FangTianChongHui
[FangTianChongHui](https://x.com/seeedstudio/status/2095469352976003482) |

Sim-to-Real VLA Course
Seeed reBot Arm ร— NVIDIA Isaac โ€” Sim-to-Real VLA Course

## ๐Ÿงน Optional Hardware ### Wrist Camera Mount | 32ร—32 UVC | Intel D435i | Intel D405 & Gemini 305 | Gemini 2 | | :--- | :--- | :--- | :--- | | | | | | | [STEP](hardware/reBot_B601_DM/3D_Printed_Parts/UVC32_mount.step) | [STEP](hardware/reBot_B601_DM/3D_Printed_Parts/D435_Gemini2_Mount.step) | [STEP](hardware/reBot_B601_DM/3D_Printed_Parts/D405_305_Mount.step) ยท [design notes](https://github.com/bowenszhu/rebot-b601-rs-d405-wrist-mount/tree/v1.0.0) | [STEP](hardware/reBot_B601_DM/3D_Printed_Parts/D435_Gemini2_Mount.step) | ### Leader Arm Compatibility | Star Arm 102-LD | Open to compatibility integration | | :--- | :--- | | | [Series Hub](https://fashionstar.com.hk/robot-arm/star-arm-102/) ยท [GitHub repo](https://github.com/servodevelop/Star-Arm-102) | ### DIY Soft Finger | Soft Finger | Open to compatibility integration | | :--- | :--- | | | Coming soon | | [Finger Mount (ABS/PLA)](hardware/reBot_B601_DM/3D_Printed_Parts/Soft_Gripper_Mount.step) ยท [Finger (TPU 95+)](hardware/reBot_B601_DM/3D_Printed_Parts/Soft_Gripper_Finger.step) | Coming soon | ### Recommended Optional Hardware | Category | Type | Preview | Product | Link | | :--- | :--- | :--- | :--- | :--- | | **Camera** | Depth Camera | Orbbec Gemini 2 | **Orbbec Gemini 2 3D Camera** | [Seeed Studio](https://www.seeedstudio.com/Orbbec-Gemini-2-3D-Camera-p-6464.html) | | **Camera** | Depth Camera | Orbbec Gemini 336 | **Orbbec Gemini 336 Depth Camera** | [Seeed Studio](https://www.seeedstudio.com/Orbbec-Gemini-336-3D-Camera-3D-p-6662.html) | | **Camera** | Depth Camera | Orbbec Gemini 335LG | **Orbbec Gemini 335LG 3D Camera** | [Seeed Studio](https://www.seeedstudio.com/Orbbec-Gemini-335LG-3D-Camera-p-6541.html) | | **Camera** | Depth Camera | SLAMTEC Aurora S | **SLAMTEC Aurora S** | [Seeed Studio](https://www.seeedstudio.com/SLAMTEC-Aurora-S-AI-Integrated-Spatial-Perception-System-p-6669.html) | | **Camera** | Depth Camera | Intel RealSense D435i | **Intel RealSense Depth Camera D435i** | [Seeed Studio](https://www.seeedstudio.com/Intel-RealSense-Depth-Camera-D435i-p-4423.html) | | **Camera** | Depth Camera | RealSense D405 | **RealSense Depth Camera D405** | [Seeed Studio](https://www.seeedstudio.com/RealSense-D405-3D-Camera-p-6758.html) | | **Camera** | Monocular Camera | Sensing SG3S-ISX031C-GMSL2F | **Sensing SG3S-ISX031C-GMSL2F 3MP GMSL2 Camera** | [Seeed Studio](https://www.seeedstudio.com/SG3S-ISX031C-GMSL2F-p-6245.html) | | **Camera** | Monocular Camera | ET-S231 | **ET-S231 Megapixel 120ยฐ Wide-Angle 1080P USB Camera** | [Seeed Studio](https://www.seeedstudio.com/ET-S231-120-USB-Camera-p-6683.html) | | **Microphone** | Mic Array | reSpeaker Flex XVF3800 | **reSpeaker Flex XVF3800 Circular-4 with XIAO ESP32S3** | [Seeed Studio](https://www.seeedstudio.com/reSpeaker-Flex-XVF3800-Circular-4-with-XIAO-ESP32S3-p-6739.html) | | **Microphone** | Mic Array | reSpeaker XMOS XVF3800 | **reSpeaker XMOS XVF3800** | [Seeed Studio](https://www.seeedstudio.com/ReSpeaker-XVF3800-USB-Mic-Array-p-6488.html) | | **Controller** | Edge Controller | reComputer J3011 | **reComputer J3011-Orin Nano 8GB** | [Seeed Studio](https://www.seeedstudio.com/reComputer-J3011-p-5590.html) | | **Controller** | Edge Controller | Jetson AGX Thor | **NVIDIA Jetson AGX Thor Developer Kit** | [Seeed Studio](https://www.seeedstudio.com/NVIDIA-Jetson-AGX-Thor-Developer-Kit-p-9965.html) | ## ๐ŸŽ“ Full-Stack Robotics Ecosystem reBot-DevArm is not just a robotic arm โ€” it is a robotics learning community. The following general tutorials are shared for free: **๐Ÿ–ฅ๏ธ Edge Computing & Master Control** - [![Jetson](https://img.shields.io/badge/NVIDIA-reComputer%20Jetson-76B900?style=for-the-badge&logo=nvidia&logoColor=white)](https://wiki.seeedstudio.com/NVIDIA_Jetson/) โ€” AI inference & compute core - [![Raspberry Pi](https://img.shields.io/badge/Raspberry%20Pi-4B%20%2F%205-C51A4A?style=for-the-badge&logo=Raspberry%20Pi&logoColor=white)](https://wiki.seeedstudio.com/raspberry-pi-devices/) โ€” general Linux dev environment - [![ESP32](https://img.shields.io/badge/MCU-Seeed%20XIAO%20(ESP32)-0091BD?style=for-the-badge&logo=espressif&logoColor=white)](https://wiki.seeedstudio.com/SeeedStudio_XIAO_Series_Introduction/) โ€” low-power wireless control node **๐Ÿ“ก Sensors & Peripherals** - **Motors & Servos** โ€” [Damiao / Gogo / Robstride / Mita / Feite / Fashion Star](https://wiki.seeedstudio.com/robotics_page/) - **Visual Perception** โ€” [Depth cameras / LiDAR / vision algorithms](https://wiki.seeedstudio.com/robotics_page/) - **Voice Interaction** โ€” [reSpeaker mic arrays / voice control / spatial awareness (DoA)](https://wiki.seeedstudio.com/control_rebot_arm_using_voice_with_respeaker_flex/) - **Motion & Attitude** โ€” [IMU (6/9-axis) / gyroscopes / magnetometers](https://wiki.seeedstudio.com/Sensor_accelerometer/) - **Comprehensive Kits** โ€” [more robotics sensors & driver examples](https://wiki.seeedstudio.com/robotics_page/) > ๐Ÿ‘‰ **[Enter the Wiki Knowledge Base](https://wiki.seeedstudio.com/)** โ€” all tutorials are free to view. ## ๐Ÿ™Œ Acknowledgments and Contributors The path of open source is never lonely. The reBot-DevArm project would not exist without the support of Seeed Studio, the global open-source community, and our hardware partners. **๐ŸŒ Ecosystem & Software Support** - [Seeed Studio](https://www.seeedstudio.com/) โ€” hardware supply chain and technical support - [Hugging Face LeRobot](https://github.com/huggingface/lerobot) โ€” end-to-end robot learning framework - [NVIDIA Isaac Sim](https://developer.nvidia.com/isaac/sim) โ€” robot simulation and synthetic data platform **โš™๏ธ Core Hardware Partners** - [Damiao Technology](https://www.damiaokeji.com/) - [Robstride](https://robstride.com/) - [Fashion Star](https://fashionstar.com.hk/wiki/) **๐Ÿ’ก Inspiration** - [SO-ARM100](https://github.com/TheRobotStudio/SO-ARM100/tree/main) - [Mobile ALOHA](https://github.com/tonyzhaozh/aloha) - [Dummy-Robot (Zhihui Jun)](https://github.com/peng-zhihui/Dummy-Robot) - [OpenArm](https://openarm.dev/) - [I2RT](https://i2rt.com/) - [TRLC-DK1](https://github.com/robot-learning-co/trlc-dk1) **๐ŸŽƒ Prototype Contributors** - SeeedStudio AI Robotics Team โ€” Yaohui Zhu (yaohui.zhu@seeed.cc) - SeeedStudio STU โ€” Wentao Dong - SeeedStudio STU โ€” Weiwei Xu - SeeedStudio Purchasing Department โ€” Fengqun Peng **๐Ÿ‘ฅ Contributors**

*Coming soon โ€” welcome to submit PRs and become a contributor!* ### โญ Star History

## ๐Ÿ“„ License - **Hardware Design** ยฉ 2026 Seeed Studio Co., Ltd. โ€” open sourced under [CERN-OHL-W-2.0](https://ohwr.org/cern_ohl_w_v2.txt) - **Firmware Code** ยฉ 2026 Seeed Studio Co., Ltd. โ€” open sourced under [Apache-2.0](https://www.apache.org/licenses/LICENSE-2.0) ### Rights and Restrictions The reBot Arm project has always followed the core philosophy of **agility, openness, responsibility, and symbiosis** to serve the developer community. Our vision is to let every enthusiast master the hardware architecture and software principles of robotic arms, and experience cutting-edge embodied-intelligence algorithms through reBot. For the first five months after launch, the project used the **CC BY-SA NC (Non-Commercial)** license, so developers could focus on iterating and improving the product during its early phase. After months of polishing, **effective May 11, 2026**, the project transitioned to the **CERN-OHL-W 2.0** open-source license, achieving **100% full-stack open source (hardware and software) with full commercial-compliance and usage rights for all scenarios**. Hardware and software use different licenses โ€” please confirm the terms applicable to the part you use. | Item | Hardware (CERN-OHL-W-2.0) | Software SDK (Apache-2.0) | | :--- | :--- | :--- | | โœ… Commercial Use | โœ… Allowed | โœ… Allowed | | โœ… Modification | โœ… Allowed | โœ… Allowed | | โœ… Redistribution | โœ… Allowed | โœ… Allowed | | โœ… Closed-source Integration | โŒ Conditional (see [CERN-OHL-W-2.0](https://ohwr.org/cern_ohl_w_v2.txt)) | โœ… Allowed (no disclosure required) | | โš ๏ธ Copyright Retention | โœ… Required | โœ… Required | | โš ๏ธ License Text Retention | โœ… Required | โœ… Required | | โš ๏ธ Modification Notice | โœ… Required (date + description) | โœ… Required (description) | | โš ๏ธ Patent Grant | โœ… Explicit | โœ… Explicit | | โš ๏ธ Source Provision on Distribution | โœ… Must provide "Complete Source" | โŒ Not required | | โš ๏ธ External/Closed Module Compatibility | โœ… Allowed (Weakly Reciprocal) | โœ… Fully allowed | | ๐Ÿ”— Relation to Other Components | Independent interface modules (External Material) may stay closed | No restrictions | | ๐Ÿ“„ Official Full Text | [CERN-OHL-W-2.0](https://ohwr.org/cern_ohl_w_v2.txt) | [Apache-2.0](https://www.apache.org/licenses/LICENSE-2.0) | ## โ˜Ž Contact Us - **Open-Source Progress & Technical Support** โ€” Yaohui: yaohui.zhu@seeed.cc - **Future Collaboration & Customization** โ€” Elaine: elaine.wu@seeed.cc