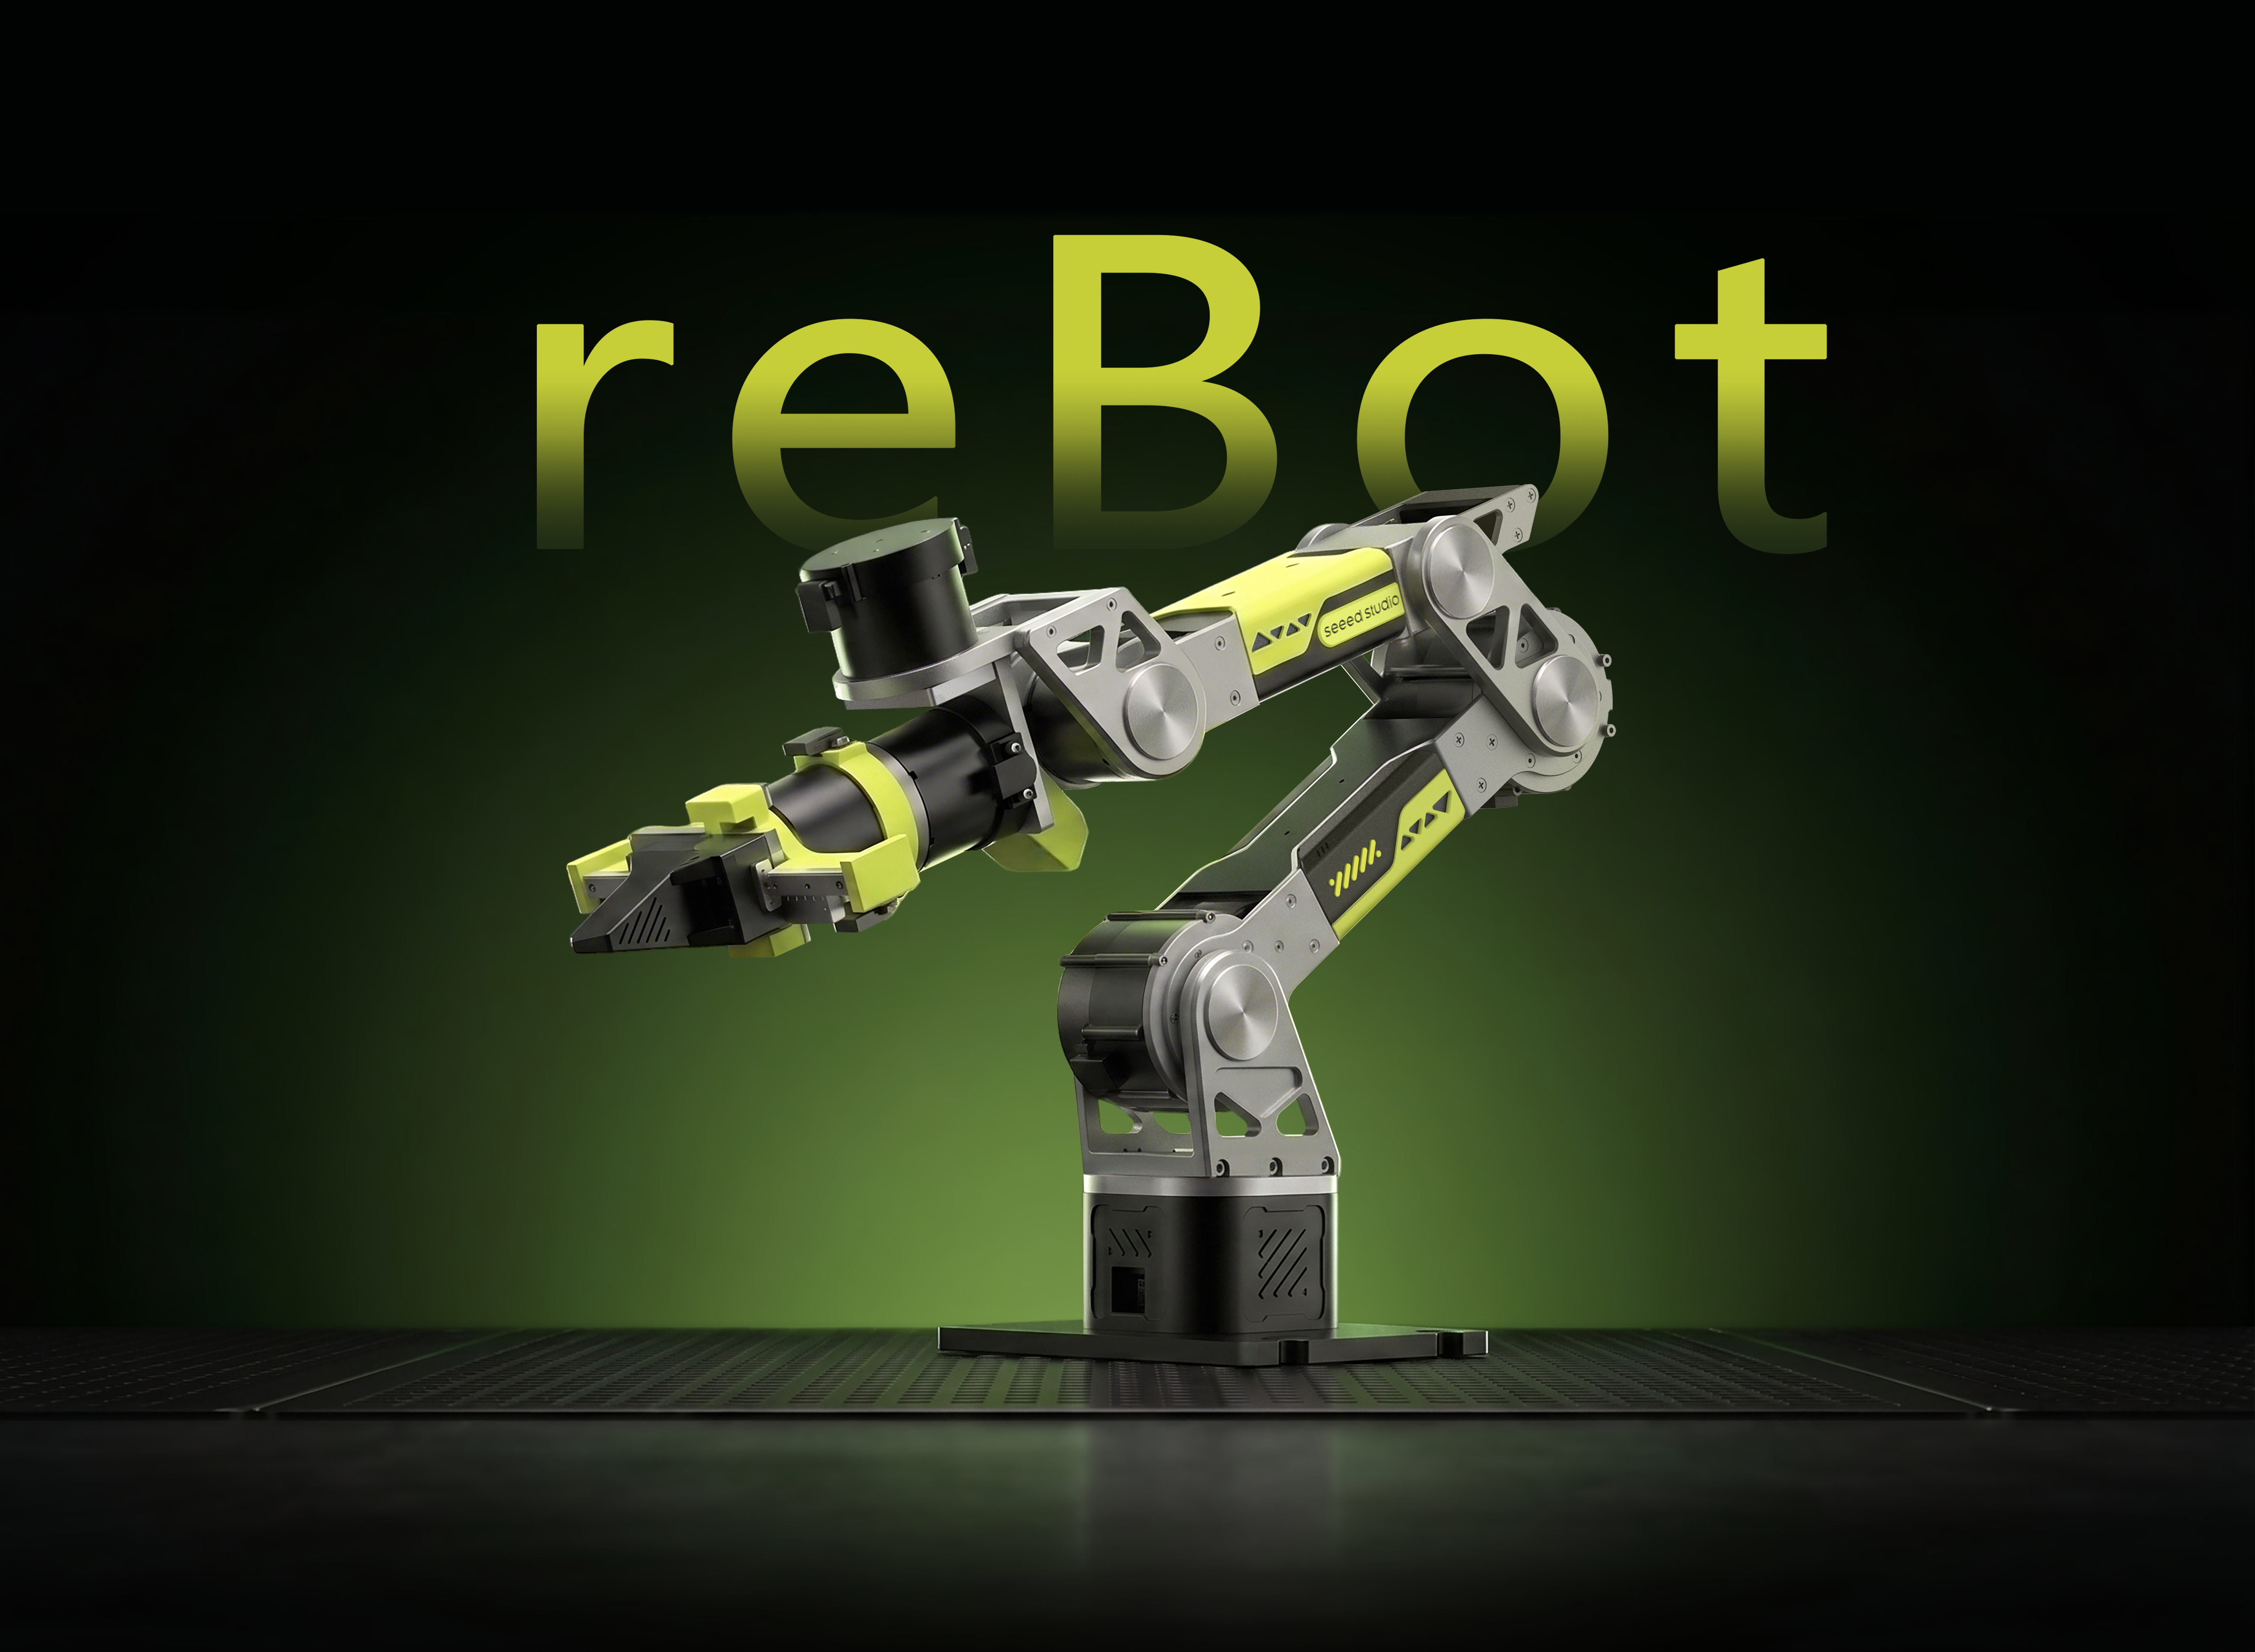
# 🦾 reBot-DevArm
**为每个开发者打造的开源机械臂**

[](./LICENSE)
[](./LICENSE)
[](#开源路线图)
[](#开源路线图)
[](#开源路线图)
[](mailto:yaohui.zhu@seeed.cc)
**100% 全开源 · 具身智能 · 软硬一体 · [商用宽松条件请看这里](#权利与限制说明)**
🌐 [落地页](https://279070161-sketch.github.io/reBot/) · 📚 [教程中心](https://wiki.seeedstudio.com/robotics_page/) · ▶ [在线体验](https://yang-ci.github.io/Rebot_Arm_AGV/)
[](https://discord.gg/AbGuqJhDpQ)
[](https://wiki.seeedstudio.com/robotics_page/)
[简体中文](README_zh.md) · [English](README.md) · [日本語](README_JP.md) · [français](README_Fr.md) · [Español](README_es.md)


 |
 |
 |
| 即将上线 | [STEP 模型文件](hardware/reBot_B601_DM/3D_Printed_Parts/D435_Gemini2_Mount.step) | [STEP 模型文件](hardware/reBot_B601_DM/3D_Printed_Parts/D405_305_Mount.step) · [设计说明](https://github.com/bowenszhu/rebot-b601-rs-d405-wrist-mount/tree/v1.0.0) | [STEP 模型文件](hardware/reBot_B601_DM/3D_Printed_Parts/D435_Gemini2_Mount.step) |
### 兼容主臂(Leader Arm)
| Star Arm 102-LD | 欢迎各类机械臂兼容接入 |
| :--- | :--- |
|
 | [系列中心](https://fashionstar.com.hk/robot-arm/star-arm-102/) · [GitHub 仓库](https://github.com/servodevelop/Star-Arm-102) |
### 爪子 DIY
| 柔性手指 | 开放兼容集成拓展 |
| :--- | :--- |
|
 | 敬请期待 |
| [手指安装座(ABS/PLA)](hardware/reBot_B601_DM/3D_Printed_Parts/Soft_Gripper_Mount.step) · [柔性手指本体(TPU 95+)](hardware/reBot_B601_DM/3D_Printed_Parts/Soft_Gripper_Finger.step) | 敬请期待 |
### 推荐可选硬件
| 类别 | 类型 | 图片 | 产品 | 链接 |
| :--- | :--- | :--- | :--- | :--- |
| **相机** | 深度相机 |
 | **Orbbec Gemini 2 3D Camera** | [Seeed Studio](https://www.seeedstudio.com/Orbbec-Gemini-2-3D-Camera-p-6464.html) |
| **相机** | 深度相机 |
 | **Orbbec Gemini 336 Depth Camera** | [Seeed Studio](https://www.seeedstudio.com/Orbbec-Gemini-336-3D-Camera-3D-p-6662.html) |
| **相机** | 深度相机 |
 | **Orbbec Gemini 335LG 3D Camera** | [Seeed Studio](https://www.seeedstudio.com/Orbbec-Gemini-335LG-3D-Camera-p-6541.html) |
| **相机** | 深度相机 |
 | **SLAMTEC Aurora S** | [Seeed Studio](https://www.seeedstudio.com/SLAMTEC-Aurora-S-AI-Integrated-Spatial-Perception-System-p-6669.html) |
| **相机** | 深度相机 |
 | **Intel RealSense Depth Camera D435i** | [Seeed Studio](https://www.seeedstudio.com/Intel-RealSense-Depth-Camera-D435i-p-4423.html) |
| **相机** | 深度相机 |
 | **RealSense Depth Camera D405** | [Seeed Studio](https://www.seeedstudio.com/RealSense-D405-3D-Camera-p-6758.html) |
| **相机** | 单目相机 |
 | **Sensing SG3S-ISX031C-GMSL2F 3MP GMSL2 Camera** | [Seeed Studio](https://www.seeedstudio.com/SG3S-ISX031C-GMSL2F-p-6245.html) |
| **相机** | 单目相机 |
 | **ET-S231 Megapixel 120° 广角 1080P USB 相机** | [Seeed Studio](https://www.seeedstudio.com/ET-S231-120-USB-Camera-p-6683.html) |
| **麦克风** | 麦克风阵列 |
 | **reSpeaker Flex XVF3800 Circular-4 with XIAO ESP32S3** | [Seeed Studio](https://www.seeedstudio.com/reSpeaker-Flex-XVF3800-Circular-4-with-XIAO-ESP32S3-p-6739.html) |
| **麦克风** | 麦克风阵列 |
 | **reSpeaker XMOS XVF3800** | [Seeed Studio](https://www.seeedstudio.com/ReSpeaker-XVF3800-USB-Mic-Array-p-6488.html) |
| **控制器** | 边缘控制器 |
 | **reComputer J3011-Orin Nano 8GB** | [Seeed Studio](https://www.seeedstudio.com/reComputer-J3011-p-5590.html) |
| **控制器** | 边缘控制器 |
 | **NVIDIA Jetson AGX Thor Developer Kit** | [Seeed Studio](https://www.seeedstudio.com/NVIDIA-Jetson-AGX-Thor-Developer-Kit-p-9965.html) |
## 🎓 全栈机器人生态
reBot-DevArm 不仅是一个机械臂,更是一个机器人学习社区。我们免费共享以下通用教程:
**🖥️ 边缘计算与主控**
- [](https://wiki.seeedstudio.com/NVIDIA_Jetson/) —— AI 推理与算力核心
- [](https://wiki.seeedstudio.com/raspberry-pi-devices/) —— 通用 Linux 开发环境
- [](https://wiki.seeedstudio.com/SeeedStudio_XIAO_Series_Introduction/) —— 低功耗无线控制节点
**📡 传感器与外设**
- **电机舵机** —— [达妙 / 高擎 / 灵足 / 脉塔 / 飞特 / 华馨京](https://wiki.seeedstudio.com/robotics_page/)
- **视觉感知** —— [深度相机 / 激光雷达 / 视觉算法](https://wiki.seeedstudio.com/robotics_page/)
- **听觉交互** —— [reSpeaker 麦克风阵列 / 语音识别 / 空间感知(DoA)](https://wiki.seeedstudio.com/control_rebot_arm_using_voice_with_respeaker_flex/)
- **运动姿态** —— [IMU(6 轴/9 轴)/ 陀螺仪 / 磁力计](https://wiki.seeedstudio.com/Sensor_accelerometer/)
- **综合套件** —— [更多机器人传感器与驱动案例](https://wiki.seeedstudio.com/robotics_page/)
> 👉 **[点击进入 Wiki 知识库](https://wiki.seeedstudio.com/)** —— 所有教程免费查阅。
## 🙌 致谢与贡献者
开源之路从不孤单。reBot-DevArm 的诞生离不开 Seeed Studio 的全力支持、全球开源社区与优秀的硬件合作伙伴。我们向以下项目与团队致以最诚挚的敬意:
**🌍 生态与软件支持**
- [Seeed Studio](https://www.seeedstudio.com/) —— 提供全方位的硬件供应链与技术支持
- [Hugging Face LeRobot](https://github.com/huggingface/lerobot) —— 优秀的端到端机器人学习框架
- [NVIDIA Isaac Sim](https://developer.nvidia.com/isaac/sim) —— 强大的机器人仿真与合成数据平台
**⚙️ 核心硬件伙伴**
- [达妙科技 Damiao Technology](https://www.damiaokeji.com/)
- [灵足时代 Robstride](https://robstride.com/)
- [华馨京科技 Fashion Star](https://fashionrobo.com/)
**💡 致敬先驱项目**
- [SO-ARM100](https://github.com/TheRobotStudio/SO-ARM100/tree/main)
- [Mobile ALOHA](https://github.com/tonyzhaozh/aloha)
- [Dummy-Robot(稚晖君)](https://github.com/peng-zhihui/Dummy-Robot)
- [OpenArm](https://openarm.dev/)
- [I2RT](https://i2rt.com/)
- [TRLC-DK1](https://github.com/robot-learning-co/trlc-dk1)
**🎃 原型机贡献者**
- SeeedStudio AI Robotics Team —— Yaohui Zhu(yaohui.zhu@seeed.cc)
- SeeedStudio STU —— Wentao Dong
- SeeedStudio STU —— Weiwei Xu
- SeeedStudio Purchasing Department —— Fengqun Peng
**👥 贡献者**
