> 🚀 TNY-360 V2 Kits are available in preorders, shipping early december. [Get your kit here](https://store.tny-robotics.com).
>
> The repository will be updated with the V2 files in a couple of days.
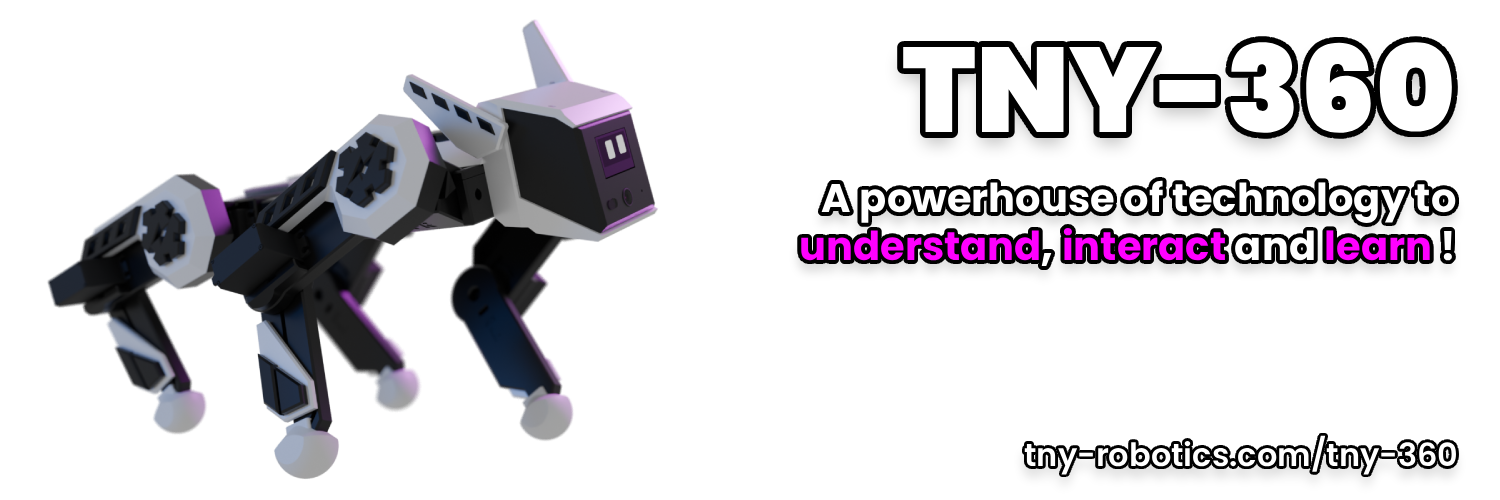
# TNY-360 - Open-Source Robot Dog
[](https://creativecommons.org/licenses/by-nc-sa/4.0/)
[](https://espressif.com)
[](https://docs.espressif.com/projects/esp-idf/en/latest/esp32/)
[](https://deepwiki.com/TNY-Robotics/TNY-360)
**The open-source quadruped you can actually *build*, *repair* and *modify* yourself.**
[🌐 Website](https://tny-robotics.com/tny-360) • [📖 Documentation](https://tny-robotics.com/docs/tny-360/) • [💬 Discord](https://discord.gg/XGABkx5A4y) • [☕ Support Us](https://ko-fi.com/tnyrobotics)
# 🛠️ Want to build one?
> ### **[👉 START HERE: The Official Step-by-Step Guide 👈](https://tny-robotics.com/docs/tny-360/build-it)**
> *From ordering the first screw to assembling the last part, this guide covers it all.*
### 🗂️ Quick Links (For Advanced Makers)
If you know what you are doing and just want the raw files, here is your toolkit:
* 🛒 **[Bill of Materials](https://tny-robotics.com/docs/tny-360/archive/v1/practical-guides/sourcing/)** - What to buy, tools needed, and where to find them. (coming soon for V2)
* 📐 **[CAD & 3D Files](./CAD)** - Grab the `.STL` and `.3MF` files for your 3D printer. (coming soon for V2)
* ⚡ **[PCB Designs (Gerbers)](./PCBs)** - Files to order the custom PCBs used in the robot. (coming soon for V2)
* 🧠 **[ESP32 Firmware](./Firmware)** - The ESP-IDF C++ firmware & drivers powering the robot.
* 🛠️ **[Servo Modding Tutorial](https://tny-robotics.com/docs/tny-360/archive/v1/practical-guides/sourcing/motors/)** - Learn the Op-Amp trick to get position-feedback on MG996R servos.
## ✨ Features
* 🧬 **Dual-Core Architecture:**
A segregated system using the ESP32-S3. Core 1 ("Reflex") runs a strict 200Hz kinematics/control loop, while Core 0 ("Brain") handles WebSockets, UI, and orchestration.
* 🔄 **Closed-Loop at 200Hz:**
We ditched blind PWM. The TNY-360 uses digital MG996R servos modified with a custom **Op-Amp buffer PCB** for noise-free, high-speed position feedback.
* ⚡ **Zero Cable Spaghetti:**
A fully modular hardware ecosystem. Dedicated PCBs (Control, Sensor, Brain, Power, etc.) communicate cleanly via JST cables and low profile pin headers.
* 🛠️ **Smart Auto-Calibration:**
Features mechanical endstops for assembly validation and runtime algorithms that compensate for backlash and actuator latency.
* 🧩 **STEM & Expansion Ready:**
Program the robot using [TNY-Coder](https://github.com/TNY-Robotics/TNY-Coder) (our block-based web app) or build custom hardware modules using the dorsal I2C/Power expansion port.
## ⚙️ Hardware Specs
### 🧠 Core & Power
* **MCU:** ESP32-S3 N16R8 Module
* **Power:** 3S LiPo Battery (6x Samsung INR18650-25R)
* **Monitoring:** INA219 (Voltage/Current sensor)
### 🦵 Actuators
* **Legs:** 12x MG996R Servos *(Must be modified for analog feedback)*
* **Head:** 2x ~~SG-90~~ MG90D Micro Servos (Ears)
* **Driver:** PCA9685 (16-Channel PWM)
### 📡 Sensors & I/O
* **Vision:** OV2640 Camera Module
* **Distance:** VL53L0X Time-of-Flight (Lidar)
* **Orientation:** ~~MPU6050~~ LSM6DS3 6-axis IMU
* **Display:** ~~SH1106~~ SSD1306 OLED (128x64)
* **Audio:** I2S MEMS Microphone + Speaker
---
## 📂 Repository Structure
* `BOM/` — **Bill of Materials.** Detailed lists of all components, PCBs, screws, and cables, with links.
* `CAD/` — **Hardware Source.** FreeCAD project files and ready-to-print STLs. (coming soon for V2)
* `PCBs/` — **PCB Designs.** Gerber files, BOMs, and Pick'n'Place for all PCBs. (coming soon for V2)
* `Firmware/` — **Codebase.** PlatformIO project (C++/ESP-IDF).
* `Firmware/components/` — **Drivers.** Custom libraries for sensors/actuators.
## ☕ Support the Project
TNY-360 is, and will always be, 100% free and open-source.
If you love the project, learned something new, or just want to help us build the next generation of affordable robots, consider supporting our R&D! Your tips help us buy prototyping materials (filament, PCBs, burned servos 😅) and keep the servers running.
 *(Even if you can't donate, simply starring this repository or sharing it with a friend is already a massive support!)*
## 🤝 Contributing
We love contributions!
* **Code:** Please follow the ESP-IDF coding style.
* **Hardware:** Submit PRs with updated FreeCAD files or improvements.
* Found a bug? [Open an Issue](https://github.com/TNY-Robotics/TNY-360/issues).
## 📄 License & Authors
**TNY-360** is maintained by the [TNY Robotics Team](https://tny-robotics.com).
Licensed under **CC BY-NC-SA 4.0**.
*You are free to share and adapt this material for non-commercial purposes, as long as you provide attribution and share alike.*
[](http://creativecommons.org/licenses/by-nc-sa/4.0/)
Need help? Contact us [by mail](mailto:contact@tny-robotics.com) or join our [Discord](https://discord.gg/XGABkx5A4y).