# torobo_mujoco
## Installation
### Install MuJoCo
Python 3.8 or higher is required.
For more information, please refer to https://github.com/google-deepmind/mujoco .
```
pip install mujoco
```
### Install torobo_mujoco
```
git clone https://github.com/TokyoRobotics/torobo_mujoco.git
cd torobo_mujoco
```
## Test
```
cd example
python example_torobo2.py
```
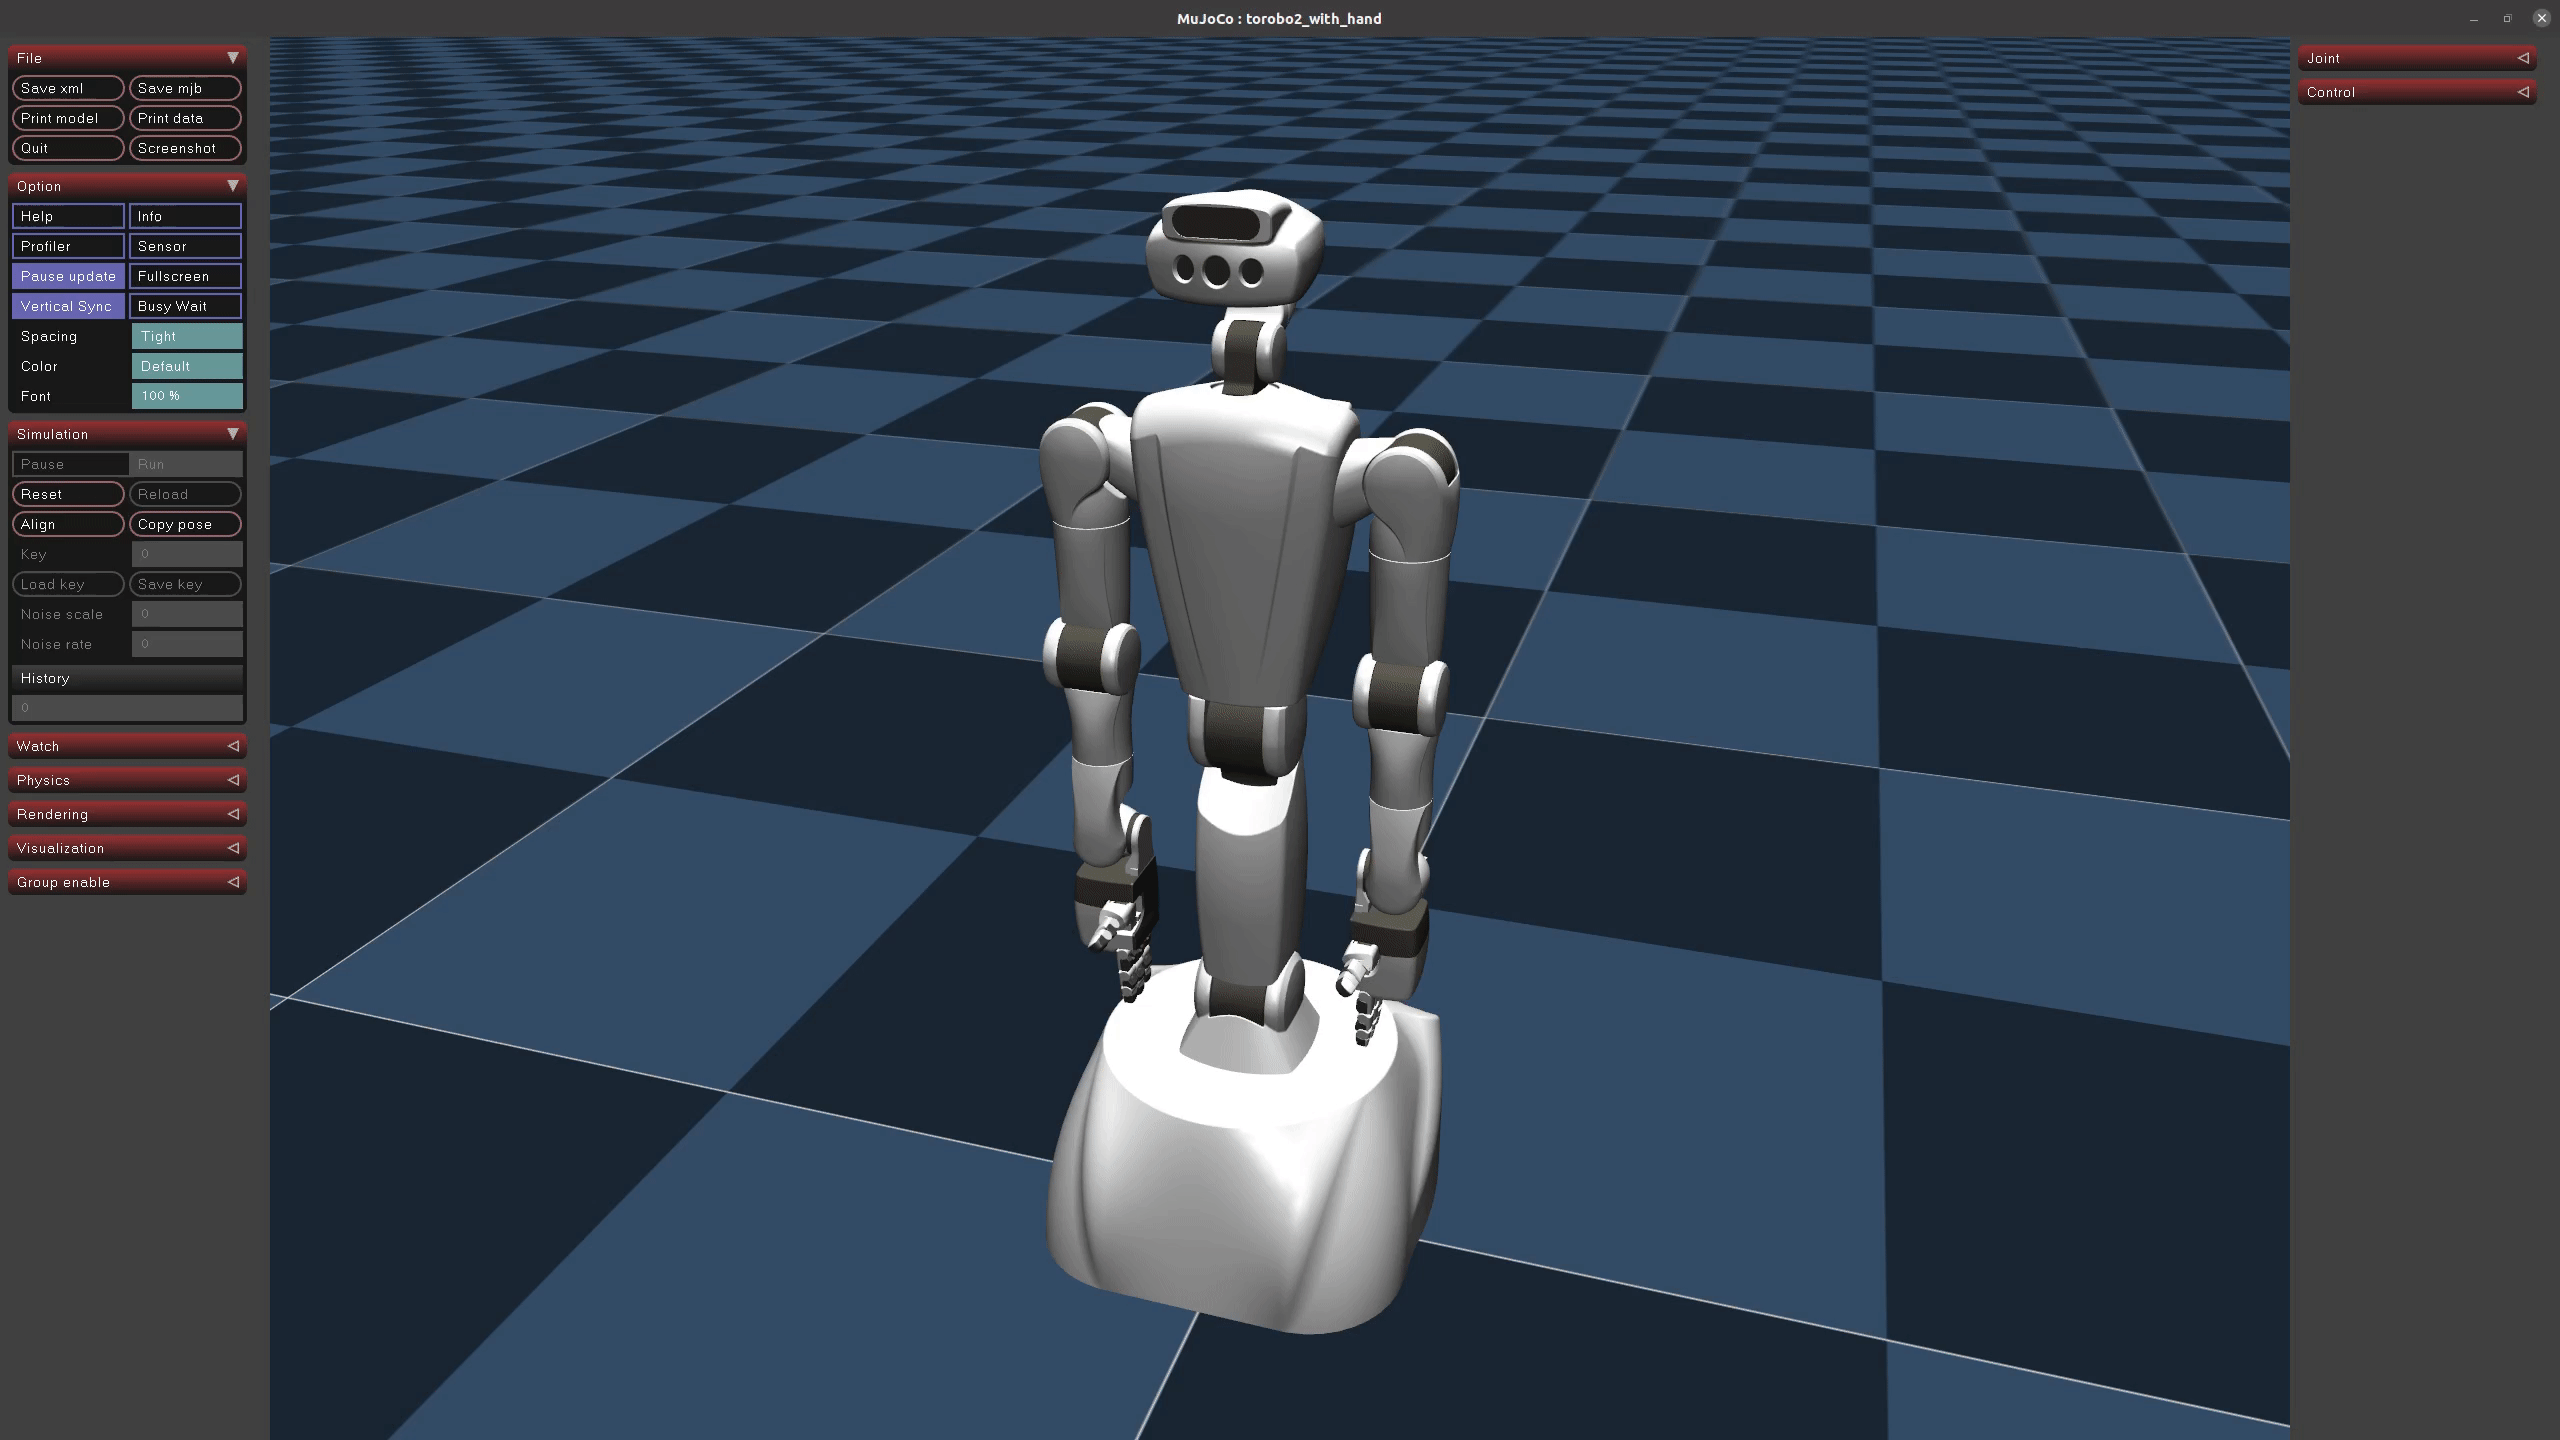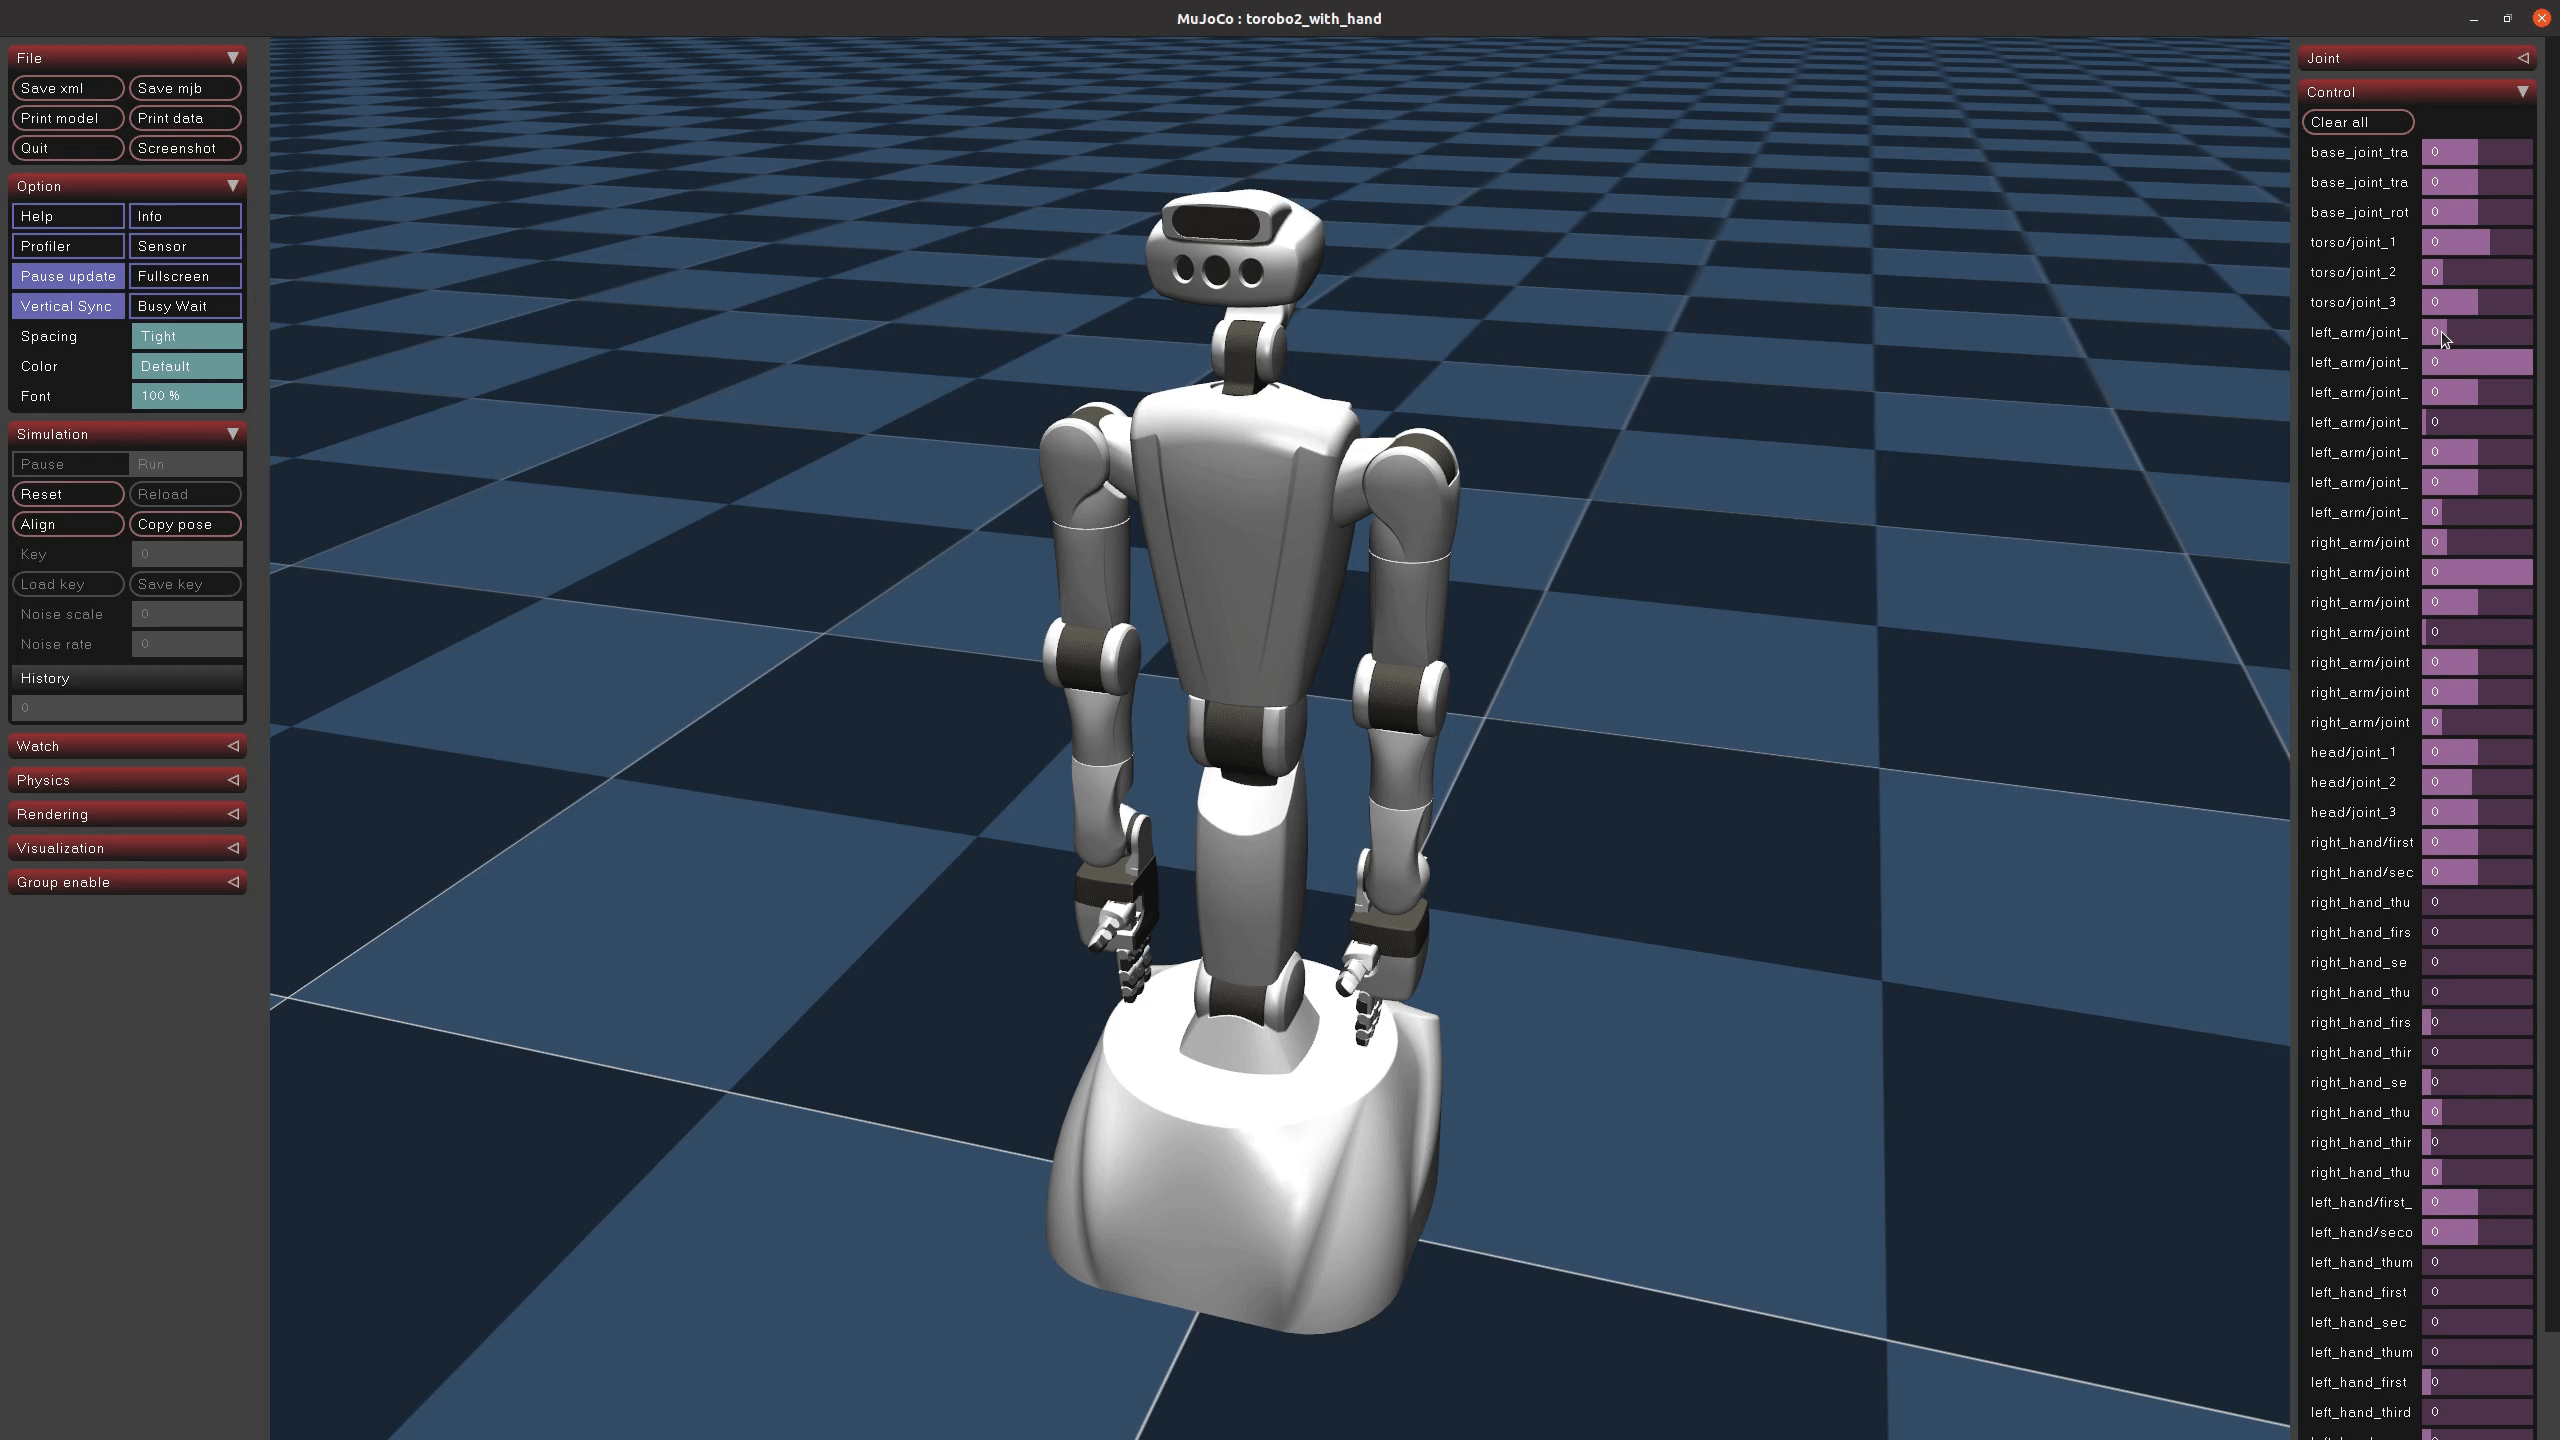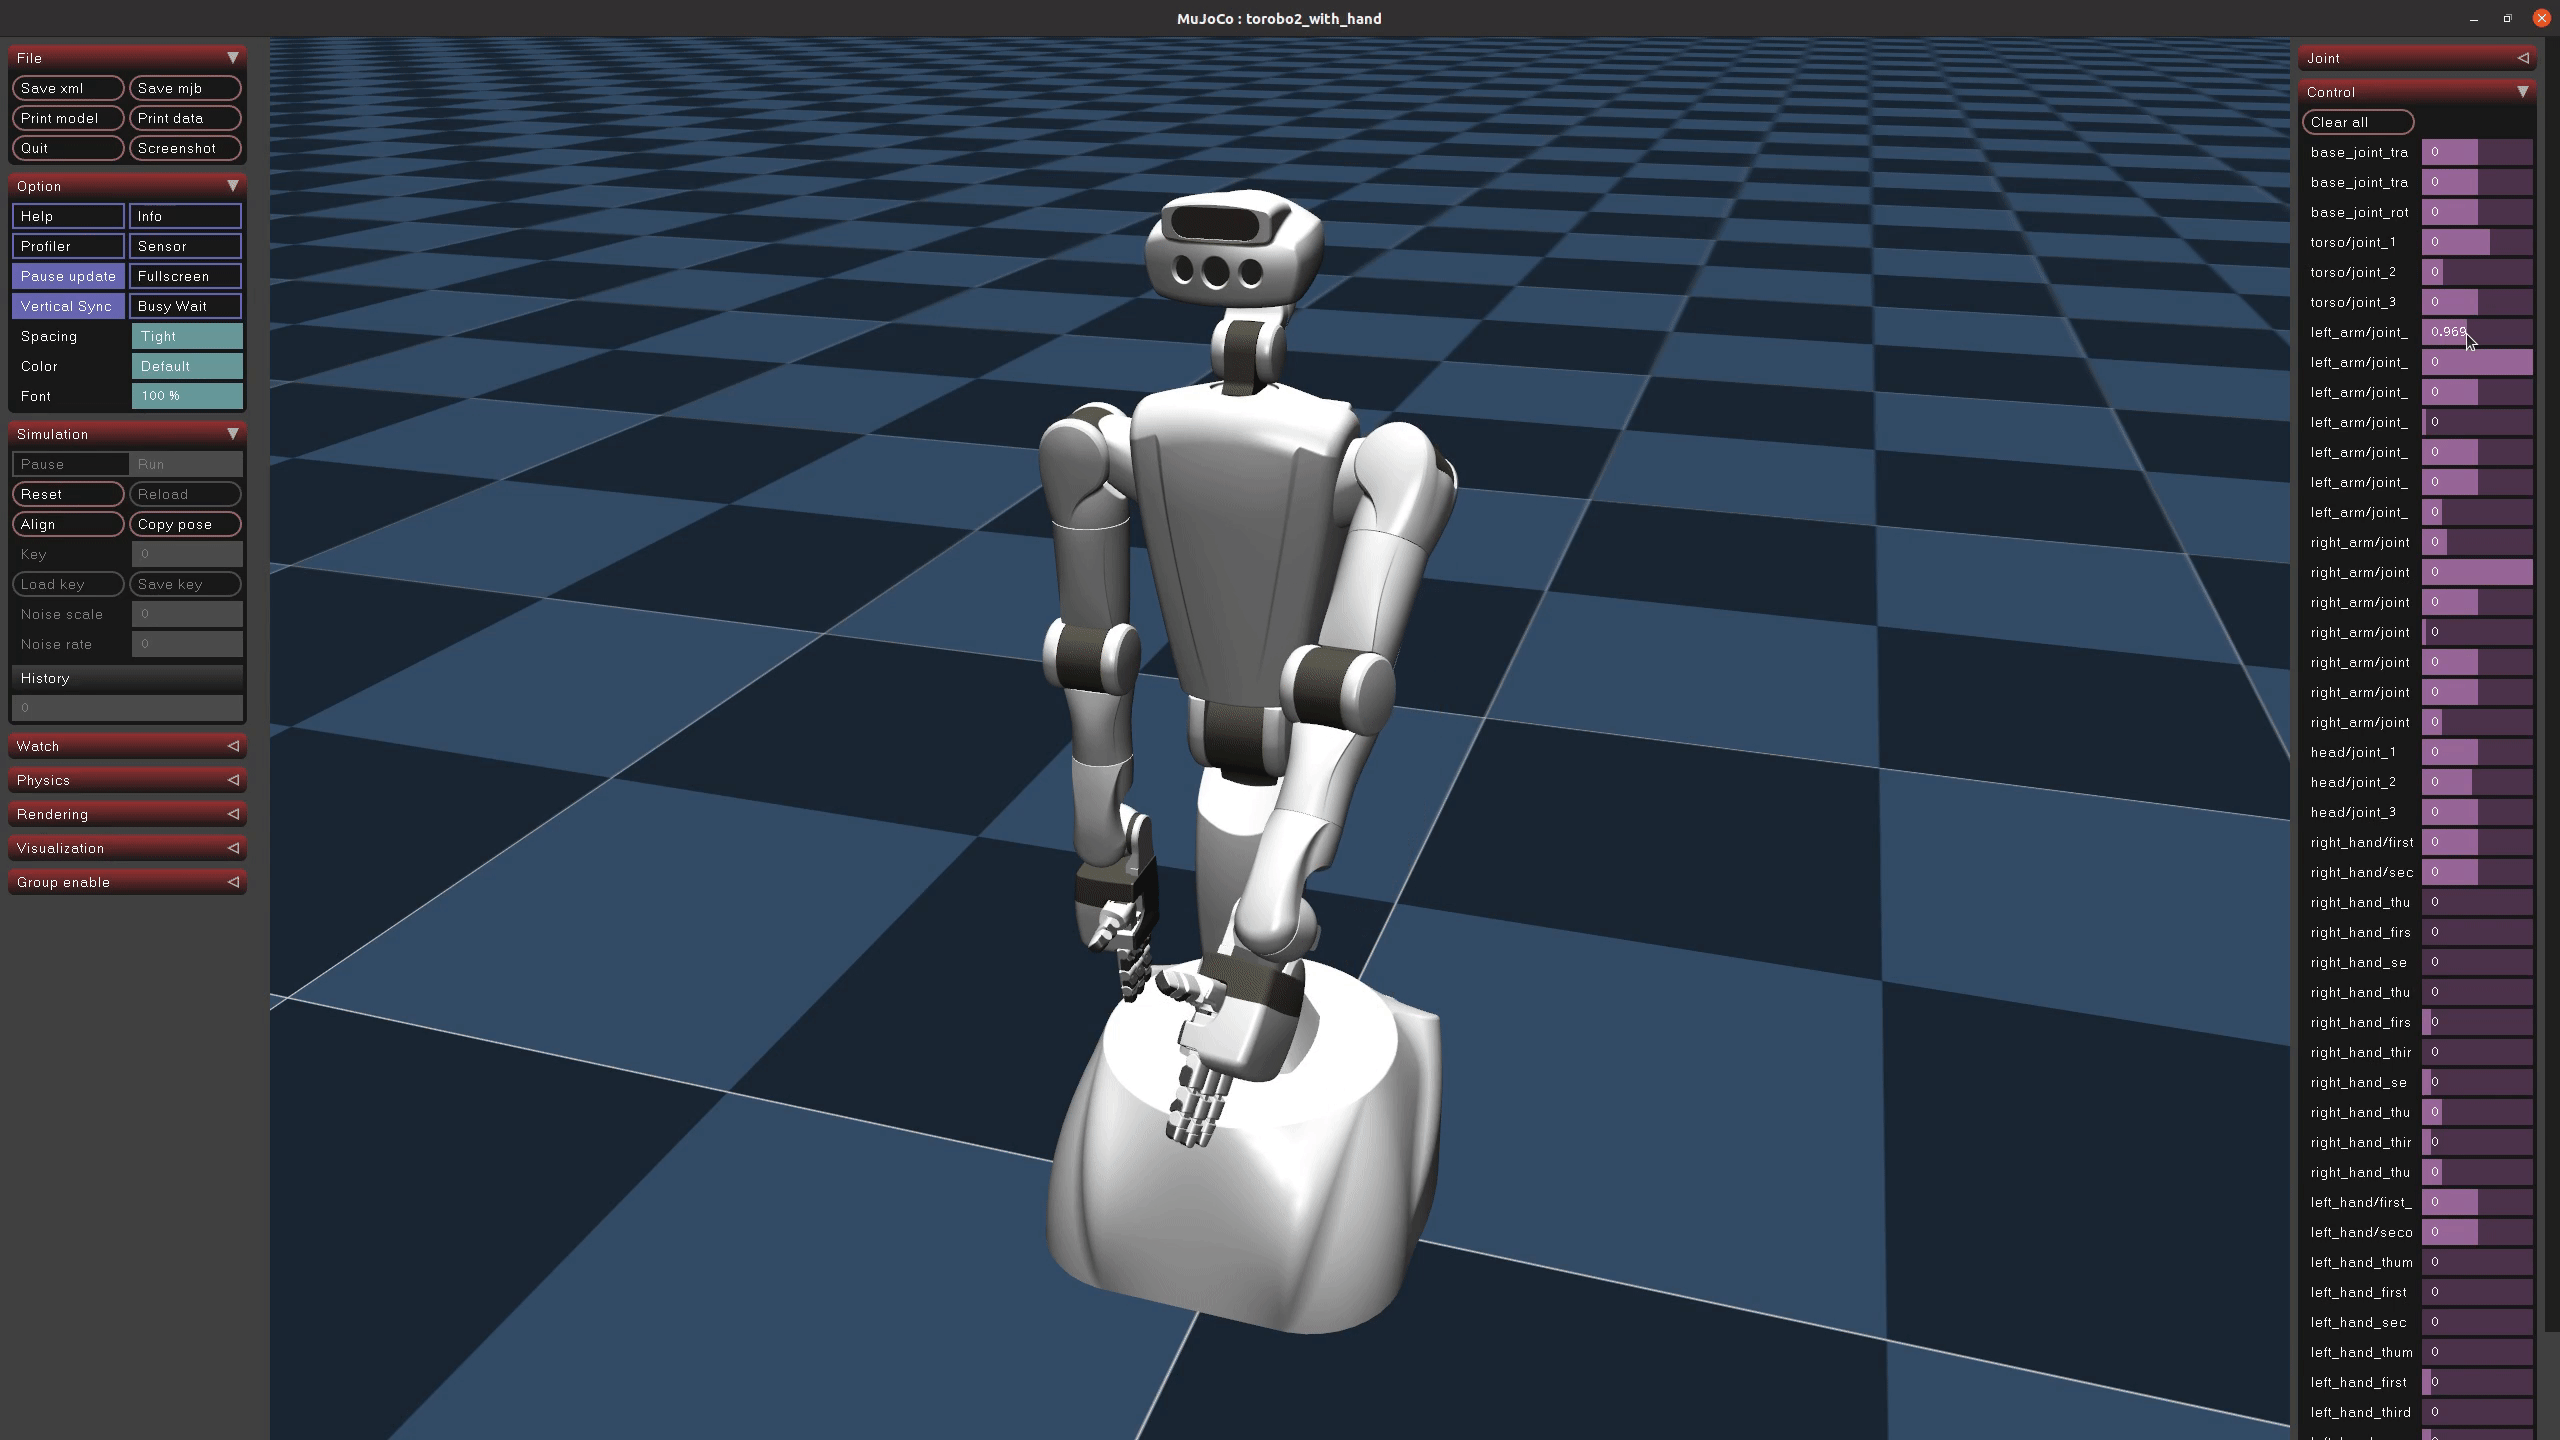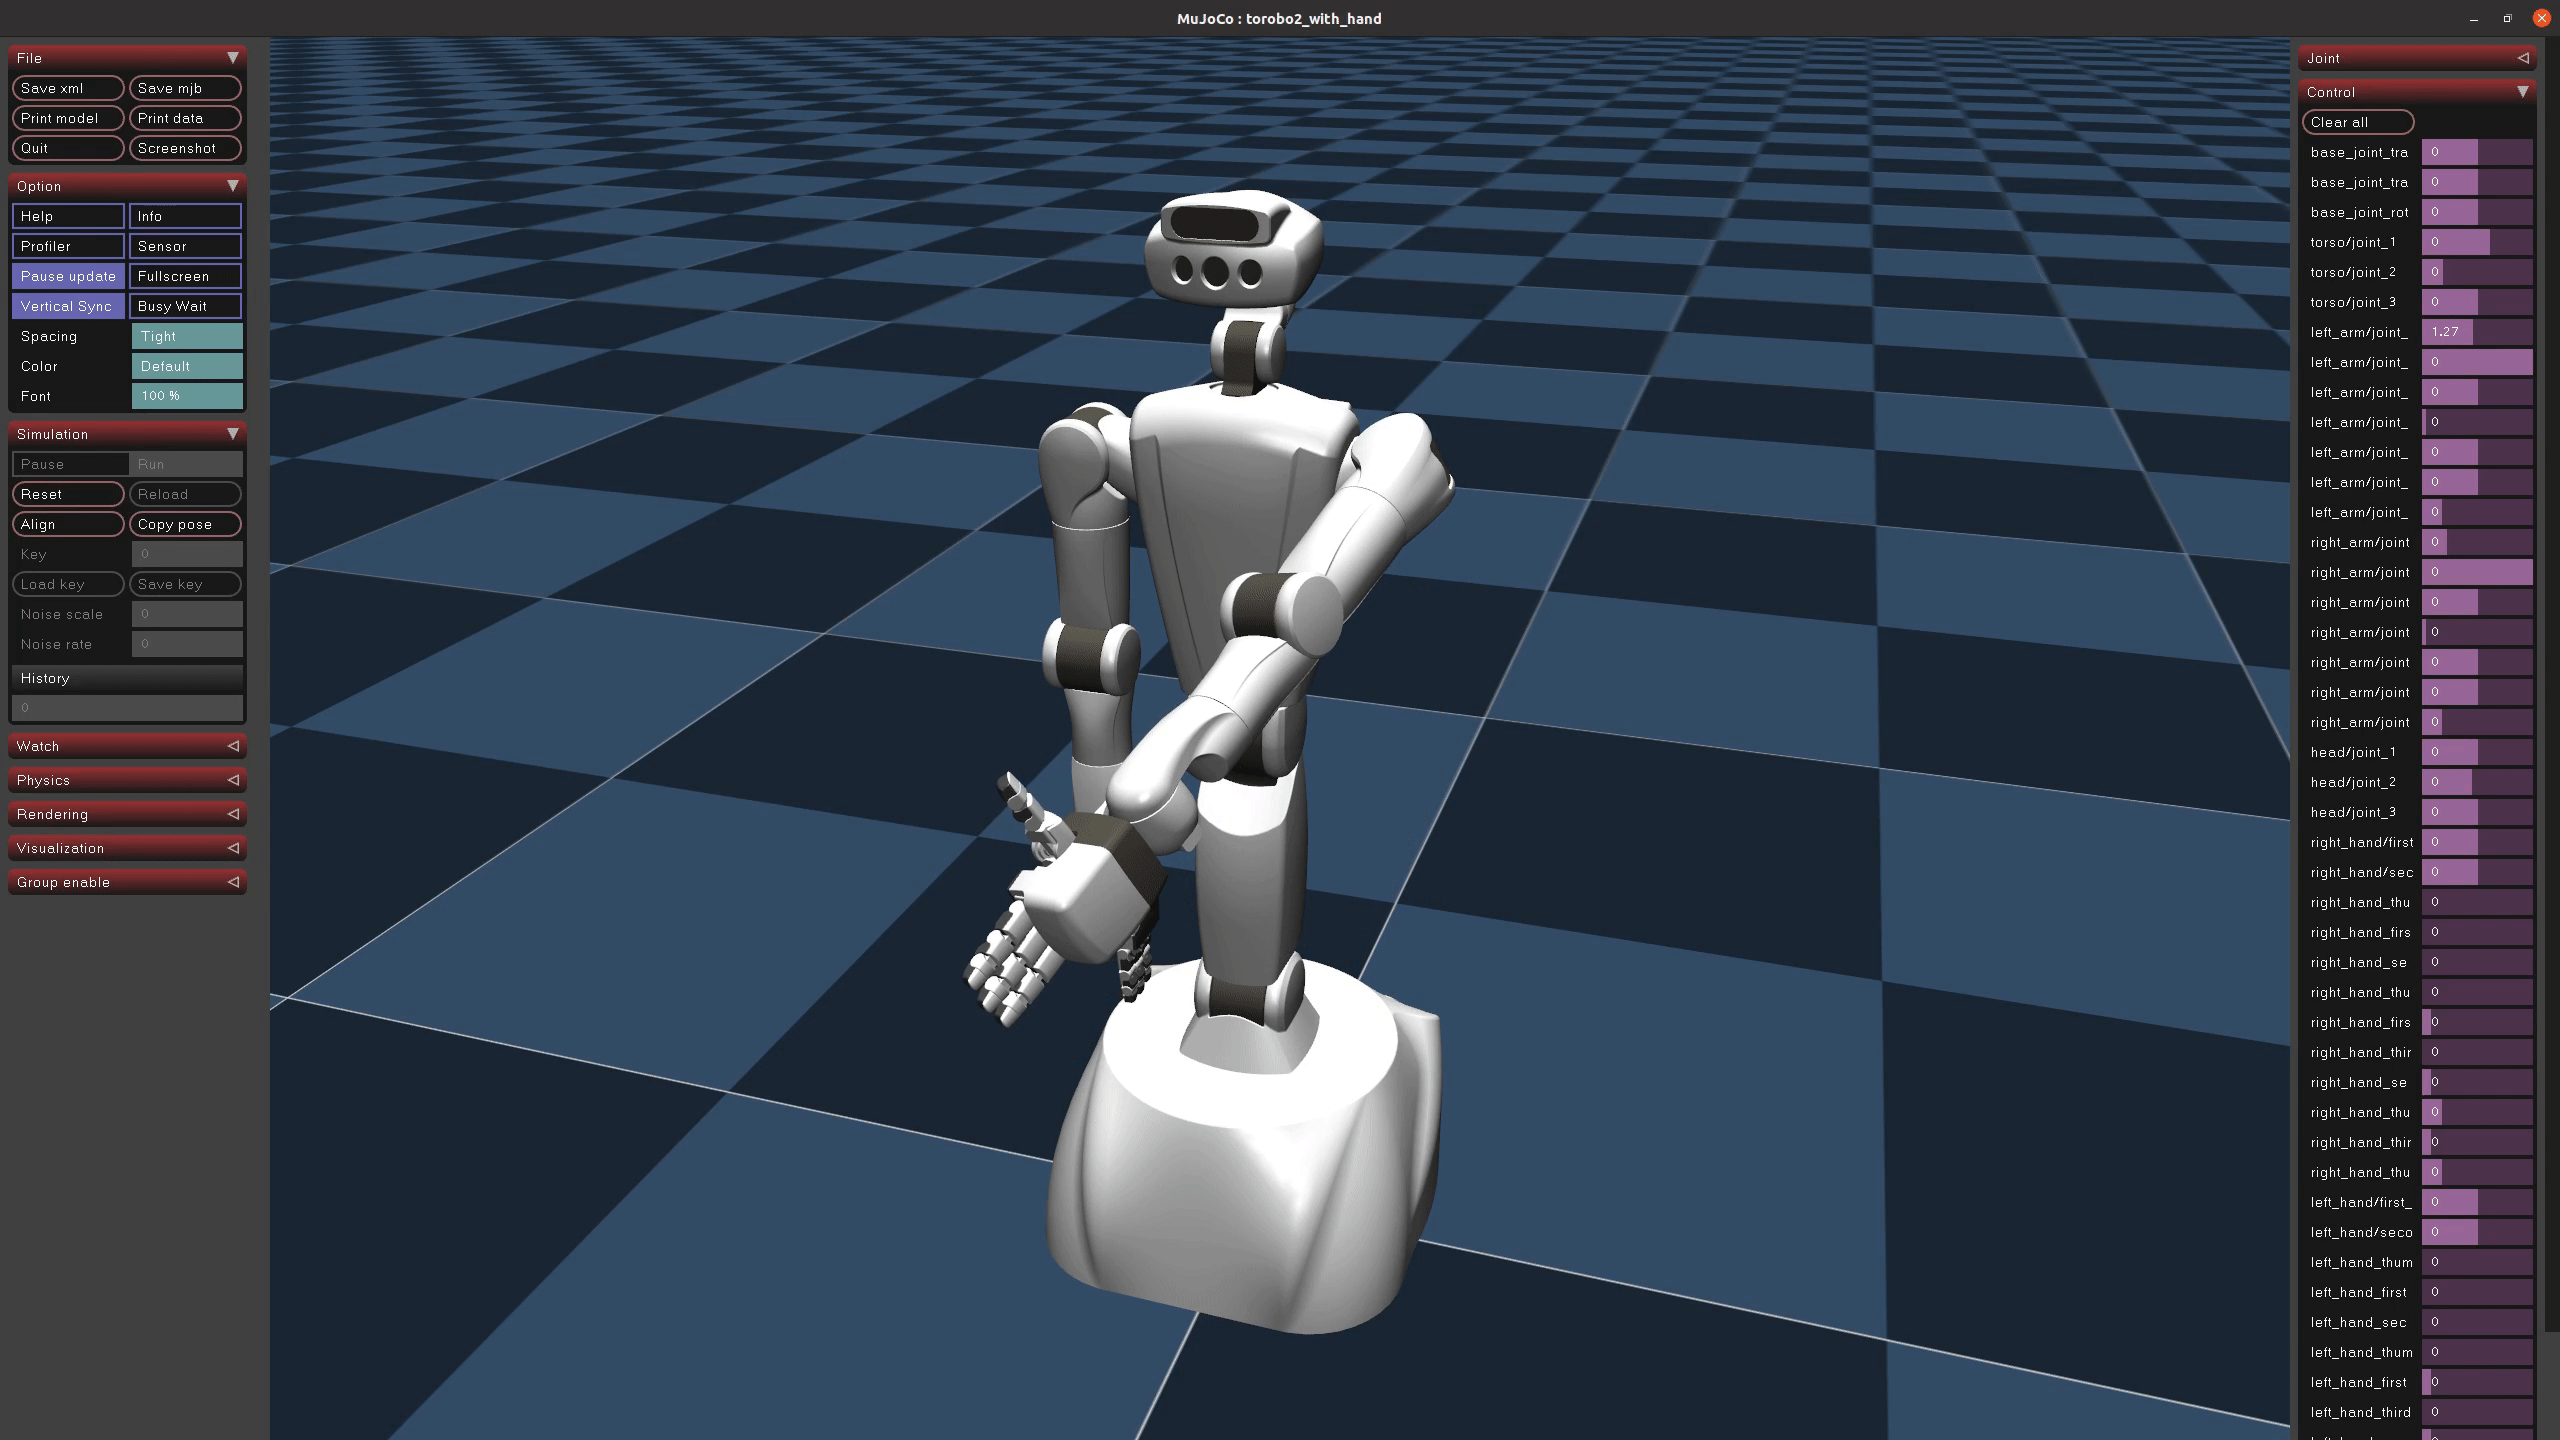
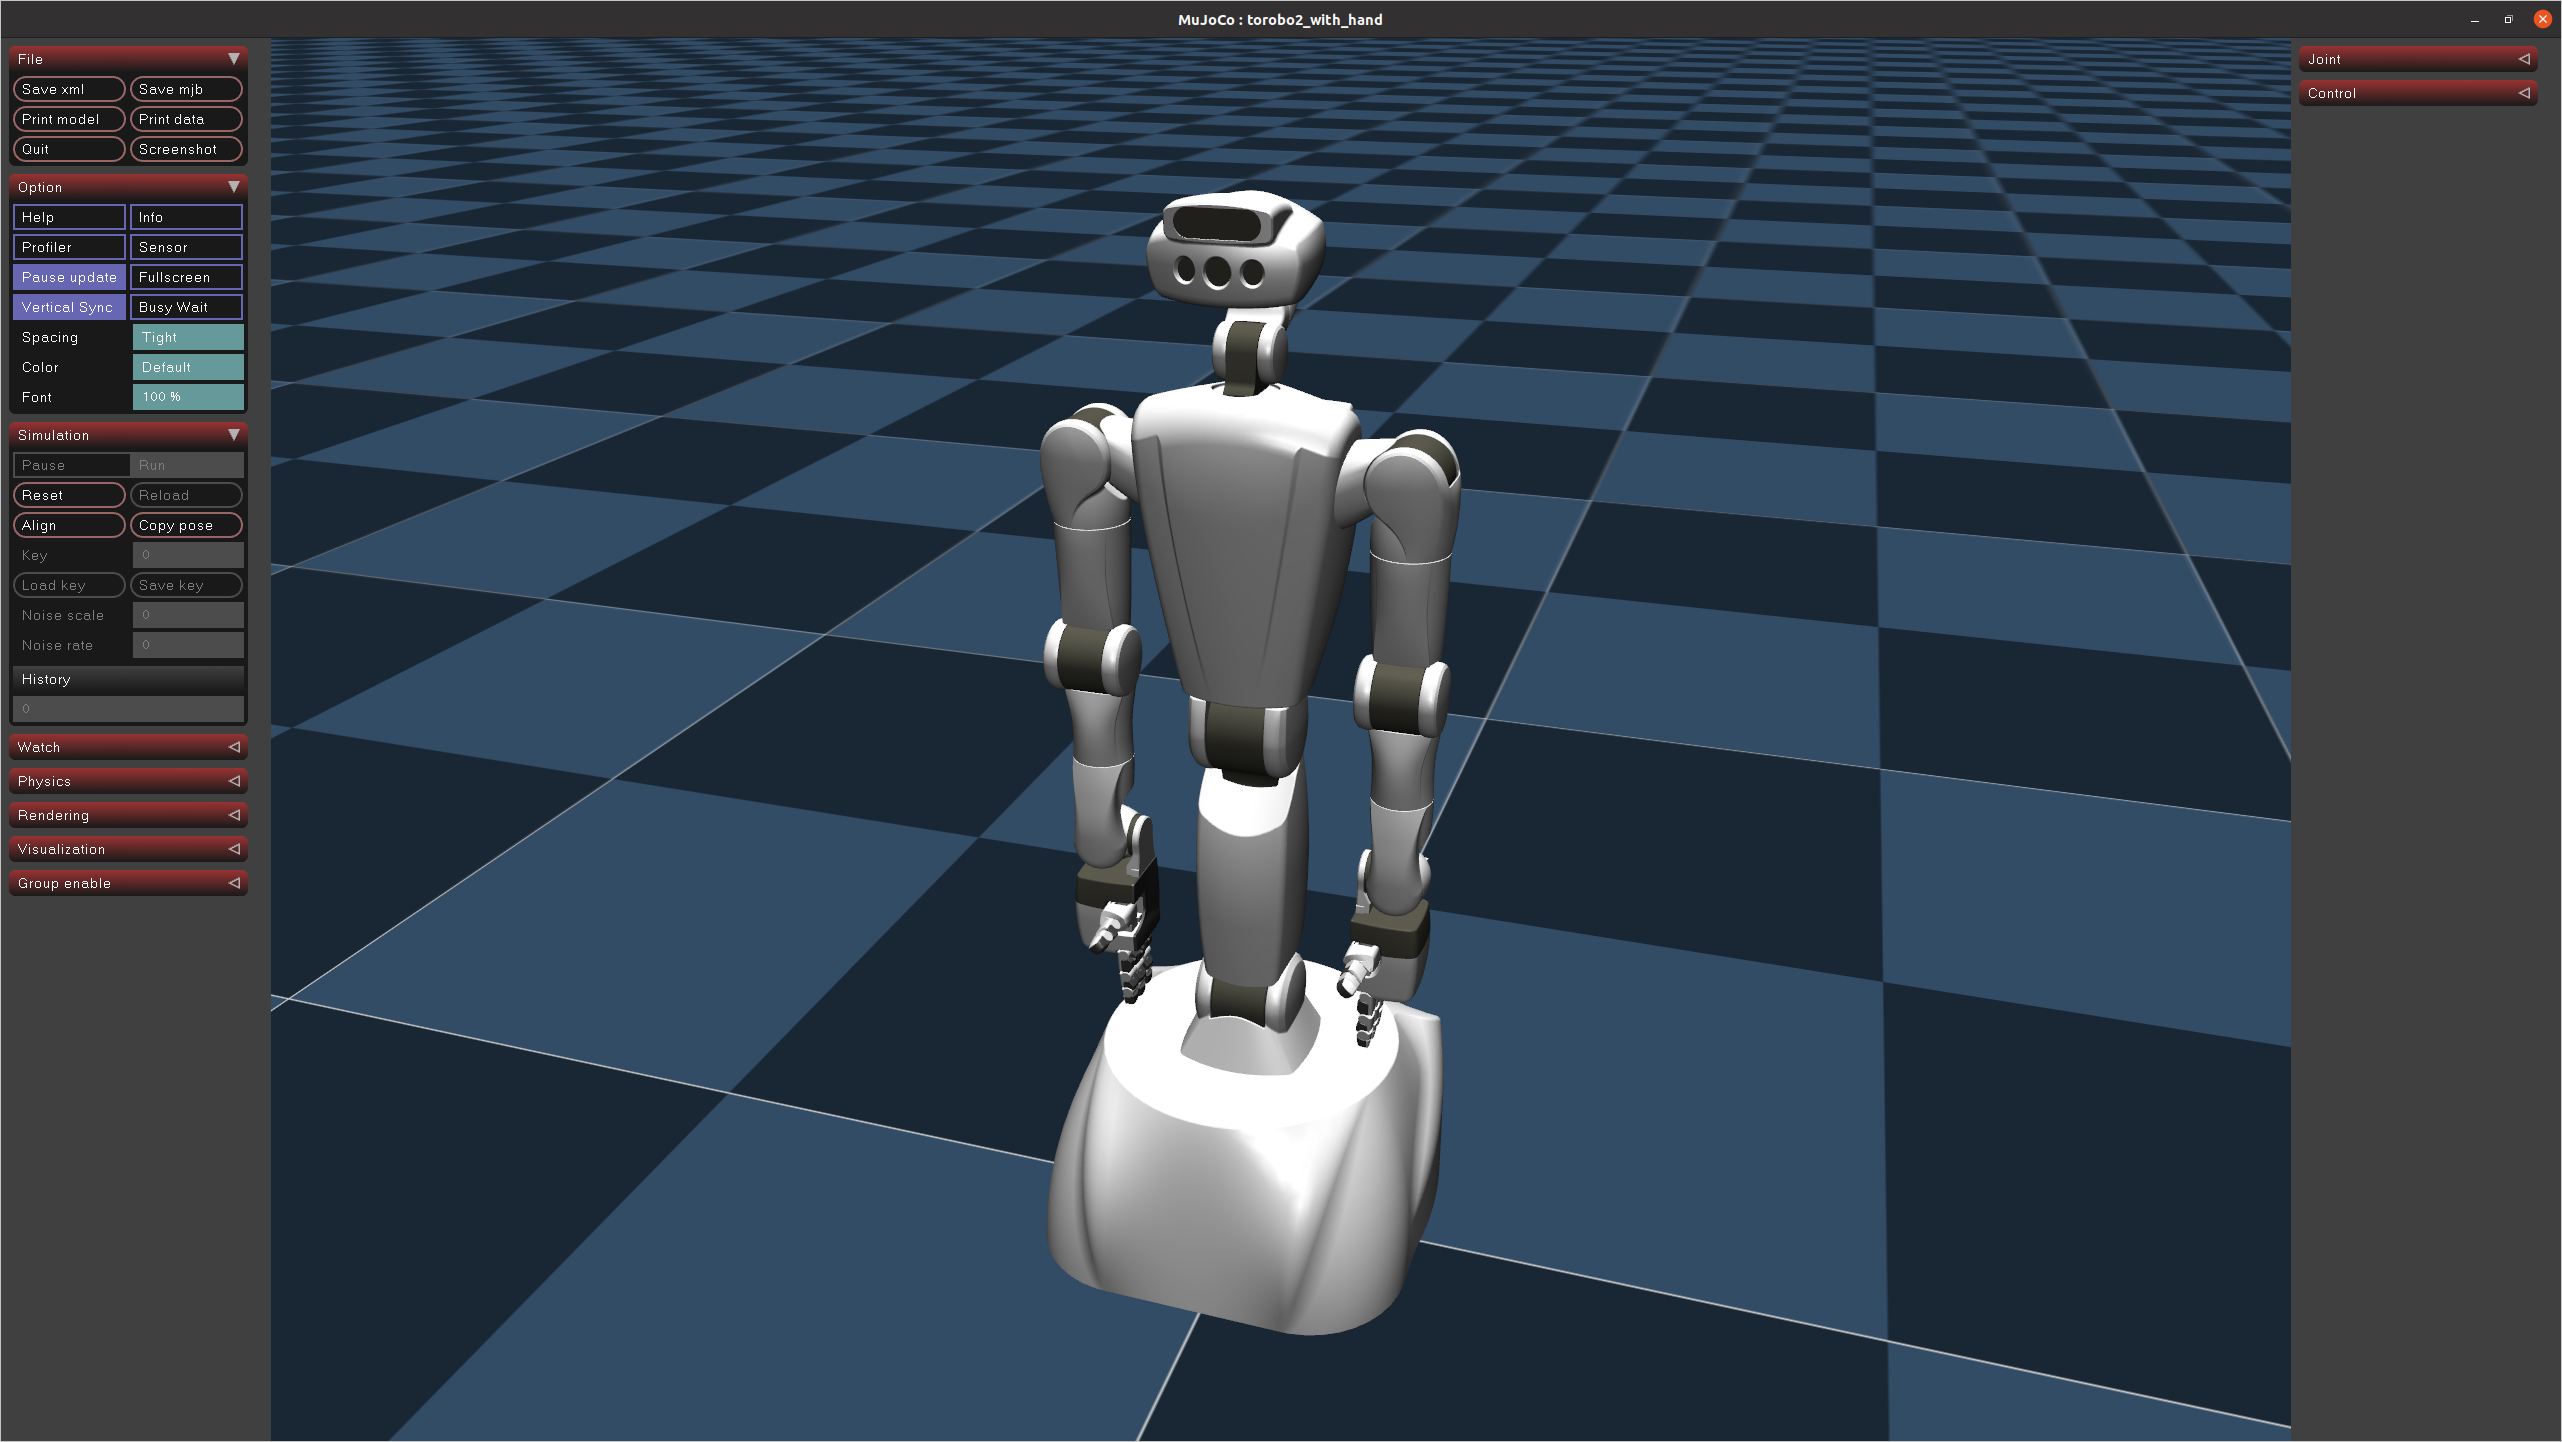 Move joints by dragging in Control tab.
 ## Example motion
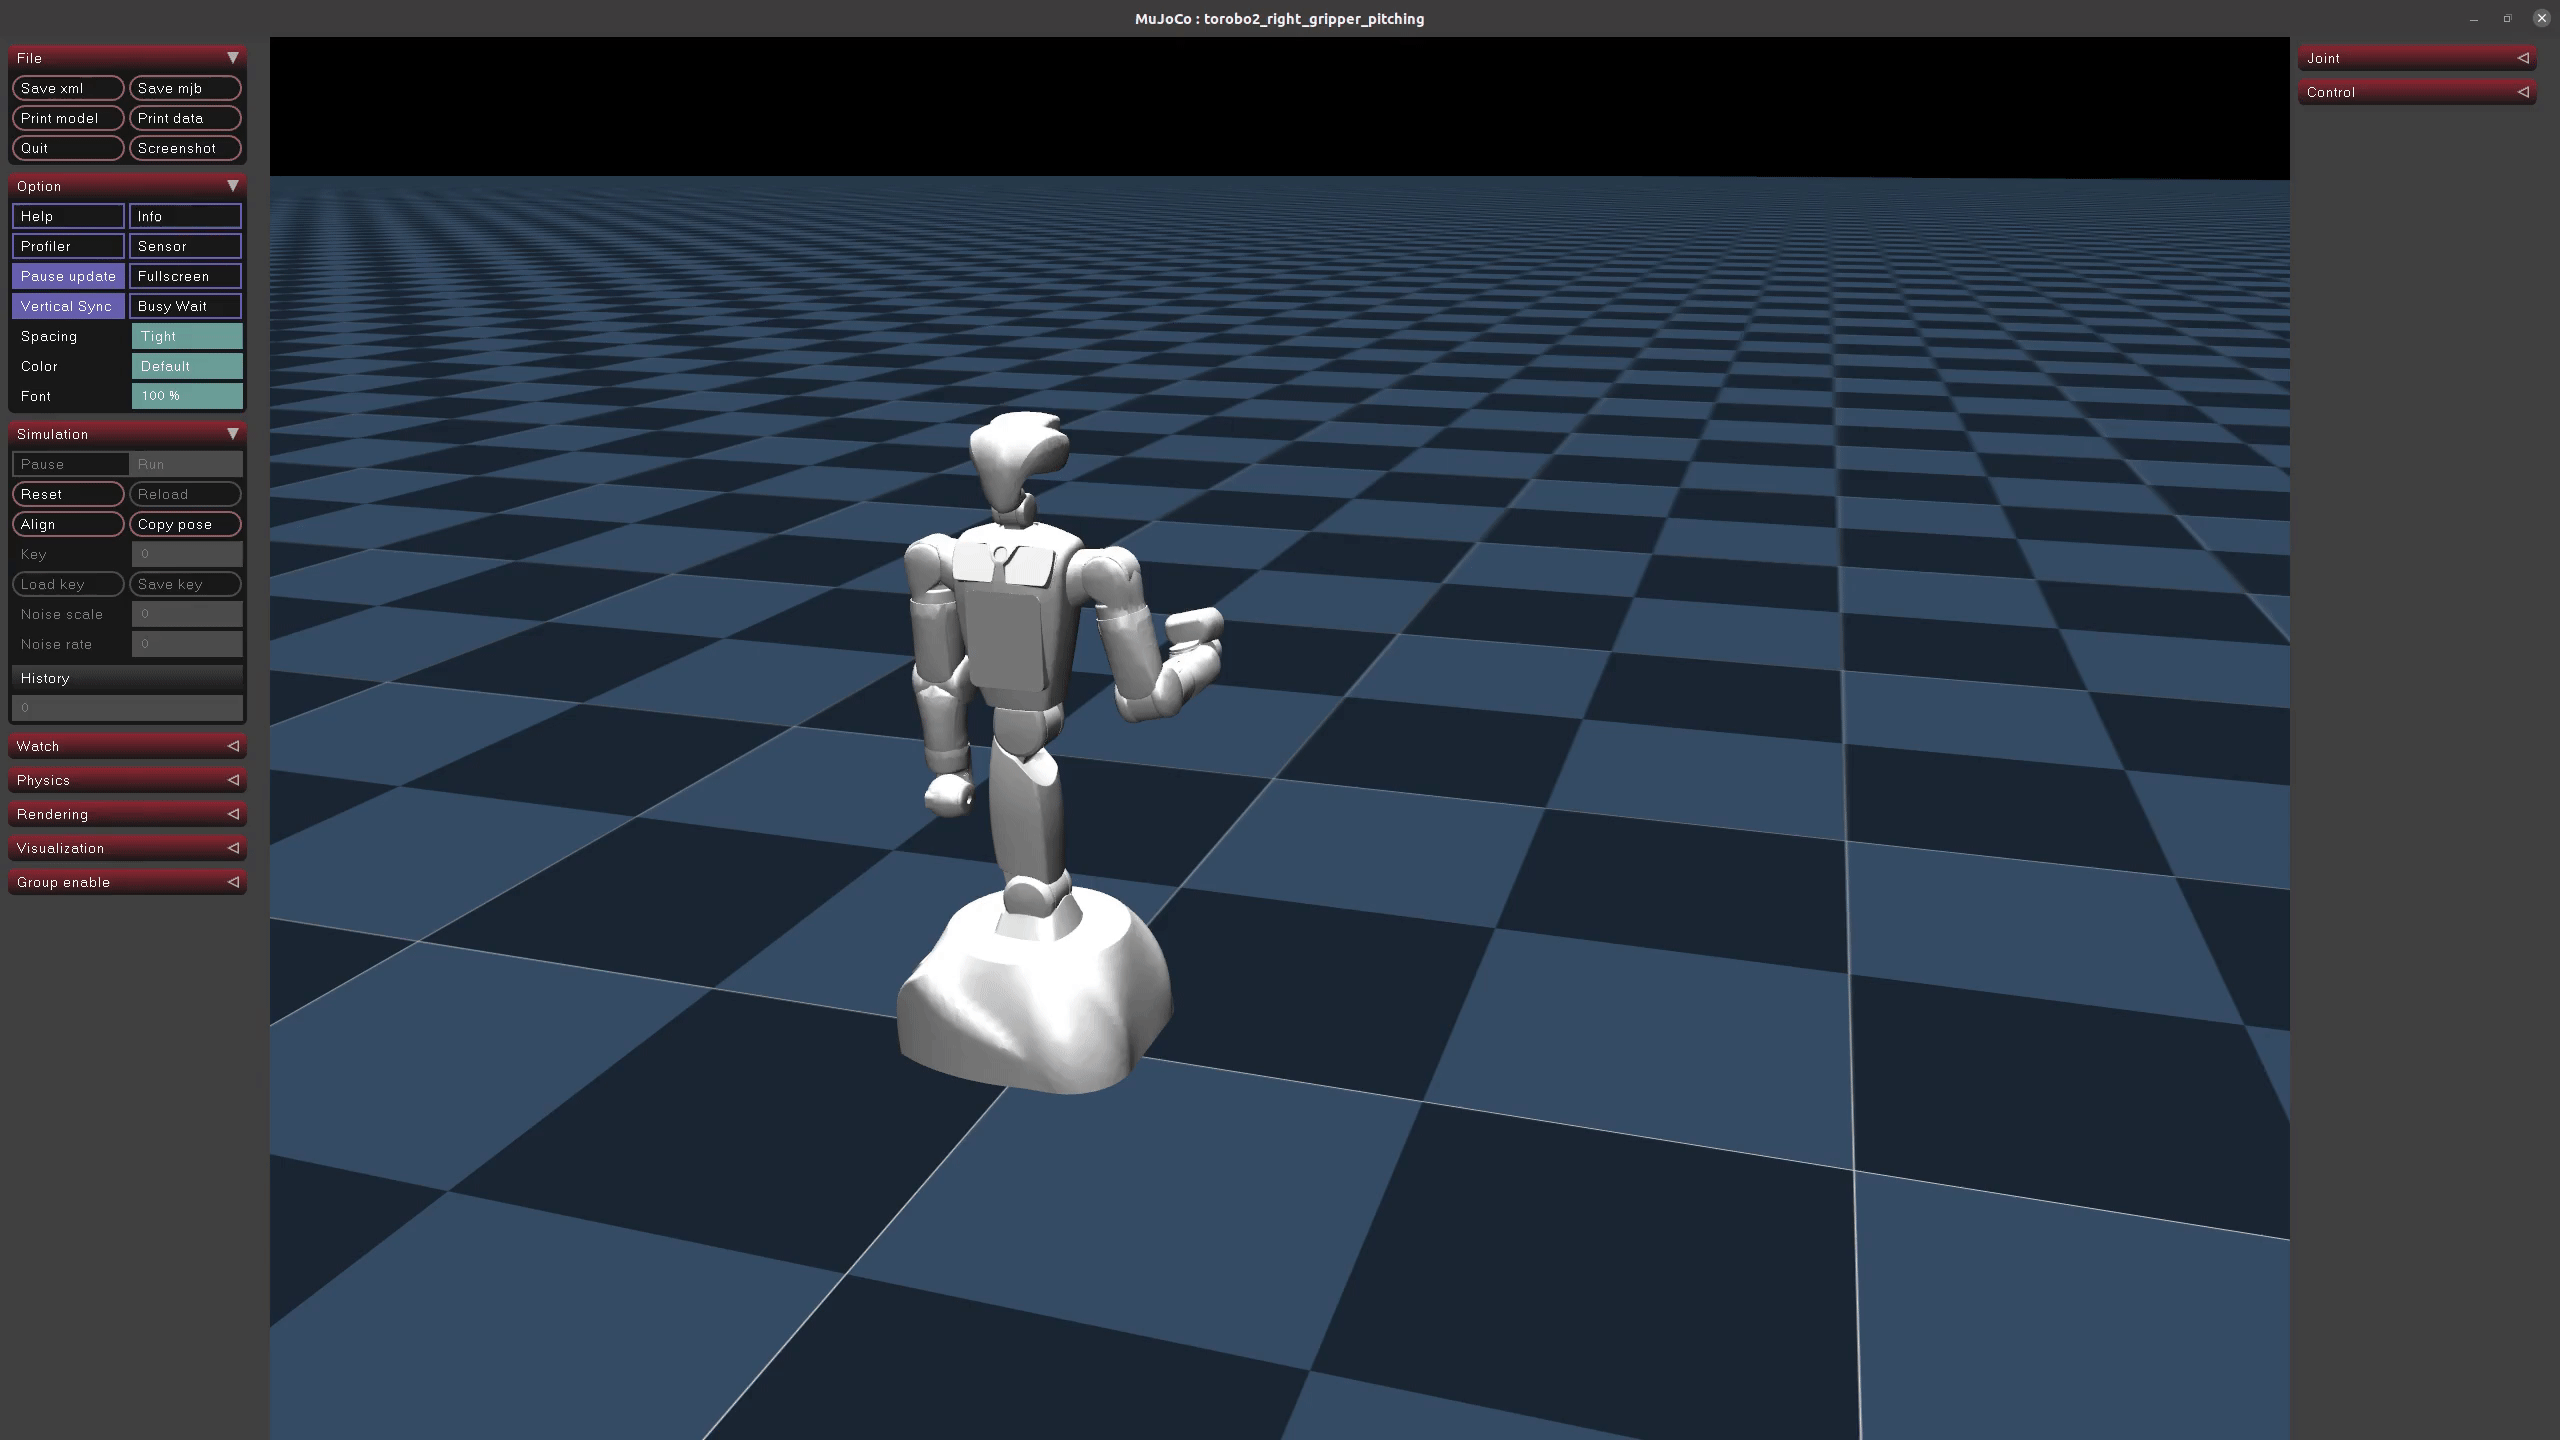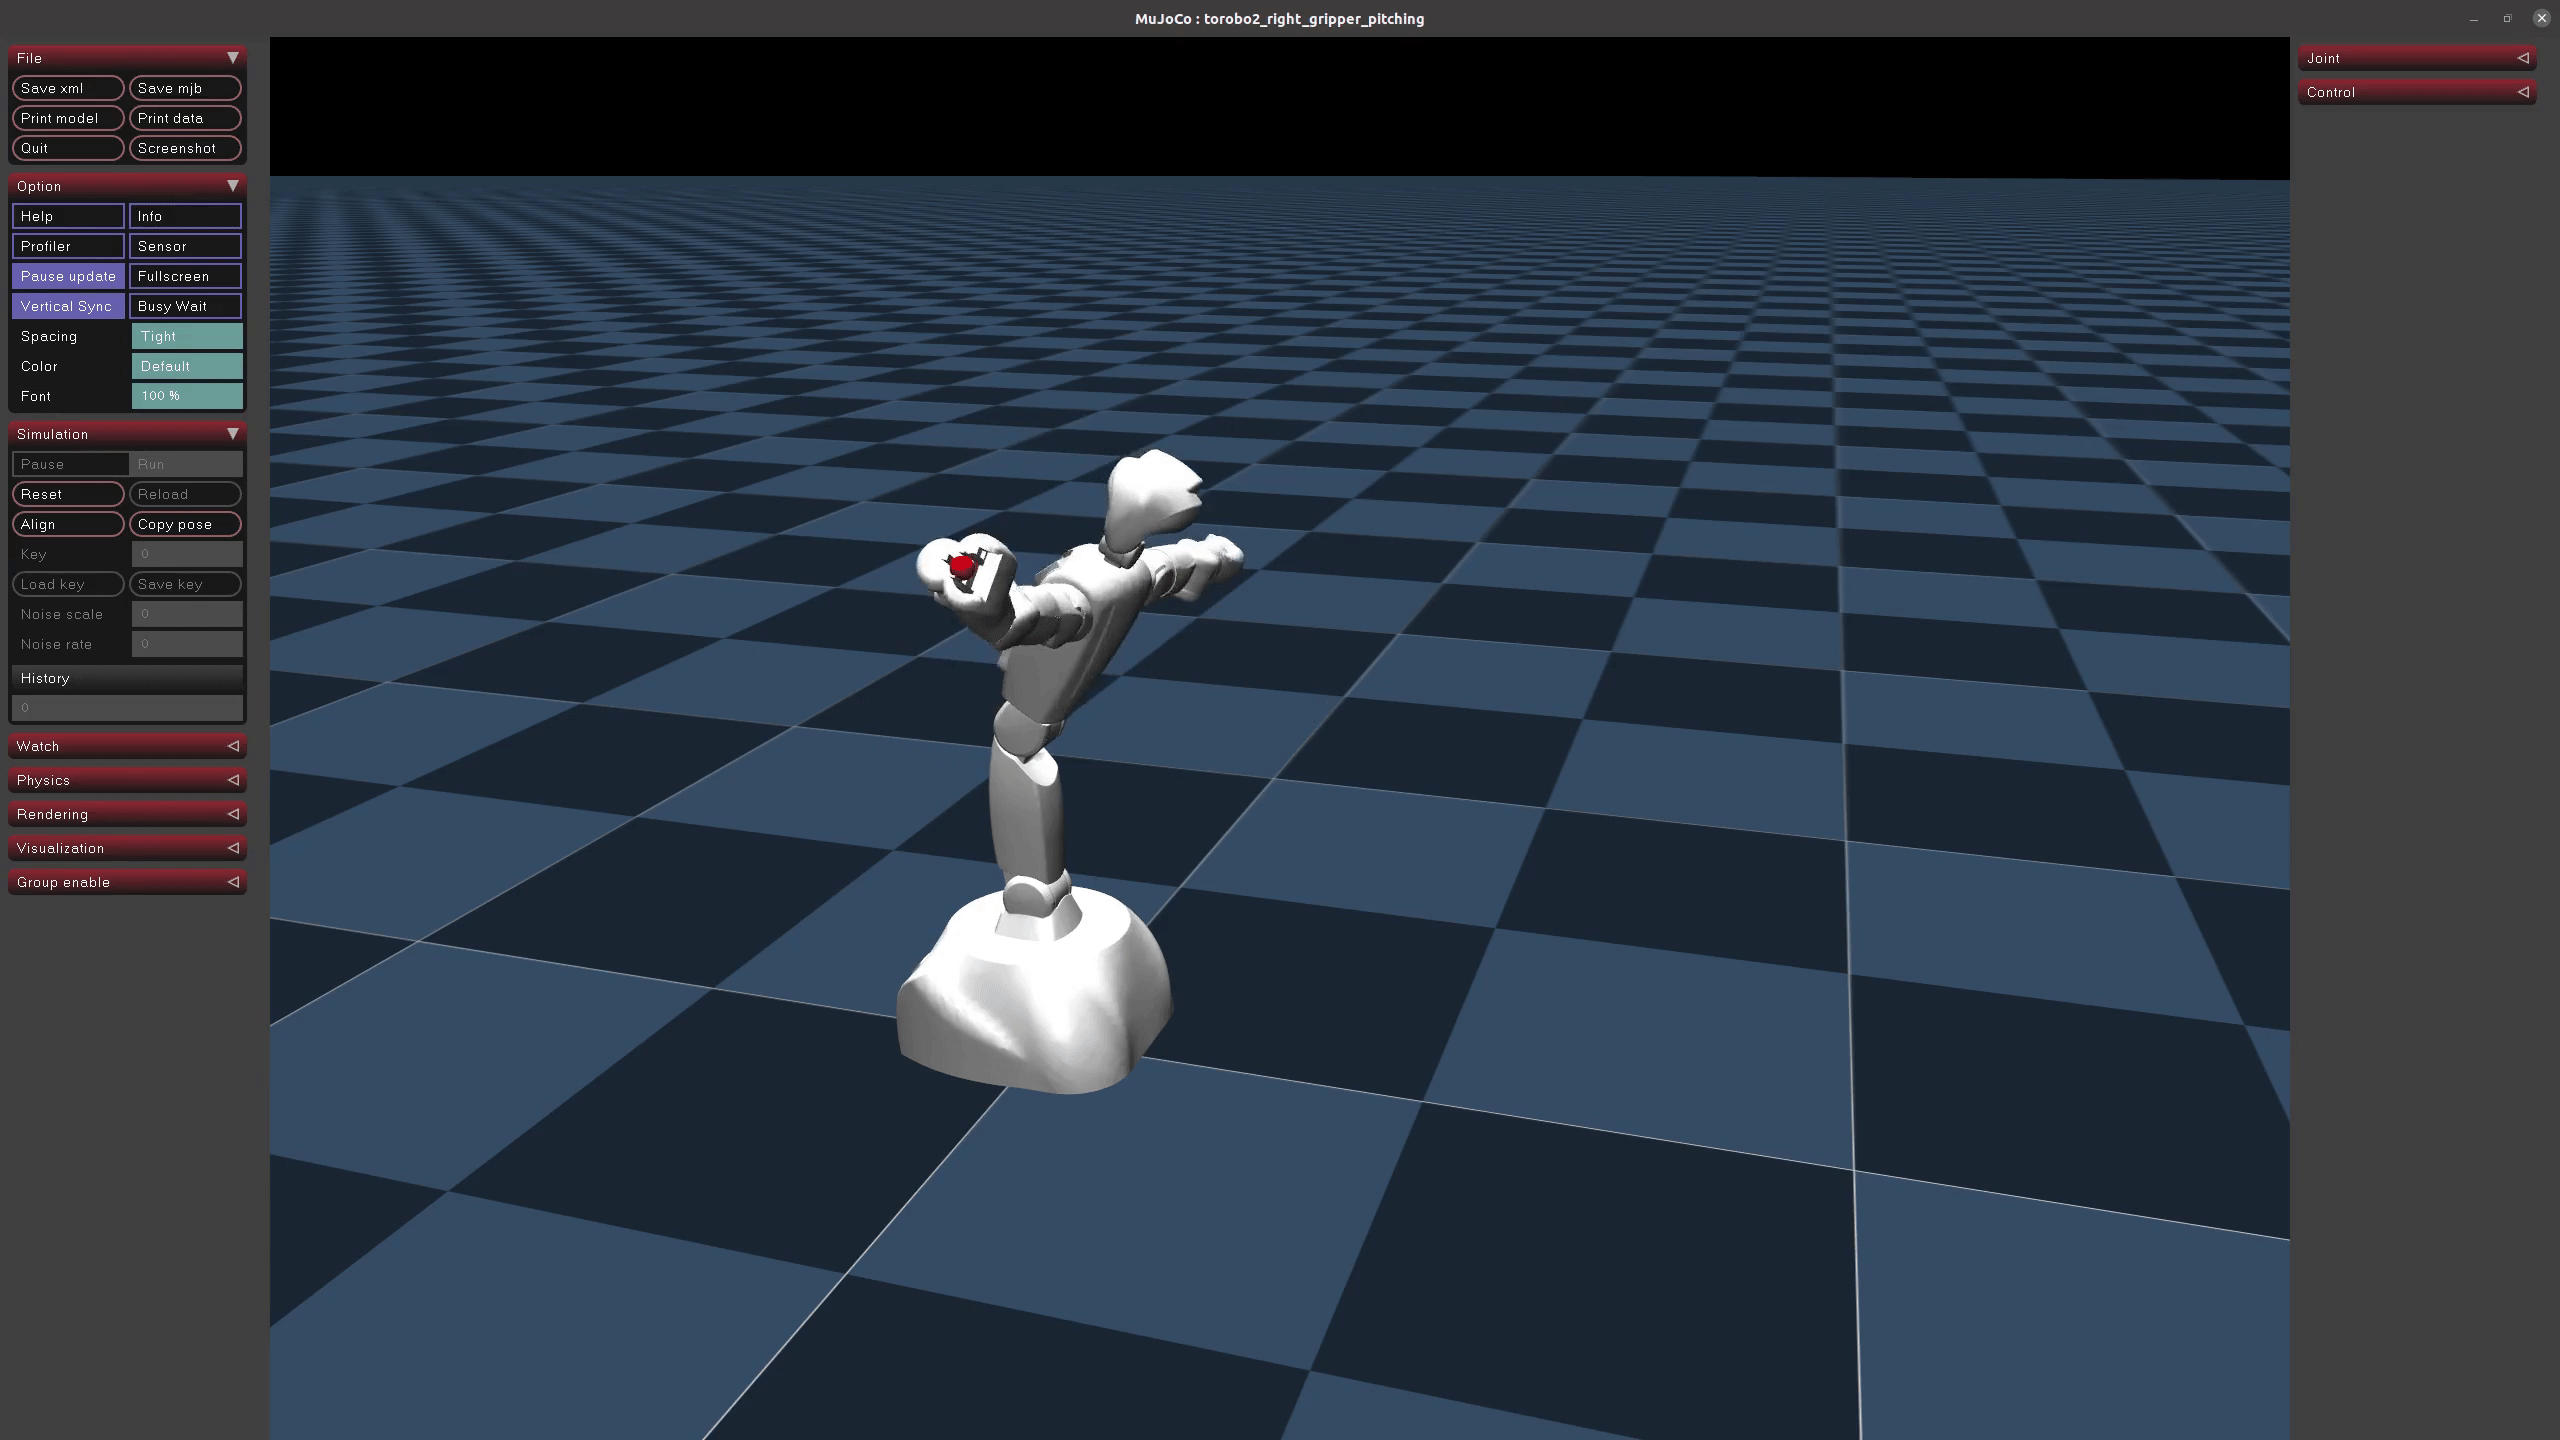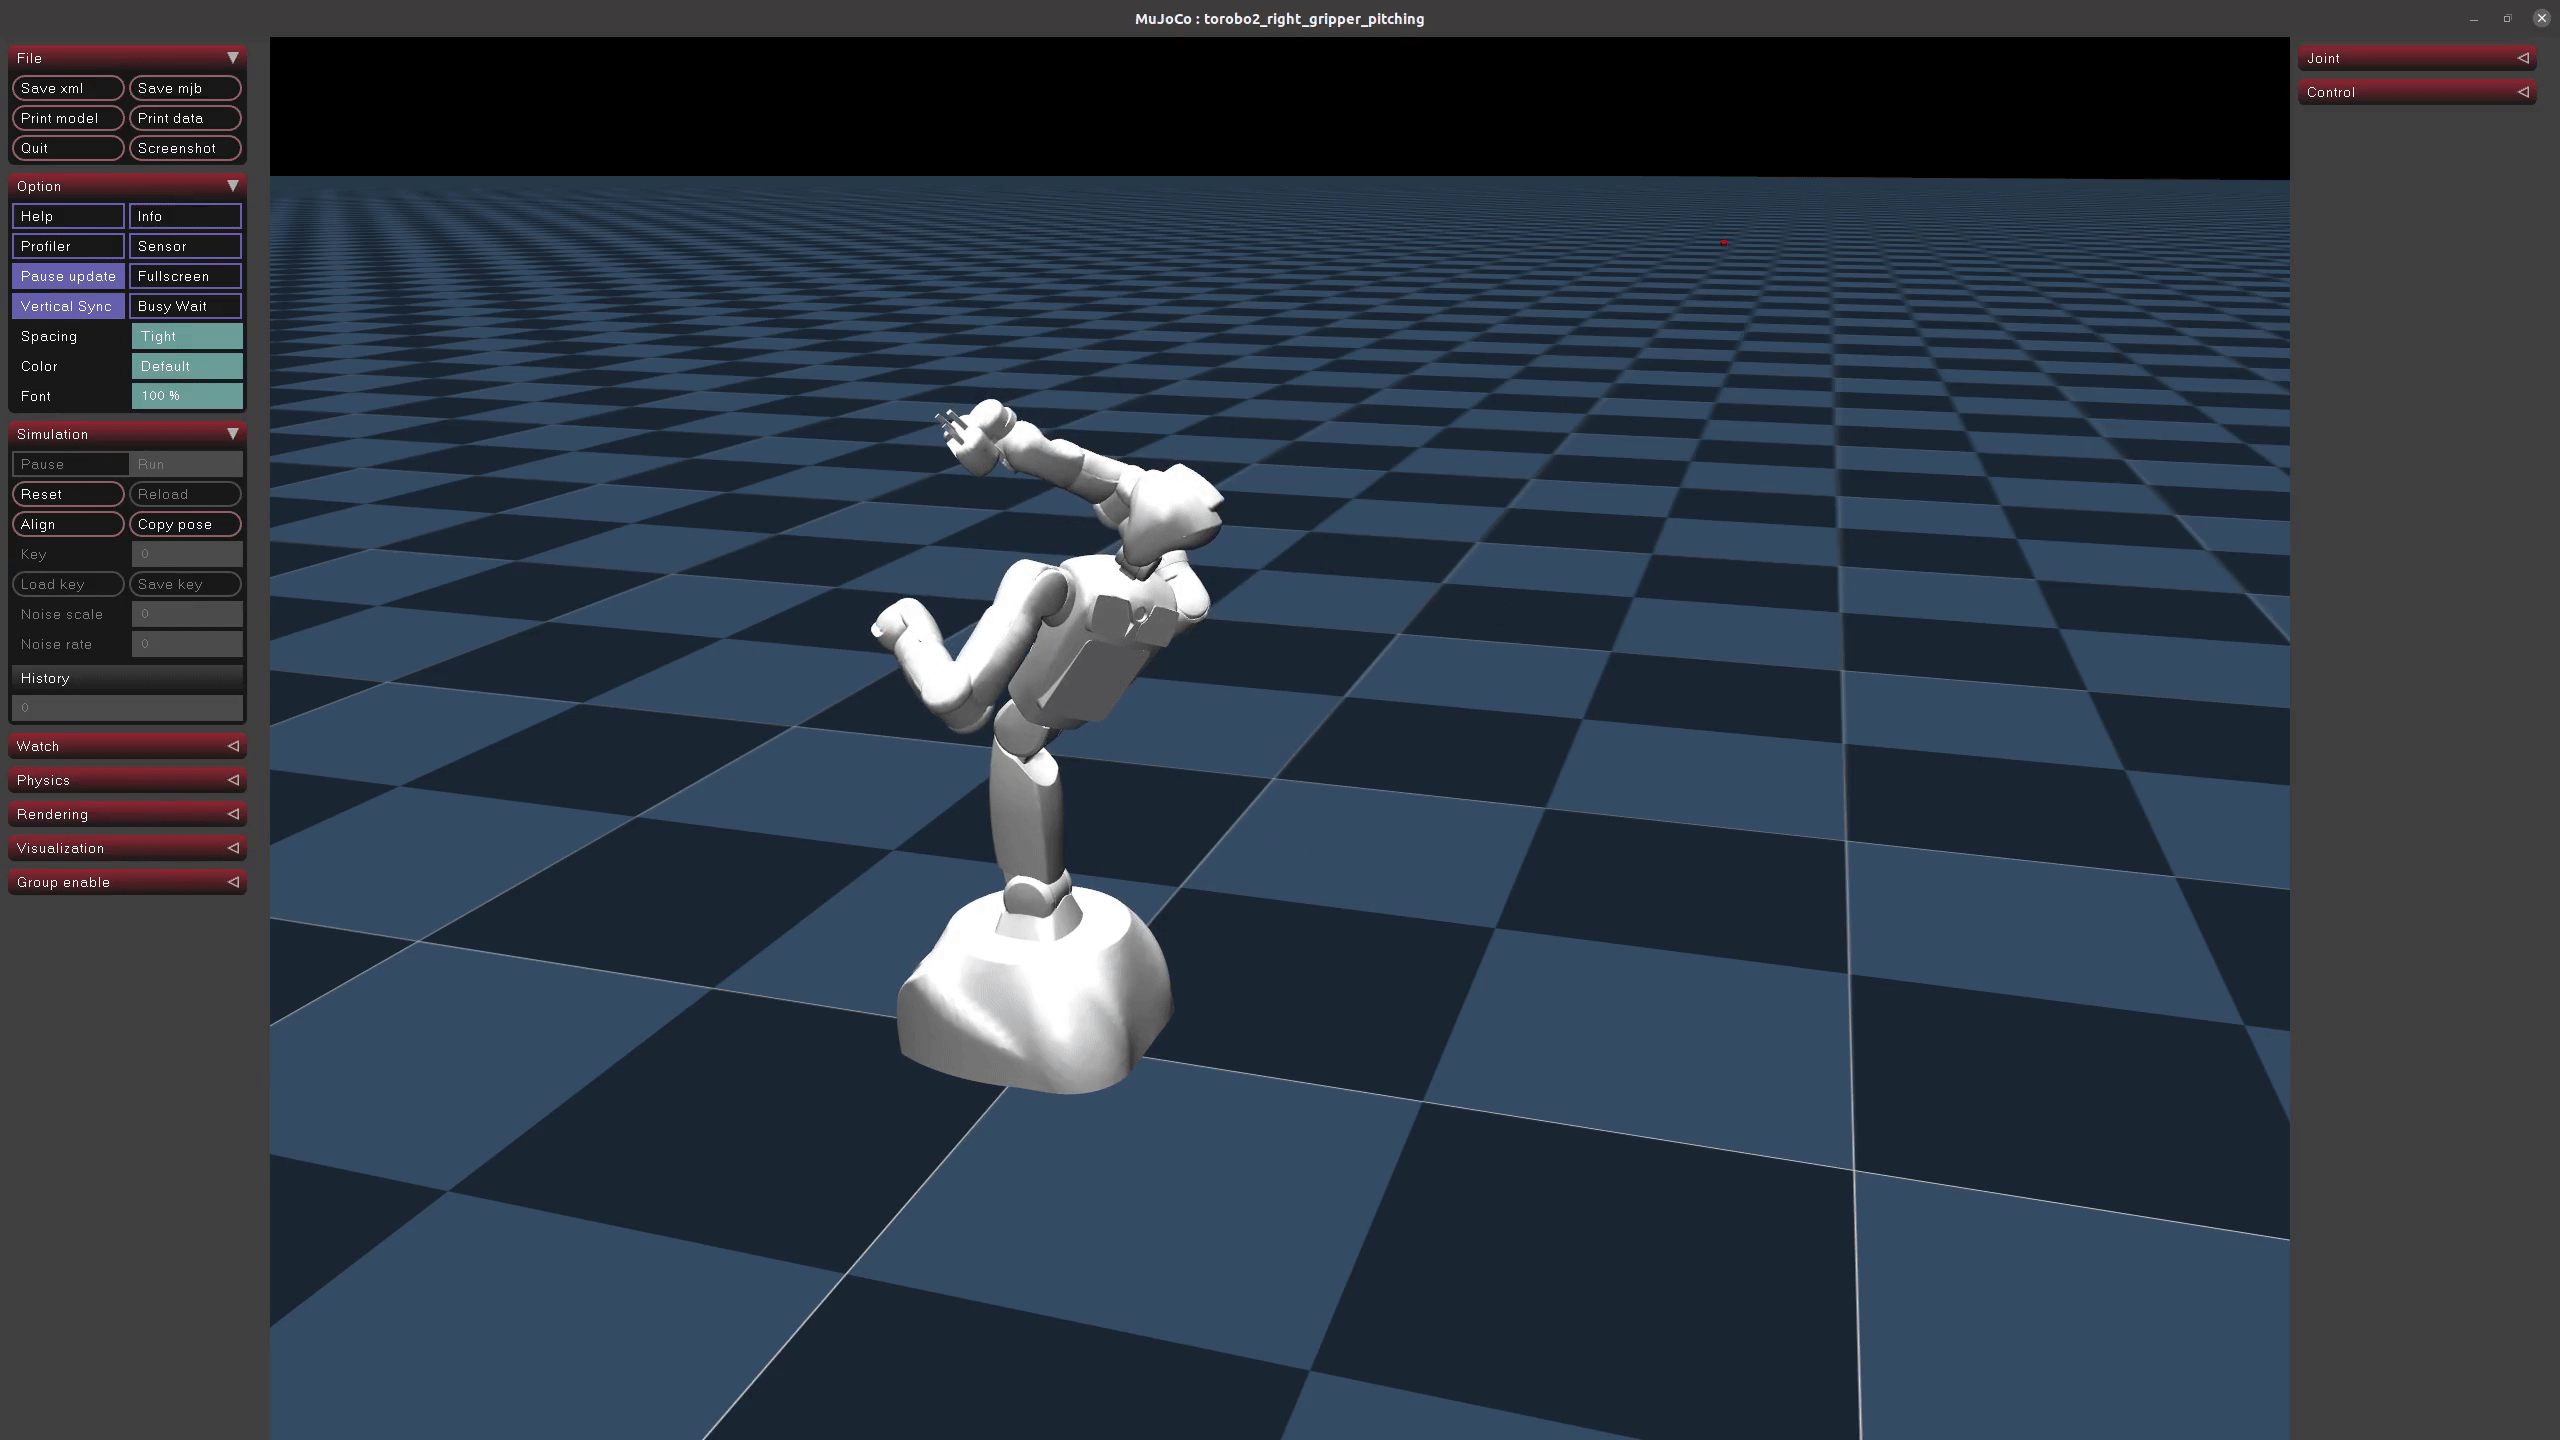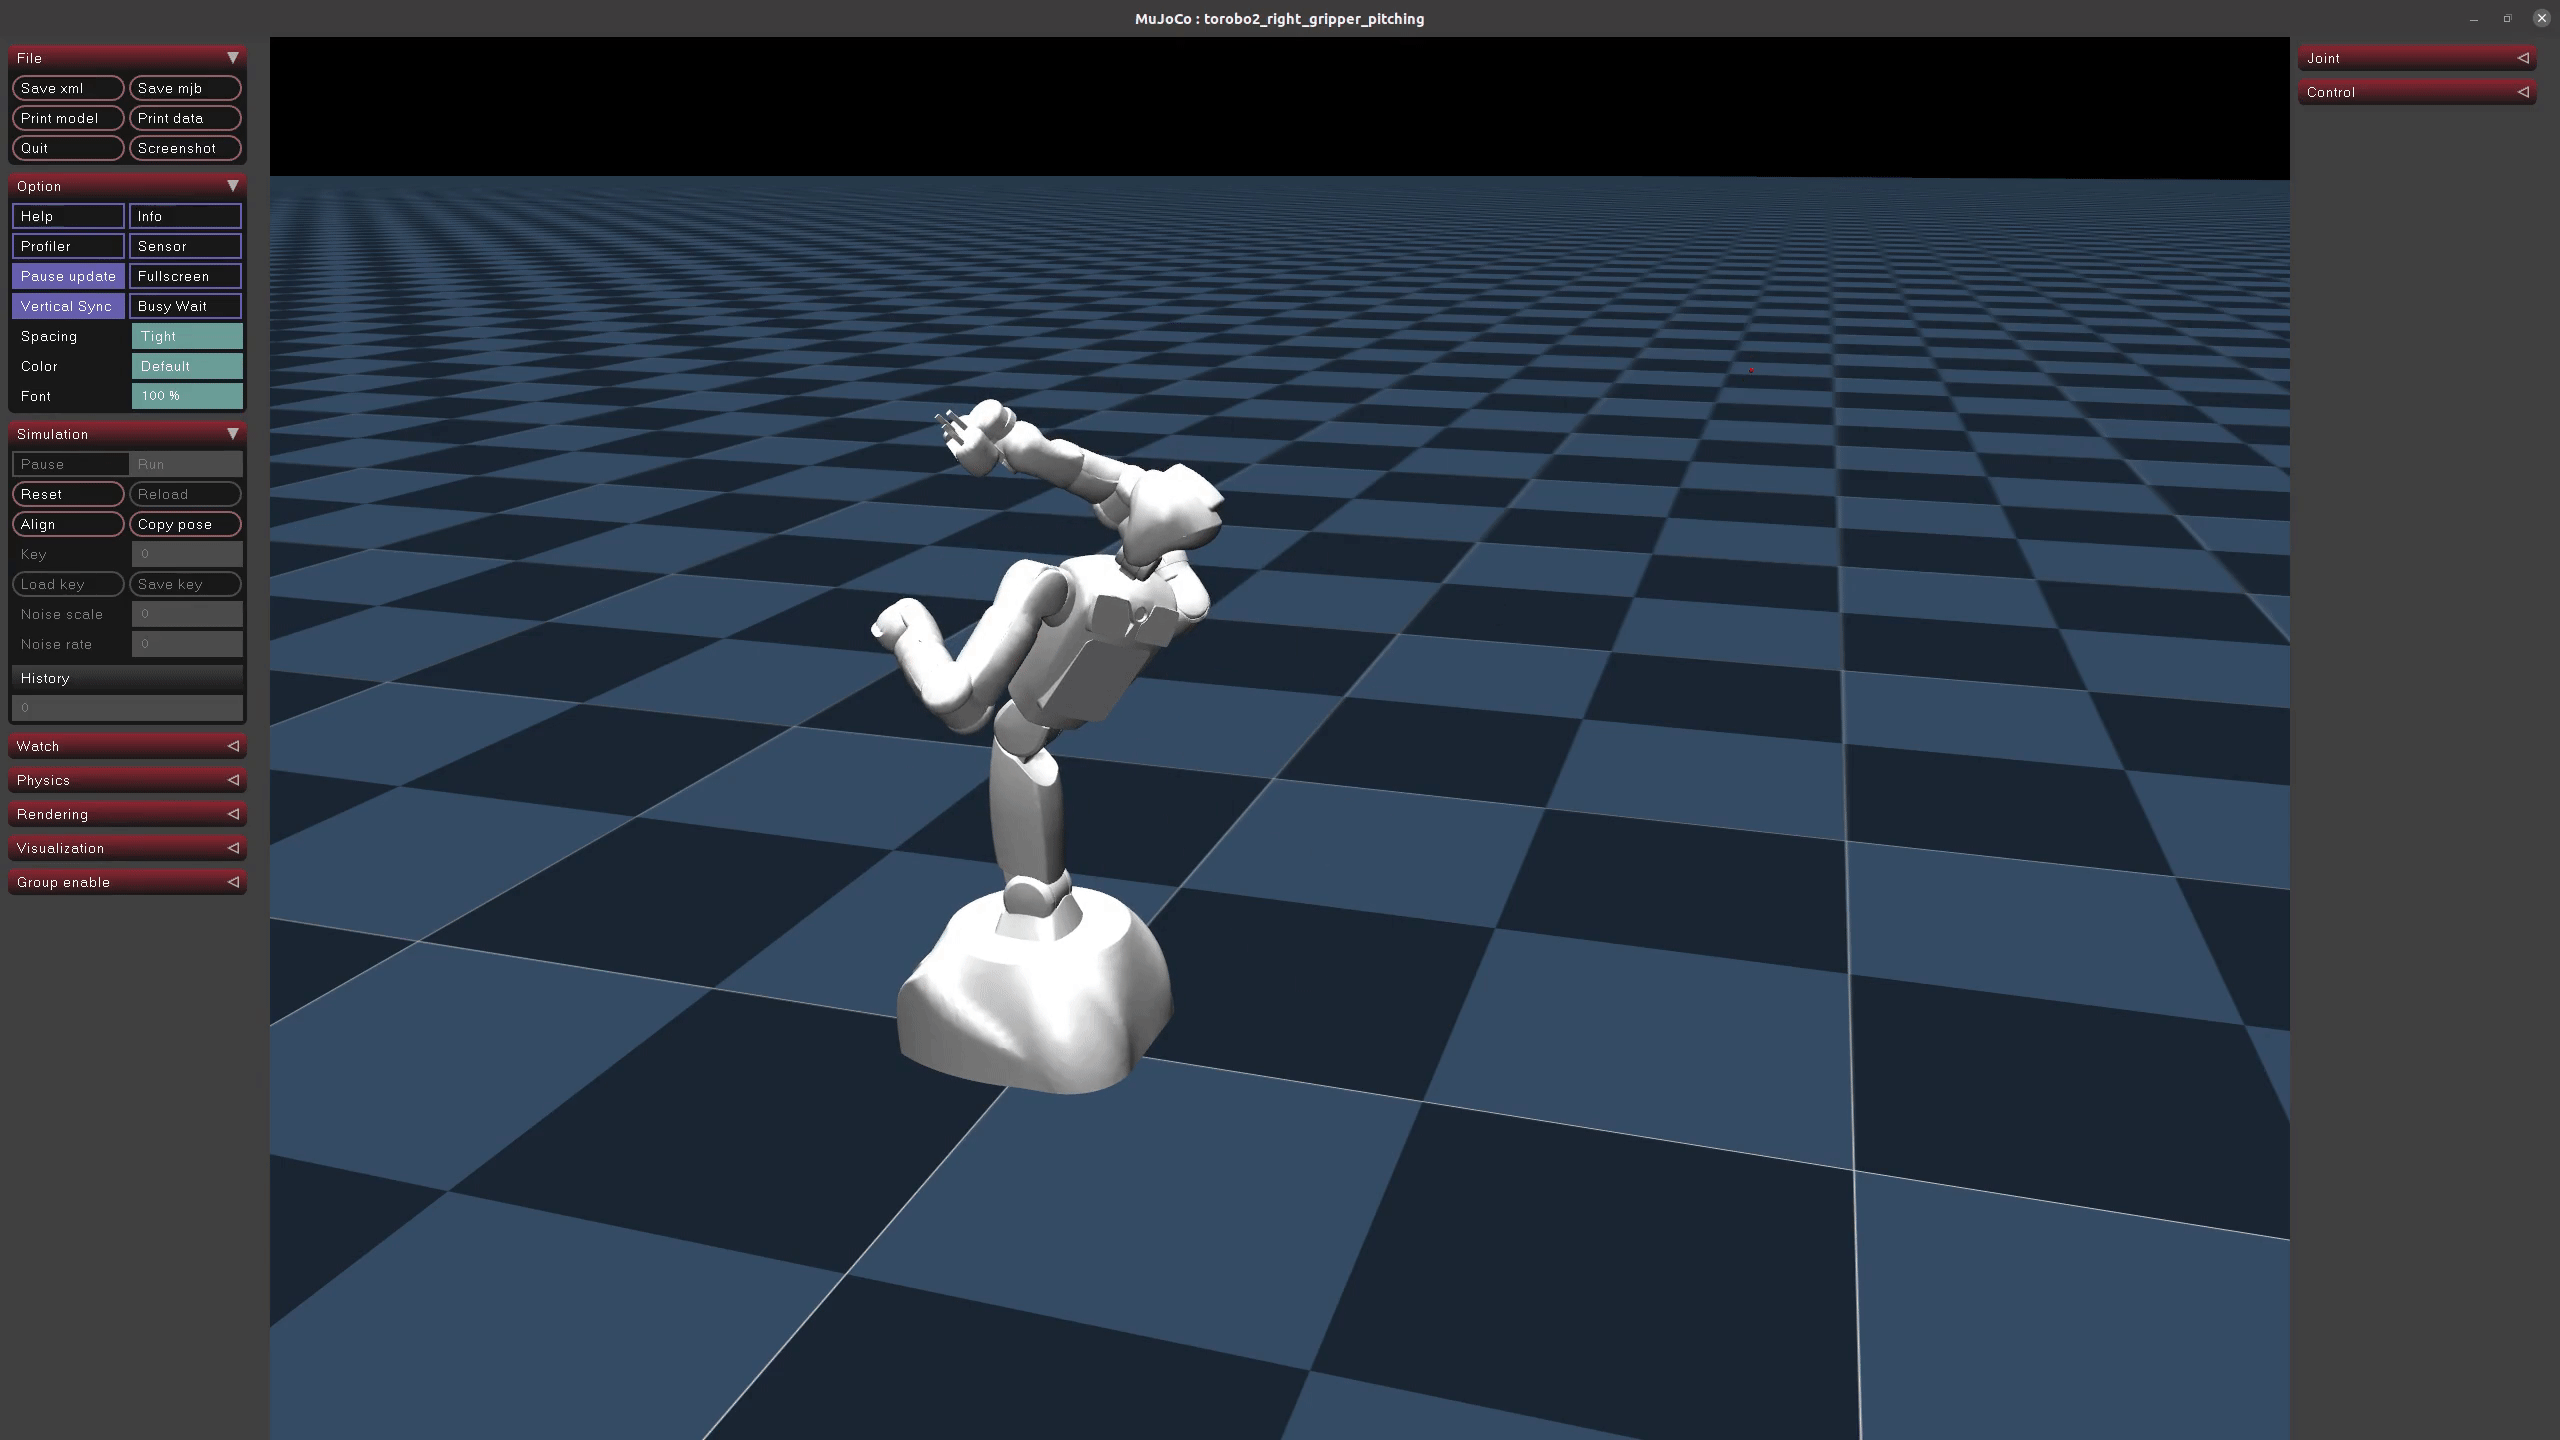
### Pitching motion
※ There is a problem with the timing of the ball release differing depending on the computer environment. If you have any solutions, please let us know in the GitHub discussions.
```
cd example
python example_torobo2_pitching.py
```
 ## Play with the trained policy in Isaac Sim (Reinforcement Learning Sim2Sim)
### Install related python packages
```
pip install -r example_rl_play/requirements.txt
```
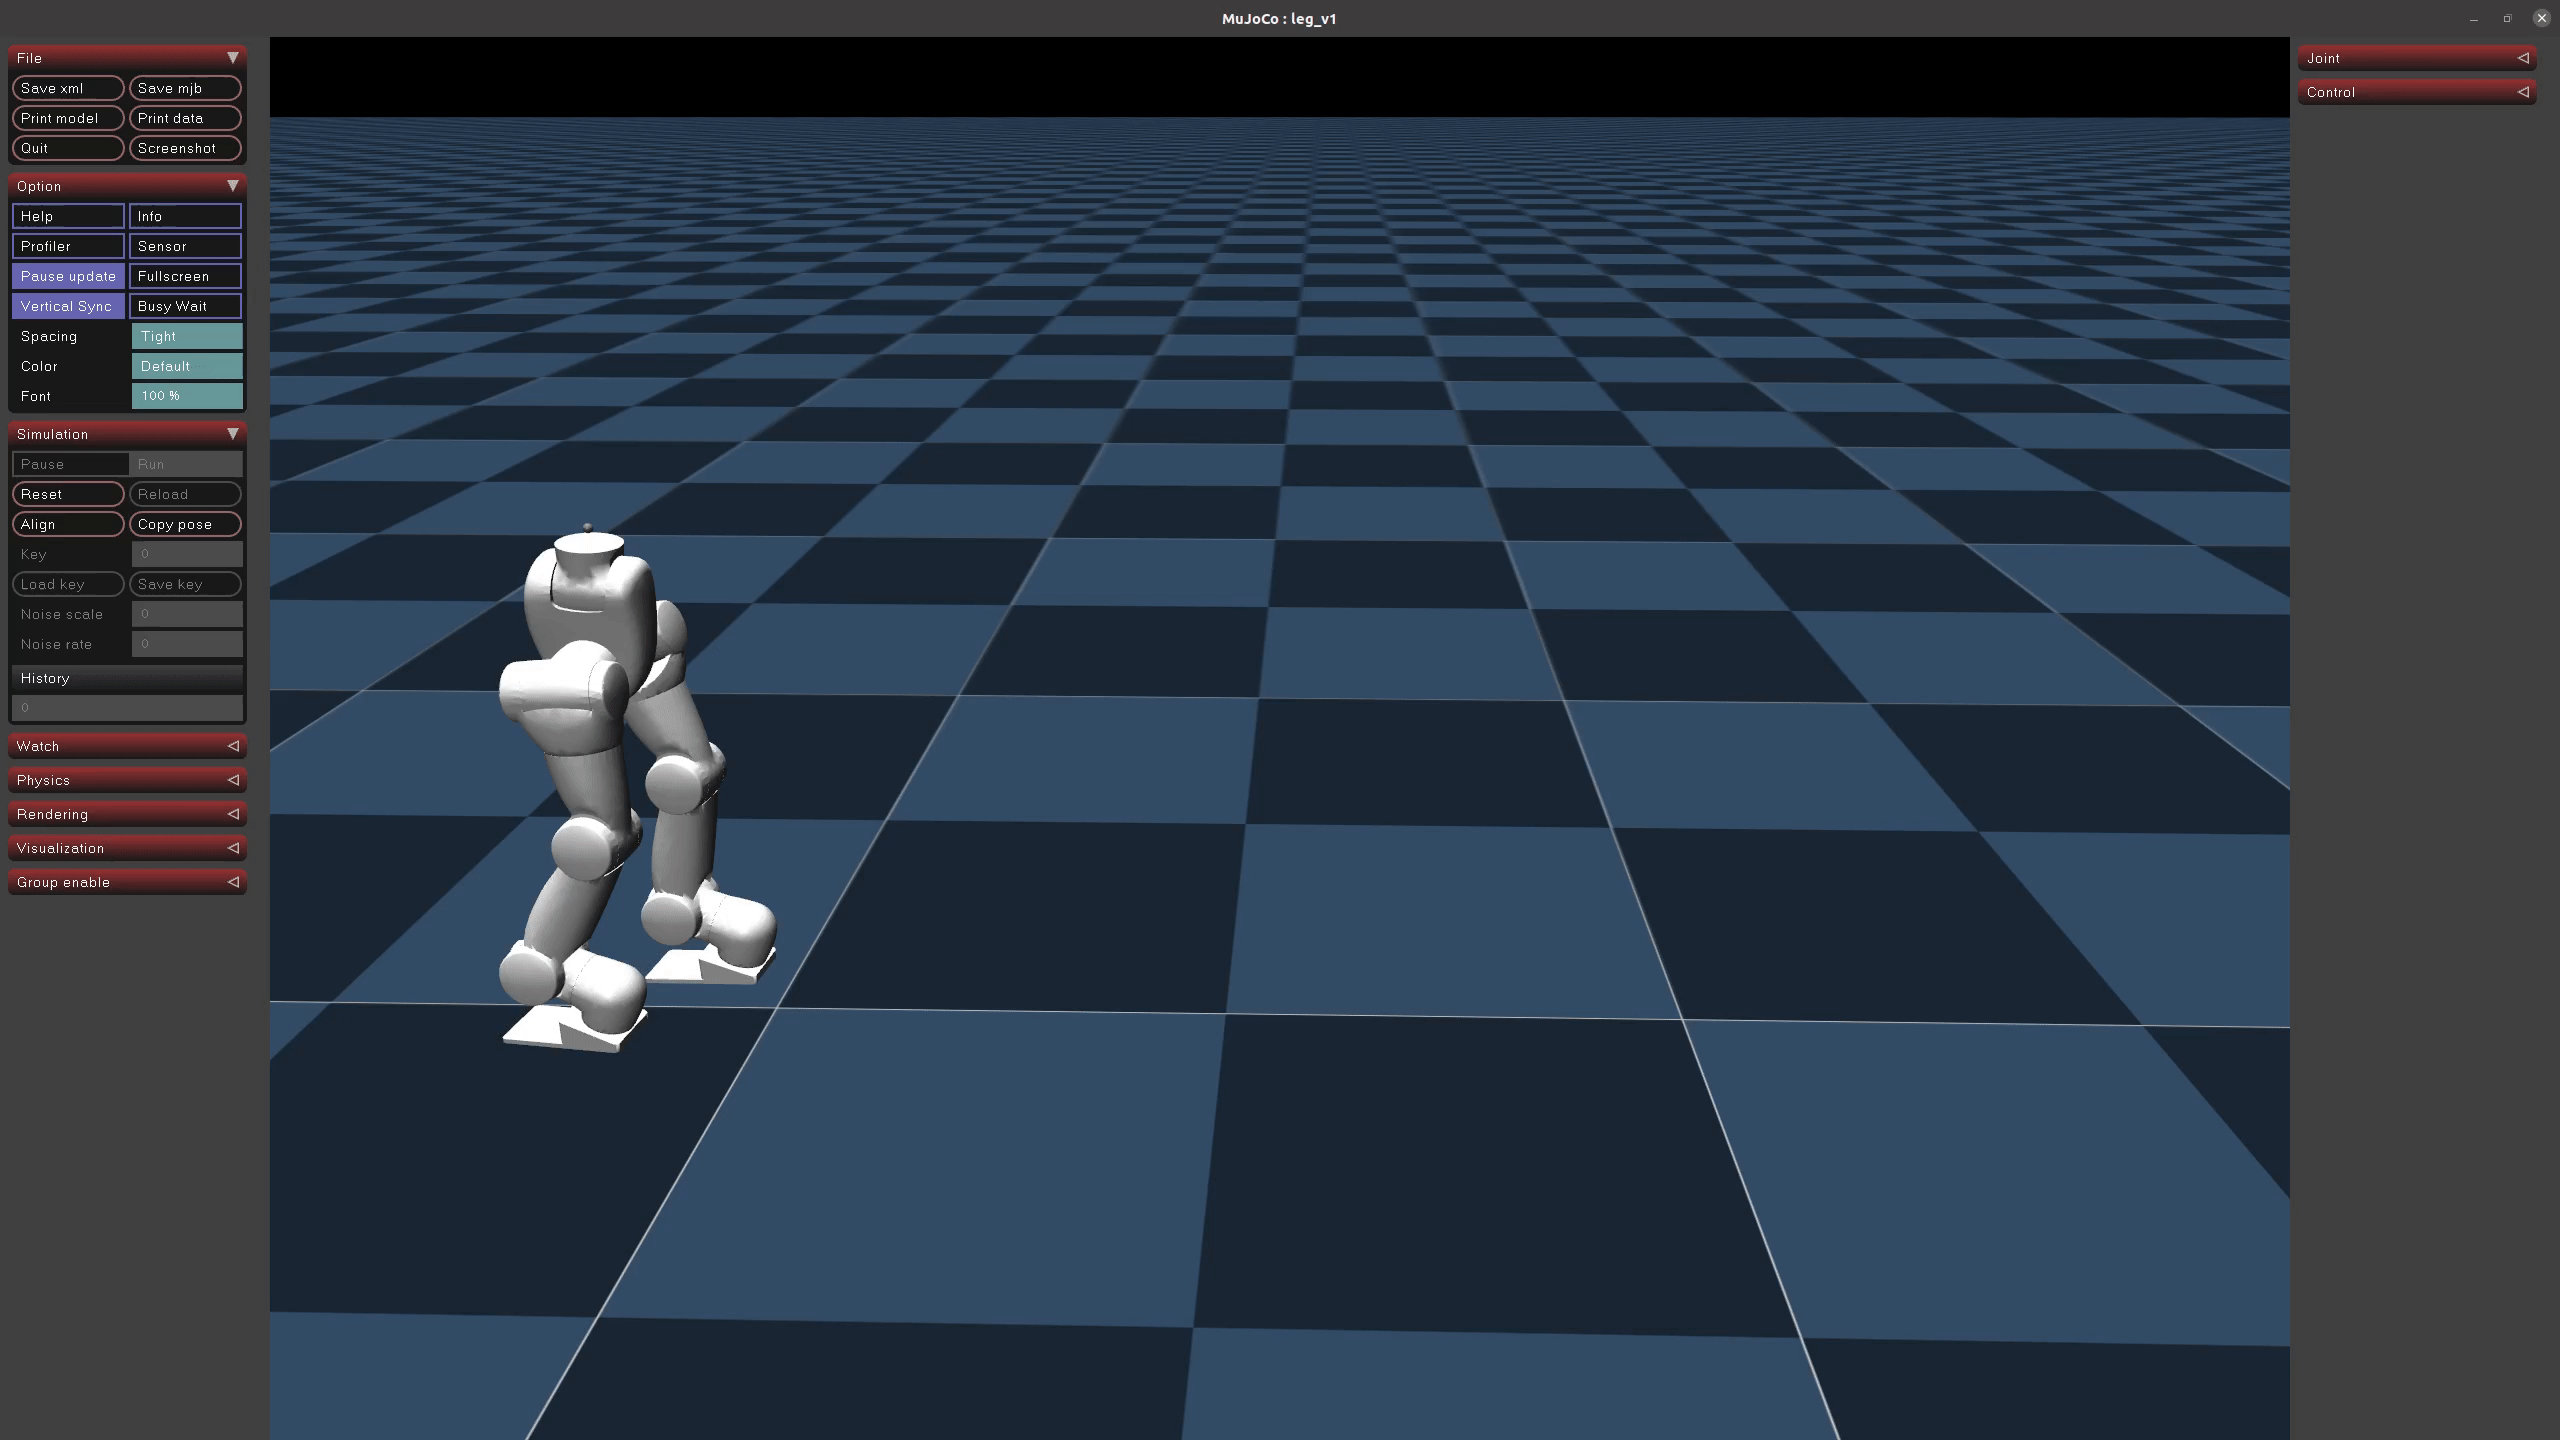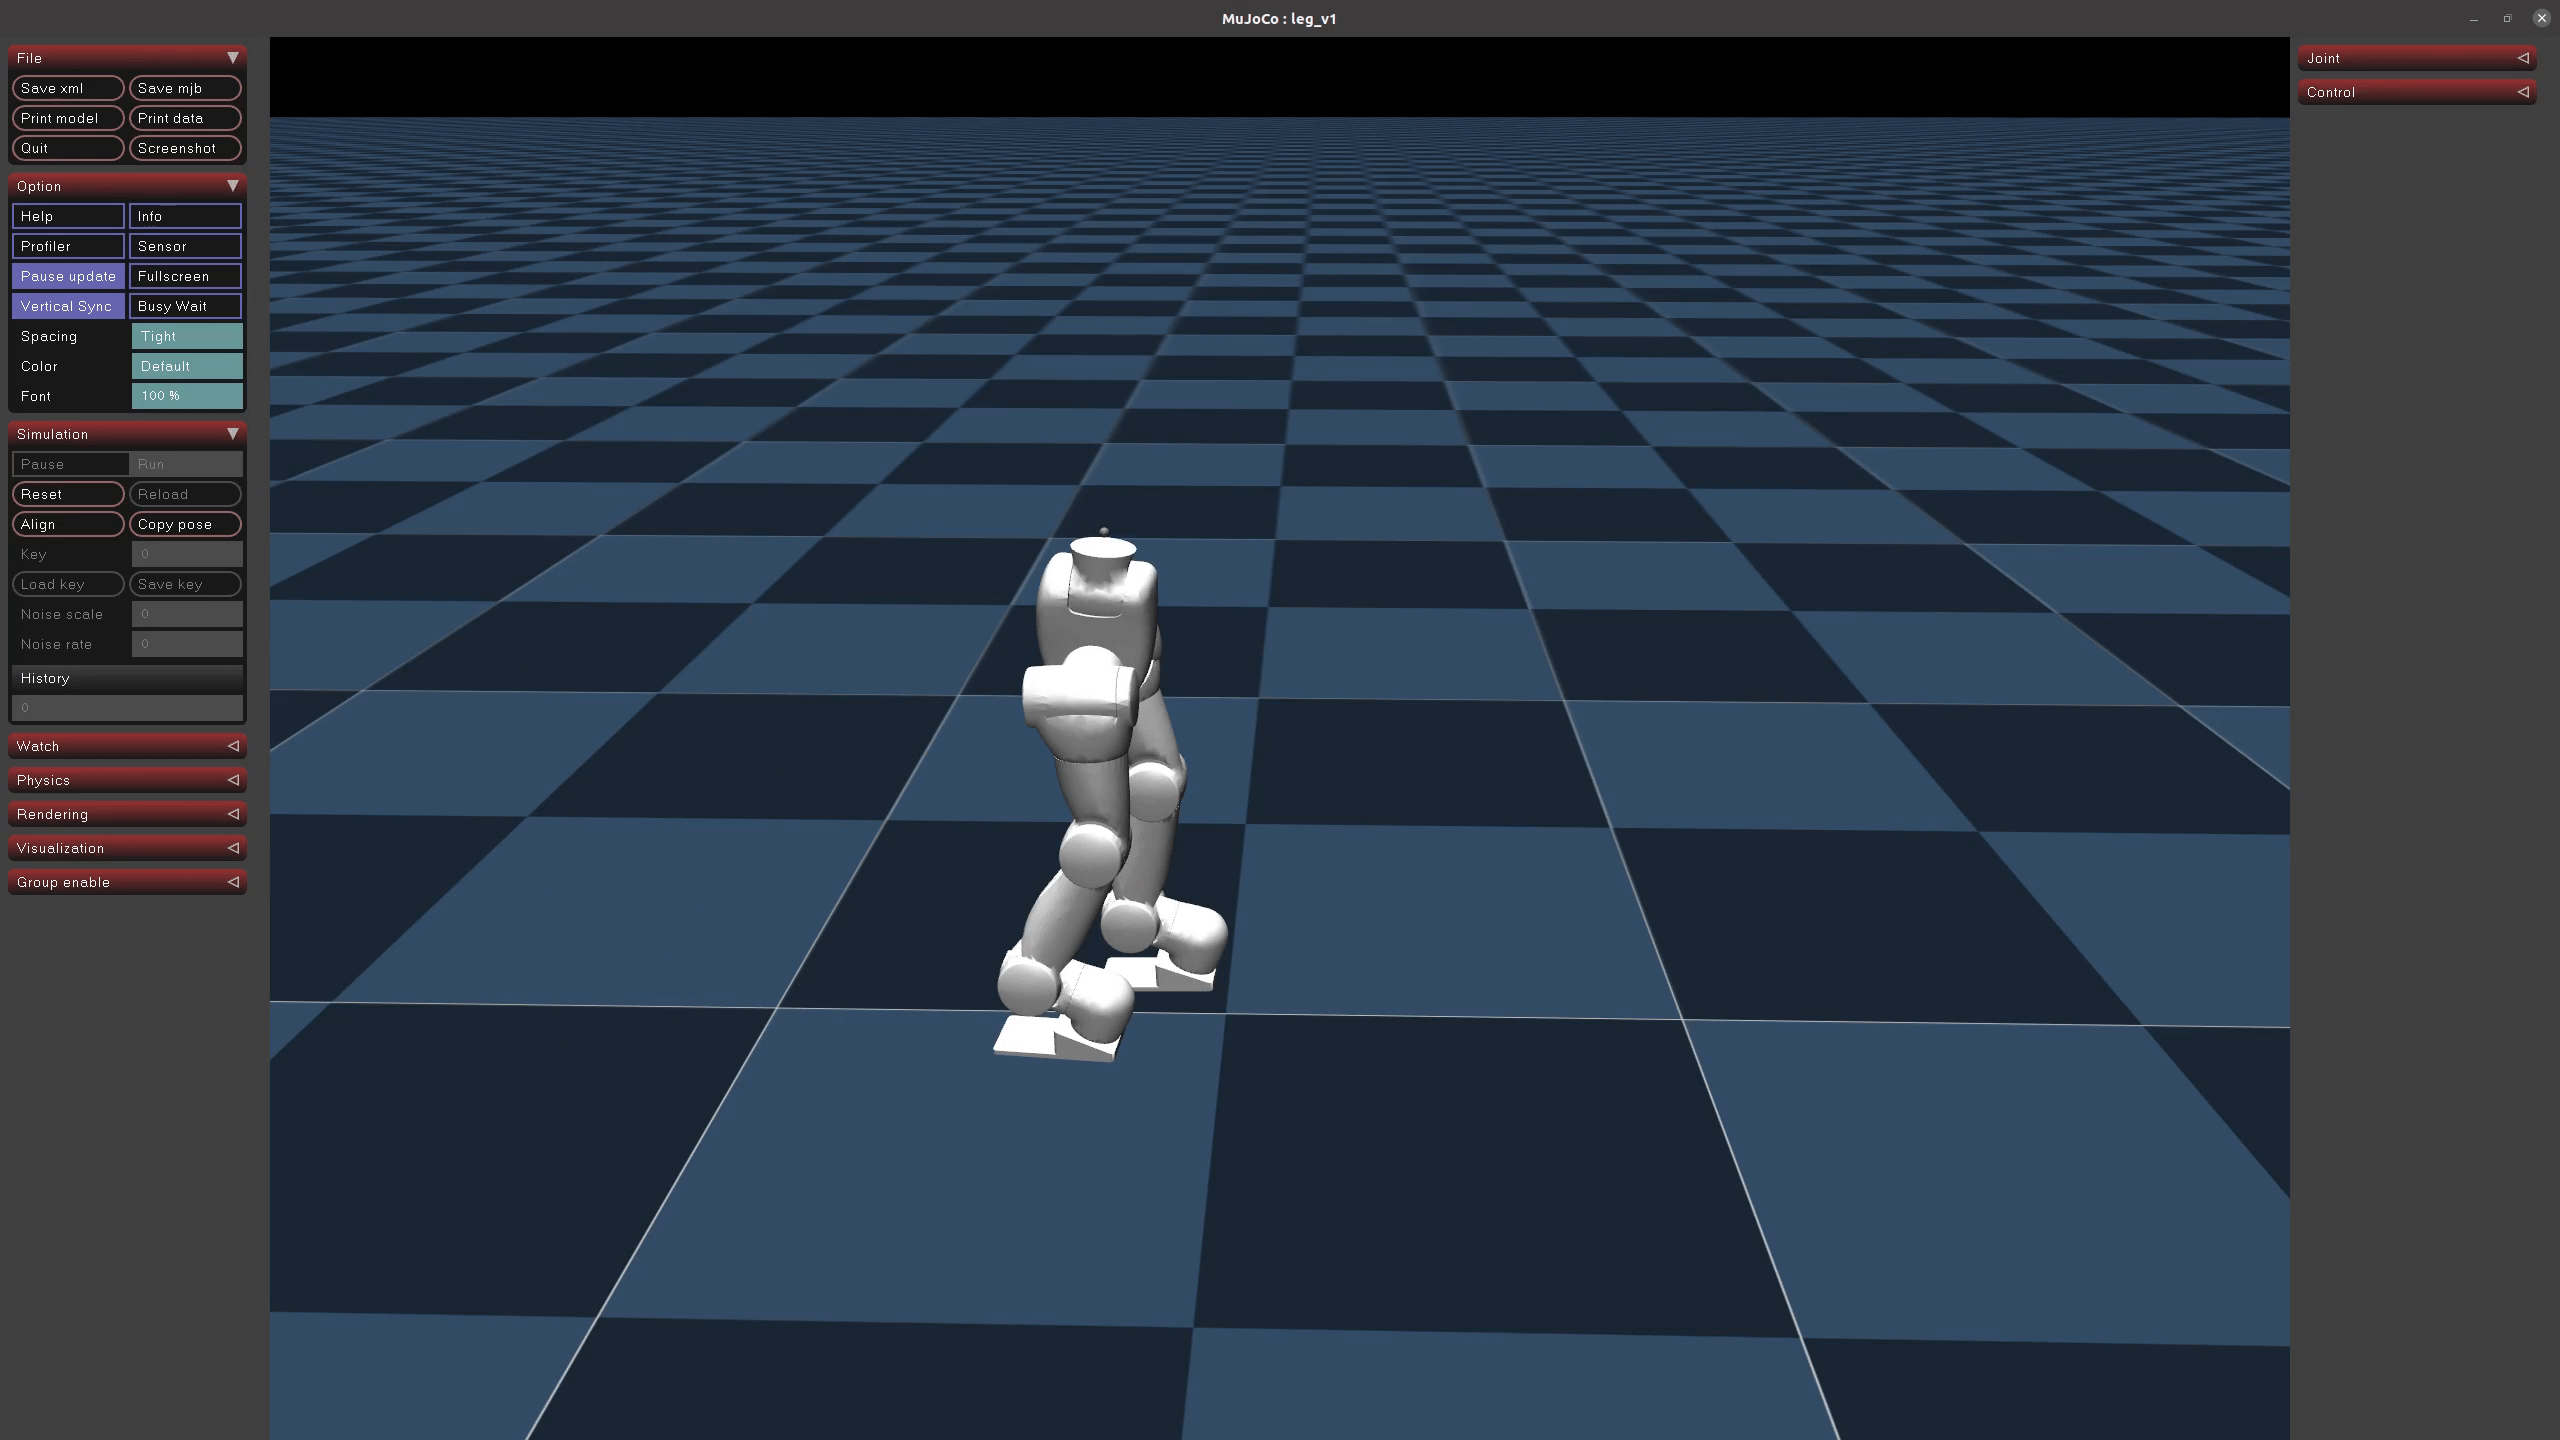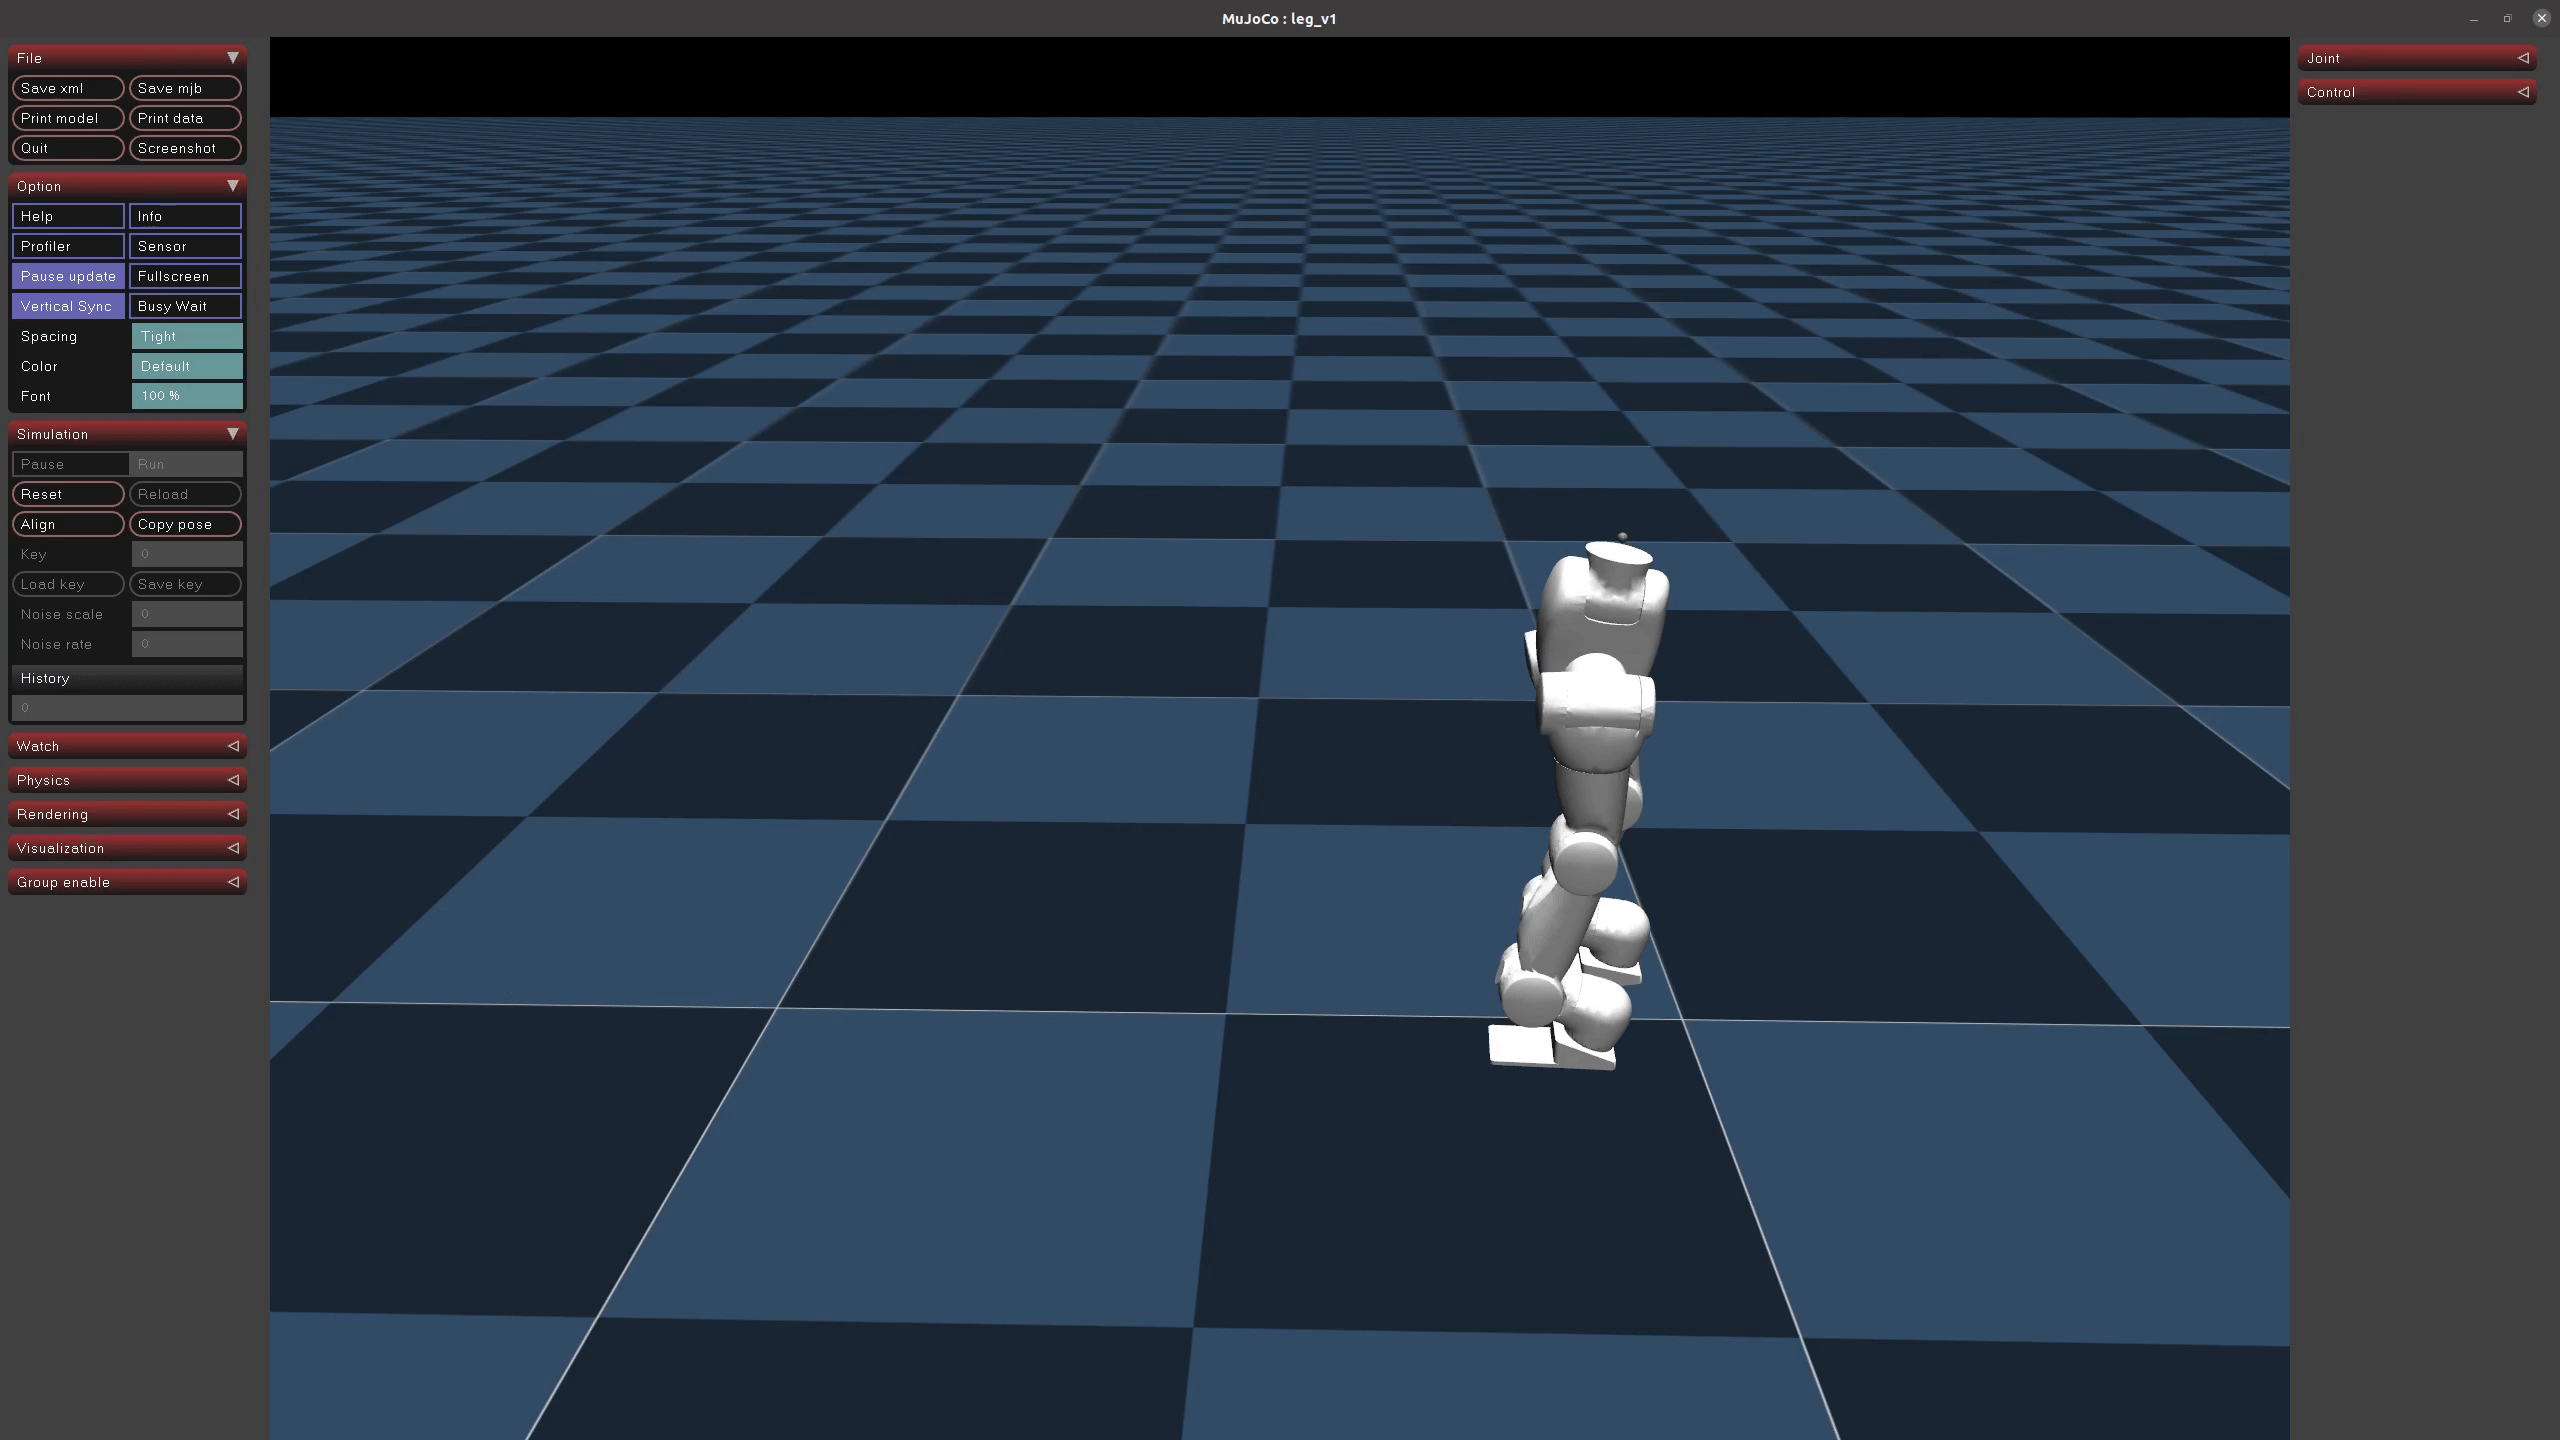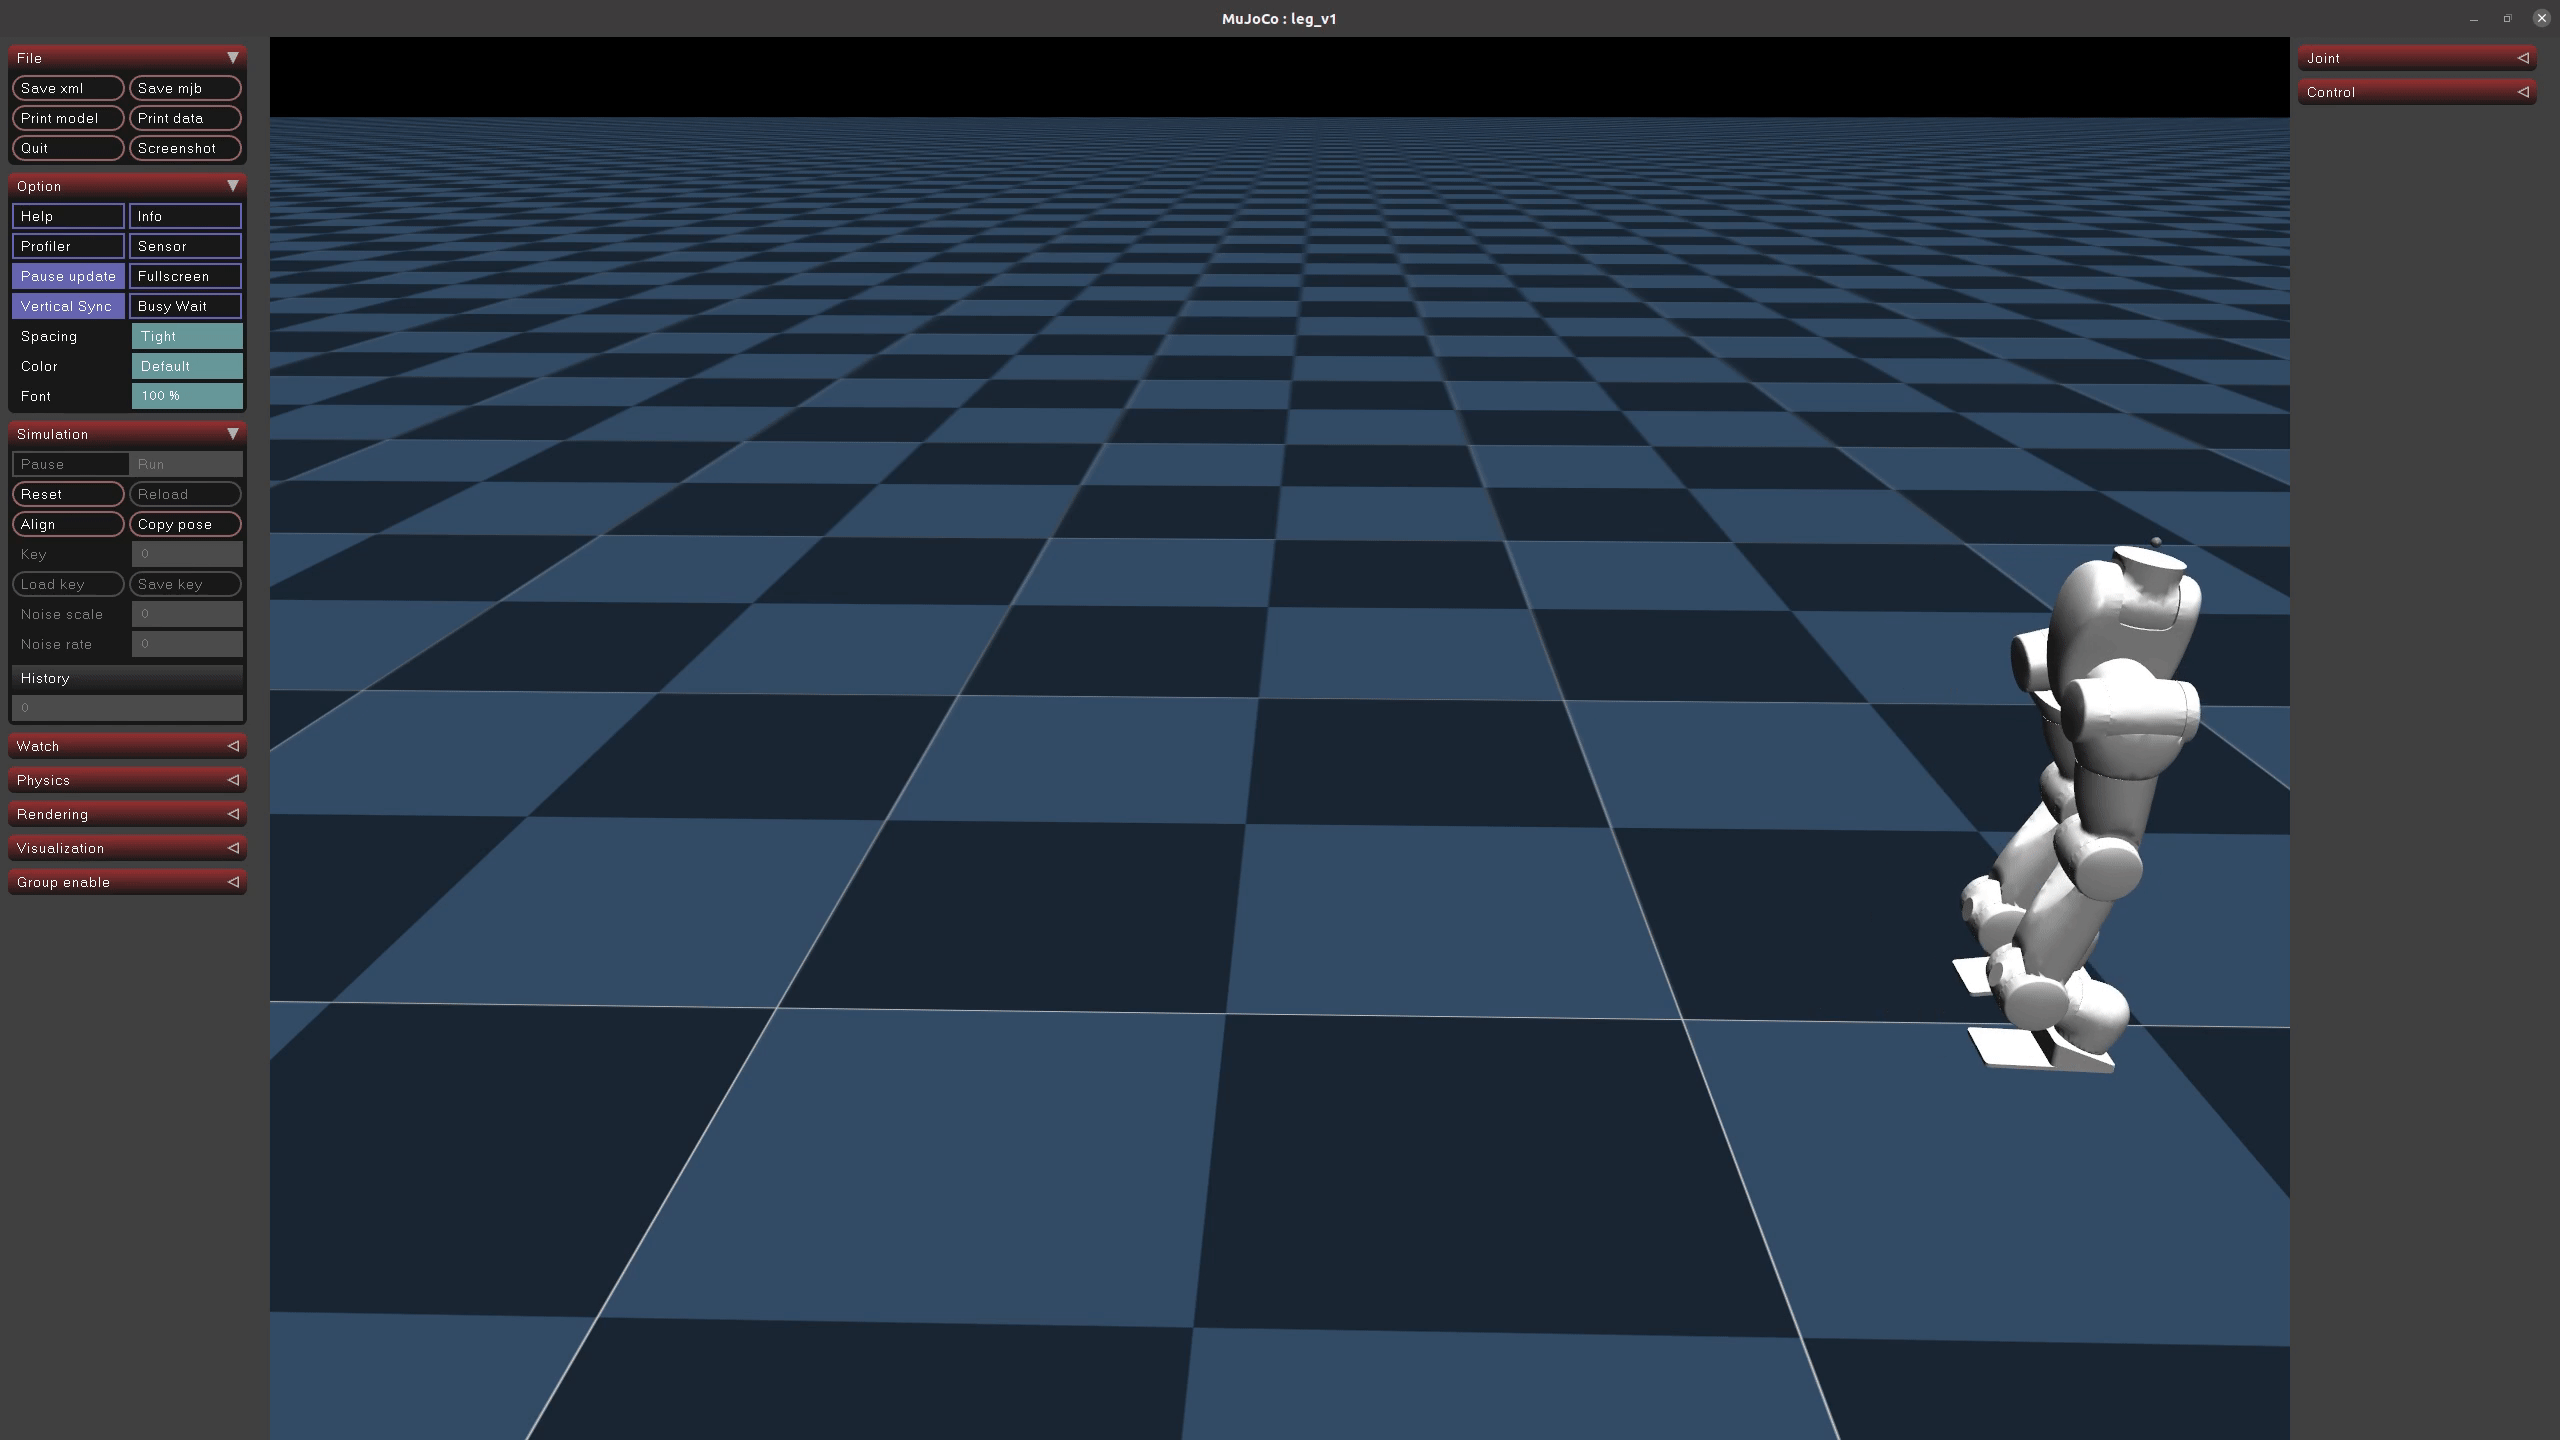
### Bipedal walk
※ leg_v1 model is now under research and development and is not currently scheduled for sale.
```
cd example_rl_play
python bipedal_walk.py
```
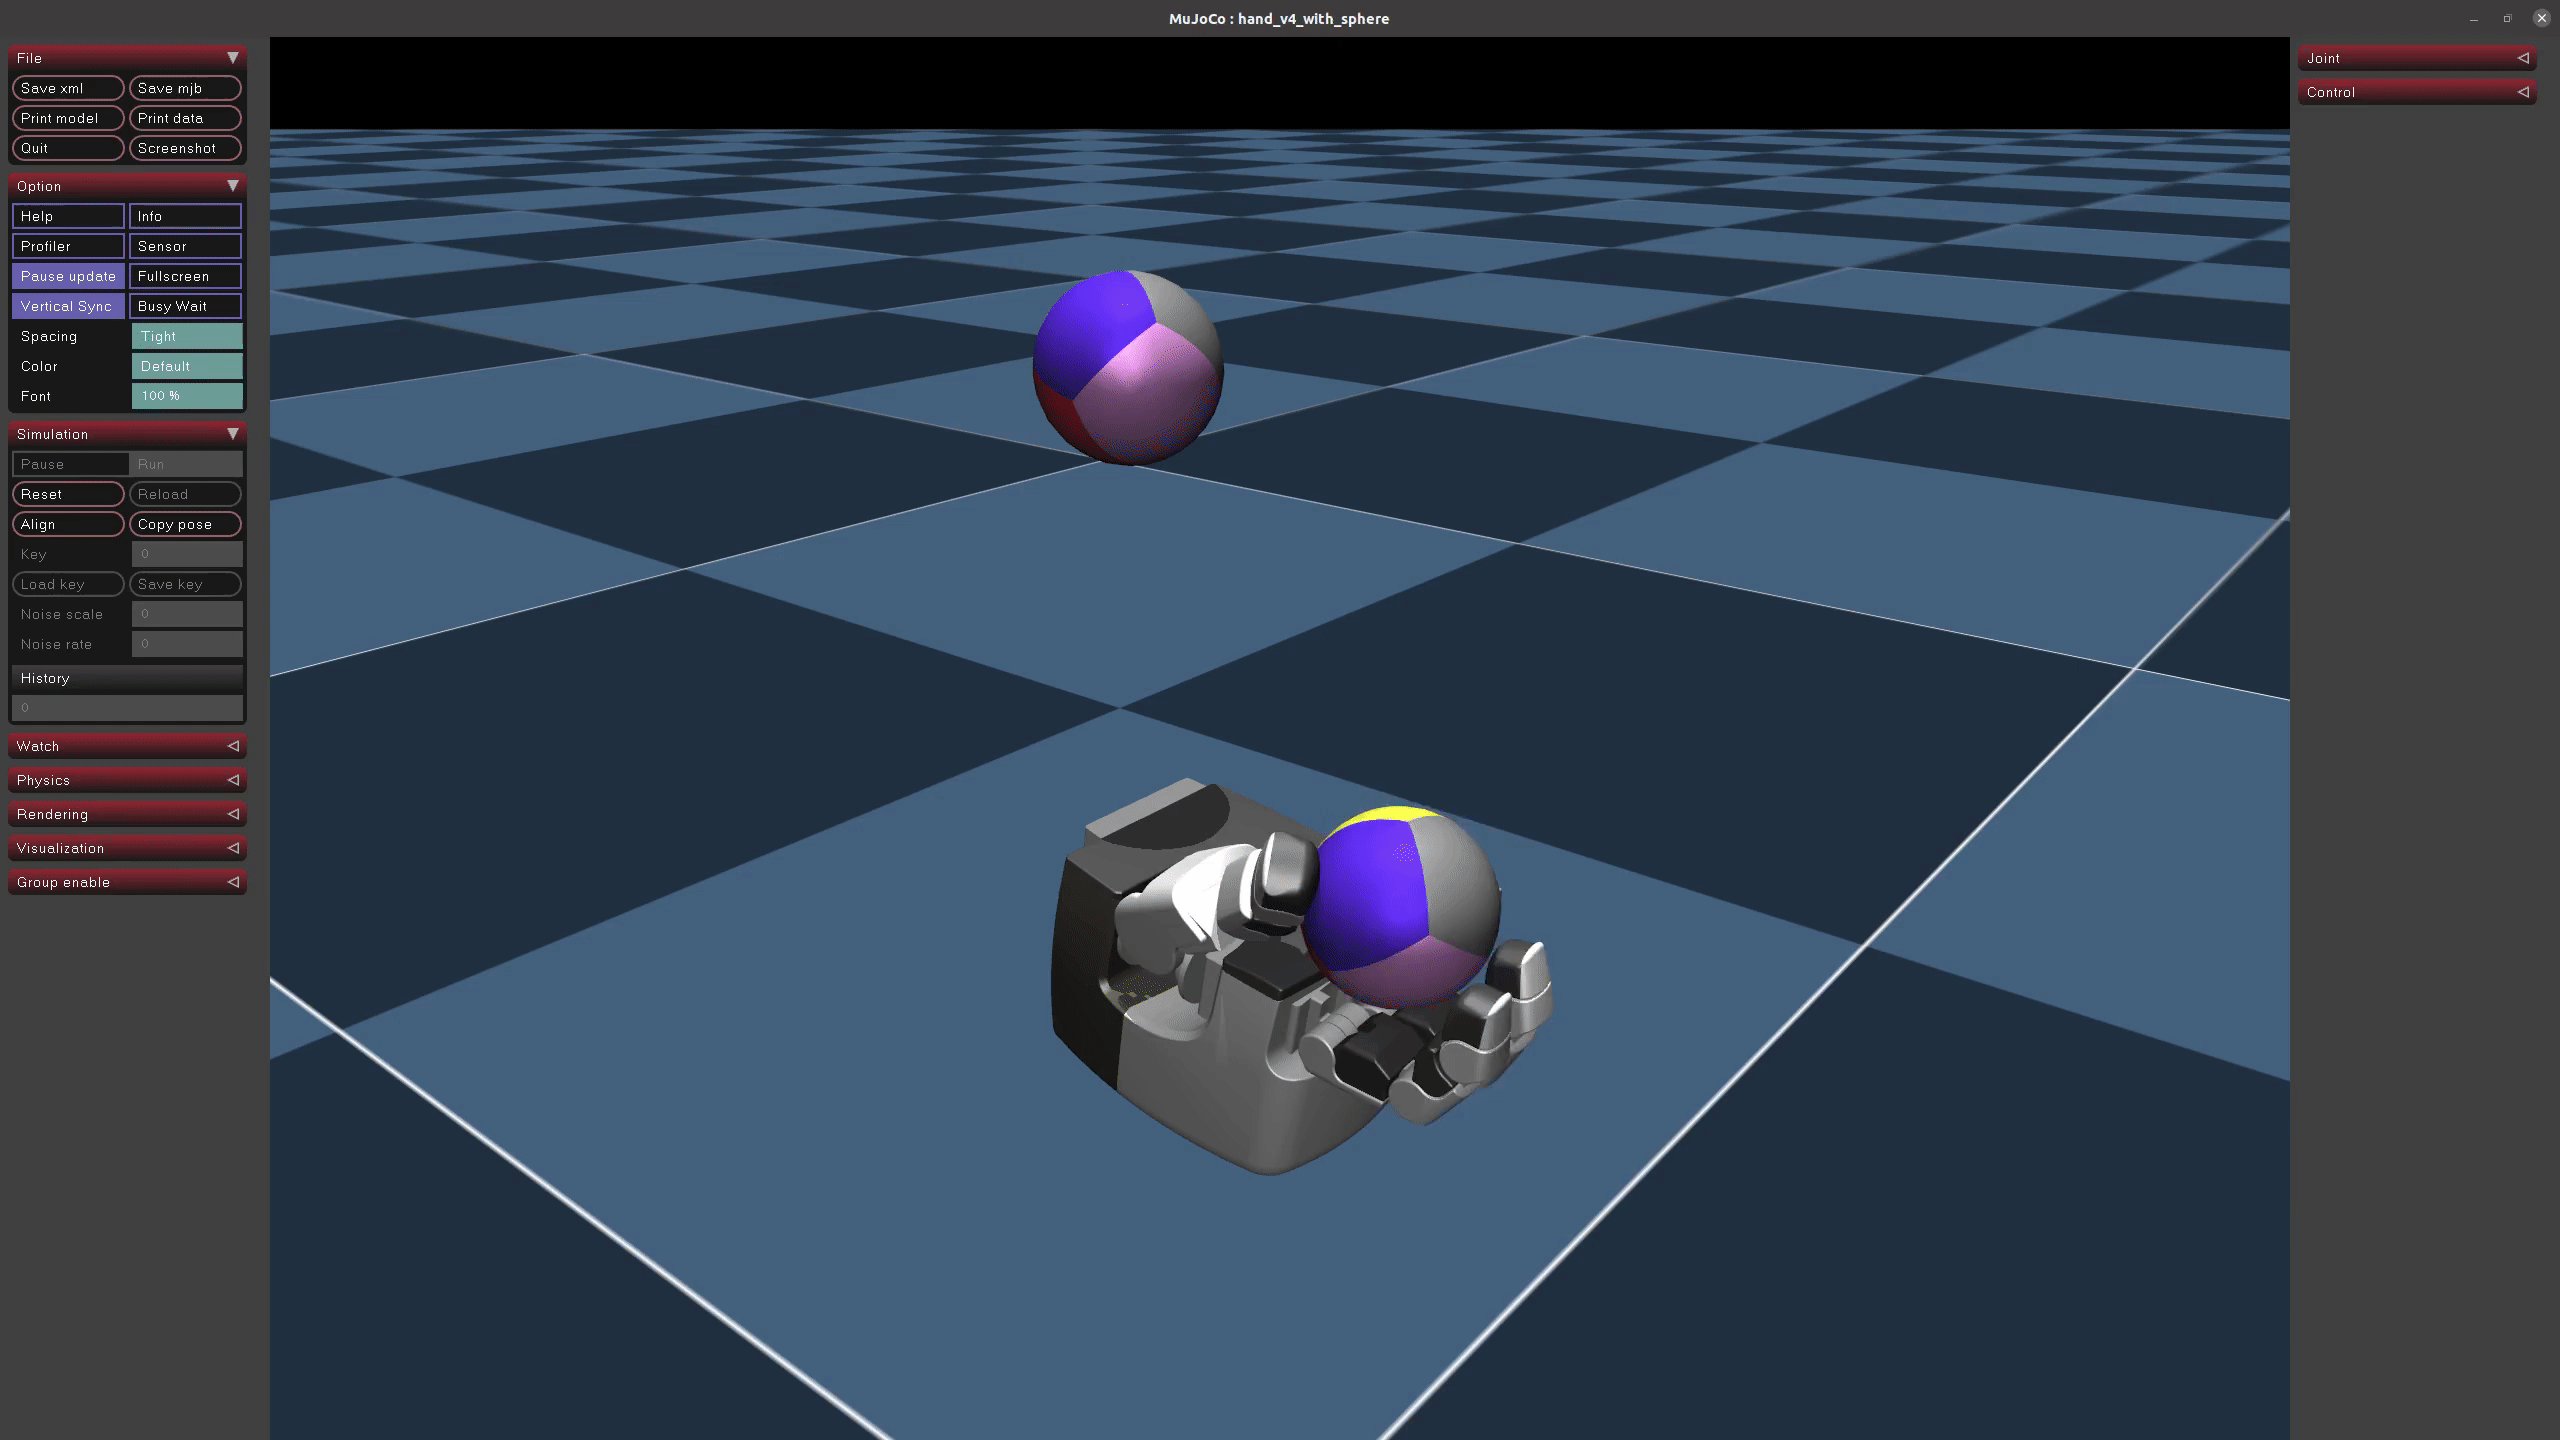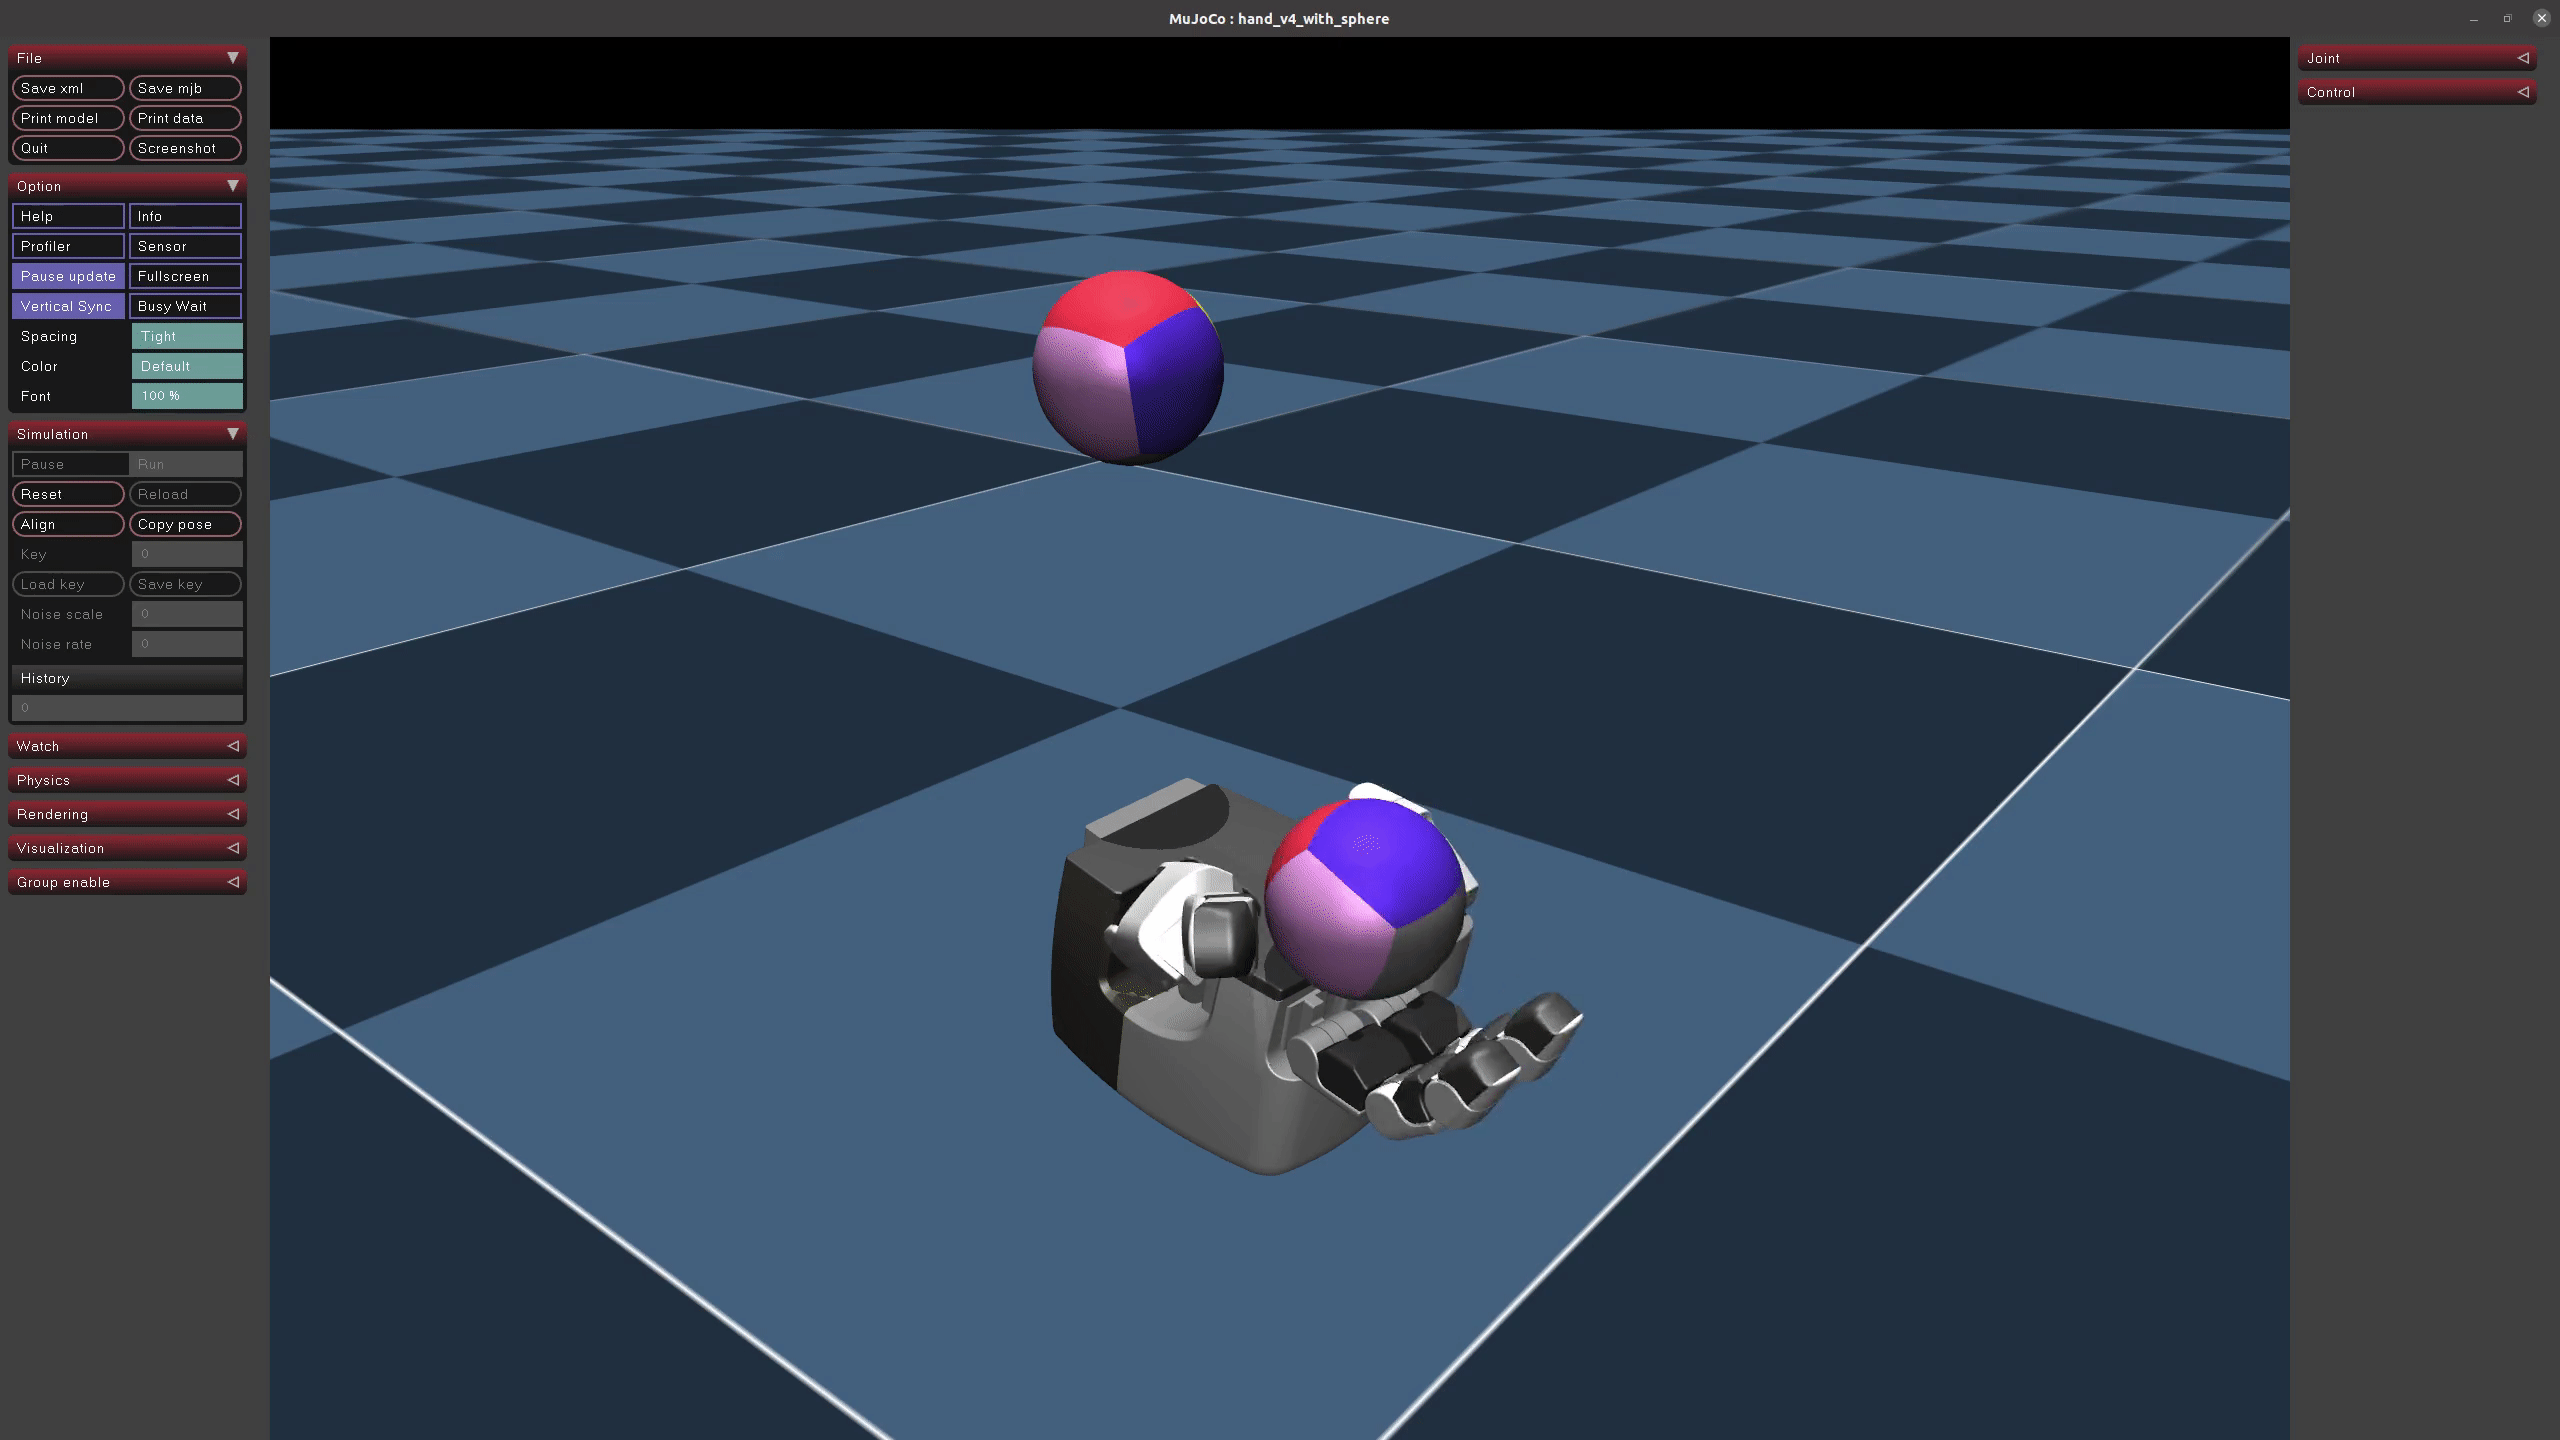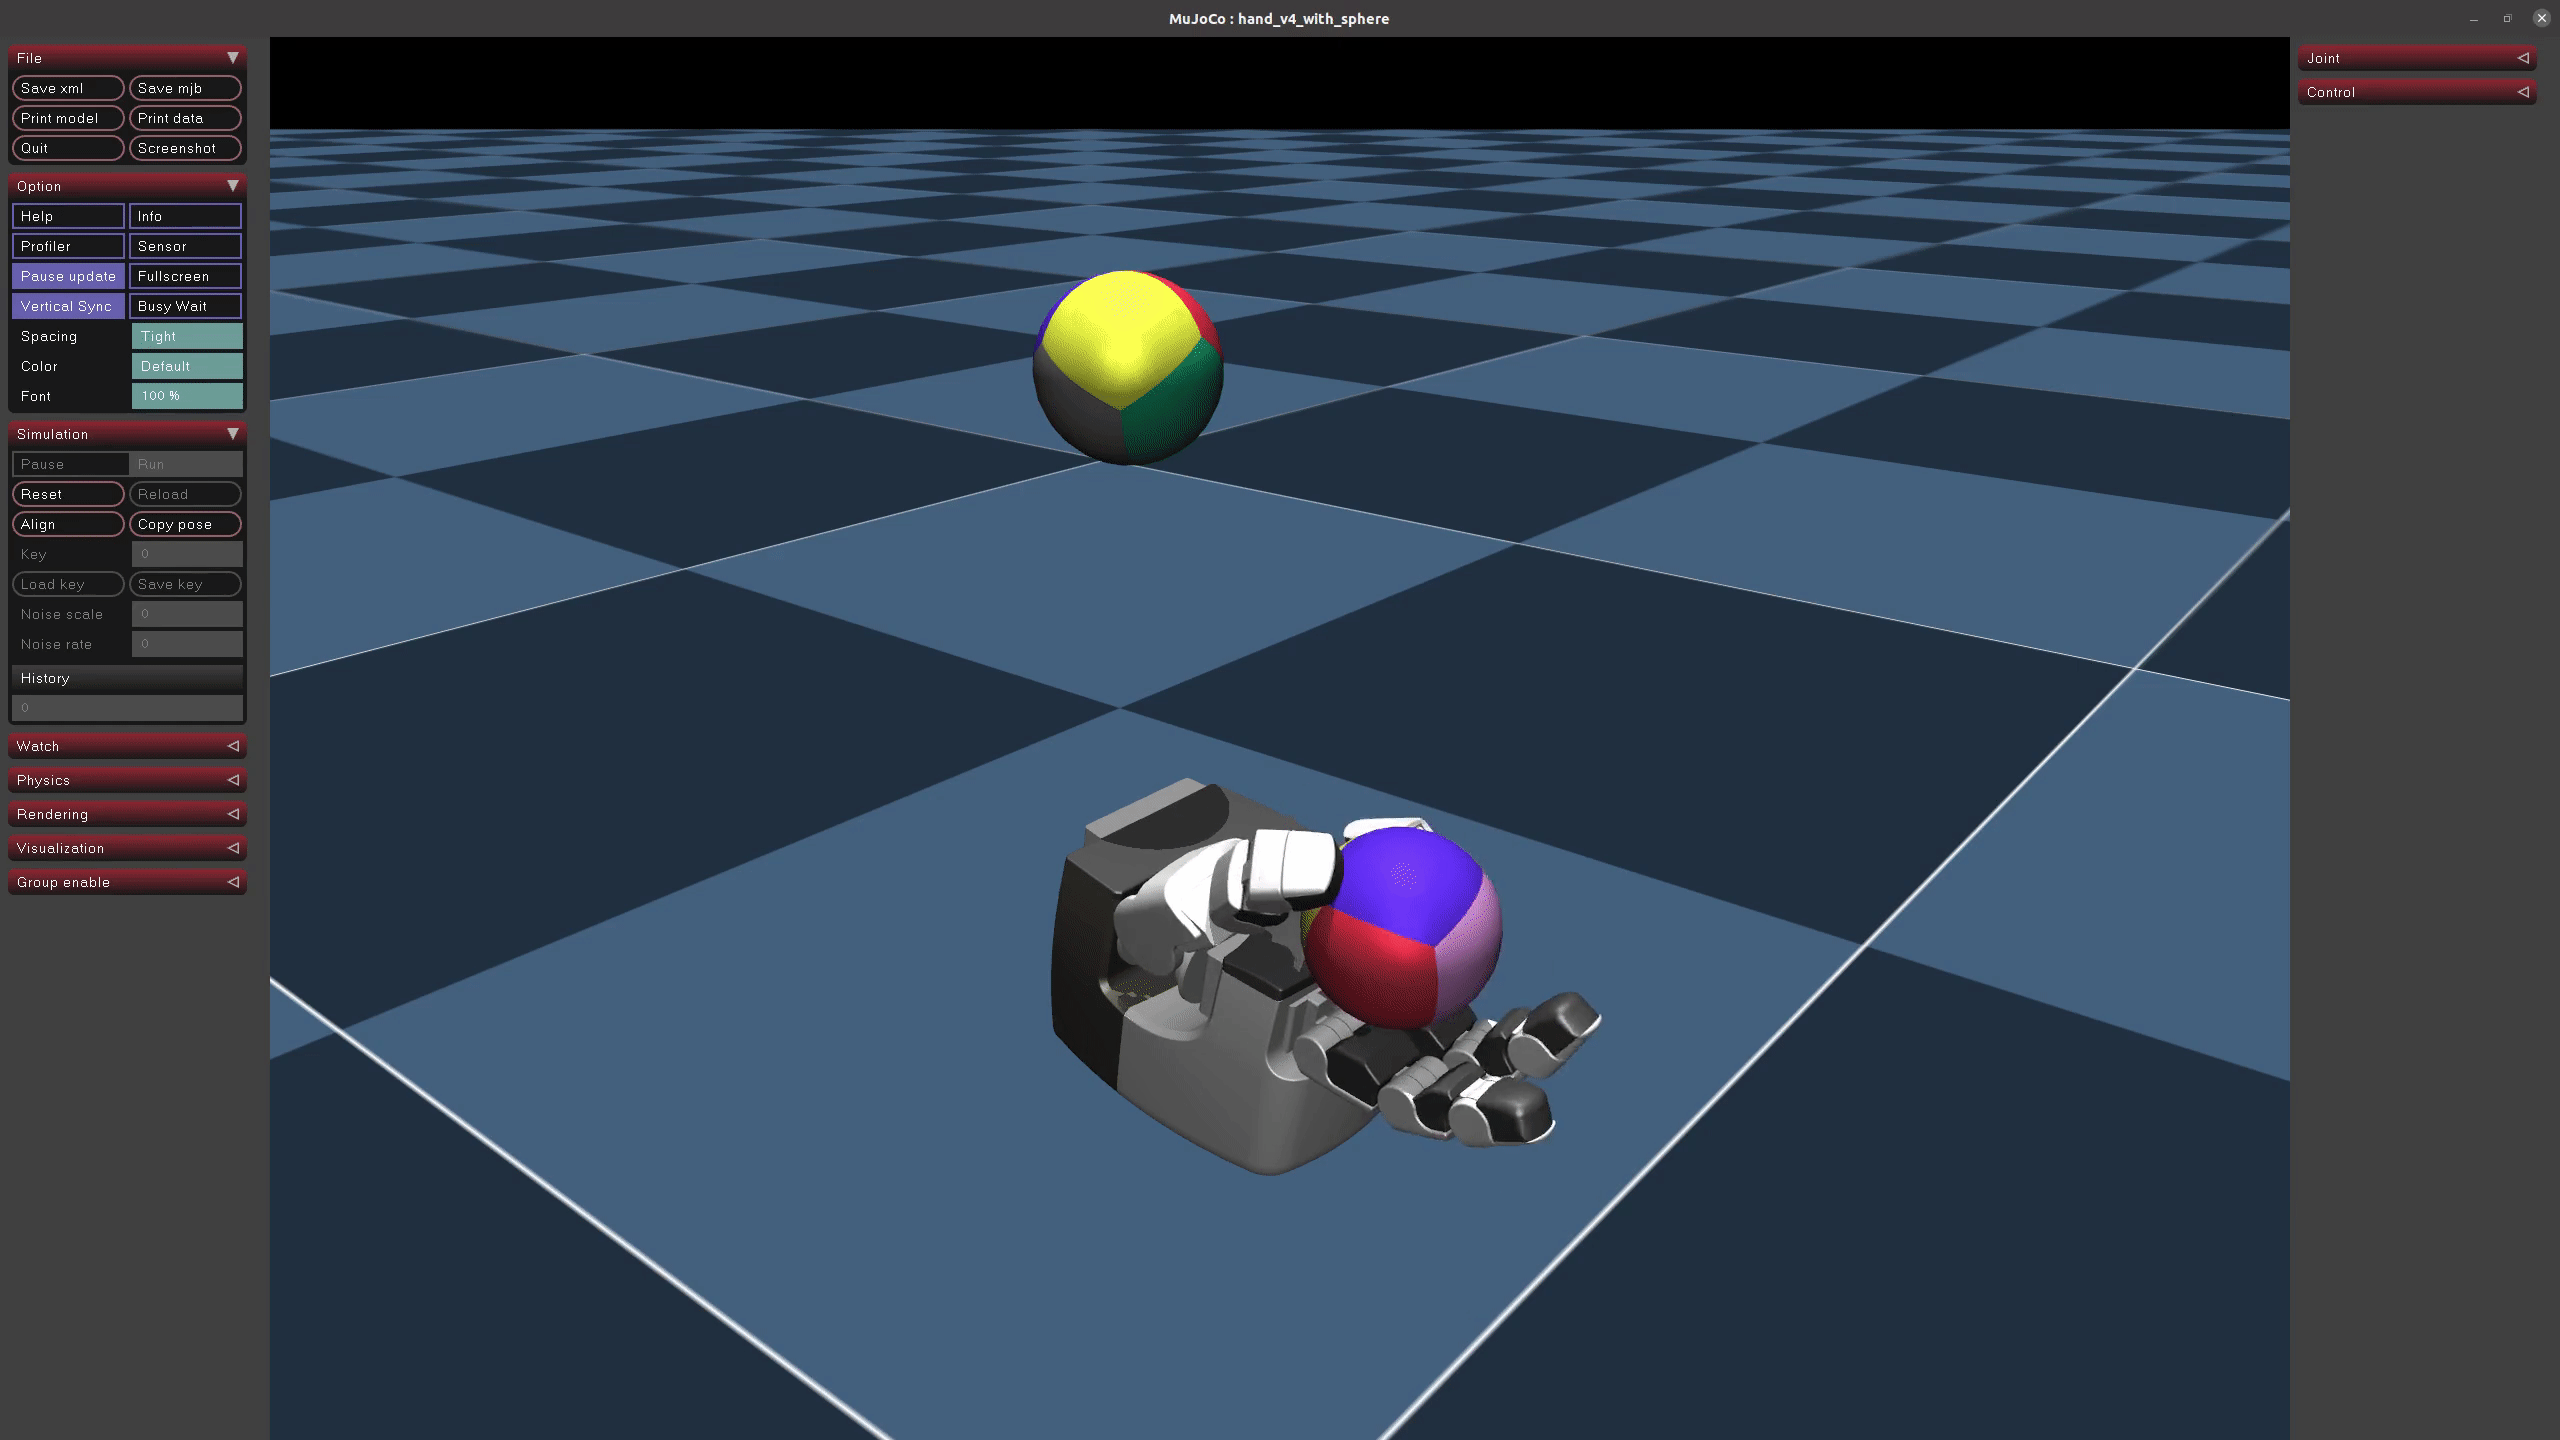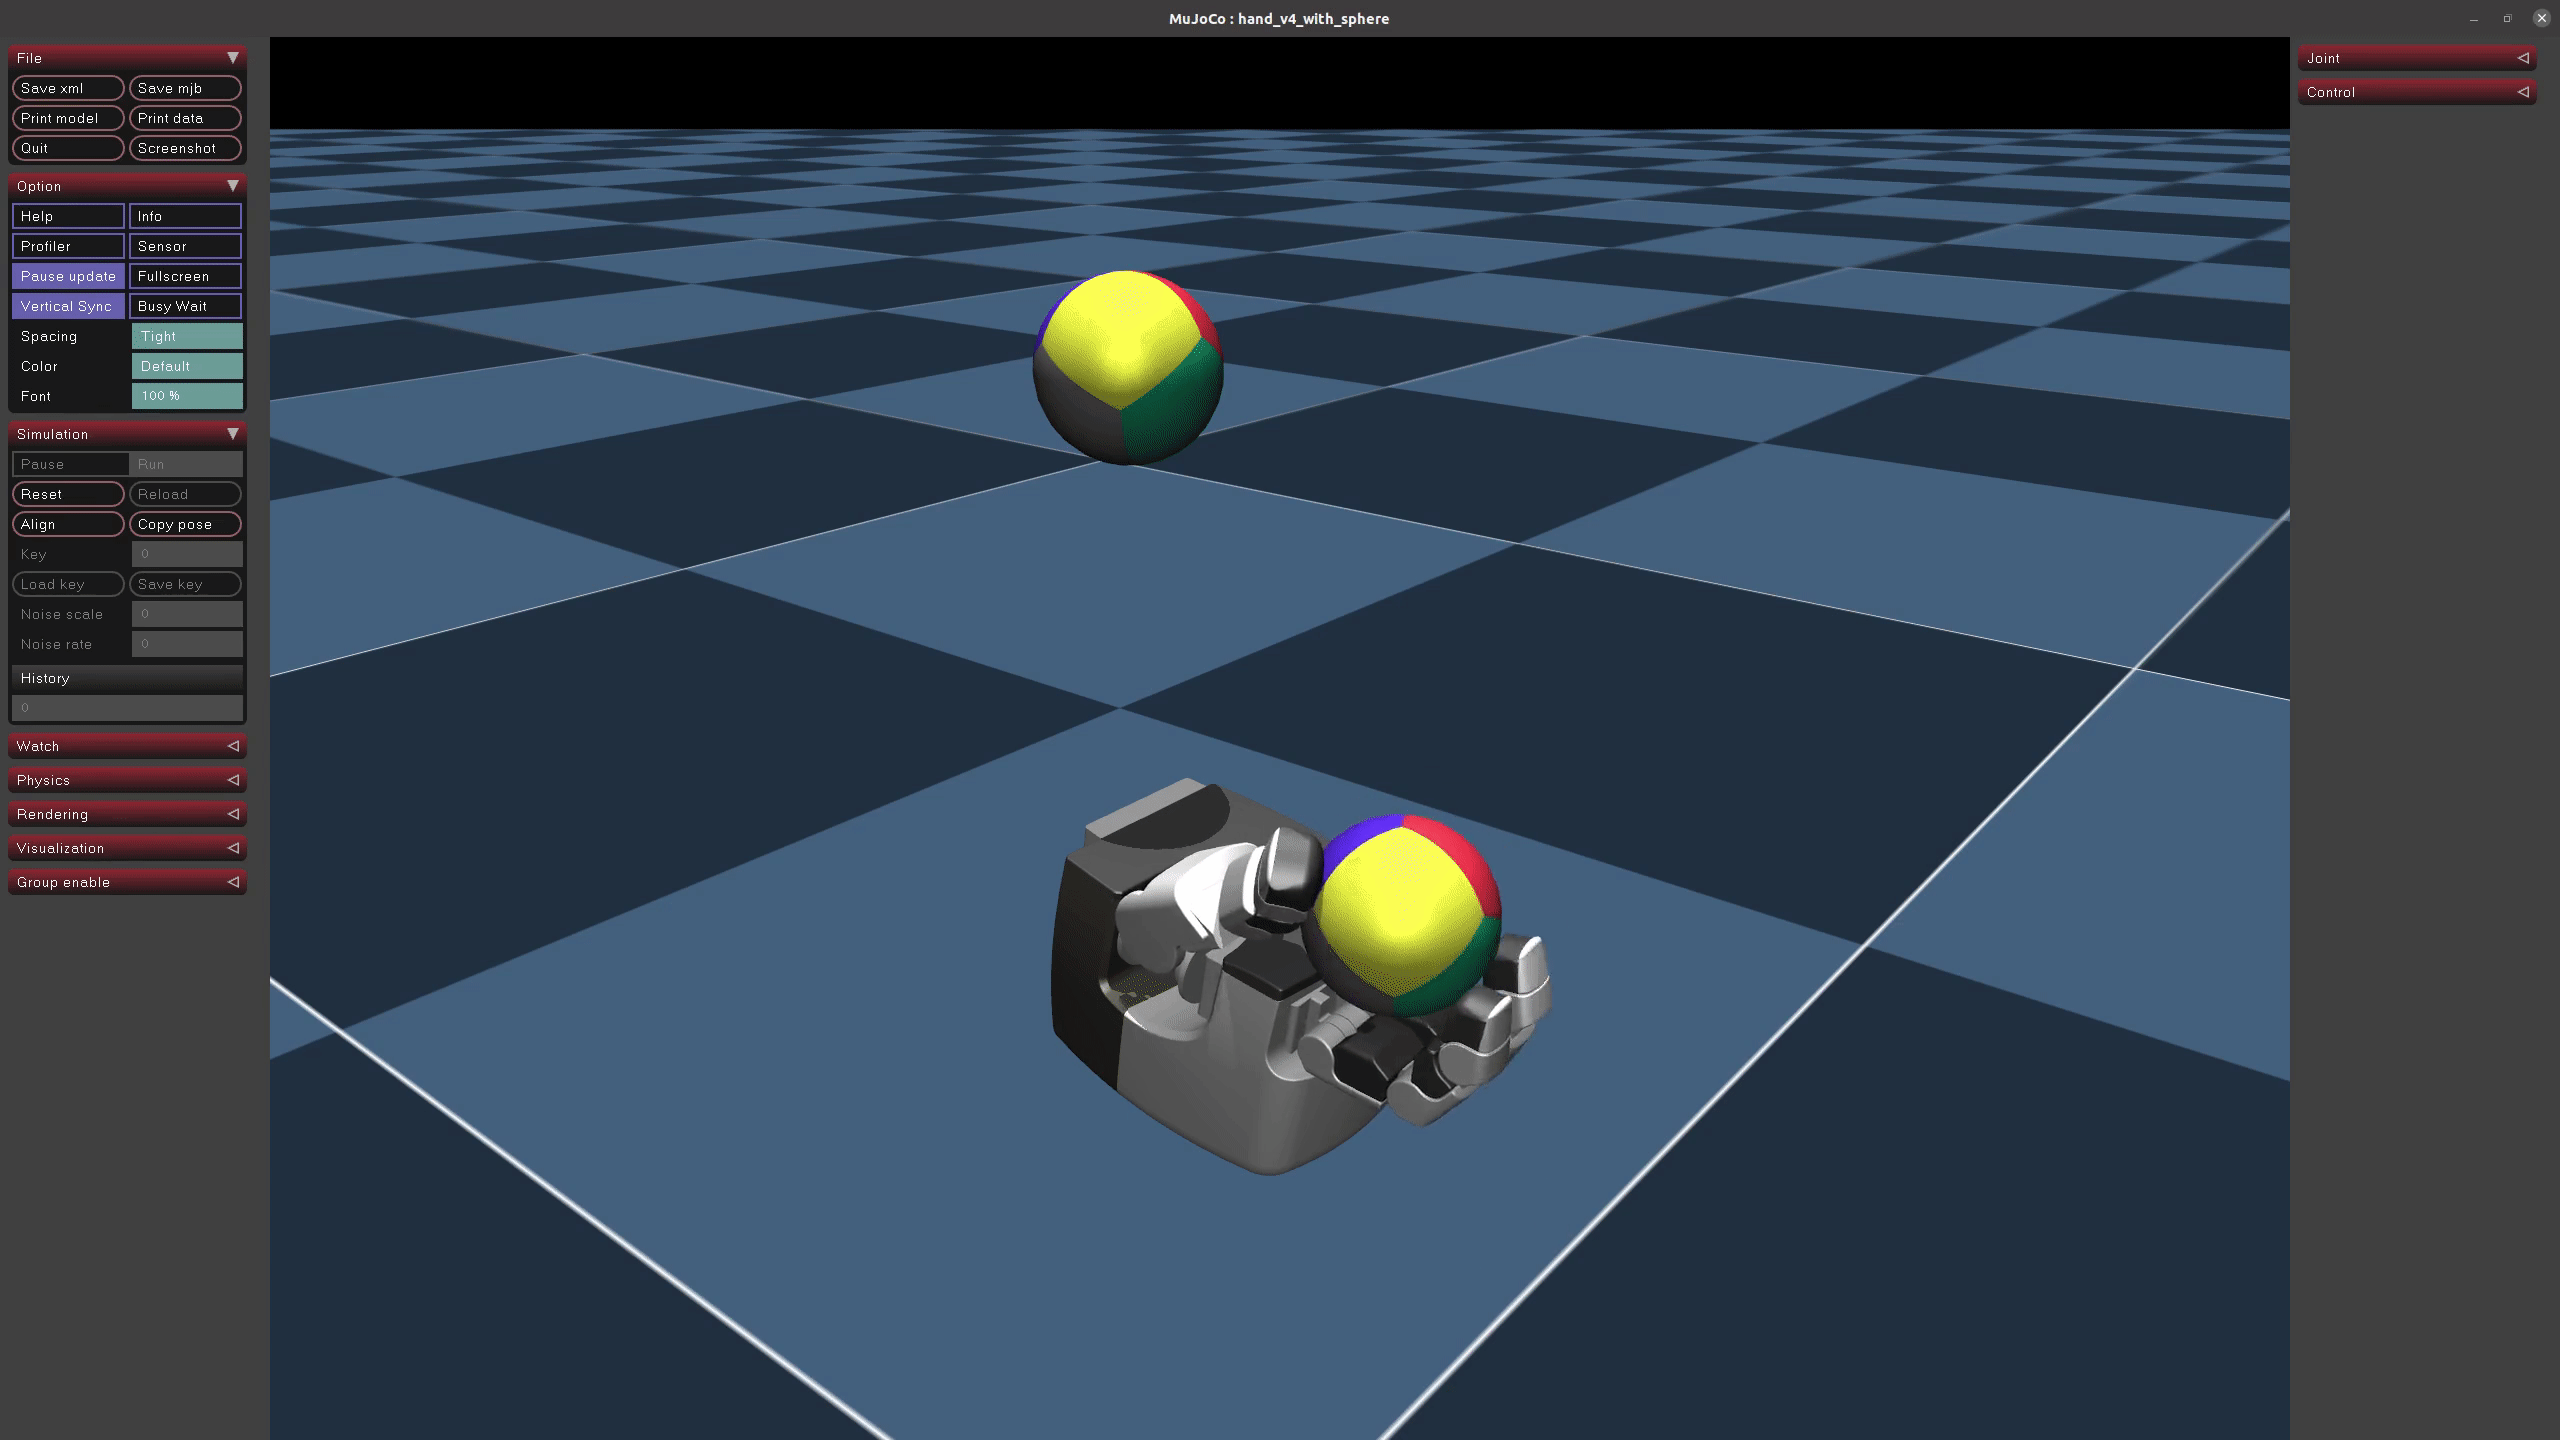
 ### Reorientate sphere
※ Please execute the script again when the sphere gets stuck in the hand or falls from the hand.
```
cd example_rl_play
python reorientation_sphere.py
```
 ### Reorientate cube
※ Please execute the script again when the cube gets stuck in the hand or falls from the hand.
```
cd example_rl_play
python reorientation_cube.py
```