# Genesis Humanoid
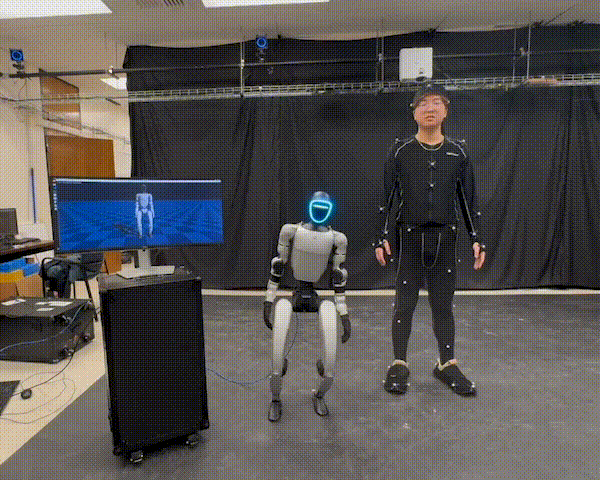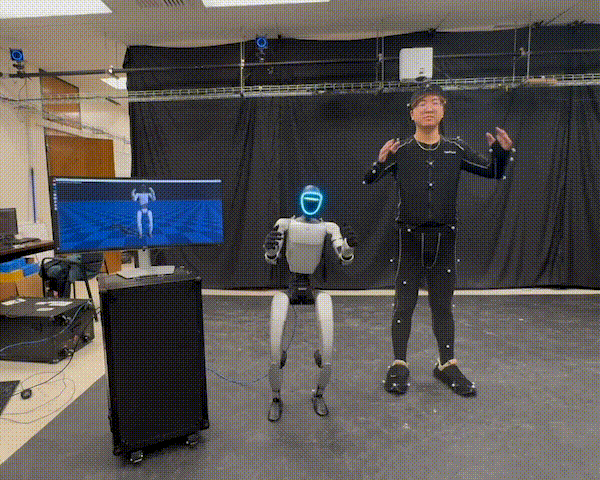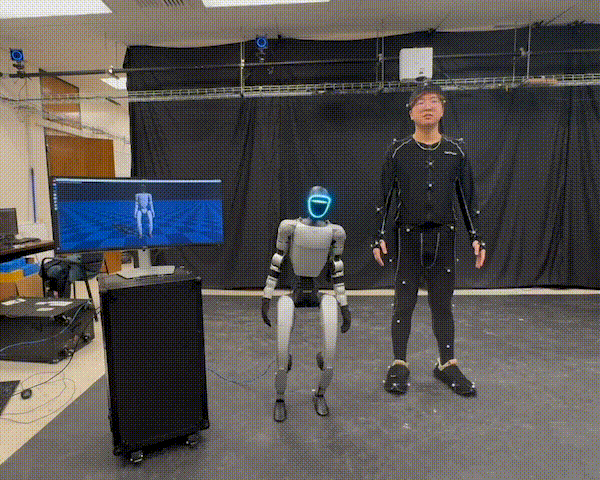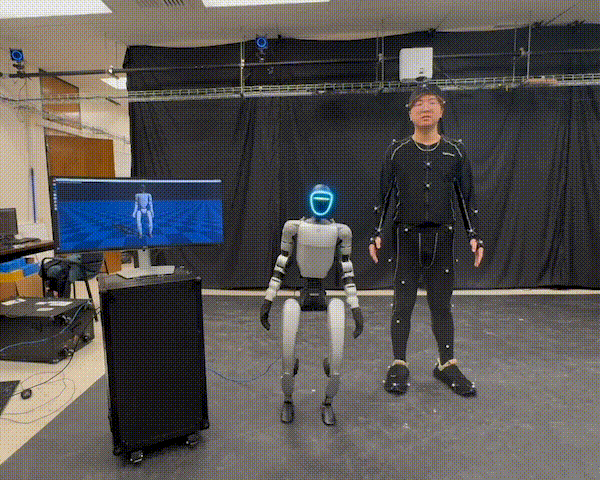
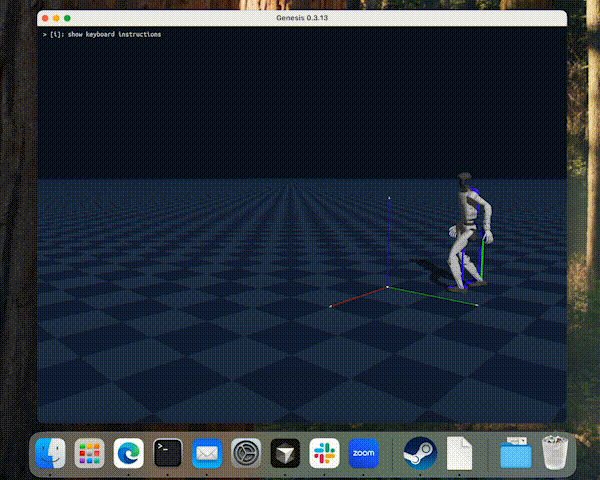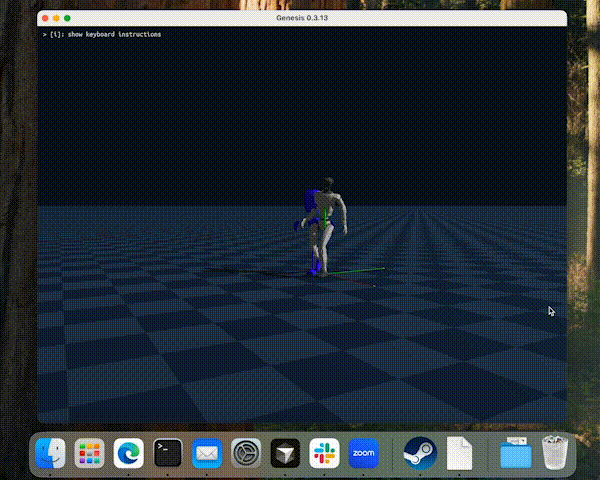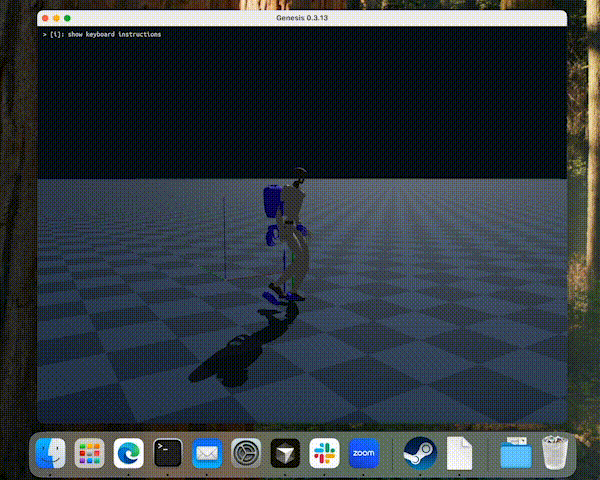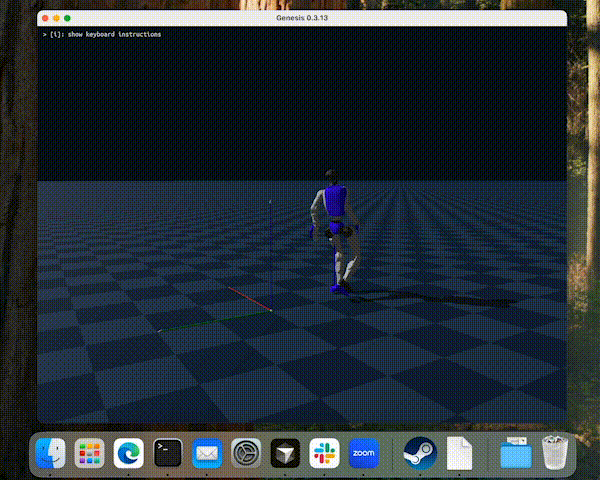
**Genesis Humanoid** is an all-in-one humanoid research platform on top of the [Genesis](https://github.com/Genesis-Embodied-AI/Genesis) simulator. It supports real-time human-to-humanoid retargeting, includes different motion dataset with unified format, provides an end-to-end learning pipeline, and offers a modular low-level control testbed for experimentation.
## Outline
- [Features](#features)
- [Code Structure](#code-structure)
- [Code Style](#code-style)
- [Installation](#installation)
- [Usage](#usage)
- [Process humanoid motions](#process-humanoid-motions)
- [Retarget human motion](#retarget-human-motion)
- [Run RL training](#run-rl-training)
- [Run BC distillation](#run-bc-distillation)
- [RL finetune / resume training](#rl-finetune--resume-training)
- [Evaluate trained policy](#evaluate-trained-policy)
- [Deploy to a real robot](#deploy-to-a-real-robot)
- [Teleoperate the robot](#teleoperate-the-robot)
- [Unified Motion Dataset](#unified-motion-dataset)
- [Citation](#citation)
- [Acknowledgement](#acknowledgement)
## Supported Hardware
- [OptiTrack Mocap](https://optitrack.com/) `src/env/gs_env/real/optitrack`
- [SteamVR](https://store.steampowered.com/app/250820/SteamVR/) `src/env/gs_env/real/steamvr`
- [ChangingTek Gripper](https://en.changingtek.com/diandong/147) (CTAG2F90-D) `src/env/gs_env/real/changingtek`
- [RealSense Camera](https://www.realsenseai.com/) (Async streaming by shared memory) `src/env/gs_env/real/realsense`
- [WitMotion IMU](https://witmotion-sensor.com/products/mpu9250-high-precision-accelerometer-magnetometer-wt901c-for-pc-arduino-raspberry-pi) (WT901C) `src/env/gs_env/real/witimu`
## Features
Genesis Humanoid shares the modular design with [GenesisPlayground](https://github.com/yun-long/GenesisPlayground), featuring with:
- **macOS compatibility** provides an interactive viewer on your MacBook.
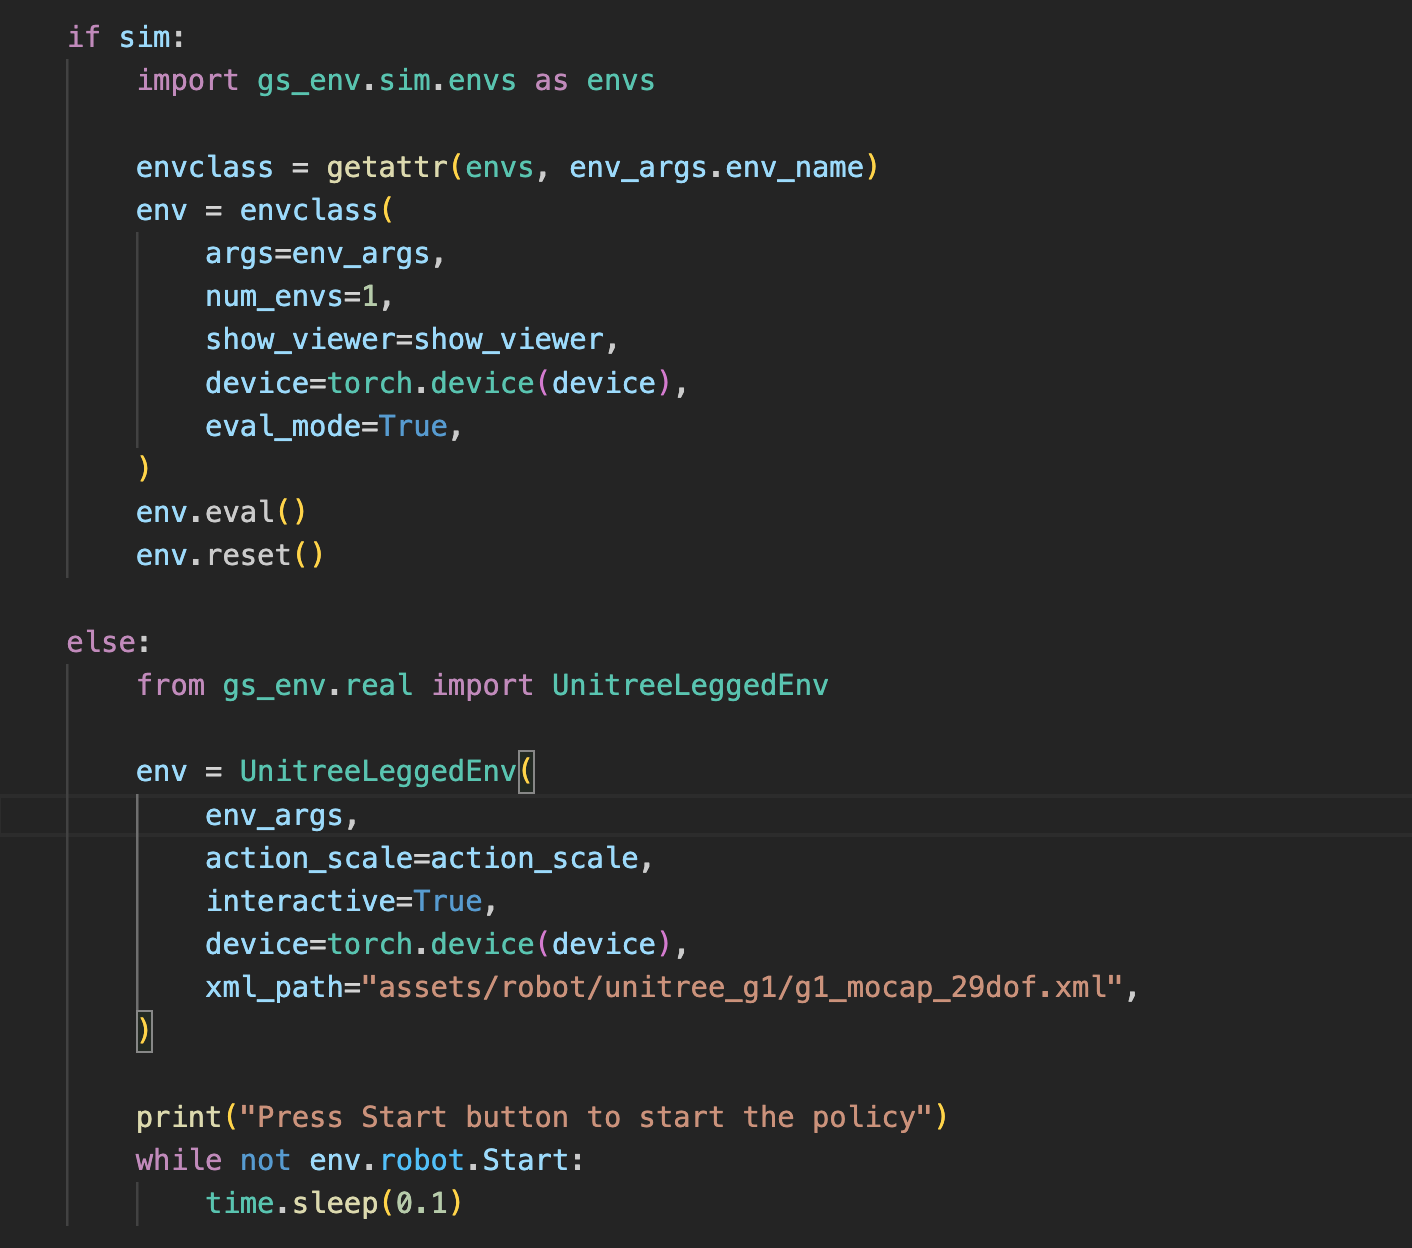
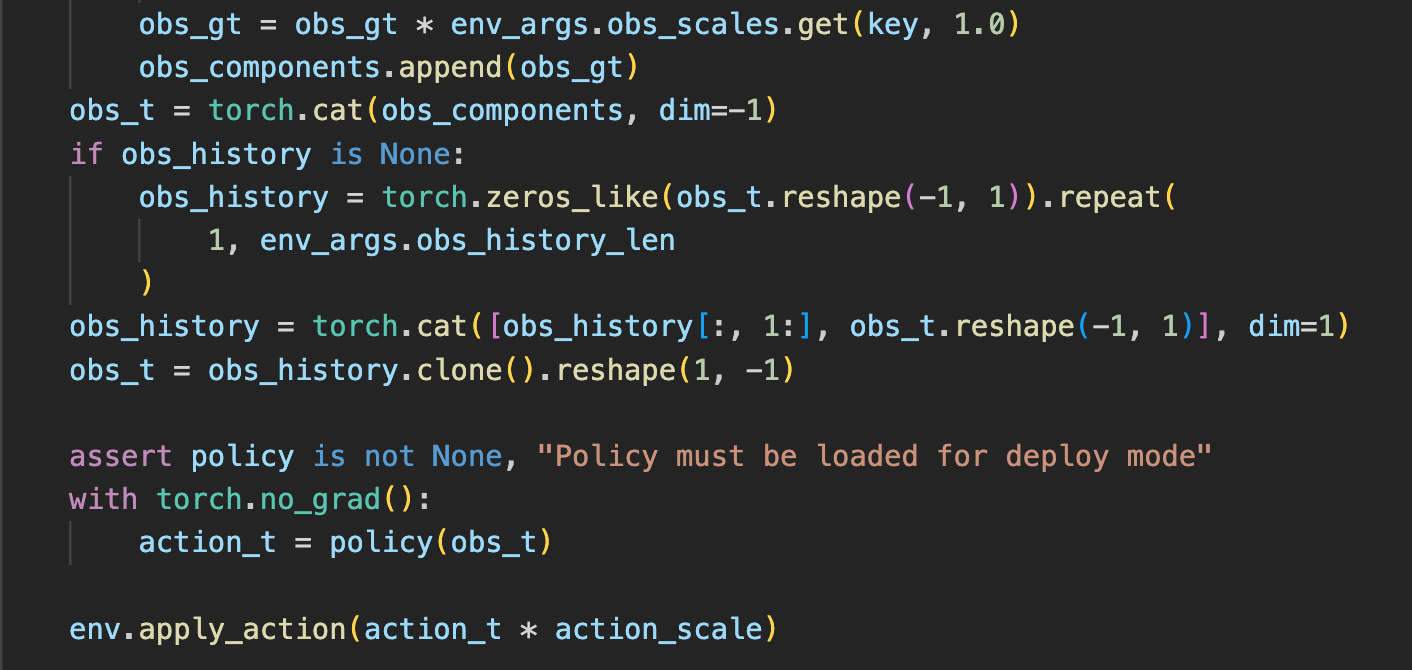
- **Sim-Real duality** enables seamless sim2real deployment with the same code.
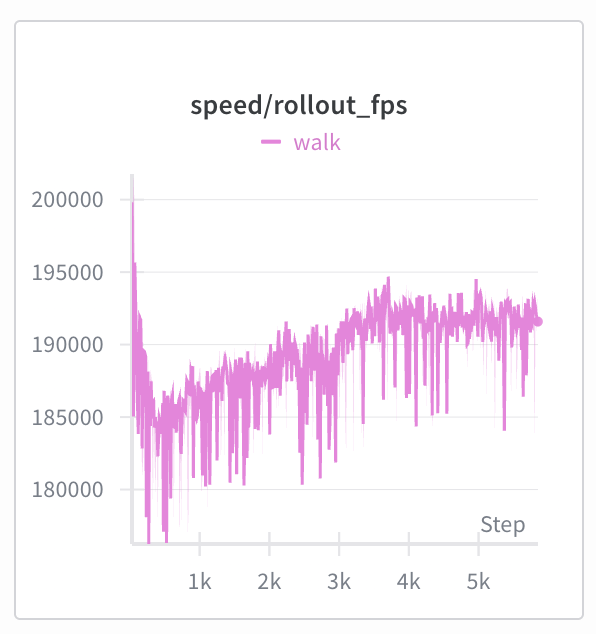
- **Extraordinary speed** that reaches **200k RL** steps per second (8192 environments, decimation 4 and 29 articulated joints, tested on a NVIDIA L40s with `run_ppo_walking.py`), which is nearly **0.8M FPS**.
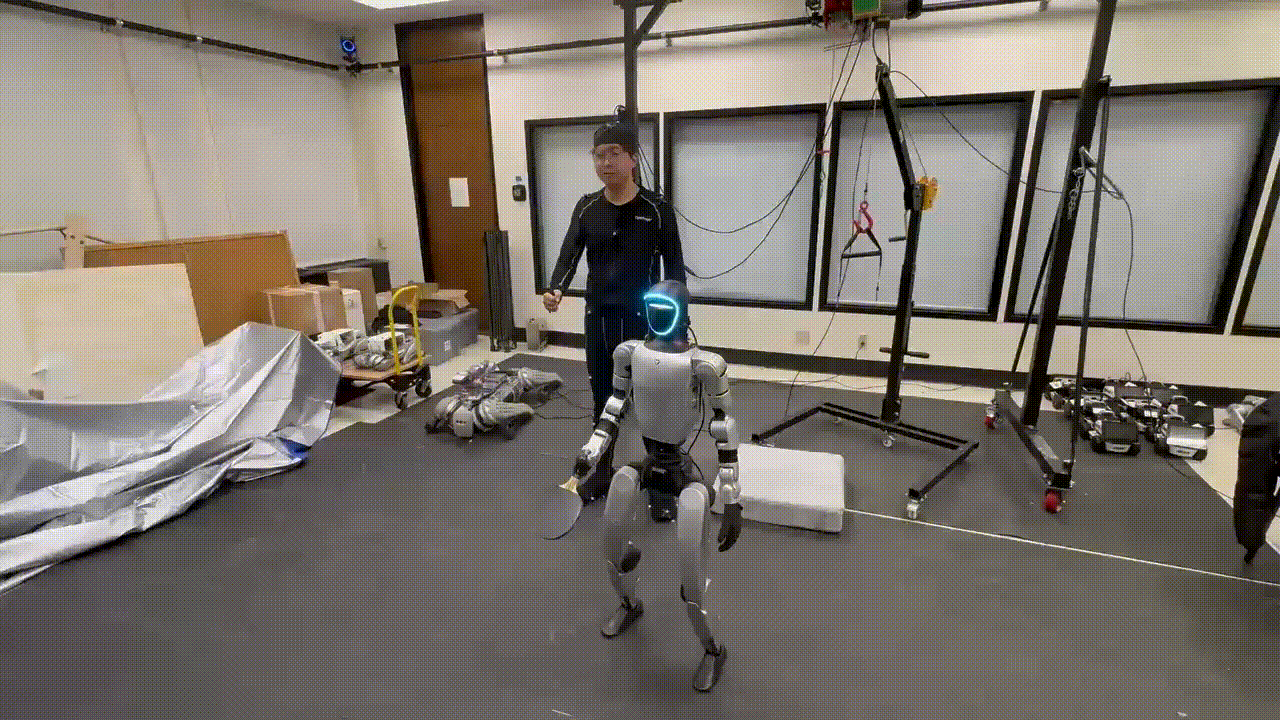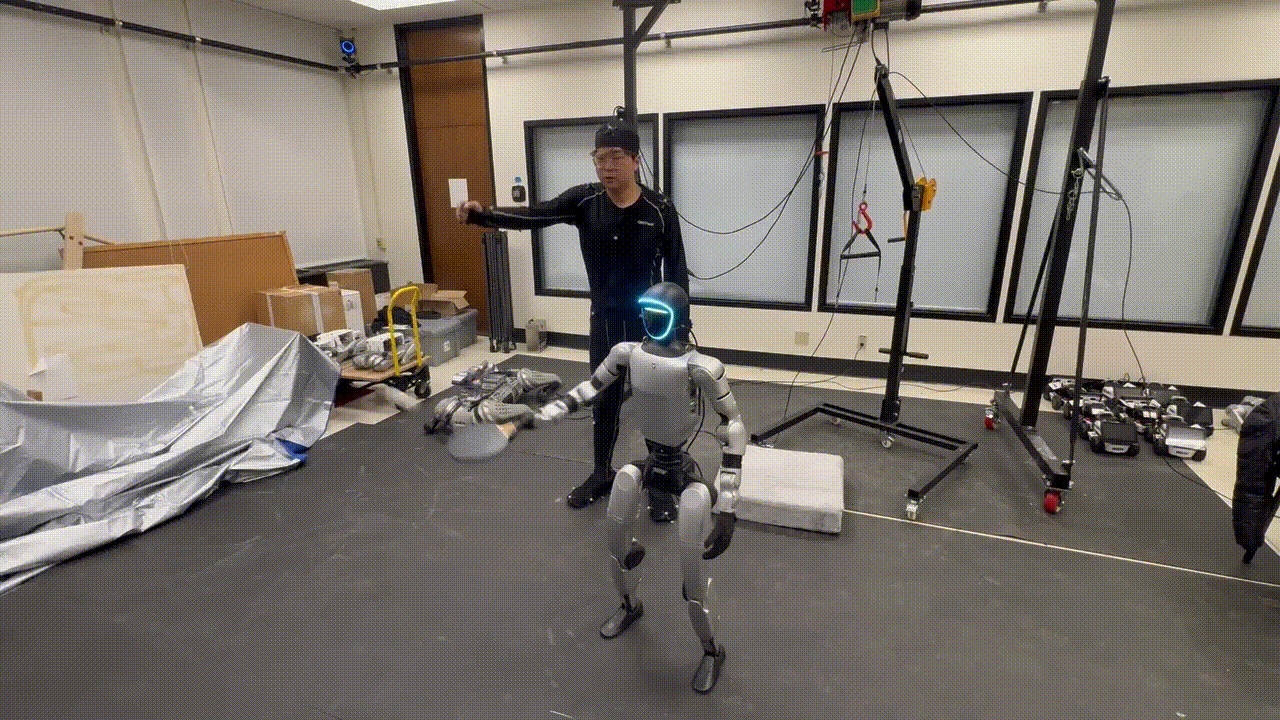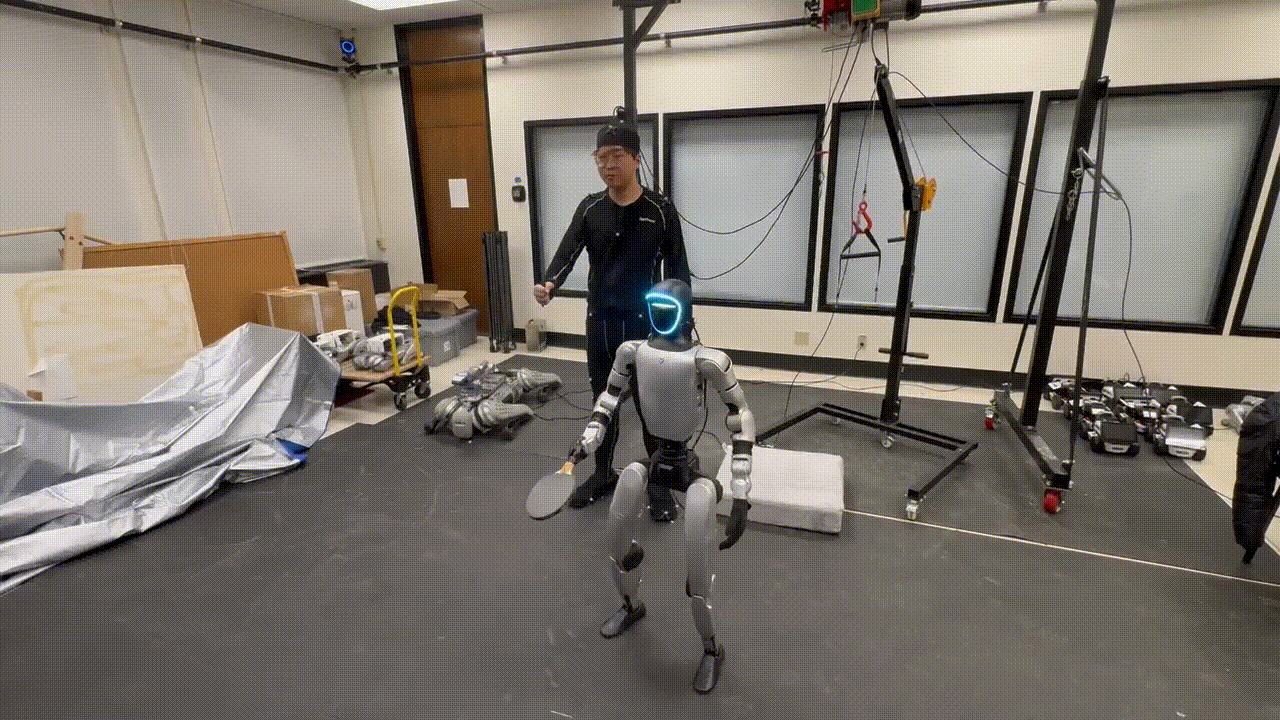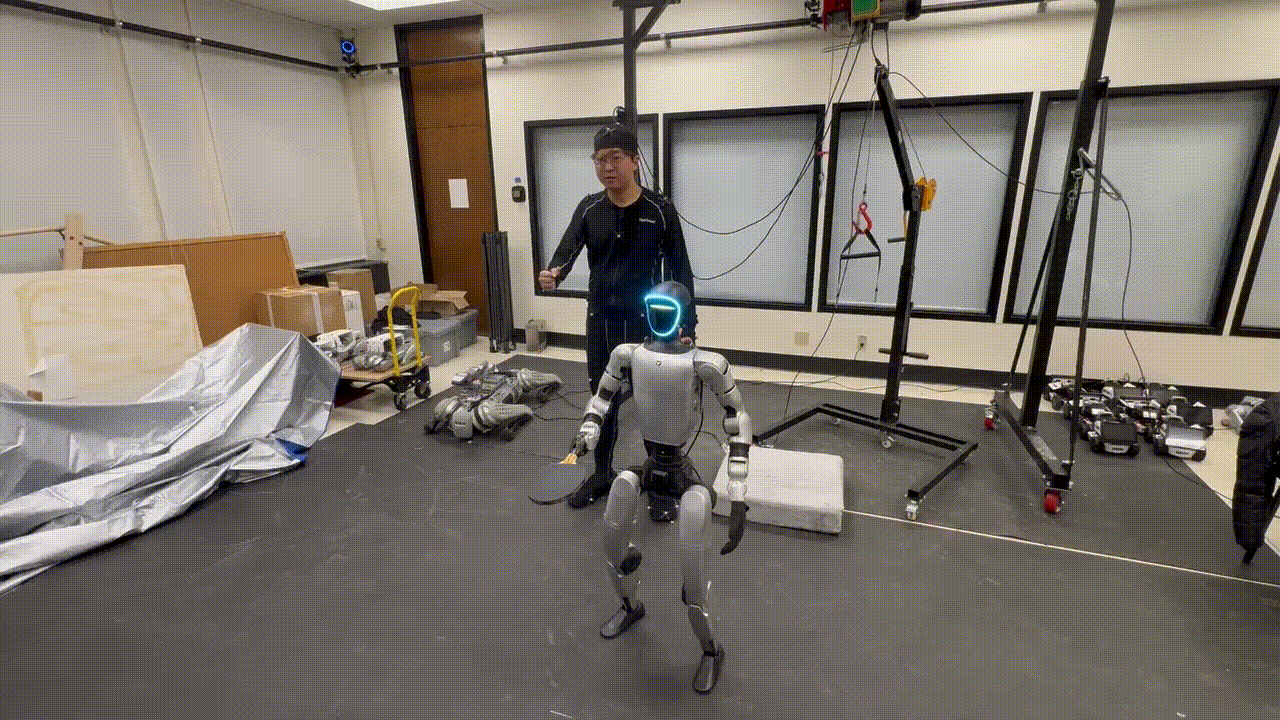
We list several featured projects built on Genesis Humanoid below:
A whole-body teleoperation system for Unitree G1 with
50ms end-to-end latency.
## Code Structure
Adopting from [GenesisPlayground](https://github.com/yun-long/GenesisPlayground), Genesis Humanoid is built with:
- `gs-schemas` - Shared data structures and interfaces
- `gs-agent` - Robot learning algorithms (PPO and DAgger)
- `gs-env` - Wrapped environments including both simulation and real world
- `examples` - Ready-to-run examples in simulation
- `deploy` - Ready-to-run examples in the real world
To setup a new simulation environment, write new robot and environment configurations in `src/env/gs_env/sim/robots/config/registry.py` & `src/env/gs_env/sim/envs/config/registry.py`.
## Code Style
We use `pre-commit` to enforce code formatting and linting.
```bash
pre-commit install
pre-commit run --all-files
```
## Installation
### 1. Install Dependencies
```bash
# Install uv (fast Python package manager)
curl -LsSf https://astral.sh/uv/install.sh | sh
# Clone and setup the repository
git clone --recurse-submodules git@github.com:UMass-Embodied-AGI/Genesis-Humanoid.git
cd Genesis-Humanoid
```
### 2. Install the `gs-env` package
```bash
# uv
uv sync --package gs-env
# pip
uv pip compile pyproject.toml -o requirements.txt --python /PATH/TO/PYTHON
python -m pip install -r requirements.txt
```
### 3. Activate the environment
```bash
source .venv/bin/activate
```
### 4. Setup real-world environment
Please refer to READMEs in each folder under `src/env/gs_env/real`.
## Usage
A wide range of example usages of Genesis Humanoid can be found in the `/examples` and `/deploy` directories.
### Process humanoid motions
```bash
# LAFAN1 (Optional but recommended)
python examples/convert_lafan.py
# HuB (Optional)
python examples/convert_hub.py
```
### Retarget human motion
```bash
# Recorded MoCap motion
python examples/convert_optitrack.py
# AMASS (Optional)
# Download SMPLX body model to assets/body_models
# Download AMASS dataset to assets/AMASS
python examples/convert_amass.py
```
For motion retargeting, Genesis Humanoid integrates Cartesian-spacing mapping from [ExtremControl](https://github.com/yourname/ExtremControl) and cleans up [GMR](https://github.com/YanjieZe/GMR) for joint-space retageting.
Check [Teleoperate](#teleoperate-the-robot) for real-time retargeting from OptiTrack or SteamVR.
### Run RL training
```bash
# Teleop teacher policy
python examples/run_ppo_motion.py \
--exp_name TEACHER_EXP_NAME \
--env_name g1_motion_teacher \
--env.motion_file assets/motion/motion.yaml
```
### Run BC distillation
```bash
# Distill a deployable policy
python examples/run_bc_motion.py \
--exp_name BC_EXP_NAME \
--env_name g1_motion \
--teacher_exp_name TEACHER_EXP_NAME \
--env.motion_file assets/motion/motion.yaml
```
### RL finetune / resume training
```bash
# Finetune the distilled policy
python examples/run_ppo_motion.py \
--exp_name BC_EXP_NAME \
--env_name g1_motion \
--resume True \
--use_stored_config False \
--runner.freeze_actor_iterations 200 \
--algo.lr 3e-5 \
--env.motion_file assets/motion/teacher.yaml
```
### Evaluate trained policy
```bash
# Evaluation will store a deployable policy to deploy/logs/EXP_NAME
python examples/run_ppo_motion.py \
--exp_name EXP_NAME \
--num_ckpt NUM_CKPT (optional) \
--eval True \
--show_viewer True \
--env.motion_file assets/motion/evaluate.pkl
```
### Deploy to a real robot
Install [unitree-sdk2-python](https://github.com/unitreerobotics/unitree_sdk2_python) for deployment.
Install [redis](https://github.com/redis/redis) for teleoperation.
```bash
# Make sure deploy/logs/EXP_NAME exists
# Sanity check in simulation
uv pip install redis
python deploy/g1_teleop.py --exp_name EXP_NAME
python deploy/g1_motion.py \
--exp_name EXP_NAME \
--motion_file MOTION_PATH
# Deployment should start from small ACTION_SCALE
python deploy/g1_teleop.py \
--exp_name EXP_NAME \
--sim False \
--action_scale ACTION_SCALE
python deploy/g1_motion.py \
--exp_name EXP_NAME \
--motion_file MOTION_PATH \
--sim False \
--action_scale ACTION_SCALE
```
### Teleoperate the robot
```bash
# Test with existing motion
python deploy/motion_publisher.py --motion_file MOTION_FILE
# Optitrack MoCap
python deploy/optitrack_publisher,py
# SteanVR
python deploy/steamvr_publisher.py
```
## Unified Motion Dataset
The `convert_[ ].py` files convert the existing motions from different format into:
```python
{
"fps": 50,
"link_names": ["LINK_NAMES_IN_ORDER"],
"dof_names": ["DOF_NAMES_IN_ORDER"],
"pos": torch.Tensor, # [num_frames, 3] position of the root link
"quat": torch.Tensor, # [num_frames, 4] quaternion of the root link
"dof_pos": torch.Tensor, # [num_frames, num_dof] dof positions in order
"link_pos": torch.Tensor, # [num_frames, num_link, 3] link positions in order
"link_quat": torch.Tensor, # [num_frames, num_link, 4] link quaternions in order
"foot_contact": torch.Tensor, # [num_frames, 2] foot contact probability
}
```
## Citation
If you find our code useful, please consider citing our related paper:
```
@misc{xiong2026extremcontrol,
title={ExtremControl: Low-Latency Humanoid Teleoperation with Direct Extremity Control},
author={Ziyan Xiong and Lixing Fang and Junyun Huang and Kashu Yamazaki and Hao Zhang and Chuang Gan},
year={2026},
eprint={2602.11321},
archivePrefix={arXiv},
primaryClass={cs.RO},
url={https://arxiv.org/abs/2602.11321},
}
```
## Acknowledgement
The entire codebase is built on [GenesisPlayground](https://github.com/yun-long/GenesisPlayground). We thank [GMR](https://github.com/YanjieZe/GMR) for serving as a reference for retargeting and OptiTrack streaming. The human datasets used in this project includes [AMASS](https://amass.is.tue.mpg.de/), [HuB](https://hub-robot.github.io/) and [LAFAN1](https://huggingface.co/datasets/lvhaidong/LAFAN1_Retargeting_Dataset).