# actuated-umi-gripper
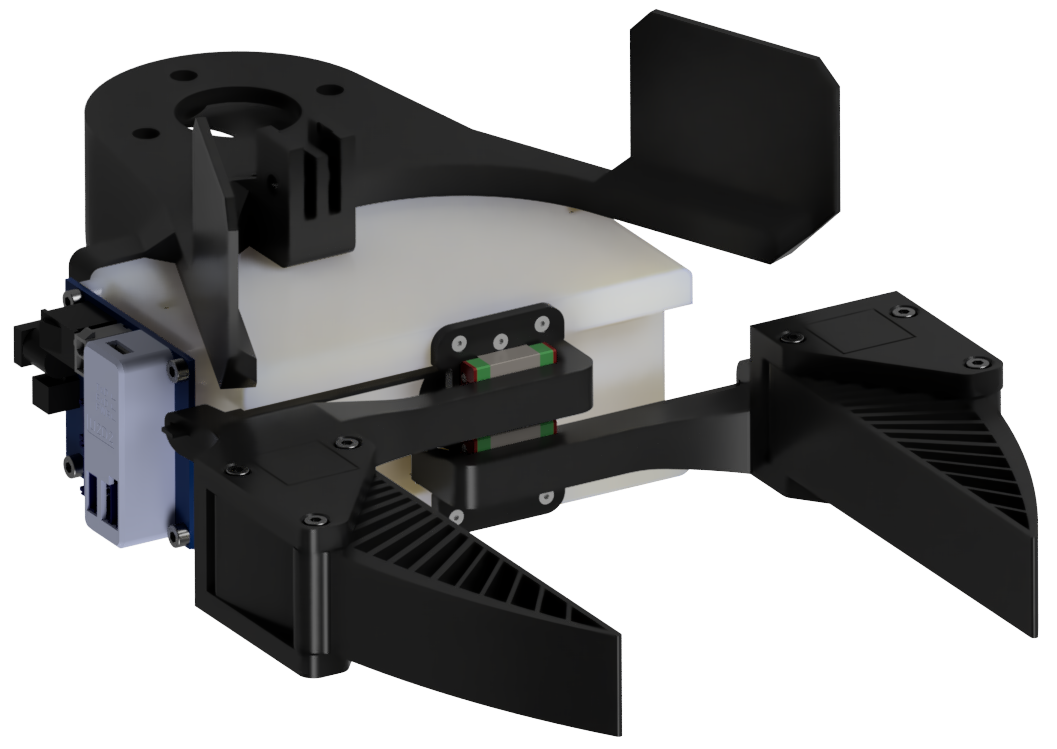
This repository provides an actuated, open-source version of the popular UMI gripper.
Designed to be cost-effective and modular, this gripper uses 3D-printed components to ensure accessibility and reproducibility.
With a Dynamixel motor for actuation, you can assemble the gripper yourself using the included design files and guidelines.
This repository contains the mechanical design files and printable components, enabling you to build and customize the gripper to suit your needs.
This project would not have been possible without the earlier efforts of Chi et al. (2024) and the work of Clayton Haight. For more information about the prior works, please see the Acknowledgements Section.
For more information about actuated-UMI, visit the project page »
## Usage
To use the gripper after it is fully assembled, you will need the appropriate software to control it. We recommend using the [Dynamixel API](https://github.com/TimSchneider42/dynamixel-api) developed by our team. This API provides a comprehensive set of tools and functions to interface with Dynamixel motors, which are used in the actuated UMI gripper.
The repository includes detailed instructions on how to install and use the API, as well as example code to get you started. By following the guidelines provided in the Dynamixel API repository, you can easily integrate the gripper into your projects and control its movements programmatically.
## Acknowledgements
This work heavily builds upon the following prior efforts. It would not have been possible without them.
- C. Chi, Z. Xu, C. Pan, E. Cousineau, B. Burchfiel, S. Feng, R. Tedrake, and S. Song, "Universal Manipulation Interface: In-The-Wild Robot Teaching Without In-The-Wild Robots," in Proc. Robotics: Science and Systems (RSS), 2024. We used the [UMI Gripper](https://umi-gripper.github.io) as a key reference for our design, aiming to closely replicate its functionality and form.
- Clayton Haight, creator of [OpenGrip](https://github.com/clayhaight01/OpenGrip). The OpenGrip gripper mechanism served as the initial design starting point for our own gripper development.
- Stan Markwell, for providing CAD files of the ROBOTIS U2D2 Power Hub Board & U2D2, available on [GrabCAD](https://grabcad.com/library/robotis_u2d2_power_hub_board-1).
## License
This project is licensed under the MIT License. However, it incorporates third-party content, which retains its original license terms. Details are as follows:
- **Third-Party Content**: Portions of this project include content from [UMI Gripper](https://umi-gripper.github.io) licensed under the MIT License. The original license file for these materials can be found in [LICENSE_THIRD_PARTY](LICENSE_THIRD_PARTY).
- **Your Contributions**: All other content in this project, created by [Actuated-UMI](https://actuated-umi.github.io), is licensed under the MIT License. You can find the license file for this project in [LICENSE](LICENSE).
For clarity:
- You are free to use, modify, and distribute this project under the terms of the MIT License.
- Please ensure compliance with the license terms for the included third-party content.
## Questions and Contributing
If you have any questions or need help with building the gripper, please create an issue.
We also welcome contributions to this repository, including new 3D models or other improvements. If you would like to contribute, please fork this repository and submit a pull request with your changes, or reach out to erik.helmut1 [at] gmail [dot] de.