๐ŸŒ Boundless-World-Model

> **BWM** is a physically consistent, action-conditioned video world model built upon Wan2.2-TI2V-5B, serving as a low-cost yet high-fidelity simulator for robotic manipulation. ## ๐Ÿ—ž๏ธ News - **[2026-07]** ๐Ÿ“„ **Technical report released!** Read the BWM technical report on [arXiv](https://arxiv.org/abs/2607.29302). - **[2026-05]** ๐Ÿ† **Top results on WorldArena Leaderboard!** BLM ranks 1st among open-source models on Track 1 and Track 2 Data Engine, while BWM-fast ranks 2nd overall on Track 1. - **[2026-05]** ๐Ÿš€ **Inference code released!** Generate action-conditioned robot manipulation videos with BWM. See [๐Ÿ› ๏ธ Usage](#๏ธ-usage). - **[2026-05]** ๐ŸŽ‰ **Model definition released!** The BWM architecture and core model components are now available. ## ๐Ÿ† Competition Results ### **CVPR 2026 WorldArena Challenge** - **BLM**: ๐Ÿฅ‡ **1st Place** among open-source models on **Track 1** and **Track 2 Data Engine**. - **BWM-fast**: ๐Ÿฅˆ **2nd Place** on the overall **Track 1** leaderboard.
Track 1 open-source leaderboard
Track 2 Data Engine open-source leaderboard
Track 1 overall leaderboard
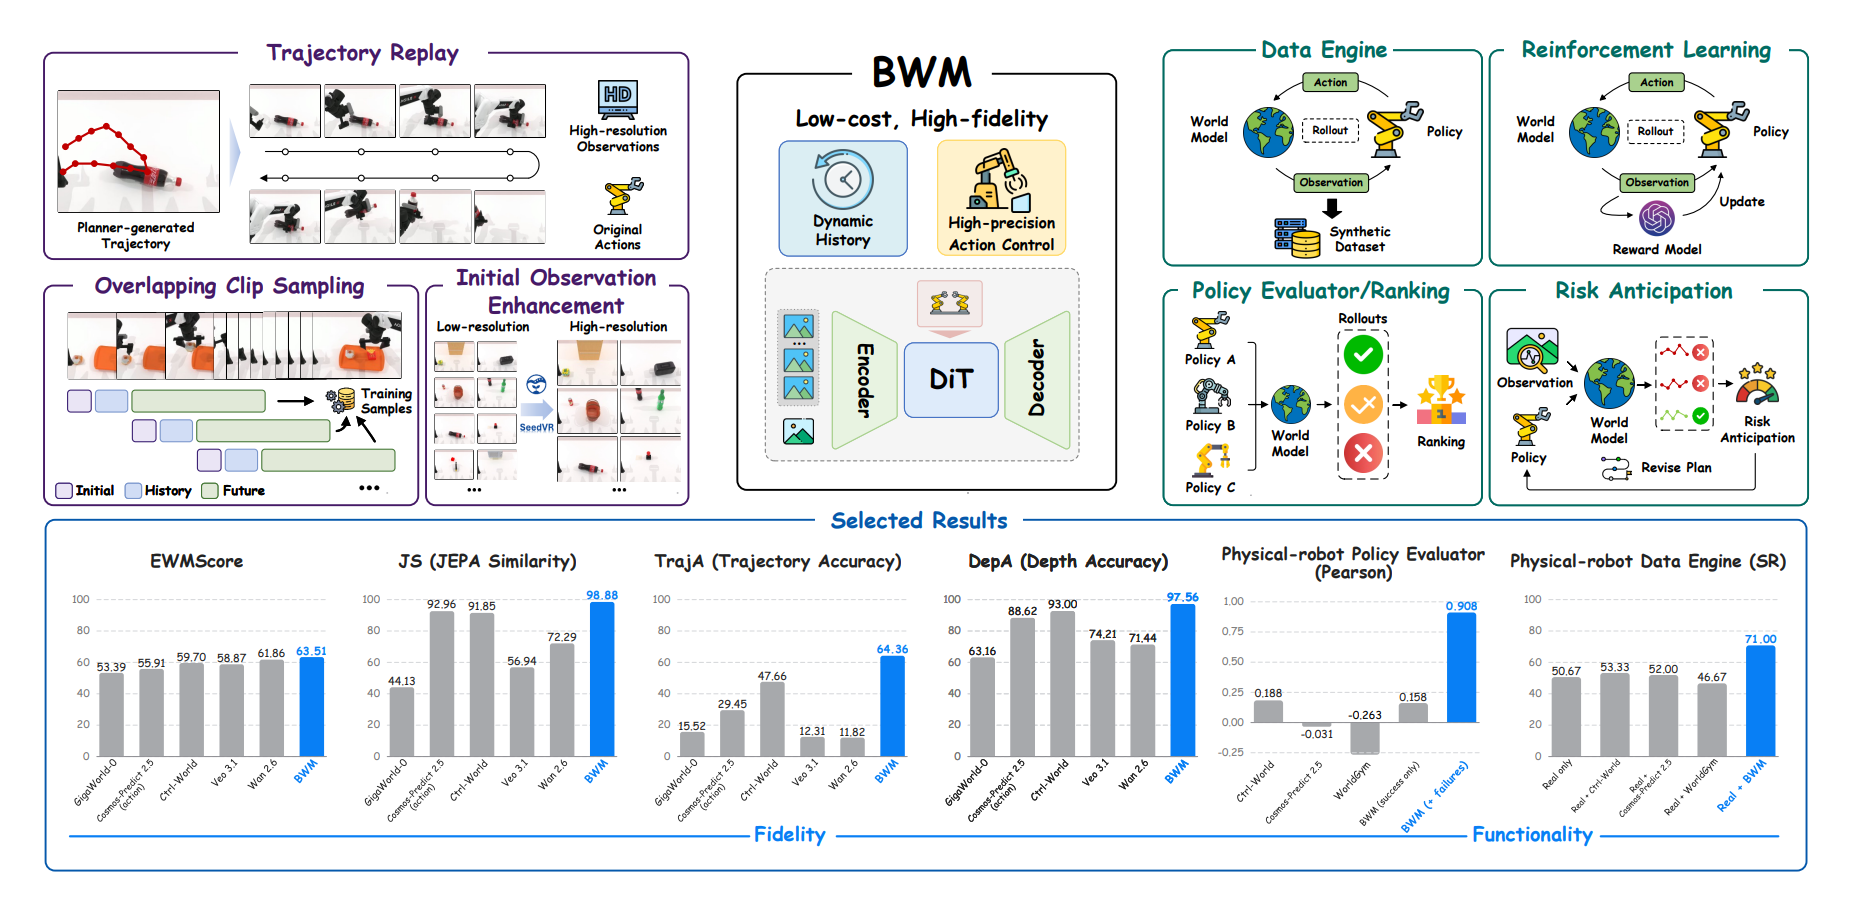
Leaderboard: https://huggingface.co/spaces/WorldArena/WorldArena ## Table of Contents - [โœ… TODO](#-todo) - [๐Ÿ—๏ธ Framework](#๏ธ-framework) - [๐ŸŽฌ Qualitative Results](#-qualitative-results) - [๐Ÿ› ๏ธ Usage](#๏ธ-usage) - [๐Ÿ‹๏ธ Training](#๏ธ-training) - [๐Ÿ™ Acknowledgements](#-acknowledgements) - [๐Ÿ“ง Contact](#-contact) - [๐Ÿ“œ Citing](#-Citing) --- ## โœ… TODO - [x] Release inference code - [x] Release model definition - [x] Release model weights - [ ] Release training code - [x] Release technical report --- ## ๐Ÿ—๏ธ Framework 1. Overview of BWM. BWM combines action-aligned data construction, action-conditioned world simulation, and downstream robot-learning applications.

Overview of BWM

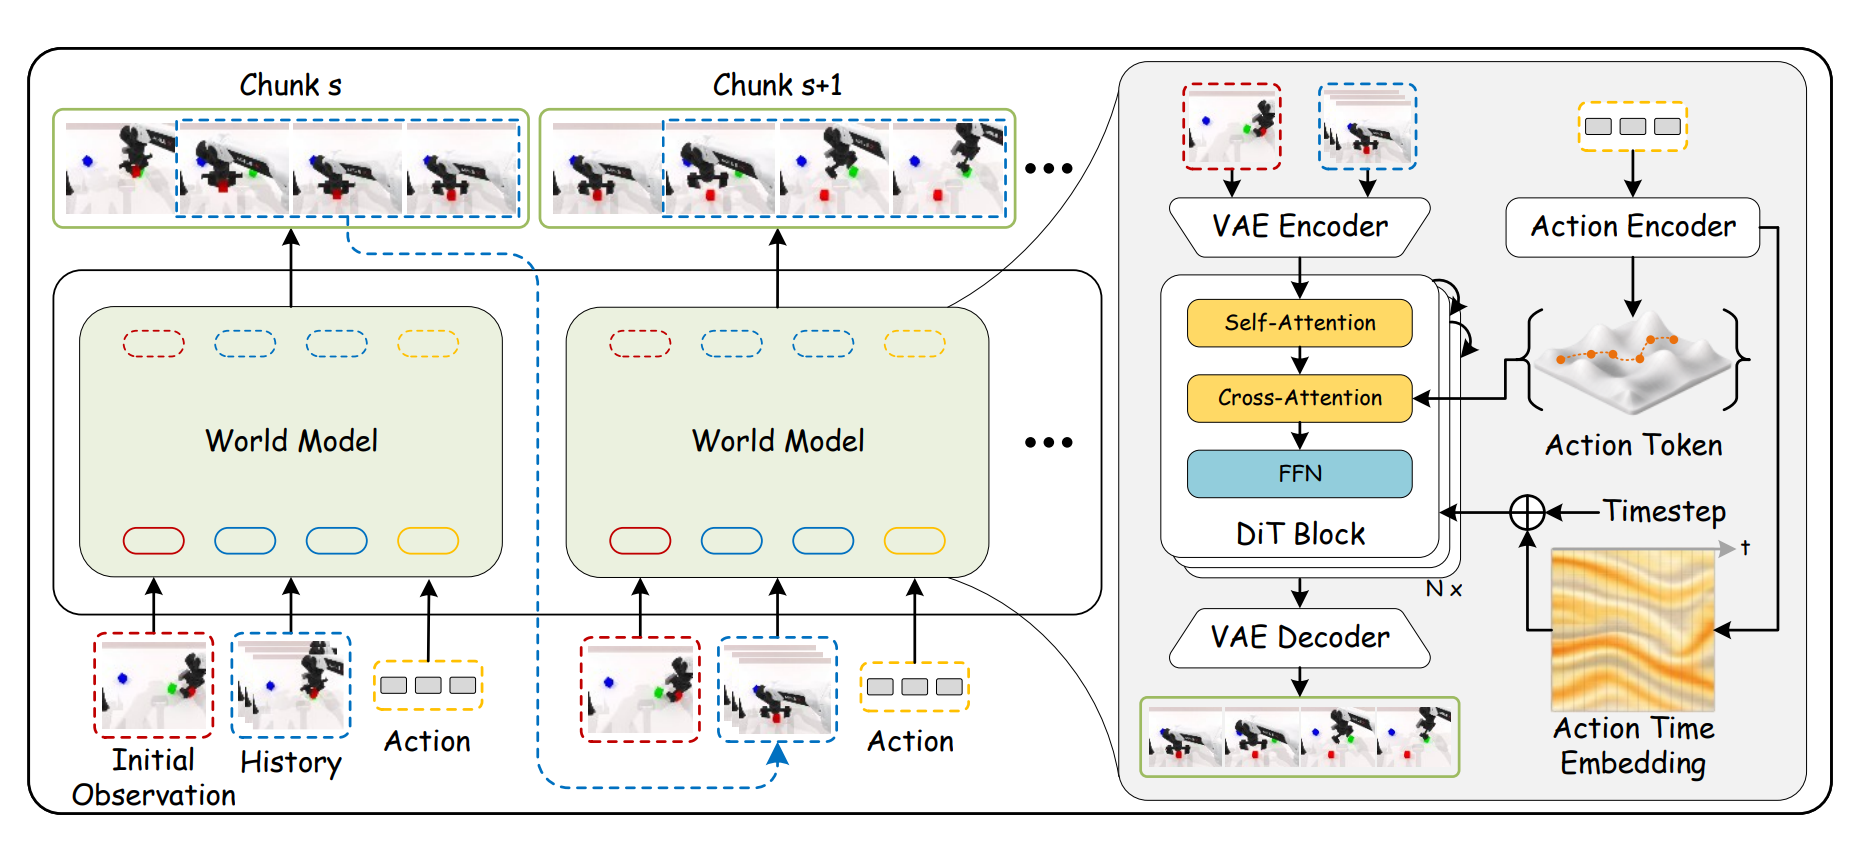
2. Overview of BWM framework. BWM autoregressively predicts future observation chunks from the initial observation, dynamic history, and action chunk. Robot actions enter the video diffusion backbone as cross-attention tokens and action-conditioned timestep embeddings.

Overview of BWM framework

--- ## ๐ŸŽฌ Qualitative Results ### **CVPR 2026 WorldArena Challenge** > The following simulation scenes are generated autoregressively by **BWM** from initial frames and action sequences in the [**WorldArena test set**](https://github.com/tsinghua-fib-lab/WorldArena/), achieving high-fidelity visual realism while maintaining long-horizon physical consistency. #### ๐Ÿงฉ Scene 1: Compositional Spatial Rearrangement
blocks ranking size stack bowls three
- **Task**: arrange blocks by size, stack bowls - **Challenge**: Multi-object spatial ordering, stacking stability, and contact-rich placement - **Ours**: - โœ… Preserves object identity and target layout - โœ… Maintains stable stacking contacts - โœ… Predicts adaptive gripper control #### ๐Ÿšช Scene 2: Articulated Hinge Interaction
open microwave open laptop
- **Task**: open microwave, open laptop - **Challenge**: Articulated hinge motion, constrained rotation, and persistent object state - **Ours**: - โœ… Captures hinge-constrained opening dynamics - โœ… Maintains coherent object geometry during rotation - โœ… Preserves opened states over long-horizon rollouts #### ๐Ÿ•น๏ธ Scene 3: Fine-Grained Affordance Interaction
turn switch hanging mug
click bell stamp seal
- **Task**: turn switch, hang mug, click bell, stamp seal - **Challenge**: Small contact regions, constrained placement, and precise state-changing interactions - **Ours**: - โœ… Captures fine-grained affordance dynamics - โœ… Aligns contact with object affordances - โœ… Preserves state-changing interactions #### ๐Ÿค Scene 4: Bimanual Coordination and Handover
handover block handover mic
- **Task**: hand over block, hand over mic - **Challenge**: Dual-arm synchronization, inter-arm occlusion, and coordinated grasp timing - **Ours**: - โœ… Models synchronized dual-arm motion - โœ… Preserves object continuity - โœ… Avoids close-contact collisions #### ๐Ÿ“ฆ Scene 5: Long-Horizon Constrained Placement
put object cabinet put bottles dustbin
- **Task**: put object in cabinet, put bottles in dustbin - **Challenge**: Long-horizon transport, partial occlusion, and constrained final placement - **Ours**: - โœ… Maintains long-horizon scene coherence - โœ… Handles occlusion without object drift - โœ… Produces stable constrained placement ### **Out-of-Distribution Generalization** > To test generalization beyond benchmark initial states, we use **GPT-Image-2-created initial scenes** with original robot action sequences and let **BWM** autoregressively roll out the future under object appearance shifts.
ood episode100 ood episode100 variant 1 ood episode100 variant 3
ood episode33 ood episode33 variant 1 ood episode33 variant 5
- **Task**: shake bottle, put object in cabinet - **Challenge**: Novel initial scenes and object appearance shifts - **Ours**: - โœ… Generalizes to GPT-Image-2-created initial scenes - โœ… Preserves action-conditioned dynamics - โœ… Maintains coherent robot-object interaction --- ## ๐Ÿ› ๏ธ Usage ### Quick Start: Video Generation Inference #### Environment Setup ```bash # Create conda environment conda create -n BWM python=3.10.20 conda activate BWM # Install PyTorch with CUDA support pip install torch==2.8.0 torchvision==0.23.0 torchaudio==2.8.0 --index-url https://download.pytorch.org/whl/cu128 # Install DiffSynth-Studio pip install diffsynth==2.0.11 # Install dependencies pip install -r requirements.txt ``` #### Model Weights Download the [Wan2.2-TI2V-5B](https://www.modelscope.cn/models/Wan-AI/Wan2.2-TI2V-5B) base model from [ModelScope](https://www.modelscope.cn): ```bash modelscope download --model Wan-AI/Wan2.2-TI2V-5B --local_dir models/Wan2.2-TI2V-5B ``` Download the [BWM checkpoint](https://huggingface.co/BLM-Lab/Boundless-World-Model) from [Hugging Face](https://huggingface.co): ```bash hf download BLM-Lab/Boundless-World-Model step-12000.safetensors --local-dir ckpt/BLM ``` #### Run Inference The demo metadata, videos, actions, and normalization statistics are already included under `demo/`. Set local paths before running inference: ```bash cp scripts/local.example.sh scripts/local.sh ``` Update `MODEL_PATHS` and `CKPT_PATH` in `scripts/local.sh`, then run: ```bash bash scripts/infer_example.sh ``` ## ๐Ÿ‹๏ธ Training Coming soon ! --- ## ๐Ÿ™ Acknowledgements This project builds upon the following open-source projects and benchmarks. We thank these teams for their contributions: - Wan2.2: https://github.com/Wan-Video/Wan2.2 - DiffSynth-Studio: https://github.com/modelscope/DiffSynth-Studio - WorldArena: https://github.com/tsinghua-fib-lab/WorldArena/ - ABot-PhysWorld: https://github.com/amap-cvlab/ABot-PhysWorld We also acknowledge the following engineering contributions: - Wentao Tan: basic architecture design ยท [Email](mailto:tan.wt.lucky@gmail.com) ยท [GitHub](https://github.com/FutureTwT) - Zengrong Lin: core code implementation ยท [Email](mailto:zengronglin@tongji.edu.cn) ยท [GitHub](https://github.com/zzezze) - Yang Sun: code refactoring and software maintainability ยท [Email](mailto:young7869264s@gmail.com) ยท [GitHub](https://github.com/DandelionWow) We further thank all project contributors for their valuable discussions, support for the paper experiments, and participation in the WorldArena challenge. - **Supervision**: Heng Tao Shen - **Principal Investigator**: Lei Zhu - **Student Project Leadership**: Wentao Tan, Tianshi Wang - **WorldArena Challenge**: - **Strategy Design**: Wentao Tan, Bowen Wang - **Inference-Time Scaling**: Tianshi Wang, Chenming Li - **Data Pipeline**: Bowen Wang, Enci Xie, Wentao Tan, Chenming Li, Yang Sun, Yipeng Chen, Xuebin Fang, Zequn Wang - **Metric Analysis**: Wentao Tan, Enci Xie, Chenming Li, Tianshi Wang - **Closed-Loop Rollout**: Zequn Wang, Zhe Li, Heng Zhi, Zengrong Lin - **Model Architecture**: - **Innovation**: Wentao Tan, Zengrong Lin, Enci Xie, Baixu Ji - **Model Training**: Zengrong Lin, Yang Sun, Zhe Li - **Post Training**: Yang Sun, Zengrong Lin, Wentao Tan - **Baselines**: Zequn Wang, Heng Zhi, Yipeng Chen, Chenyu Liu, Wenjie Yang, Hao Xue, Chen Xu - **VLAs Support**: - **Real-World**: Heng Zhi - **Simulation**: Heng Zhi, Baixu Ji - **Infrastructure**: - **Distributed Evaluation**: Wenhao Liu - **Real-World Setup**: Zhe Li - **Discussion Support**: Fengling Li, Pengfei Zhang --- ## ๐Ÿ“ง Contact Contributors are listed in alphabetical order by English name. [Baixu Ji](mailto:baixuji@tongji.edu.cn), [Bowen Wang](mailto:wbw1090809192@gmail.com), [Chen Xu](mailto:1187092474@qq.com), [Chenming Li](mailto:2252661@tongji.edu.cn), [Chenyu Liu](mailto:2431993@tongji.edu.cn), [Enci Xie](mailto:elect@tongji.edu.cn), [Fengling Li](mailto:fenglingli2023@gmail.com), [Hao Xue](mailto:2534205@tongji.edu.cn), [Heng Tao Shen](mailto:shenhengtao@tongji.edu.cn), [Heng Zhi](mailto:2431992@tongji.edu.cn), [Lei Zhu](mailto:leizhu0608@gmail.com), [Pengfei Zhang](mailto:mima.zpf@gmail.com), [Tianshi Wang](mailto:tswang0116@163.com), [Wenhao Liu](mailto:liuwwhh594@gmail.com), [Wenjie Yang](mailto:blankyang@tongji.edu.cn), [Wentao Tan](mailto:tan.wt.lucky@gmail.com), [Xuebin Fang](mailto:xuebinfang@163.com), [Yang Sun](mailto:young7869264s@gmail.com), [Yipeng Chen](mailto:2431994@tongji.edu.cn), [Zengrong Lin](mailto:zengronglin@tongji.edu.cn), [Zequn Wang](mailto:wangzequn369@gmail.com), [Zhe Li](mailto:zheli25@tongji.edu.cn) --- ## ๐Ÿ“œ Citing If you find **BWM** is useful in your research or applications, please consider giving us a **star** ๐ŸŒŸ. ```bibtex @article{bwm2026, author = {{BWM Team}}, title = {{BWM}: A Low-Cost High-Fidelity World Simulator for Robot Learning}, year = {2026}, journal = {arXiv preprint arXiv:2607.29302} } ``` ---