# Magpie Gripper
**Design and manufacture of the MAGPIE hand — version 2**
A 3D-printed parallel-jaw gripper with a depth camera in its palm, built from
two smart servos and about $455 of off-the-shelf parts.
[](Documentation/assembly.md)
[](Documentation/BOM.md)
[](https://github.com/correlllab/MAGPIE)
[](https://arxiv.org/abs/2402.06018)
[](LICENSE)
---
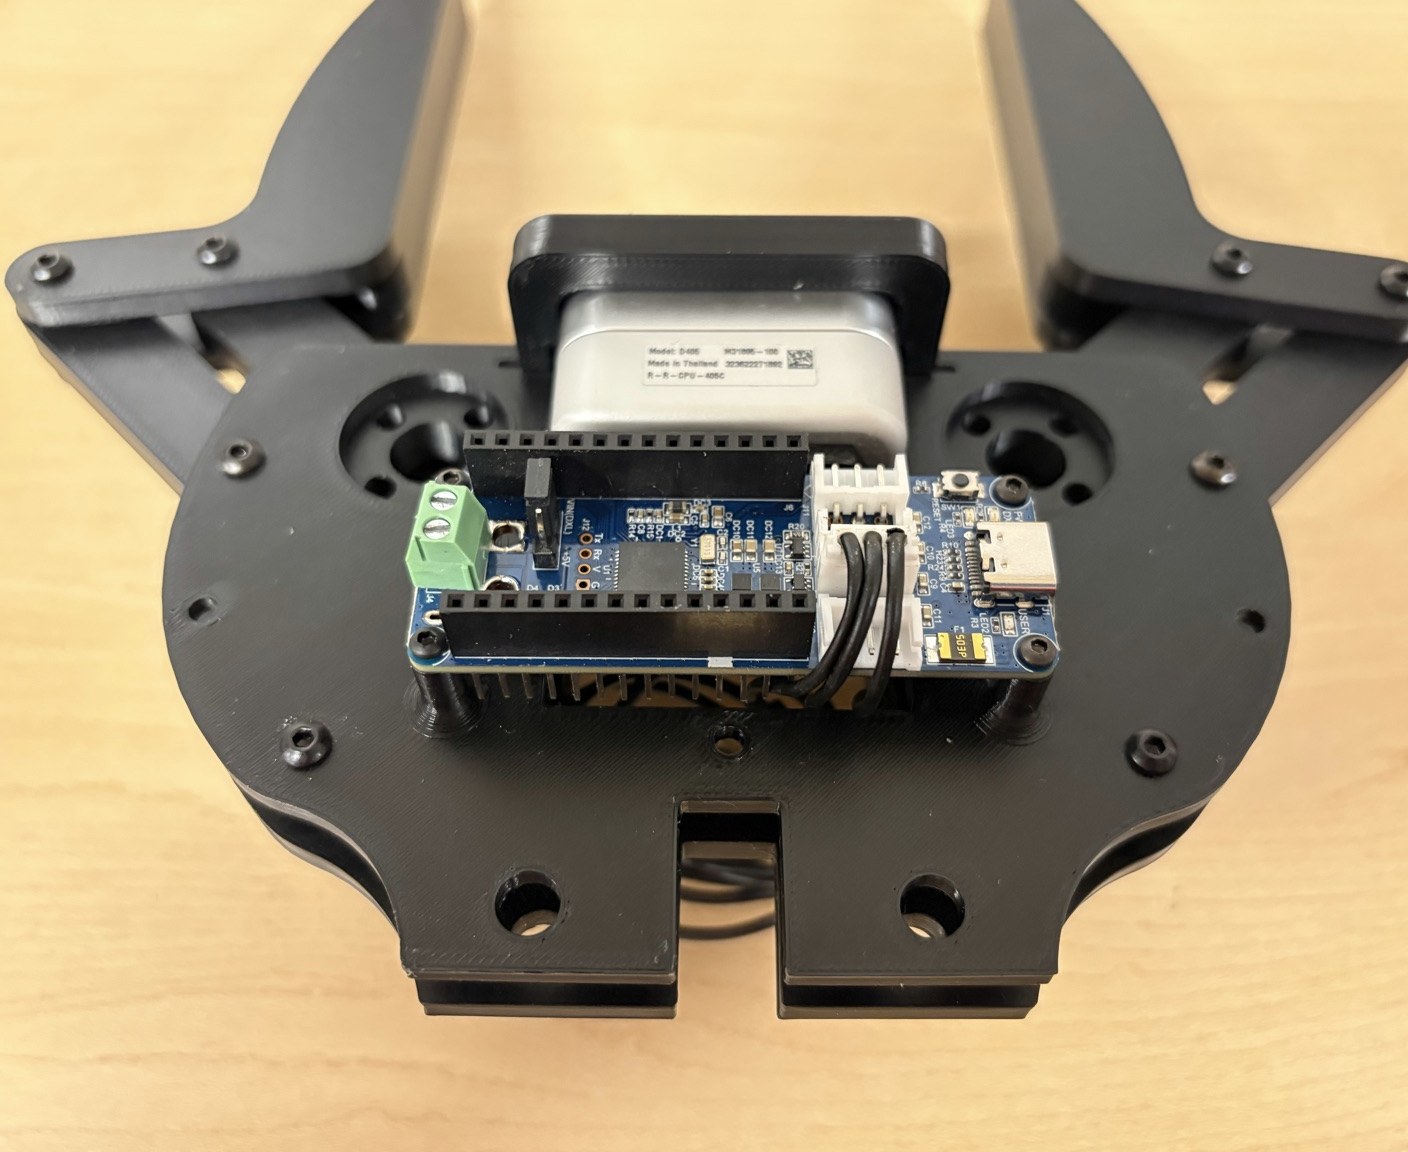
Two AX-12A servos drive a four-bar linkage — crank and rocker — that keeps the
fingers parallel through their whole travel, an OpenRB-150 board controls them,
and an Intel RealSense D405 looks out from the palm. Because the servos are
current-limited, the gripper can be told how hard to squeeze; because the camera
is between the fingers rather than on the wrist, it can still see the object at
the moment of contact.
This repository is the **hardware**: models, bill of materials, a photographed
step-by-step build, and the record of what changed from version 1. The software
that drives it lives in [correlllab/MAGPIE](https://github.com/correlllab/MAGPIE).
**Version 2 is a simplification.** Fewer parts, fewer fasteners, and less to get
wrong: the three-piece finger became one piece, the camera moved from slots to
holes so it lands in the same place every time, the controller's standoffs are
printed into the base plate, and the two-piece camera cover became one part that
snaps on. It weighs **390 g** on the bench scale, against 414 g for the hand in
the paper. [What changed, and why →](Documentation/MagpieDesignChanges.md)
| | |
| --- | --- |
| **Actuation** | 2 × Dynamixel AX-12A, four-bar linkage per finger |
| **Control** | OpenRB-150, one USB-C cable |
| **Sensing** | Intel RealSense D405 in the palm |
| **Mass** | ≈ 390 g ([weighed](Documentation/assembly_photos/IMG_5022.jpg)) |
| **Parts cost** | ≈ $455, of which the camera is $272 |
| **Printed** | 9 pieces, ≈ 140 cm³, PLA at 30 % gyroid infill |
| **CAD** | Onshape, [live document](https://cad.onshape.com/documents/ebf3bee4cb16cf8695a8fb0b/w/7cb77bbbbc0cfa118c533903/e/7df3b127506ca0a4fec0e6dc?renderMode=0&uiState=6a8f814e30e68e6c32fd1782) · STLs in [`CAD/`](CAD) |
## Build one
**1 · Print.** Everything in [`CAD/`](CAD), PLA, 30 % gyroid infill with 2 mm
borders and organic supports. The rocker and the crank are the parts that break,
so give them at least 50 % infill.
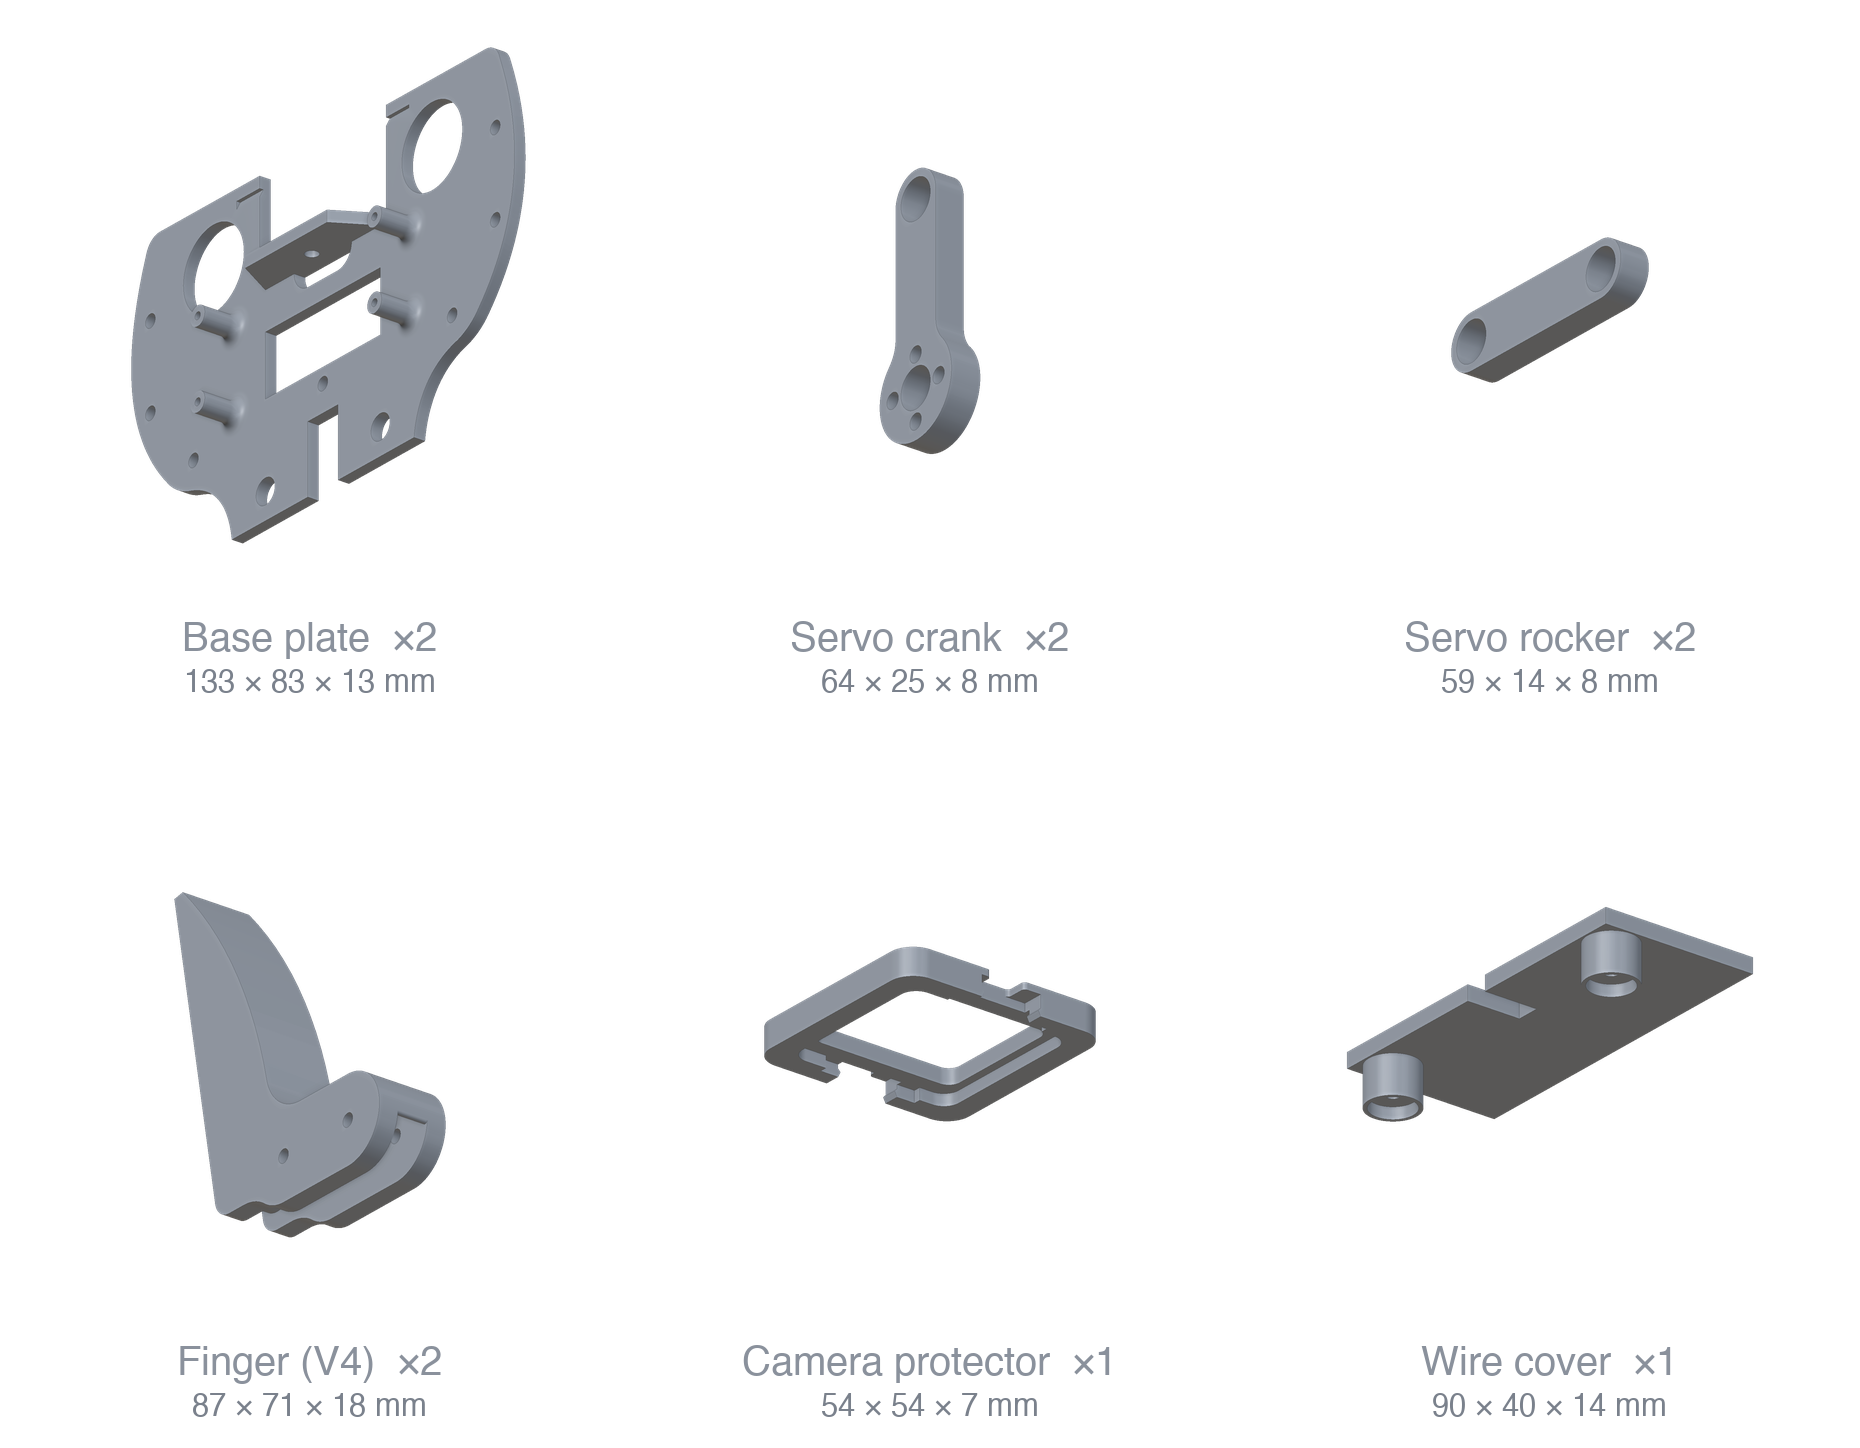
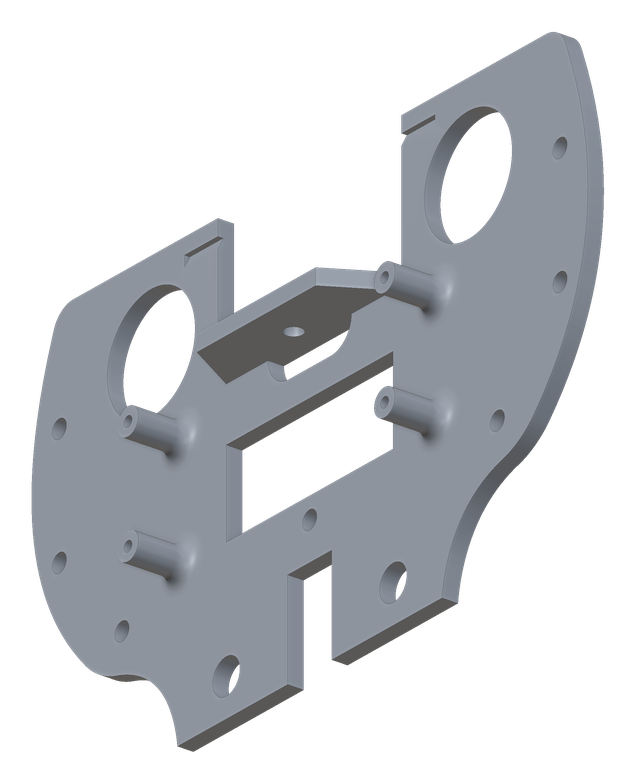 | Base plate | 2 | 133 × 83 × 13 mm | [`Base Top.stl`](CAD/Base%20Top.stl), [`Base Bottom.stl`](CAD/Base%20Bottom.stl) |
|
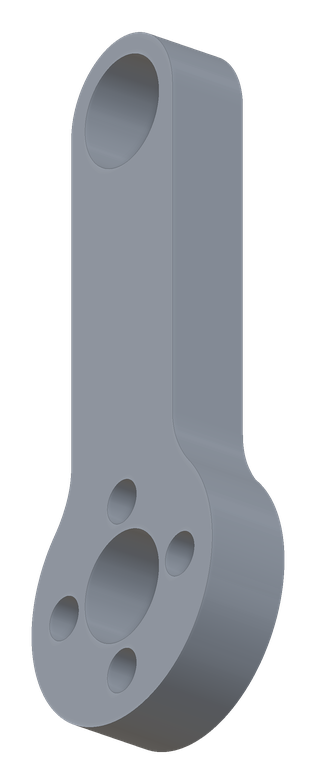 | Servo crank | 2 | 64 × 25 × 8 mm | [`Crank.stl`](CAD/Crank.stl) |
|
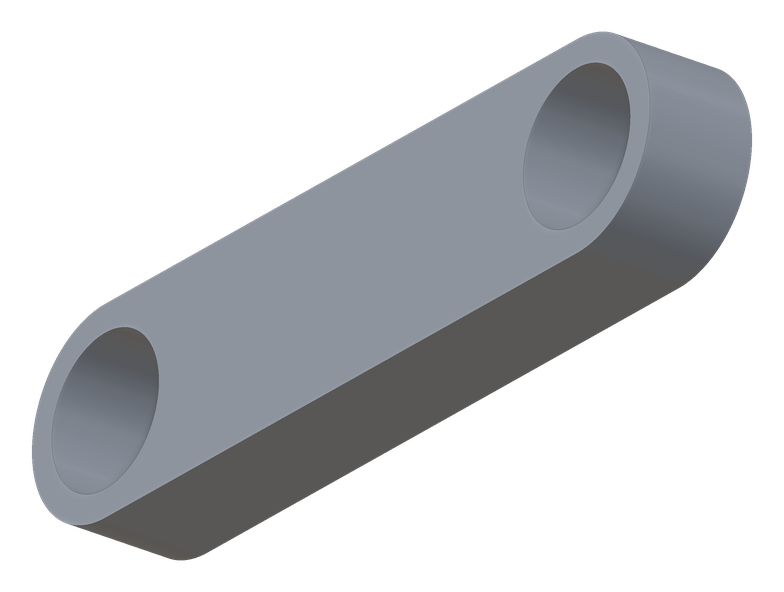 | Servo rocker | 2 | 59 × 14 × 8 mm | [`Rocker.stl`](CAD/Rocker.stl) |
|
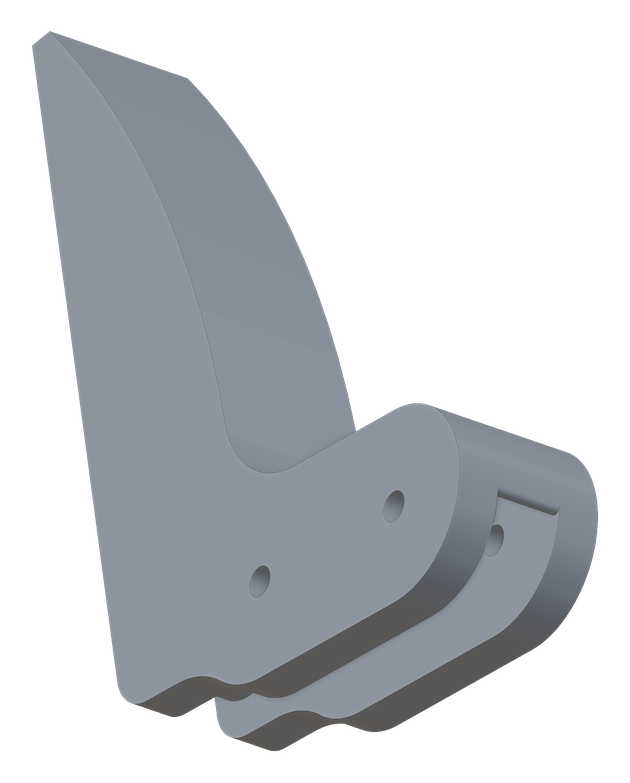 | Finger | 2 | 87 × 71 × 18 mm | [`Finger V4 - covered.stl`](CAD/Finger%20V4%20-%20covered.stl) |
|
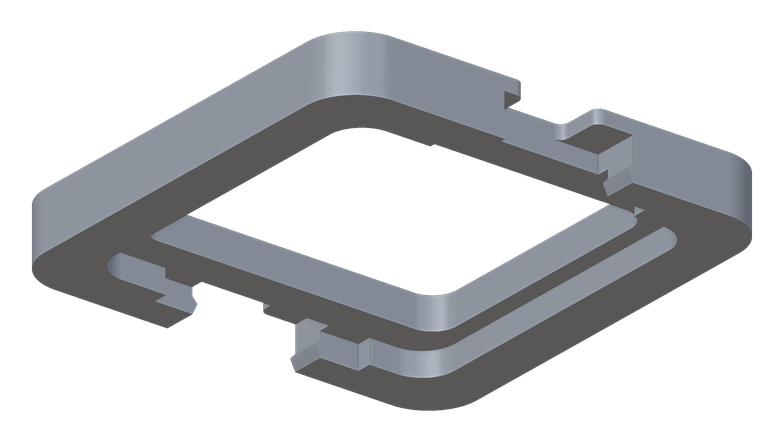 | Camera protector | 1 | 54 × 54 × 7 mm | [`Camera Cover.stl`](CAD/Camera%20Cover.stl) |
|
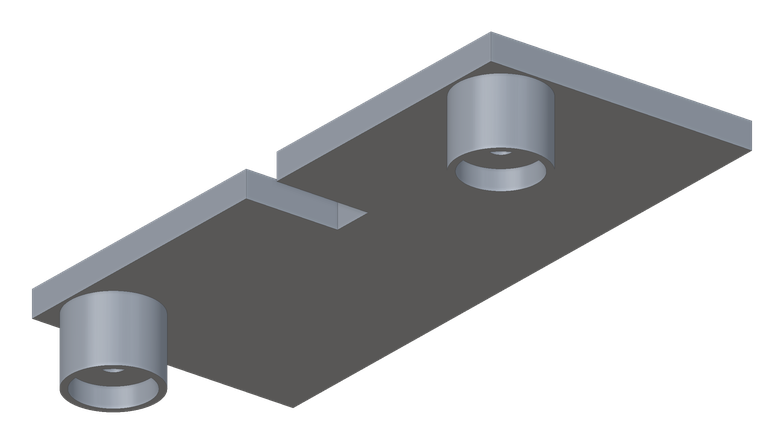 | Wire cover | 1 | 90 × 40 × 14 mm | [`Wire Cover.stl`](CAD/Wire%20Cover.stl) |
> [!NOTE]
> `Base Top.stl` and `Base Bottom.stl` are currently **the same file, byte for
> byte** — it is the plate carrying the printed OpenRB-150 standoffs. If version 2
> really does use one plate twice, the BOM (which prices them separately) and the
> assembly guide (which says the plates are different sizes) should say so;
> otherwise the second export is missing.
**2 · Buy.** [The bill of materials](Documentation/BOM.md) lists both versions.
For V2: two AX-12A servos, an OpenRB-150, a RealSense D405, six 5 mm bearings,
M2/M3 hardware, and grip tape.
**3 · Assemble.** [The assembly guide](Documentation/assembly.md) — eleven steps,
photographed, from taping the fingers to setting the servo IDs. Also available as
[a PDF to print](Documentation/Magpie%20Assembly%20Guide.pdf).
## The fingers are the experiment
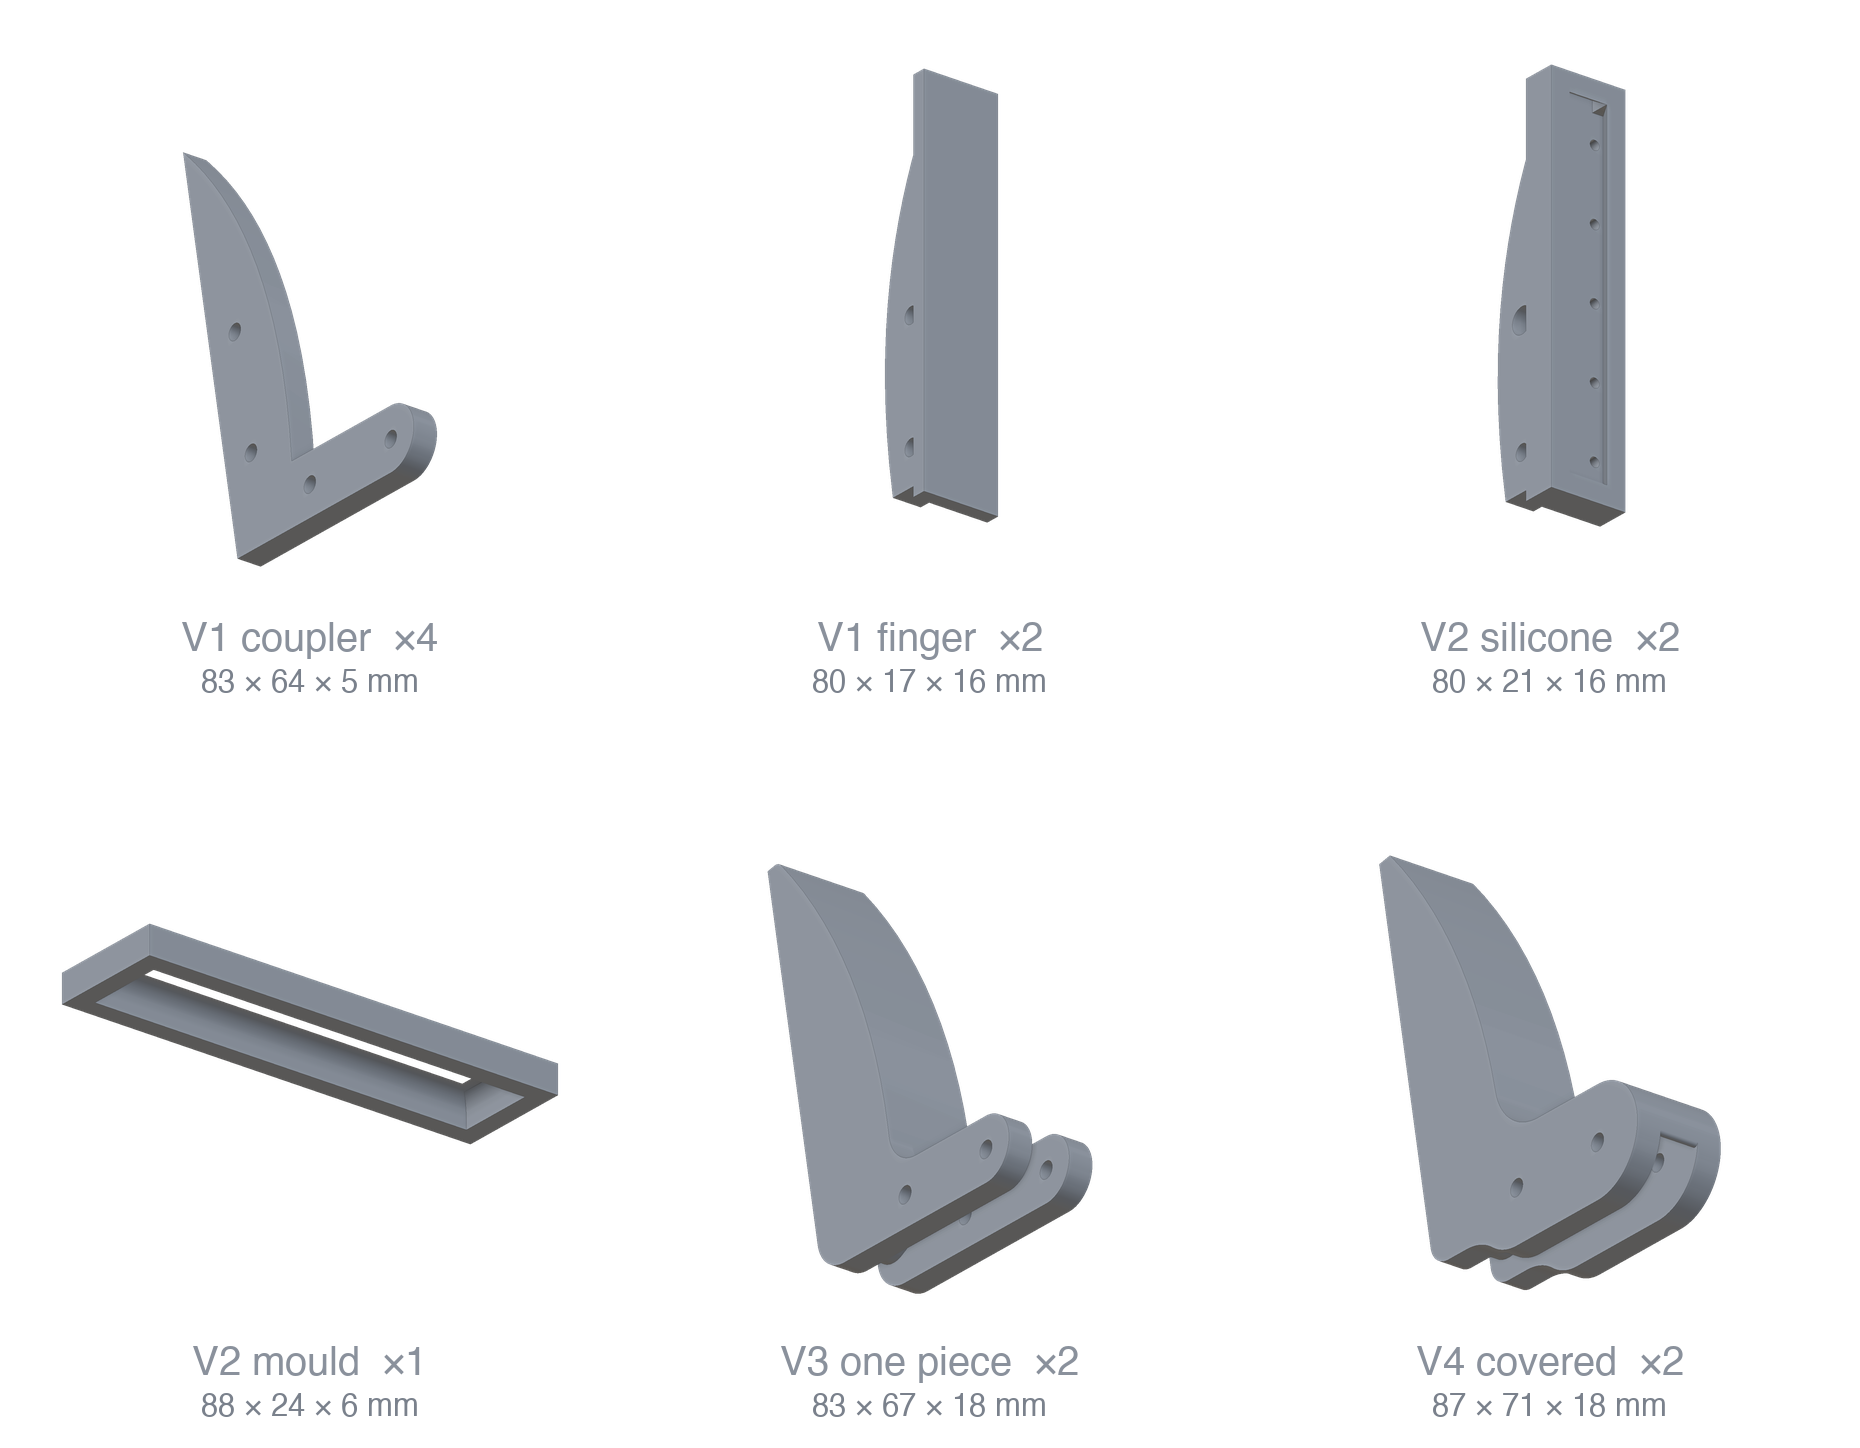
Grip is where a jaw gripper is won or lost, so the finger is the part that has
been through the most versions. All four are in [`CAD/`](CAD) and interchangeable: