# Velxio: Arduino & Embedded Board Emulator
**Live at [velxio.dev](https://velxio.dev)**
An open-source multi-board emulator and circuit simulator. Write Arduino C++, MicroPython, ESP-IDF or Python, compile it, and run it against real CPU emulation with 150+ interactive electronic components — all in your browser.
**40 boards · 5 CPU families**: AVR8 (ATmega / ATtiny), ARM Cortex-M (RP2040 / RP2350 / STM32), Xtensa LX6/LX7 (ESP32 / ESP32-S3), RISC-V (ESP32-C3 / ESP32-C6) and ARM Cortex-A Linux (Raspberry Pi Zero to 5).

[](https://velxio.dev)
[](https://github.com/davidmonterocrespo24/velxio/pkgs/container/velxio)
[](https://github.com/davidmonterocrespo24/velxio/stargazers)
[](https://discord.gg/3mARjJrh4E)
[](LICENSE)
[](COMMERCIAL_LICENSE.md)
---
[](https://www.producthunt.com/products/velxio)
---
## Support the Project
Velxio is free and open-source. Building and maintaining a full multi-board emulator takes a lot of time — if it saves you time or you enjoy the project, sponsoring me directly helps keep development going.
| Platform | Link |
| --- | --- |
| **GitHub Sponsors** (preferred) | [github.com/sponsors/davidmonterocrespo24](https://github.com/sponsors/davidmonterocrespo24) |
| **PayPal** | [paypal.me/odoonext](https://paypal.me/odoonext) |
Your support helps cover server costs, library maintenance, and frees up time to add new boards, components, and features. Thank you!
---
## Hardware Partners
These companies have supported Velxio and provided their hardware so their components can be emulated accurately:
The DFRobot and M5Stack links above are affiliate links: a purchase made through them earns Velxio a small commission at no extra cost to you, and it helps pay for the hosted instance. The simulator itself is AGPL and free either way.
Their hardware is in the catalog today: the M5Stack Cardputer and Core, the Pimoroni Badger 2350 and Galactic Unicorn, the Seeed Studio XIAO family and Grove modules, the DFRobot UNIHIKER and Gravity sensors, and the whole Espressif ESP32 line up to the ESP32-C6. Of these, the M5Stack, Pimoroni and DFRobot boards, the Seeed XIAO Sense, C6 and RP2040, and the ESP32-C6 DevKit are only available online at velxio.dev; the self-hosted image ships the Arduino, Raspberry Pi Pico and ESP32 families (see [Supported Boards](#supported-boards)).
---
## Try it now
**[https://velxio.dev](https://velxio.dev)** — no installation needed. Open the editor, write your sketch, and simulate directly in the browser.
To self-host with Docker (single command):
```bash
docker run -d \
--name velxio \
-p 3080:80 \
-v velxio-data:/app/data \
-v velxio-arduino-libs:/root/.arduino15 \
-v velxio-arduino-user-libs:/root/Arduino \
-v velxio-ccache:/var/cache/ccache \
-v velxio-build:/var/lib/velxio-build \
ghcr.io/davidmonterocrespo24/velxio:master
```
Then open . Tail logs any time with
`docker logs -f velxio`.
> The self-hosted image runs the Arduino, Raspberry Pi Pico and ESP32
> families. STM32, Raspberry Pi Linux, the ESP32-C6 and the partner boards
> are only available online at velxio.dev.
The named volumes are what make compile times reasonable on subsequent
runs — without them, every container restart wipes the ESP-IDF build
cache and the first compile after each restart takes 5-7 minutes
instead of 5-30 seconds.
---
## Screenshots
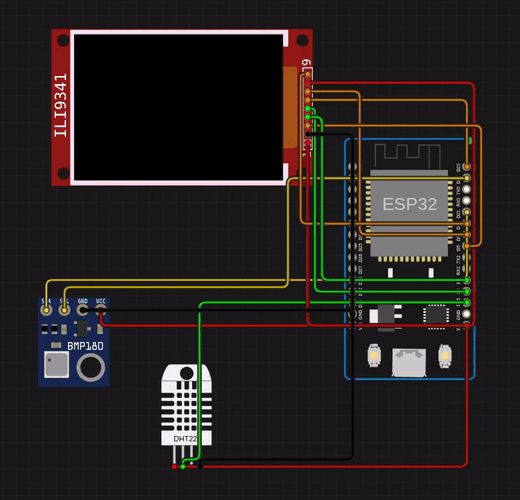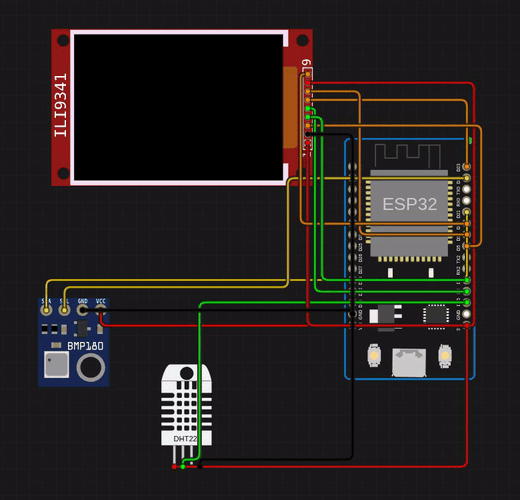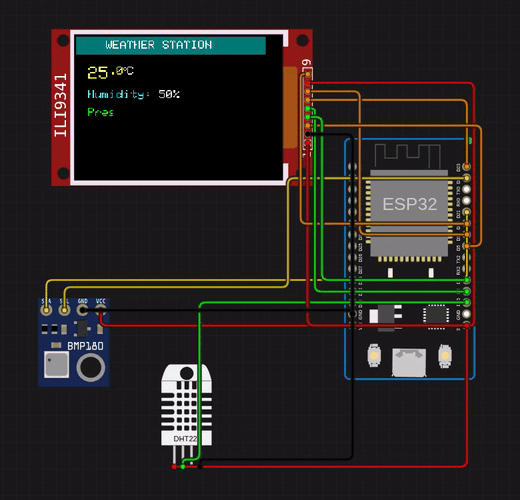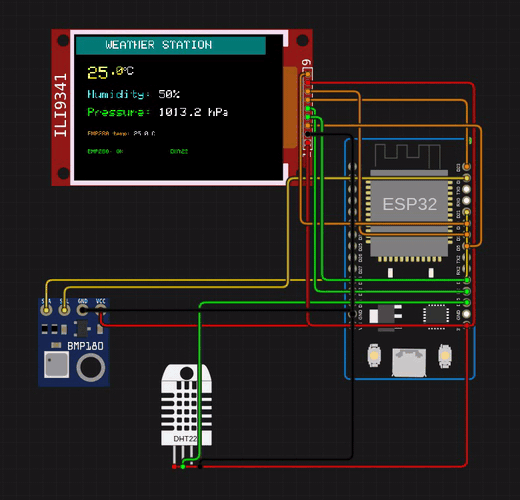
ESP32 weather station — a BMP280 over I2C, a DHT22 on a GPIO and an ILI9341 TFT over SPI wired on the canvas, three buses working at once while the display updates live.
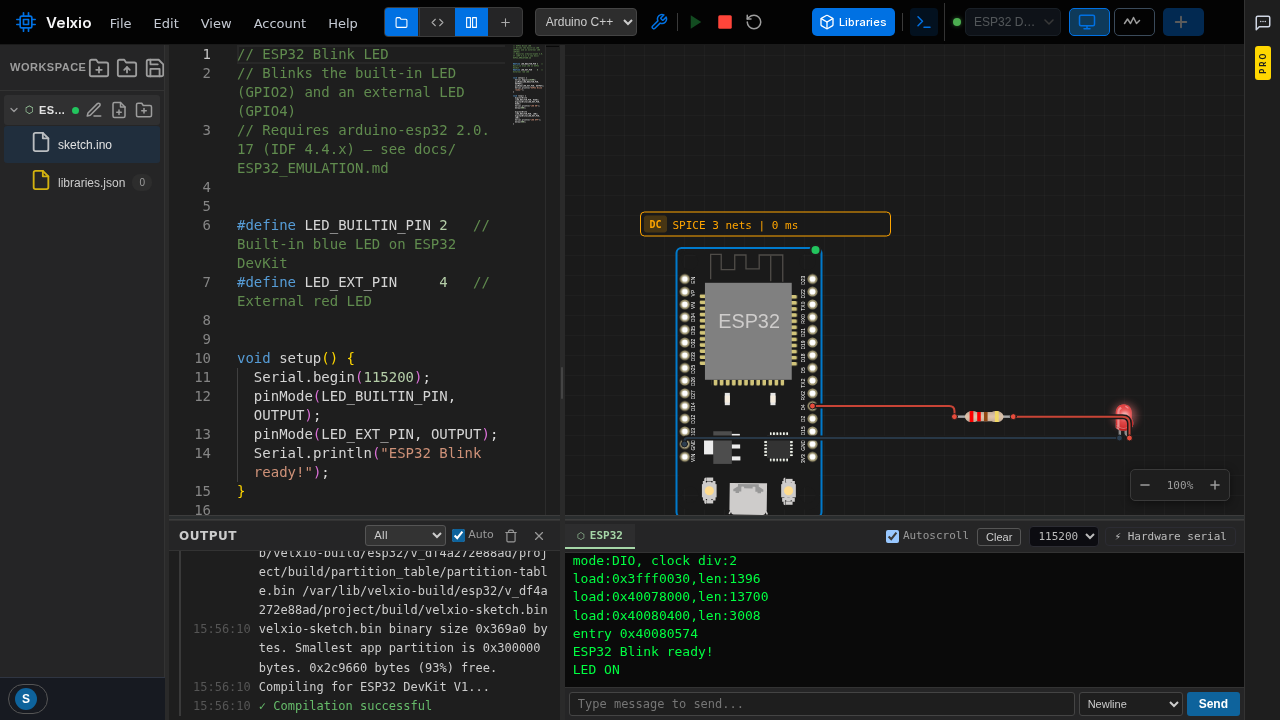
The editor: Monaco on the left, the circuit canvas on the right, compiler output and Serial Monitor at the bottom. Here an ESP32 DevKit blinks an external LED and prints over UART.
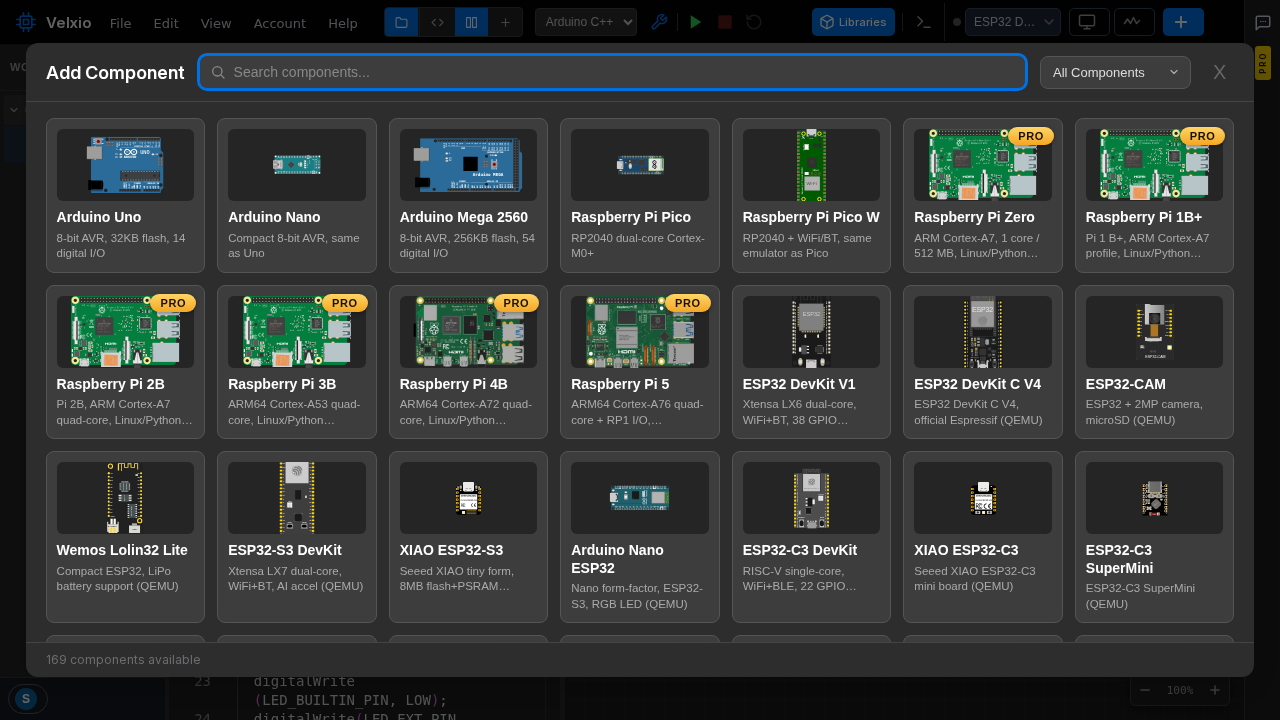
Component picker — every board and module with a live preview, search and category filters. The catalog is over 150 parts: displays, sensors, motors, logic ICs, analog parts, breadboards and branded modules.
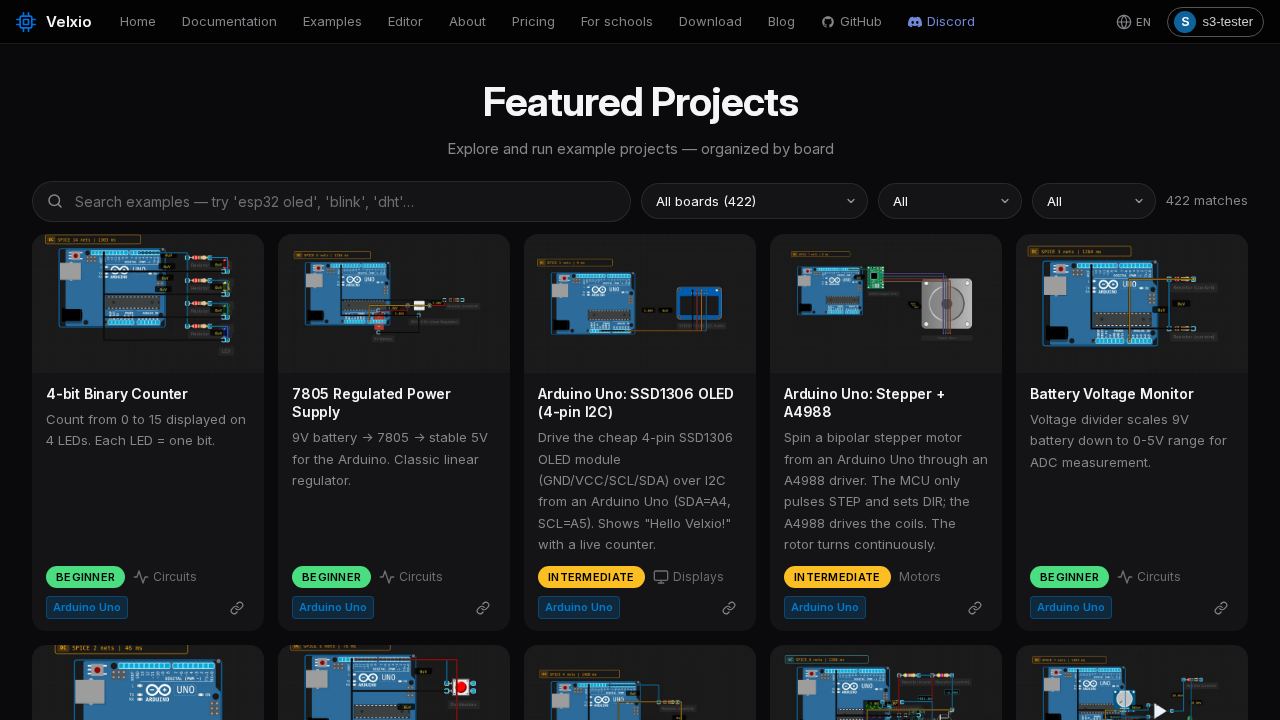
Examples gallery — more than 400 ready-to-run projects filtered by board, difficulty and topic, including the [100 Days 100 IoT Projects](https://github.com/velxio/100_Days_100_IoT_Projects) collection.
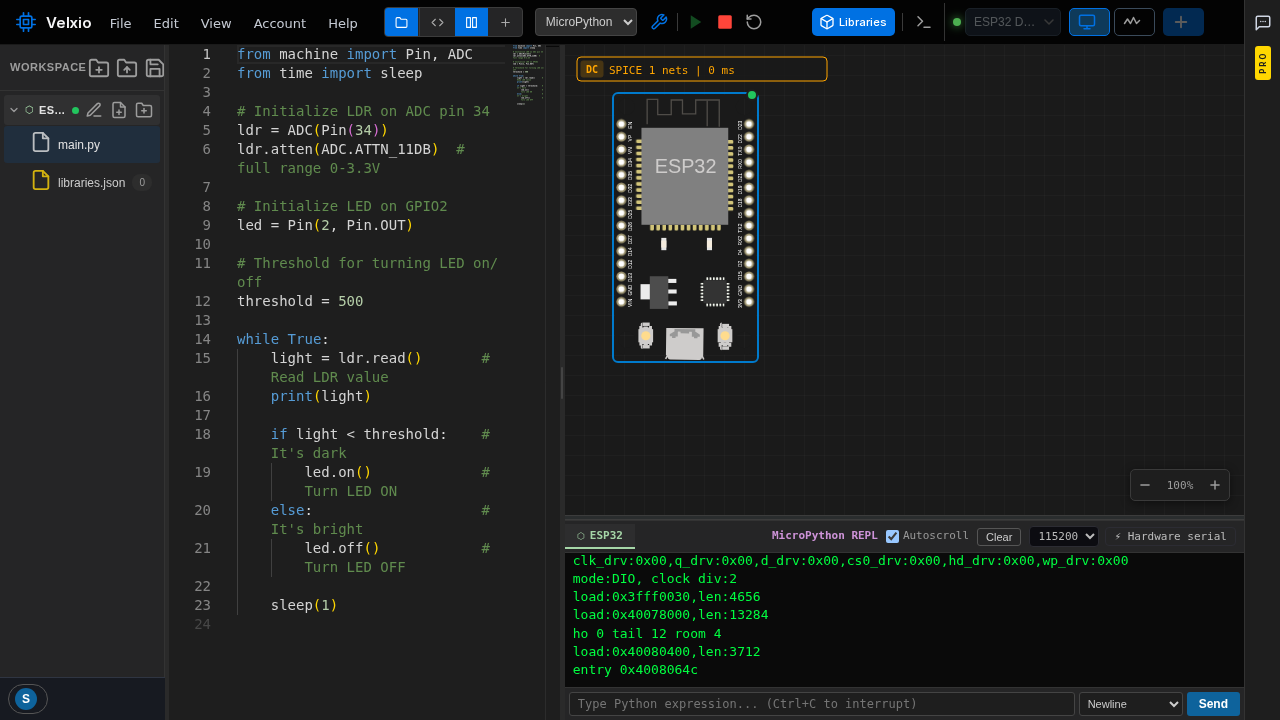
MicroPython — the same ESP32, now running `main.py`, with the REPL in the terminal panel. ESP32 boards also accept pure ESP-IDF projects.
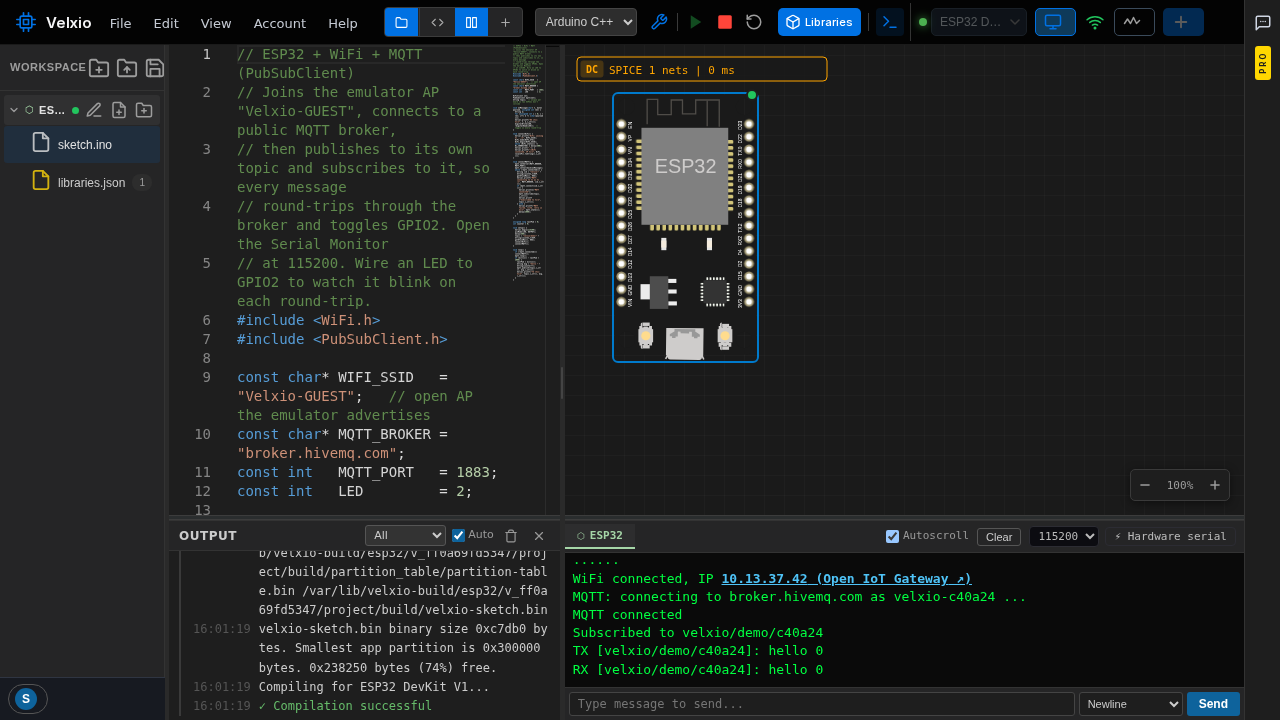
Emulated WiFi — the ESP32 joins the virtual access point, gets an IP and round-trips messages through a public MQTT broker.
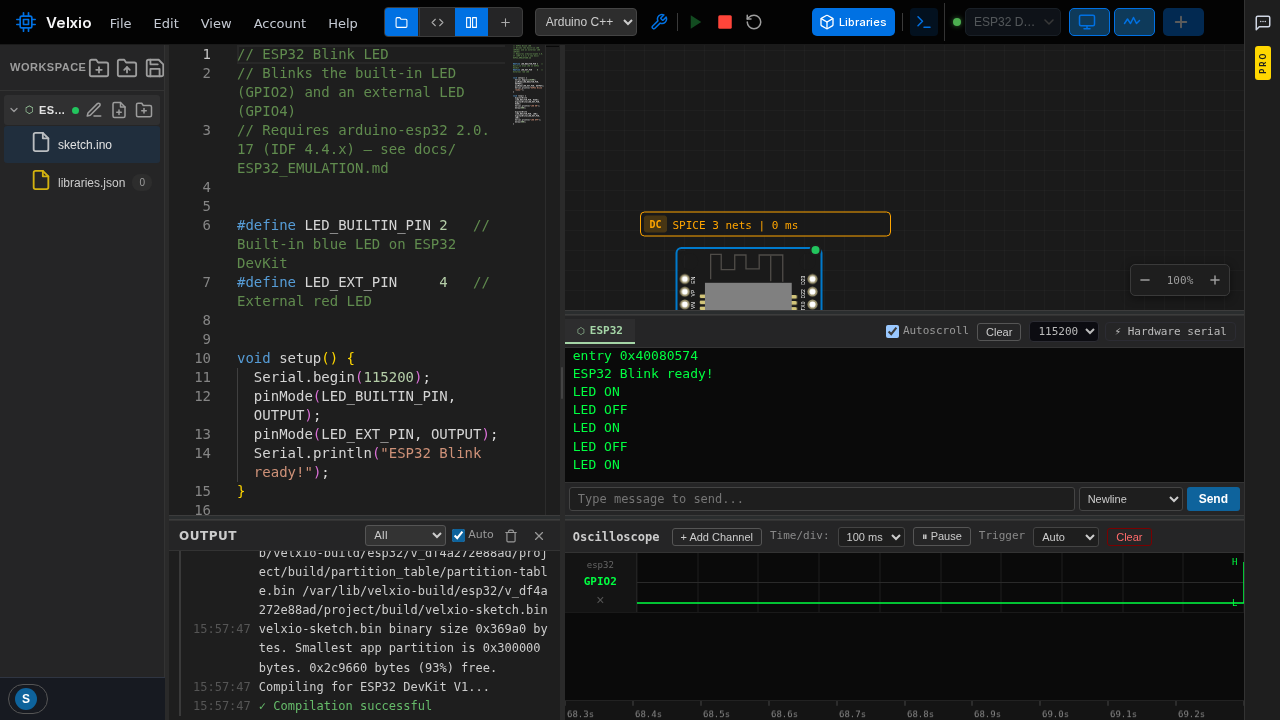
Instruments — oscilloscope channels on any pin, plus a SPICE-based electrical layer that shows currents, voltages and shorts on the wires you draw.
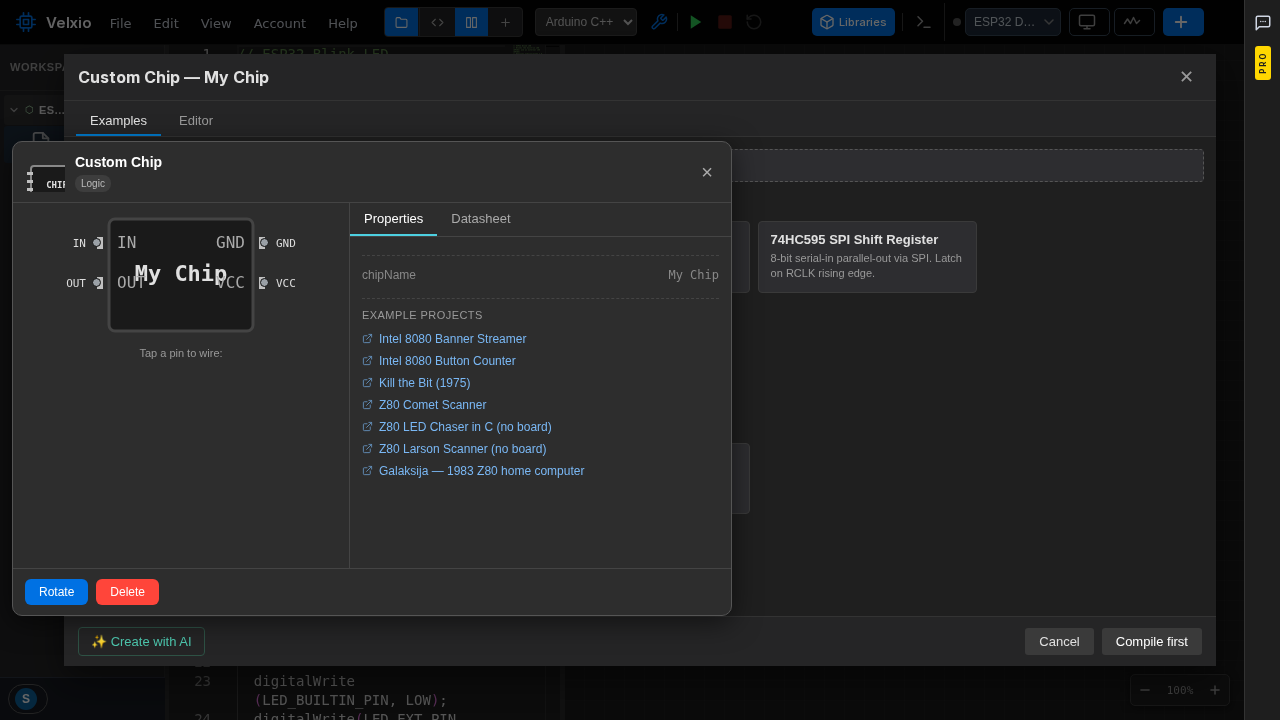
Custom chips — write your own IC in C, compile it to WebAssembly and drop it on the canvas next to the boards.
---
## Supported Boards
Arduino Uno
Arduino Nano
Arduino Mega 2560
ATtiny85
Raspberry Pi 3
Raspberry Pi 5
Raspberry Pi Pico
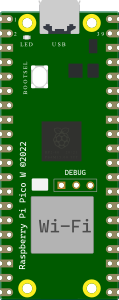
Raspberry Pi Pico W
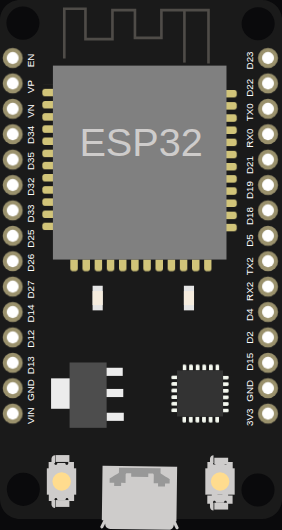
ESP32 DevKit V1
ESP32-S3
ESP32-C3
ESP32-CAM
XIAO ESP32-S3
XIAO ESP32-C3
Arduino Nano ESP32
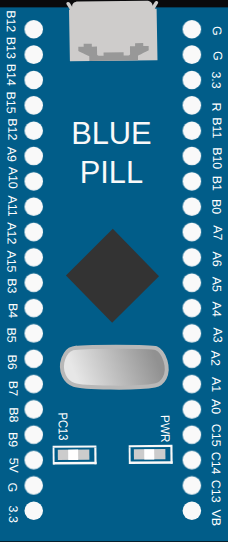
STM32 Blue Pill
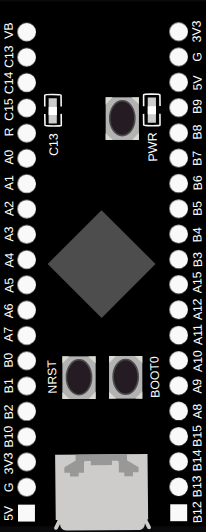
STM32 Black Pill
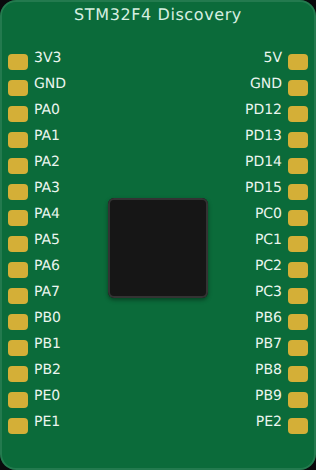
STM32F4 Discovery
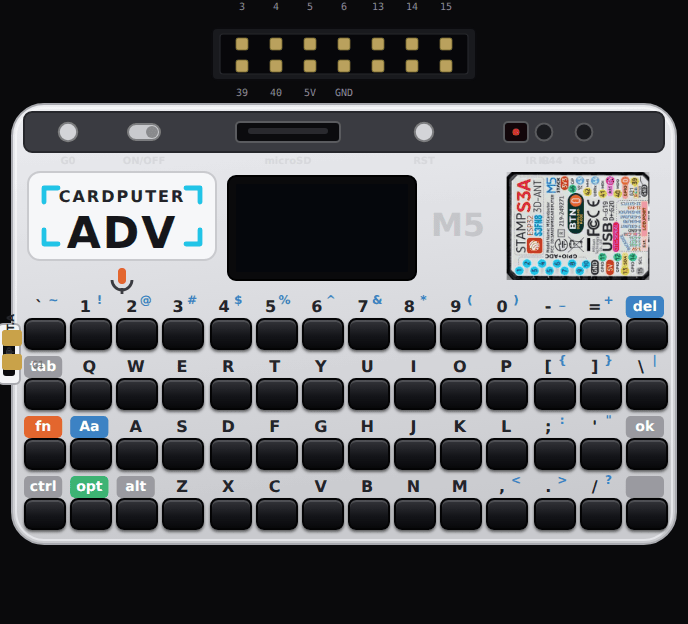
M5 Cardputer ADV
M5Stack Core
Pimoroni Badger 2350
XIAO ESP32S3 Sense
ESP32-C6 DevKit
DFRobot UNIHIKER M10
Boards run in one of two places. **Browser boards** (AVR, RP2040) are emulated entirely in the page with avr8js and rp2040js — nothing leaves your machine. **Server boards** (ESP32 family, STM32, Raspberry Pi Linux) boot a real QEMU machine on the backend and stream GPIO and serial to the canvas. Both feel the same: press Play.
| Family | Boards | Languages | Where it runs |
| --- | --- | --- | --- |
| **Arduino / AVR** | Uno, Nano, Mega 2560, ATtiny85 | Arduino C++ | Browser — self-hosted and velxio.dev |
| **Raspberry Pi Pico** | Pico, Pico W | Arduino C++, MicroPython | Browser — self-hosted and velxio.dev |
| **ESP32** | ESP32 DevKit V1, DevKit-C V4, ESP32-CAM, Wemos Lolin32 Lite | Arduino C++, MicroPython, ESP-IDF | Self-hosted (QEMU) and velxio.dev |
| **ESP32-S3** | ESP32-S3 DevKit, XIAO ESP32-S3, Arduino Nano ESP32 | Arduino C++, MicroPython, ESP-IDF | Self-hosted (QEMU) and velxio.dev |
| **ESP32-C3** | ESP32-C3 DevKit, XIAO ESP32-C3, ESP32-C3 SuperMini | Arduino C++, MicroPython, ESP-IDF | Self-hosted (QEMU) and velxio.dev |
| **STM32** | Blue Pill (F103C8 / F103CB), Black Pill (F411CE / F401CE), STM32F4 Discovery, Olimex STM32-H405, Netduino 2 / Plus 2 | Arduino C++ | Online only: velxio.dev (paid plan) or Velxio Desktop, not in the self-hosted image |
| **Raspberry Pi (Linux)** | Zero, 1B+, 2B, 3B, 4B, 5 — boot a real Linux and run Python in a full terminal | Python | Online only: velxio.dev (paid plan) or Velxio Desktop, not in the self-hosted image |
| **Branded boards** | M5Stack Cardputer ADV and Core, Pimoroni Badger 2350, Galactic Unicorn and Pico Plus 2 W, Seeed XIAO ESP32S3 Sense, XIAO ESP32C6 and XIAO RP2040, Espressif ESP32-C6 DevKit, DFRobot UNIHIKER M10 | Arduino C++, MicroPython, ESP-IDF | Online only: velxio.dev (free plan; UNIHIKER needs a paid plan), not in the self-hosted image |
The self-hosted image runs the first five families out of the box. Everything else is only available online at velxio.dev: STM32 and Raspberry Pi Linux need licensed emulator binaries and multi-GB boot images (they also run in Velxio Desktop with a paid plan), and the branded boards boot their factory firmware (the M5 launcher, BadgeOS) from the hosted catalog. The OSS picker shows these boards as links to the online editor. The full list with pinouts, languages and quirks is in the [boards reference](https://velxio.dev/docs/boards/overview/).
---
## Features
### Code Editing
- **Monaco Editor** — Full C++ / Python editor with syntax highlighting, autocomplete, minimap, and dark theme
- **Multi-file workspace** — create, rename, delete, and switch between multiple `.ino` / `.h` / `.cpp` / `.py` files
- **Arduino compilation** via `arduino-cli` backend — compile sketches to `.hex` / `.bin` files
- **Compile / Run / Stop / Reset** toolbar buttons with status messages
- **Compilation console** — resizable output panel showing full compiler output, warnings, and errors
### Multi-Board Simulation
#### AVR8 (Arduino Uno / Nano / Mega / ATtiny85)
- **Real ATmega328p / ATmega2560 / ATtiny85 emulation** at native clock speed via avr8js
- **Full GPIO** — PORTB, PORTC, PORTD (Uno/Nano/Mega); all ATtiny85 ports (PB0–PB5)
- **Timer0/Timer1/Timer2** — `millis()`, `delay()`, PWM via `analogWrite()`
- **USART** — full transmit and receive, auto baud-rate detection
- **ADC** — `analogRead()`, voltage injection from potentiometers on canvas
- **SPI** — hardware SPI peripheral (ILI9341, SD card, etc.)
- **I2C (TWI)** — hardware I2C with virtual device bus
- **ATtiny85** — all 6 I/O pins, USI (Wire), Timer0/Timer1, 10-bit ADC; uses `AttinyCore`
- ~60 FPS simulation loop via `requestAnimationFrame`
#### RP2040 (Raspberry Pi Pico / Pico W)
- **Real RP2040 emulation** at 133 MHz via rp2040js — ARM Cortex-M0+
- **All 30 GPIO pins** — input/output, event listeners, pin state injection
- **UART0 + UART1** — serial output in Serial Monitor; Serial input from UI
- **ADC** — 12-bit on GPIO 26–29 (A0–A3) + internal temperature sensor (ch4)
- **I2C0 + I2C1** — master mode with virtual device bus (DS1307, TMP102, EEPROM)
- **SPI0 + SPI1** — loopback default; custom handler supported
- **PWM** — available on any GPIO pin
- **WFI optimization** — `delay()` skips ahead in simulation time instead of busy-waiting
- **Oscilloscope** — GPIO transition timestamps at ~8 ns resolution
- Compiled with the [earlephilhower arduino-pico](https://github.com/earlephilhower/arduino-pico) core
See [docs/RP2040_EMULATION.md](docs/RP2040_EMULATION.md) for full technical details.
#### ESP32, STM32 and Raspberry Pi Linux
The ESP32 family (Xtensa and RISC-V), the STM32 family and the Raspberry Pi Linux boards run on QEMU-based backends with the same canvas, Serial Monitor and instruments as the browser boards. Their setup, peripherals and quirks are covered board by board in the [documentation](https://velxio.dev/docs/boards/overview/); the technical notes for the QEMU bridges live in [docs/ESP32_EMULATION.md](docs/ESP32_EMULATION.md), [docs/RISCV_EMULATION.md](docs/RISCV_EMULATION.md) and [docs/RASPBERRYPI3_EMULATION.md](docs/RASPBERRYPI3_EMULATION.md).
### Example Projects
- Hundreds of ready-to-run examples in the gallery (400+ on velxio.dev), filtered by board, difficulty and topic — from Blink and Traffic Light to TFT dashboards, e-paper displays, MQTT over emulated WiFi and Pi + Arduino serial links
- The [100 Days 100 IoT Projects](https://github.com/velxio/100_Days_100_IoT_Projects) collection, imported as runnable projects
- One-click loading into the editor
---
## Self-Hosting
Pick the install path that matches your appetite for setup. **All three
work out-of-the-box without an `.env` file** — defaults are picked
automatically.
| Path | Boards available | Build time | Best for |
| --- | --- | --- | --- |
| **A. Docker (prebuilt image)** | AVR, RP2040 and the whole **ESP32** family (Xtensa + RISC-V) | ~30 s download | Just want it running |
| **B. Docker Compose (build from source)** | Same as A | ~10–15 min first build | Want to modify the code |
| **C. Manual install** | Browser-only boards (AVR, RP2040) | ~5 min | Frontend / backend dev |
> ESP32 emulation relies on QEMU `.so` libraries that ship inside the
> Docker image. Manual installs get the browser-side boards out of the
> box — **for ESP32 you'll want Docker** (or follow
> [docs/ESP32_EMULATION.md](docs/ESP32_EMULATION.md) to wire up the QEMU
> binaries by hand). STM32, Raspberry Pi Linux, the ESP32-C6 and the
> partner boards are only available online at velxio.dev (STM32 and Pi
> also in Velxio Desktop with a paid plan); the self-hosted image does
> not ship them.
---
### Option A: Docker (prebuilt image)
```bash
docker run -d \
--name velxio \
-p 3080:80 \
-v velxio-data:/app/data \
-v velxio-arduino-libs:/root/.arduino15 \
-v velxio-arduino-user-libs:/root/Arduino \
-v velxio-ccache:/var/cache/ccache \
-v velxio-build:/var/lib/velxio-build \
ghcr.io/davidmonterocrespo24/velxio:master
```
Open .
The five named volumes persist:
- `velxio-data` → `/app/data`: SQLite DB, project sketch files, auto-generated `SECRET_KEY`
- `velxio-arduino-libs` → `/root/.arduino15`: arduino-cli config + installed
cores (saves a 5–10 min reinstall on every container restart)
- `velxio-arduino-user-libs` → `/root/Arduino`: Library Manager-installed
Arduino libraries (e.g. Adafruit_BMP280, DHT, GFX). Without this,
every container restart re-downloads them on next compile.
- `velxio-ccache` → `/var/cache/ccache`: ccache C/C++ object cache for
ESP-IDF compiles. Empty on first compile, populated as you go;
subsequent compiles hit the cache and finish in seconds instead of
minutes.
- `velxio-build` → `/var/lib/velxio-build`: persistent ESP-IDF build dir
(one subdir per target — esp32, esp32c3, esp32s3). Lets ninja's
incremental build skip everything that hasn't changed; a re-compile
of an unchanged sketch finishes in 2-5 seconds.
If you skip the volume flags, the Dockerfile declares all five paths as
`VOLUME`, so docker creates anonymous volumes and the caches still
survive container restarts (just harder to inspect/back up than named
ones). Only `docker rm -v` or `docker volume prune` would wipe them.
---
### Option B: Docker Compose (build from source)
```bash
git clone https://github.com/davidmonterocrespo24/velxio.git
cd velxio
docker compose up -d --build
```
First build takes ~10–15 minutes (downloads ESP-IDF, builds the frontend).
Subsequent builds are cached and take ~1 min.
Then open . The container generates a random
`SECRET_KEY` on first boot and persists it in `./data/`, so **no `.env` is
required** to get going.
#### Optional: customize environment
The OSS image has almost no configuration — there's no database, no auth,
no third-party integrations. Create `backend/.env` only if you want to
change the CORS origin used during local development.
| Variable | Default | Description |
| --- | --- | --- |
| `FRONTEND_URL` | `http://localhost:5173` | Origin allowed by CORS for local Vite dev |
| `VELXIO_NEWS` | `on` | Product news: the backend fetches release notes and product news from velxio.dev's public feed (cached ~6h, anonymous, no identifiers sent) and the editor shows each item once as a "What's New" modal. Posts may embed remote media (screenshots, GIFs, YouTube previews) which the viewer's browser loads directly from the hosting site; video players only load after an explicit click. Set to `off` to disable entirely; an offline host degrades to no news automatically. |
> **Deploying behind a reverse proxy?** The container listens on plain HTTP
> on port 80 and accepts any `Host` header — no `server_name` whitelist.
> **Running velxio.dev itself?** Production-only configuration (host nginx
> + HTTPS, backups, pinned upstream commit) lives in its own repo:
> [github.com/velxio/velxio-prod](https://github.com/velxio/velxio-prod).
---
### Option C: Manual Setup (frontend + backend separately)
**Prerequisites:** Node.js 18+, Python 3.12+, arduino-cli
```bash
git clone https://github.com/davidmonterocrespo24/velxio.git
cd velxio
```
> No `--recurse-submodules` needed. `@wokwi/elements`, `avr8js` and
> `rp2040js` come from the npm registry. Board SVGs live in
> `frontend/public/boards/`. The folders under `third-party/` are
> reference-only — you only need to clone wokwi-elements if you're adding
> a new component to the catalog (the metadata generator scans its `src/`).
```bash
# Terminal 1 — backend
cd backend
python -m venv venv
source venv/bin/activate # Windows: venv\Scripts\activate
pip install -r requirements.txt
uvicorn app.main:app --reload --port 8001
```
```bash
# Terminal 2 — frontend
cd frontend
npm install
npm run dev
```
Open .
**arduino-cli setup (first time):**
```bash
arduino-cli core update-index
arduino-cli core install arduino:avr
# For Raspberry Pi Pico / Pico W:
arduino-cli config add board_manager.additional_urls \
https://github.com/earlephilhower/arduino-pico/releases/download/global/package_rp2040_index.json
arduino-cli core install rp2040:rp2040
# For ATtiny85:
arduino-cli config add board_manager.additional_urls \
http://drazzy.com/package_drazzy.com_index.json
arduino-cli core install ATTinyCore:avr
```
> ESP32 (Xtensa / RISC-V) compilation in a manual install requires ESP-IDF
> v5.5.4 plus the arduino-esp32 3.3.10 core installed locally, the same pair
> velxio.dev builds with. The Docker image bundles both — for manual installs
> see [docs/ESP32_EMULATION.md](docs/ESP32_EMULATION.md). If you only need
> AVR / RP2040 boards you can skip ESP-IDF entirely.
---
## Documentation
The user documentation lives at **[velxio.dev/docs](https://velxio.dev/docs/)** — getting started, every board and part, the circuit editor, programming in Arduino / MicroPython / ESP-IDF, WiFi and IoT, instruments, custom chips and the AI assistant, in 9 languages. Its source is the public [velxio/velxio_docs](https://github.com/velxio/velxio_docs) repository; corrections and new pages are welcome there.
The `docs/` folder of this repository keeps the technical notes for contributors (emulator internals, QEMU bridges, MCP server, roadmap).
---
## Community
Join the Discord server to ask questions, share projects, and follow updates:
**[discord.gg/3mARjJrh4E](https://discord.gg/3mARjJrh4E)**
## Contributing
Suggestions, bug reports, and pull requests are welcome at [github.com/davidmonterocrespo24/velxio](https://github.com/davidmonterocrespo24/velxio).
If you'd like to support the project financially, see the [Support the Project](#support-the-project) section above or sponsor directly at [github.com/sponsors/davidmonterocrespo24](https://github.com/sponsors/davidmonterocrespo24).
> **Note:** All contributors must sign a Contributor License Agreement (CLA) so that the dual-licensing model remains valid. A CLA check runs automatically on pull requests.
## License
Velxio uses a **dual-licensing** model:
| Use case | License | Cost |
| --- | --- | --- |
| Personal, educational, open-source (AGPLv3 compliant) | [AGPLv3](LICENSE) | Free |
| Proprietary / closed-source product or SaaS | [Commercial License](COMMERCIAL_LICENSE.md) | Paid |
The AGPLv3 is a certified Open Source license. It is free for all uses — including commercial — as long as any modifications or network-accessible deployments make their source code available under the same license. Companies that cannot comply with that requirement can purchase a Commercial License.
For commercial licensing inquiries: [davidmonterocrespo24@gmail.com](mailto:davidmonterocrespo24@gmail.com)
See [LICENSE](LICENSE) and [COMMERCIAL_LICENSE.md](COMMERCIAL_LICENSE.md) for full terms.
## Star History
## References
- [Wokwi](https://wokwi.com) — Inspiration
- [avr8js](https://github.com/wokwi/avr8js) — AVR8 emulator
- [wokwi-elements](https://github.com/wokwi/wokwi-elements) — Electronic web components
- [wokwi-boards](https://github.com/wokwi/wokwi-boards) — Board SVG assets
- [wokwi-features](https://github.com/wokwi/wokwi-features) — Wokwi feature definitions
- [rp2040js](https://github.com/wokwi/rp2040js) — RP2040 emulator
- [ngspice-wasm](https://github.com/wokwi/ngspice-wasm) — ngspice compiled to WebAssembly (electrical simulation)
- [lcgamboa/qemu](https://github.com/lcgamboa/qemu) — QEMU fork for ESP32 Xtensa emulation
- [espressif/qemu](https://github.com/espressif/qemu) — Espressif QEMU ESP32 emulator
- [esp32-camera](https://github.com/espressif/esp32-camera) — ESP32 camera driver reference
- [fritzing-parts](https://github.com/fritzing/fritzing-parts) — Electronic component SVG assets
- [picowi](https://github.com/jbentham/picowi) — Raspberry Pi Pico W WiFi reference
- [100 Days 100 IoT Projects](https://github.com/velxio/100_Days_100_IoT_Projects) — IoT example projects collection
- [arduino-cli](https://github.com/arduino/arduino-cli) — Arduino compiler
- [Monaco Editor](https://microsoft.github.io/monaco-editor/) — Code editor
- [QEMU](https://www.qemu.org) — Machine emulator (Raspberry Pi 3)