# One-Stop VLA Development Toolbox for Embodied Intelligence
[](https://arxiv.org/pdf/2510.23511)
[](https://huggingface.co/Dexmal)
[](https://dexbotic.com/docs/)
[](LICENSE)
[](README.zh-CN.md)
Pretraining · Fine-tuning · Inference · Evaluation
Supporting mainstream policies such as π0, CogACT, OFT, MemVLA, and more
## Introduction
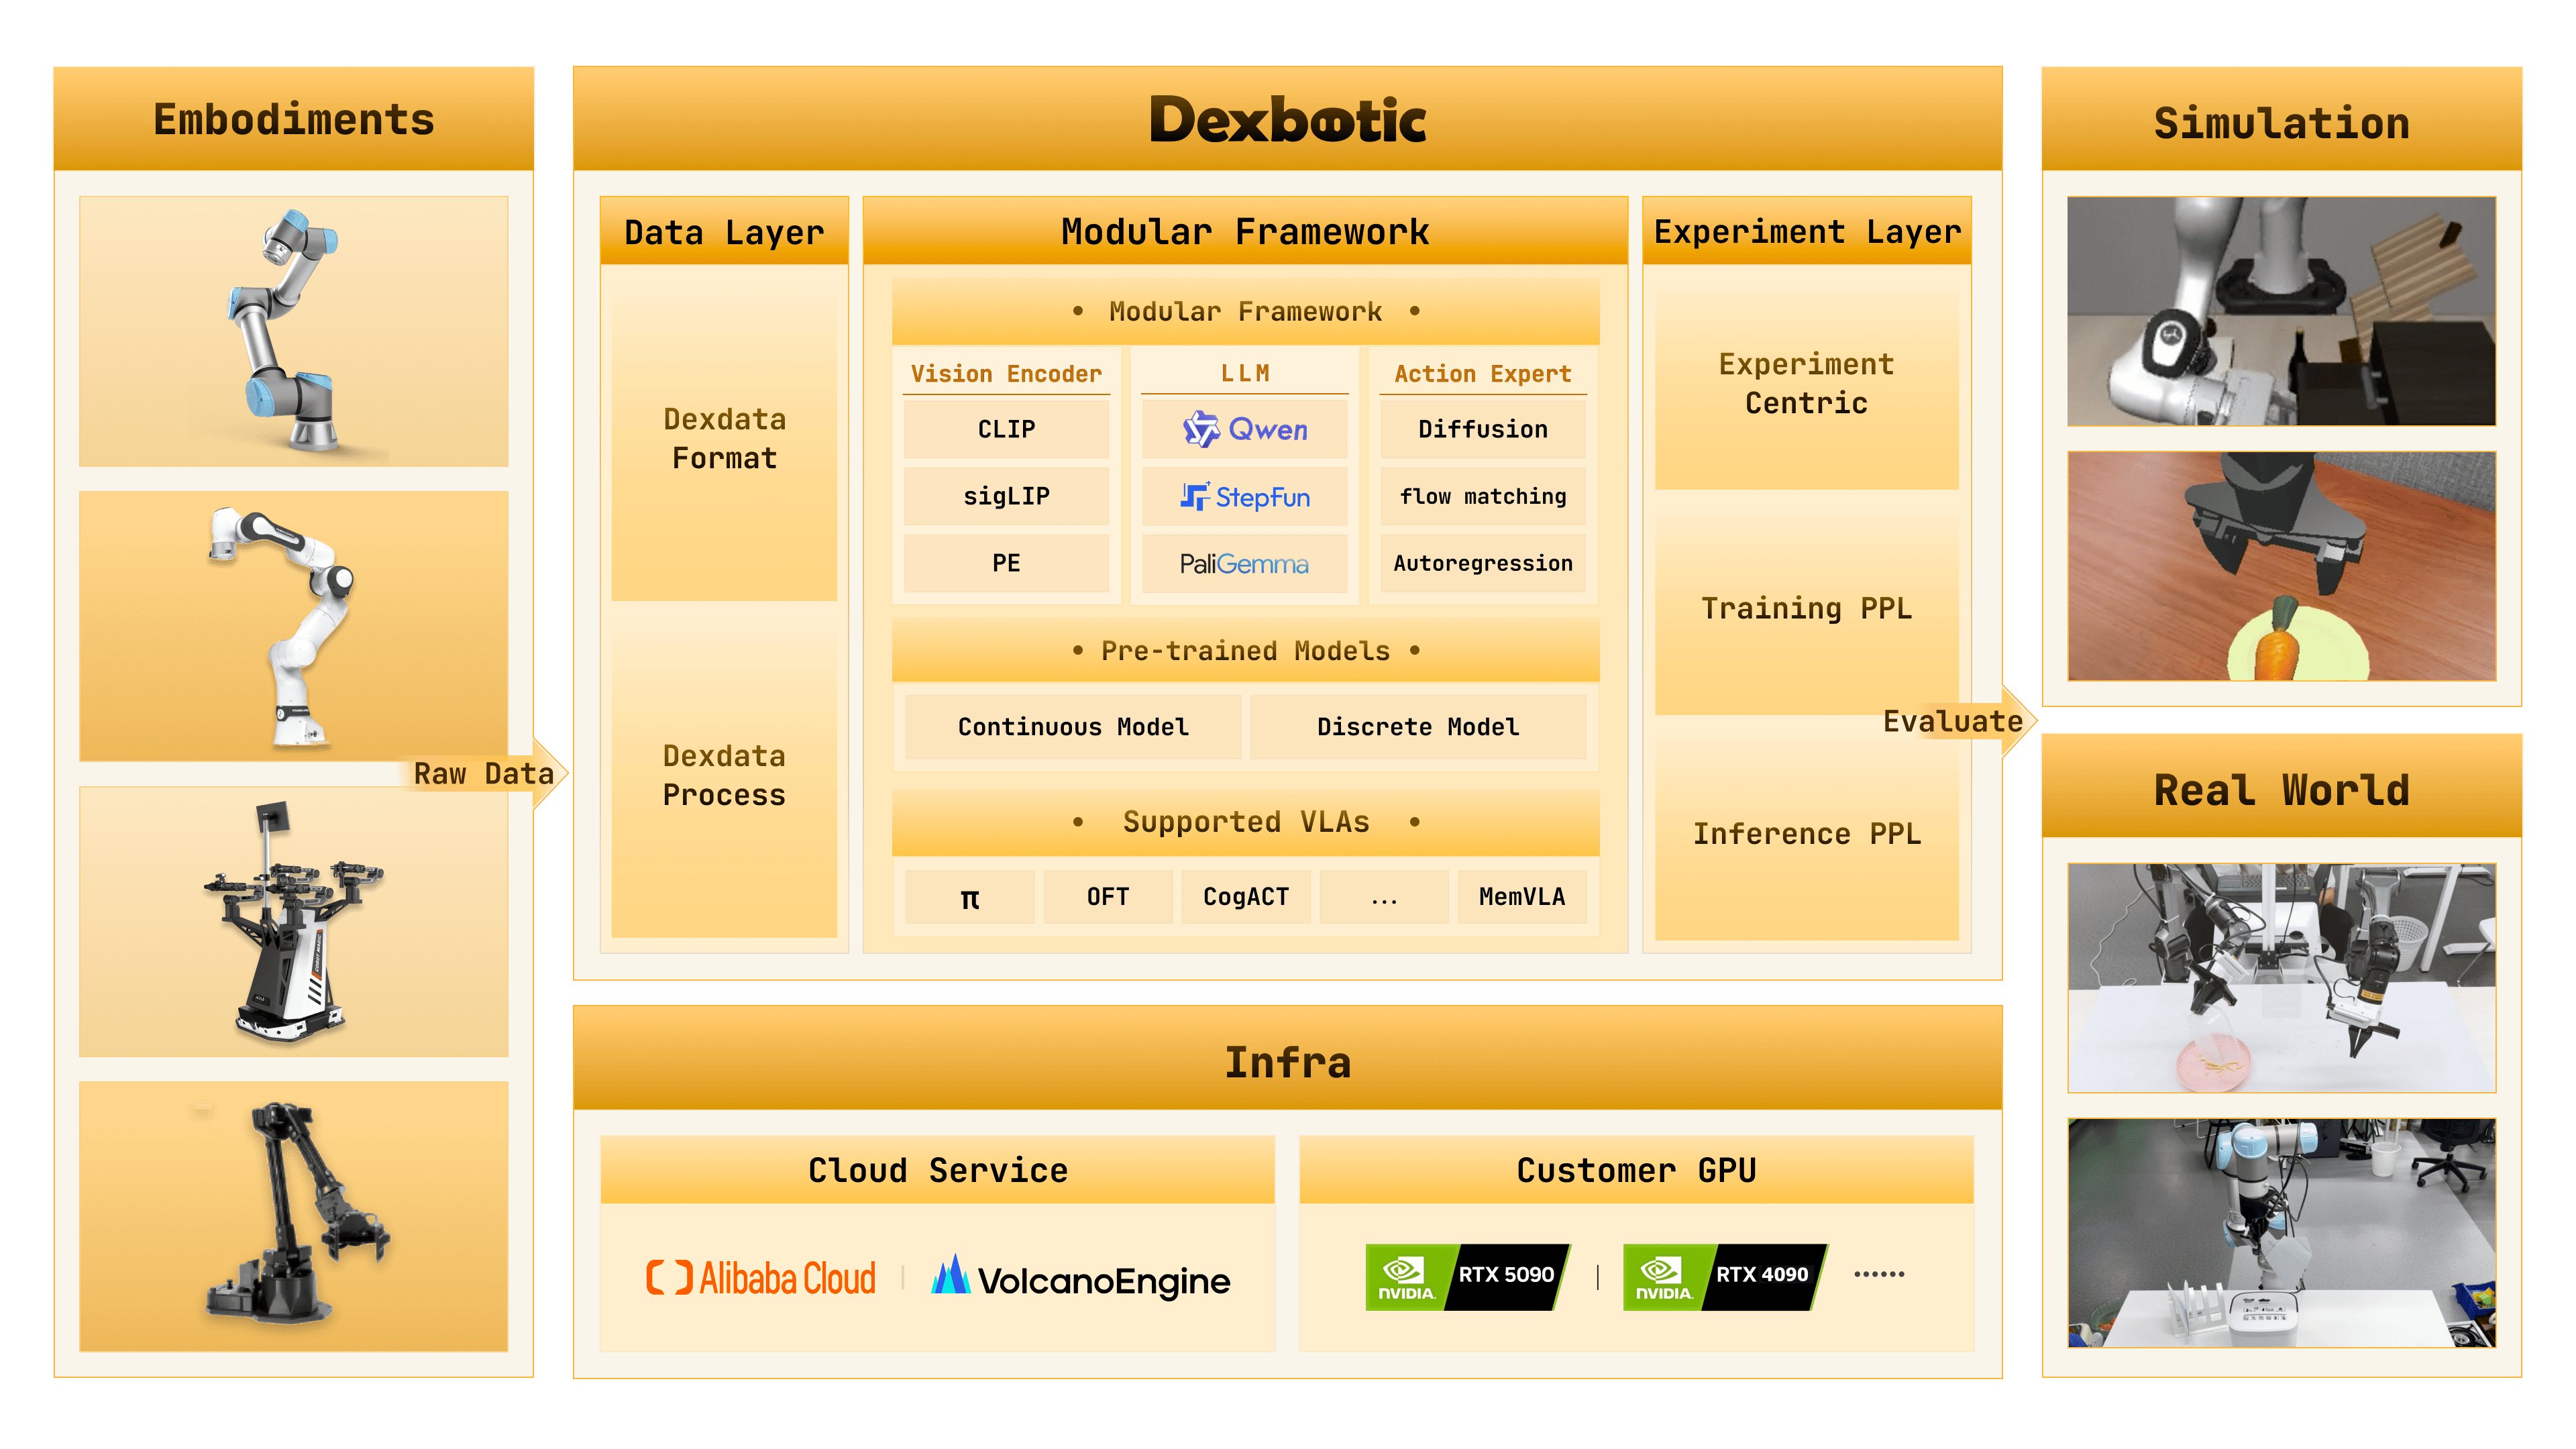
**Dexbotic** is a VLA (Vision-Language-Action) development toolbox built on the PyTorch framework, designed to provide a unified and efficient solution for embodied intelligence research. It comes with built-in environment configurations for various mainstream VLA models, allowing users to reproduce, fine-tune, and inference cutting-edge VLA algorithms with simple setup.
- **Ready-to-Use VLA Framework**: Centered around VLA models, integrating embodied manipulation and navigation capabilities, supporting multiple cutting-edge algorithms.
- **High-Performance Pre-trained Foundation Models**: For mainstream VLA algorithms such as π0 and CogACT, Dexbotic provides multiple optimized pre-trained models.
- **Modular Development Architecture**: Adopting a "layered configuration + factory registration + entry dispatch" architecture, users can easily modify configurations, change models, or add tasks by simply modifying experimental scripts.
- **Unified Cloud and Local Training**: Fully supports both cloud and local training needs, supporting cloud training platforms such as Alibaba Cloud and Volcano Engine, while also accommodating consumer-grade GPUs for local training.
- **Extensive Robot Compatibility**: For mainstream robots such as UR5, Franka, and ALOHA, Dexbotic provides a **unified training data format** and deployment scripts.
## 🔥 News
- **[2026-09-11]** Added history-aware inference support to [DM05](docs/DM05.md#history-frame-inference) for richer temporal context.
- **[2026-09-10]** Upgraded [DM05](docs/DM05.md#inference-performance) inference with a high-performance backend, delivering an approximately **5x model-inference speedup**.
- **[2026-09-01]** Dexbotic [DM05](docs/DM05.md) released! See the [technical report](https://www.dexmal.com/blog/dm0.5) for more information. See [libero_dm05.py](playground/benchmarks/libero/libero_dm05.py) and [libero_dm05_lora.py](playground/benchmarks/libero/libero_dm05_lora.py) for LIBERO full SFT and LoRA.
- **[2026-08-06]** Added [CogACT LIBERO LoRA SFT](docs/LiberoLora.md#cogact-lora-recipe) support; see the [CogACT LoRA](playground/benchmarks/libero/libero_cogact_lora.py) for details.
- **[2026-08-06]** Added [DM0 LIBERO LoRA SFT](docs/LiberoLora.md#dm0-lora-recipe) support; see the [DM0 LoRA](playground/benchmarks/libero/libero_dm0_lora.py) for details.
- **[2026-07-29]** Added [PI05 LIBERO LoRA SFT](docs/LiberoLora.md#pi05-lora-recipe) support; see the [PI05 LoRA](playground/benchmarks/libero/libero_pi05_lora.py) for details.
- **[2026-07-29]** Added [PI0 LIBERO LoRA SFT](docs/LiberoLora.md#pi0-lora-recipe) support; see the [PI0 LoRA](playground/benchmarks/libero/libero_pi0_lora.py) for details.
- **[2026-07-28]** Added [gr00tsonic](playground/example_gr00tsonic_exp.py) support for Unitree G1 SONIC. See the [Unitree G1 SONIC guide](hardware/unitree_sonic/README.md).
- **[2026-06-25]** Added [Co-training](dexbotic/exp/hybrid_dm0_exp.py) capability for the DM0 model. See [Hybrid DM0 Co-Training](docs/DM0.md#hybrid-dm0-co-training) for details.
- **[2026-06-18]** Released a [DOS-W1 inference tutorial](hardware/docs/dosw1_inference_example.md), covering how to integrate DOS-W1 with Dexbotic.
- **[2026-06-18]** Added a [DM0 realtime inference guide](docs/DM0RealtimeInference.md) for the Triton-backed realtime backend, including 5x core inference speedup results.
- **[2026-06-12]** Added a unified [v1 inference API](docs/InferenceAPI.md) for consistent VLA/VLM serving across model wrappers.
- **[2026-05-15]** Supported [FSDP2 training backend](docs/FSDP2.md) for faster distributed training.
- **[2026-05-09]** Supported [Uni-NaVid](playground/example_uninavid_exp.py) with a [guide](docs/Uni-NaVid.md).
- **[2026-04-27]** Supported [RLinf as an RL backend](docs/RLinfAsRLBackend.md) for RL post-training.
- **[2026-03-30]** Supported [GR00TN1](playground/benchmarks/libero/libero_gr00tn1.py).
- **[2026-03-30]** Added [Co-training](dexbotic/exp/hybrid_pi05_exp.py) capability for the Pi05 model.
- **[2026-03-30]** Released a tutorial on integrating [XLeRobot](hardware/docs/xlerobot_inference_example.md) with Dexbotic.
- **[2026-02-10]** [DM0](docs/DM0.md) released! See the [technical report](https://dexmal.com/DM0_Tech_Report.pdf) for more information.
- **[2026-02-10]** Partnership Announcement: We are excited to announce a strategic collaboration with [RLinf](https://github.com/RLinf/RLinf). Together, our teams will advance VLA + RL research and applications.
- **[2026-01-15]** Released a tutorial on integrating [SO-101](hardware/docs/so101_inference_example.md) with Dexbotic.
- **[2026-01-15]** Supported [GRPO](docs/RL.md)
- **[2026-01-15]** Supported [NaVILA](playground/example_navila_exp.py).
- **[2026-01-08]** Added [Co-training](dexbotic/exp/hybrid_cogact_exp.py) capability, enabling joint optimization of action experts and LLMs for the CogACT model.
- **[2026-01-08]** Released a specialized image compatible with [Blackwell GPUs](#blackwell-gpus).
- **[2025-12-29]** Supported [OFT](playground/benchmarks/libero/libero_oft.py) and [Pi0.5](playground/benchmarks/libero/libero_pi05.py) models.
- **[2025-10-20]** Dexbotic officially released! Check out the [technical report](https://arxiv.org/pdf/2510.23511) and [official documentation](https://dexbotic.com/docs/) for details.
## Quick Start
We strongly recommend using Docker for development or deployment to get the best experience.
### 1. Installation and Environment Setup
```bash
# 1. Clone the repository
git clone https://github.com/dexmal/dexbotic.git
# 2. Start Docker container
docker run -it --rm --gpus all --network host \
-v $(pwd)/dexbotic:/dexbotic \
dexmal/dexbotic \
bash
# 3. Activate environment and install dependencies
cd /dexbotic
conda activate dexbotic
pip install -e .
```
> **System Requirements**: Ubuntu 20.04/22.04, recommended GPUs: RTX 4090, A100, or H100 (8 GPUs recommended for training, 1 GPU for deployment).