High-quality Robot Models for Simulation and Planning
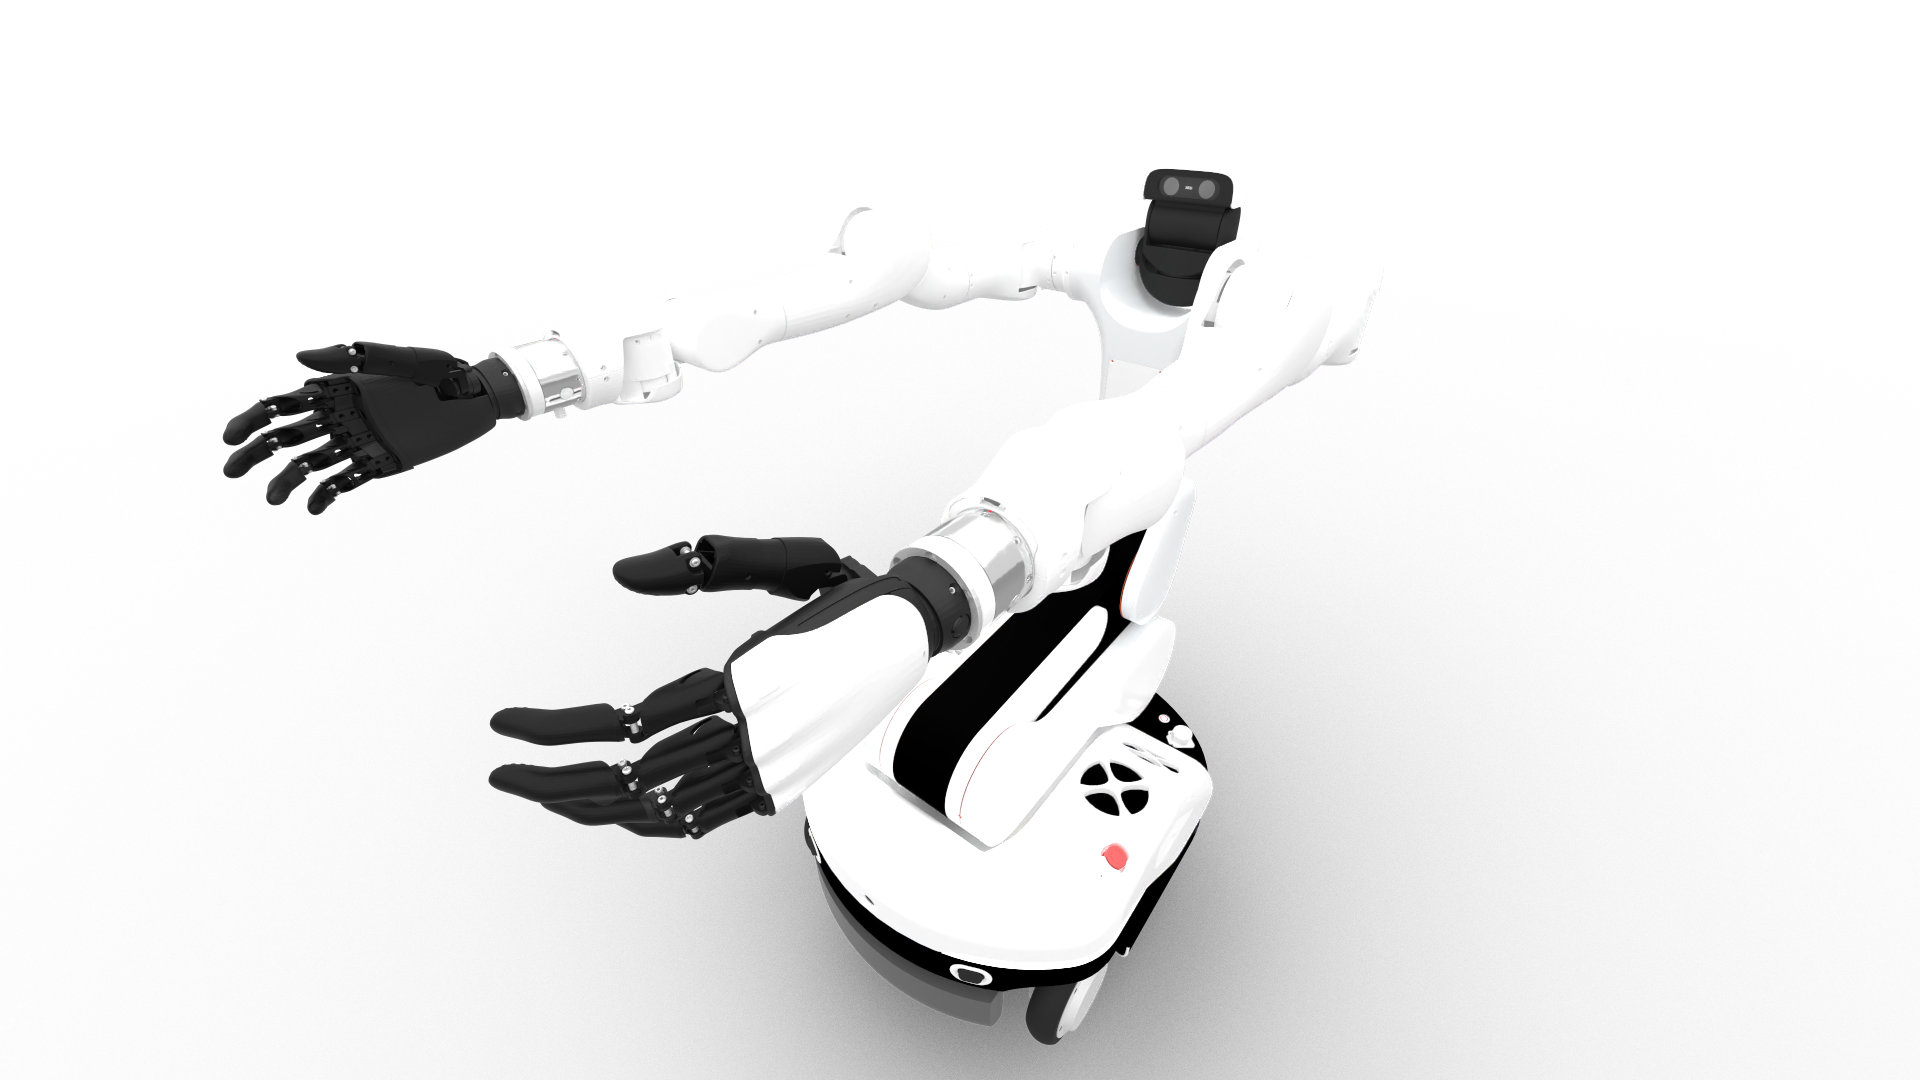 |
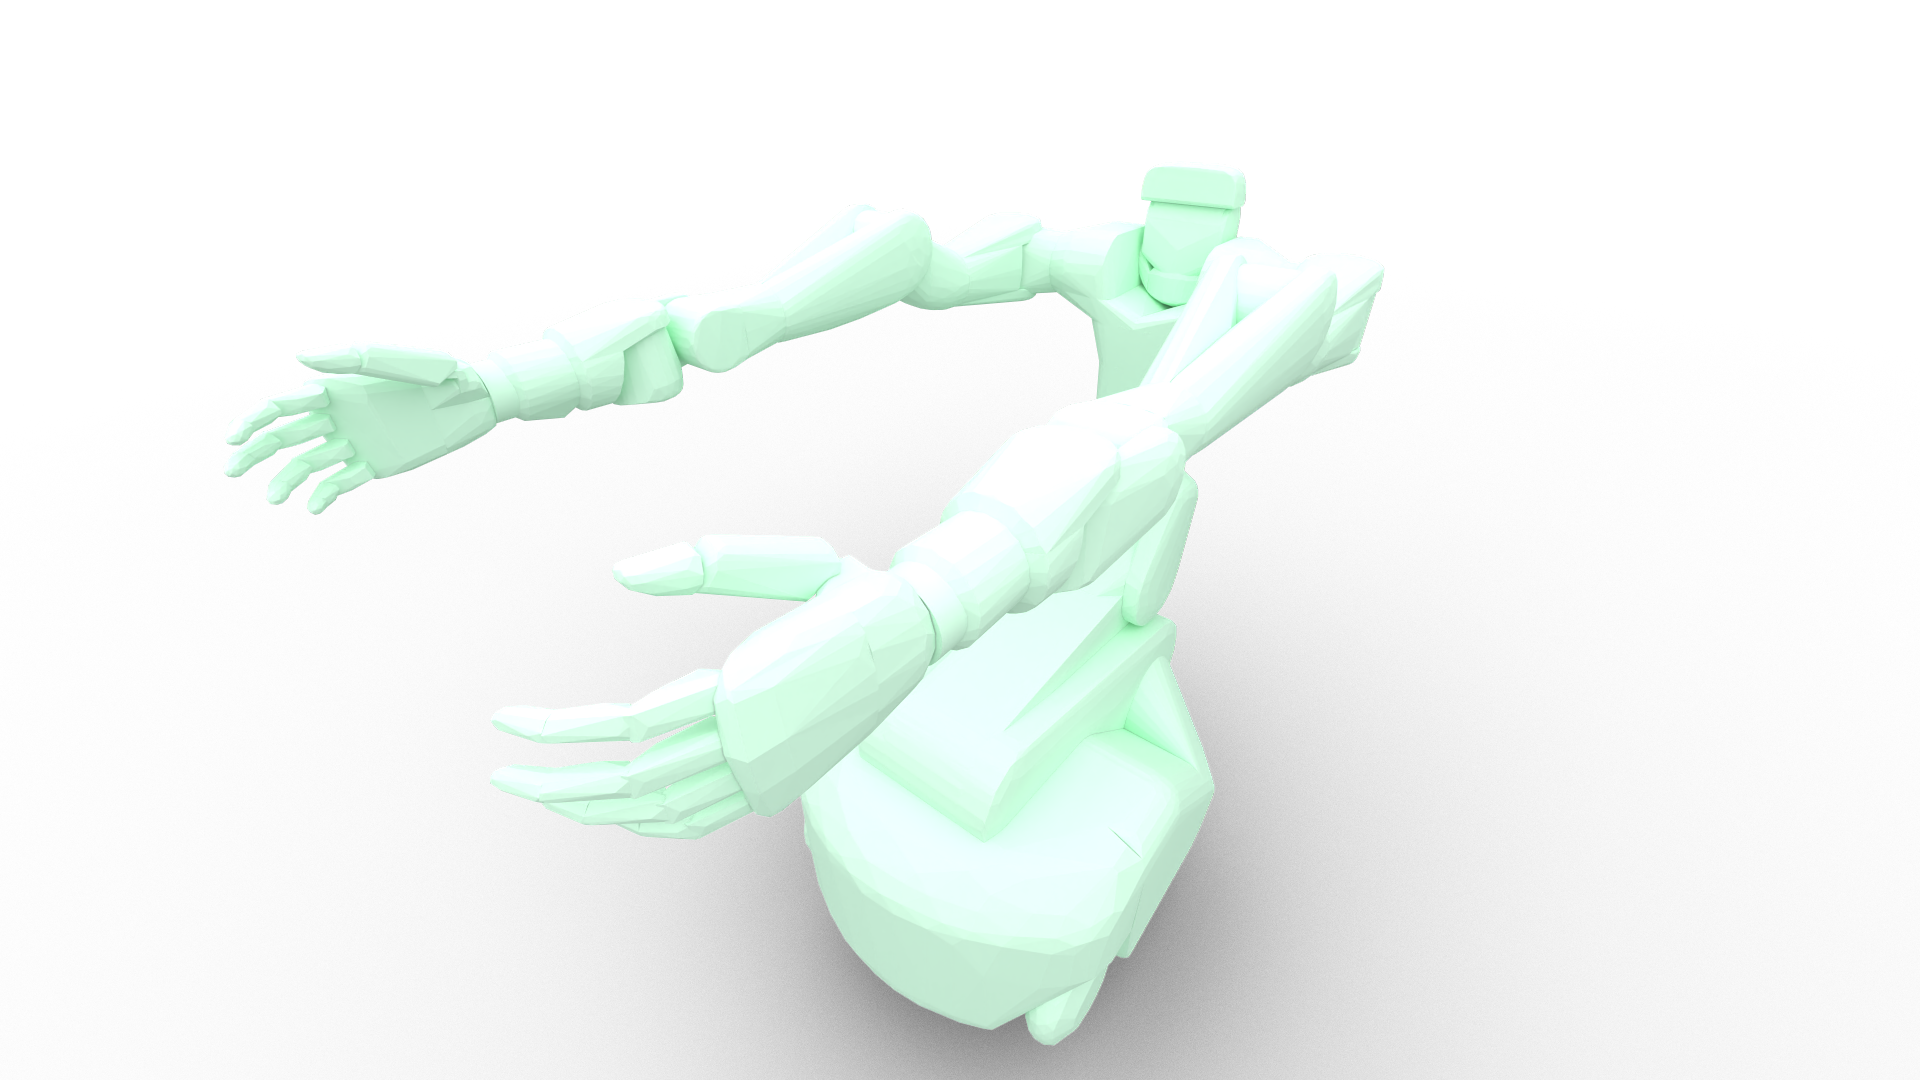 |
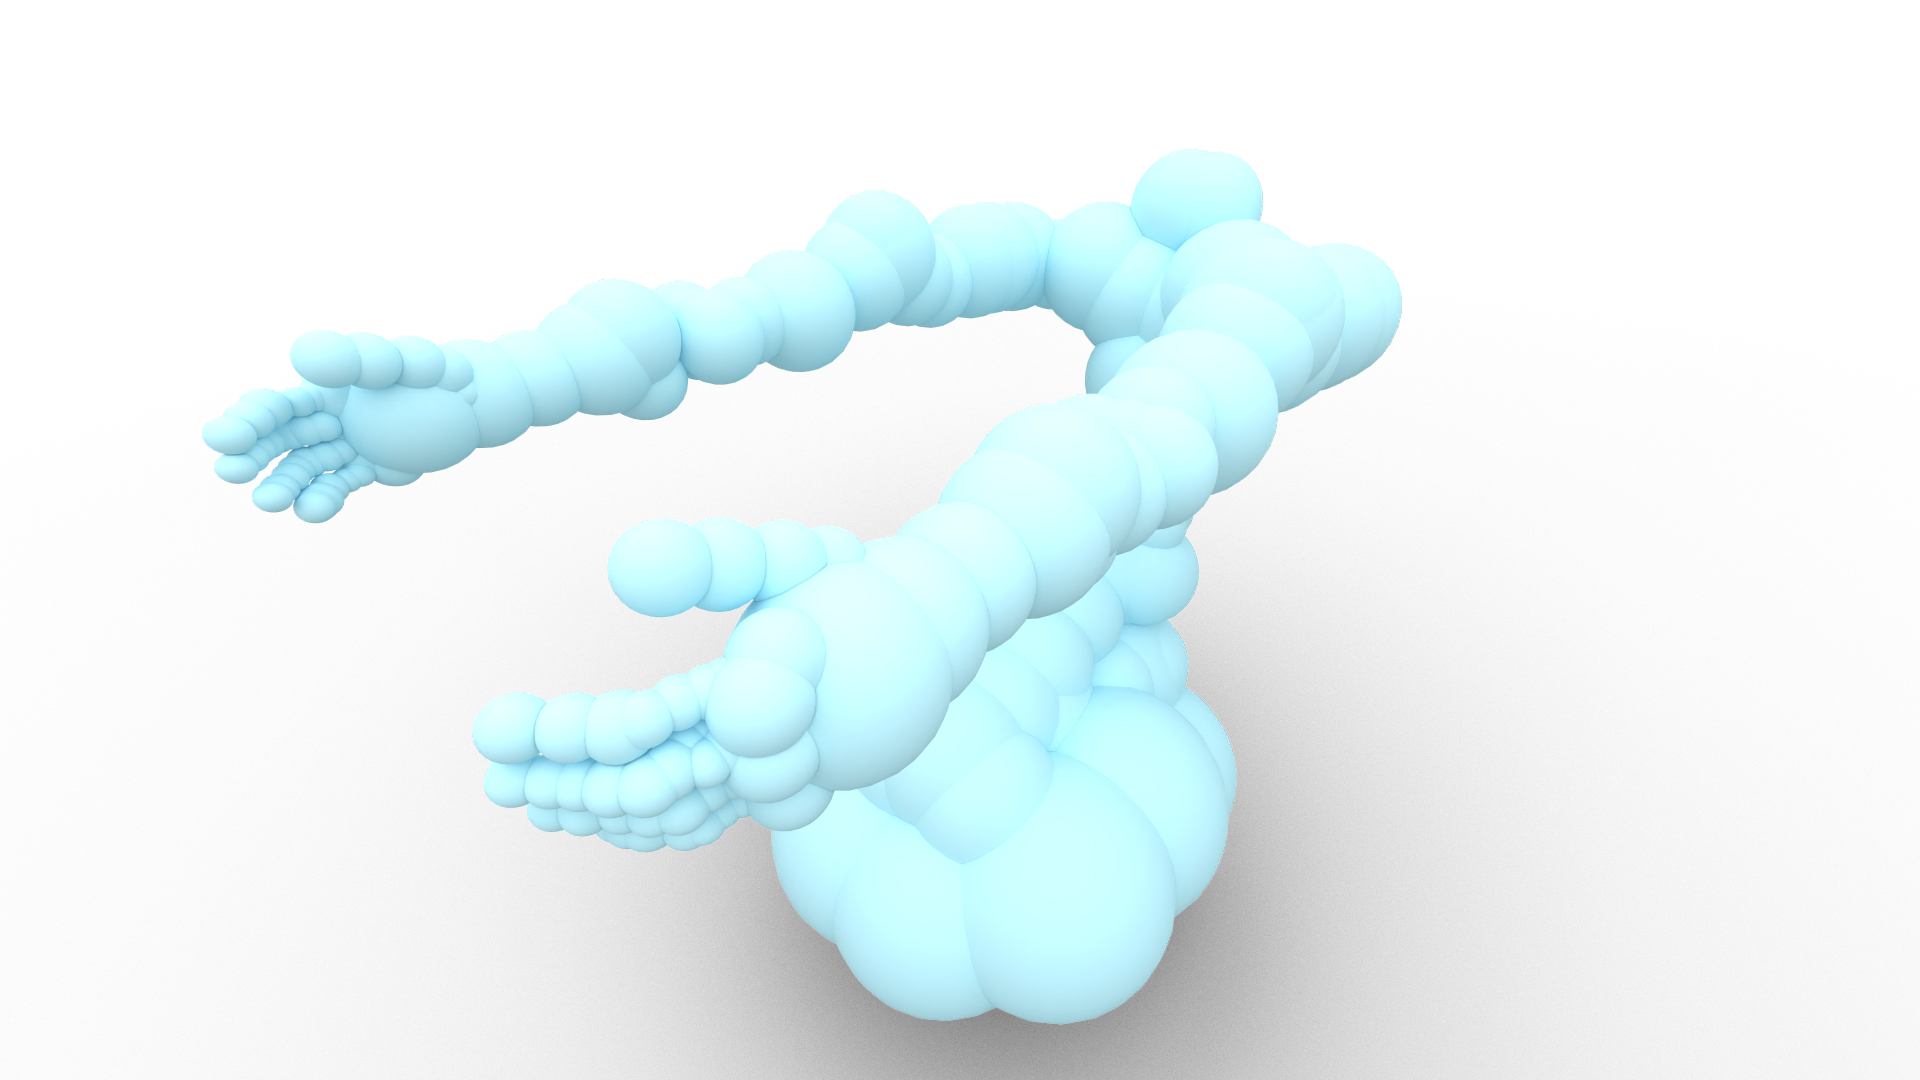 |
[^1]: High quality visual modeling for rendering.
[^2]: Collision modeling composed of convex decomposition meshes with light simplification, which can be used for physical simulation, etc.
[^3]: Collision modeling composed of spheres, which can be an alternative collision representation when speed is more of a concern. These meshes are larger than the real one, which is not desirable to be used in high-fidelity simulation.
## 🔧 Supported Platforms
Our models are tested with popular robotics frameworks:
- 🎮 **IsaacSim/IsaacLab/IsaacGym** - For simulation and RL training
- 🔄 **Pinocchio** - For kinematics and dynamics computation
- 🎯 **SAPIEN** - For simulation and visualization
## 📚 Package Structure
```python
dexmate_urdf.robots
├── humanoid/
│ ├── vega_1/ # Base variant folder
│ │ ├── vega_1.urdf # Base variant (no hands)
│ │ ├── vega_1_f5d6.urdf # With F5D6 hands
│ │ ├── vega_1_gripper.urdf # With gripper hands
│ │ ├── vega.urdf # Alias (symlink to vega_1_f5d6)
│ │ └── configs/ # Variant-specific configs
│ ├── vega_1u/ # Upper body variants
│ │ ├── vega_1u.urdf
│ │ ├── vega_1u_f5d6.urdf
│ │ └── vega_1u_gripper.urdf
│ └── vega_1p/ # Pro variants
│ ├── vega_1p.urdf
│ ├── vega_1p_f5d6.urdf
│ └── vega_1p_gripper.urdf
└── ... # More robots
```
## 📝 Changelog
For information about recent updates and changes, please refer to the [CHANGELOG.md](CHANGELOG.md).
## 📄 Licensing
### 🔓 Apache License 2.0
This software is licensed under the **Apache License 2.0**. This permissive license allows you to:
- ✅ Use the software commercially
- ✅ Modify the software and create derivatives
- ✅ Distribute copies and modifications
- ✅ Use patent claims (if applicable)
See the [LICENSE](./LICENSE) file for the complete license text.
---