# Debug Probe MCP Server


A stateful debug probe Model Context Protocol (MCP) server for developer tooling and AI agents.
Works out of the box with Claude Code, VS Code with Copilot, and any MCP-compatible runtime. Communicates over **stdio** and drives on-chip debug probes (J-Link first, OpenOCD and pyOCD planned) to flash, debug, and inspect embedded targets.
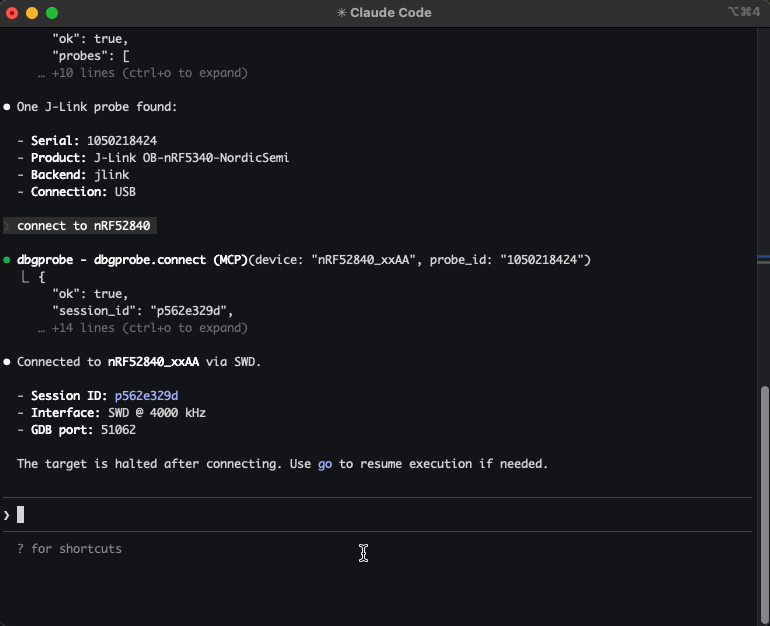
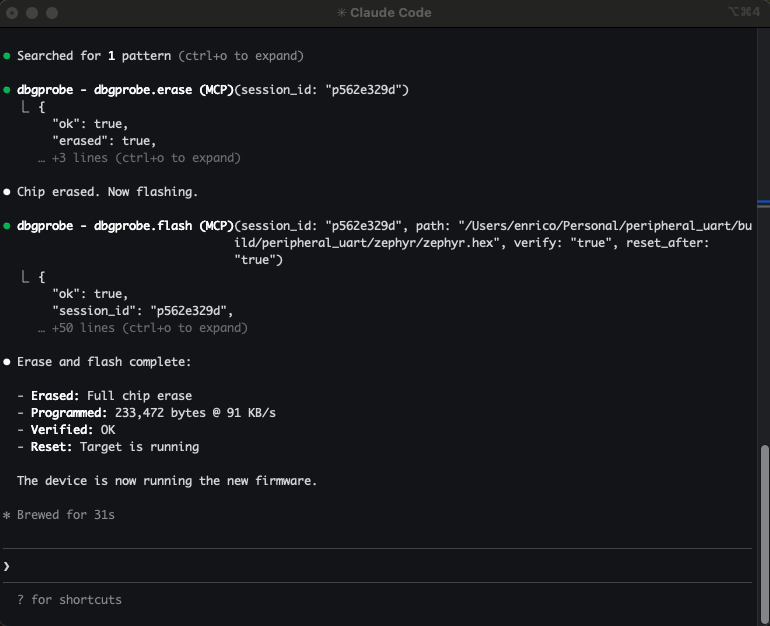
> **Example:** Let Claude Code list attached J-Link probes, connect to your nRF52840, flash a new firmware, read memory, and reset the target — all conversationally.
### Demo
[Video walkthrough](https://youtu.be/nLt0Vj8TAHs) — connecting to a J-Link probe, flashing firmware, loading ELF and SVD for symbol-aware debugging, RTT logging, and breakpoints.
---
## Why this exists
If you've ever typed J-Link Commander commands by hand, copy-pasted memory addresses between a datasheet and a terminal, re-flashed the same firmware 20 times during a debug session, and juggled multiple tool windows — this is for you.
You have a microcontroller on a debug probe. You want an AI agent to interact with it — connect, flash firmware, read/write memory, reset, halt, resume. This server makes that possible.
It gives any MCP-compatible agent a full set of debug probe tools. The agent calls these tools, gets structured JSON back, and reasons about what to do next — without you manually driving JLinkExe for every operation.
**What agents can do with it:**
- **Flash and iterate** — build firmware, flash it, reset, check behavior — all in one conversation
- **Inspect memory** — read peripheral registers, check RAM contents, verify flash writes
- **Debug interactively** — halt, step, set breakpoints, inspect state, resume
- **Automate test flows** — flash → reset → read output → validate
- **Multi-probe setups** — connect to multiple probes simultaneously, each with its own session
---
## Who is this for?
- **Embedded engineers** — faster iteration: flash, debug, inspect memory conversationally
- **Hobbyists and makers** — interact with microcontrollers without learning JLinkExe command syntax
- **QA and test engineers** — automated flash-and-test sequences across multiple boards
- **Researchers** — systematic exploration of embedded systems, register inspection
---
## Quickstart (Claude Code)
```bash
pip install dbgprobe-mcp-server
# Register the MCP server with Claude Code
claude mcp add dbgprobe -- dbgprobe_mcp
# Or with explicit J-Link path
claude mcp add dbgprobe \
-e DBGPROBE_JLINK_PATH=/Applications/SEGGER/JLink/JLinkExe \
-- dbgprobe_mcp
```
Then in Claude Code, try:
> "List attached debug probes, connect to the J-Link, and read 16 bytes from address 0x20000000."
---
## Supported backends
| Backend | Status | Probe hardware |
|---|---|---|
| **J-Link** | Working (v0) | SEGGER J-Link (EDU, EDU Mini, PLUS, PRO, etc.) |
| **OpenOCD** | Planned | ST-Link, CMSIS-DAP, and many others |
| **pyOCD** | Planned | CMSIS-DAP, ST-Link, J-Link (via pyOCD) |
The server is backend-agnostic — tool names (`dbgprobe.*`) stay the same regardless of which probe you use.
### J-Link requirements
Install the [SEGGER J-Link Software Pack](https://www.segger.com/downloads/jlink/). The server auto-detects `JLinkExe` on PATH or in common install locations:
- **macOS:** `/Applications/SEGGER/JLink/`
- **Linux:** `/opt/SEGGER/JLink/`, `/usr/bin/`
- **Windows:** `C:\Program Files\SEGGER\JLink\`
Or set `DBGPROBE_JLINK_PATH` to point to the executable directly.
> *This project is not affiliated with or sponsored by SEGGER. J-Link is used because it's widely available and well-supported.*
---
## Tools
| Category | Tools |
|---|---|
| **Probe** | `dbgprobe.probes.list`, `dbgprobe.connect`, `dbgprobe.erase`, `dbgprobe.disconnect`, `dbgprobe.reset`, `dbgprobe.halt`, `dbgprobe.go`, `dbgprobe.step`, `dbgprobe.status`, `dbgprobe.flash`, `dbgprobe.mem.read`, `dbgprobe.mem.write`, `dbgprobe.breakpoint.set`, `dbgprobe.breakpoint.clear`, `dbgprobe.breakpoint.list` |
| **Introspection** | `dbgprobe.connections.list` |
| **ELF** | `dbgprobe.elf.attach`, `dbgprobe.elf.info`, `dbgprobe.elf.lookup`, `dbgprobe.elf.symbols` |
| **SVD** | `dbgprobe.svd.attach`, `dbgprobe.svd.info`, `dbgprobe.svd.read`, `dbgprobe.svd.write`, `dbgprobe.svd.set_field`, `dbgprobe.svd.update_fields`, `dbgprobe.svd.list_peripherals`, `dbgprobe.svd.list_registers`, `dbgprobe.svd.list_fields`, `dbgprobe.svd.describe` |
| **RTT** | `dbgprobe.rtt.start`, `dbgprobe.rtt.stop`, `dbgprobe.rtt.read`, `dbgprobe.rtt.write`, `dbgprobe.rtt.status` |
| **Plugins** | `dbgprobe.plugin.list`, `dbgprobe.plugin.template`, `dbgprobe.plugin.load`, `dbgprobe.plugin.reload` |
| **Tracing** | `dbgprobe.trace.status`, `dbgprobe.trace.tail` |
See [docs/tools.md](https://github.com/es617/dbgprobe-mcp-server/blob/main/docs/tools.md) for full schemas and examples.
---
## Install (development)
```bash
# Editable install from repo root
pip install -e ".[test]"
# Or with uv
uv pip install -e ".[test]"
```
> MCP is a protocol — this server works with any MCP-compatible client. Below are setup instructions for the most common ones.
## Add to Claude Code
```bash
# Standard setup
claude mcp add dbgprobe -- dbgprobe_mcp
# With default target device
claude mcp add dbgprobe \
-e DBGPROBE_JLINK_DEVICE=nRF52840_xxAA \
-- dbgprobe_mcp
# Debug logging
claude mcp add dbgprobe -e DBGPROBE_MCP_LOG_LEVEL=DEBUG -- dbgprobe_mcp
```
## Add to VS Code / Copilot
Add to your project's `.vscode/mcp.json` (or create it):
```json
{
"servers": {
"dbgprobe": {
"type": "stdio",
"command": "dbgprobe_mcp",
"args": [],
"env": {
"DBGPROBE_JLINK_DEVICE": "nRF52840_xxAA"
}
}
}
}
```
Adjust `env` to match your target — set `DBGPROBE_JLINK_DEVICE` to your chip, or remove it to specify the device at connect time.
## Add to Cursor
Add to your project's `.cursor/mcp.json` (or create it). Cursor does not support dots in tool names, so `DBGPROBE_MCP_TOOL_SEPARATOR` must be set to `_`:
```json
{
"mcpServers": {
"dbgprobe": {
"command": "dbgprobe_mcp",
"args": [],
"env": {
"DBGPROBE_JLINK_DEVICE": "nRF52840_xxAA",
"DBGPROBE_MCP_TOOL_SEPARATOR": "_"
}
}
}
}
```
## Environment variables
### Server
| Variable | Default | Description |
|---|---|---|
| `DBGPROBE_BACKEND` | `jlink` | Debug probe backend. Future: `openocd`, `pyocd`. |
| `DBGPROBE_MCP_LOG_LEVEL` | `WARNING` | Python log level (`DEBUG`, `INFO`, `WARNING`, `ERROR`). Logs go to stderr. |
| `DBGPROBE_MCP_TRACE` | enabled | JSONL tracing of every tool call. Set to `0`, `false`, or `no` to disable. |
| `DBGPROBE_MCP_TRACE_PAYLOADS` | disabled | Include memory data payloads in traced args (stripped by default). |
| `DBGPROBE_MCP_TRACE_MAX_BYTES` | `16384` | Max payload chars before truncation (only when `TRACE_PAYLOADS` is on). |
| `DBGPROBE_MCP_TOOL_SEPARATOR` | `.` | Character used to separate tool name segments. Set to `_` for MCP clients that reject dots in tool names (e.g. Cursor). |
| `DBGPROBE_MCP_PLUGINS` | disabled | Plugin policy: `all` or comma-separated plugin names (e.g. `nrf52,stm32`). |
### J-Link backend
| Variable | Default | Description |
|---|---|---|
| `DBGPROBE_JLINK_PATH` | auto-detect | Explicit path to `JLinkExe` (or `JLink.exe` on Windows). |
| `DBGPROBE_JLINK_GDBSERVER_PATH` | auto-detect | Explicit path to `JLinkGDBServerCLExe`. |
| `DBGPROBE_JLINK_DEVICE` | *(none)* | Default target device string (e.g. `nRF52840_xxAA`). Can be overridden per-session. |
| `DBGPROBE_INTERFACE` | `SWD` | Debug interface: `SWD` or `JTAG`. |
| `DBGPROBE_SPEED_KHZ` | `4000` | Interface clock speed in kHz. |
| `DBGPROBE_GDB_TRACE` | disabled | Log all GDB RSP packets to file. Set to `1`, `true`, or `yes` to enable. |
| `DBGPROBE_GDB_TRACE_FILE` | `/tmp/gdb_trace.log` | Path for GDB RSP trace log (only when `GDB_TRACE` is on). |
---
## ELF Support
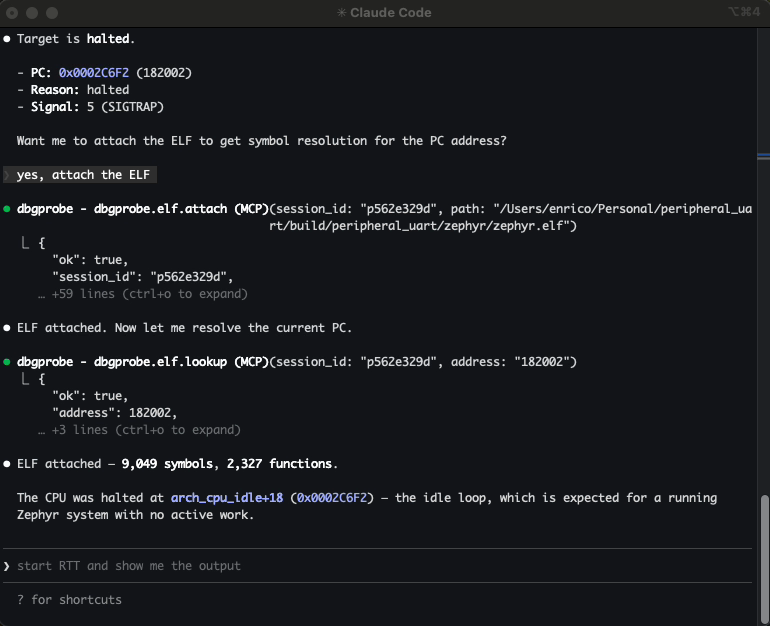
Attach an ELF file to a session to enable symbol-aware debugging:
- **Symbol lookup** — resolve function names to addresses and vice versa
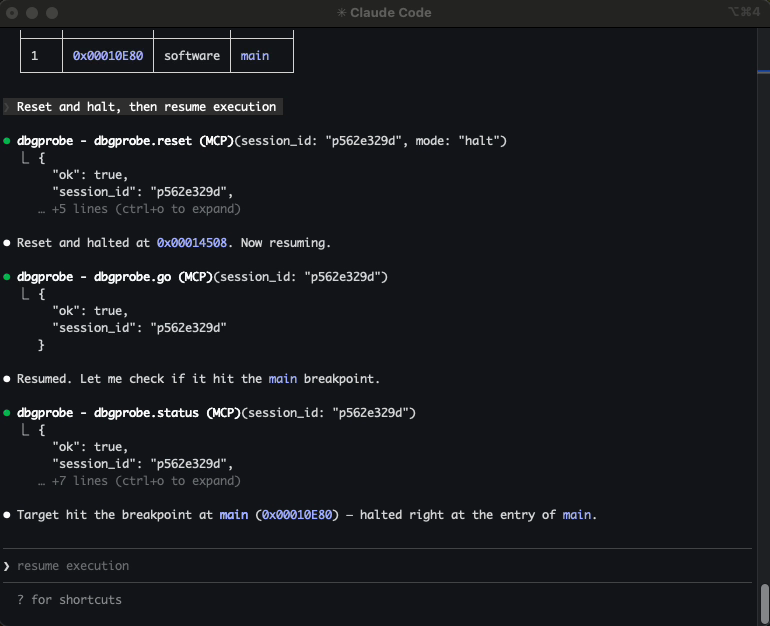
- **Breakpoints by name** — `breakpoint.set(symbol="main")` instead of raw addresses
- **Auto-enriched responses** — `status`, `step`, and `halt` include `symbol` + `symbol_offset` when an ELF is attached
- **Flash integration** — flashing an `.elf` auto-attaches it; flashing `.hex`/`.bin` auto-reloads a previously attached ELF; sibling `.elf` files are suggested via hints
```
> "Attach the ELF, set a breakpoint on main, run, and show me where it halted."
```
The agent calls `elf.attach`, `breakpoint.set(symbol="main")`, `go`, then `status` — and gets back `"halted at main+0"` instead of a raw hex address.
---
## SVD Support
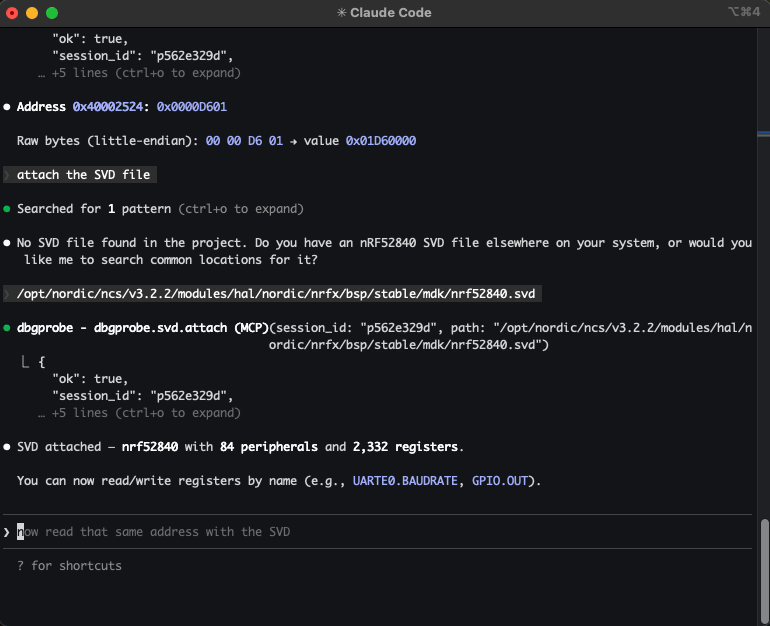
Attach an SVD (System View Description) file to a session to enable register-level peripheral access:
- **Named register reads** — `svd.read("GPIO.OUT")` returns the raw value and all decoded fields with enum names
- **Field-level reads** — `svd.read("GPIO.PIN_CNF[3].PULL")` returns the field value and enum name ("PullUp")
- **Safe field writes** — `svd.set_field("GPIO.PIN_CNF[3].PULL", "PullUp")` does read-modify-write
- **Batch field updates** — `svd.update_fields("GPIO.PIN_CNF[3]", {"DIR": "Output", "PULL": "PullUp"})` — one read, one write
- **Raw register writes** — `svd.write("GPIO.OUT", 0x01)` — full register, no RMW
- **Discovery** — list peripherals, registers, fields; describe with enums
- **Auto-decode on mem.read** — when an SVD is attached and `mem.read` hits a known register address, the response includes decoded fields
```
> "Attach the SVD, read GPIO.PIN_CNF[3], and set PULL to PullUp."
```
The agent calls `svd.attach`, `svd.read("GPIO.PIN_CNF[3]")`, then `svd.set_field("GPIO.PIN_CNF[3].PULL", "PullUp")` — and gets back decoded field values instead of raw hex.
---
## RTT (Real-Time Transfer)
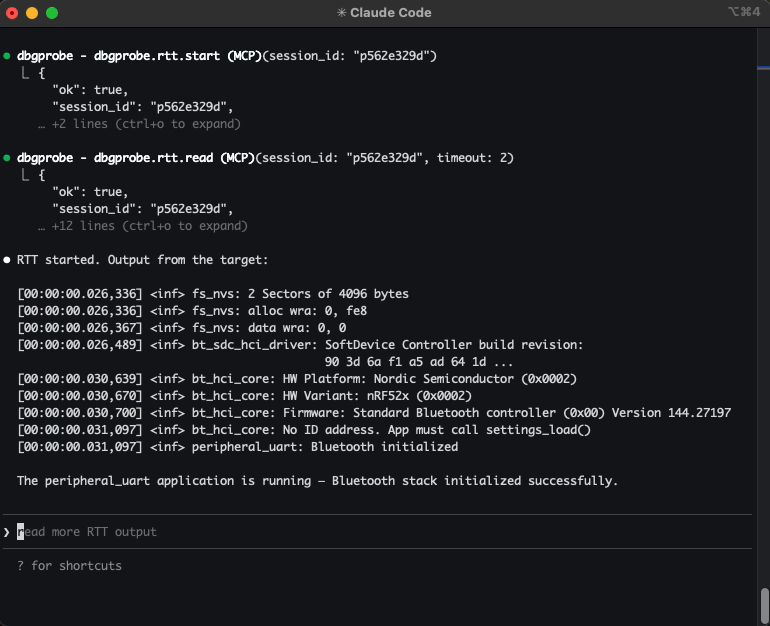
Start, stop, read, and write to SEGGER RTT channels. The agent can stream target log output and send data to the device — useful for debugging firmware that prints over RTT instead of UART.
```
> "Start RTT and show me the output."
```
For repetitive flows — read device ID, run a self-test sequence, validate calibration — you can package them as **plugins**: Python modules that expose custom tools the agent can call directly. Enable with `DBGPROBE_MCP_PLUGINS=all`. See the [nrf52_info example](https://github.com/es617/dbgprobe-mcp-server/blob/main/examples/nrf52840-dk/nrf52_info_plugin.py).
---
## Tracing
Every tool call is traced to `.dbgprobe_mcp/traces/trace.jsonl` and an in-memory ring buffer (last 2000 events). Tracing is **on by default** — set `DBGPROBE_MCP_TRACE=0` to disable.
Use `dbgprobe.trace.status` and `dbgprobe.trace.tail` to inspect the trace without reading the file directly.
---
## Try without an agent
You can test the server interactively using the [MCP Inspector](https://github.com/modelcontextprotocol/inspector):
```bash
npx @modelcontextprotocol/inspector python -m dbgprobe_mcp_server
```
---
## Roadmap / TODO
- [ ] **OpenOCD backend** — support ST-Link, CMSIS-DAP, and other probes via OpenOCD subprocess
- [ ] **pyOCD backend** — native Python probe access via pyOCD library
- [ ] **Multi-core support** — target specific cores on multi-core SoCs
- [ ] **Cortex-A/R support** — ARM-mode breakpoints (`kind=4`); currently Thumb-only (Cortex-M)
---
## Known limitations
- **Single-client only.** The server handles one MCP session at a time (stdio transport).
- **RTT channel 0 only.** RTT support is limited to channel 0 (terminal). Multi-channel RTT is a future enhancement.
- **Flash clears breakpoints.** Flashing new firmware invalidates breakpoints (the code at those addresses may have changed). The session stays alive but breakpoints are cleared.
- **Cortex-M only.** Breakpoints use Thumb-mode (`kind=2`). Cortex-A/R targets (ARM-mode, `kind=4`) are not yet supported.
- **Instruction-level step only.** `dbgprobe.step` single-steps one CPU instruction. Source-level stepping (step into/over/out) is not supported.
---
## Safety
This server connects an AI agent to real debug hardware. That's the point — and it means the stakes are higher than pure-software tools.
**Plugins execute arbitrary code.** When plugins are enabled, the agent can create and run Python code on your machine with full server privileges. Review agent-generated plugins before loading them.
**Writes affect real hardware.** A bad memory write or flash operation can brick a device, wipe calibration data, or trigger unintended behavior. Consider what the agent can reach.
**Use tool approval deliberately.** When your MCP client prompts you to approve a tool call, consider whether you want to allow it once or always.
This software is provided as-is under the MIT License. You are responsible for what the agent does with your hardware.
---
## License
This project is licensed under the MIT License — see [LICENSE](https://github.com/es617/dbgprobe-mcp-server/blob/main/LICENSE) for details.