# Fourier N1 Description (MJCF)
> [!IMPORTANT]
> Requires MuJoCo 2.2.2 or later.
## Changelog
See [CHANGELOG.md](./CHANGELOG.md) for a full history of changes.
## Overview
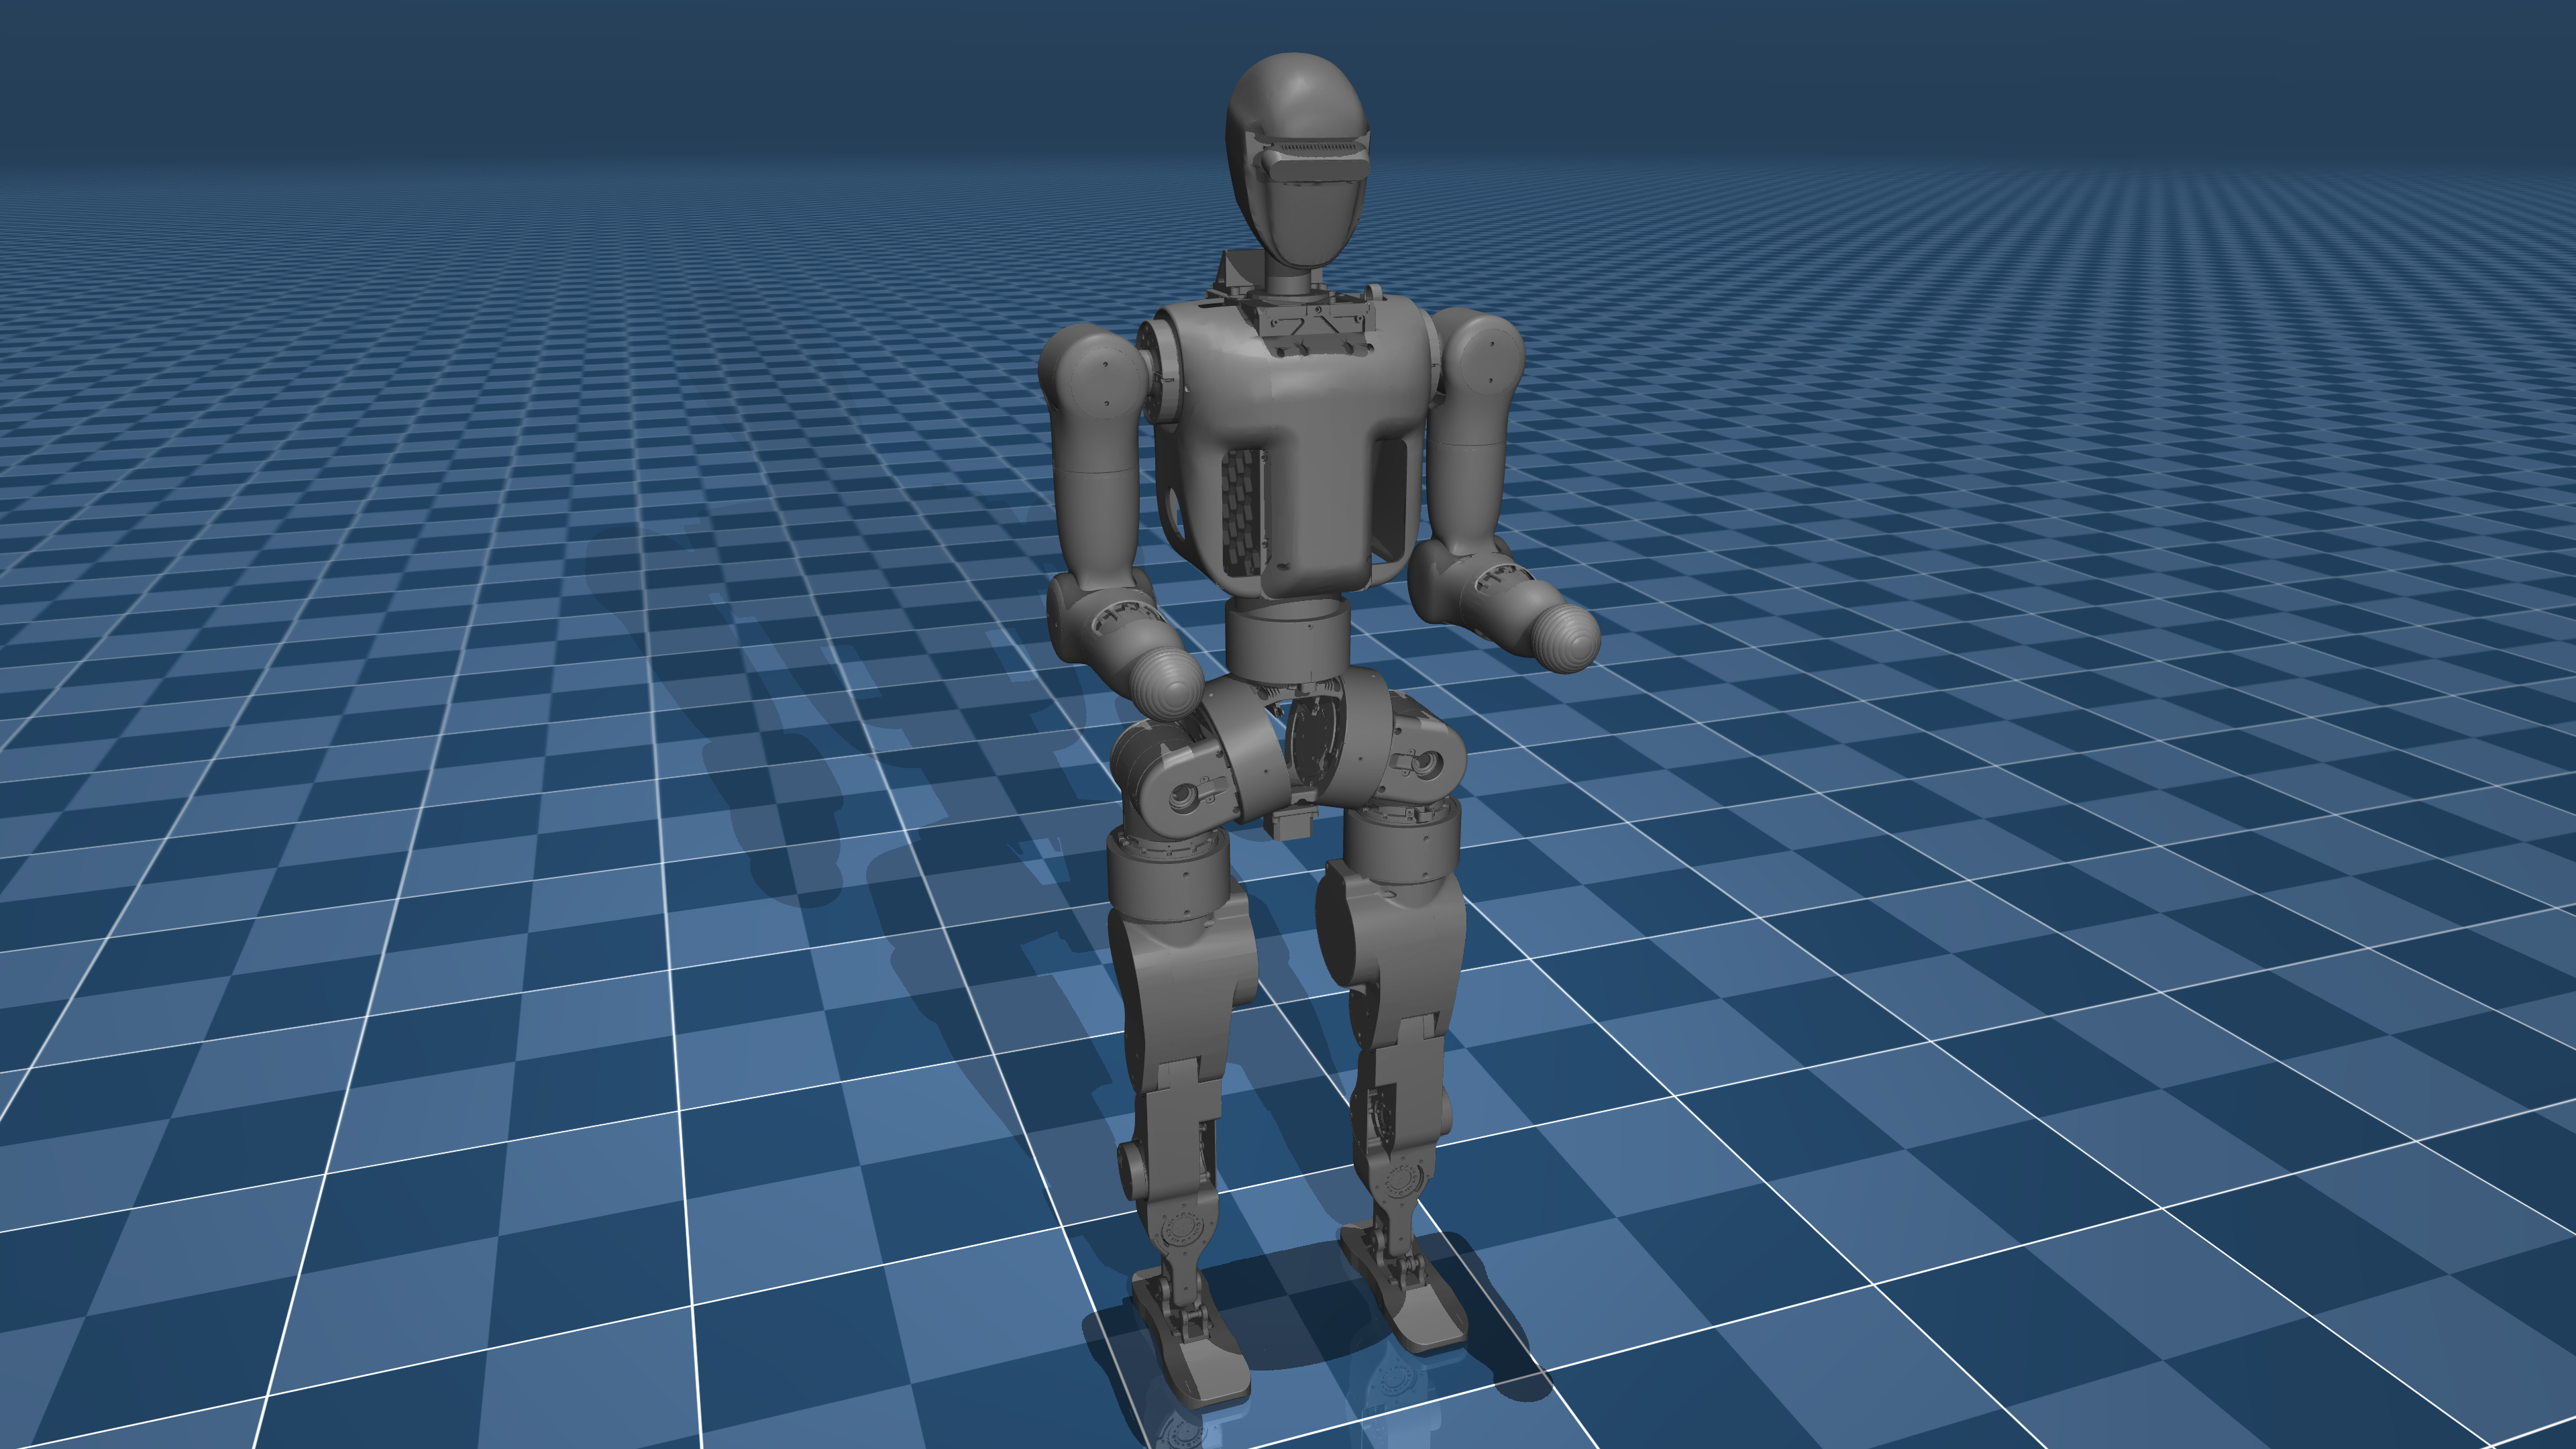
This package contains a simplified robot description (MJCF) of the
[Fourier N1 Humanoid Robot](https://www.fftai.cn/open-source/18)
developed by
[Fourier](https://www.fftai.com).
It is derived from the
[Fourier N1 URDF Description](https://github.com/FFTAI/Wiki-GRx-Models).
## MJCF derivation steps
1. Started from `N1_raw.urdf` in [Fourier N1 URDF Description](https://github.com/FFTAI/Wiki-GRx-Models).
- Commit: `f29a87905bdcfc32fdac9c5342644630fd27156a`
2. Loaded the URDF into MuJoCo and saved a corresponding MJCF.
3. Manually edited the MJCF to extract common properties into the `` section.
4. Manually edited the `` section to include the textures and meshes.
5. Manually added actuators.
6. Manually added sensors.
7. Added `scene.xml` which includes the robot, with a textured groundplane, skybox, and haze.
8. Renamed all STL files from `*.STL` to `*.stl`.
More information can be found [here](https://github.com/FFTAI/wiki-grx-mjcf).
## License
This model is released under an [Apache-2.0 License](LICENSE).