


 | Unitree H1 | 19 | [BSD-3-Clause](unitree_h1/LICENSE) |
|
 | Robotis OP3 | 20 | [Apache-2.0](robotis_op3/LICENSE) |
|
 | Unitree G1 | 29 | [BSD-3-Clause](unitree_g1/LICENSE) |
|
 | TALOS | 44 | [Apache-2.0](pal_talos/LICENSE) |
|
 | Booster T1 | 23 | [Apache-2.0](booster_t1/LICENSE) |
|
 | ToddlerBot 2XC | 44 | [MIT](toddlerbot_2xc/LICENSE) |
|
 | PNDbotics Adam_lite | 25 | [MIT](pndbotics_adam_lite/LICENSE) |
|
 | Apptronik Apollo | 32 | [Apache-2.0](apptronik_apollo/LICENSE) |
|
 | Berkeley Humanoid | 12 | [BSD-3-Clause](berkeley_humanoid/LICENSE) |
|
 | Fourier N1 | 23 | [Apache-2.0](fourier_n1/LICENSE) |
|
 | ToddlerBot 2XM | 44 | [MIT](toddlerbot_2xm/LICENSE) |
**Quadrupeds.**
| Preview | Name | DoFs | License |
|:---:|---|---|---|
|
 | Unitree A1 | 12 | [BSD-3-Clause](unitree_a1/LICENSE) |
|
 | Google Barkour v0 | 12 | [Apache-2.0](google_barkour_v0/LICENSE) |
|
 | ANYmal B | 12 | [BSD-3-Clause](anybotics_anymal_b/LICENSE) |
|
 | Unitree Go1 | 12 | [BSD-3-Clause](unitree_go1/LICENSE) |
|
 | ANYmal C | 12 | [BSD-3-Clause](anybotics_anymal_c/LICENSE) |
|
 | Google Barkour vB | 12 | [Apache-2.0](google_barkour_vb/LICENSE) |
|
 | Unitree Go2 | 12 | [BSD-3-Clause](unitree_go2/LICENSE) |
|
 | Boston Dynamics Spot | 19 | [BSD-3-Clause](boston_dynamics_spot/LICENSE) |
**Bipeds.**
| Preview | Name | DoFs | License |
|:---:|---|---|---|
|
 | Agility Cassie | 28 | [MIT](agility_cassie/LICENSE) |
**Biomechanical.**
| Preview | Name | DoFs | License |
|:---:|---|---|---|
|
 | Flybody | 102 | [Apache-2.0](flybody/LICENSE) |
|
 | IIT SoftFoot | 92 | [BSD-3-Clause](iit_softfoot/LICENSE) |
|
 | MS-Human-700 | 85 | [Apache-2.0](ms_human_700/LICENSE) |
**Dual Arms.**
| Preview | Name | DoFs | License |
|:---:|---|---|---|
|
 | ALOHA | 16 | [BSD-3-Clause](aloha/LICENSE) |
**Mobile Manipulators.**
| Preview | Name | DoFs | License |
|:---:|---|---|---|
|
 | Google Robot | 9 | [Apache-2.0](google_robot/LICENSE) |
|
 | Hello Robot Stretch 2 | 17 | [BSD-3-Clause-Clear](hello_robot_stretch/LICENSE) |
|
 | Stanford TidyBot | 18 | [MIT](stanford_tidybot/LICENSE) |
|
 | Hello Robot Stretch 3 | 20 | [Apache-2.0](hello_robot_stretch_3/LICENSE) |
|
 | TIAGo | 22 | [Apache-2.0](pal_tiago/LICENSE) |
|
 | TIAGo++ | 25 | [Apache-2.0](pal_tiago_dual/LICENSE) |
**Drones.**
| Preview | Name | DoFs | License |
|:---:|---|---|---|
|
 | Skydio X2 | 0 | [Apache-2.0](skydio_x2/LICENSE) |
|
 | Bitcraze Crazyflie 2 | 0 | [MIT](bitcraze_crazyflie_2/LICENSE) |
**Arms.**
| Preview | Name | DoFs | License |
|:---:|---|---|---|
|
 | Franka Emika Panda | 9 | [Apache-2.0](franka_emika_panda/LICENSE) |
|
 | Franka Robotics FR3 | 7 | [Apache-2.0](franka_fr3/LICENSE) |
|
 | Lite 6 | 6 | [BSD-3-Clause](ufactory_lite6/LICENSE) |
|
 | Unitree Z1 | 6 | [BSD-3-Clause](unitree_z1/LICENSE) |
|
 | Universal Robots UR5e | 6 | [BSD-3-Clause](universal_robots_ur5e/LICENSE) |
|
 | Rethink Robotics Sawyer | 7 | [Apache-2.0](rethink_robotics_sawyer/LICENSE) |
|
 | Universal Robots UR10e | 6 | [BSD-3-Clause](universal_robots_ur10e/LICENSE) |
|
 | KUKA LBR iiwa 14 | 7 | [BSD-3-Clause](kuka_iiwa_14/LICENSE) |
|
 | ViperX 300 6DOF | 8 | [BSD-3-Clause](trossen_vx300s/LICENSE) |
|
 | xArm7 | 13 | [BSD-3-Clause](ufactory_xarm7/LICENSE) |
|
 | Kinova Gen3 | 7 | [BSD-3-Clause](kinova_gen3/LICENSE) |
|
 | AgileX PiPER | 8 | [MIT](agilex_piper/LICENSE) |
|
 | Flexiv Robotics Rizon4 | 7 | [Apache-2.0](flexiv_rizon4/LICENSE) |
|
 | ARX L5 | 8 | [BSD-3-Clause](arx_l5/LICENSE) |
|
 | Flexiv Robotics Rizon4S | 7 | [Apache-2.0](flexiv_rizon4s/LICENSE) |
|
 | WidowX 250 6DOF | 8 | [BSD-3-Clause](trossen_wx250s/LICENSE) |
|
 | Standard Open Arm-100 5DOF - Version 1.3 | 6 | [Apache-2.0](trs_so_arm100/LICENSE) |
|
 | Low-Cost Robot Arm | 6 | [Apache-2.0](low_cost_robot_arm/LICENSE) |
|
 | Yet Another Manipulator (YAM) | 8 | [MIT](i2rt_yam/LICENSE) |
|
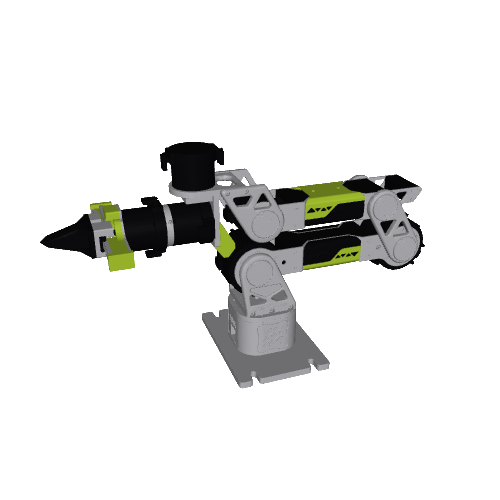 | Seeed Studio reBot DevArm | 8 | [MIT](seeed_rebot_devarm/LICENSE) |
**End-effectors.**
| Preview | Name | DoFs | License |
|:---:|---|---|---|
|
 | Panda Gripper | 2 | [Apache-2.0](franka_emika_panda/LICENSE) |
|
 | Allegro Hand V3 | 16 | [BSD-2-Clause](wonik_allegro/LICENSE) |
|
 | Shadow Hand E3M5 | 24 | [Apache-2.0](shadow_hand/LICENSE) |
|
 | Robotiq 2F-85 | 8 | [BSD-2-Clause](robotiq_2f85/LICENSE) |
|
 | xarm7 Gripper | 6 | [BSD-3-Clause](ufactory_xarm7/LICENSE) |
|
 | Shadow DEX-EE Hand | 12 | [Apache-2.0](shadow_dexee/LICENSE) |
|
 | Leap Hand | 16 | [MIT](leap_hand/LICENSE) |
|
 | UMI-Gripper | 8 | [MIT](umi_gripper/LICENSE) |
|
 | Sharpa Wave | 22 | [Apache-2.0](sharpa_wave/LICENSE) |
**Mobile Bases.**
| Preview | Name | DoFs | License |
|:---:|---|---|---|
|
 | Robot soccer kit omnidirectional | 64 | [MIT](robot_soccer_kit/LICENSE) |
**Miscellaneous.**
| Preview | Name | DoFs | License |
|:---:|---|---|---|
|
 | Realsense D435i | 0 | [Apache-2.0](realsense_d435i/LICENSE) |
## Citing Menagerie
If you use Menagerie in your work, please use the following citation:
```bibtex
@software{menagerie2022github,
author = {Zakka, Kevin and Tassa, Yuval and {MuJoCo Menagerie Contributors}},
title = {{MuJoCo Menagerie: A collection of high-quality simulation models for MuJoCo}},
url = {http://github.com/google-deepmind/mujoco_menagerie},
year = {2022},
}
```
## Acknowledgments
The models in this repository are based on third-party models designed by many talented people, and would not have been possible without their generous open-source contributions. We would like to acknowledge all the designers and engineers who made MuJoCo Menagerie possible.
We'd like to thank Pedro Vergani for his help with visuals and design.
The main effort required to make this repository publicly available was undertaken by [Kevin Zakka](https://kzakka.com/), with help from the Robotics Simulation team at Google DeepMind.
This project has also benefited from contributions by members of the broader community — see the [CONTRIBUTORS.md](./CONTRIBUTORS.md) for a full list.
## Changelog
For a summary of key updates across the repository, see the [global CHANGELOG.md](./CHANGELOG.md).
Each individual model also includes its own `CHANGELOG.md` file with model-specific updates, linked directly from the corresponding README.
## License and Disclaimer
XML and asset files in each individual model directory of this repository are
subject to different license terms. Please consult the `LICENSE` files under
each specific model subdirectory for the relevant license and copyright
information.
All other content is Copyright 2022 DeepMind Technologies Limited and licensed
under the Apache License, Version 2.0. A copy of this license is provided in the
top-level LICENSE file in this repository.
You can also obtain it from https://www.apache.org/licenses/LICENSE-2.0.
This is not an officially supported Google product.