# models — 3D-printed parts and CAD
## Full assembly
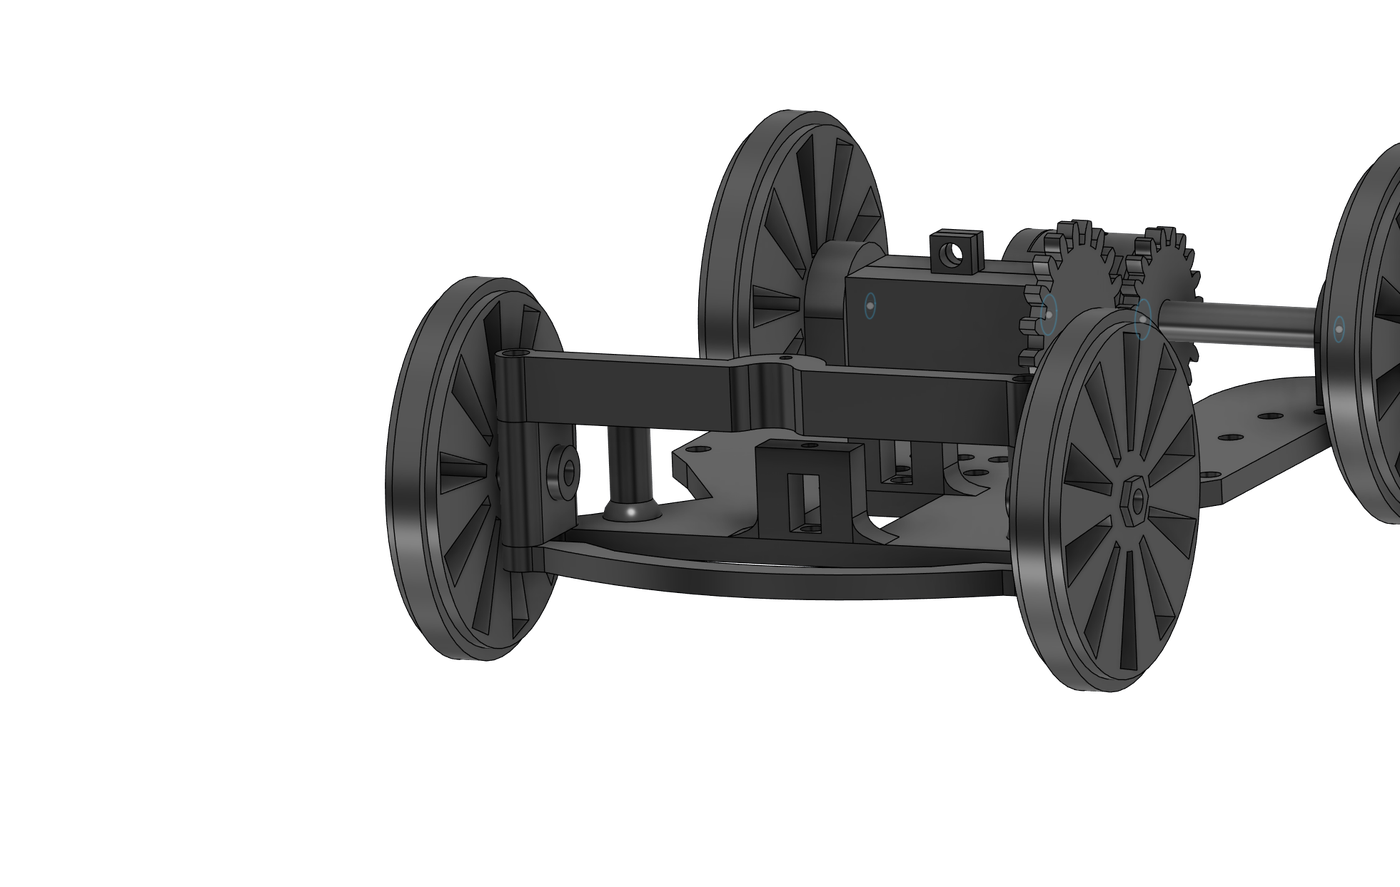
Front Ackermann steering axle on the left, rear differential axle with the N20
motor and gear cluster on the right.
## Front steering assembly
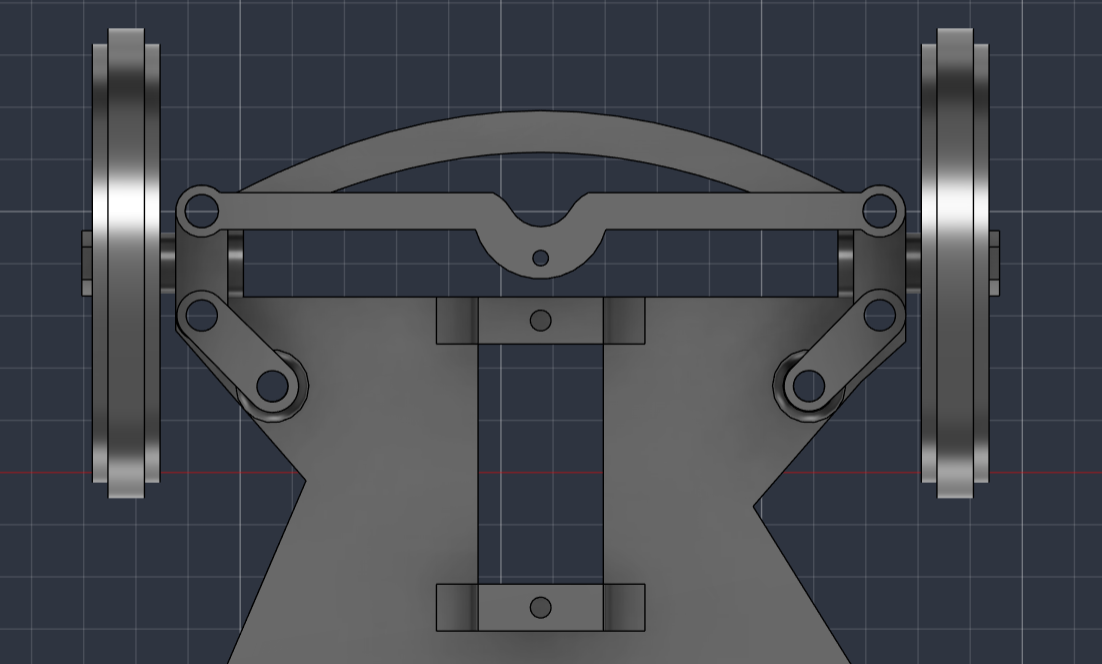
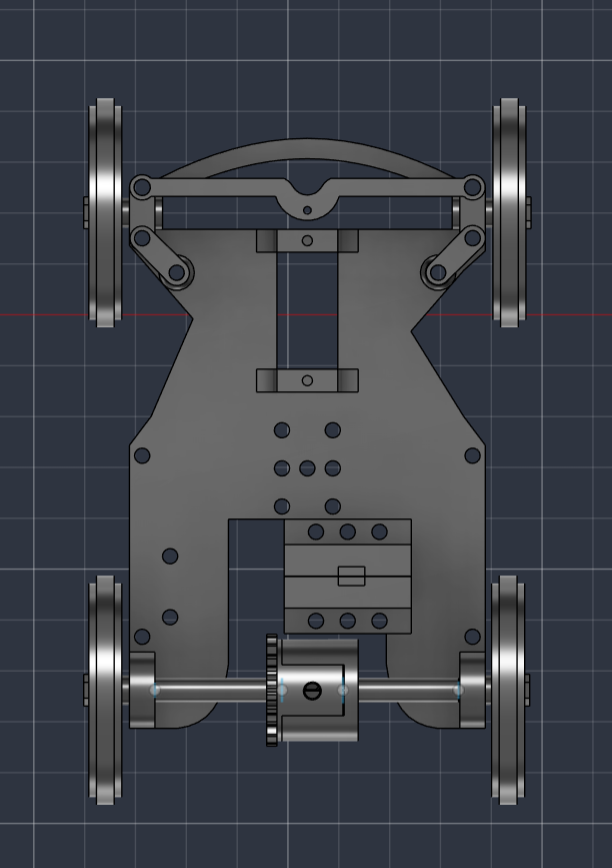
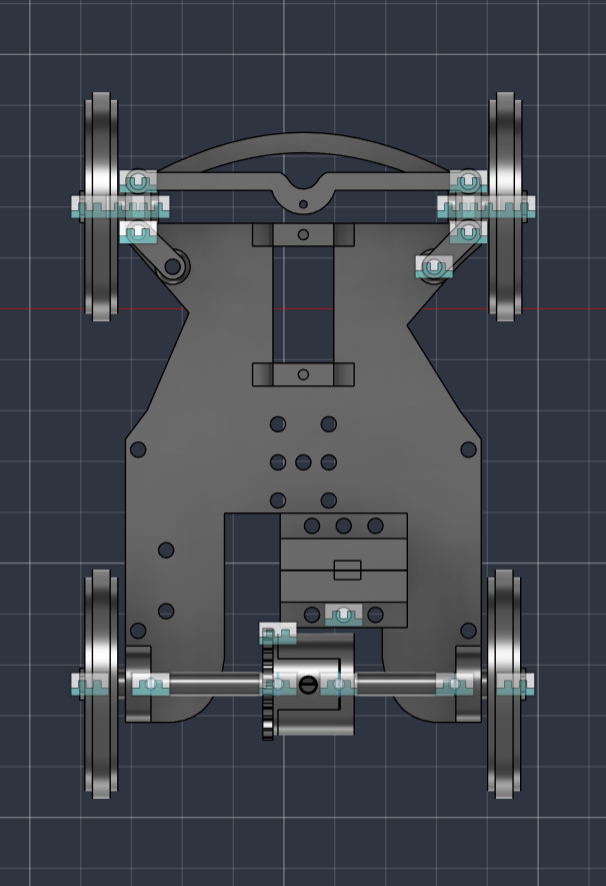
A single MG90S servo drives a central bell-crank through a tie-rod to both
steering knuckles, so the inner wheel turns more sharply than the outer one
through a corner. Mechanical limit **±35°**.
## Rear axle and differential
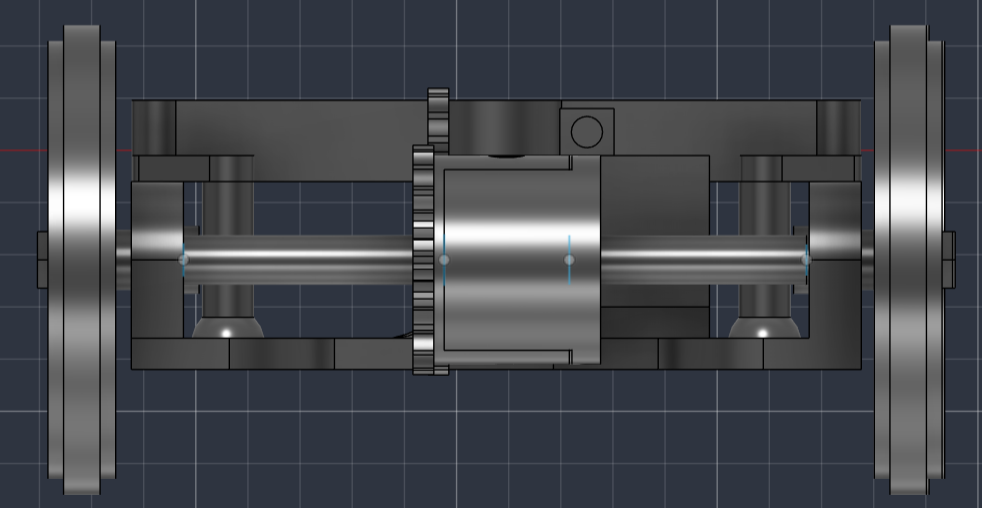
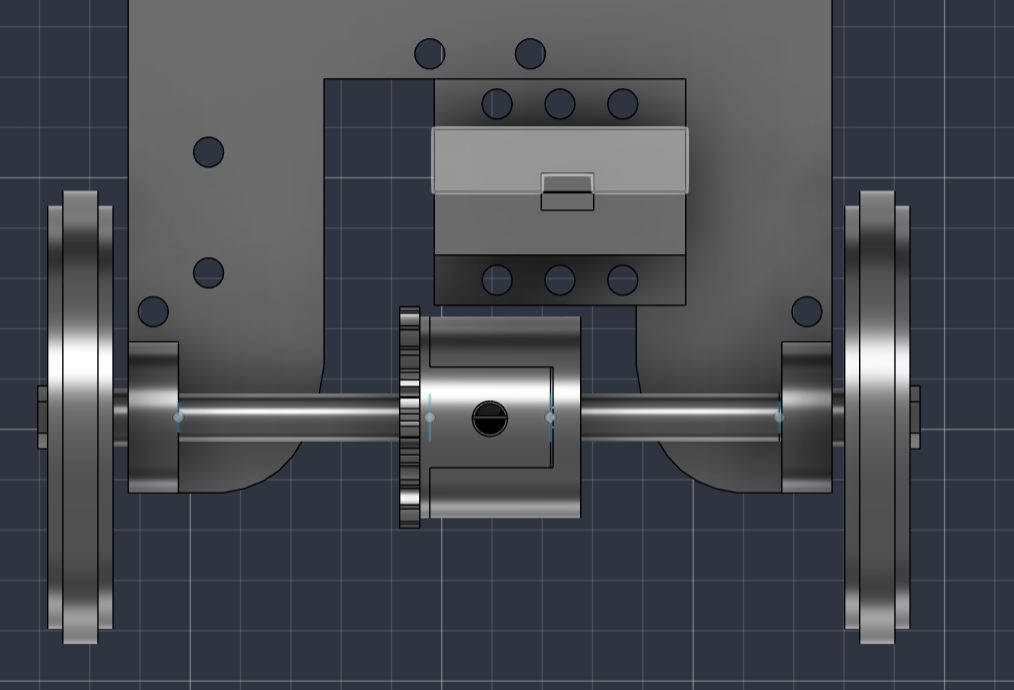
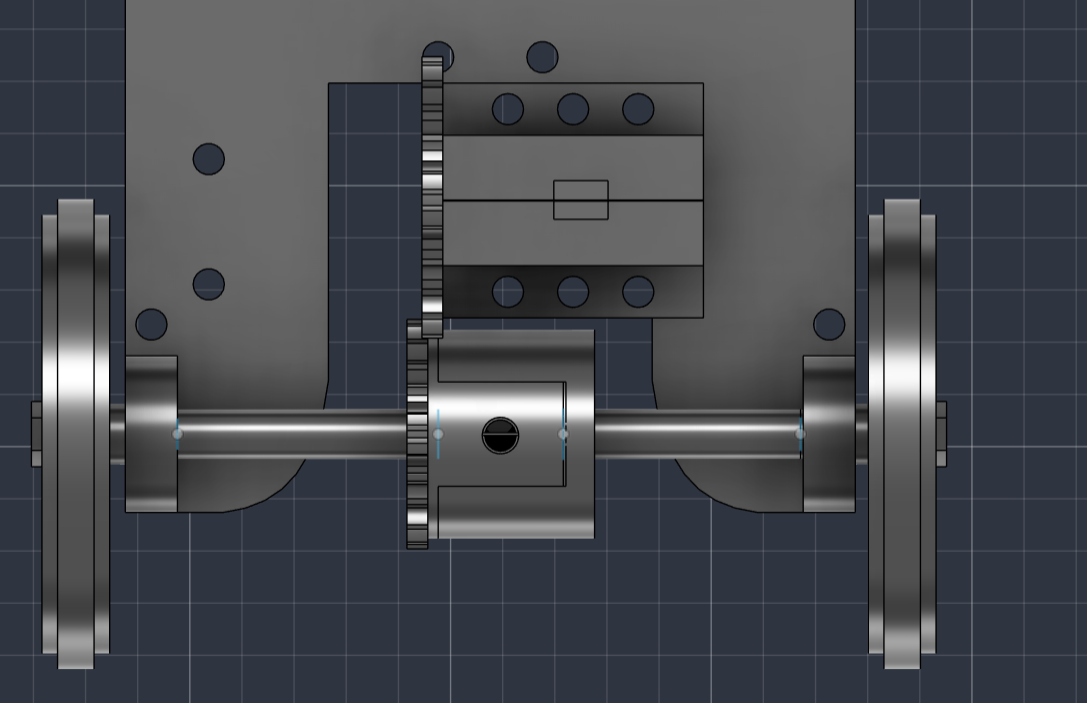
An **N20 gear motor (12 V, 200 rpm)** drives the axle through a **25:20 spur
pair (1.25:1)** into the differential. The differential lets the driven wheels
turn at different speeds through a corner, which is what allows the full ±35°
of steering — an earlier solid axle scrubbed and forced the software limit
down to ~8°. See [`../Documentation.pdf`](../Documentation.pdf).
## Chassis
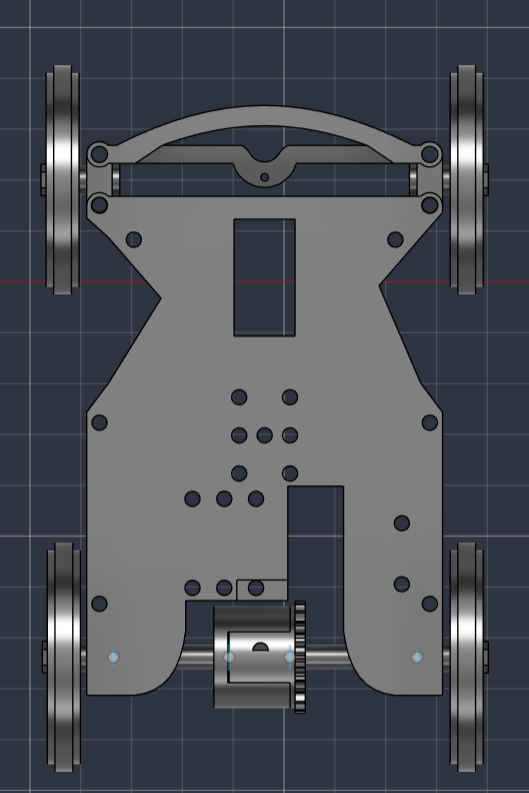
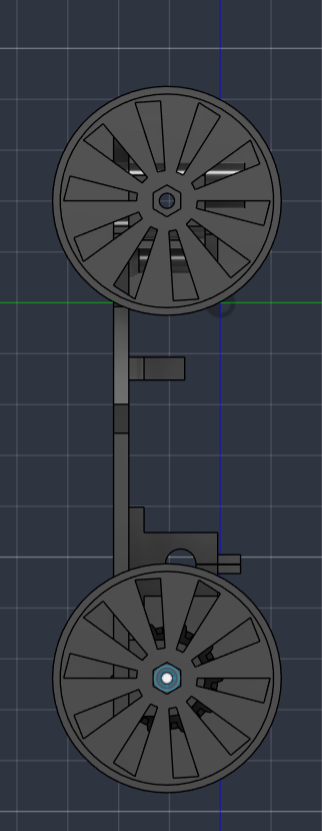
The base plate's hole grid carries the Raspberry Pi, the L9110S driver, the
buck converter and the battery holder; the camera mast bolts to the front.
## Manufacturing
| | |
|---|---|
| **CAD** | Fusion 360 |
| **Printer** | Bambu Lab A1 |
| **Material** | PLA+ Silk Silver |
## Bill of materials — 3D-printed parts
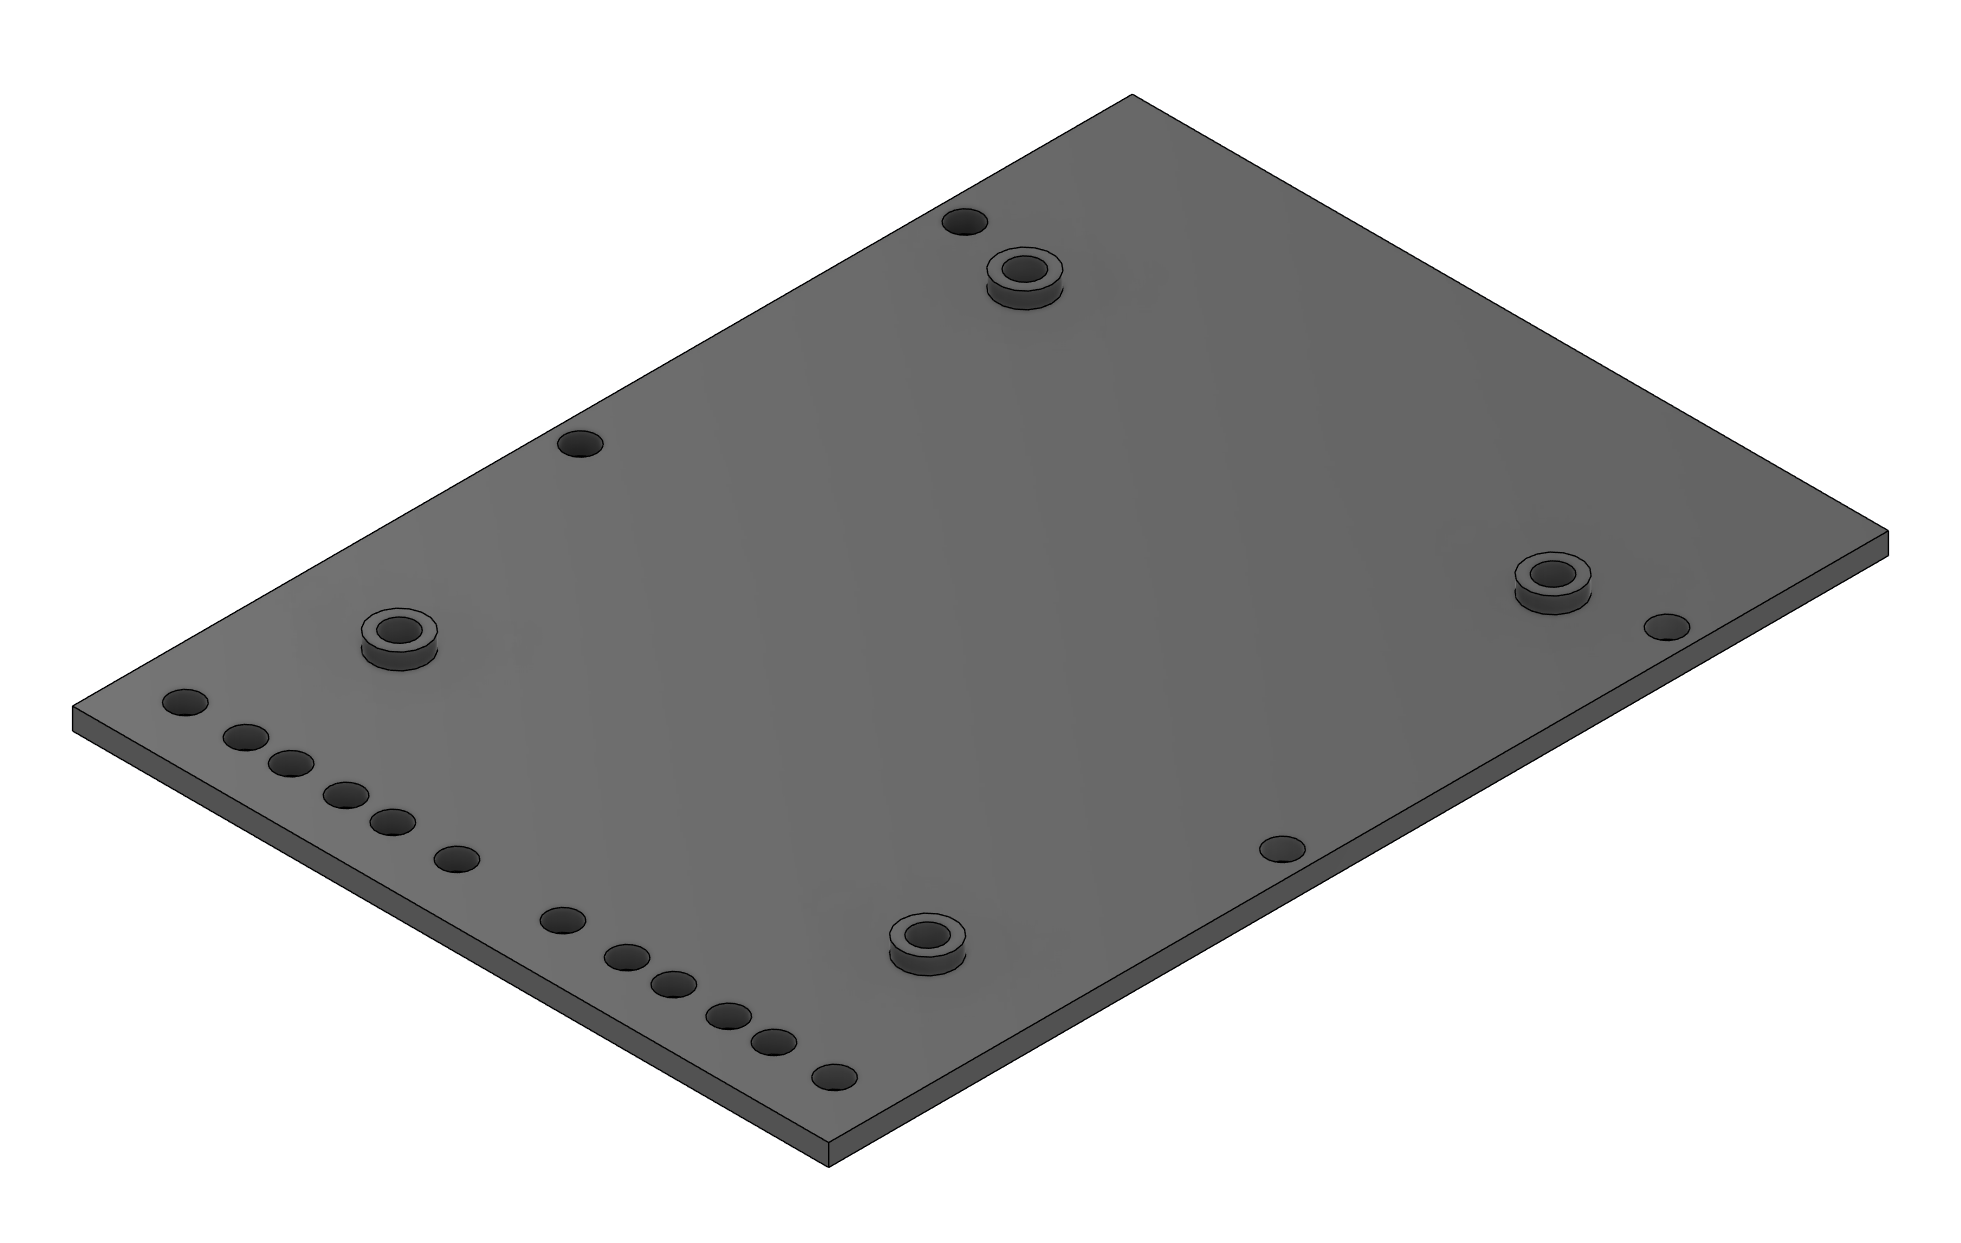
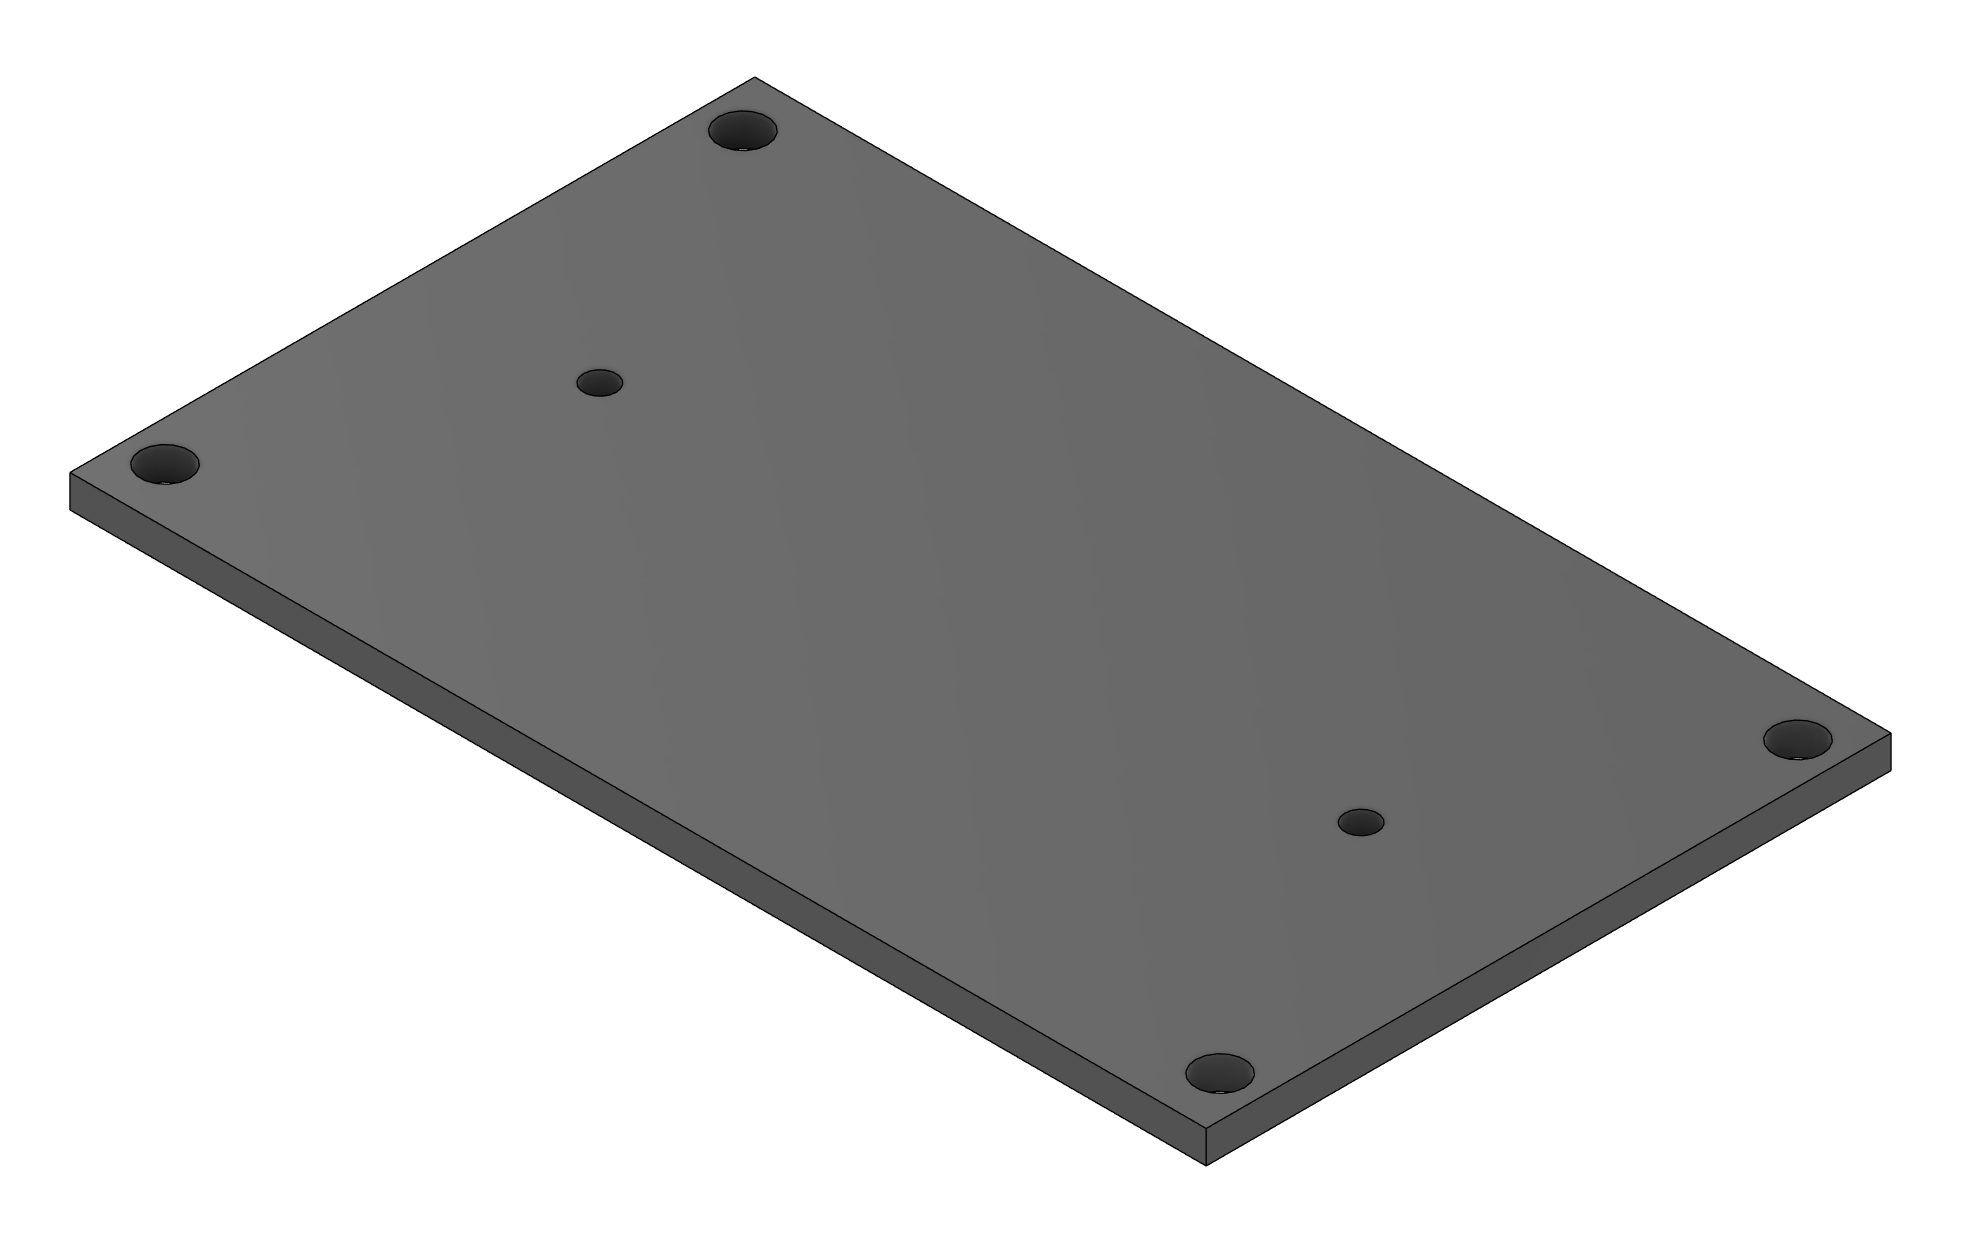
All printed parts, quantities, and whether each is a fixed or moving part
(from `3d-parts/Mechanical-BOM.docx`). All parts are **PLA+**.
| Part | Qty | Fixed / Moving | Photo |
|---|---|---|---|
| Base | 1 | Fixed | 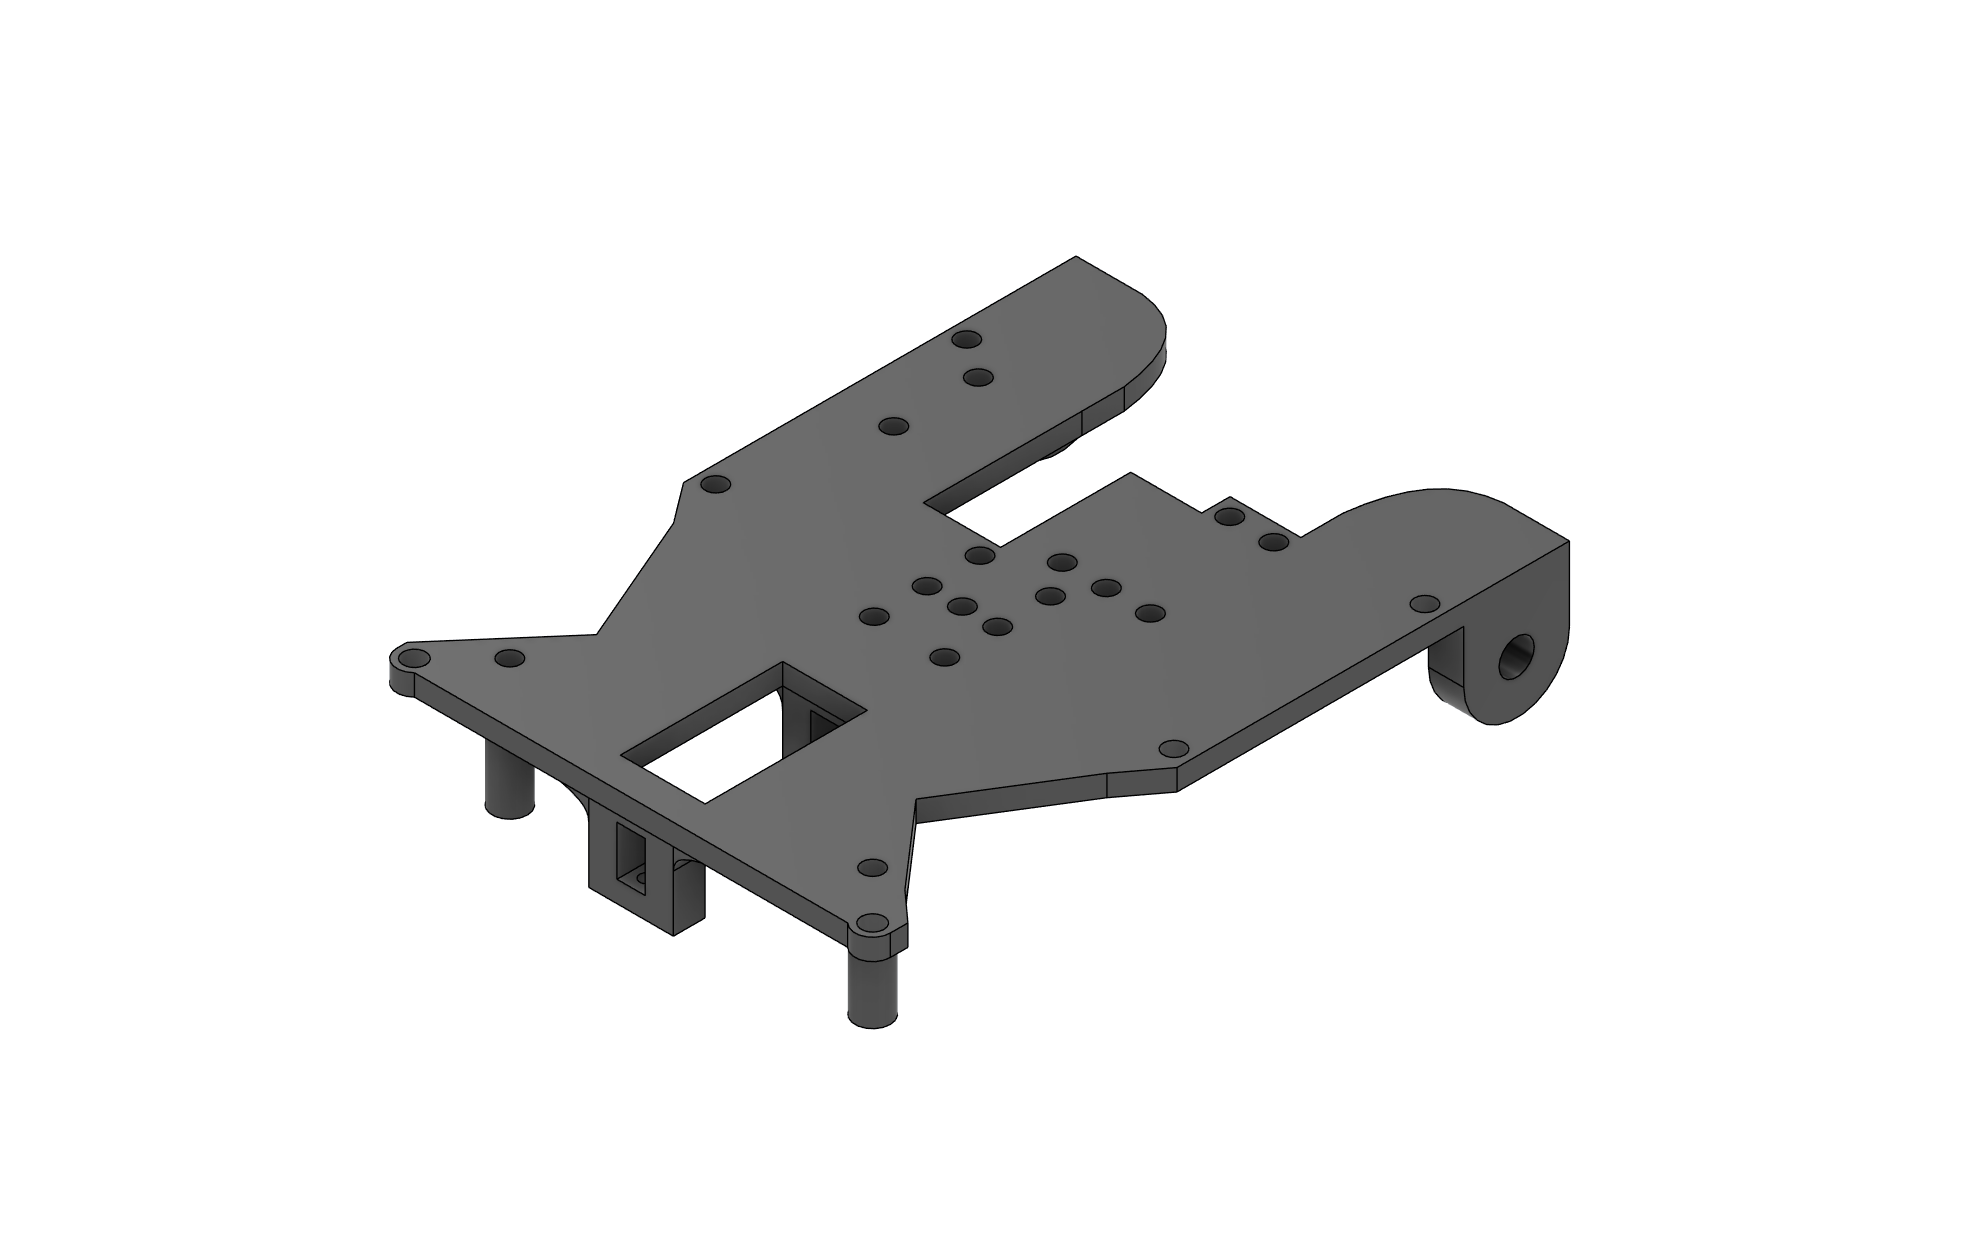 |
| Middle plate | 1 | Fixed |
 |
| Top plate | 1 | Fixed |
 |
| Camera holder | 1 | Fixed |
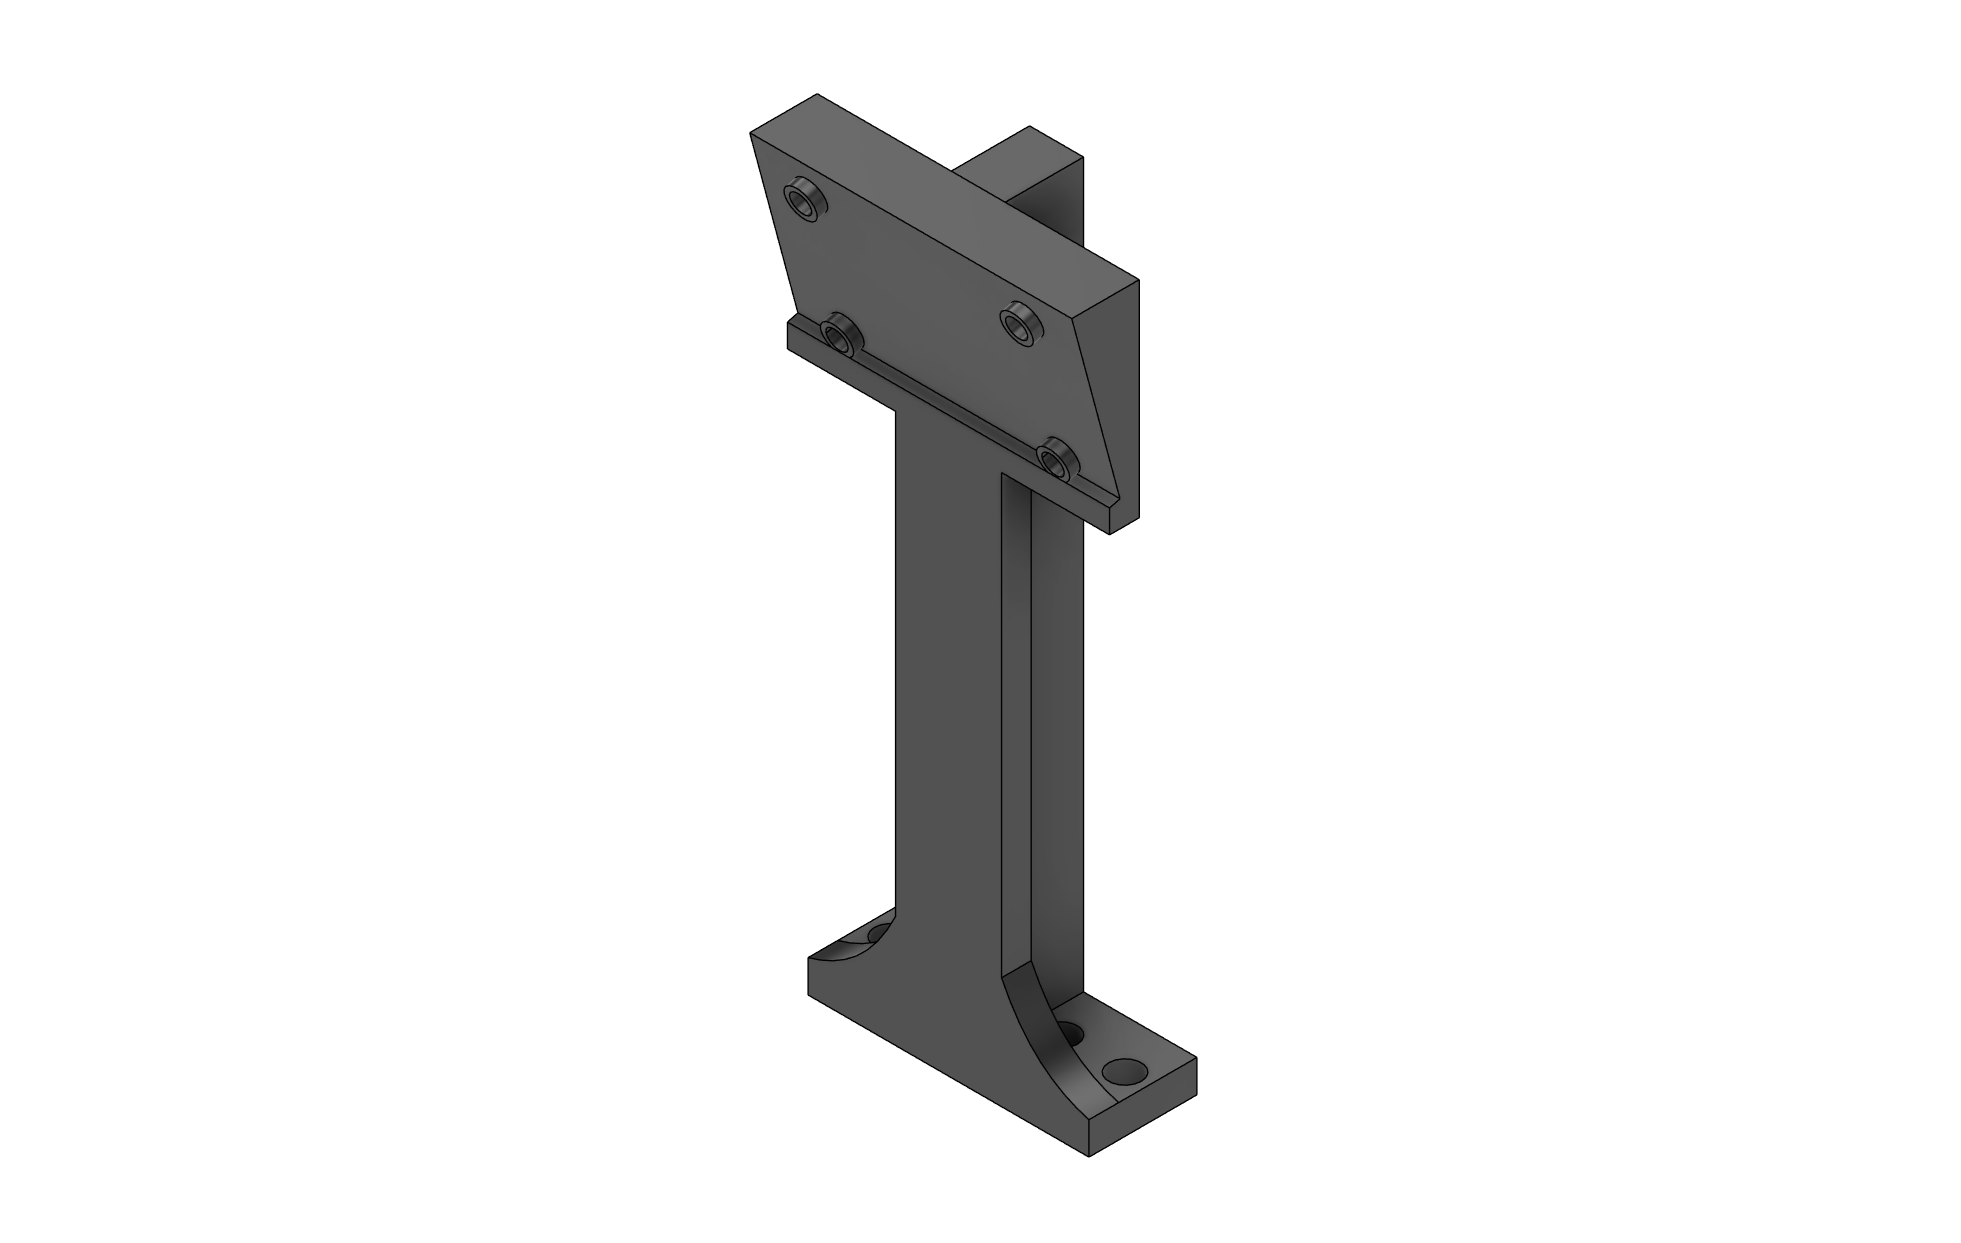 |
| Battery slider p1 | 1 | Fixed |
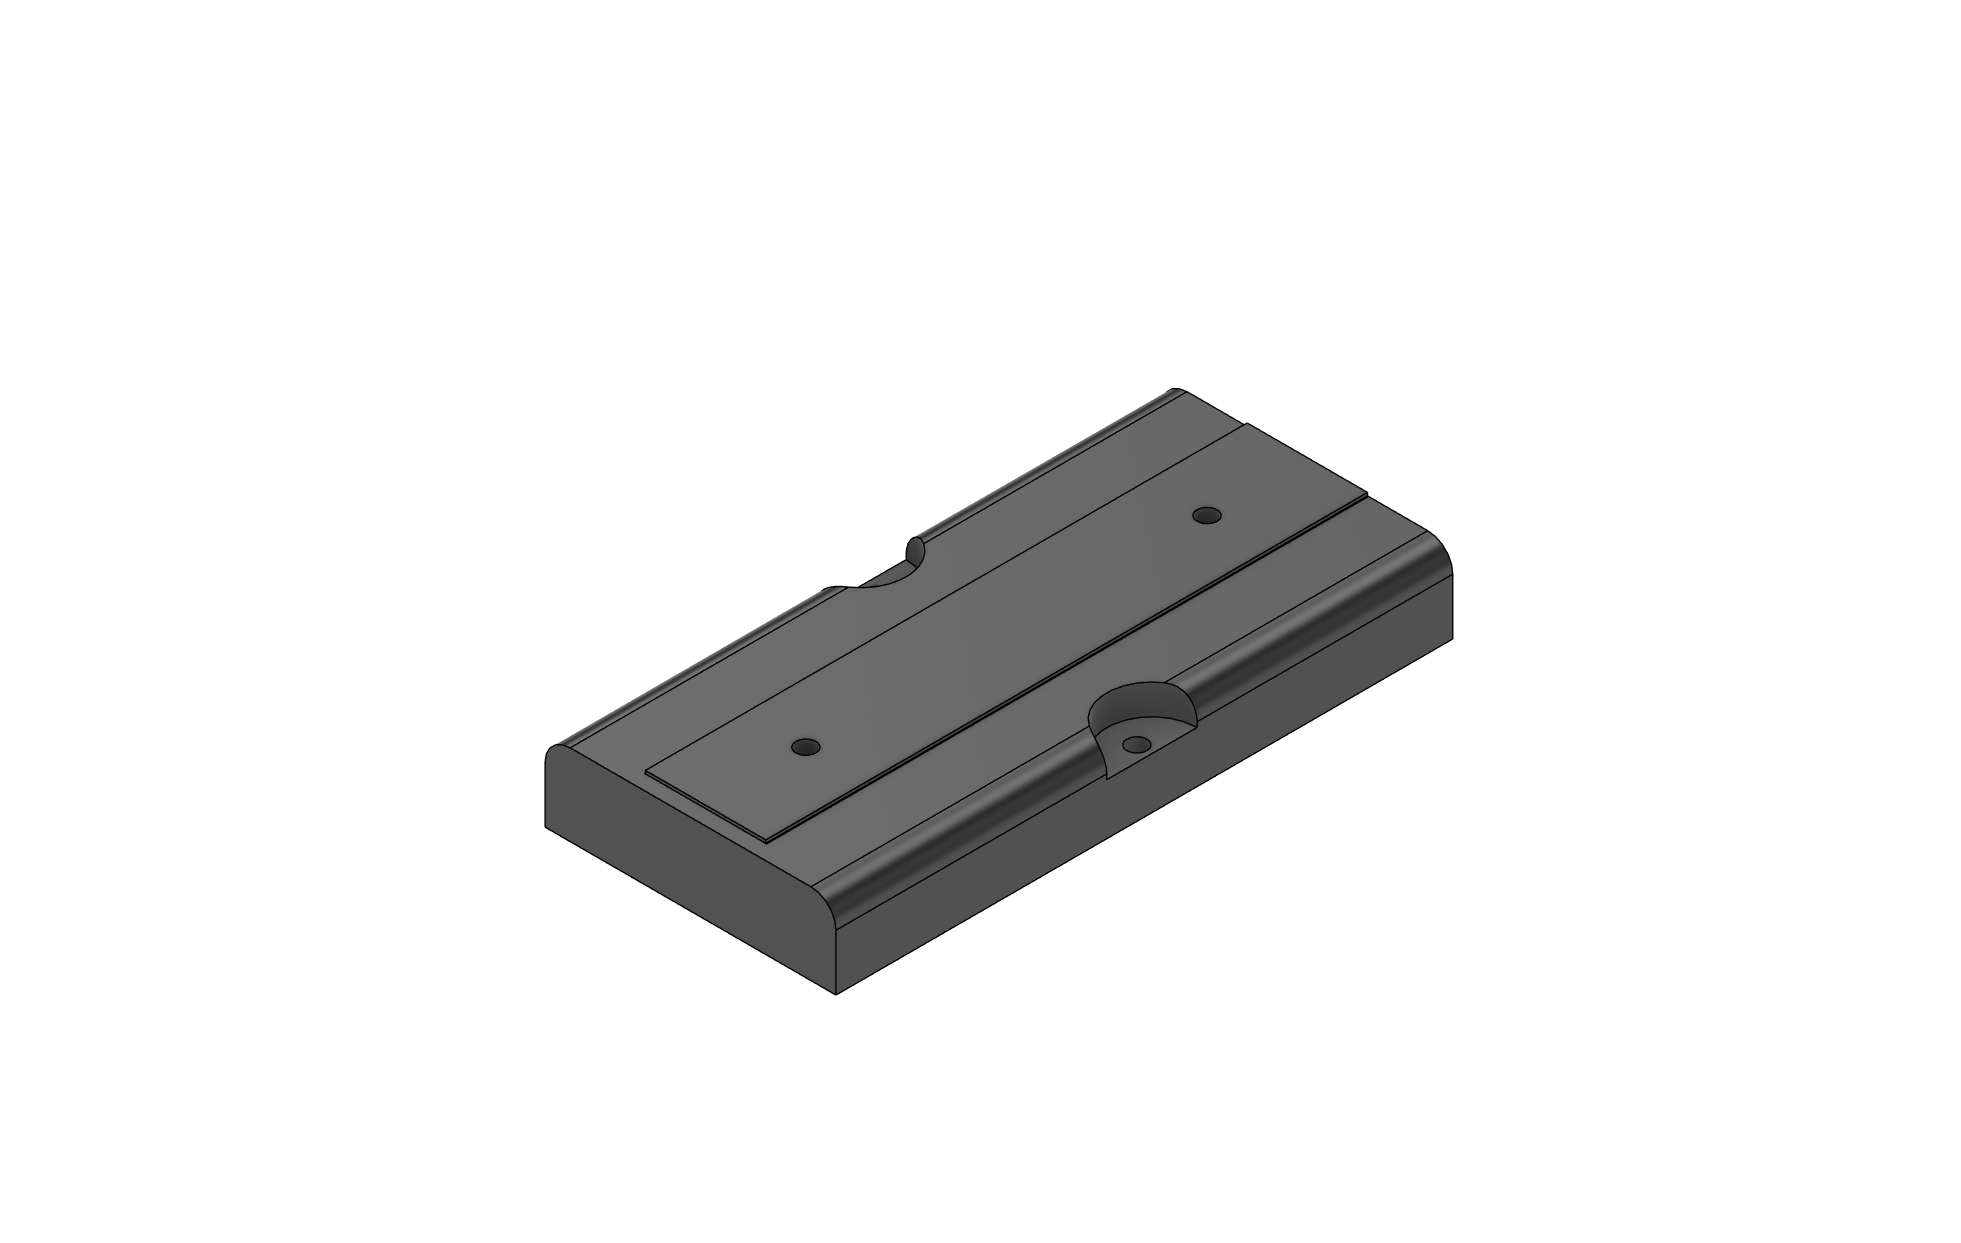 |
| Battery slider p2 | 1 | Moving | __ |
| N20 motor holder | 1 | Fixed |
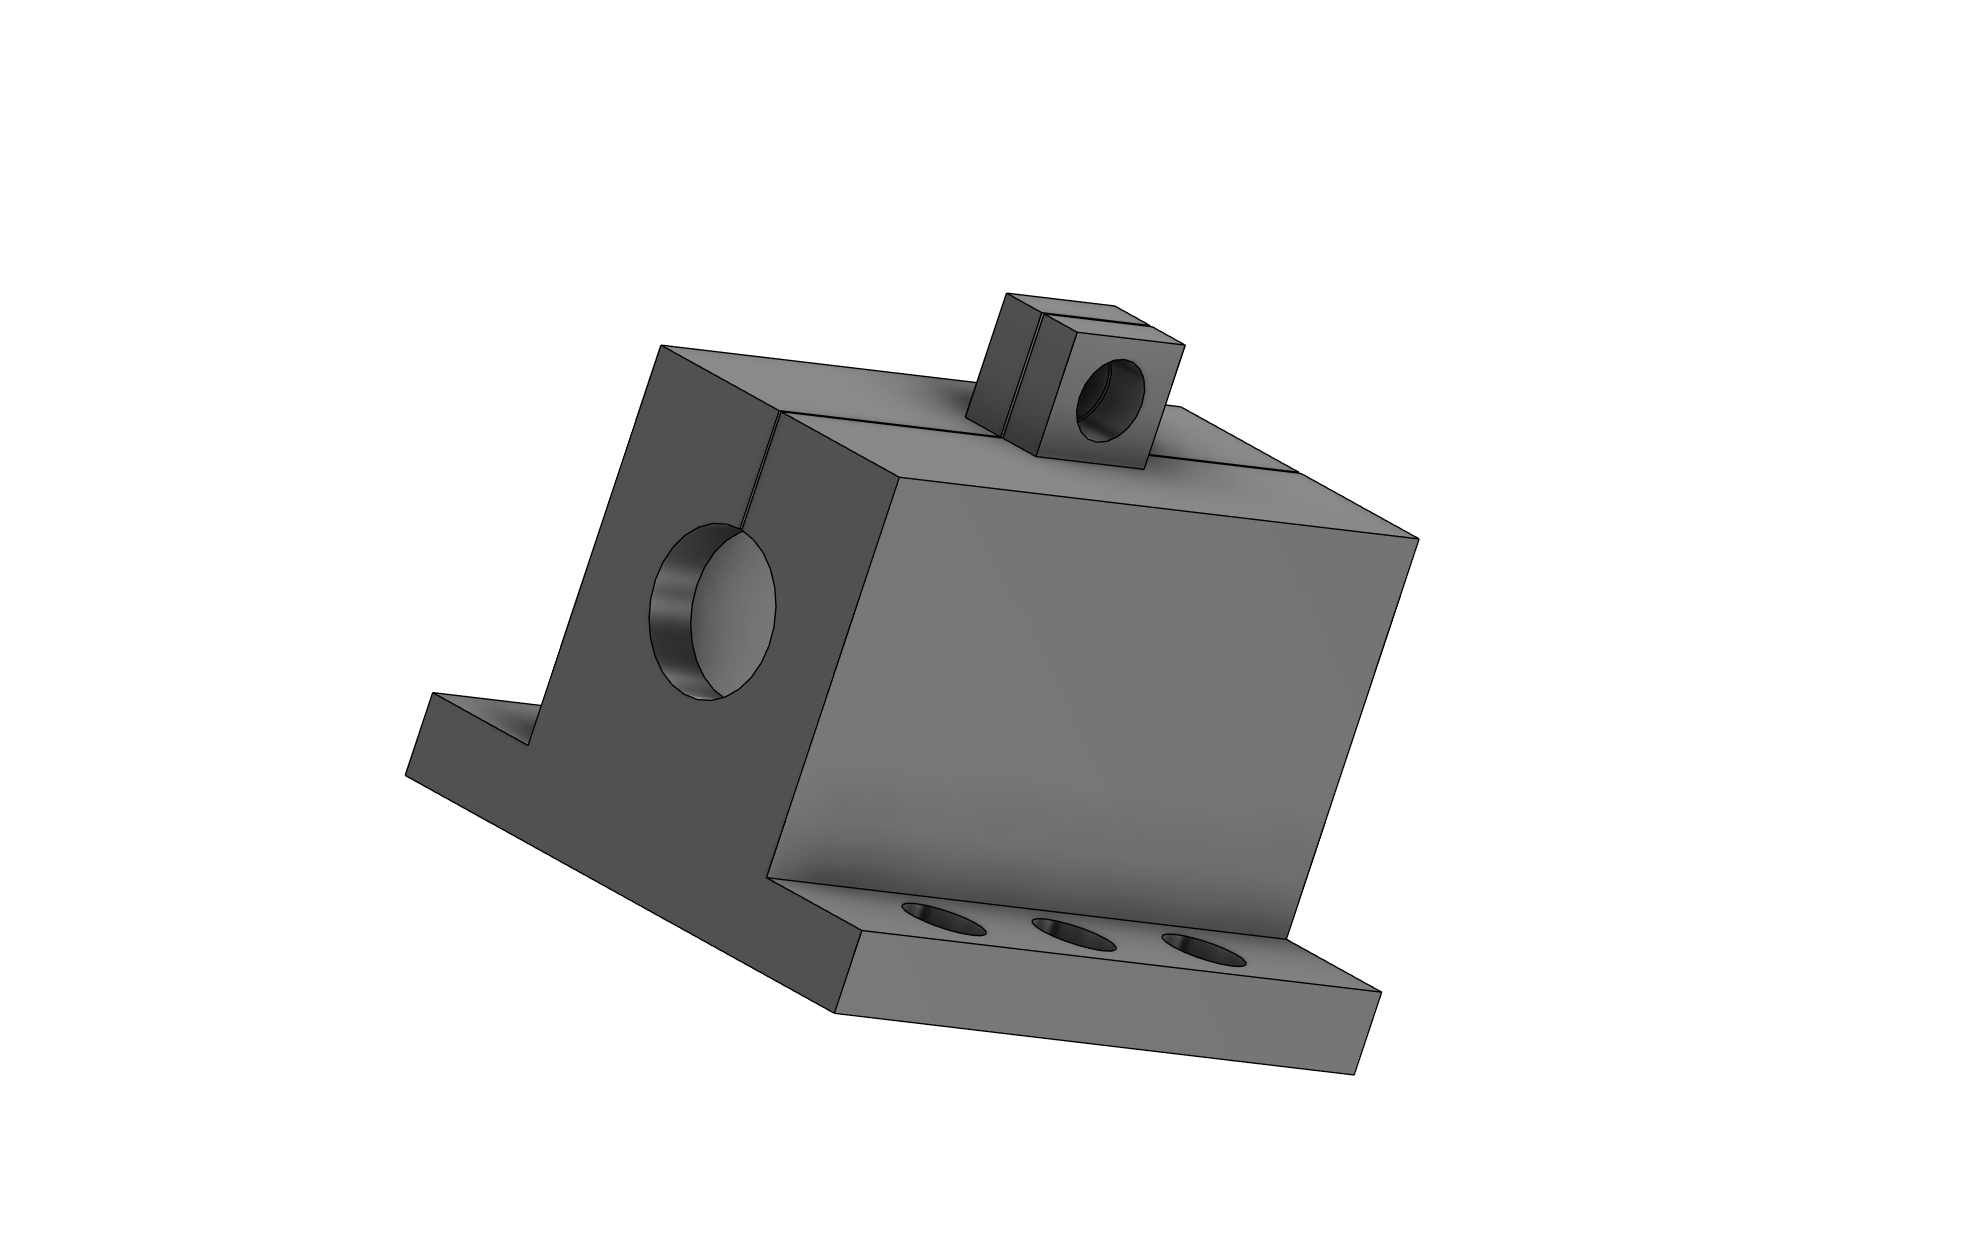 |
| N20 gear | 1 | Moving |
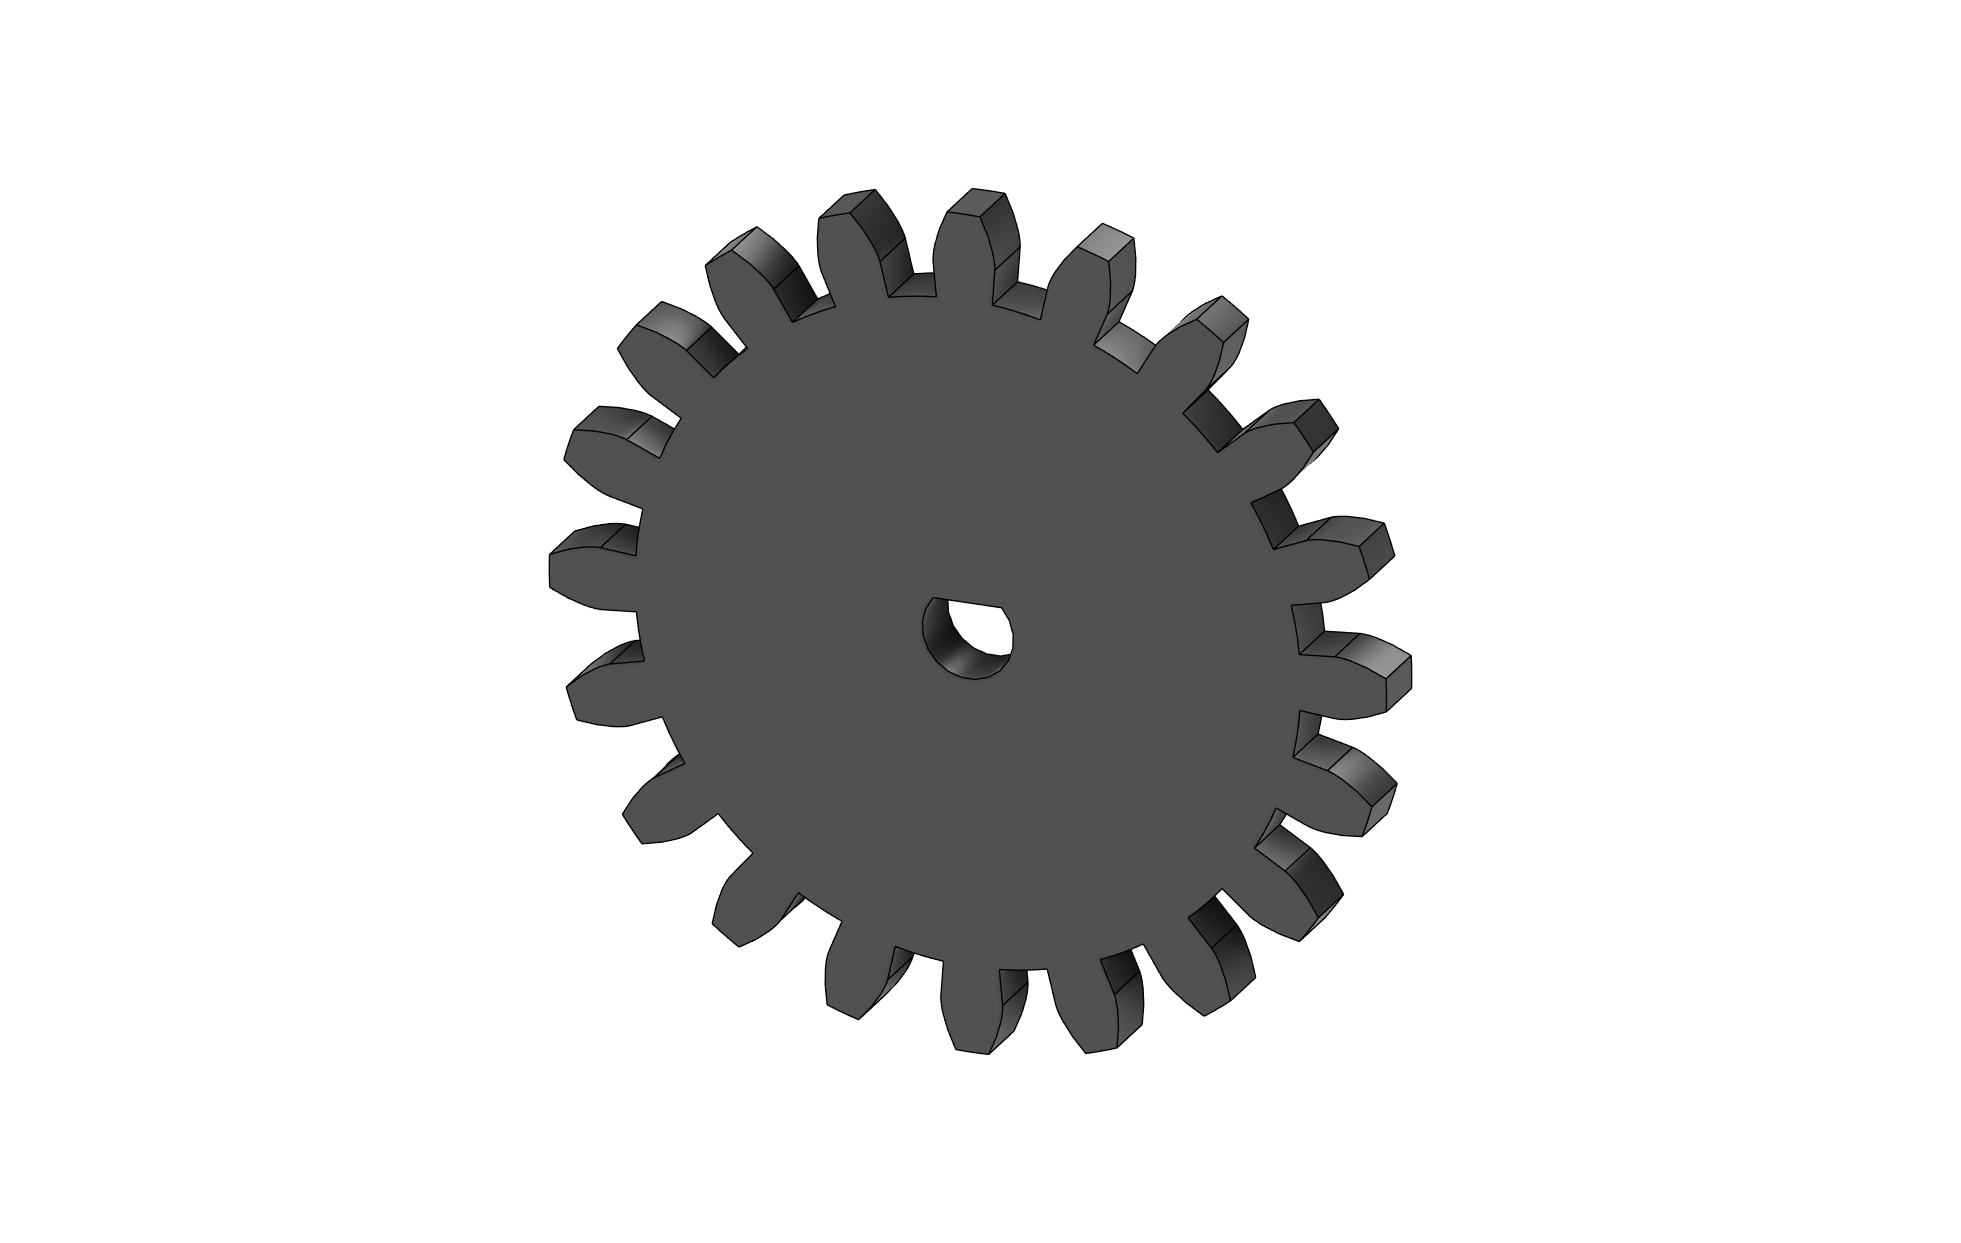 |
| Inner differential gear | 2 | Moving |
 |
| Outer differential gear | 1 | Moving |
 |
| Differential outer shell | 1 | Fixed |
 |
| Inner gear with long shaft | 1 | Moving |
 |
| Inner gear with short shaft | 1 | Moving |
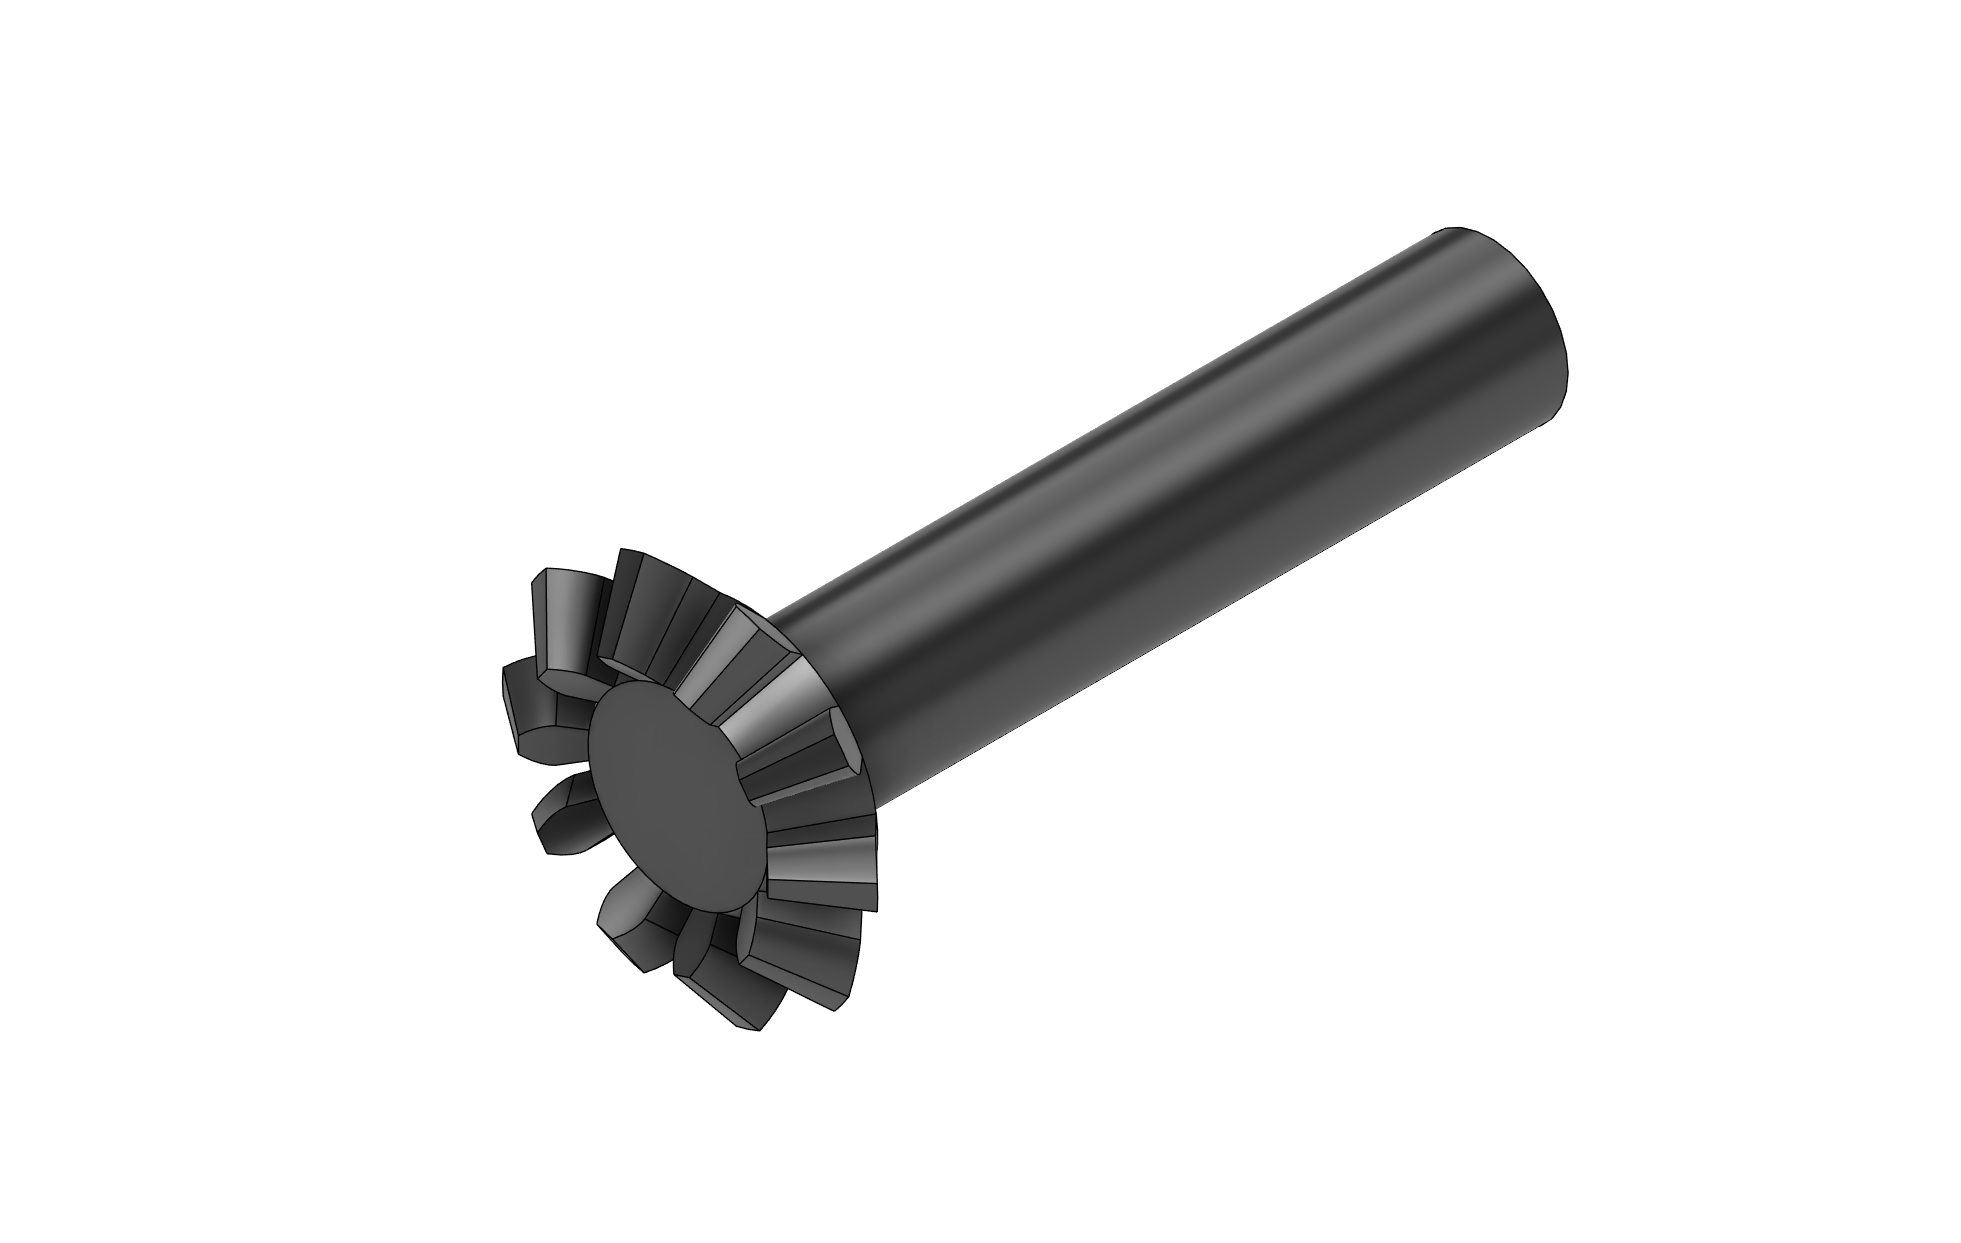 |
| Ring | 2 | Moving |
 |
| Steering base | 1 | Moving |
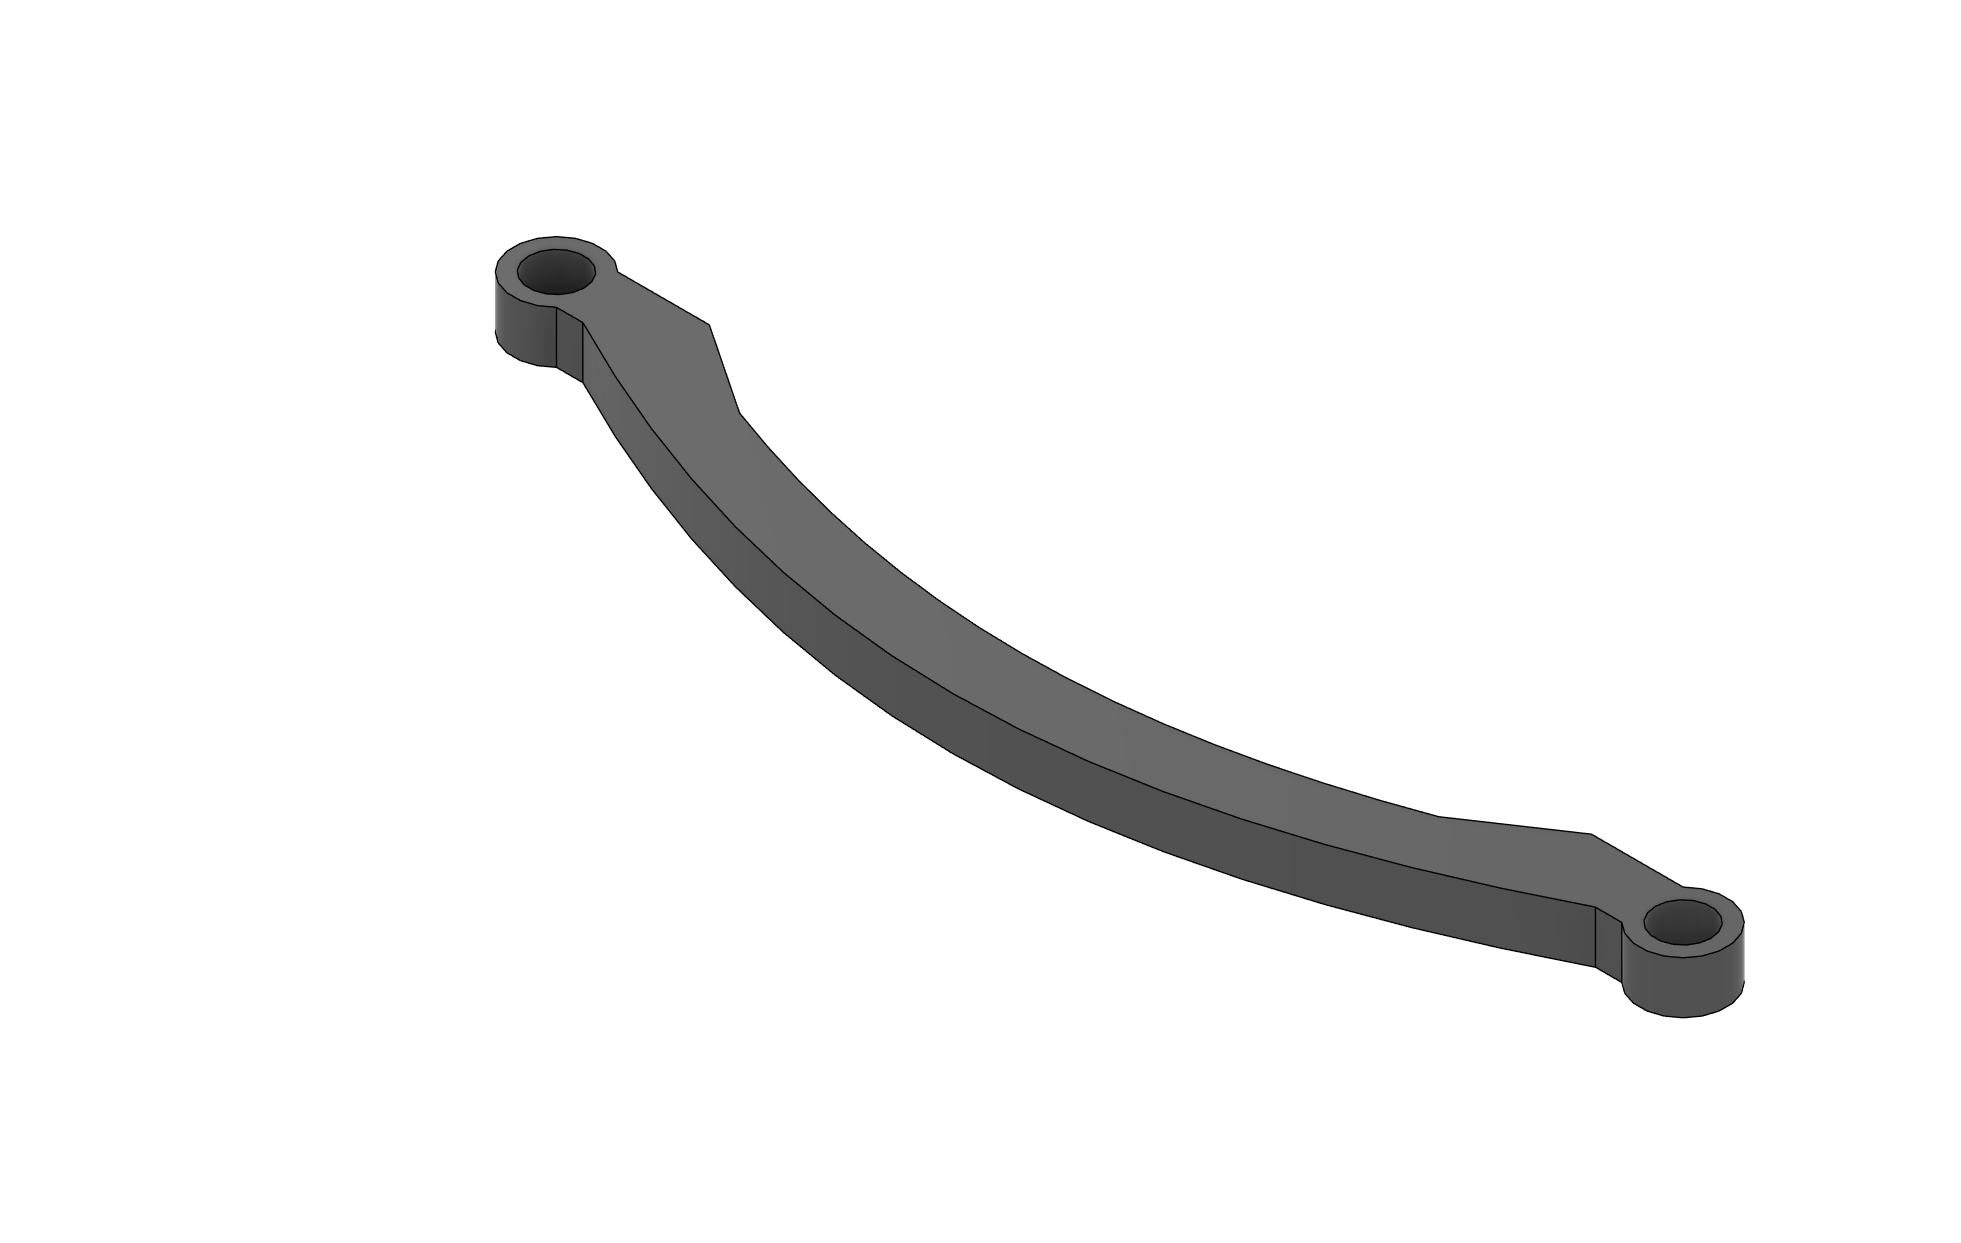 |
| Steering base servo mount | 1 | Moving |
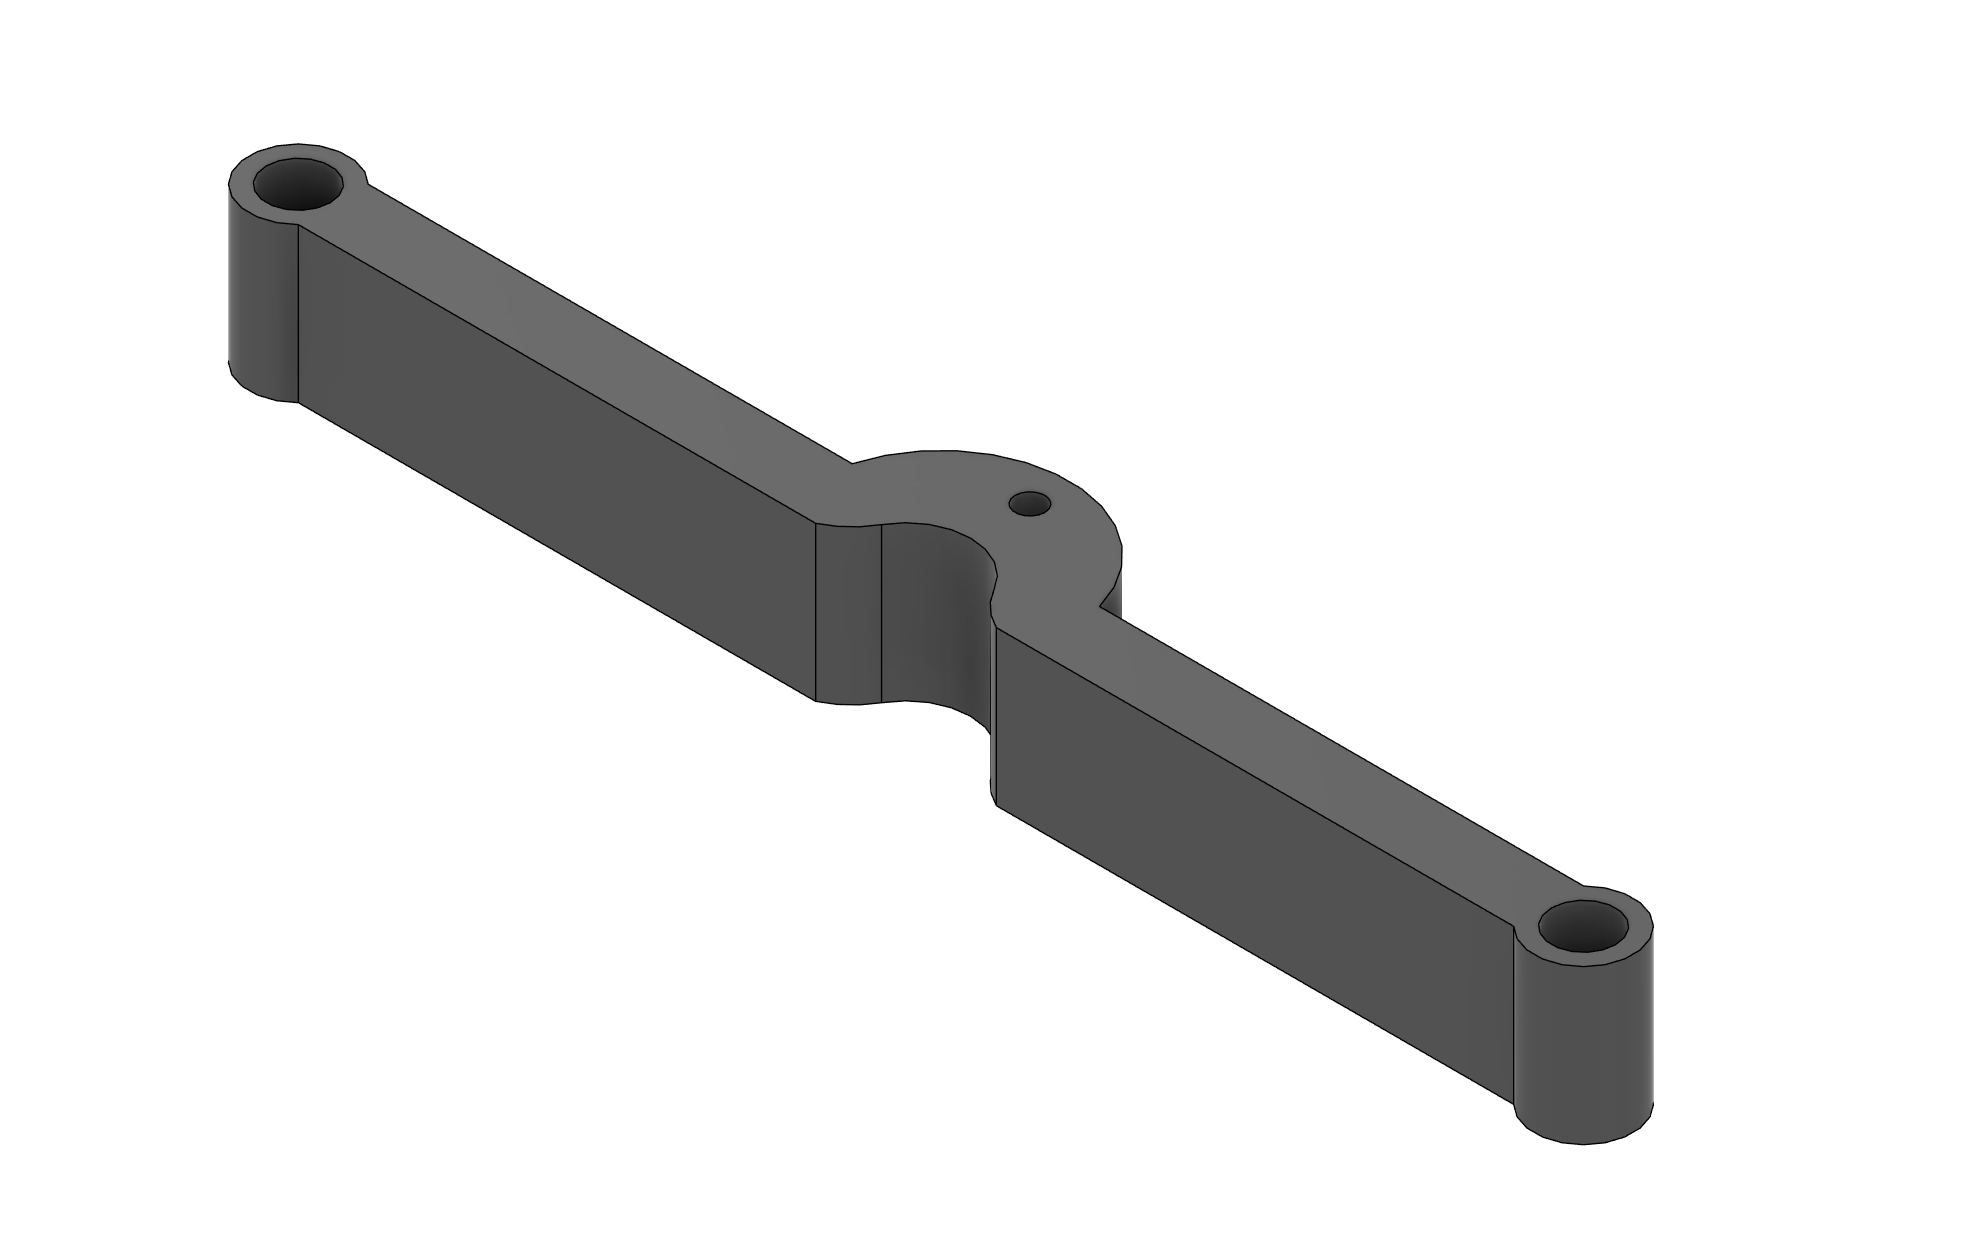 |
| Steering nut | 2 | Moving |
 |
| Steering wheel mount | 2 | Moving |
 |
| Wheel | 4 | Moving |
 |
| Wheel mount to shaft | 4 | Moving | __ |
**Print note:** moving parts need lubrication to reduce friction — we use
Vaseline on all mating surfaces listed as "Moving" above.
## Fasteners and spacers
| Part | Spec | Qty |
|---|---|---|
| Screw | M3 × 8 mm | 18 |
| Screw | M3 × 20 mm | 4 |
| Standoff, male–female | brass, 25 mm | 4 |
| Standoff, female–female | brass, 20 mm | 4 |
## Folder contents
```
models/
├── renders/ # CAD renders (above)
│ └── parts/ # individual per-part renders, used in the BOM photo column
├── 3d-parts/ # source CAD — individual part STLs, by subassembly, + Mechanical-BOM.docx
└── printing/ # 5 pre-sliced 3MF plates, ready to print on the Bambu Lab A1
```
> **To add:** the full Fusion 360 assembly file, a separate photo for battery
> slider p2 (its mating half), and a photo for the wheel-to-shaft mount.