# 🤖 OLAF
**An open-source AI companion robot. Built in public.**
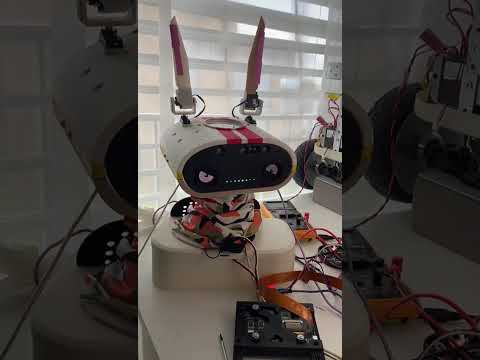
▶ Watch OLAF cycle through its expressions
---
## The Journey: 20 Weeks and Counting
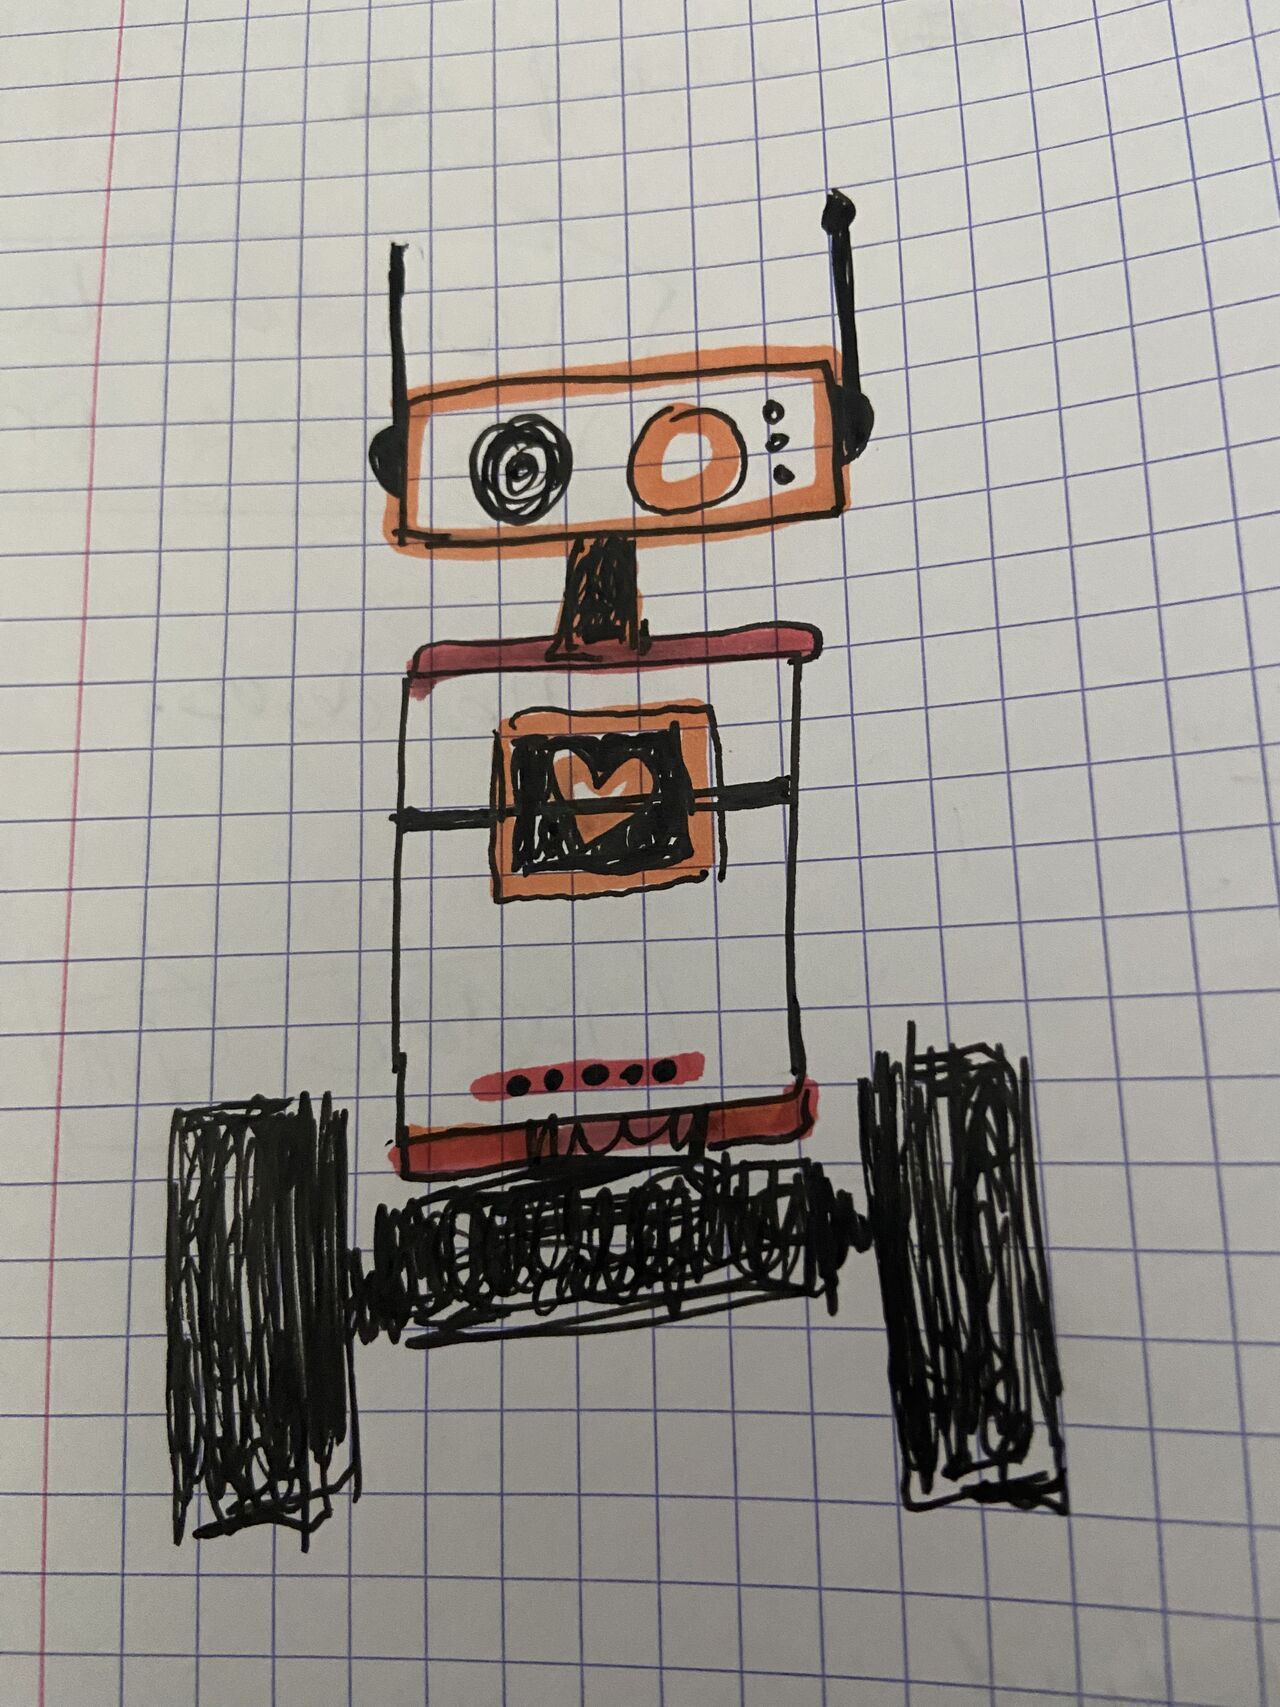
Week 0
Initial concept sketch
|
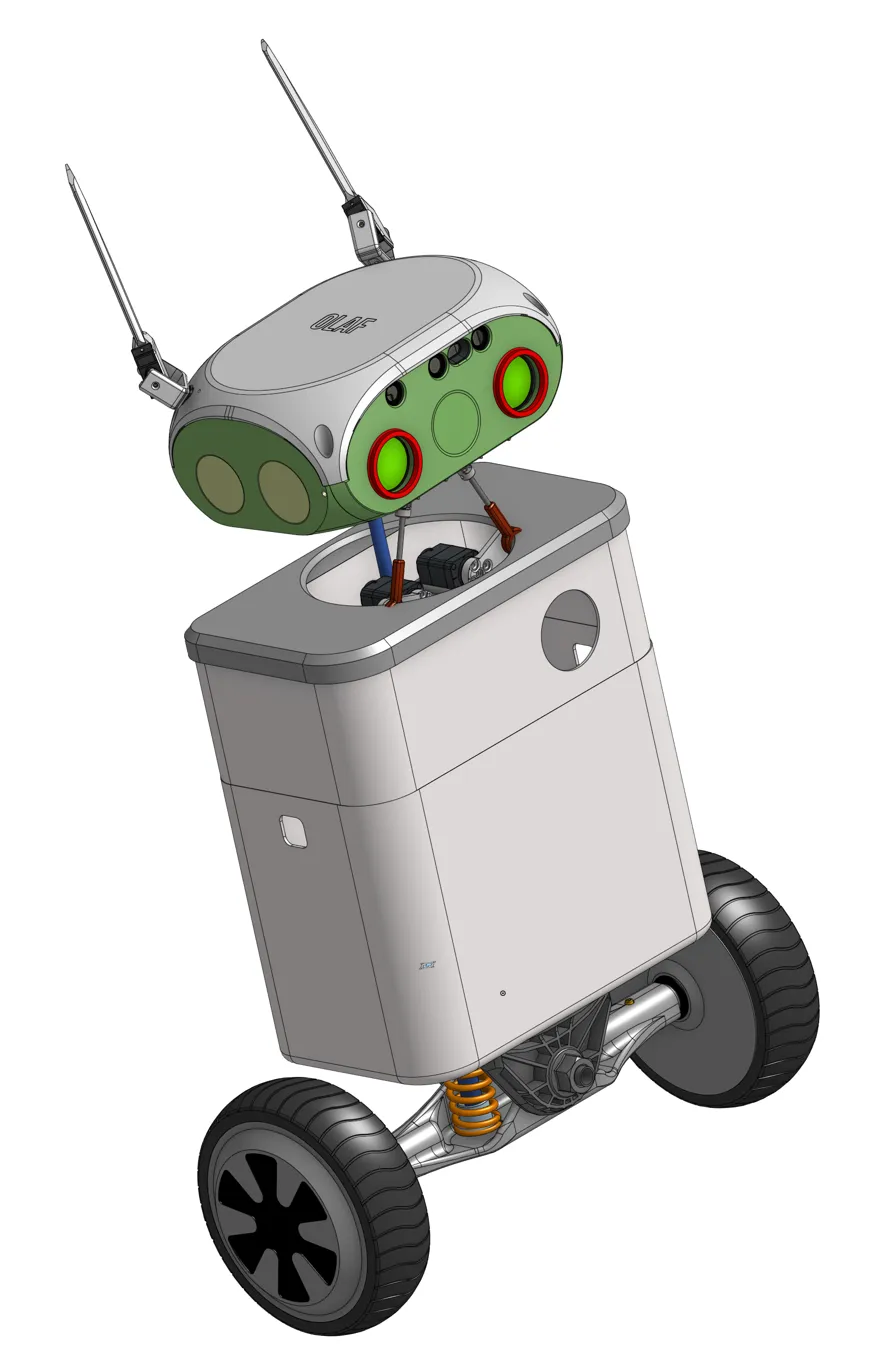
Week 8
3D CAD design complete
|
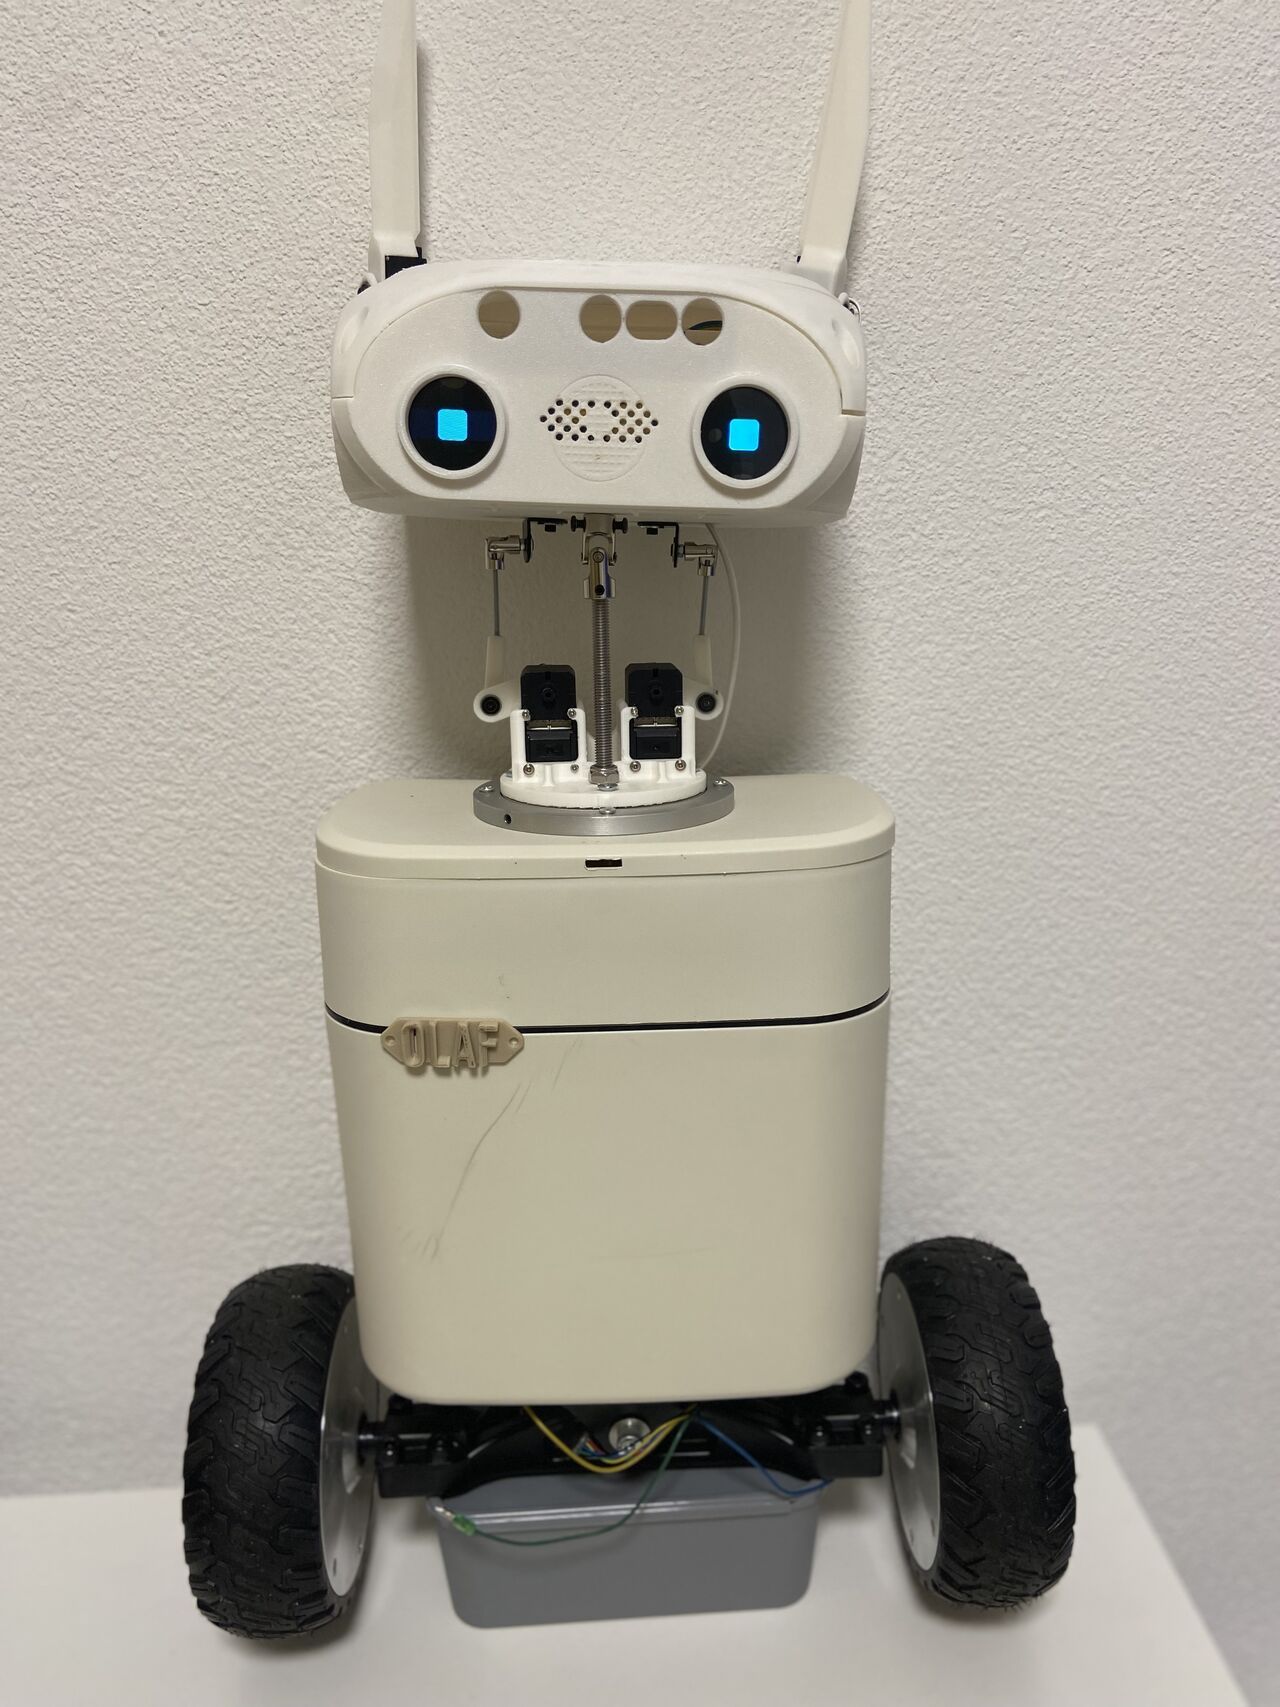
Week 20
Head alive — eyes, ears & neck expressing
|
**An active build-in-public project.** Built while relocating cities and starting a new job — learning CAD, ROS2, embedded systems, and AI integration as I go, with AI coding assistants accelerating development. The journey continues!
---
## What is OLAF?
OLAF is a **personality-first robotics framework** that brings AI agents into physical form. Think R2D2's charm meeting modern AI capabilities — a 2-3 foot tall companion that communicates through expressive OLED eyes, articulated ears (Chappie-inspired), an animated heart display, R2D2-style beeps, and LED status indicators.
**This is not another voice assistant in a box.**
When you BUILD your AI companion, something fundamental changes. It becomes a partner, not a servant. JARVIS challenges Tony Stark's ideas. R2D2 takes initiative. The difference? Tony BUILT JARVIS. Luke CHOSE R2D2 and they grew together. **Building creates relationship, and relationship enables true collaboration.**
---
## The Problem We're Solving
AI assistants (Alexa, Siri, ChatGPT, Claude) have impressive reasoning but remain fundamentally **disembodied** — trapped in screens and speakers. Meanwhile, building physical AI with personality forces impossible choices:
| Option | What You Get | What You Lose |
|--------|-------------|---------------|
| **Commercial robots** (Boston Dynamics, Vector) | Polish, capability | $1000s+, closed-source, no customization |
| **Educational platforms** (Poppy, Niryo) | Modularity, learning | AI integration, personality, high cost |
| **ROS2 robots** (Linorobot2, Andino) | Excellent navigation | Zero personality, assistant features |
| **Hobbyist kits** (Otto DIY) | Affordable, charming | Limited capabilities, no AI |
| **Closed AI robots** (HIWONDER) | AI + robotics bridge | Generic design, closed ecosystem |
**The Core Gap:** No open-source framework integrates modular architecture + AI conversation + personality expression + practical assistance + maker-accessible approach + community ecosystem.
**The Opportunity:** All the pieces are finally here — 3D printers, powerful LLMs, modern SBCs (Raspberry Pi 5), AI coding assistants, local AI accelerators (Hailo). **This is the democratization moment.** The future of embodied AI belongs to builders, not just consumers.
---
## Architecture: Three Layers, Five Modules
> **Repo scope (Phase 2, 2026-05-15).** This repository is the **OLAF body / expression engine** — the Orchestration + Module layers below. The Intelligence Layer (STT, reasoning, personality, mood/emotion decisions) is a **separate sibling project, `olaf_companion`**, which publishes 4 canonical ROS 2 topics (`mood`, `activity`, `speech_emotion`, `vocalization`). This repo subscribes to those and renders them on the body. The "personality-first" vision is unchanged at the *system* level; it's just split across two repos. See `docs/sprint-change-proposal-2026-05-15.md`.
```
┌─────────────────────────────────────────────────────────────────┐
│ INTELLIGENCE LAYER (Hybrid AI) — sibling repo olaf_companion │
│ │
│ Local AI (Hailo-accelerated): │
│ • Whisper STT (<200ms latency) │
│ • Real-time vision processing │
│ │
│ Cloud AI Agents (Claude/GPT-4): │
│ • Natural language understanding │
│ • Complex reasoning & decision-making │
│ • Tool use, function calling, multi-step planning │
│ │
└──────────────────────┬──────────────────────────────────────────┘
│ 4 canonical ROS 2 topics
│ (mood · activity · speech_emotion · vocalization)
┌──────────────────────▼──────────────────────────────────────────┐
│ ORCHESTRATION LAYER ◀── THIS REPO │
│ Raspberry Pi 5 16GB + Fusion HAT+ + Hailo AI Kit │
│ Ubuntu 24.04 • ROS2 Jazzy │
│ │
│ • Expression Engine (subscribes to olaf_companion's 4 topics) │
│ • Composes activity → mood → speech_emotion → vocalization │
│ • Renders pose/LED/eye/heart from expression_map.yaml │
│ • Direct Hardware Control (servos, LEDs, kickstand via HAT) │
│ • I2C Master for ESP32 modules │
│ │
└──┬───────┬───────┬─────────────────┬───────────────────────────┘
│ │ │ │
│I2C │USB×2 │HAT WS2812 │HAT PWM
│ │ │ │
┌──▼───┐ ┌─▼─────────────┐ ┌────────▼───┐ ┌──▼──────┐
│ HEAD │ │ WAVESHARE USB │ │ INDICATOR │ │KICKSTAND│
│ESP32 │ │ Neck + Ears │ │ 24 LEDs │ │ Servos │
│(0x10)│ │ Servo Adapters│ │ (3 strips) │ │(at base)│
└──────┘ └───────────────┘ └────────────┘ └──▲──────┘
┌──▼───┐ │
│ BASE │ │
│ESP32 │ │
│(0x11)│ │
└──────┘
```
### The Five Modules (MECE Principle)
Each module owns its domain exclusively — no cross-dependencies. **Hybrid control:** ESP32s for real-time tasks, Pi direct control for latency-tolerant hardware.
**1. HEAD Module (ESP32, I2C 0x10)**
- **Hardware:** 2× GC9A01 round OLED eyes (240×240, SPI 30-60 FPS), ESP32-S3 for real-time eye animation
- **Personality:** Animated eye expressions, smooth emotional transitions, blink patterns
- **Why ESP32:** 60 FPS animation requires dedicated real-time control
**2. BASE Module (ESP32, I2C 0x11)**
- **Hardware:** Two-wheel inverted pendulum, hoverboard BLDC motors, ODrive v3.6 (UART), BNO085 9-axis AHRS (200Hz on-chip sensor fusion)
- **Control:** 200Hz PID balancing loop (hard real-time, Linux can't guarantee this)
- **Why ESP32:** Self-balancing requires hard real-time guarantees
**3. NECK Module (Pi-controlled, USB Serial)**
- **Hardware:** 3× Feetech STS3215 servos (pan/tilt/roll), Waveshare Bus Servo Adapter
- **Personality:** Head orientation, expressive gestures (tilts, nods, shakes) with organic easing
- **Why Pi Direct:** USB serial via Waveshare adapter — no soldering, plug-and-play
**4. EARS Module (Pi-controlled, USB Serial)**
- **Hardware:** 4× Feetech SCS0009 servos (2-DOF × 2 ears), Waveshare Bus Servo Adapter
- **Personality:** Chappie-inspired ears — perked = alert, drooping = sad, swiveling = curious
- **Why Pi Direct:** USB serial via Waveshare adapter — no soldering, plug-and-play
**5. INDICATOR Module (Pi-controlled, Fusion HAT WS2812)**
- **Hardware:** 3× 8-LED WS2812 strips (24 LEDs, daisy-chained)
- **Functions:** interaction state (listening/working/speaking) · module health · PID visualization
- **Why Pi Direct:** Single data line via Fusion HAT WS2812 port
**Additional Pi-controlled hardware:** 4" heart display (animated beating heart) · kickstand (2× landing-gear servos via HAT PWM) · I2S speaker via HAT.
### Why This Architecture?
- **Hybrid control topology** — ESP32s for the two real-time-critical jobs (60 FPS eyes, 200Hz balancing); Pi direct (via Fusion HAT) for everything else. Minimal soldering, fewer firmware projects, maximum reliability.
- **Modular MECE** — each module completable in 1-2 weekend sprints, independently testable, contribution-friendly.
- **Hybrid intelligence** — local AI (Hailo) for fast/private sensing; cloud agents for sophisticated reasoning.
- **ROS2 foundation** — industry-standard pub/sub on ROS2 Jazzy / Ubuntu 24.04, with a rich ecosystem (SLAM, navigation, sensor fusion).
---
## How Expression Works
The expression engine is a ROS2 node that turns "what the companion is feeling/doing" into coordinated motion + light across every channel — in real time, from a single data-driven map.
```
companion topics ─▶ activity base ─▶ + mood bias ─▶ + speech_emotion ─▶ + vocalization
(mood/activity/ (posture) (LED tint / (12 authored (transient
speech/voc) idle drift) emotions) gestures)
│
▼
eyes (OLED) · ears · neck · WS2812 LEDs
```
- **Single source of truth:** `ros2/src/expression_engine/config/expression_map.yaml` (+ `neck_motion.yaml`, `ears_motion.yaml`). See the [config index](ros2/src/expression_engine/config/README.md).
- **Additive composition:** later layers ride on top of earlier ones, so a vocalization gesture never wipes the underlying emotional pose.
- **Hand-authored, hardware-tuned:** every emotion is authored, then frozen after a pass on the real avatar.
---
## Current Status
**🔄 Active build-in-public (Phase 2 — Expression Engine).** This is a work-in-progress; here's what's real today.
**✅ Working on real hardware:**
- **Head / eyes** — 2× OLED eyes animated by ESP32 firmware; a full set of distinct expressions (the video above)
- **Ears** — 4× SCS0009 servos: perk / droop / swivel, hardware-calibrated
- **Neck** — 3× STS3215 servos: pan / tilt / roll with organic easing
- **Expression engine (ROS2 Jazzy)** — subscribes to the companion's 4 canonical topics and drives eyes + ears + neck + LEDs in sync
- **Idle behaviour** — head drifts to sleep when idle, stirs awake on activity
- **Status LEDs** — WS2812 strips reflect listening / working / speaking
**🔨 In progress / next:**
- Expression authoring finalization (Epic 7 — in review: speech emotions, vocalizations, activity postures, mood→LED tint)
- Heart display animation (Epic 8)
- Self-balancing base — PID tuning (experimental)
- SLAM navigation (deferred)
**🔗 Companion brain:** the AI/intelligence layer lives in the sibling repo **`olaf_companion`**, which publishes the 4 topics this body renders.
**Realistic timeline:** a complex build done in spare time while working full-time. Progress is incremental, iterative, and documented as it happens.
---
## 📹 Demo Videos
### May 2026
- **OLAF expression cycling** — *2026-05-20* — the expression engine cycling through OLAF's authored emotions on real hardware (OLED eyes, articulated ears, 3-DOF neck). [▶ Watch on YouTube](https://youtube.com/shorts/9D4Txb85EnM)
---
## Repository Organization
**Module-first structure.** Everything for a module lives in one place.
```
modules/
├── head/ # OLED eyes (ESP32, I2C 0x10)
├── base/ # Self-balancing (ESP32, I2C 0x11)
├── neck/ # 3-DOF servos (Pi USB serial)
├── ears/ # Articulated ears (Pi USB serial)
├── indicator/ # WS2812 LED strips (Pi Fusion HAT)
└── shared/ # Shared ESP32 libraries
```
**ESP32 modules** (head, base): `firmware/` (PlatformIO) · `hardware/` (3D models + BOM) · `tests/` · `wiring.md`.
**Pi-controlled modules** (neck, ears, indicator): `hardware/` · `tests/` · `assembly.md`.
**ROS2 lives separately:**
```
ros2/src/
├── olaf_drivers/ # Driver logic (head_ears, neck, base, torso)
├── expression_engine/ # Phase 2: renders olaf_companion's 4 canonical topics
└── olaf_ai/ # (deferred) STT/agents now in olaf_companion
```
**Full details:** see [repository-structure.md](docs/architecture/repository-structure.md).
---
## License & Credits
**License:** Open Source (TBD: MIT or Apache 2.0)
**Builder:** [Kamal Singh](https://www.linkedin.com/in/kamal-singh)
- 15 years in tech (5 at Amazon) · 1 year intentional AI deep-dive · MBA + full-stack (hardware + software + AI)
**Inspiration:** R2D2 (non-verbal personality) · JARVIS (AI partner, not servant) · Chappie (expressive ears) · Wall-E (friendly retro-futurism).
**Built with:** AI coding assistants (Claude, GPT-4) · Raspberry Pi 5 16GB / Ubuntu 24.04 · Sunfounder Fusion HAT+ · Hailo AI Kit (26 TOPS) · ROS2 Jazzy · ESP32-S3 · Waveshare Bus Servo Adapters · OnShape · PlatformIO.
---
## Tags
`#BuildInPublic` `#Robotics` `#ROS2` `#PhysicalAI` `#OpenSource` `#MakerMovement` `#AI` `#LearnInPublic` `#EmbodiedAI` `#ModularRobotics`
---
"Feel alive first, be useful second."
Star ⭐ this repo if you believe the future of AI should be open and collaborative!