# Awesome Code as X **Coding-agent papers that treat a program as the intermediate representation.**
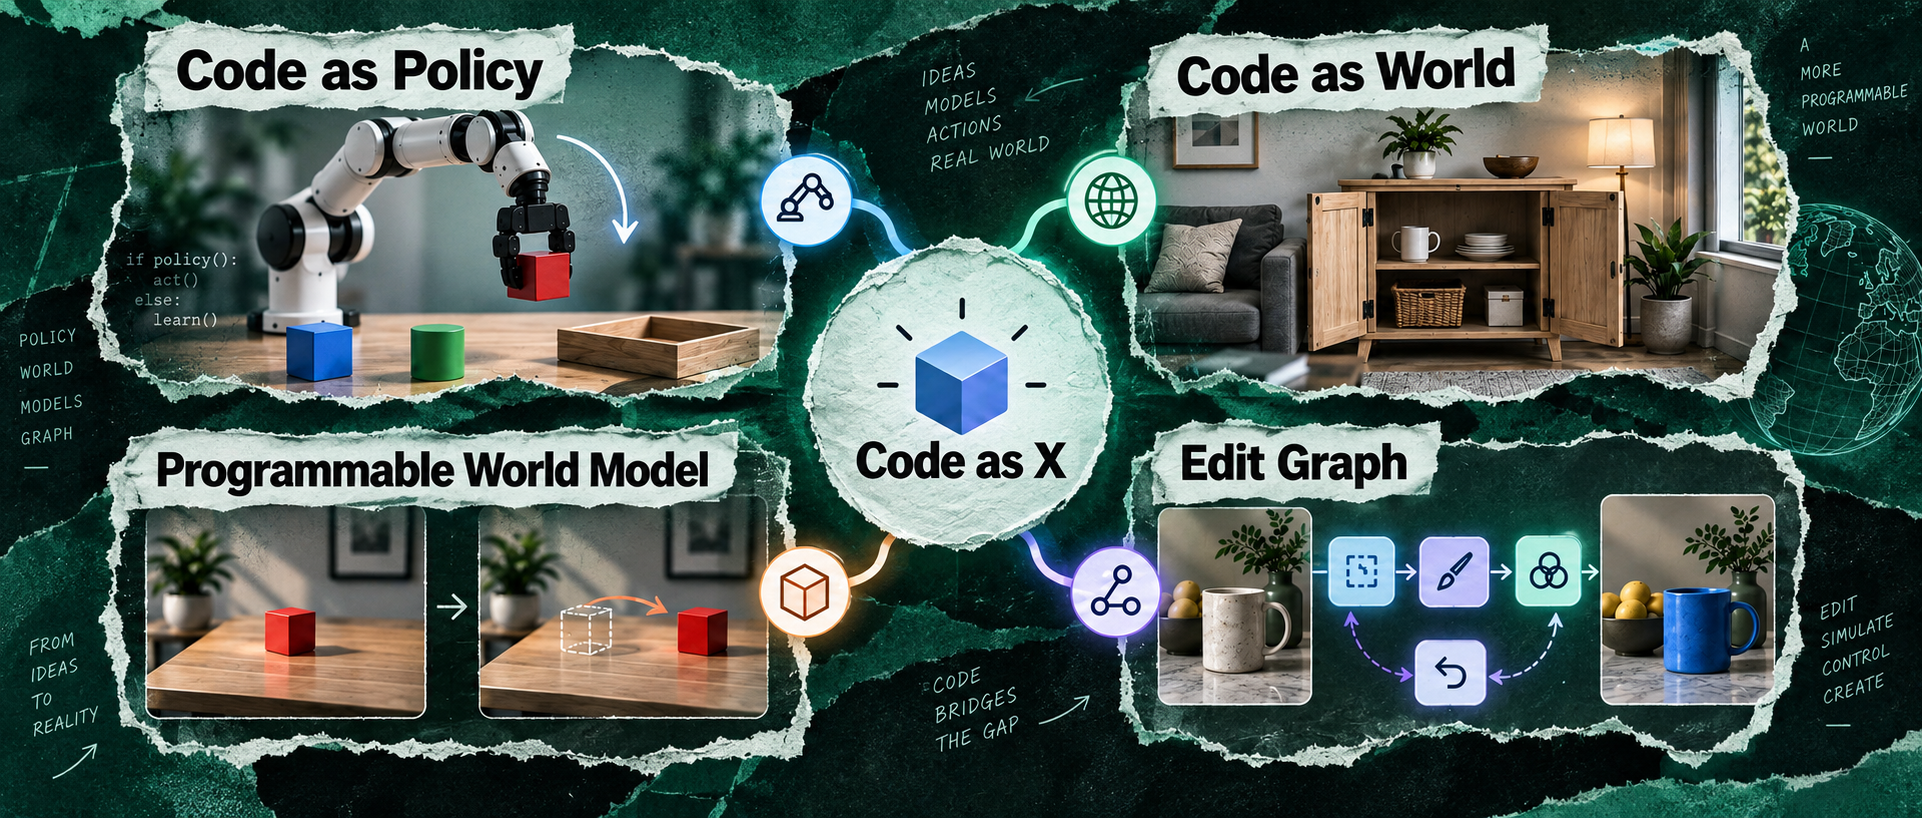
Awesome Code as X

[English](README.md) | [Blog](https://huggingface.co/blog/kkakkkka/from-coding-agents-to-physical-agents) | [SourceMind](assets/sourcemind.jpg) | [中文](README.zh.md) | [公众号文章](https://mp.weixin.qq.com/s/MuOz0KmmQa5CxzjY7WEEvA)
## Overview - 🎯 [Aim](#aim) - 📚 [Definitions](#definitions) - 🦾 [Code as Policy](#code-as-policy) - 🧠 [Code as Memory](#code-as-memory) - 🗺️ [Code as World](#code-as-world) - 🧮 [Programmable World Models](#programmable-world-models) - ✂️ [Edit Graph](#edit-graph) - 📊 [Benchmark](#benchmark) - [Policy programs](#policy-programs) - [World programs](#world-programs) - [Edit programs](#edit-programs) - [Robot evaluation infrastructure](#robot-evaluation-infrastructure) - 📚 [Surveys and Lessons](#surveys-and-lessons) - 🛠️ [Projects](#projects) - [Eval reports](#eval-reports) - [Policy programs in simulation](#policy-programs-in-simulation) - [Policy programs on a real robot](#policy-programs-on-a-real-robot) - [Plan, then call a VLA](#plan-then-call-a-vla) - [World programs from video](#world-programs-from-video) - [RL training stacks](#rl-training-stacks) - [Scene programs](#scene-programs) - 🔗 [Related Resources](#related-resources) ## Aim We collect papers where an agent writes or edits a program, a tool graph, or an explicit world state, then a simulator, renderer, robot, or editor runs it. That includes robot policies, executable scenes, programmable world models, image or video edit graphs, and benchmarks for those agents. Systems, evals, and case catalogs without a paper go under Projects, not under the paper sections. New papers and projects get added as they appear. PRs are welcome. ## Definitions - [Policy program](#def-policy-program) - [World program](#def-world-program) - [Programmable world model](#def-programmable-world-model) - [Edit graph](#def-edit-graph) - [Benchmark](#def-benchmark) - [Project](#def-project) **Policy program.** A Code-as-Policy agent is an LLM or VLM that writes executable robot programs, or a thin semantic action interface. That is the alternative to VLA action tokens. The name comes from Code as Policies. - [⭐️] **Code as Policies**: Language Model Programs for Embodied Control. [![arXiv](https://img.shields.io/badge/arXiv-2209.07753-b31b1b.svg)](https://arxiv.org/abs/2209.07753) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://code-as-policies.github.io) **World program.** A world program is an executable scene or physics program in Blender, MuJoCo, USD, CadQuery, or a similar stack. It is not a static mesh and not a video. Generation writes the program from language or a layout. Inversion / Reconstruction writes it from images, video, or scans. - [⭐️] **SceneCode**: Executable World Programs for Editable Indoor Scenes with Articulated Objects. [![arXiv](https://img.shields.io/badge/arXiv-2605.19587-b31b1b.svg)](https://arxiv.org/abs/2605.19587) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://scene-code.github.io/) Physical Coding, from Self-Evolving Coding Agents: From Digital Programs to Physical-World Intelligence, also uses Code as World for symbolic robot task state: objects, relations, constraints, observations, and progress predicates. That is separate from the executable scene programs grouped below; see [Physical Coding / HexaAnything](#code-as-policy). [![arXiv](https://img.shields.io/badge/arXiv-2609.35432-b31b1b.svg)](https://arxiv.org/abs/2609.35432) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/HexaFuture/PhysicalCoding) **Programmable world model.** Programmable world models keep state and transitions in code. The generator or renderer only handles how things look. - [⭐️] **Code World Model**: Coding Agent as World Brain. [![arXiv](https://img.shields.io/badge/arXiv-2608.25927-b31b1b.svg)](https://arxiv.org/abs/2608.25927) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://buaacyw.github.io/cwm/) **Edit graph.** An edit graph is a sequence of tool calls, a visual program, or a timeline patch. You can inspect it and roll it back. VisProg is an early example. - [⭐️] **VisProg**, Visual Programming: Compositional Visual Reasoning Without Training. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://prior.allenai.org/projects/visprog) **Benchmark.** These benchmarks test whether a coding agent can write, run, and revise a program. RLE-Bench is the policy side: robot learning, training stacks, and control. PhysCodeGym is the world side: reconstruct a video as an executable Blender program and check that the physics holds. - [⭐️] **RLE-Bench**: A Qualifying Exam for Coding Agents as Robot Learning Engineers. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://rle-bench.github.io/) - [⭐️] **PhysCodeGym**: Benchmarking Coding Agents for Physically Verifiable 4D Reconstruction. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/ShaoShuai0605/PhysCodeGym) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://huggingface.co/datasets/ShaoShuai0605/PhysCodeGym) **Project.** A project here is an X post, Xiaohongshu post, webpage-only system, or eval whose primary artifact is not a paper. The coding agent still writes a program as the IR, or closed-loop controls a robot or simulator from code. - [⭐️] **Awesome Astra Embodied AI**: GPT-6 Astra with embodied AI / robotics workflows and demos. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/zjwzcx/Awesome-Astra-Embodied-AI) ## Code as Policy - [⭐️] **Code as Policies**: Language Model Programs for Embodied Control. [![arXiv](https://img.shields.io/badge/arXiv-2209.07753-b31b1b.svg)](https://arxiv.org/abs/2209.07753) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://code-as-policies.github.io) - [⭐️] **CaP-X**: A Framework for Benchmarking and Improving Coding Agents for Robot Manipulation. [![arXiv](https://img.shields.io/badge/arXiv-2603.22435-b31b1b.svg)](https://arxiv.org/abs/2603.22435) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://capgym.github.io) - [⭐️] **RATs**, Playful Agentic Robot Learning. [![arXiv](https://img.shields.io/badge/arXiv-2606.19419-b31b1b.svg)](https://arxiv.org/abs/2606.19419) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://Playful-RATs.github.io/) - [⭐️] **Show-Harness**: Just a VLM Agent Can Play Robots. [![arXiv](https://img.shields.io/badge/arXiv-2609.10522-b31b1b.svg)](https://arxiv.org/abs/2609.10522) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://showlab.github.io/Show-Harness/) - **RACaP**, Agentic Reasoning, Acting, and Coding as Policies for Evolvable Robot Learning: evolves typed Policy APIs offline, then a runtime ReAct loop calls the frozen APIs. [![arXiv](https://img.shields.io/badge/arXiv-2609.29394-b31b1b.svg)](https://arxiv.org/abs/2609.29394) - **RoboDawn**, Transferring the Intelligence of VLMs to Robotic Control: gives the VLM a thin discrete command interface that grounds `move`, `rotate`, `gripper`, and related commands into motion. [![arXiv](https://img.shields.io/badge/arXiv-2609.22966-b31b1b.svg)](https://arxiv.org/abs/2609.22966) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://robodawn.top/) - **GPT-Policy**, In-Context Robot Learning with VLM Agents: compiles context for a VLM agent that issues robot-tool commands through a constrained controller. [![arXiv](https://img.shields.io/badge/arXiv-2609.19138-b31b1b.svg)](https://arxiv.org/abs/2609.19138) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://cheng-haha.github.io/GPT-Policy/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/cheng-haha/GPT-Policy-Eval) - **RoboDojo GPT-6 Astra evaluation**, An Unexpected Robot Policy: Early Evaluations of GPT-6 Astra on RoboDojo and Beyond: runs a VLM policy through the fixed RoboProbe harness on 42 simulation tasks and 2,100 trials; reports 28.97 average score and 22.48% average success, with real-robot testing halted for safety. [![arXiv](https://img.shields.io/badge/arXiv-2609.24170-b31b1b.svg)](https://arxiv.org/abs/2609.24170) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://robodojo-benchmark.com/report/gpt-6-astra-eval) - **SafeHarness**, Coding Agents with an Obstacle-Aware Harness for Safe Robot Manipulation: adds obstacle-aware routing and contact execution to reduce collisions in generated robot controllers. [![arXiv](https://img.shields.io/badge/arXiv-2609.20822-b31b1b.svg)](https://arxiv.org/abs/2609.20822) - **WetRobo**, A Reproducible Robot Kit for Coding Agents in Biological Laboratories: lets agents write and execute lab protocols while calling perception, planning, and simulation tools. [![arXiv](https://img.shields.io/badge/arXiv-2609.18435-b31b1b.svg)](https://arxiv.org/abs/2609.18435) - **AGP**, Agent as Policy for Robotic Manipulation: writes runtime programs, executes them, and revises the policy from physical feedback. [![arXiv](https://img.shields.io/badge/arXiv-2609.12541-b31b1b.svg)](https://arxiv.org/abs/2609.12541) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/agent-as-policy-2026/agent-as-policy) - **PhysCaP**, Grounding Code-as-Policy Agent with Physics-Informed Exploration: adds information-seeking interactions to estimate hidden physical properties for robot manipulation. [![arXiv](https://img.shields.io/badge/arXiv-2608.21031-b31b1b.svg)](https://arxiv.org/abs/2608.21031) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://physcap.github.io/) - **Agentic Push-T**, Revisiting the "Push-T" Robot Manipulation Task with Agentic Robotics: has a coding agent write the manipulation algorithm for Push-T without demonstrations. [![arXiv](https://img.shields.io/badge/arXiv-2608.18227-b31b1b.svg)](https://arxiv.org/abs/2608.18227) - **GaP**, A Graph-as-Policy Multi-Agent Self-Learning Harness for Variational Automation Tasks: represents policy as a directed perception-planning-control graph and refines it in simulation. [![arXiv](https://img.shields.io/badge/arXiv-2607.05369-b31b1b.svg)](https://arxiv.org/abs/2607.05369) - **ASPIRE**: Agentic /Skills Discovery for Robotics. Writes and repairs control programs from execution traces, then stores validated fixes in a reusable skill library. [![arXiv](https://img.shields.io/badge/arXiv-2607.00272-b31b1b.svg)](https://arxiv.org/abs/2607.00272) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/NVlabs/ASPIRE) - **ENPIRE**: Agentic Robot Policy Self-Improvement in the Real World. Resets scenes, executes policies, verifies outcomes, and refines policy or training code from real-robot feedback. [![arXiv](https://img.shields.io/badge/arXiv-2606.19980-b31b1b.svg)](https://arxiv.org/abs/2606.19980) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://research.nvidia.com/labs/gear/enpire/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/NVlabs/ENPIRE) - **Physical Coding / HexaAnything**, Self-Evolving Coding Agents: From Digital Programs to Physical-World Intelligence: uses Code as World for symbolic task state and Code as Policy for execution; HexaAnything routes perception, planning, control, and VLA / WAM tools, verifies outcomes, and persists accepted traces as memory or training data. [![arXiv](https://img.shields.io/badge/arXiv-2609.35432-b31b1b.svg)](https://arxiv.org/abs/2609.35432) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/HexaFuture/PhysicalCoding) - **Harness VLA**: memory and visual feedback compose frozen VLA calls with analytic motion primitives. [![arXiv](https://img.shields.io/badge/arXiv-2607.08448-b31b1b.svg)](https://arxiv.org/abs/2607.08448) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://harnessvla.github.io/) - **Recursive Harness Distillation**: Astra writes a playbook and revises it from Luna’s execution feedback, so the cheaper agent can guide a frozen VLA. [![arXiv](https://img.shields.io/badge/arXiv-2609.33378-b31b1b.svg)](https://arxiv.org/abs/2609.33378) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://seungyeon.me/RHD/) - **RoboICL**: frozen GPT-6 Astra controls a robot from demonstration context and bounded interaction memory, without robot-specific finetuning or a learned VLA. [![arXiv](https://img.shields.io/badge/arXiv-2609.34261-b31b1b.svg)](https://arxiv.org/abs/2609.34261) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://mosi-ai.github.io/RoboICL-GPT6-Astra.github.io/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/Mosi-AI/RoboICL) - **SimEX**: a coding agent grows a toolbox of perception and action primitives in simulation, then writes a fresh code-as-policies script per instruction. Five real-robot trials adapt the toolbox and the simulator together. [![arXiv](https://img.shields.io/badge/arXiv-2609.38982-b31b1b.svg)](https://arxiv.org/abs/2609.38982) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://robo-simex.github.io/) - **OpenRUA**: coding agents use native ROS 2 from the terminal, treat sensor readings as file I/O, and revise manipulation programs from execution feedback. [![arXiv](https://img.shields.io/badge/arXiv-2610.02459-b31b1b.svg)](https://arxiv.org/abs/2610.02459) - **URAI**, Make Code as Policy Great Again: a programming agent writes and revises reusable robot tools; an execution agent picks tools between complete local motions. [![arXiv](https://img.shields.io/badge/arXiv-2609.39018-b31b1b.svg)](https://arxiv.org/abs/2609.39018) - **EmbodiedSWE**: coding agents solve long-horizon dexterous tasks, then turn successful programs into simulation demonstrations for policy training. [![arXiv](https://img.shields.io/badge/arXiv-2609.27308-b31b1b.svg)](https://arxiv.org/abs/2609.27308) - **SpatialClaw**: a VLM writes iterative Python cells in a persistent kernel, mixing geometry tools with intermediate visual feedback. [![arXiv](https://img.shields.io/badge/arXiv-2606.13673-b31b1b.svg)](https://arxiv.org/abs/2606.13673) - **EmbodiedRSI**: picks informative trials, tests competing hypotheses, and revises executable code, skills, and memory around a frozen robot model. [![arXiv](https://img.shields.io/badge/arXiv-2610.10498-b31b1b.svg)](https://arxiv.org/abs/2610.10498) - **Recova**: a coding agent discovers recovery skills in a digital twin, then calls task and recovery policies with progress checks on the robot. [![arXiv](https://img.shields.io/badge/arXiv-2610.01178-b31b1b.svg)](https://arxiv.org/abs/2610.01178) - **PyRUA-Lean**: composes robot primitives and frozen VLA calls inside persistent Python cells, with local checks and retries. [![arXiv](https://img.shields.io/badge/arXiv-2610.01939-b31b1b.svg)](https://arxiv.org/abs/2610.01939) - **DynaHarness**: grounds runtime commands, monitors execution, and revises reusable robot programs only after regression checks. [![arXiv](https://img.shields.io/badge/arXiv-2609.40306-b31b1b.svg)](https://arxiv.org/abs/2609.40306) - **HarnessPAI**: runs a fixed task program over perception and action primitives, then edits that code between rollouts and keeps repair skills that pass. [![arXiv](https://img.shields.io/badge/arXiv-2609.29166-b31b1b.svg)](https://arxiv.org/abs/2609.29166) - **Eureka**: an LLM writes reward code from the environment source and task text, then revises it from RL returns. [![arXiv](https://img.shields.io/badge/arXiv-2310.12931-b31b1b.svg)](https://arxiv.org/abs/2310.12931) - **Code-as-Monitor**: generates visual monitoring code for spatio-temporal constraints, including checks that fire before a violation. [![arXiv](https://img.shields.io/badge/arXiv-2412.04455-b31b1b.svg)](https://arxiv.org/abs/2412.04455) - **ReKep**: turns language and RGB-D into Python constraint functions over 3D keypoints, then solves end-effector actions from those functions. [![arXiv](https://img.shields.io/badge/arXiv-2409.01652-b31b1b.svg)](https://arxiv.org/abs/2409.01652) - **COAP**, Embodied Turing Machines: improvement is a diff to stateful robot code. A shared library is written, tested, and debugged across rounds, then frozen and replayed. Reports 70.24% success on RoboDojo’s 42 bimanual tasks. [![arXiv](https://img.shields.io/badge/arXiv-2610.12369-b31b1b.svg)](https://arxiv.org/abs/2610.12369) - **AgenticGenTAMP**: coding agents synthesize one program per task-and-motion-planning environment; the frozen program then runs on held-out instances. [![arXiv](https://img.shields.io/badge/arXiv-2609.30233-b31b1b.svg)](https://arxiv.org/abs/2609.30233) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/tomsilver/robocode) - **PhysEvo**: keeps one model frozen and improves robot behavior from physical trials on RoboDojo and a real AgileX PiPER. [![arXiv](https://img.shields.io/badge/arXiv-2610.08995-b31b1b.svg)](https://arxiv.org/abs/2610.08995) - **VLCP**, Vision Language Control Policy: Closed-Loop Code Replanning for Robot Manipulation. [![arXiv](https://img.shields.io/badge/arXiv-2608.16978-b31b1b.svg)](https://arxiv.org/abs/2608.16978) - **RHO**, Your Coding Agent is Secretly a Roboticist. [![arXiv](https://img.shields.io/badge/arXiv-2606.16458-b31b1b.svg)](https://arxiv.org/abs/2606.16458) - **ALRM**, Agentic LLM for Robotic Manipulation. [![arXiv](https://img.shields.io/badge/arXiv-2601.19510-b31b1b.svg)](https://arxiv.org/abs/2601.19510) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://tiiuae.github.io/ALRM) - **Act-Observe-Rewrite**, Multimodal Coding Agents as In-Context Policy Learners for Robot Manipulation. [![arXiv](https://img.shields.io/badge/arXiv-2603.04466-b31b1b.svg)](https://arxiv.org/abs/2603.04466) - **HyCodePolicy**, Hybrid Language Controllers for Multimodal Monitoring and Decision in Embodied Agents. [![arXiv](https://img.shields.io/badge/arXiv-2508.02629-b31b1b.svg)](https://arxiv.org/abs/2508.02629) - **ModuLoop**, Low-Level Code Generation using Modular Synthesizer and Closed-Loop Debugger for Robotic Control. [![arXiv](https://img.shields.io/badge/arXiv-2606.03047-b31b1b.svg)](https://arxiv.org/abs/2606.03047) - **NeSyRo**, Towards Reliable Code-as-Policies: A Neuro-Symbolic Framework for Embodied Task Planning. [![arXiv](https://img.shields.io/badge/arXiv-2510.21302-b31b1b.svg)](https://arxiv.org/abs/2510.21302) - **RoboPro**, Robotic Programmer: Video Instructed Policy Code Generation for Robotic Manipulation. [![arXiv](https://img.shields.io/badge/arXiv-2501.04268-b31b1b.svg)](https://arxiv.org/abs/2501.04268) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://video2code.github.io/RoboPro-website/) - **ProgPrompt**: Generating Situated Robot Task Plans using Large Language Models. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://progprompt.github.io/) - **VoxPoser**: Composable 3D Value Maps for Robotic Manipulation with Language Models. [![arXiv](https://img.shields.io/badge/arXiv-2307.05973-b31b1b.svg)](https://arxiv.org/abs/2307.05973) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://voxposer.github.io) - **Instruct2Act**: Mapping Multi-modality Instructions to Robotic Actions with Large Language Model. [![arXiv](https://img.shields.io/badge/arXiv-2305.11176-b31b1b.svg)](https://arxiv.org/abs/2305.11176) - **Language to Rewards** for Robotic Skill Synthesis. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://language-to-reward.github.io/) - **Demo2Code**: From Summarizing Demonstrations to Synthesizing Code via Extended Chain-of-Thought. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://github.com/portal-cornell/demo2code) - **Voyager**: An Open-Ended Embodied Agent with Large Language Models. [![arXiv](https://img.shields.io/badge/arXiv-2305.16291-b31b1b.svg)](https://arxiv.org/abs/2305.16291) - **AdaHVLA**: separate agents analyze evidence, revise a code harness, and judge behavior, keeping a graph of hypotheses and observed effects. [![arXiv](https://img.shields.io/badge/arXiv-2609.29204-b31b1b.svg)](https://arxiv.org/abs/2609.29204) - **RegenHarness**: proposes versioned edits to task templates, routing, and recovery rules, and only keeps a harness change after regression checks. [![arXiv](https://img.shields.io/badge/arXiv-2609.27612-b31b1b.svg)](https://arxiv.org/abs/2609.27612) - **Zetta**: freezes the base policy and grows runtime critics, recovery playbooks, and tools from failure diagnosis and held-out promotion. [![arXiv](https://img.shields.io/badge/arXiv-2608.16590-b31b1b.svg)](https://arxiv.org/abs/2608.16590) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://air-embodied-brain.github.io/zetta/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/air-embodied-brain/Zetta-Embodiment) - **SHAPER**: with model weights frozen, target-environment rollouts evolve reusable skills and the context-code harness around them. [![arXiv](https://img.shields.io/badge/arXiv-2608.11350-b31b1b.svg)](https://arxiv.org/abs/2608.11350) - **VASO**: revises embodied skill contracts against temporal specifications and model-checking counterexamples. [![arXiv](https://img.shields.io/badge/arXiv-2606.05395-b31b1b.svg)](https://arxiv.org/abs/2606.05395) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://languagegroundedriskdetection.github.io/ProjectPage/vaso-webpage) - **Code-as-Symbolic-Planner**: writes executable symbolic planning code from multimodal task context, then reuses those planning abstractions. [![arXiv](https://img.shields.io/badge/arXiv-2503.01700-b31b1b.svg)](https://arxiv.org/abs/2503.01700) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://yongchao98.github.io/Code-Symbol-Planner) - **Agentic Skill Discovery**: a language model writes tasks and reward code, RL trains the skill, and a visual check decides whether the skill enters a persistent library. [![arXiv](https://img.shields.io/badge/arXiv-2405.15019-b31b1b.svg)](https://arxiv.org/abs/2405.15019) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://agentic-skill-discovery.github.io) - **RAX**: a coding agent explores a robot task, records successful preconditions, actions, and effects, then compiles a standalone Python controller that runs without the agent. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://robot-agent-exploration.com/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/robot-agent-exploration/rax) - **ASENA**: connects a coding agent to robot sensing, supervised execution, and persistent experience. An optional learned navigation policy can be called as a tool. Model weights stay fixed while repeated tasks improve. [![arXiv](https://img.shields.io/badge/arXiv-2609.39207-b31b1b.svg)](https://arxiv.org/abs/2609.39207) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://research.nvidia.com/labs/gear/asena/) - **EmbodiedEvo**: turns interaction feedback in a playground scene into reusable code skills and diagnostic lessons, then freezes them so a fresh agent can solve unseen scenes without weight updates. On RoboDojo-Sim the authors report an average score of 44.48 and 37.82% success. [![arXiv](https://img.shields.io/badge/arXiv-2610.18867-b31b1b.svg)](https://arxiv.org/abs/2610.18867) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://lab.einsia.ai/embodiedevo/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/Einsia/EmbodiedEvo) - **Kinex**: a harness that connects coding agents to robots and simulators through device, tool, and skill layers. The agent reaches a configured device with executable tools. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://stacx-lab.github.io/kinex/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/stacx-lab/kinex) - **BT-Agent**: an onboard language model makes task decisions, and behavior-tree skills check local execution conditions and return structured failure feedback. The paper reports onboard quadruped runs and a 161-task text benchmark, with 39 tasks evaluated in Habitat. [![arXiv](https://img.shields.io/badge/arXiv-2610.13862-b31b1b.svg)](https://arxiv.org/abs/2610.13862) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://goldengait.github.io/bt-agent/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/fabiohuebel/bt-agent) - **robot-use**: a coding agent writes short Python programs for bimanual SO-101 arms, with MCP tools and an optional MuJoCo preview. It checks cameras at program checkpoints, and a procedure becomes a skill only after repeated runs on different layouts. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/tensortron/robot-use) - **CarryOn**: a dual-loop harness around a frozen VLA. It keeps user and scene memory, shields actions with geometry, and revises recovery skills from reflection. [![arXiv](https://img.shields.io/badge/arXiv-2610.21453-b31b1b.svg)](https://arxiv.org/abs/2610.21453) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://vincent2311.github.io/Projects/CarryOn/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/JIA-Lab-research/CarryOn) - **ChunkAct**: groups robot-tool primitives into reusable action chunks, and hands control back to the agent when a chunk fails. Chunks can be triggered online or compiled offline from agent memory. [![arXiv](https://img.shields.io/badge/arXiv-2610.18874-b31b1b.svg)](https://arxiv.org/abs/2610.18874) - **RoboHarness**: connects a general-purpose LLM to visual-geometric tools, using clicks, tracked keypoints, and spatial constraints instead of a trained robot policy. [![arXiv](https://img.shields.io/badge/arXiv-2610.14018-b31b1b.svg)](https://arxiv.org/abs/2610.14018) - **CoEvolve**: represents multi-robot coordination as executable code over fixed motor skills. A verifier checks each transition, and a rejected behavior is revised from the last accepted checkpoint. [![arXiv](https://img.shields.io/badge/arXiv-2610.23288-b31b1b.svg)](https://arxiv.org/abs/2610.23288) - **SenseNova-RoboRSI**: a shared runtime revises the harness from execution traces while model weights stay fixed. On RoboDojo it reports an average score of 60.08 and 54.17% success, against a GPT-6 Astra baseline of 28.97. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/OpenSenseNova/SenseNova-RoboRSI) - **MOTIO**, Agentic Skill Engineering for Reality-Grounded Humanoid Loco-Manipulation: turns human-action videos, metric assets, and reusable robot skills into staged executable programs, then revises targets and contact logic using physics execution, multi-frame feedback, and human review. [![arXiv](https://img.shields.io/badge/arXiv-2610.33446-b31b1b.svg)](https://arxiv.org/abs/2610.33446) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://iiiiqiiii.github.io/motio/) - **METATRON**, A Promptable Whole-Body Execution Layer for Humanoids: coding agents write and refine stateful skill programs that supply timed body goals and velocity commands to a frozen whole-body policy, without task-specific policy retraining. [![arXiv](https://img.shields.io/badge/arXiv-2610.38027-b31b1b.svg)](https://arxiv.org/abs/2610.38027) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://research.nvidia.com/labs/par/projects/metatron/) - **Spotter**: a parallel VLM monitor intervenes only after confirming a failure, composes executable motion primitives for recovery, verifies the repair, and returns control to the frozen embodied policy. [![arXiv](https://img.shields.io/badge/arXiv-2609.36808-b31b1b.svg)](https://arxiv.org/abs/2609.36808) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://zqc3117.github.io/Spotter/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/zqc3117/Spotter) - **Self-Building Labs**: an agent builds a laboratory digital twin, turns exploration guided by execution feedback into reusable Python skills with sensor conditions and recovery branches, and composes those skills into experimental workflows. [![arXiv](https://img.shields.io/badge/arXiv-2610.23826-b31b1b.svg)](https://arxiv.org/abs/2610.23826) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://self-building-labs.github.io/) - **Recursia**, Learning to Compose: revises an executable stack of shared tools, skills, contracts, handoffs, and verification from execution traces, then freezes it for composition on new tasks. [![arXiv](https://img.shields.io/badge/arXiv-2610.24464-b31b1b.svg)](https://arxiv.org/abs/2610.24464) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://cocacola-lab.github.io/Recursia-website/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/cocacola-lab/Recursia) - **Skill-RSI**, Compile Once, Run Cheap: a coding agent writes, tests, and repairs Python manipulation skills offline in simulation, freezes candidates before hidden-layout qualification, and deploys accepted files unchanged without continuous frontier-model control. [![arXiv](https://img.shields.io/badge/arXiv-2610.25114-b31b1b.svg)](https://arxiv.org/abs/2610.25114) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/Orillusion/embodied-skill-rsi) - **InstAgent**: represents heterogeneous robot cooperation as executable behavior trees, revises them from feedback, and checks capability bindings and handoffs. [![arXiv](https://img.shields.io/badge/arXiv-2610.23098-b31b1b.svg)](https://arxiv.org/abs/2610.23098) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://instagent01.github.io/) - **AdaRSI**: writes and repairs tools and harness code before retrying from saved states; selectively finetunes VLA substeps that remain unreliable after those repairs. [![arXiv](https://img.shields.io/badge/arXiv-2610.20474-b31b1b.svg)](https://arxiv.org/abs/2610.20474) - **HexaShell**: an acting agent controls robots through a lightweight CLI, while an optimizer turns failure traces into reusable tool programs with tests, retaining experience in code. [![arXiv](https://img.shields.io/badge/arXiv-2610.23479-b31b1b.svg)](https://arxiv.org/abs/2610.23479) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/HexaFuture/HexaShell) - **Fly-by-Code**: writes aerial manipulation programs and separate diagnostic programs that change viewpoints or test physical hypotheses, then uses their results to revise the task program. [![arXiv](https://img.shields.io/badge/arXiv-2610.12549-b31b1b.svg)](https://arxiv.org/abs/2610.12549) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://fly-by-code.github.io/) - **RAPID**, Robot Agentic Programming from Demonstrations: infers task specifications, action primitives, and an interactive test environment from one visual demonstration, then validates and revises programs centered on object relations. [![arXiv](https://img.shields.io/badge/arXiv-2609.30249-b31b1b.svg)](https://arxiv.org/abs/2609.30249) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://yuyaoliu.me/projects/rapid/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/nature21/RAPID) - **AgenticRoboRL**: trains a planner with SFT and multi-turn RL inside a fixed harness, supporting VLA tool calls and generated Python control code while leaving the executor unchanged. [![arXiv](https://img.shields.io/badge/arXiv-2610.28589-b31b1b.svg)](https://arxiv.org/abs/2610.28589) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://xinxinliu-ai.github.io/AgenticRoboRL/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/xinxinliu-ai/AgenticRoboRL) - **SERA**: revises planning guidance, verdict criteria, and supported executable harness rules from rollout feedback while keeping the VLA fixed; freezes the selected configuration before held-out evaluation. [![arXiv](https://img.shields.io/badge/arXiv-2610.29560-b31b1b.svg)](https://arxiv.org/abs/2610.29560) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://stevenkkxs.github.io/sera-webpage/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/StevenKKXS/SERA) - **Scale and Selection**: an optimizer coding agent revises a robot harness with visual interfaces, testing generalization through larger rollout batches and paired incumbent-candidate selection. [![arXiv](https://img.shields.io/badge/arXiv-2609.39304-b31b1b.svg)](https://arxiv.org/abs/2609.39304) - **HARBOR**: coding agents develop simulation tasks, reward code, and policy-training configurations through persistent artifacts, executable gates, and parallel experiments. [![arXiv](https://img.shields.io/badge/arXiv-2606.08610-b31b1b.svg)](https://arxiv.org/abs/2606.08610) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://supersglzc.github.io/harbor-rl/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/supersglzc/harbor-rl) ## Code as Memory Agents write and revise programs that construct memory and retrieve evidence; the program determines how experience gets stored and queried. - **Spatial Memory by Agents, for Agents**: a designer coding agent writes and revises spatial-memory construction and query programs for a fixed query agent, freezing the implementation before processing held-out histories. [![arXiv](https://img.shields.io/badge/arXiv-2610.22736-b31b1b.svg)](https://arxiv.org/abs/2610.22736) ## Code as World ### Inversion / Reconstruction - [⭐️] **NeoWorld-Pro**: Programming Interactive Scenes from Monocular Images for Embodied Simulation. [![arXiv](https://img.shields.io/badge/arXiv-2608.24212-b31b1b.svg)](https://arxiv.org/abs/2608.24212) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://neoworldproject.github.io/neoworld-pro-website/) - [⭐️] **Code as Worlds**: Agentic Discovery of Executable World Representations for Physical Reasoning. [![arXiv](https://img.shields.io/badge/arXiv-2608.27549-b31b1b.svg)](https://arxiv.org/abs/2608.27549) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://mirros-lab.github.io/code-as-world/) - [⭐️] **Mundo**, Customized World Model: a VLM agent refines a scene program from context images through rendering and review. The program maintains objects and physical properties, a simulator computes interactions, and a video model renders the resulting proxy frames using the input views. Code and weights are not yet released. [![Paper / Blog](https://img.shields.io/badge/Paper-Blog-blue)](https://huggingface.co/blog/Luo-Yihang/mundo-world-model) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://mundo-world-model.github.io/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/Luo-Yihang/Mundo) - [⭐️] **LiteReality-Agent**, An Agentic System for Interactable 3D Indoor Scene Reconstruction: reconstructs RGB-D scans as executable `Room.py` scene programs, gathering evidence and revising the script through an observe-edit-verify loop. [![arXiv](https://img.shields.io/badge/arXiv-2610.01863-b31b1b.svg)](https://arxiv.org/abs/2610.01863) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://litereality.github.io/agent/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/LiteReality/LiteReality-Agent) - **VIGA**, Vision-as-Inverse-Graphics Agent via Interleaved Multimodal Reasoning. [![arXiv](https://img.shields.io/badge/arXiv-2601.11109-b31b1b.svg)](https://arxiv.org/abs/2601.11109) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://fugtemypt123.github.io/VIGA-website) - **Thinking in Blender**: Staged Executable Inverse Graphics with Vision-Language Models. [![arXiv](https://img.shields.io/badge/arXiv-2606.02580-b31b1b.svg)](https://arxiv.org/abs/2606.02580) - **RCWM**, Recursive Code World Models: Building Complex Worlds through Recursive Scene Programs. [![arXiv](https://img.shields.io/badge/arXiv-2609.11499-b31b1b.svg)](https://arxiv.org/abs/2609.11499) - **VisPhyWorld**: Probing Physical Reasoning via Code-Driven Video Reconstruction. [![arXiv](https://img.shields.io/badge/arXiv-2602.13294-b31b1b.svg)](https://arxiv.org/abs/2602.13294) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://github.com/TIGER-AI-Lab/VisPhyWorld) - **AstraLOD3**: multi-view evidence to an editable building reconstruction. [![arXiv](https://img.shields.io/badge/arXiv-2609.28061-b31b1b.svg)](https://arxiv.org/abs/2609.28061) - **RoboSimStudio**: humans and coding agents refine a Newton simulation's scene and physical parameters against observed robot behavior. [![arXiv](https://img.shields.io/badge/arXiv-2610.18835-b31b1b.svg)](https://arxiv.org/abs/2610.18835) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://robosimstudio.github.io/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/robosimstudio/robosimstudio) - **WorldMirror**: a coding agent reconstructs robot demonstrations as executable world programs, revising asset and assembly code from visual, geometric, and physical feedback while preserving trajectory replay. [![arXiv](https://img.shields.io/badge/arXiv-2610.31834-b31b1b.svg)](https://arxiv.org/abs/2610.31834) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://worldmirror-page.github.io/) ### Generation - [⭐️] **SceneCode**: Executable World Programs for Editable Indoor Scenes with Articulated Objects. [![arXiv](https://img.shields.io/badge/arXiv-2605.19587-b31b1b.svg)](https://arxiv.org/abs/2605.19587) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://scene-code.github.io/) - [⭐️] **VideoCoCo**: Code-as-CoT for Physically-Consistent Video Generation via an Agentic Dual-Engine System. [![arXiv](https://img.shields.io/badge/arXiv-2607.27380-b31b1b.svg)](https://arxiv.org/abs/2607.27380) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://github.com/micky-li-hd/VideoCoCo) - **Code Video Model**: writes a Three.js program as an executable previs, renders a proxy video and a reference image, then conditions a pretrained video model on the proxy only in early sampling steps. Code edits change layout, motion, and camera before the final clip. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://code-video-model.github.io/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/code-video-model/CodeVideoModel) - **EmbodiedGen V2**: an agent builds and edits assets, multi-room scenes, and task environments, then exports URDF, USD, or MJCF after physics checks. [![arXiv](https://img.shields.io/badge/arXiv-2607.07459-b31b1b.svg)](https://arxiv.org/abs/2607.07459) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/HorizonRobotics/EmbodiedGen) - **SimFoundry**: a modular video-to-simulation pipeline that reconstructs objects, compiles a physical scene, and proposes tasks in OmniGibson. [![arXiv](https://img.shields.io/badge/arXiv-2606.28276-b31b1b.svg)](https://arxiv.org/abs/2606.28276) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/NVlabs/SimFoundry) - **Procedura**: agentic 3D assemblies whose named parts are joined by typed, machine-checkable constraints. [![arXiv](https://img.shields.io/badge/arXiv-2608.26238-b31b1b.svg)](https://arxiv.org/abs/2608.26238) - **Articraft**: an agentic pipeline for scalable articulated 3D assets. [![arXiv](https://img.shields.io/badge/arXiv-2605.15187-b31b1b.svg)](https://arxiv.org/abs/2605.15187) - **HARMONY**: hierarchical agentic reasoning that turns one image into a scene program. [![arXiv](https://img.shields.io/badge/arXiv-2609.26793-b31b1b.svg)](https://arxiv.org/abs/2609.26793) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://cwchenwang.github.io/harmony/) - **AssemblyWorld**: general-purpose agents solve 3D assembly from rendered views and part records, not mesh vertices. [![arXiv](https://img.shields.io/badge/arXiv-2609.40353-b31b1b.svg)](https://arxiv.org/abs/2609.40353) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/AssemblyWorld/assembly-world-bench) - **USDCraft**: an LLM writes and revises a program that turns a mesh and a reference image into a simulation-ready articulated USD asset. [![arXiv](https://img.shields.io/badge/arXiv-2610.11322-b31b1b.svg)](https://arxiv.org/abs/2610.11322) - **AffordCraft**: from one photo and a task, builds task-ready simulation assets. [![arXiv](https://img.shields.io/badge/arXiv-2610.06643-b31b1b.svg)](https://arxiv.org/abs/2610.06643) - **Agentic RSR**: real-to-sim-to-real through scene reconstruction and execution-grounded robot policies. Eighteen scenes on two robots pass a joint visual check, and real-robot task success reaches 80% of simulation success. [![arXiv](https://img.shields.io/badge/arXiv-2610.10479-b31b1b.svg)](https://arxiv.org/abs/2610.10479) - **Artisan**: a multi-agent pipeline for physically grounded articulated 3D assets. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://physicalvision.github.io/artisan/) - **Code-as-Room**: Generating 3D Rooms from Top-Down View Images via Agentic Code Synthesis. [![arXiv](https://img.shields.io/badge/arXiv-2605.18451-b31b1b.svg)](https://arxiv.org/abs/2605.18451) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://code-as-room.github.io/) - **RoomWright**, Beyond Placement and Articulation: Usage-Driven Code Scenes for Embodied Interaction. [![arXiv](https://img.shields.io/badge/arXiv-2608.18840-b31b1b.svg)](https://arxiv.org/abs/2608.18840) - **SR-Platform**: An Agentic Pipeline for Natural Language-Driven Robot Simulation Environment Synthesis. [![arXiv](https://img.shields.io/badge/arXiv-2605.14700-b31b1b.svg)](https://arxiv.org/abs/2605.14700) - **GS-Agent**: Creating 4D Physical Worlds With Generative Simulation. [![arXiv](https://img.shields.io/badge/arXiv-2607.21522-b31b1b.svg)](https://arxiv.org/abs/2607.21522) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://umass-embodied-agi.github.io/gs-agent/) - **SceneCraft**: An LLM Agent for Synthesizing 3D Scenes as Blender Code. [![arXiv](https://img.shields.io/badge/arXiv-2403.01248-b31b1b.svg)](https://arxiv.org/abs/2403.01248) - **3D-GPT**: Procedural 3D Modeling with Large Language Models. [![arXiv](https://img.shields.io/badge/arXiv-2310.12945-b31b1b.svg)](https://arxiv.org/abs/2310.12945) - **LL3M**: Large Language 3D Modelers. [![arXiv](https://img.shields.io/badge/arXiv-2508.08228-b31b1b.svg)](https://arxiv.org/abs/2508.08228) - **3DCodeVerse**: coding agents write raw Blender, Three.js, CadQuery, OpenSCAD, GLSL, or OpenGL, and a harness executes, measures, and judges the program. The release includes about 2M executable 3D programs. On 100 text-to-3D prompts, GPT-6 Astra's human preference rises from 31% in Codex to 69% inside this harness. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://3dcodeverse.com) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/gaoypeng/3dcodeverse) - **BrickWright**: writes and revises BrickLayer Python programs for LEGO models using connector assembly, collision, floating-part, and connectivity checks, and rendered feedback, then exports LDraw. [![arXiv](https://img.shields.io/badge/arXiv-2610.31651-b31b1b.svg)](https://arxiv.org/abs/2610.31651) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://avalovelace1.github.io/brickwright/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/AvaLovelace1/brickwright) ## Programmable World Models This section also includes generative rendering components for code-driven worlds. In those systems, the upstream engine or program maintains state and transition rules, while the renderer turns its structural output into video. - [⭐️] **Code World Model**: Coding Agent as World Brain. [![arXiv](https://img.shields.io/badge/arXiv-2608.25927-b31b1b.svg)](https://arxiv.org/abs/2608.25927) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://buaacyw.github.io/cwm/) - [⭐️] **Programmable World Model**. [![arXiv](https://img.shields.io/badge/arXiv-2609.10540-b31b1b.svg)](https://arxiv.org/abs/2609.10540) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://alaya-lab.github.io/pwm/) - [⭐️] **Fight World Model**, Customizable Combat through Visual Interaction Proxies: an executable engine maintains fighter state and resolves combat rules; a deterministic compiler aligns actions, hit reactions, and health in a visual interaction proxy for video rendering. Damage scaling, immunity, lifesteal, and multi-stage skills can change without retraining the renderer. [![arXiv](https://img.shields.io/badge/arXiv-2610.40607-b31b1b.svg)](https://arxiv.org/abs/2610.40607) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://fight-world-model.github.io/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/fight-world-model/FWM) - **PoE-World**: Compositional World Modeling with Products of Programmatic Experts. [![arXiv](https://img.shields.io/badge/arXiv-2505.10819-b31b1b.svg)](https://arxiv.org/abs/2505.10819) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://topwasu.github.io/poe-world) - **PatchWorld**: Gradient-Free Optimization of Executable World Models for Agent Environments. [![arXiv](https://img.shields.io/badge/arXiv-2605.30880-b31b1b.svg)](https://arxiv.org/abs/2605.30880) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://github.com/HKBU-KnowComp/PatchWorld) - **Mind-Studio**: Executable World Models with Lookahead Evaluation for Partially Observable Games. [![arXiv](https://img.shields.io/badge/arXiv-2606.16070-b31b1b.svg)](https://arxiv.org/abs/2606.16070) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://github.com/HKBU-KnowComp/MindStudio) - **CWM-GGP**, Code World Models for General Game Playing. [![arXiv](https://img.shields.io/badge/arXiv-2510.04542-b31b1b.svg)](https://arxiv.org/abs/2510.04542) - **Web World Models**. [![arXiv](https://img.shields.io/badge/arXiv-2512.23676-b31b1b.svg)](https://arxiv.org/abs/2512.23676) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://princeton-ai2-lab.github.io/Web-World-Models/) - **gWorld**, Generative Visual Code Mobile World Models. [![arXiv](https://img.shields.io/badge/arXiv-2602.01576-b31b1b.svg)](https://arxiv.org/abs/2602.01576) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://trillionlabs-gworld.github.io) - **WorldCoder**: Building World Models by Writing Code and Interacting with the Environment. [![arXiv](https://img.shields.io/badge/arXiv-2402.12275-b31b1b.svg)](https://arxiv.org/abs/2402.12275) - **GIF-MCTS**, Generating Code World Models with Large Language Models Guided by Monte Carlo Tree Search. [![arXiv](https://img.shields.io/badge/arXiv-2405.15383-b31b1b.svg)](https://arxiv.org/abs/2405.15383) - **Baba in Wonderland**: discovers dynamics online and writes them down as an executable world model. [![arXiv](https://img.shields.io/badge/arXiv-2605.16725-b31b1b.svg)](https://arxiv.org/abs/2605.16725) - **Tycho**: builds programmatic world models by active abstraction for ARC-AGI-3. [![arXiv](https://img.shields.io/badge/arXiv-2607.28287-b31b1b.svg)](https://arxiv.org/abs/2607.28287) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/NIMI-research/Tycho) - **WALL-E**: learns rules that align a world model, then uses those rules for LLM-agent planning. [![arXiv](https://img.shields.io/badge/arXiv-2410.07484-b31b1b.svg)](https://arxiv.org/abs/2410.07484) - **WALL-E 2.0**: learns neurosymbolic rules so a world-model agent can adapt when the environment changes. [![arXiv](https://img.shields.io/badge/arXiv-2504.15785-b31b1b.svg)](https://arxiv.org/abs/2504.15785) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/elated-sawyer/WALL-E) - **VisualPredicator**: learns neuro-symbolic predicates as an abstract world model for robot planning. [![arXiv](https://img.shields.io/badge/arXiv-2410.23156-b31b1b.svg)](https://arxiv.org/abs/2410.23156) - **Matrix-Game 4.0**: gameplay, physics, and player input stay in an executable game engine. A causal video model only turns the engine's low-poly frames into detailed visuals. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://matrix-game-v4-0.github.io/page/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/SkyworkAI/Matrix-Game) - **TheoryCoder**, Synthesizing World Models for Bilevel Planning: pairs human-provided high-level PDDL abstractions with a learned low-level Python transition model for bilevel search. [![arXiv](https://img.shields.io/badge/arXiv-2503.20124-b31b1b.svg)](https://arxiv.org/abs/2503.20124) - **TheoryCoder-2**, Learning Abstractions for Hierarchical Planning in Program-Synthesis Agents: learns the reusable high-level abstractions from experience instead of taking them from people. [![arXiv](https://img.shields.io/badge/arXiv-2602.00929-b31b1b.svg)](https://arxiv.org/abs/2602.00929) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/ZerghamAhmed/TheoryCoder) - **OneLife**, One Life to Learn: Inferring Symbolic World Models for Stochastic Environments from Unguided Exploration: writes transitions as conditionally activated precondition–effect laws, learned within one episode; only the laws that fire get updated. [![arXiv](https://img.shields.io/badge/arXiv-2510.12088-b31b1b.svg)](https://arxiv.org/abs/2510.12088) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/codezakh/onelife) - **CASSANDRA**: Programmatic and Probabilistic Learning and Inference for Stochastic World Modeling. Python code covers the deterministic features, and Bayesian-network structure learning covers the stochastic variables. [![arXiv](https://img.shields.io/badge/arXiv-2601.18620-b31b1b.svg)](https://arxiv.org/abs/2601.18620) - **Agent2World**: Learning to Generate Symbolic World Models via Adaptive Multi-Agent Feedback. A researcher, a model developer, and a testing team write unit and simulation tests, then repair PDDL and Python world models from the failures. [![arXiv](https://img.shields.io/badge/arXiv-2512.22336-b31b1b.svg)](https://arxiv.org/abs/2512.22336) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/DeepExperience/agent2world) - **Memento 3**: Model-Based Recursive Self-Improvement through Reflective Rulebooks. Keeps a natural-language rulebook, compiles it into Python dynamics, and accepts an update only if it replays past observations cell for cell. [![arXiv](https://img.shields.io/badge/arXiv-2610.11794-b31b1b.svg)](https://arxiv.org/abs/2610.11794) - **Executable World Models for ARC-AGI-3** in the Era of Coding Agents: a coding agent checks its Python world model against the full interaction history and periodically refactors it for minimum description length, so ad-hoc fixes collapse into compact rules. [![arXiv](https://img.shields.io/badge/arXiv-2605.05138-b31b1b.svg)](https://arxiv.org/abs/2605.05138) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/astroseger/arc-3-agents-baseline1) - **Do Coding Agents Need Executable World Models, Simplification, and Verification to Solve ARC-AGI-3?** Nested ablations: requiring an executable model alone has mixed effects against text reasoning, while the full verification-oriented design scores highest in all four reported model–effort settings, at a higher token cost. [![arXiv](https://img.shields.io/badge/arXiv-2607.15439-b31b1b.svg)](https://arxiv.org/abs/2607.15439) - **OPINE-World**: Programmatic World Modeling with Ontology-error-Prioritized Interactive Exploration for ARC-AGI-3. Explores where a Bayesian ontology error says the current object-type hierarchy explains interactions worst. [![arXiv](https://img.shields.io/badge/arXiv-2607.01531-b31b1b.svg)](https://arxiv.org/abs/2607.01531) - **Kepler**: Auditable World Models for ARC-AGI-3. Compares each pre-action prediction with the next observation and halts the plan on a mismatch. The audits show that unguarded runs can be confounded by source-code leakage or silent agent self-repair. [![arXiv](https://img.shields.io/badge/arXiv-2610.00834-b31b1b.svg)](https://arxiv.org/abs/2610.00834) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/Cveinnt/kepler) - **RoleWorld**: Knowledge Transfer in World Modeling with Functional Role Abstractions. Writes DSL transition rules over functional roles, then probes a new environment only to bind its objects to those roles. [![arXiv](https://img.shields.io/badge/arXiv-2610.13172-b31b1b.svg)](https://arxiv.org/abs/2610.13172) - **World-Time Compute** with Verified Code World Models: samples trajectories from verified symbolic code worlds (OpenWorld) as training data for cross-world generalization. [![arXiv](https://img.shields.io/badge/arXiv-2609.09163-b31b1b.svg)](https://arxiv.org/abs/2609.09163) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/quome-cloud/openworld) - **VisualPatchWorld**: Code World Models as Latent Structured Representations for Planning. Image-derived scene graphs feed Python kinematic and contact sketches for CEM-MPC. Planning success is 69.0% with oracle state and 61.0% from RGB, against 97.5% for MuJoCo under the same planner. [![arXiv](https://img.shields.io/badge/arXiv-2607.25236-b31b1b.svg)](https://arxiv.org/abs/2607.25236) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/HKBU-KnowComp/VisualPatchWorld) - **NeSyS**, Neuro-Symbolic Synergy for World Modeling: reranks neural next-state candidates with executable rule scores, and focuses fine-tuning on transitions the rules cover weakly. [![arXiv](https://img.shields.io/badge/arXiv-2602.10480-b31b1b.svg)](https://arxiv.org/abs/2602.10480) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/tianyi-lab/NeSyS) - **ProgGen**, Programmatic Video Prediction Using Large Language Models: synthesizes Python programs for state estimation, dynamics, and RGB rendering of physical scenes. [![arXiv](https://img.shields.io/badge/arXiv-2505.14948-b31b1b.svg)](https://arxiv.org/abs/2505.14948) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/metro-smiles/ProgGen) - **DR-WM**, From Pixels to Executable Physics: Behavior-Grounded World Models for Embodied Action Consequence Prediction: calibrates terrain contact from robot action–response data, runs candidate actions in a physics simulator, and uses the simulated trajectories to guide video generation. The dynamics come from a calibrated physics engine, not from synthesized transition code. [![arXiv](https://img.shields.io/badge/arXiv-2610.17630-b31b1b.svg)](https://arxiv.org/abs/2610.17630) - **Streaming Code World Model**: adds causal chunk-wise rendering and diffusion-forcing conditioning to CWM, using proxies from a separate scripted-world generator. The authors report 5.1 s to render a 0.71 s chunk with the four-step distilled model on one H200; the release is not real time. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/TingtingLiao/streaming-code-world-model) - **CoDeR**, Code Plans, Diffusion Renders: Open-Ended Generative World Modeling: multi-agent Three.js coders build the logical space, diffusion "Artists" paint it, and the generated appearance is registered back onto the 3D geometry. [![arXiv](https://img.shields.io/badge/arXiv-2609.26458-b31b1b.svg)](https://arxiv.org/abs/2609.26458) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://becauseimbatman0.github.io/CoDeR) - **AgentGarten**: Code Worlds for Evolving Agents. Code-authored simulation worlds export depth and normal buffers to a real-time block-causal neural renderer distilled with Adversarial Forcing. [![arXiv](https://img.shields.io/badge/arXiv-2610.12374-b31b1b.svg)](https://arxiv.org/abs/2610.12374) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/MirroS-Lab/AgentGarten) - **GameDirector**: Decoupling Gameplay Logic from Rendering for Player-Configurable Game World Models. State tracking and agentic action control let players reconfigure gameplay mechanics separately from the renderer. [![arXiv](https://img.shields.io/badge/arXiv-2609.25652-b31b1b.svg)](https://arxiv.org/abs/2609.25652) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://jimntu.github.io/gamedirector/) - **DAO & JING**, Generative World Simulation with DAO and JING: keeps one persistent shared world whose evolving state conditions audiovisual generation for each observer. [![arXiv](https://img.shields.io/badge/arXiv-2610.19726-b31b1b.svg)](https://arxiv.org/abs/2610.19726) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/XGEN-Labs/XGEN-JING) - **Magpie**: Real-Time World Renderer for Interactive Games. Designer-written gameplay rules run in a game engine; a separate render server generates visuals from the engine's observations. [![arXiv](https://img.shields.io/badge/arXiv-2608.27168-b31b1b.svg)](https://arxiv.org/abs/2608.27168) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://zhanxy.xyz/Magpie-website) - **Code2World**: A GUI World Model via Renderable Code Generation. A VLM predicts the next mobile screen as HTML/CSS that a browser renders. As with gWorld, the code describes the predicted screen, and the transition stays inside the network. [![arXiv](https://img.shields.io/badge/arXiv-2602.09856-b31b1b.svg)](https://arxiv.org/abs/2602.09856) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/AMAP-ML/Code2World) - **StreamRender-H3**: Interactive Coding Worlds with Real-time Streaming Diffusion Render. Maps, physics, and interaction rules stay in a code game engine, which streams flat-colored semantic maps to a two-step streaming diffusion renderer styled by a reference image and a prompt. Rendering takes 218 ms per streaming step on eight GB200 GPUs, and all reported results come from one racing game. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://nvlabs.github.io/Sana/Sol-Engine/StreamRender-H3/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/NVlabs/Sana/tree/sol-engine/models/streamrender_h3) - **SolarRenderer**: Few-Step Generative Reference Rendering. A control LoRA on a frozen MiniMax-H3 backbone reads structural videos (block-outs, semantic maps, depth maps) frame by frame, and an acceleration LoRA cuts sampling to four steps. It generalizes to 11 structural representations unseen in training, and a block-causal variant streams 768p video in real time. The renderer keeps no world state; the structure comes from whatever engine or program makes the input video. [![arXiv](https://img.shields.io/badge/arXiv-2610.28630-b31b1b.svg)](https://arxiv.org/abs/2610.28630) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://enderfga.cn/SolarRenderer/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/Enderfga/SolarRenderer) - **AnyGameRenderer**: Entity-Consistent Generative Rendering Across Games and an Entity-Level Benchmark. Re-renders crude gameplay from agent-made games, improving entity position, timing, and count correspondence while leaving game logic and state to the source program. Its benchmark scores 753 entities in 59 held-out clips; temporal match rises from 50.9% to 62.9% over the base model. [![arXiv](https://img.shields.io/badge/arXiv-2610.31466-b31b1b.svg)](https://arxiv.org/abs/2610.31466) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://alaya-lab.github.io/AnyGameRenderer/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/AlayaLab/AnyGameRenderer) - **Trace2World**: reconstructs app states and transitions with source evidence from interaction traces, compiles them into executable browser environments, and repairs the implementation through independent workflow replay. [![arXiv](https://img.shields.io/badge/arXiv-2610.30792-b31b1b.svg)](https://arxiv.org/abs/2610.30792) ## Edit Graph - [⭐️] **VisProg**, Visual Programming: Compositional Visual Reasoning Without Training. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://prior.allenai.org/projects/visprog) - [⭐️] **IEAP**, Image Editing As Programs with Diffusion Models. [![arXiv](https://img.shields.io/badge/arXiv-2506.04158-b31b1b.svg)](https://arxiv.org/abs/2506.04158) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://github.com/YujiaHu1109/IEAP) - [⭐️] **EditDuet**: A Multi-Agent System for Video Non-Linear Editing. [![arXiv](https://img.shields.io/badge/arXiv-2509.10761-b31b1b.svg)](https://arxiv.org/abs/2509.10761) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://mudtriangle.com/editduet) - [⭐️] **VideoAgent**: All-in-One Framework for Video Understanding and Editing. [![arXiv](https://img.shields.io/badge/arXiv-2606.23327-b31b1b.svg)](https://arxiv.org/abs/2606.23327) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://github.com/HKUDS/VideoAgent) - **CoSTA\***: Cost-Sensitive Toolpath Agent for Multi-turn Image Editing. [![arXiv](https://img.shields.io/badge/arXiv-2503.10613-b31b1b.svg)](https://arxiv.org/abs/2503.10613) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://github.com/tianyi-lab/CoSTAR) - **FaSTA\***: Fast-Slow Toolpath Agent with Subroutine Mining for Efficient Multi-turn Image Editing. [![arXiv](https://img.shields.io/badge/arXiv-2506.20911-b31b1b.svg)](https://arxiv.org/abs/2506.20911) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://github.com/tianyi-lab/FaSTAR) - **Lego-Edit**: A General Image Editing Framework with Model-Level Bricks and MLLM Builder. [![arXiv](https://img.shields.io/badge/arXiv-2509.12883-b31b1b.svg)](https://arxiv.org/abs/2509.12883) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://github.com/xiaomi-research/lego-edit) - **CanvasAgent**: Enabling Complex Image Creation and Editing via Visual Tool Orchestration. [![arXiv](https://img.shields.io/badge/arXiv-2607.05465-b31b1b.svg)](https://arxiv.org/abs/2607.05465) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://github.com/GML-FMGroup/CanvasAgent) - **IMAGAgent**: Orchestrating Multi-Turn Image Editing via Constraint-Aware Planning and Reflection. [![arXiv](https://img.shields.io/badge/arXiv-2603.29602-b31b1b.svg)](https://arxiv.org/abs/2603.29602) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://github.com/hackermmzz/IMAGAgent) - **RefineCut**, Plans You Can Check: Verifier-Grounded Learning of an Open-Weight Planner for Executable Video-Editing. [![arXiv](https://img.shields.io/badge/arXiv-2608.25622-b31b1b.svg)](https://arxiv.org/abs/2608.25622) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://github.com/Lancelot-wy/RefineCut) - **RAP**: turns a human poster into styled HTML/CSS with typed slots, then generates a new poster by retrieving a template and refilling those slots. RAP-150 holds out 150 papers for render-and-compare. [![arXiv](https://img.shields.io/badge/arXiv-2610.23230-b31b1b.svg)](https://arxiv.org/abs/2610.23230) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://reconstruct-a-poster.github.io/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/VincentHancoder/RAP) - **Back2Struct**: Making Structured Images Editable Again. Recovers object-level SVG/XML (text, shapes, topology, layout) from a raster diagram or chart, with rewards for compilability, length consistency, and structural similarity. The output imports into tools such as PowerPoint. [![arXiv](https://img.shields.io/badge/arXiv-2609.37016-b31b1b.svg)](https://arxiv.org/abs/2609.37016) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://pengyu965.github.io/Back2Struct.github.io/) - **ImageEye**: Batch Image Processing Using Program Synthesis. Synthesizes a neuro-symbolic DSL program from a few user-edited images. Guarded actions such as crop or blur apply to objects picked by pretrained perception models and symbolic relations, so one program processes a whole batch; it automates 48 of 50 evaluated tasks. [![arXiv](https://img.shields.io/badge/arXiv-2304.03253-b31b1b.svg)](https://arxiv.org/abs/2304.03253) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/celestebarnaby/ImageEye) - **SIRI**, Improving Unsupervised Visual Program Inference with Code Rewriting Families: parameter-optimization, pruning, and grafting rewriters improve inferred visual programs at test time. [![arXiv](https://img.shields.io/badge/arXiv-2309.14972-b31b1b.svg)](https://arxiv.org/abs/2309.14972) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://bardofcodes.github.io/coref/) - **Learning to Edit Visual Programs** with Self-Supervision: a network predicts a local edit that brings a complete program closer to a visual target. Under equal search time, edit-based search beats the one-shot predictor alone. [![arXiv](https://img.shields.io/badge/arXiv-2406.02383-b31b1b.svg)](https://arxiv.org/abs/2406.02383) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/rkjones4/VPI-Edit) - **Motion Vectorization**, Editing Motion Graphics Video via Motion Vectorization and Transformation: recovers an SVG motion program with explicit objects, motions, and per-frame occlusion order (average L2 RGB error 0.0086 over 38 web videos), then edits it through a transformation API, for example retiming object motion to a music beat. [![arXiv](https://img.shields.io/badge/arXiv-2309.14642-b31b1b.svg)](https://arxiv.org/abs/2309.14642) - **Differentiable 3D CAD Programs** for Bidirectional Editing: maps direct manipulation of the geometry back to updates of the existing CAD program's parameters. [![arXiv](https://img.shields.io/badge/arXiv-2110.01182-b31b1b.svg)](https://arxiv.org/abs/2110.01182) - **ParSEL**: Parameterized Shape Editing with Language. Turns a language request on a segmented mesh into a parameterized editing program whose parameters set the edit magnitudes. [![arXiv](https://img.shields.io/badge/arXiv-2405.20319-b31b1b.svg)](https://arxiv.org/abs/2405.20319) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://bardofcodes.github.io/parsel/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/BardOfCodes/parsel) - **DeTikZify**: Synthesizing Graphics Programs for Scientific Figures and Sketches with TikZ. MCTS-based inference refines the TikZ output without extra training. [![arXiv](https://img.shields.io/badge/arXiv-2405.15306-b31b1b.svg)](https://arxiv.org/abs/2405.15306) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/potamides/DeTikZify) - **StarVector**: Generating Scalable Vector Graphics Code from Images and Text. Writes SVG with primitives such as ellipses, polygons, and text, not only path curves. [![arXiv](https://img.shields.io/badge/arXiv-2312.11556-b31b1b.svg)](https://arxiv.org/abs/2312.11556) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://starvector.github.io) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/joanrod/star-vector) - **RefineSVG**: Visual Feedback-Driven Reinforcement Learning for Image-to-SVG Generation. Renders its first SVG, compares it with the target, and feeds the residual map back for a correction step. [![arXiv](https://img.shields.io/badge/arXiv-2607.27699-b31b1b.svg)](https://arxiv.org/abs/2607.27699) - **ShapeMOD**: Macro Operation Discovery for 3D Shape Programs. Discovers macros across datasets of shape programs; in a user study, the macros made interactive shape editing more efficient. [![arXiv](https://img.shields.io/badge/arXiv-2104.06392-b31b1b.svg)](https://arxiv.org/abs/2104.06392) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/rkjones4/ShapeMOD) - **ShapeCoder**: Discovering Abstractions for Visual Programs from Unstructured Primitives. Jointly discovers abstraction functions and programs that use them, so rewritten programs expose fewer free parameters. [![arXiv](https://img.shields.io/badge/arXiv-2305.05661-b31b1b.svg)](https://arxiv.org/abs/2305.05661) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/rkjones4/ShapeCoder) - **MaLiang-Harness**: A Programmable Path to Image and Video Generation. A generation framework rather than an editor: the visual program, its construction history, and its verification share one revision reference. Restoring earlier content creates a new revision that must pass verification. [![arXiv](https://img.shields.io/badge/arXiv-2609.34309-b31b1b.svg)](https://arxiv.org/abs/2609.34309) ## Benchmark ### Policy programs The agent writes, runs, or revises a robot control or learning program. - [⭐️] **RLE-Bench**: A Qualifying Exam for Coding Agents as Robot Learning Engineers. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://rle-bench.github.io/) - **CodeActionBench**: 25 simulated dual-arm tasks where the agent writes, runs, and revises code against a robot API with RGB and calibrated geometry, without depth or privileged state. [![arXiv](https://img.shields.io/badge/arXiv-2609.33807-b31b1b.svg)](https://arxiv.org/abs/2609.33807) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://codeactionbench.org/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/lyhkk/CodeActionBench) - **LIBERO-Agent**: general-purpose agents choose observations and issue native robot commands; the split is perception, short-horizon execution, and long-horizon manipulation. [![arXiv](https://img.shields.io/badge/arXiv-2609.39507-b31b1b.svg)](https://arxiv.org/abs/2609.39507) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/dzj441/Libero-Agent) - **RoboQuest**: general-purpose agents issue robot commands through tool calls on ten simulated kitchen mobile-manipulation tasks, searching, inspecting, or testing to find hidden information before pressing SUBMIT. Astra leads five frontier agents (23.2% success). [![arXiv](https://img.shields.io/badge/arXiv-2610.10388-b31b1b.svg)](https://arxiv.org/abs/2610.10388) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://declare-lab.github.io/RoboQuest/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/declare-lab/RoboQuest) - **AA-Robotics v0.1**: eight tabletop tasks on a real Hiwonder NexArm. A coding agent in an isolated container drives the arm through an HTTP API and four cameras, and a person scores the end state. GPT-6 Astra scores 69.4, first of five. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://artificialanalysis.ai/articles/aa-robotics) - **SEAR**: evaluates code-as-policy, live agent control, and agent-led VLA research, with controls that separate persistent skill memory from extra retry budgets. [![arXiv](https://img.shields.io/badge/arXiv-2610.18792-b31b1b.svg)](https://arxiv.org/abs/2610.18792) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://sear.bot/) - **PhysRSI-Eval**: 18 simulated tasks evaluate continued revision of skills, tools, policy code, and notes, separating initial ability, time to improvement, final score, budget, and recovery. [![arXiv](https://img.shields.io/badge/arXiv-2610.26848-b31b1b.svg)](https://arxiv.org/abs/2610.26848) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://physrsi-eval.github.io/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/PhysRSI-Eval/PhysRSI-Eval-code) - **EmbodiedSkillBench**: compares native control, skill-only execution, and agents that select, call, or modify skills on 100 perturbed LIBERO-Pro tasks, recording success and cost. [![arXiv](https://img.shields.io/badge/arXiv-2610.16238-b31b1b.svg)](https://arxiv.org/abs/2610.16238) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/HanZhi306/EmbodiedSkill-Bench) - **Embodied First Exam (EFE)**: freezes robot tasks across multiple benchmarks, asks agents to answer with executable programs, and validates those programs in an independent sandbox. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://www.embodied-first-exam.ai/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/mll-lab-nu/embodied-first-exam) ### World programs The agent writes an executable scene, CAD model, or physics program. A renderer or simulator then runs it. - [⭐️] **PhysCodeGym**: 156 tasks where a coding agent reconstructs a reference video as an executable Blender program. Scoring covers the rendered video and the scene's physical behavior, including counterfactual interventions. With Codex, GPT-6 Astra leads overall at 0.663. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/ShaoShuai0605/PhysCodeGym) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://huggingface.co/datasets/ShaoShuai0605/PhysCodeGym) - **4DCodeBench**: agents write executable code that reconstructs dynamic scenes from 200 videos. Astra Max leads 18 agents (overall 0.79) and leads dynamics by 31%. [![arXiv](https://img.shields.io/badge/arXiv-2610.03715-b31b1b.svg)](https://arxiv.org/abs/2610.03715) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://4dcodebench.com/) - **Video2World**: 222 tasks from 189 embodied videos; coding agents rebuild interactive simulated worlds. Astra ranks 2nd of 9 (V2WScore 43.55, 10.7% success) with the most accurate geometry, still far below the human-assisted reference. [![arXiv](https://img.shields.io/badge/arXiv-2610.04432-b31b1b.svg)](https://arxiv.org/abs/2610.04432) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://aetherlabsai.github.io/Video2World/) - **BVB**: the agent rebuilds each video as a Blender program, then answers spatiotemporal questions on that program. Astra high scores overall 70.07, rank 1 of 51 on the paper's frontier set. On the live leaderboard of 63 configurations (2026-10-14), Astra xhigh is 73.82, rank 1. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://frank-zy-dou.github.io/awesome-ai-3d-modeling-robotics/#3d-cad-and-spatial) - **WorldCoder-Bench**: Evaluating Executable Three.js Worlds. [![arXiv](https://img.shields.io/badge/arXiv-2606.01869-b31b1b.svg)](https://arxiv.org/abs/2606.01869) - **CodeVideoBench**: 22 editable Three.js cases for controllable video, covering gaming, scene editing, physics, and 3D/4D reconstruction. With MiniMax-H3, Code Video Model reports overall scores of 85.2 / 82.1 / 85.8 under QwenVL-3.8-27B, GPT-5.6, and GPT-6, versus 74.3 / 73.1 / 80.6 for VACE. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://huggingface.co/datasets/code-video-model/CodeVideoBench) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/code-video-model/CodeVideoModel) - **3JSBench**: 100 short text-to-Three.js tasks, with the generation requests and inspectable geometry. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/GeneralContext/3jsbench) - **BenchCAD**: multi-view renders to CadQuery, scored by mean voxel IoU. With tools, Astra is reported at 95.9%. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://frank-zy-dou.github.io/awesome-ai-3d-modeling-robotics/#3d-cad-and-spatial) - **Moonlake 3D Agent**: sim-ready asset benchmark across 22 metrics and Isaac Sim interaction tests; reported rank score 65.2 versus Astra 47.0. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://moonlakeai.com/blog/evaluating-3d-agent) - **BuildingBench**: a coding agent turns four photographs of a public building into one textured glTF. On the 2026-10-14 leaderboard, Codex CLI at ultra effort scores 0.843 ± 0.014, third of 32. Claude Opus 5.5 (max) leads at 0.868. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://enactra.ai/buildingbench/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/enactra-ai/building-bench) - **threejseval**: 16 fixed Three.js scene prompts. People vote between unlabeled scenes. Astra at medium effort is Elo 1884 ± 105, rank 4 of 36. Claude Opus 5.5 High leads at 2071. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://threejseval.com/ranking) - **MineBench**: the model writes JavaScript against a small voxel API (`block`, `box`, `line`), then people vote. Astra Pro is 2259 ± 16.7, rank 2 of 74. Gemini 4 Argon leads at 2269, and the two intervals overlap. The author does not call it a benchmark. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://minebench.ai/leaderboard) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/Ammaar-Alam/minebench) - **BlenderWorld**: 223 tasks. The agent turns text, image, or video references into an editable Blender project, scored on 2,651 binary criteria. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://blenderworld.github.io/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/QwenLM/BlenderWorld) - **LegoBench**: a coding agent rebuilds a brick model as LDraw from instructions, a finished-set photo, or a real-car photo. Scoring covers structural match and appearance. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://unifiedsense.com/blog/legobench) - **WorldBench**: one prompt asks for a floating voxel island with ten biomes, rivers, weather, and seasons. The model must return one self-contained Three.js HTML file, scored by what that program does when it runs. [![arXiv](https://img.shields.io/badge/arXiv-2610.10622-b31b1b.svg)](https://arxiv.org/abs/2610.10622) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://worldbench.krishbakshi.com) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/KrishBakshi/worldbench) ### Edit programs Editing benchmarks for structured visuals such as charts, SVG graphics, and slides, where the source program or structure can supply exact references. - **StructBench**, Factuality Matters: When Image Generation and Editing Meet Structured Visuals: generation and editing of charts, diagrams, and other structured visuals, scored by question answering. On ground-truth targets the metric first scored about 80%, and rose above 95% only after the failing questions were rewritten. [![arXiv](https://img.shields.io/badge/arXiv-2510.05091-b31b1b.svg)](https://arxiv.org/abs/2510.05091) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://structvisuals.github.io) - **ChartSync**: A Benchmark for Visuo-Logical Cascading Chart Editing. A GPT-5.5 pipeline that reconstructs plotting code from the chart image, edits it, and re-renders gets the highest OCR F1 (88.76) but a judged background fidelity of 37.44, against 89.60 for Nano Banana Pro. [![arXiv](https://img.shields.io/badge/arXiv-2607.10301-b31b1b.svg)](https://arxiv.org/abs/2607.10301) - **VeriEdit-Bench**, Beyond Plausibility: Verifiable Fine-Grained Image Editing on Structured Assets: compiles controlled edits to the source of SVG graphics, charts, web interfaces, and slides into exact target images and pixel-level edit masks. The unchanged input scores 100 on preservation and 0 on fidelity, localization, and magnitude. [![arXiv](https://img.shields.io/badge/arXiv-2610.04381-b31b1b.svg)](https://arxiv.org/abs/2610.04381) ### Robot evaluation infrastructure These evaluate robot policies broadly, including learned policies and program or command interfaces. They are policy-evaluation infrastructure, not code-generation benchmarks. - **XPolicyLab**: A Unified Standard and Open Ecosystem for Robot Policy Evaluation and Deployment. [![arXiv](https://img.shields.io/badge/arXiv-2608.09892-b31b1b.svg)](https://arxiv.org/abs/2608.09892) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/XPolicyLab/XPolicyLab) - **RoboDojo**: A Unified Sim-and-Real Benchmark for Comprehensive Evaluation of Generalist Robot Manipulation Policies. [![arXiv](https://img.shields.io/badge/arXiv-2607.04434-b31b1b.svg)](https://arxiv.org/abs/2607.04434) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/robodojo-benchmark/RoboDojo) - **HumanCLAW**: Can Vision-Language Models Act Through a Body? Tests VLM decisions through a harness that turns them into humanoid motion-generator calls. [![arXiv](https://img.shields.io/badge/arXiv-2607.27180-b31b1b.svg)](https://arxiv.org/abs/2607.27180) - **Robo Use Leaderboard**: aggregates published solve rates for agent harnesses and VLA policies, with 95% Wilson intervals. Each task counts once per model and harness. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://robouse.ai/hub/leaderboard/) ## Surveys and Lessons - **World Models for Embodied Intelligence: From Plausible to Controllable to Actionable**: surveys embodied world models by predictive plausibility, intervention controllability, and downstream decision utility. Useful context for executable and programmable world models. It does not require code as the intermediate representation. [![arXiv](https://img.shields.io/badge/arXiv-2609.16697-b31b1b.svg)](https://arxiv.org/abs/2609.16697) - **Robot-Use Agents** (Phillip Isola): perspective on general-purpose agents that use robots through sensor and actuator APIs. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://web.mit.edu/phillipi/www/writing/robot-use-agents.html) - **Goosebumps** (Ken Goldberg): argues that coding agents can write, test, and revise modular robot programs offline, between model-based engineering and robot learning. [![X](https://img.shields.io/badge/X-Post-black)](https://x.com/Ken_Goldberg/status/2100986412762087909) - **Multimodal Embodied Agents: A Unified Capability-centric Perspective from Computer-Use to Robot-Use**: unifies computer-use and robot-use as perceive, anticipate, plan, act, and verify. Broader than code-as-IR methods. [![arXiv](https://img.shields.io/badge/arXiv-2610.30108-b31b1b.svg)](https://arxiv.org/abs/2610.30108) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://showlab.github.io/Awesome-Multimodal-Embodied-Agent/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/showlab/Awesome-Multimodal-Embodied-Agent) - **Weights or Skills?** A Survey of Robot-Learning Techniques: from Action-Predicting Weights to Robots that Write their Own Skills: frames the split between frozen action-predicting weights and executable robot skills. [![arXiv](https://img.shields.io/badge/arXiv-2608.01851-b31b1b.svg)](https://arxiv.org/abs/2608.01851) - **Code as Agent Harness**: surveys executable, verifiable, stateful harness design for agents that write and run code. [![arXiv](https://img.shields.io/badge/arXiv-2605.18747-b31b1b.svg)](https://arxiv.org/abs/2605.18747) - **What Stops Recursive Self-Improvement in Robotics?** Lessons from 123 Rounds of Agentic Skill Discovery: reports an agent that wrote, installed, and tested skills, but never solved the target fridge task; relational perception, early-skill bottlenecks, and evaluator behavior were the main failure points. [![arXiv](https://img.shields.io/badge/arXiv-2609.31760-b31b1b.svg)](https://arxiv.org/abs/2609.31760) - **Harness Engineering for Physical AI**: argues that robot middleware should be the harness: it projects, isolates, and transfers control, compute, and communication around a model. [![arXiv](https://img.shields.io/badge/arXiv-2606.09416-b31b1b.svg)](https://arxiv.org/abs/2606.09416) - **Agentic World Modeling**: a survey of agentic world models, their capabilities, and the laws proposed for them. It is broader than code-as-IR methods. [![arXiv](https://img.shields.io/badge/arXiv-2604.22748-b31b1b.svg)](https://arxiv.org/abs/2604.22748) - **Towards Agentic Robots: Model, Data, Environment, and Harness**: organizes agentic-robot research into those four domains. Broader than code-as-IR methods; harness is one of the four. [![arXiv](https://img.shields.io/badge/arXiv-2610.20442-b31b1b.svg)](https://arxiv.org/abs/2610.20442) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/chonghanqin/Awesome-Agentic-Robots) - **Toward Recursive Self-Improvement in Physical AI**: surveys physical feedback that revises robot behavior and the procedures for subsequent improvement, distinguishing persistent gains from evidence attributable to recursion itself. [![arXiv](https://img.shields.io/badge/arXiv-2610.29677-b31b1b.svg)](https://arxiv.org/abs/2610.29677) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://physical2rsi.github.io/) ## Projects X posts, Xiaohongshu posts, and webpage-only systems. Papers stay in the sections above. Case catalog: [Awesome Astra Embodied AI](https://github.com/zjwzcx/Awesome-Astra-Embodied-AI). - [⭐️] **Awesome Astra Embodied AI**: GPT-6 Astra case catalog for embodied workflows. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/zjwzcx/Awesome-Astra-Embodied-AI) - **GPT-6 Astra** (OpenAI): coding agent used here as a robot policy, world programmer, and RL environment engineer. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://openai.com/index/gpt-6-astra/) ### Eval reports - **GPT-as-Policy**, Galbot: public benchmark and report that scores GPT-6 Astra as an embodied policy. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/anonymous-report-421/GPT-as-Policy) - **RoboCurve GPT-6 Astra evaluation**: controlled YAM-arm study; reports 19/20 bowl-task completions and 80% fewer output tokens. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://openai.robocurve.org/gpt-6-astra/) - **RPent** (RLinf): recursive harness that pairs an agentic planner with frozen VLA primitives. The leaderboard reports GPT-6 Astra at 92.63% overall on LIBERO-PRO (741/800) and 59.20% on RoboCasa365 Target50. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/RLinf/RPent) - **Astra on RoboMME**: three-tier controller on 16 RoboMME tasks; reports 79.13% success (633/800) with 3.63 Astra planning calls per episode. A fine-tuned π0.5 runs the subtask, and a Qwen3-VL-4B monitor decides when Astra should replan. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://bingaochen.github.io/Astra-on-RoboMME/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/bingaochen/Astra-on-RoboMME) - **RoboICL**: frozen Astra on 30 RoboDojo tasks; reports overall progress 50.64, zero-shot on Open and one demonstration elsewhere, plus three real-robot tasks. See also [RoboICL](#code-as-policy). [![Website](https://img.shields.io/badge/Website-Link-blue)](https://mosi-ai.github.io/RoboICL-GPT6-Astra.github.io/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/Mosi-AI/RoboICL) - **TacTalent**: few-shot GPT-6 Astra as a visuo-tactile policy inside the RoboICL loop, with no task-specific policy training. On 19 UniVTAC and OpenViTac simulation tasks, vision plus tactile reports 93.8% and 81.8% average success, against 76.3% and 80.6% for vision only. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://tactalent.github.io/) ### Policy programs in simulation - **UR10 conveyor sorting** (NVIDIA Omniverse): Astra builds a conveyor and inspection scene in VS Code, then wires a UR10 and Robotiq gripper to sort rejects. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://nvidia-omniverse.github.io/omniverse-labs/projects/astra-vscode-simulation/) - **G1 stage burpee**: a scripted Unitree G1 routine in public code: carry a stand on stage, hold a pose, do push-ups, then jump. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/Siriuslala/g1-robot-burpee) - **Dual-ALOHA Spatial-constraint Puzzles** ([Qineng Wang](https://x.com/qineng_wang)): plans Dual-ALOHA motions that unhook interlocked parts and thread a rope through three rings. [![X](https://img.shields.io/badge/X-Post-black)](https://x.com/qineng_wang/status/2099893504658866561) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://qinengwang-aiden.github.io/demos/constraint_demos/) - **Vision-only Humanoid Body Control** ([ZQ](https://www.rednote.com/user/profile/5f20ee17000000000101c247)): controls a simulated humanoid from camera observations only, with no privileged simulator state. [![Rednote](https://img.shields.io/badge/Rednote-Post-ff2442)](https://www.rednote.com/discovery/item/6aa7e0f6000000002b01297c?xsec_token=ABmjC06EQ2omZK2bVc-pqYOZHTFYlemRyPYY3Kj_9_a1g=&xsec_source=pc_search&source=web_search_result_notes) - **G1 Cola Bottle Pick-up in Isaac Sim** ([Flood Sung](https://x.com/RotekSong)): high-level plan for a Unitree G1 cola pick-up; GEAR-SONIC tracks the whole-body qpos. [![X](https://img.shields.io/badge/X-Post-black)](https://x.com/RotekSong/status/2099104628562608371) - **Quadruped Five-key-joint Trajectory** ([Akira Sasaki](https://x.com/gclue_akira)): outputs a sparse five-joint trajectory; a low-level controller runs the quadruped in MuJoCo. [![X](https://img.shields.io/badge/X-Post-black)](https://x.com/gclue_akira/status/2098300921658868185) - **G1 Navigation Tracked by SONIC** ([Flood Sung](https://x.com/RotekSong)): navigation plan for a simulated G1; GEAR-SONIC converts it into a whole-body trajectory. [![X](https://img.shields.io/badge/X-Post-black)](https://x.com/RotekSong/status/2098212303263183329/video/1) - **Robot Hands Solve a Rubik’s Cube** ([Ze Yanjie](https://x.com/ZeYanjie)): zero-shot dexterous cube solving in simulation. [![X](https://img.shields.io/badge/X-Post-black)](https://x.com/ZeYanjie/status/2098118164626501669) - **Dexterous Apple-stem Grasp in SuperDex** ([Kiki Huang](https://www.rednote.com/user/profile/62f72244000000001f0176ea)): dexterous hand grasps the narrow stem of an apple in SuperDex / MuJoCo. [![Rednote](https://img.shields.io/badge/Rednote-Post-ff2442)](https://www.rednote.com/discovery/item/6aa27b3a000000002b025d03?xsec_token=ABWznjLAd9oNPOxPF1Mc6ZfMK0VKAVH4AMkoYwkdPqQRw=&xsec_source=pc_search&source=web_profile_page) - **HumanCLAW-Bench** ([Jiawei Gu](https://x.com/Kuvvius)): completes benchmark navigation and interaction tasks through the HumanCLAW-Bench harness. [![X](https://img.shields.io/badge/X-Post-black)](https://x.com/Kuvvius/status/2098038921301311753) - **Whole-body Trajectory + Controller** ([橘子不是唯一的水果](https://www.rednote.com/user/profile/695bb2a2000000003702ea8f)): writes a whole-body trajectory; a whole-body controller closes the loop. [![Rednote](https://img.shields.io/badge/Rednote-Post-ff2442)](https://www.rednote.com/discovery/item/6a9fe4df00000000110341b8?xsec_token=ABMaVBcBS54ctuQIxmhMJMZVm36xy72xuPS8s6aICdfXM=&xsec_source=pc_search&source=web_profile_page) - **Isaac Sim Cube Grasp from One Prompt** ([神秘小孙](https://www.rednote.com/user/profile/5b3f9fc86b58b75d4c02ccc0)): one task sentence builds a depth-camera cube-grasp demo in Isaac Sim. [![Rednote](https://img.shields.io/badge/Rednote-Post-ff2442)](https://www.rednote.com/discovery/item/6aa017a8000000002b002341?xsec_token=ABeuYgBbxlsBRQGFSm3KRd7TFtNG2CtmpEnSxlcSsSC4E=&xsec_source=pc_like) - **Physically Writing a Fibonacci Sequence** ([Dmytro Hrybov](https://x.com/dimentary)): long-horizon G1 Fibonacci-writing task in simulation, ending in generated code and motion. [![X](https://img.shields.io/badge/X-Post-black)](https://x.com/dimentary/status/2097455860541009958) - **LLM Harness for Tabletop Robot Control** ([Jiafei Duan](https://x.com/DJiafei)): writes and runs the control loop for a simulated tabletop grasp-and-place task. [![X](https://img.shields.io/badge/X-Post-black)](https://x.com/DJiafei/status/2096601096705995155) ### Policy programs on a real robot - **Agent as Policy on a real YAM**: GPT-6 Astra in Codex writes and runs programs on a real arm, then revises them from camera feedback. Tasks include assembly from a human video, block building from a goal image, dice reorientation, throwing, and bimanual towel folding. See also [AGP](#code-as-policy). [![Website](https://img.shields.io/badge/Website-Link-blue)](https://agent-as-policy-2026.github.io/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/agent-as-policy-2026/agent-as-policy) - **Learning to Type on a Keyboard** ([Kaifeng Zhang](https://x.com/kaiwynd)): turns an open-ended “express yourself” prompt into real key presses with about 40 minutes of visual feedback. [![X](https://img.shields.io/badge/X-Post-black)](https://x.com/kaiwynd/status/2098823484474348008) - **Marker Grasp from Low-level Control Only** ([star大小变](https://www.rednote.com/user/profile/69c2311e000000003203e786)): discovers joint-to-end-effector control and grasps a marker in about 30 minutes, with no prior skills. [![Rednote](https://img.shields.io/badge/Rednote-Post-ff2442)](https://www.rednote.com/discovery/item/6aa4d7e200000000260145ff?xsec_token=ABur_B60E14GxVQp2ei3USGtEElW40SN75Vj5aB_USVUA=&xsec_source=pc_search&source=web_profile_page) - **Mobile Manipulation with In-context Learning** ([Axel](https://x.com/ax_pey)): infers mobile-manipulation behavior from visual context across rooms and layouts, without a task-specific text prompt. [![X](https://img.shields.io/badge/X-Post-black)](https://x.com/ax_pey/status/2098216469012283681) - **Rapid Adaptation to an Unseen Embodiment** ([Lucas Cassiano](https://x.com/lucascassiano)): learns a new robot and [Vitrus AI](https://x.com/Vitrus_ai) control interface online, without human egocentric data or a VLA. [![X](https://img.shields.io/badge/X-Post-black)](https://x.com/lucascassiano/status/2097830777438486557) - **ENPIRE Robotics Harness In-context Learning** ([Tonghe Zhang](https://x.com/TongheZhang01)): in-context robot learning through the ENPIRE harness, without task-specific retraining. [![X](https://img.shields.io/badge/X-Post-black)](https://x.com/TongheZhang01/status/2097801107602911243) - **Cucumber Slicing with Loop-ROS** ([盒子桥](https://www.rednote.com/user/profile/65bb8b3d000000000d03e137)): directly controls a real arm through Loop-ROS for a cucumber-slicing sequence. [![Rednote](https://img.shields.io/badge/Rednote-Post-ff2442)](https://www.rednote.com/discovery/item/6aa0c4900000000012034a2f?xsec_token=ABYB6HItIwwYq0Yyi9-hwoM-vMalkFRmYMAkN0iUWpTM4=&xsec_source=pc_search&source=web_profile_page) - **Painting the Golden Gate Bridge** ([thijs](https://x.com/cdngdev)): given a robot, a paintbrush, and a camera, turns a semantic prompt into real brush strokes and improves across attempts. [![X](https://img.shields.io/badge/X-Post-black)](https://x.com/cdngdev/status/2097339677128982873) - **Direct End-effector Pose Control** ([Loule](https://www.rednote.com/user/profile/69ddd8920000000033024ad0)): outputs end-effector poses to put the longest piece of bread into a basket, using third-person and wrist cameras. [![Rednote](https://img.shields.io/badge/Rednote-Post-ff2442)](https://www.rednote.com/discovery/item/6a9fc0710000000029015578?xsec_token=ABMaVBcBS54ctuQIxmhMJMZSAU7Wspgd3bmCnb4tQqHsU=&xsec_source=pc_search&source=web_profile_page) - **Piper Carrot Pick-and-place** ([虽然不但是](https://www.rednote.com/user/profile/5f5ca72900000000010061fb)): Codex / GPT-6 plus Piper and RealSense; repeated visual pick-and-place of a carrot. [![Rednote](https://img.shields.io/badge/Rednote-Post-ff2442)](https://www.rednote.com/discovery/item/6a9bd4c80000000028037f67?xsec_token=ABLUcokp8Tzdy13Avv1khxst1pWqWBaR7JLjQhUhWsSs4=&xsec_source=pc_like) - **SimEX on a dual-arm YAM**: after sim autoresearch, about ten minutes of real-robot time per task covers barcode scanning, plate-to-tote, and towel folding. See also [SimEX](#code-as-policy). [![Website](https://img.shields.io/badge/Website-Link-blue)](https://robo-simex.github.io/) - **Mocap whip and lasso** ([Krishna Suresh](https://krishnasuresh.org/blog/2026/robot-whips/)): one prompt builds IK, dynamics-constrained trajectory optimization, and an inverse-dynamics controller so an OpenarmX and an xArm7 replay whip cracking and cleat lassoing open-loop. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://krishnasuresh.org/blog/2026/robot-whips/) ### Plan, then call a VLA - **Harness VLA / RPent**: Astra plans with memory and visual feedback, then calls a frozen VLA plus a fixed library of analytic motion primitives. The real-robot demo sorts plates and retries a failed grasp without fine-tuning the VLA. See also [Harness VLA](#code-as-policy). [![Website](https://img.shields.io/badge/Website-Link-blue)](https://harnessvla.github.io/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/RLinf/RPent) - **Recursive Harness Distillation**: Astra distills robot problem solving into a playbook and revises it from Luna’s feedback, so Luna can steer a frozen VLA. See also [Recursive Harness Distillation](#code-as-policy). [![Website](https://img.shields.io/badge/Website-Link-blue)](https://seungyeon.me/RHD/) - **Astra on RoboMME**: Astra plans subtasks from instructions and visual history; a fine-tuned π0.5 executes them, and a fine-tuned Qwen3-VL-4B says when the subtask is done. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://bingaochen.github.io/Astra-on-RoboMME/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/bingaochen/Astra-on-RoboMME) - **Zero-shot Task Execution through FluxVLA** ([Jikun](https://www.rednote.com/user/profile/5e25bcdc00000000010085a8)): Astra does task inference and planning; pretrained [FluxVLA](https://github.com/FluxVLA/FluxVLA) runs the low-level actions. [![Rednote](https://img.shields.io/badge/Rednote-Post-ff2442)](https://www.rednote.com/discovery/item/6aa16835000000000b00f46d?xsec_token=ABDcu5eBZZYkAUcveAv8IZNWsbLmXk6CUM5u5BhDPODB0=&xsec_source=pc_search&source=web_profile_page) ### World programs from video - **Astra for 4D Shape Fitting** ([Edgar Sucar](https://x.com/SucarEdgar)): fits a 4D shape from video, using a human tip that leaves are symmetric to constrain the fit. Takes hours and back-and-forth prompting. [![X](https://img.shields.io/badge/X-Post-black)](https://x.com/SucarEdgar/status/2101739645759361322) - **Guan’s Fencing Club**: match video, two animated fencers, and a procedural hall on a UE5 timeline, with a one-second sword-tip trail. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/samguan2020/guans-fencing-club) - **AHa-3D**: Astra plus reconstruction tools turn indoor video into editable Blender rooms, recover human motion with contact refinement, and export a browser scene. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://kevinxu02.github.io/real2sim-indoor-site/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/KevinXu02/aha-3d) - **Real2Gym**: an agent rebuilds a Blender / MuJoCo gym from video, then runs generated Python stages with visual feedback before skill transfer. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/real2gym/Real2Gym) - **Lab Kitchen Reconstruction** ([Frank ZY Dou](https://www.rednote.com/user/profile/5e3431cf0000000001002919)): rebuilds a lab kitchen with articulated cabinets from a 20-second monocular RGB video. [![Rednote](https://img.shields.io/badge/Rednote-Post-ff2442)](https://www.rednote.com/discovery/item/6aa4d64c000000000b037809?xsec_token=ABur_B60E14GxVQp2ei3USGkgJntlivJm_02tlDaUFWmg=&xsec_source=pc_search&source=web_profile_page) - **Rope-driven Dexterous Hand Reconstruction** ([Dmytro Hrybov](https://x.com/dimentary)): recreates 1X’s tendon-driven hand demo in MuJoCo, with simplified tendon mechanics. [![X](https://img.shields.io/badge/X-Post-black)](https://x.com/dimentary/status/2097857980150763900) - **Tendon-driven Dexterous Hand Motion Reconstruction** ([Jake Fitzgerald](https://x.com/earthtojake)): designs a tendon-driven hand and reconstructs cable-actuated finger motion in simulation. [![X](https://img.shields.io/badge/X-Post-black)](https://x.com/earthtojake/status/2097789988670709821) - **Dexterous Hand-object Data Rollout** ([Lingxiao](https://x.com/Lingxiao234)): two videos drive real-to-sim reconstruction and physical retargeting onto Wuji hands, without explicit states or actions. [![X](https://img.shields.io/badge/X-Post-black)](https://x.com/Lingxiao234/status/2097717020540481630) - **Video in → Physics out** ([xiao hu](https://x.com/huxiao93612565)): writes hand tracking, IK retargeting, and grasp-refinement code for a 44-DoF hand. [![X](https://img.shields.io/badge/X-Post-black)](https://x.com/huxiao93612565/status/2097815230105399402) - **Multi-view Real-to-sim Reconstruction** ([Lingxiao](https://x.com/Lingxiao234)): builds a replayable MuJoCo / Blender simulator from multi-view RGB, robot actions, calibration, assets, and system identification. [![X](https://img.shields.io/badge/X-Post-black)](https://x.com/Lingxiao234/status/2096992059731443923) - **Robotica Real2Sim**: a table photo becomes a MuJoCo scene with a Franka Panda. Codex records 50 inverse-kinematics episodes, then a plan is replayed under physics variations. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/inematds/robotica-real2sim) - **AWSM**, Agentic World Simulation and Mapping: grounds agent-written Blender scene programs in camera-pose and depth evidence, then renders and revises them as editable spatial references for mapping and simulation. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://phygital-ai.github.io/agentic-world-simulation-and-mapping/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/wentingw/AWSM) ### RL training stacks - **Dexterous Astra** ([Jianglong Ye](https://github.com/jianglongye)): released artifacts from Astra experiments, not a harness given to the agent. Sharpa Wave pen spinning in Isaac Lab (a zero-shot keyframe planner, then PPO for three turns and a hold) and Wuji-hand Rubik's cube in MuJoCo (a zero-shot two-hand script, then a learned one-hand policy that solves `U F L`). [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/jianglongye/dexterous-astra) - **Office Real2Sim2Real Cart Push** ([watchtower](https://www.rednote.com/user/profile/5e38ca4e00000000010034fa)): rebuilds an office, estimates contact supervision, trains an RL cart-push policy with SONIC for whole-body motion, then deploys it on the real humanoid. [![Rednote](https://img.shields.io/badge/Rednote-Post-ff2442)](https://www.rednote.com/discovery/item/6ab34cfd0000000018005cab?xsec_token=CBoKOnuhKTqoyv12enaYThxB4L_a-12BnOafHa5vF3aRw=&xsec_source=app_share) - **Sharpa Hand Pen-spinning RL** ([Wentao Zhu](https://x.com/walterzhu8) / Chengyang Li): autonomous ~1.5-day run that builds the pen mesh, an Isaac Lab Sharpa-hand task, a PPO policy, and a visualization video. [![X](https://img.shields.io/badge/X-Post-black)](https://x.com/walterzhu8/status/2100212420840989112) - **RL-trained Duck Robot** ([拂晓时分_茉莉飘香](https://www.rednote.com/user/profile/5ffbc96d00000000010060ae)): one image and one description become an RL-trained duck locomotion demo. [![Rednote](https://img.shields.io/badge/Rednote-Post-ff2442)](https://www.rednote.com/discovery/item/6aa347e2000000000b036667?xsec_token=AB1z4k50CvQ0PFZpqtQXWYlVMONqE2yr3ER8jk-hVWI74=&xsec_source=pc_search&source=web_profile_page) - **Quadruped Locomotion from RL** ([Akira Sasaki](https://x.com/gclue_akira)): co-designs a robot dog, iterates 25 loops in five days, and trains nine simulated motions with RL. [![X](https://img.shields.io/badge/X-Post-black)](https://x.com/gclue_akira/status/2098300921658868185) - **Dexterous In-hand Manipulation RL** ([十一](https://www.rednote.com/user/profile/610bc8f100000000200284e2)): trains in-hand walnut manipulation; the reported run did not enable self-collision. [![Rednote](https://img.shields.io/badge/Rednote-Post-ff2442)](https://www.rednote.com/discovery/item/6aa3e146000000002b0123dc?xsec_token=AB5n_GSvnshtGoIJqykTNpkWlIS-zHnIYe2n5pAiGLSgw=&xsec_source=pc_like) - **Office Scan → Newton / G1 Gym** ([Jiarui Xu](https://x.com/Jiarui_X)): rebuilds an office scan in Blender, exports USD, and makes a G1 walking scene in Newton. [![X](https://img.shields.io/badge/X-Post-black)](https://x.com/Jiarui_X/status/2098439950991806804) - **Isaac Sim Environment, PPO Training, and Tuning** ([十一](https://www.rednote.com/user/profile/610bc8f100000000200284e2)): builds an Isaac Sim RL environment, configures PPO, and iterates the run in one workflow. [![Rednote](https://img.shields.io/badge/Rednote-Post-ff2442)](https://www.rednote.com/discovery/item/6aa29087000000002600bb2e?xsec_token=ABupW63bXfa1dAqIk6vaYviNev-xOXuTmePvxk8Su9NK4=&xsec_source=pc_collect) ### Scene programs Astra writes a scene, CAD model, or playable world as code, then Blender, OpenSCAD, Three.js, or a game engine runs it. The full set is 414 Astra examples in [Awesome Astra 3D](https://github.com/carpentry-liu/awesome-astra-3d) ([gallery](https://carpentry-liu.github.io/awesome-astra-3d/)). Entries below are source-backed starting points, grouped by the program that gets executed. Video-only renders stay in that atlas. - [⭐️] **Awesome Astra 3D**: Blender, Houdini, Three.js, CAD, VRM, and interactive-game case catalog. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/carpentry-liu/awesome-astra-3d) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://carpentry-liu.github.io/awesome-astra-3d/) #### Executable scenes - **Solace**: architectural iteration through Blender, Cycles, and UE5. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://developers.openai.com/blog/architectural-visualization-with-astra) - **Pelican on a bicycle**: three Blender iterations with editable meshes and recorded conversations. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/simonw/gpt-6-astra-blender-pelican-bicycle) - **GPTBlender floor plan**: turns a floor plan into a furnished four-bedroom Blender home. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://gptblender.com/turn-floor-plan-into-3d-model-gpt6-astra/) - **Realsee**: scan to an editable Blender space, with roaming video and prompts. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/realsee-developer/realsee-astra-blender) - **Orbital Core**: Blender and GLB assets inside an interactive Three.js page. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/wangruofeng/orbital-core-showcase) - **Piața Unirii**: same brief, voxel square, prompt and source kept. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/danmana/piata-unirii) - **Real2Sim rooms**: photos to editable rooms, with failed reconstructions kept in the repo. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/Roboparty/gpt-6-astra-real2sim-workflow) - **Jetis**: DWG factory walkthrough exported as a native SketchUp model. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/bambssquad/jetis-digital-twin-astra) - **WorldGen**: three text scenes built in Blender and Unity. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/andyyuyc/WorldGen_Unity) - **Junya city generator**: JSON road networks become an editable Blender scene, then Unreal renders. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/junya-tashiro/agent-jp-citygen) - **Renders**: four Blender architecture projects with revision scripts and an archive of older cuts. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/lucas-chu/Renders) - **Stanford in Blender**: five editable campus scenes, with procedural scripts and standalone `.blend` files. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/minsik-ai/stanford-in-blender) - **Gulou campus**: a walkable Nanjing University campus in TypeScript, Three.js, and Rapier, with cycling, gliding, and weather. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/wang-jiahao/gulou) - **Gargantua**: a shader accretion disk and bent light, with an orbit camera. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/pedroaugustonyo/gargantua) - **BHBench**: Astra’s native black-hole renderer, with the generated C++ / GLSL, ray integration, and a curvature grid. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/SSHdotCodes/bhbench/tree/main/submissions/gpt-6-astra-xhigh) - **One Equation, Three Worlds**: one Lorenz curve kept as an editable copper sculpture, procedural ink, and moving light. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/davisbuilds/oneshots/tree/main/runs/three-worlds-chatgpt) - **Gemera**: a public Koenigsegg Gemera Blender scene. Astra handles material logic and asset integration; the geometry comes from existing assets. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/ITzNomadic/koenigsegg-gemera-blender) - **Single-image tabletop**: one RGB photo becomes a Blender scene. Codex and Blender MCP place occluded objects and revise the scene for up to five rounds. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/anhao-zhang/gpt6-blender-reconstruction) - **Hina**: a procedural umbrella character in Three.js, with a four-side inspection viewer and a static GLB. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://ecooxai.github.io/hina-gpt6-astra-pro-chatgpt-threejs/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/ecooxai/hina-gpt6-astra-pro-chatgpt-threejs) - **A Frontier for the Zeros**: a Manim fly-through of a zeta-function surface, kept as editable Python. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/HarleyCoops/Math-To-Manim/tree/main/papers/quasi-riemann) #### CAD programs - **J-hook**: OpenSCAD print design compared across models; strength testing still pending. [![X](https://img.shields.io/badge/X-Post-black)](https://x.com/WescheNex1q/status/2104590493191479337) - **Villa, recursive film, turbine CAD**: three editable 3D projects in one repo. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/az9713/gpt-6-3d-projects) - **Realitizer**: Swift code-first models of a manta ray and a house. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/koher/realitizer) - **Aetheris difference engine**: hierarchical CAD of digit wheels, carry gears, and a crank, with STEP export. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/yuechen-li-dev/Aetheris/tree/master/demos/Aetheris.DifferenceEngine.Showcase) - **LDraw Nova**: Python generators emit editable LDraw cathedrals and a tidal observatory. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/anteloc/ldraw-nova) - **DeepSeek whale**: a logo silhouette becomes an editable single-solid desktop print mesh. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/shyrz/gpt-6-astra-3dp-test) #### Playable world programs - **Living Deep**: extends an existing ocean simulation with underwater ecology. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/emollick/abyssal-living-deep) - **Smash Karts**: multiplayer client, server, and a public agent trajectory. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/amsminn/gpt-6-astra-smash-karts) - **Little Flock**: one-shot pasture world, with the goal prompt in the repo. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/songkeys/little-flock) - **Windfield**: 3D adventure plus a terrain editor. [![X](https://img.shields.io/badge/X-Post-black)](https://x.com/fuguai1/status/2104531704740512143) - **Melon Jelly**: WebGPU soft-body comparison. [![X](https://img.shields.io/badge/X-Post-black)](https://x.com/esrhengwu/status/2104504957173153951) - **Pelagic**: procedural ocean and sailboat exploration. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/az9713/gpt-6-astra-3D-ocean) - **H3 Battle Lab**: 3D units wired to native VCMI combat. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/yzh119/h3-battle-lab) - **Seabright**: Unity coastal city builder with roads, services, and taxes. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/codersusu/game-city-skylines) - **Octane Arena**: procedural 3D car soccer with source for the physics. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/Goofykings/Octane-Arena) - **Astra Air Combat**: seeded arenas and a 60 Hz dogfight loop. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/FLYING37520/astra-air-combat) - **Palm Bay**: a preserved one-shot low-poly driving sandbox, with the original prompt and recovered JavaScript. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/nitzangames/PalmBayOneShot) - **Corner Mart**: an editable convenience store with shopping lists and a three-minute shift, plus the `.blend`, GLB, and generation scripts. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/ericyanpek/game-sample-corner-mart) - **Hallowmere**: a torchlit village RPG with procedural characters, combat, and co-op. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/miguelsolorio/hallowmere) - **Morrow**: an interactive moonlit plush ghost in one HTML file, with grab, poke, brush, and color controls. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/Kayou-31/moonlit-plush-gallery/blob/main/morrow.html) - **Moss & Moon**: a procedural fox and woodland ecosystem in Three.js, with a skeleton, foot IK, and need-driven pathfinding. The Astra submission is kept in its own folder. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/hdnng/ai-3d-animal-astra-vs-argon-vs-opus/tree/main/astra) - **Sunline Archipelago**: a tropical island railway in Blender and a Three.js viewer, with walking and a train-follow camera. [![Website](https://img.shields.io/badge/Website-Link-blue)](https://givros.github.io/sunline-archipelago/) [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/givros/sunline-archipelago) ## Related Resources - **Awesome Physical AI**: broader curated reading list for robot-policy VLMs, coding agents, policy harnesses, and RoboDojo-style scorecards. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/HexaFuture/Awesome-Physical-AI) - **Awesome Robot Use Agent**: catalog of robot-use agents, harnesses, ROS tool stacks, and social demos. Entries here keep only the ones that use a program as the intermediate representation. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/kairunwen/Awesome-Robot-Use-Agent) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://kairunwen.github.io/Awesome-Robot-Use-Agent/) - **Awesome AI for 3D Modeling & Robotics**: source-linked cases for AI 3D modeling, CAD, and robot control, plus benchmark numbers read from the original reports. Social clips stay in that catalog. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/Frank-ZY-Dou/awesome-ai-3d-modeling-robotics) [![Website](https://img.shields.io/badge/Website-Link-blue)](https://frank-zy-dou.github.io/awesome-ai-3d-modeling-robotics/) - **Awesome Multimodal Embodied Agent**: computer-use and robot-use agents, from surveys through benchmarks. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/showlab/Awesome-Multimodal-Embodied-Agent) - **Awesome Embodied RSI**: embodied recursive self-improvement, grouped by what gets updated: model, memory, skills, or harness. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/cocacola-lab/awesome-embodied-rsi) - **Awesome Humanoid Robot Learning**: humanoid locomotion, manipulation, teleoperation, and sim-to-real. Most entries are learned policies, not programs. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/YanjieZe/awesome-humanoid-robot-learning) - **Awesome Embodied Robotics and Agent**: embodied robotics methods and benchmarks. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/zchoi/Awesome-Embodied-Robotics-and-Agent) - **Awesome Agentic Robotics**: agent, harness, and VLA stacks for robot control. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/w-xb/awesome-agentic-robotics) - **Awesome Agentic World Modeling**: world models sorted into predictor, simulator, and evolver. [![GitHub](https://img.shields.io/badge/GitHub-Repo-black)](https://github.com/matrix-agent/awesome-agentic-world-modeling)