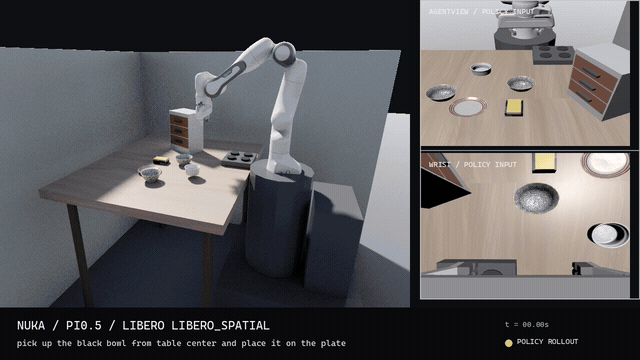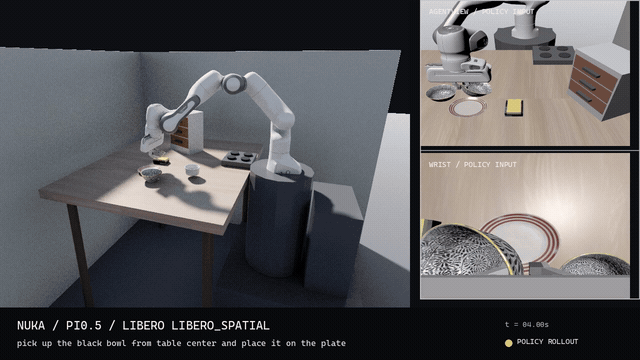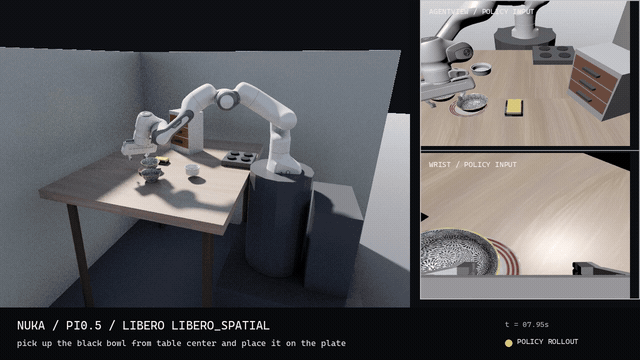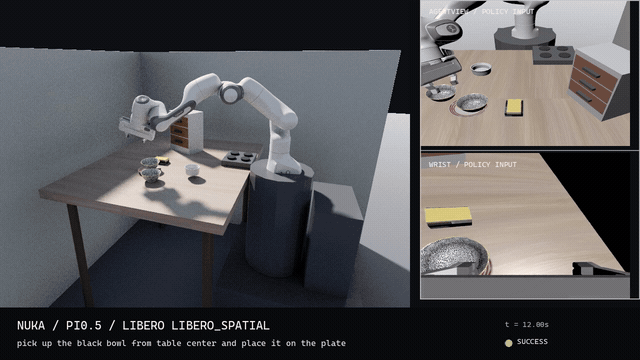
π0.5 Inference Vision-language-action · LIBERO pick and place
Full video · Run demo
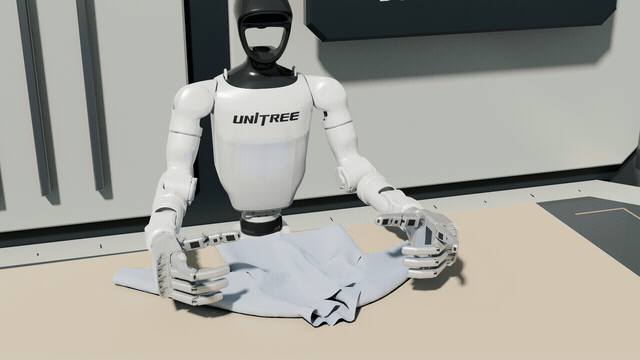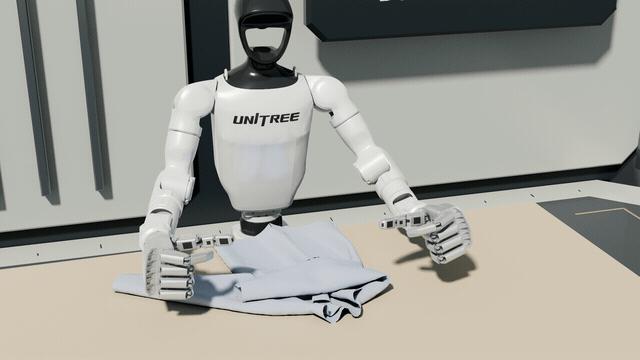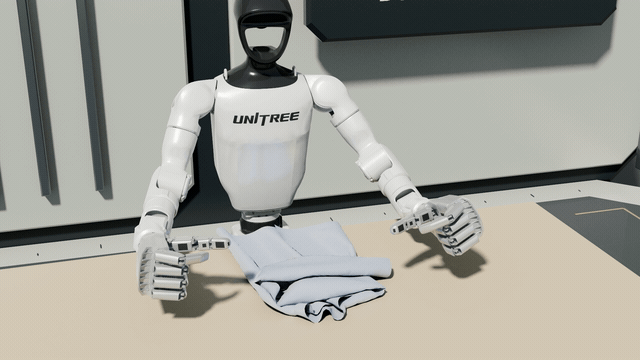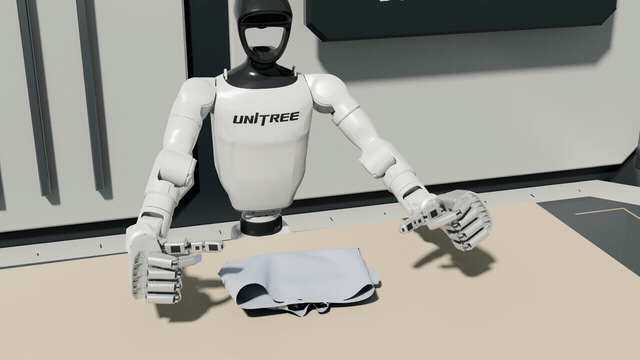
G1 Shirt Folding Robot–cloth coupling · Shirt folding
1080p video
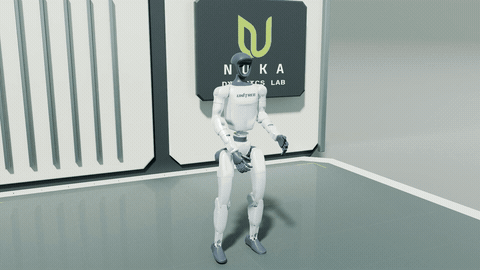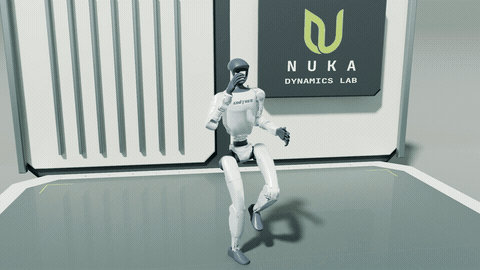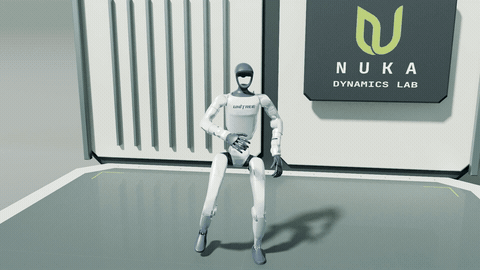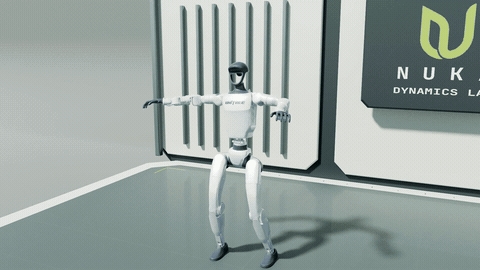
G1 Dance 29-DoF humanoid · Shuffle policy inference
Full video · Run demo
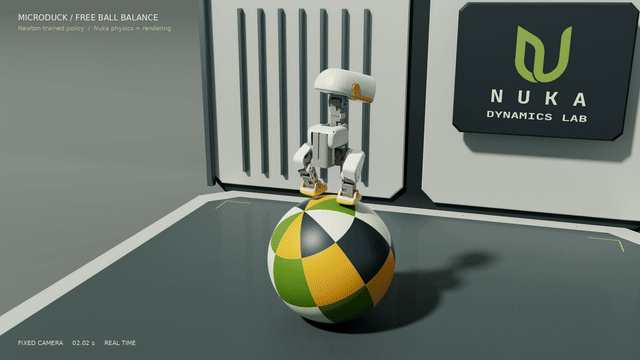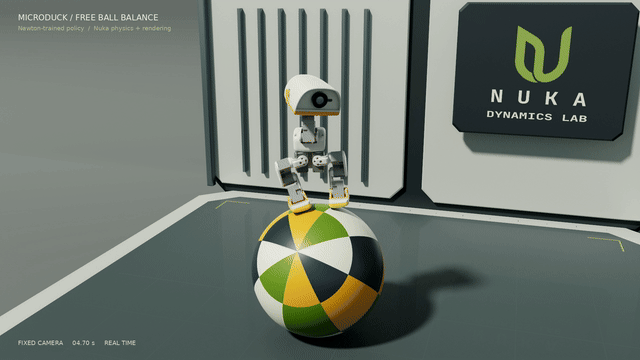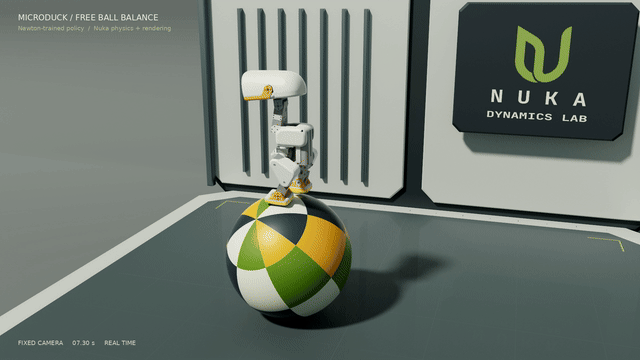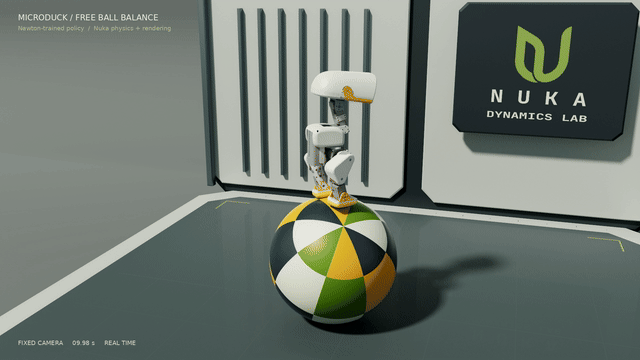
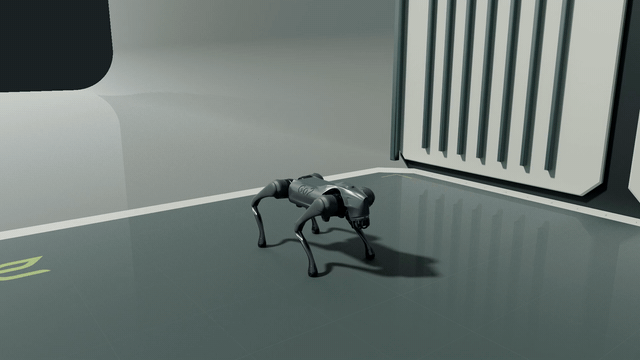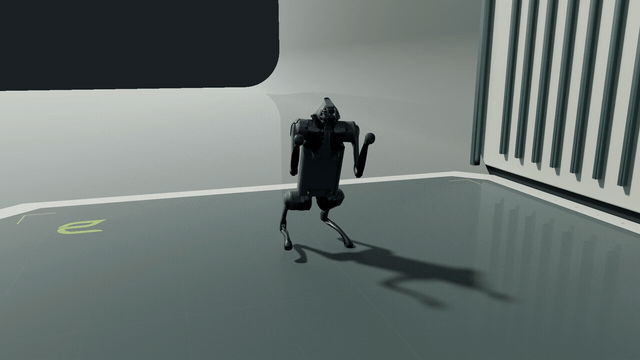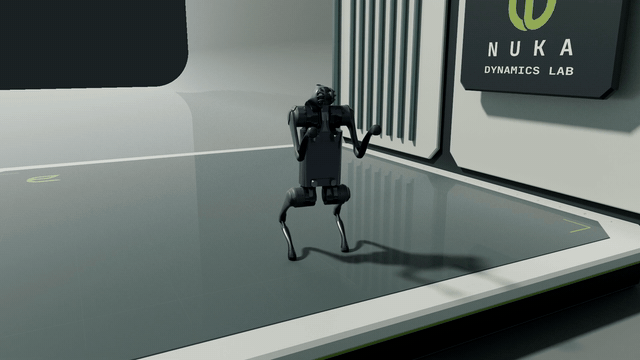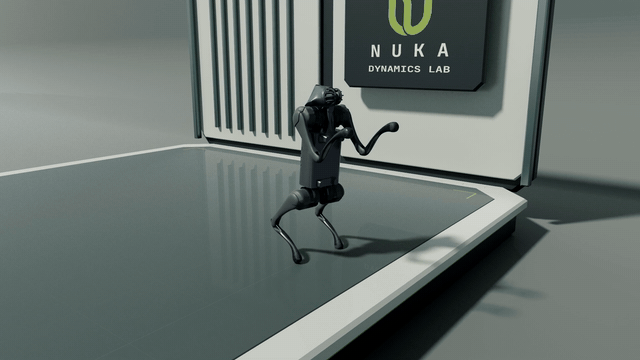
Microduck Ball Balance Pure Nuka Physics RL
1080p video
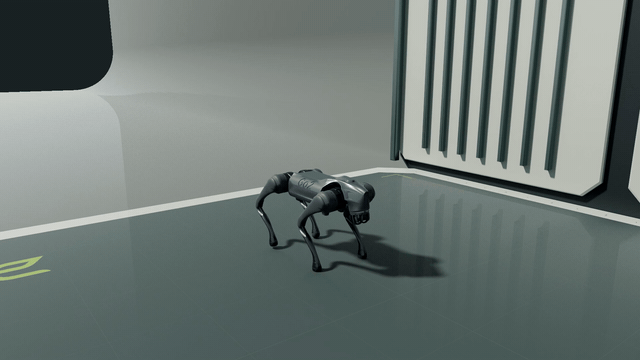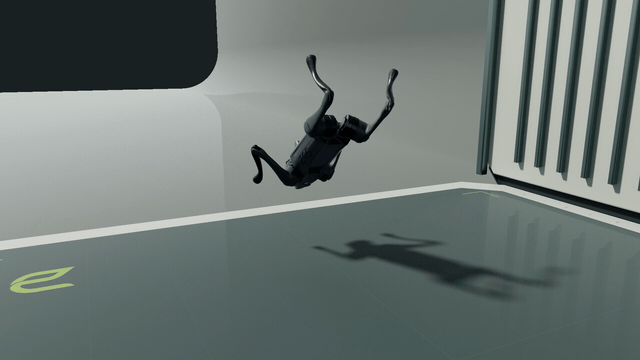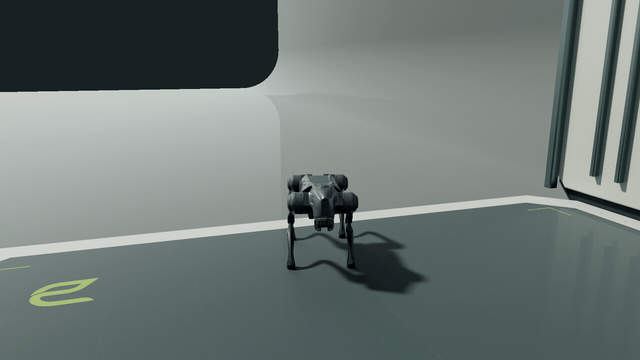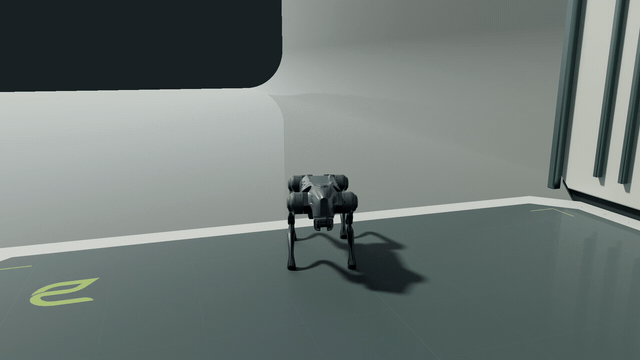
Go2 Backflip TorchScript policy inference
1080p video
Go2 Handstand TorchScript policy inference
1080p video
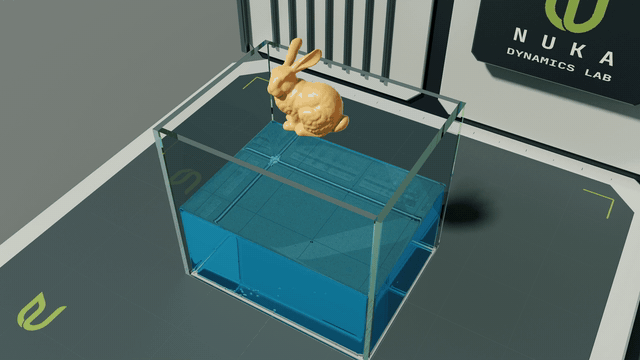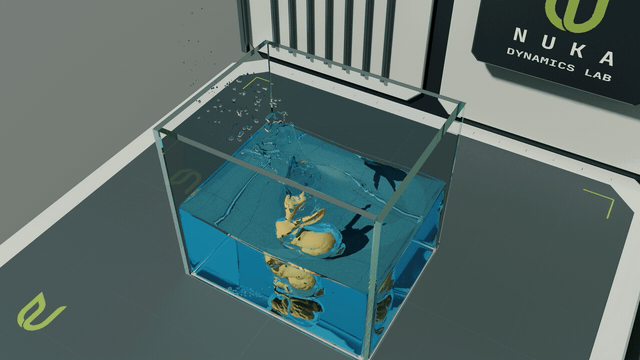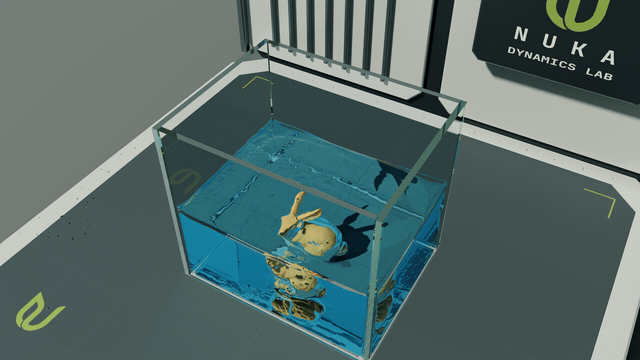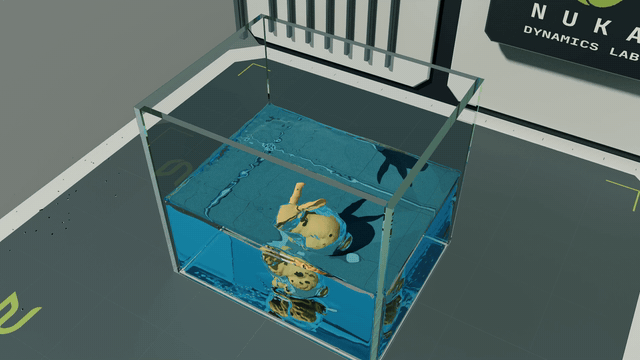
Bunny × Water Two-way MLS-MPM coupling · 2× slow motion
1080p video · Run demo
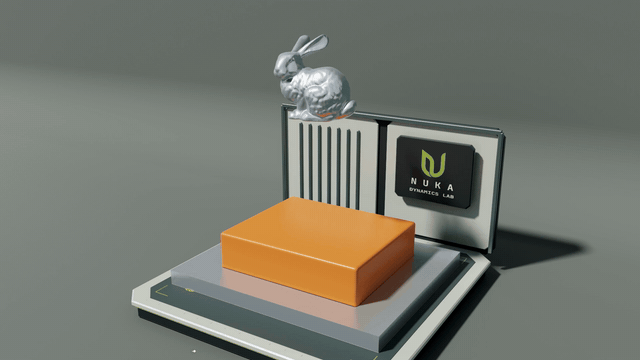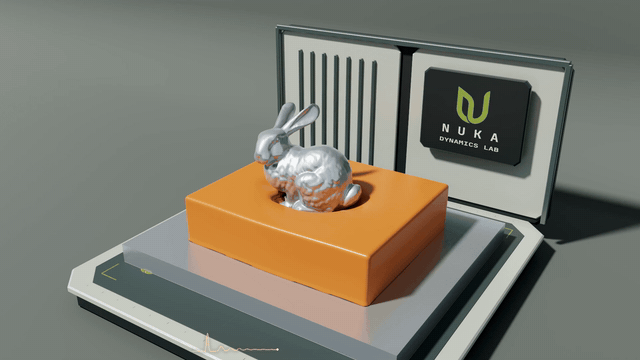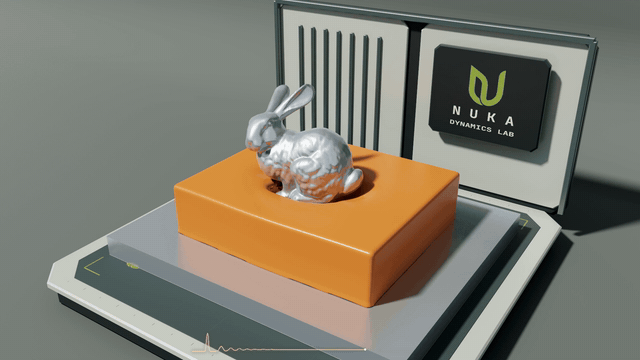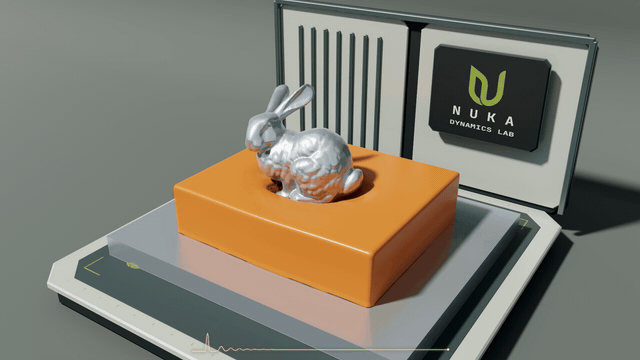
Bunny × Elastoplastic Free fall · Plastic indentation · Real time
1080p video · Run demo
Material demos load the shared [Nuka Dynamics Lab assets](docs/nuka-stage.md), with a layered experiment deck, warm grey panels and avocado green accents. Layouts, materials, lights and cameras are editable in NKS. Existing gallery recordings retain their recorded environment and physics. The Microduck clip replays recorded Nuka physics with a Newton-trained balancing policy on a freely moving ball.
## Why Nuka
- **GPU-resident at scale.** One cooked world template drives thousands of independent environments on one GPU.
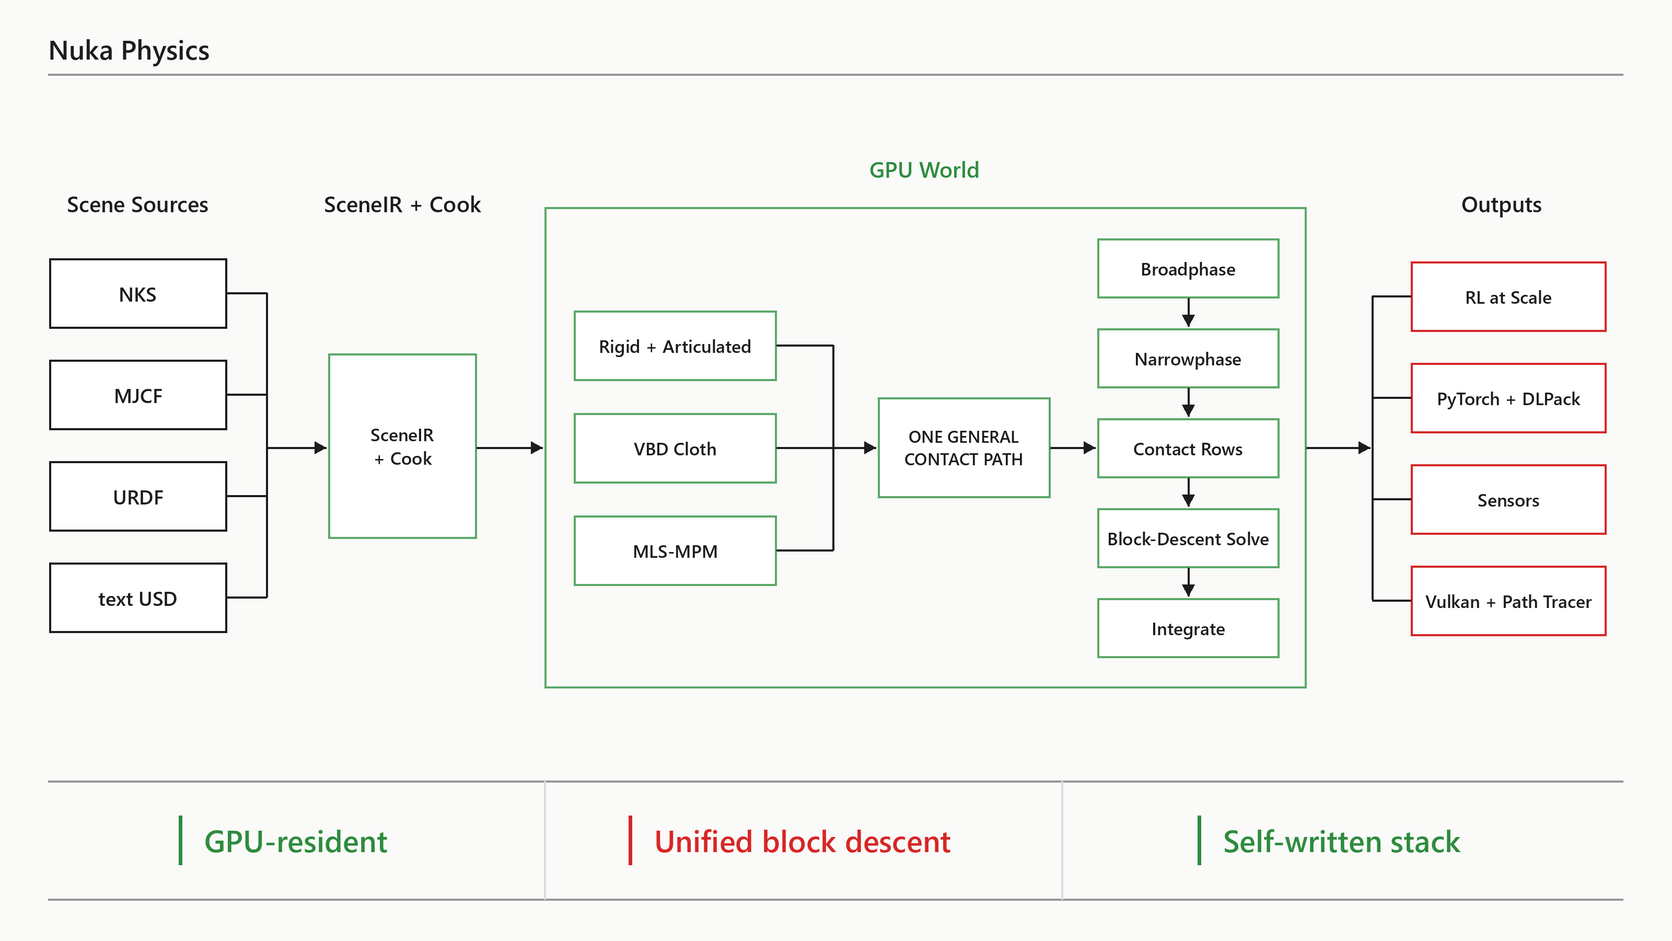
- **One solver.** Robot, rigid, cloth, and MLS-MPM contacts all run through one unified block-descent (UABD) solve.
- **Self-written stack.** CUDA physics, importers, Vulkan rendering, and a CUDA path tracer, with no external physics or rendering SDK.
## Architecture
| Layer | Core modules | Responsibility |
| --- | --- | --- |
| Authoring | `scene`, `import` | NKS, MJCF, URDF, and text-USD → SceneIR → cooked model |
| Simulation | `nk`, `collision`, `constraint` | GPU world, broadphase, narrowphase, contact rows, block-descent solve |
| Platform | `phi`, `sensor`, `render`, `rt` | CUDA backend, sensors, Vulkan raster, CUDA path tracer |
## Capabilities
| System | Status |
| --- | --- |
| Rigid + articulated dynamics (Featherstone / ABA) | Production |
| Contact, terrain, and heightfields | Production |
| Unified block-descent contact solve (UABD) | Production |
| VBD cloth and cables | Functional |
| MLS-MPM elastic and elastoplastic solids | Functional |
| Two-way robot / rigid / cloth / MLS-MPM coupling | [Functional](docs/concepts/coupling.md) |
| Sensors with calibration and noise models | [Functional](docs/concepts/sensors.md) |
| Batched RL with PyTorch and DLPack | Functional |
| Vulkan raster + CUDA path tracing | Functional |
## Quick Start
Requires Linux, CUDA 12.8, g++-10, CMake 3.20+, Python 3.10+, and an NVIDIA GPU.
```bash
export CC=gcc-10 CXX=g++-10
cmake -S . -B build-cuda128 \
-DNK_BUILD_TESTS=ON \
-DNK_REQUIRE_CUDA=ON \
-DNK_PHYSICS_BACKEND=CUDA
cmake --build build-cuda128 -j
pip install -e python
```
Step 4096 Go2 environments from PyTorch:
```python
import torch
import nuka
with nuka.Device.create(0) as device:
world = nuka.World.create_from_scene(
device, "examples/scenes/go2_locomotion.usda", env_count=4096
)
q = torch.from_dlpack(world.buffer_view(nuka.JOINT_POSITION))
target = torch.from_dlpack(world.buffer_view(nuka.DRIVE_TARGET))
target[:, 1:].copy_(q[:, 1:])
world.step()
nuka.sync()
world.destroy()
```
Train Go2 locomotion (needs `rl_games==1.6.5`), or run the [material demos](examples/demo/README.md):
```bash
CUDA_VISIBLE_DEVICES=0 python examples/training/train_go2_ppo.py --num_actors 4096
```
## Documentation
[Getting started](docs/getting-started.md) · [Architecture](docs/concepts/architecture.md) · [Isaac Lab compatibility](docs/concepts/isaaclab-compat.md)
## License
Nuka Physics is dual-licensed under [AGPL-3.0](LICENSE) or a [commercial license](LICENSING.md). See [NOTICE](NOTICE), [CONTRIBUTING.md](CONTRIBUTING.md), and [SECURITY.md](SECURITY.md).