

# 🐭 Toshiba Micromouse
**Autonomous 16×16 Maze-Solving Robot**
*Register-level firmware on Arm Cortex-M4*
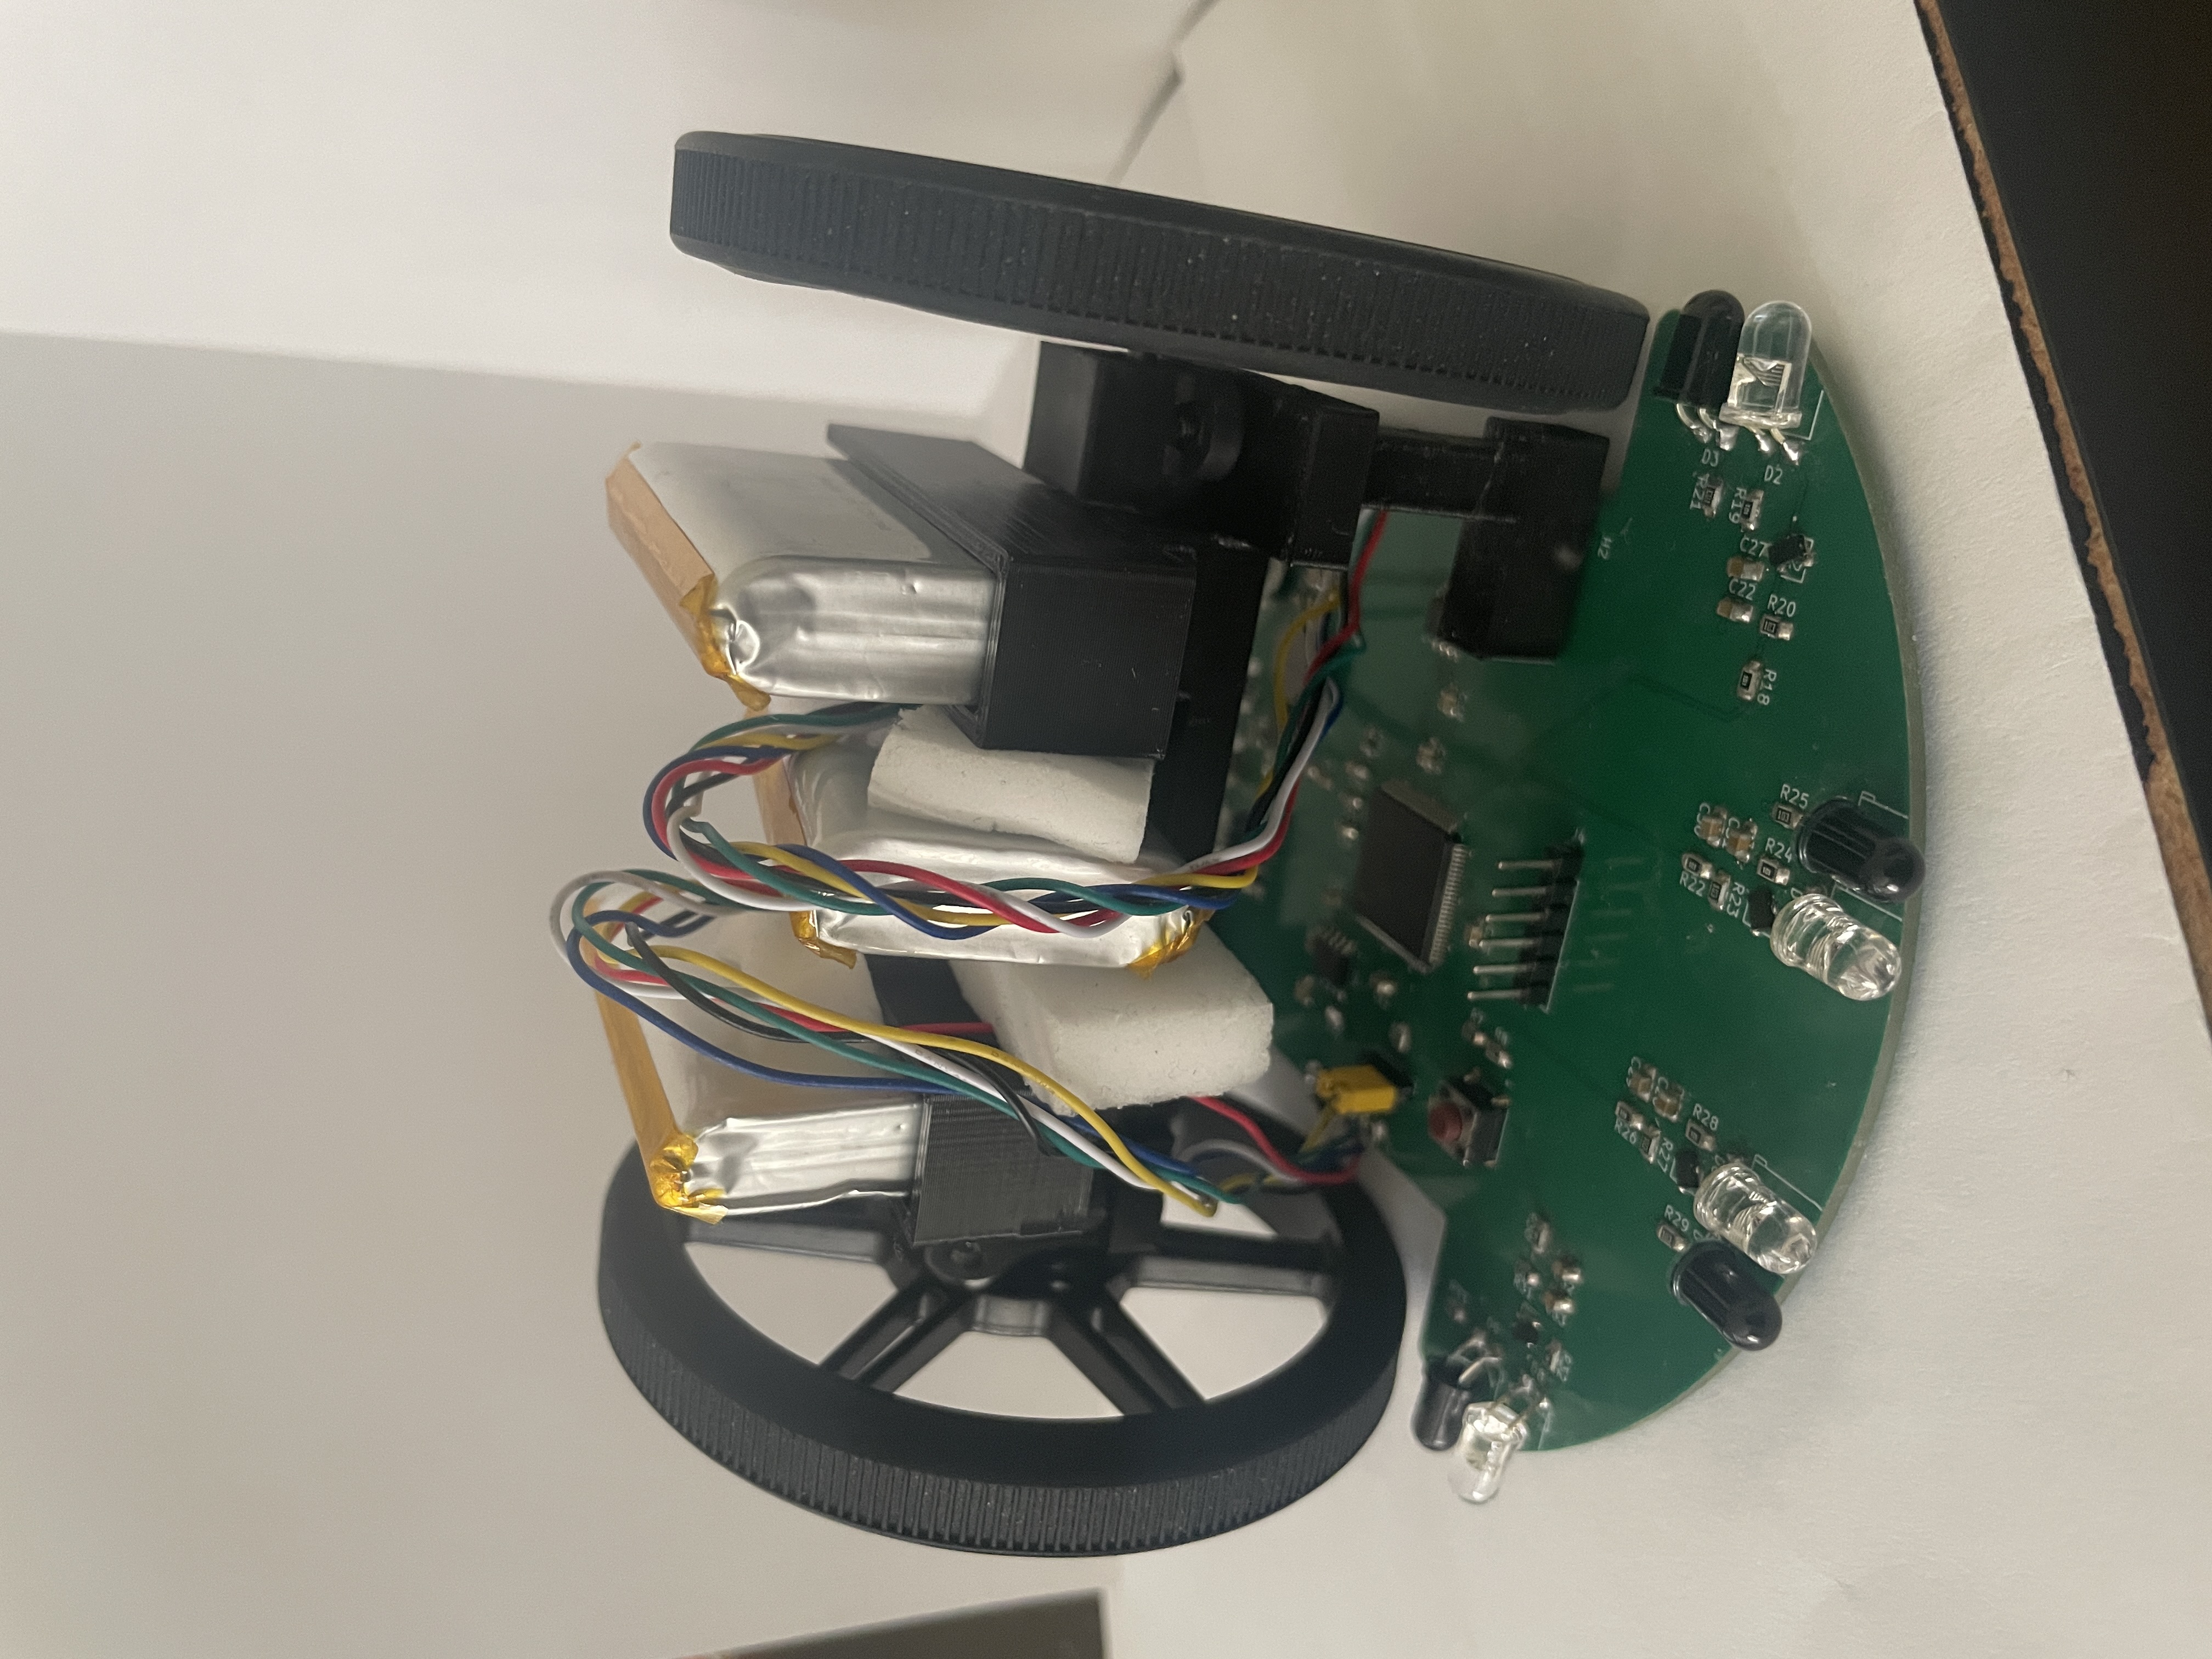
*Robot exploring and solving the maze*
### **Toshiba TMPM4KNF10AFG**, Arm Cortex-M4 with FPU
The TMPM4KNF10AFG comes from the **[M4K Group](https://toshiba.semicon-storage.com/us/semiconductor/product/microcontrollers/txz4aplus-series/m4k-group.html)** of Toshiba's **[TXZ+™4A Series](https://toshiba.semicon-storage.com/us/semiconductor/product/microcontrollers/txz4aplus-series.html)**, a line of 160 MHz Arm Cortex-M4 microcontrollers built for motor and inverter control. It pairs a fast floating-point core with dedicated on-chip hardware for driving motors, reading encoders, and sampling analog sensors. The same parts show up in BLDC/PMSM drives, HVAC compressors, power tools, and factory automation, and they carry IEC 60730 self-diagnosis support for appliance functional safety.
| Capability | Role in this build |
|-----------|--------------------|
| Cortex-M4 @ 160 MHz + FPU | Navigation, PID, and flood-fill maze solving |
| On-chip motor & encoder hardware | Wheel feedback and PPG-generated motor PWM |
| High-speed analog sensing | IR wall detection |
Here the same silicon runs a much smaller problem: a 1 kHz driven by an interrupt and closed-loop PID over two brushed DC gear-motors. Dedicated hardware handles encoder counting and motor PWM, so the CPU stays free for navigation and flood-fill maze solving.
---
## Built With
|
|
|
|
|
|
|
|:---:|:---:|:---:|:---:|:---:|:---:|
| **Arm Cortex-M4** | **Keil µVision** | **KiCad** | **Fusion 360** | **Git** | **MATLAB** |
| Register-level C | IDE / Build / Flash | 4-layer PCB | Chassis CAD | Version Control | Data Analysis |
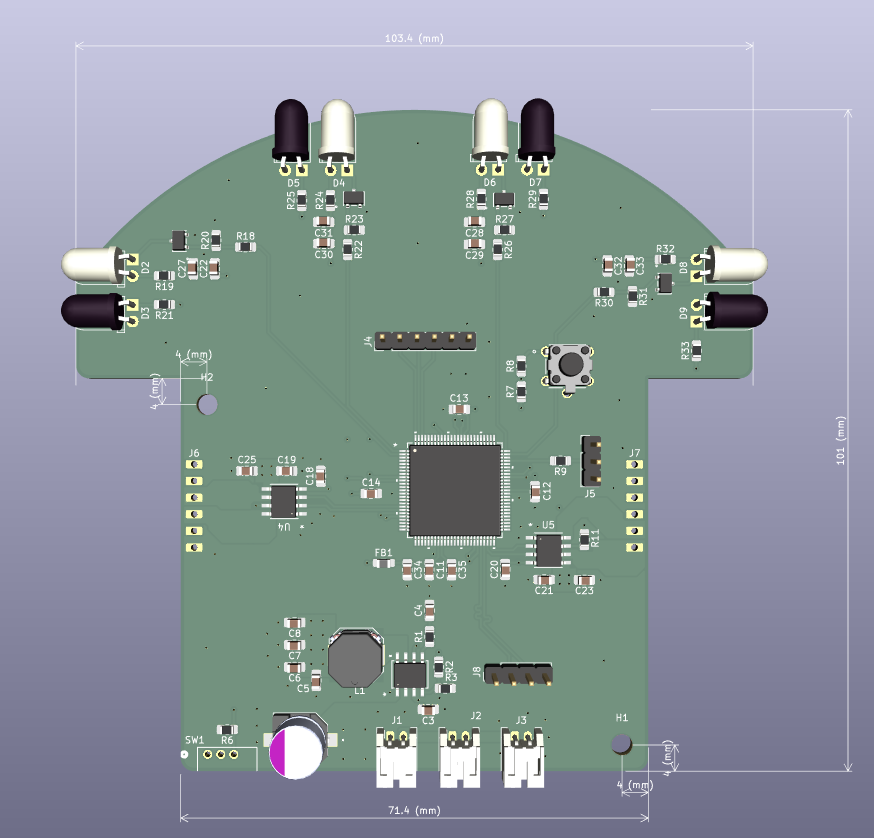
*Custom PCB*
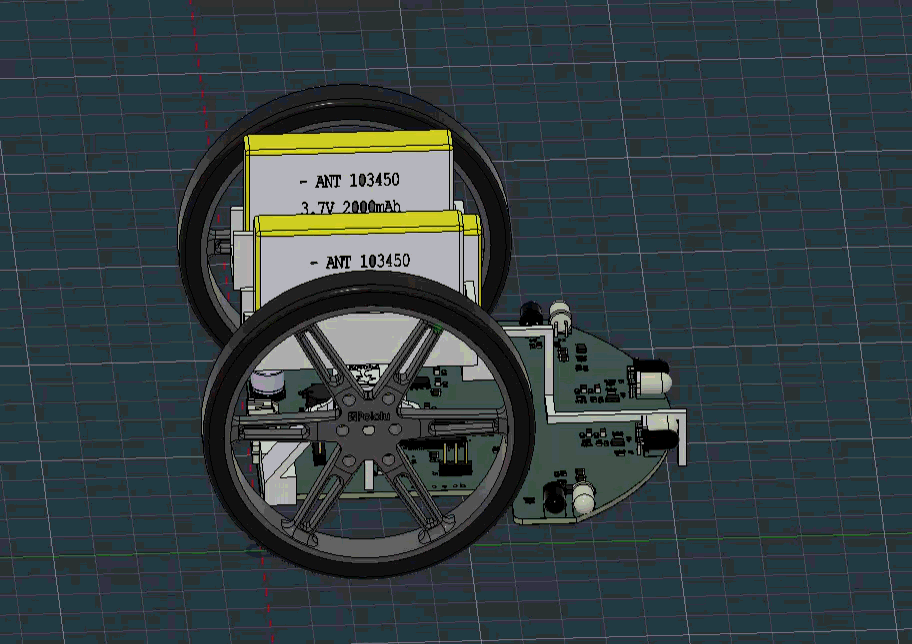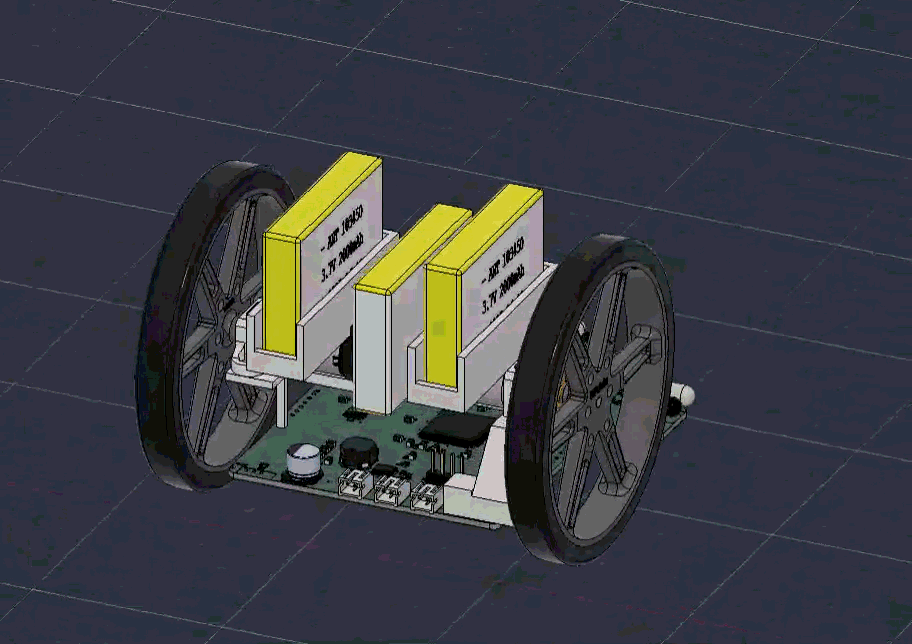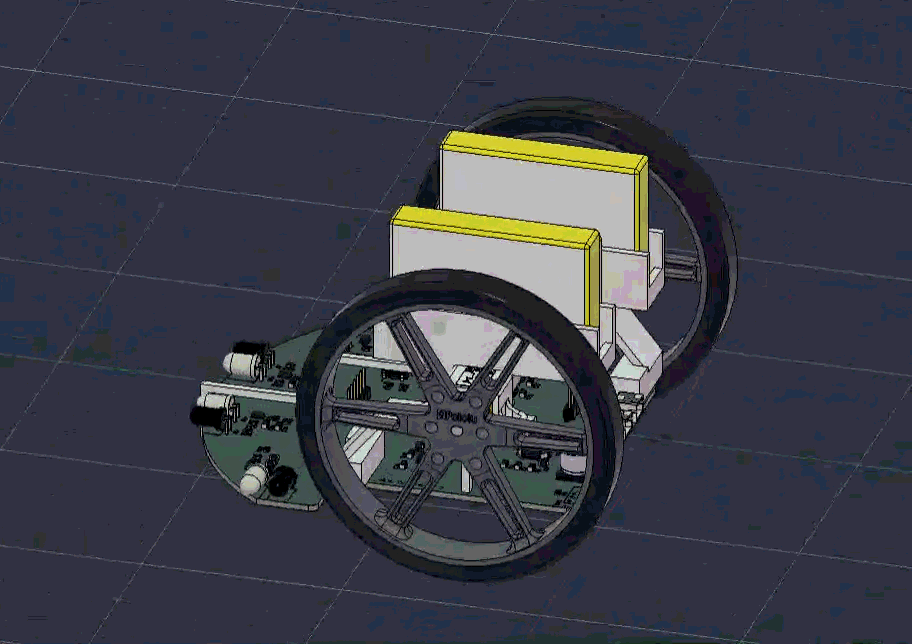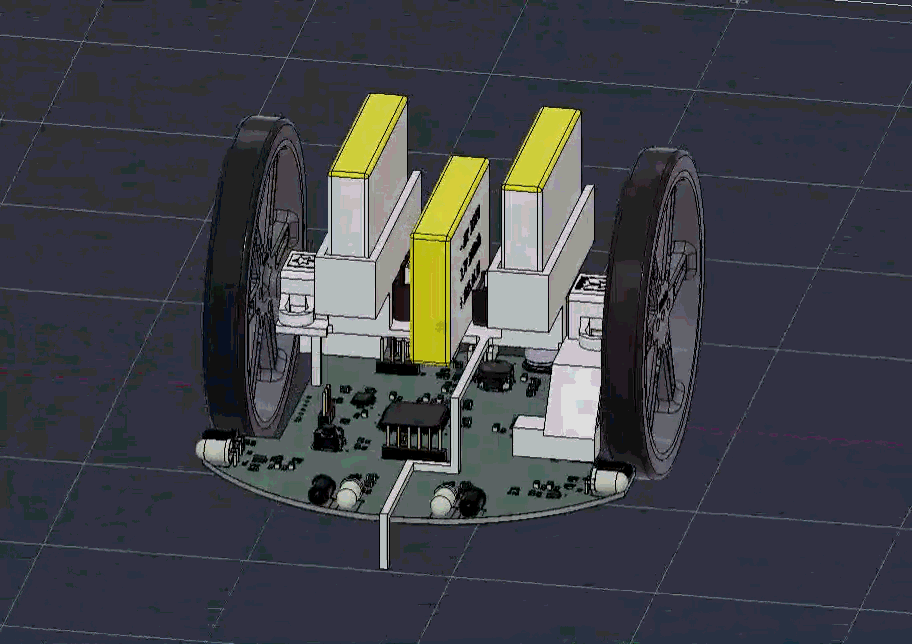
*(Outdated Version) Fusion 360 render of the full mechanical assembly*
---
## Documentation
| Path | Contents |
|------|----------|
| [`src/README.md`](src/README.md) | Firmware architecture, control loops, pin map, timer config |
| [`hardware/README.md`](hardware/README.md) | Hardware overview: chassis (Fusion) + PCB (KiCad) |
| [`hardware/pcb/README.md`](hardware/pcb/README.md) | Board specs, layout, schematic, component list |
| [`docs/README.md`](docs/README.md) | Docs index: assets, evidence, and analysis tooling |
| [`docs/evidence/README.md`](docs/evidence/README.md) | Module-test checklist and captured evidence |
---
## Quick Start
```text
IDE: Keil µVision
Target: TMPM4KNF10AFG (Arm Cortex-M4)
Debug: CMSIS-DAP
Flash: 512 KB on-chip
```
[`Quick Start`](docs/README.md)
---
**Kevin Le** • 2026