**English** | [中文](README_cn.md)
[](LICENSE)
[](#ros-1--2)
[](#mujoco)
[](#isaac-sim--isaac-lab)
# luna-description
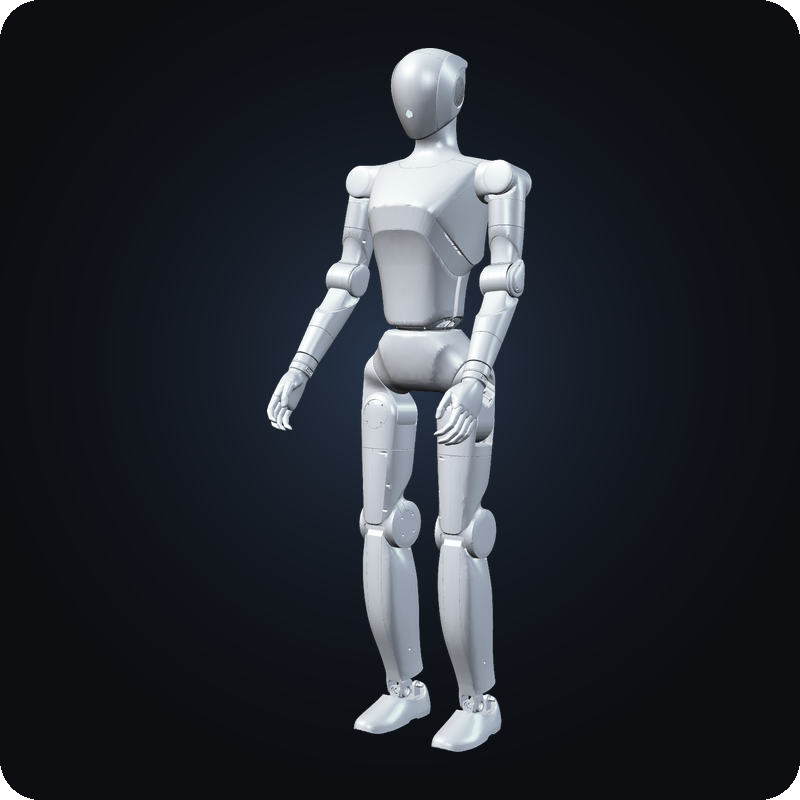
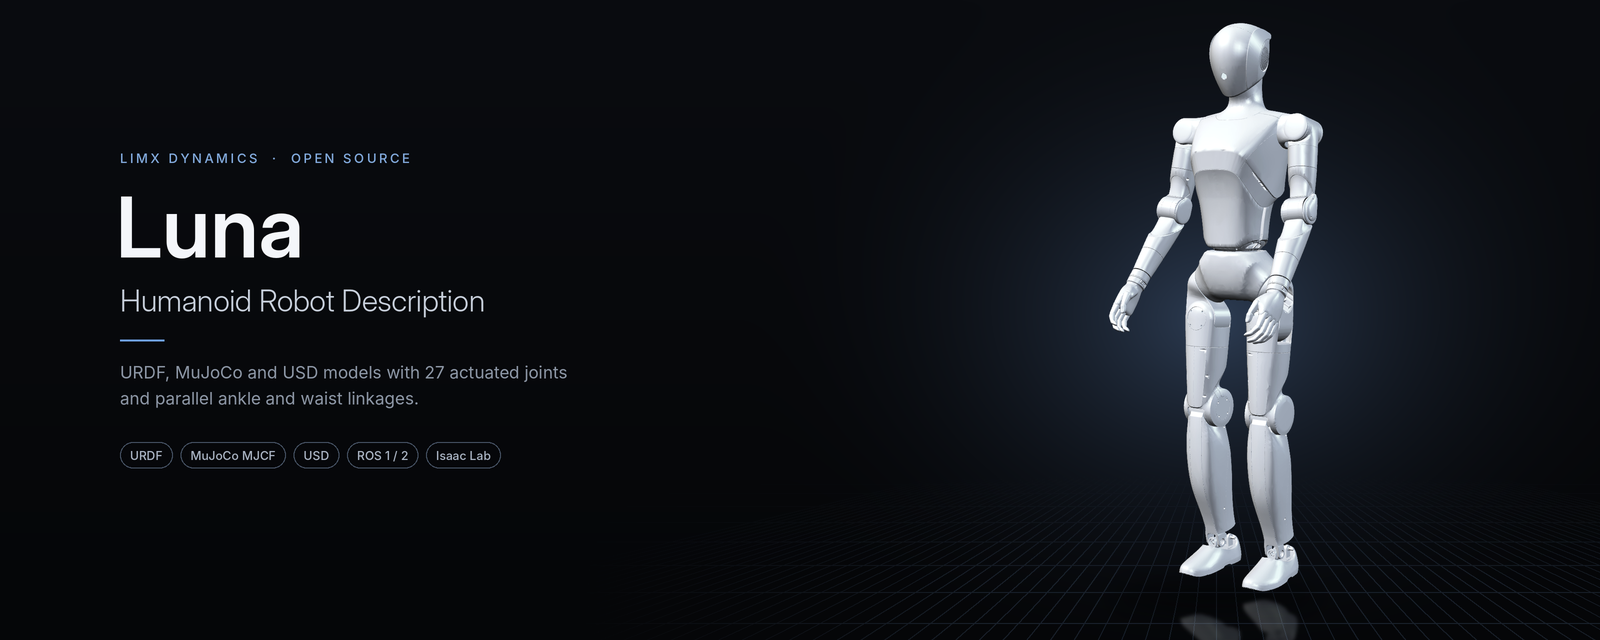
URDF, MuJoCo MJCF & USD models for the LimX Dynamics Luna humanoid robot (HU_L04). Provides simulation-ready robot descriptions for ROS, MuJoCo, and NVIDIA Isaac Sim / Isaac Lab.
## Highlights
- **Full-body humanoid, 27 actuated joints.** Legs, a 3-DoF waist, a 2-DoF head and 5-DoF arms, with `rotor_mass` and `gear_ratio` per joint in the SRDF.
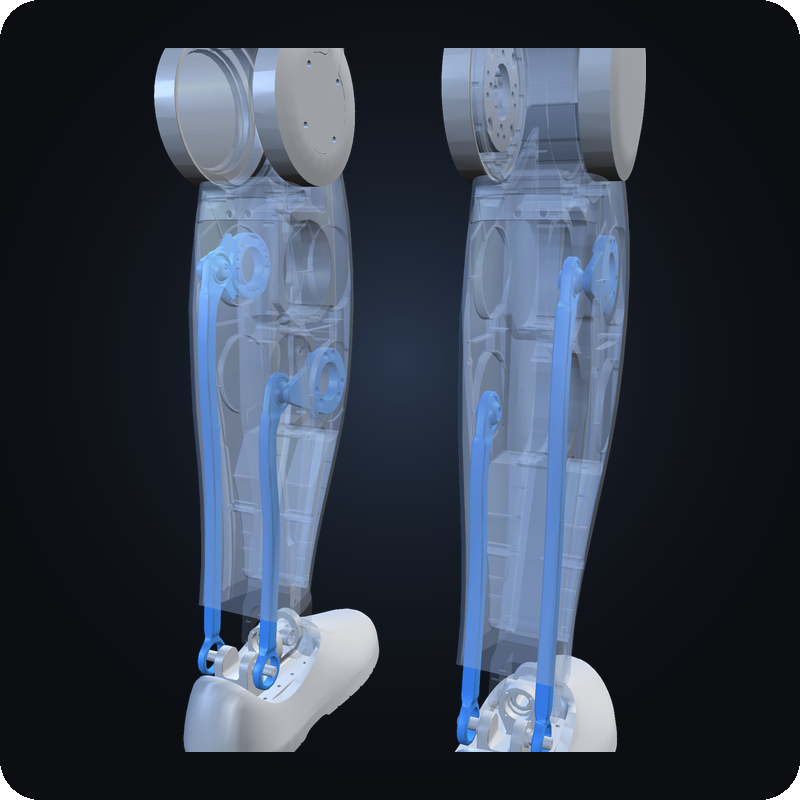
- **Parallel linkages modeled faithfully.** The ankles and waist are driven through parallel linkages; the MJCF expresses them with `equality` constraints and `usd_parallel/` as true closed loops.
- **One robot, every simulator.** URDF for ROS, MJCF for MuJoCo, USD for Isaac Sim / Isaac Lab, all from the same geometry.
- **Ready for learning pipelines.** The MJCF ships actuators plus joint position/velocity and IMU sensors, and a kinematics-only variant for motion retargeting.
## Try it in 30 seconds
No ROS needed:
```bash
git clone https://github.com/limxdynamics/luna-description.git
cd luna-description
pip install mujoco
python -m mujoco.viewer --mjcf=HU_L04_description/xml/HU_L04_01.xml
```
## Available models