# Jaxonomy
**Differentiable simulation of hybrid dynamical systems — powered by JAX.**
[](https://pypi.org/project/jaxonomy/)
[](https://www.python.org/)
[](https://github.com/machinavitalis/jaxonomy/blob/main/LICENSE.md)
[](https://py.jaxonomy.com)
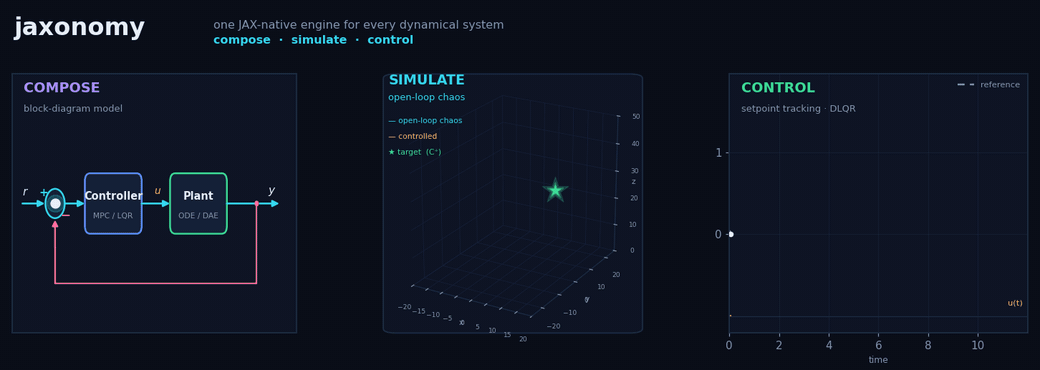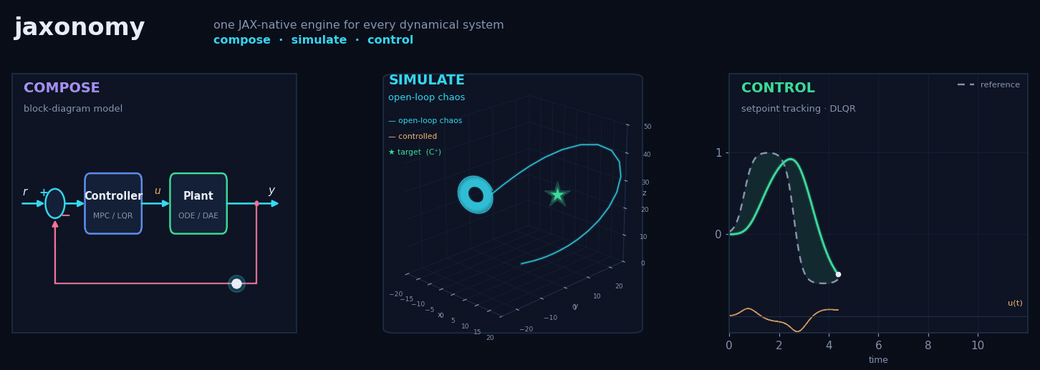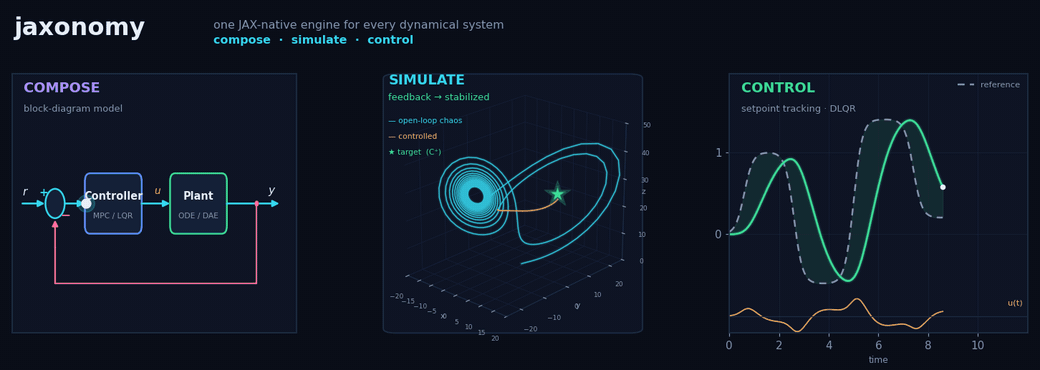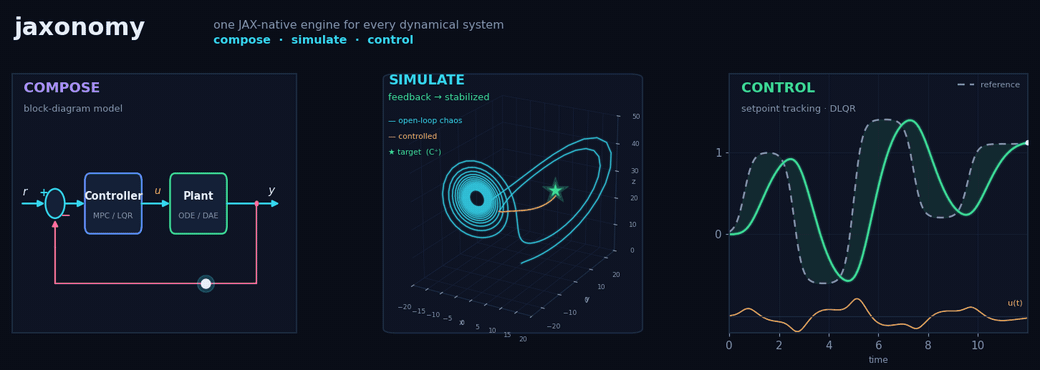
*Block diagrams meet automatic differentiation. Model physical systems, close the loop with LQR/MPC/Kalman, and differentiate through everything.*
**[Why JAX?](#-why-jax)** · **[Install](#-installation)** · **[Quick Start](#-quick-start)** · **[Gallery](#-gallery)** · **[Examples](#-examples)** · **[Docs](https://py.jaxonomy.com)**
Every panel above is produced by jaxonomy.simulate on a model built from the library.
---
## What is Jaxonomy?
Jaxonomy is a Python framework for modeling, simulating, and optimizing **hybrid dynamical systems** — systems that combine continuous physics, discrete control laws, and event-driven logic in a single model. Every simulation runs on **JAX**, so it is JIT-compilable, batchable with `vmap`, and **fully differentiable from end to end**.
```python
import jax.numpy as jnp
import jaxonomy as jx
# Double integrator: A, B, C, D define the plant; Q, R weight the LQR cost.
A, B = jnp.array([[0., 1.], [0., 0.]]), jnp.array([[0.], [1.]])
C, D = jnp.eye(2), jnp.zeros((2, 1))
Q, R = jnp.eye(2), jnp.array([[1.]])
builder = jx.DiagramBuilder()
# Start displaced from the origin, so the regulator has something to do.
plant = builder.add(jx.library.LTISystem(A, B, C, D,
initialize_states=jnp.array([1.0, 0.0])))
controller = builder.add(jx.library.LinearQuadraticRegulator(A, B, Q, R))
builder.connect(plant.output_ports[0], controller.input_ports[0])
builder.connect(controller.output_ports[0], plant.input_ports[0])
diagram = builder.build()
results = jx.simulate(
diagram,
diagram.create_context(),
(0.0, 10.0),
# Nothing is stored unless you name it here: without recorded_signals,
# results.time and results.outputs come back as None.
recorded_signals={"x": plant.output_ports[0],
"u": controller.output_ports[0]},
)
results.outputs["x"] # (T, 2) — position and velocity, driven back to zero
```
---
## 🔥 Why JAX?
Choosing JAX as the compute backbone unlocks capabilities that are impractical with NumPy-based simulators:
```
Traditional simulator Jaxonomy / JAX
────────────────────── ─────────────────────────────────────────
simulate(params) → jit(simulate)(params) 10–100× faster
for p in param_grid: … → vmap(simulate)(param_grid) embarrassingly parallel
finite_diff_gradient(…) → grad(simulate)(params) exact gradients, free
```
| Feature | SciPy / NumPy | Julia / DiffEq | Modelica | MathWorks¹ | **Jaxonomy** |
|---|:---:|:---:|:---:|:---:|:---:|
| Python-native | ✓ | ✗ | ✗ | ✗ | **✓** |
| JIT / code generation | ✗ | ✓ | ✓ (C++) | ✓ (C/C++) | **✓** |
| Full autodiff through ODE | ✗ | Partial | ✗ | Partial² | **✓** |
| Hybrid events & zero-crossing | Partial | ✓ | ✓ | ✓ | **✓** |
| Acausal / equation-based | ✗ | ✗ | ✓ | ✓ (Simscape) | **✓** |
| Block-diagram composition | ✗ | Partial | Partial | ✓ (Simulink) | **✓** |
| State-machine modeling | ✗ | ✗ | ✗ | ✓ (Stateflow) | **✓** |
| LQR / MPC / Kalman built-in | ✗ | Partial | Via libs | ✓ (Toolboxes) | **✓** |
| Neural ODE / SINDy | ✗ | ✓ | ✗ | ✗ | **✓** |
| Reduced-order modeling (balred / POD-DEIM / DMD / Koopman) | ✗ | Partial | ✗ | ✓ (Toolboxes) | **✓** |
| Batch / ensemble (vmap) | ✗ | ✗ | ✗ | ✗ | **✓** |
| Open-source (MIT) | ✓ | ✓ | Partial | ✗ | **✓** |
¹ Simulink + Simscape + Stateflow + Control System Toolbox · ² Via Simulink Design Optimization, no end-to-end AD
---
## ⚡ Key Capabilities
| Capability | What it enables |
|---|---|
| ⚡ **JAX-native engine** | JIT-compile simulations, run ensembles with `vmap`, differentiate through ODE solvers including event handling |
| 🔀 **Hybrid dynamics + state machines** | Continuous ODEs, periodic discrete updates, zero-crossing events, and `StateMachineBuilder`-authored finite state machines composed in one model. `jax.grad` flows through event times for hybrid trajectory optimisation. |
| 🔌 **Acausal modeling** | Modelica-inspired multi-domain components (electrical, mechanical, thermal, fluid, battery) with Pantelides index reduction and a BDF mass-matrix DAE solver |
| 🎯 **Control & estimation** | LQR (continuous, discrete, finite-horizon, LQG), linear MPC (native + OSQP), nonlinear MPC (shooting / transcription / Hermite-Simpson), Kalman / EKF / UKF / RLS / Luenberger, 2-DOF PID with classical tuning helpers |
| 🧮 **Unit-aware wiring** | Optional `BusUnit` annotations on ports and signals; the diagram compiler catches dimensional mismatches at build time instead of as silent runtime bugs |
| 🧠 **Data-driven modeling** | Neural ODEs, Universal Differential Equations, SINDy symbolic regression, neural-network blocks (`MLP` / `PyTorch` / `TensorFlow` / `ONNX`), differentiable lookup-table fitting, and statistical surrogates (Gaussian process, polynomial chaos, RBF) |
| 📉 **Reduced-order modeling** | `jaxonomy.library.rom`: linear MOR (balanced truncation, `minreal`, modal / residualization), POD–Galerkin with DEIM hyper-reduction, and data-driven operator ROM (DMD / DMDc / ERA, Koopman / eDMD lifted-linear predictors). One `reduce(...)` front door; every reduced model is a differentiable, simulatable block |
| 🎲 **Uncertainty & sensitivity** | First-class `jaxonomy.uq` workflow: Monte Carlo with parameter distributions, Latin Hypercube + quasi-Monte Carlo sampling, Sobol sensitivity decomposition, Morris screening |
| 🤝 **FMI 2.0 / 3.0 interop** | Import FMI co-simulation FMUs (`ModelicaFMU`, mixed-type and array I/O) or model-exchange FMUs (`ModelicaFMUME`, integrated by Jaxonomy's own solver with FMI event indicators as zero-crossings); export a diagram as a binary `.fmu` via `build_fmu`. Verified against the Reference FMUs, OpenModelica, and the `fmusim` reference simulator in CI |
| 🧩 **150+ library blocks** | Integrators, filters, state machines, look-up tables, coordinate transforms, container blocks, bus / mux family, stochastic sources, and more |
---
## 📦 Installation
Requires **Python 3.10+**.
```bash
# Create and activate a virtual environment (recommended)
python -m venv .venv
source .venv/bin/activate # Windows: .venv\Scripts\activate
# Install
pip install jaxonomy # core
pip install jaxonomy[safe] # + SciPy, Matplotlib, control, jaxopt
pip install jaxonomy[nmpc] # + nonlinear MPC (requires IPOPT on PATH)
pip install jaxonomy[all] # + everything
```
**From source:**
```bash
git clone https://github.com/machinavitalis/jaxonomy
cd jaxonomy
pip install -e .
```
**CLI runner:**
```bash
jaxonomy_cli run --model path/to/model.json
```
---
## 🚀 Quick Start
A first simulation in a few lines — a custom block, built into a diagram, integrated through its ODE:
```python
import jaxonomy as jx
import jax.numpy as jnp
# Van der Pol oscillator as a custom block
class VanDerPol(jx.LeafSystem):
def __init__(self, mu=1.0, **kwargs):
super().__init__(**kwargs)
self.declare_dynamic_parameter("mu", mu)
self.declare_continuous_state(
default_value=jnp.array([0.0, 2.0]), ode=self._ode
)
self.declare_continuous_state_output(name="x")
def _ode(self, time, state, *inputs, **params):
x, mu = state.continuous_state, params["mu"]
return jnp.array([x[1], mu * (1 - x[0]**2) * x[1] - x[0]])
builder = jx.DiagramBuilder()
vdp = builder.add(VanDerPol(mu=2.0, name="vdp"))
diagram = builder.build()
results = jx.simulate(
diagram, diagram.create_context(), (0.0, 20.0),
options=jx.SimulatorOptions(buffer_length=4000), # room for adaptive steps
recorded_signals={"x": vdp.output_ports[0]},
)
# results.outputs["x"] → time-series of shape (T, 2)
```
---
## 📚 Documentation
- **Online docs & tutorials:** [py.jaxonomy.com](https://py.jaxonomy.com)
- **Local docs:**
```bash
pip install -r requirements.docs.txt
mkdocs serve # → http://127.0.0.1:8000
```
- **Example notebooks:** [`docs/examples/`](https://github.com/machinavitalis/jaxonomy/tree/main/docs/examples)
- **Scope notes:** [PINNs & PDE surrogates](https://github.com/machinavitalis/jaxonomy/blob/main/docs/scope/pinn.md) — classical
PDE PINNs are out of scope; physics-informed *dynamics* learning (UDE /
Neural DAE / Neural ODE / SINDy) is core.
---
## 🤖 Driving Jaxonomy from an AI agent (MCP)
Jaxonomy ships an [MCP](https://modelcontextprotocol.io) server that exposes the
engine as tools an AI agent can call directly — it can enumerate library blocks,
build and validate a model, run a simulation, fit parameters to data, and
linearize a system, then reason over the actual results. This is worth wiring up
if you drive Jaxonomy from an agent (Claude Desktop/Code, Cursor, …); if you're
writing Python by hand, the `pip install` above is all you need and you can skip
this.
```bash
pip install jaxonomy[mcp]
```
Then register the server with your agent client. For Claude Desktop, add to
`claude_desktop_config.json`:
```json
{
"mcpServers": {
"jaxonomy": {
"command": "python",
"args": ["-m", "jaxonomy.mcp.server"]
}
}
}
```
Use the interpreter where `jaxonomy[mcp]` is installed (or the `jaxonomy-mcp`
entry point). The server is listed in the
[MCP Registry](https://registry.modelcontextprotocol.io) as
`io.github.machinavitalis/jaxonomy`; full tool reference, client configuration
and limitations are at [py.jaxonomy.com/mcp](https://py.jaxonomy.com/mcp/).
If you'd rather just point an agent at the documentation, start it on
[`SKILL.md`](SKILL.md) — when to use Jaxonomy, when to reach for something else,
the core API, and the pitfalls that most often break a first script. The docs
site also publishes [llms.txt](https://llmstxt.org/) views:
[py.jaxonomy.com/llms.txt](https://py.jaxonomy.com/llms.txt) for an index of
every page, and
[py.jaxonomy.com/llms-full.txt](https://py.jaxonomy.com/llms-full.txt) for the
whole documentation set as one Markdown file.
---
## 📖 Examples
### 1 · Hybrid Dynamics: The Bouncing Ball
Jaxonomy is designed for **hybrid systems** — models where continuous physics interacts with instantaneous discrete resets. The bouncing ball is the canonical example: free-fall ODE interrupted by a collision event that reverses velocity.
#### Governing equations
The dynamics between bounces follow:
$$
\dot{x} = v, \qquad \dot{v} = -g
$$
When the ball hits the ground ($x = 0$, $v < 0$) a zero-crossing event fires and the state resets:
$$
x^+ = 0, \qquad v^+ = -e \cdot v \quad (e \in [0, 1] \text{ — coefficient of restitution})
$$
```python
import jaxonomy as jx
import jax.numpy as jnp
class BouncingBall(jx.LeafSystem):
def __init__(self, g=9.81, e=0.8, **kwargs):
super().__init__(**kwargs)
self.declare_dynamic_parameter("g", g)
self.declare_dynamic_parameter("e", e)
# [height, velocity]
self.declare_continuous_state(
default_value=jnp.array([5.0, 0.0]), ode=self._ode
)
self.declare_continuous_state_output(name="state")
# Zero-crossing: fires as height crosses zero from above
self.declare_zero_crossing(
guard=self._hit_ground,
reset_map=self._bounce,
direction="positive_then_non_positive",
)
def _ode(self, time, state, *inputs, **params):
v = state.continuous_state[1]
return jnp.array([v, -params["g"]])
def _hit_ground(self, time, state, *inputs, **params):
return state.continuous_state[0] # guard on height
def _bounce(self, time, state, *inputs, **params):
x, v = state.continuous_state
new_state = jnp.array([0.0, -params["e"] * v])
return state.with_continuous_state(new_state)
builder = jx.DiagramBuilder()
ball = builder.add(BouncingBall(g=9.81, e=0.85, name="ball"))
diagram = builder.build()
results = jx.simulate(
diagram, diagram.create_context(), (0.0, 8.0),
recorded_signals={"state": ball.output_ports[0]},
)
```
Zero-crossing events are located with **40-step bisection** on the solver's dense output polynomial — giving sub-microsecond temporal accuracy without user-specified tolerances.
---
### 2 · Optimal Control: LQR Pendulum
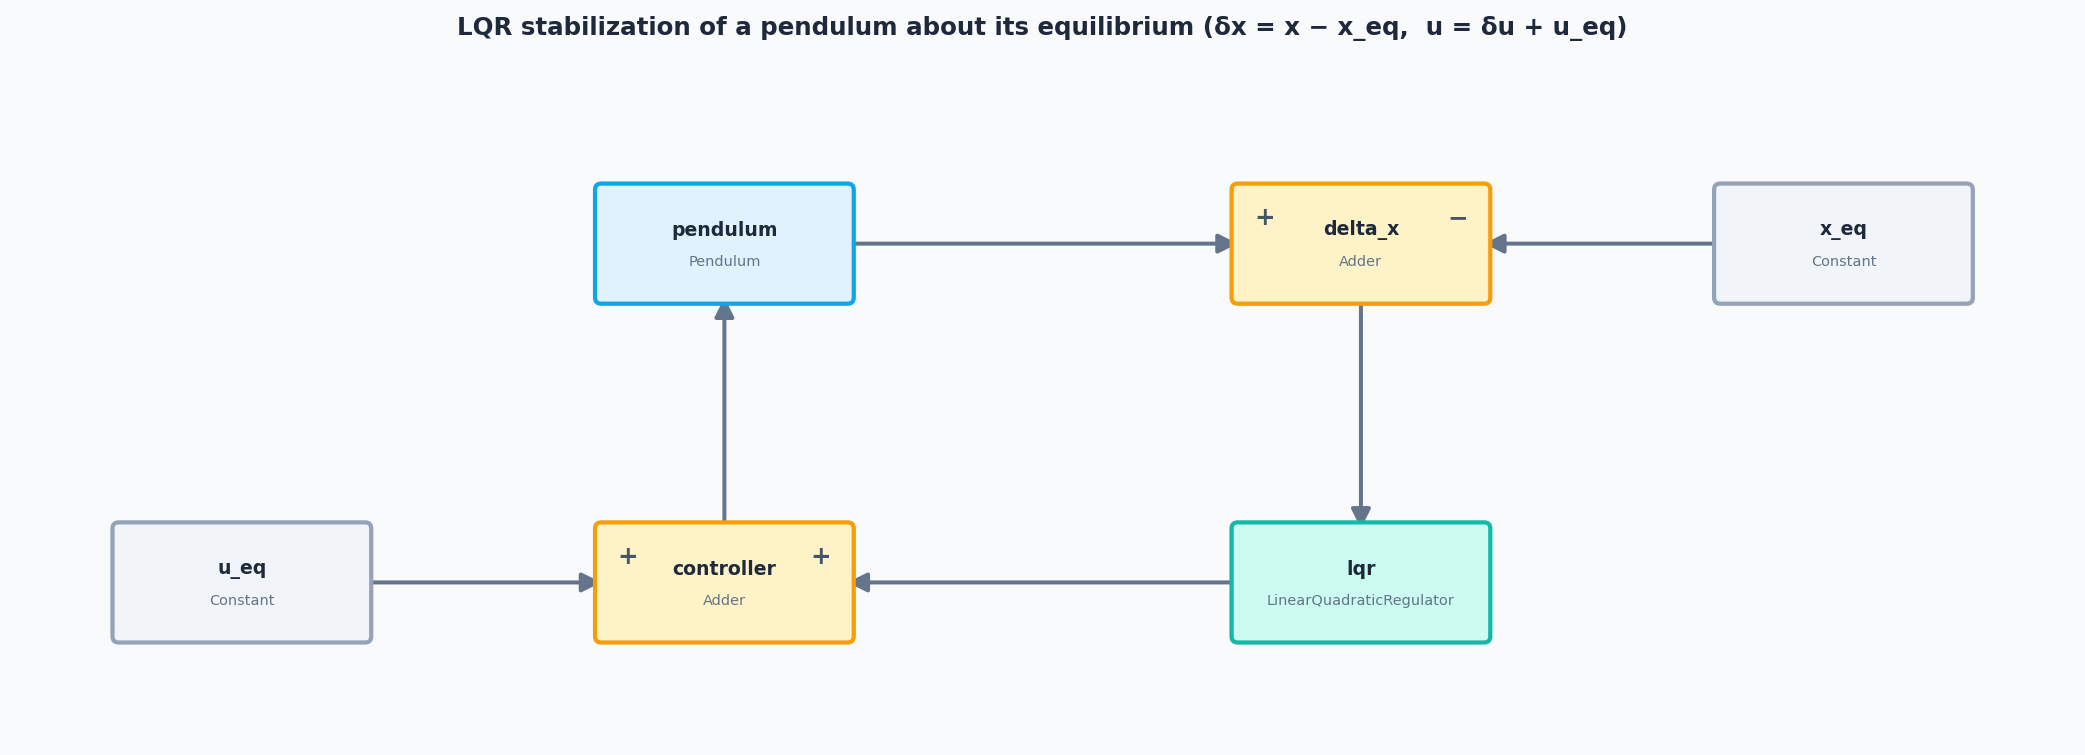
For a linearized pendulum with state $x = [\theta, \dot\theta]^\top$:
$$
\dot{x} = Ax + Bu, \qquad
A = \begin{bmatrix} 0 & 1 \\ g/L & 0 \end{bmatrix}, \quad
B = \begin{bmatrix} 0 \\ 1/mL^2 \end{bmatrix}
$$
The **Linear Quadratic Regulator** minimizes infinite-horizon cost:
$$
J = \int_0^\infty \bigl( x^\top Q\, x + u^\top R\, u \bigr)\, dt
$$
by solving the algebraic Riccati equation $A^\top P + PA - PBR^{-1}B^\top P + Q = 0$ for the optimal gain $K = R^{-1}B^\top P$, so $u^* = -Kx$.
```python
import jaxonomy as jx
from jaxonomy.library import LTISystem, LinearQuadraticRegulator
import jax.numpy as jnp
g, L, m = 9.81, 1.0, 1.0
A = jnp.array([[0, 1], [g/L, 0]])
B = jnp.array([[0], [1 / (m * L**2)]])
C, D = jnp.eye(2), jnp.zeros((2, 1))
Q = jnp.diag(jnp.array([10.0, 1.0])) # penalise angle more than rate
R = jnp.array([[0.1]]) # control effort cost
builder = jx.DiagramBuilder()
plant = builder.add(LTISystem(A, B, C, D, name="pendulum"))
controller = builder.add(LinearQuadraticRegulator(A, B, Q, R, name="lqr"))
builder.connect(plant.output_ports[0], controller.input_ports[0])
builder.connect(controller.output_ports[0], plant.input_ports[0])
diagram = builder.build()
context = diagram.create_context()
# Perturb the pendulum's initial angle by 15° (set one block's sub-state)
context = context.with_subcontext(
plant.system_id,
context[plant.system_id].with_continuous_state(jnp.array([jnp.pi / 12, 0.0])),
)
results = jx.simulate(
diagram, context, (0.0, 5.0),
recorded_signals={"x": plant.output_ports[0]},
)
```
---
### 3 · Differentiable Parameter Identification
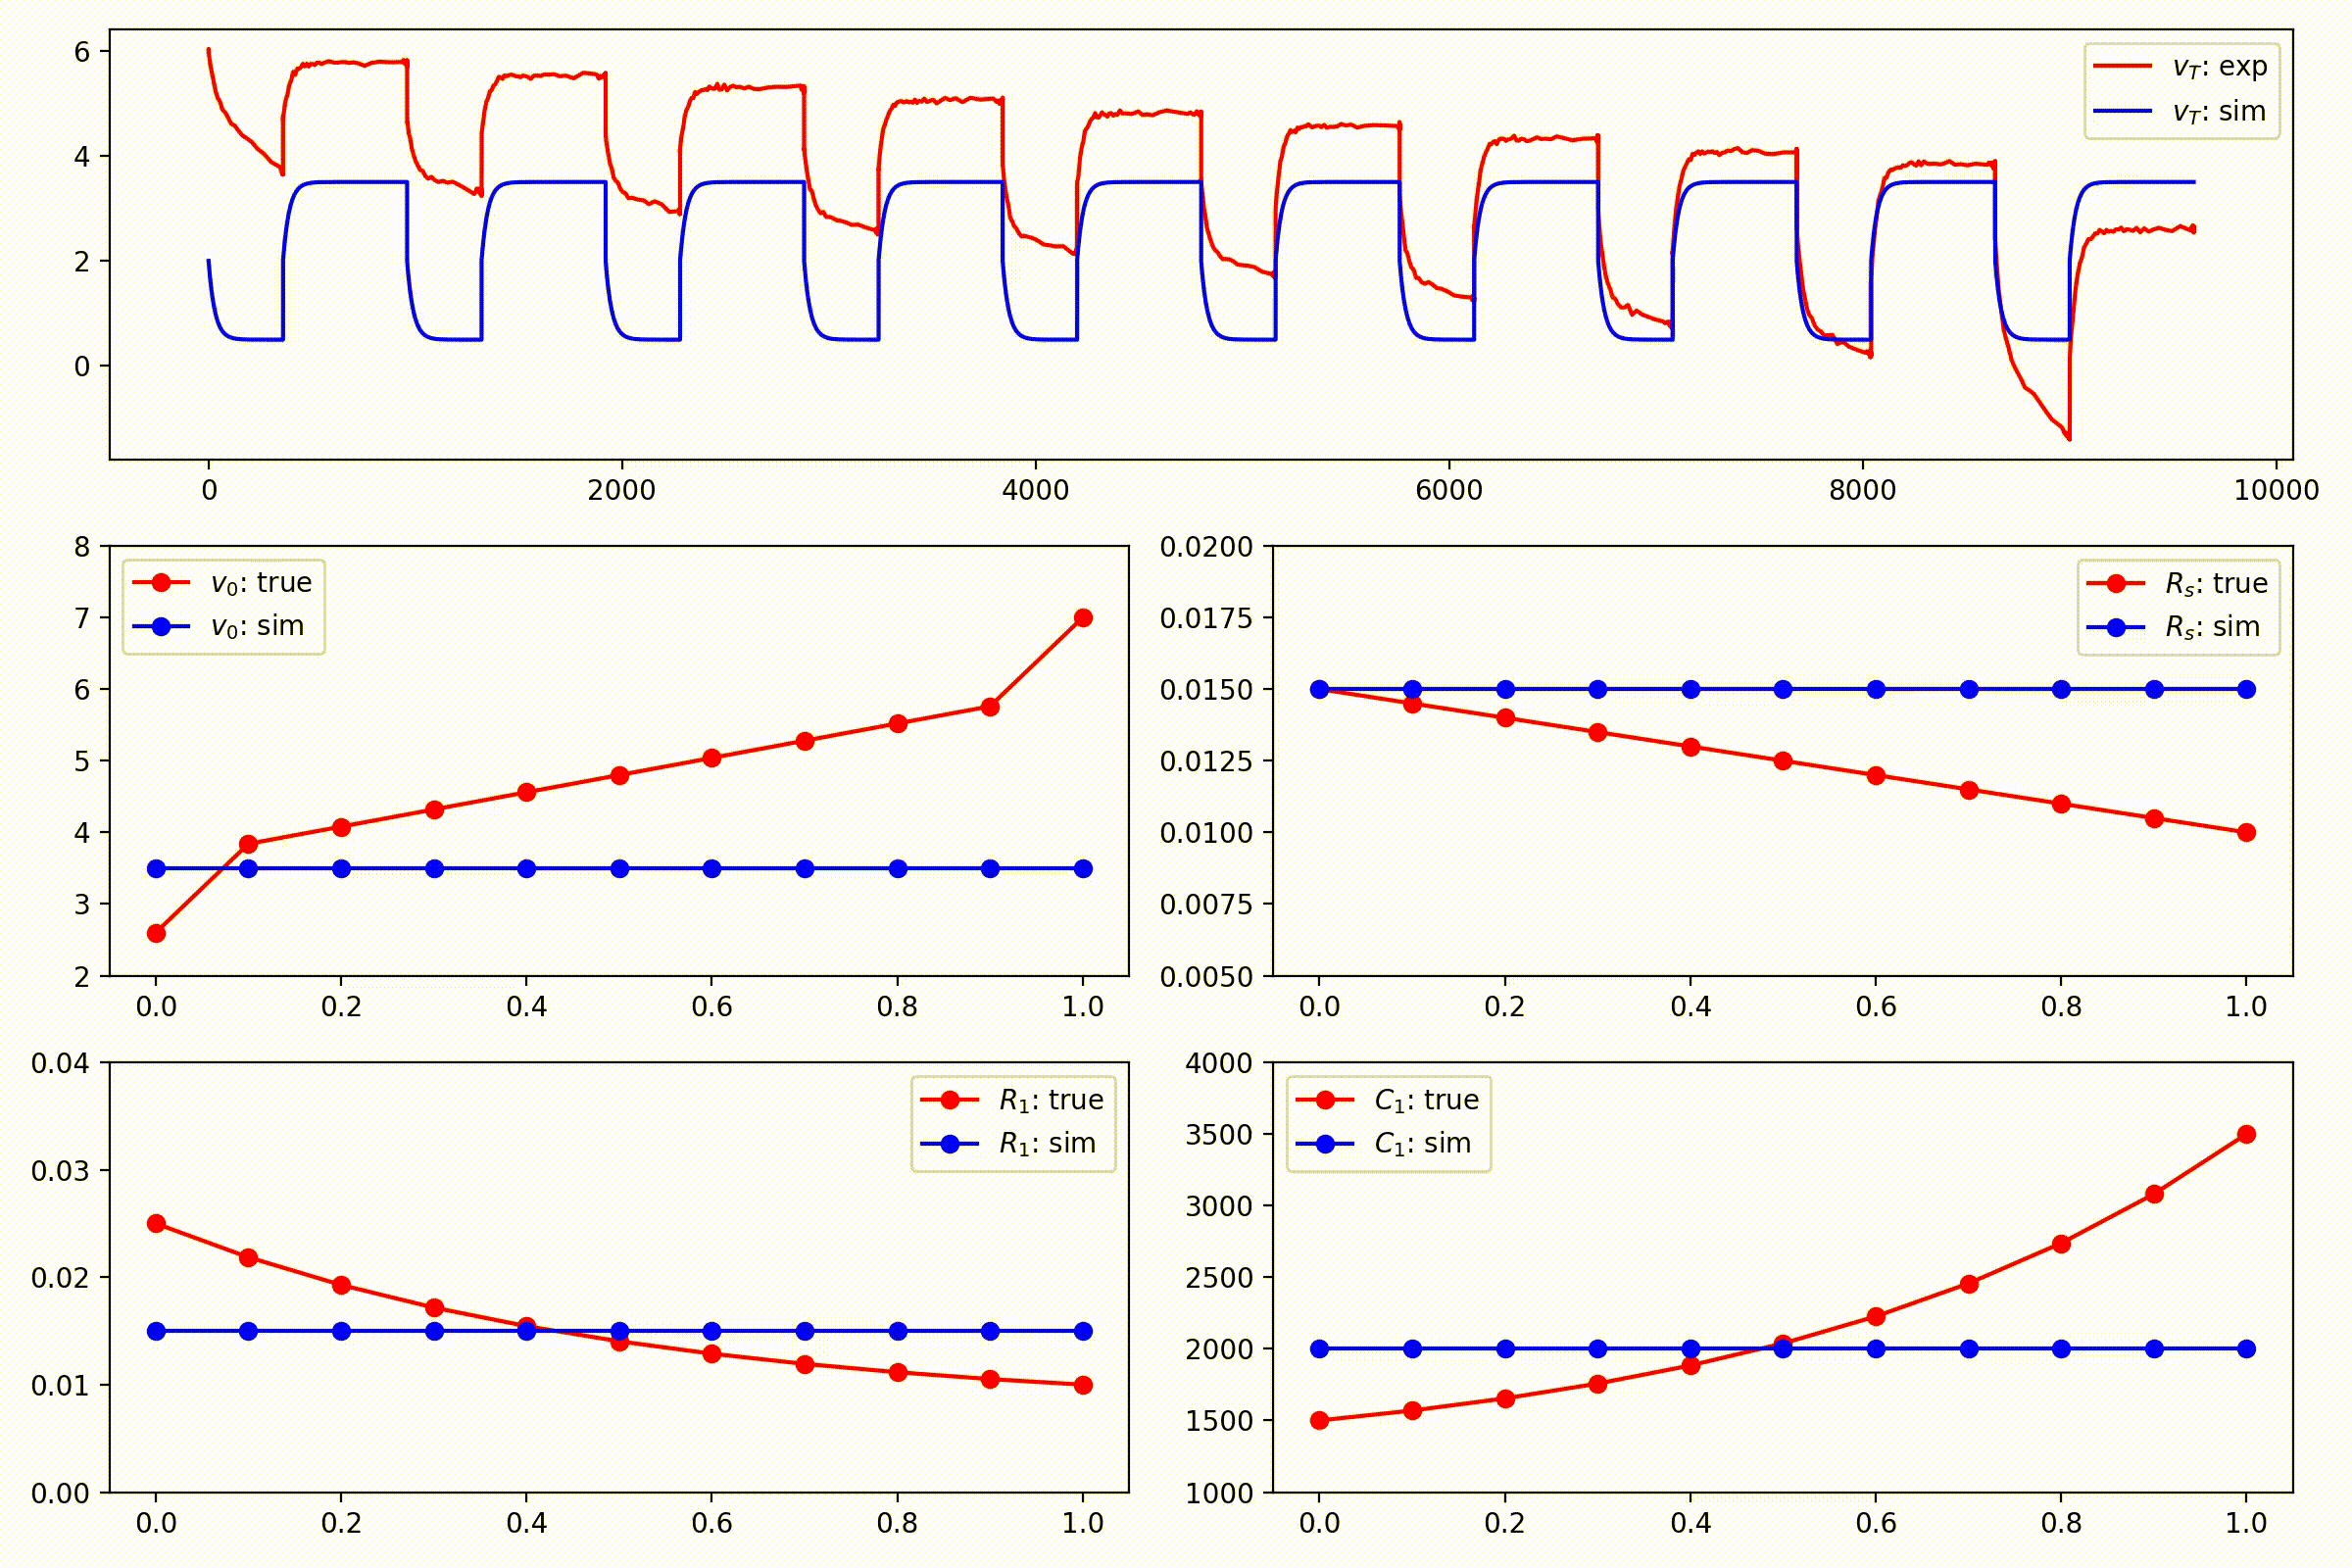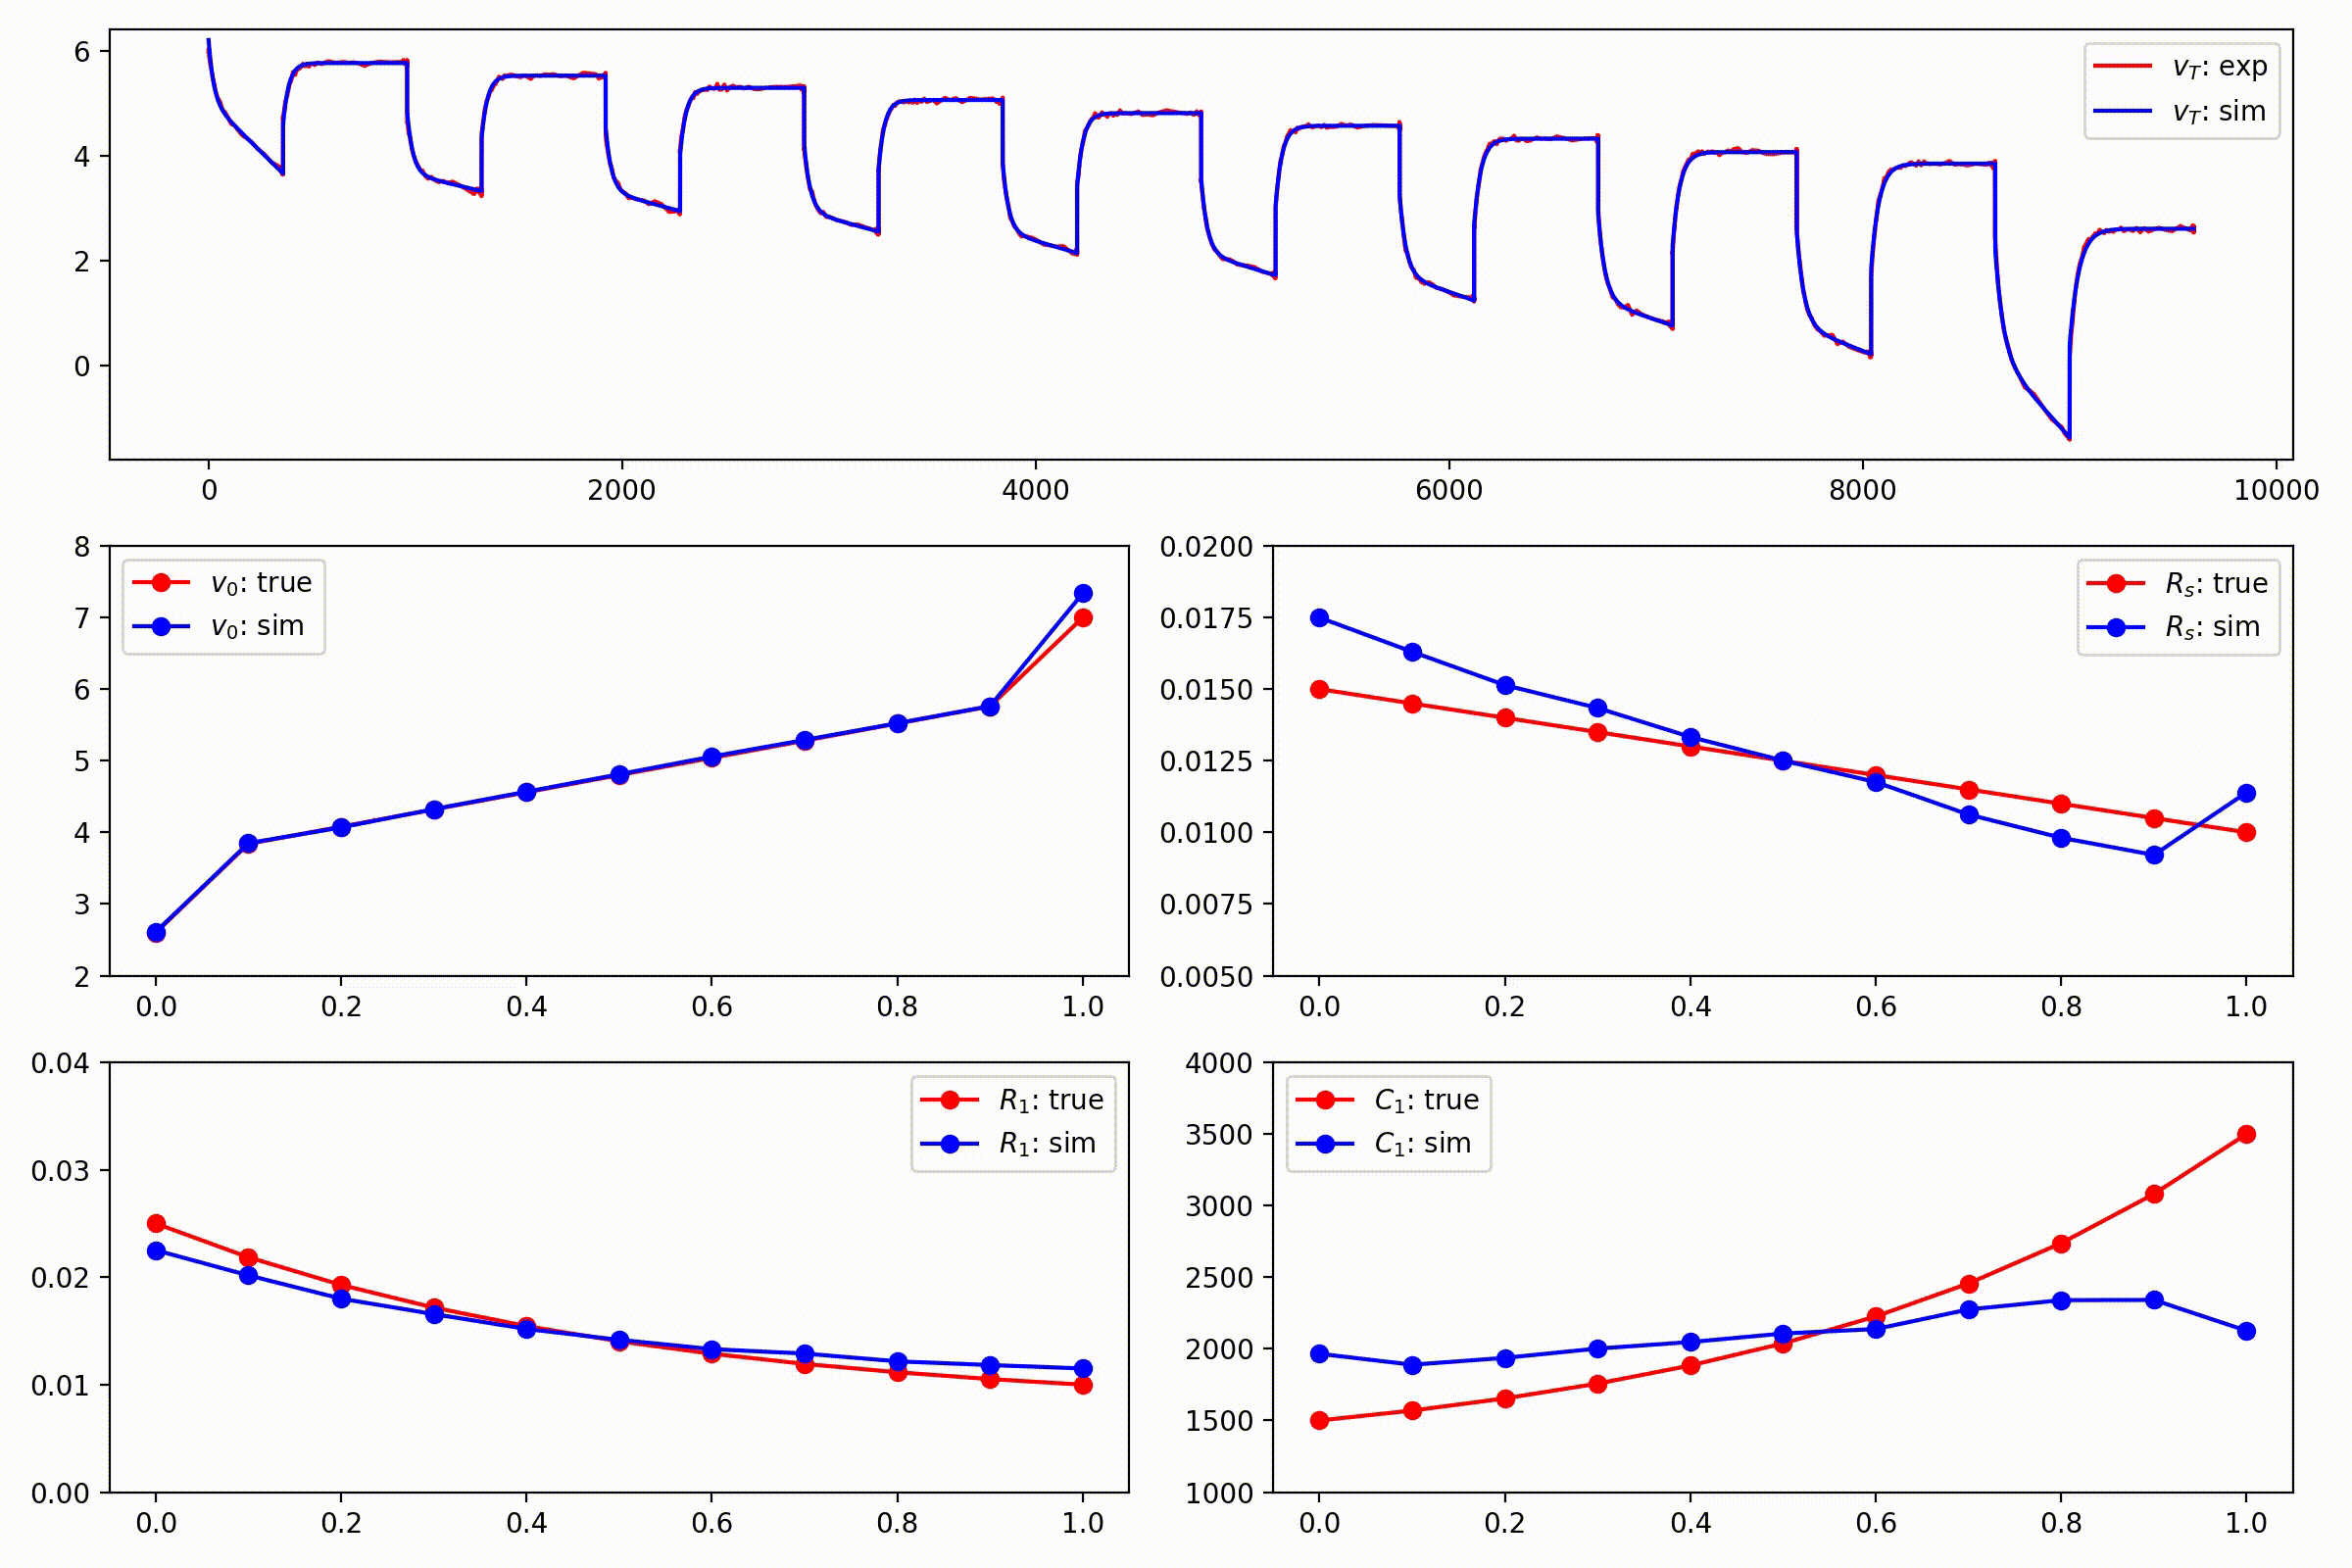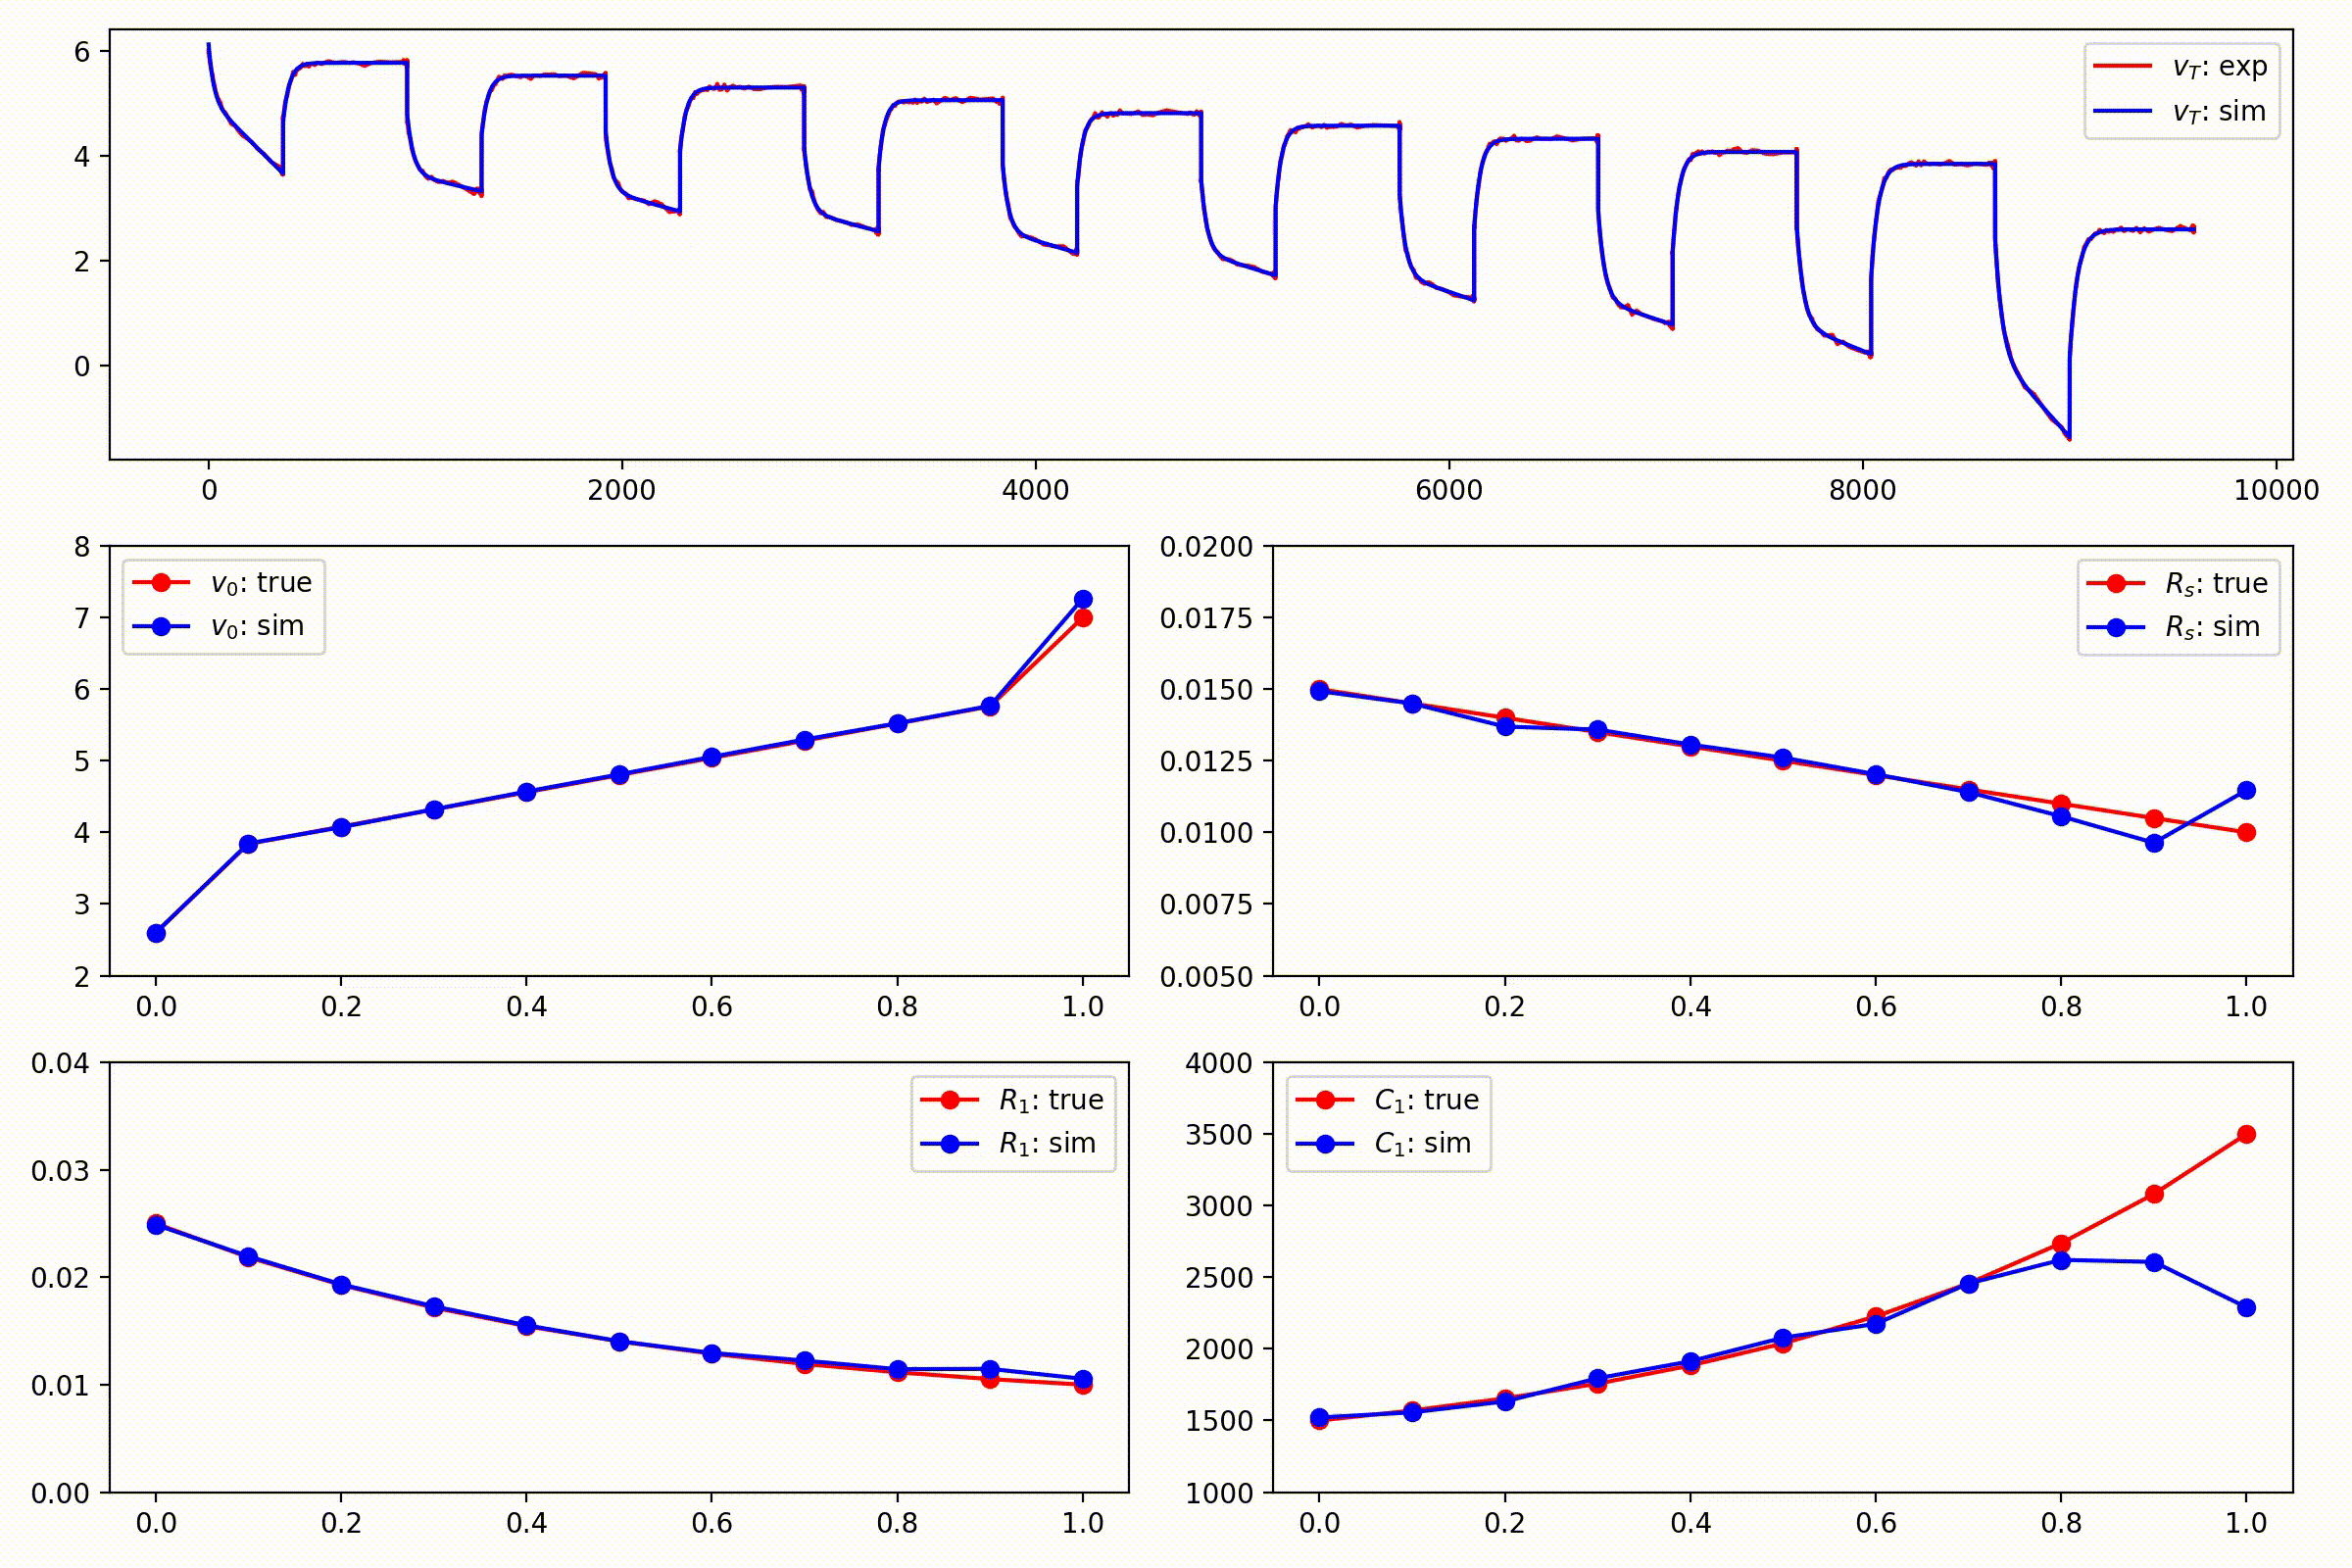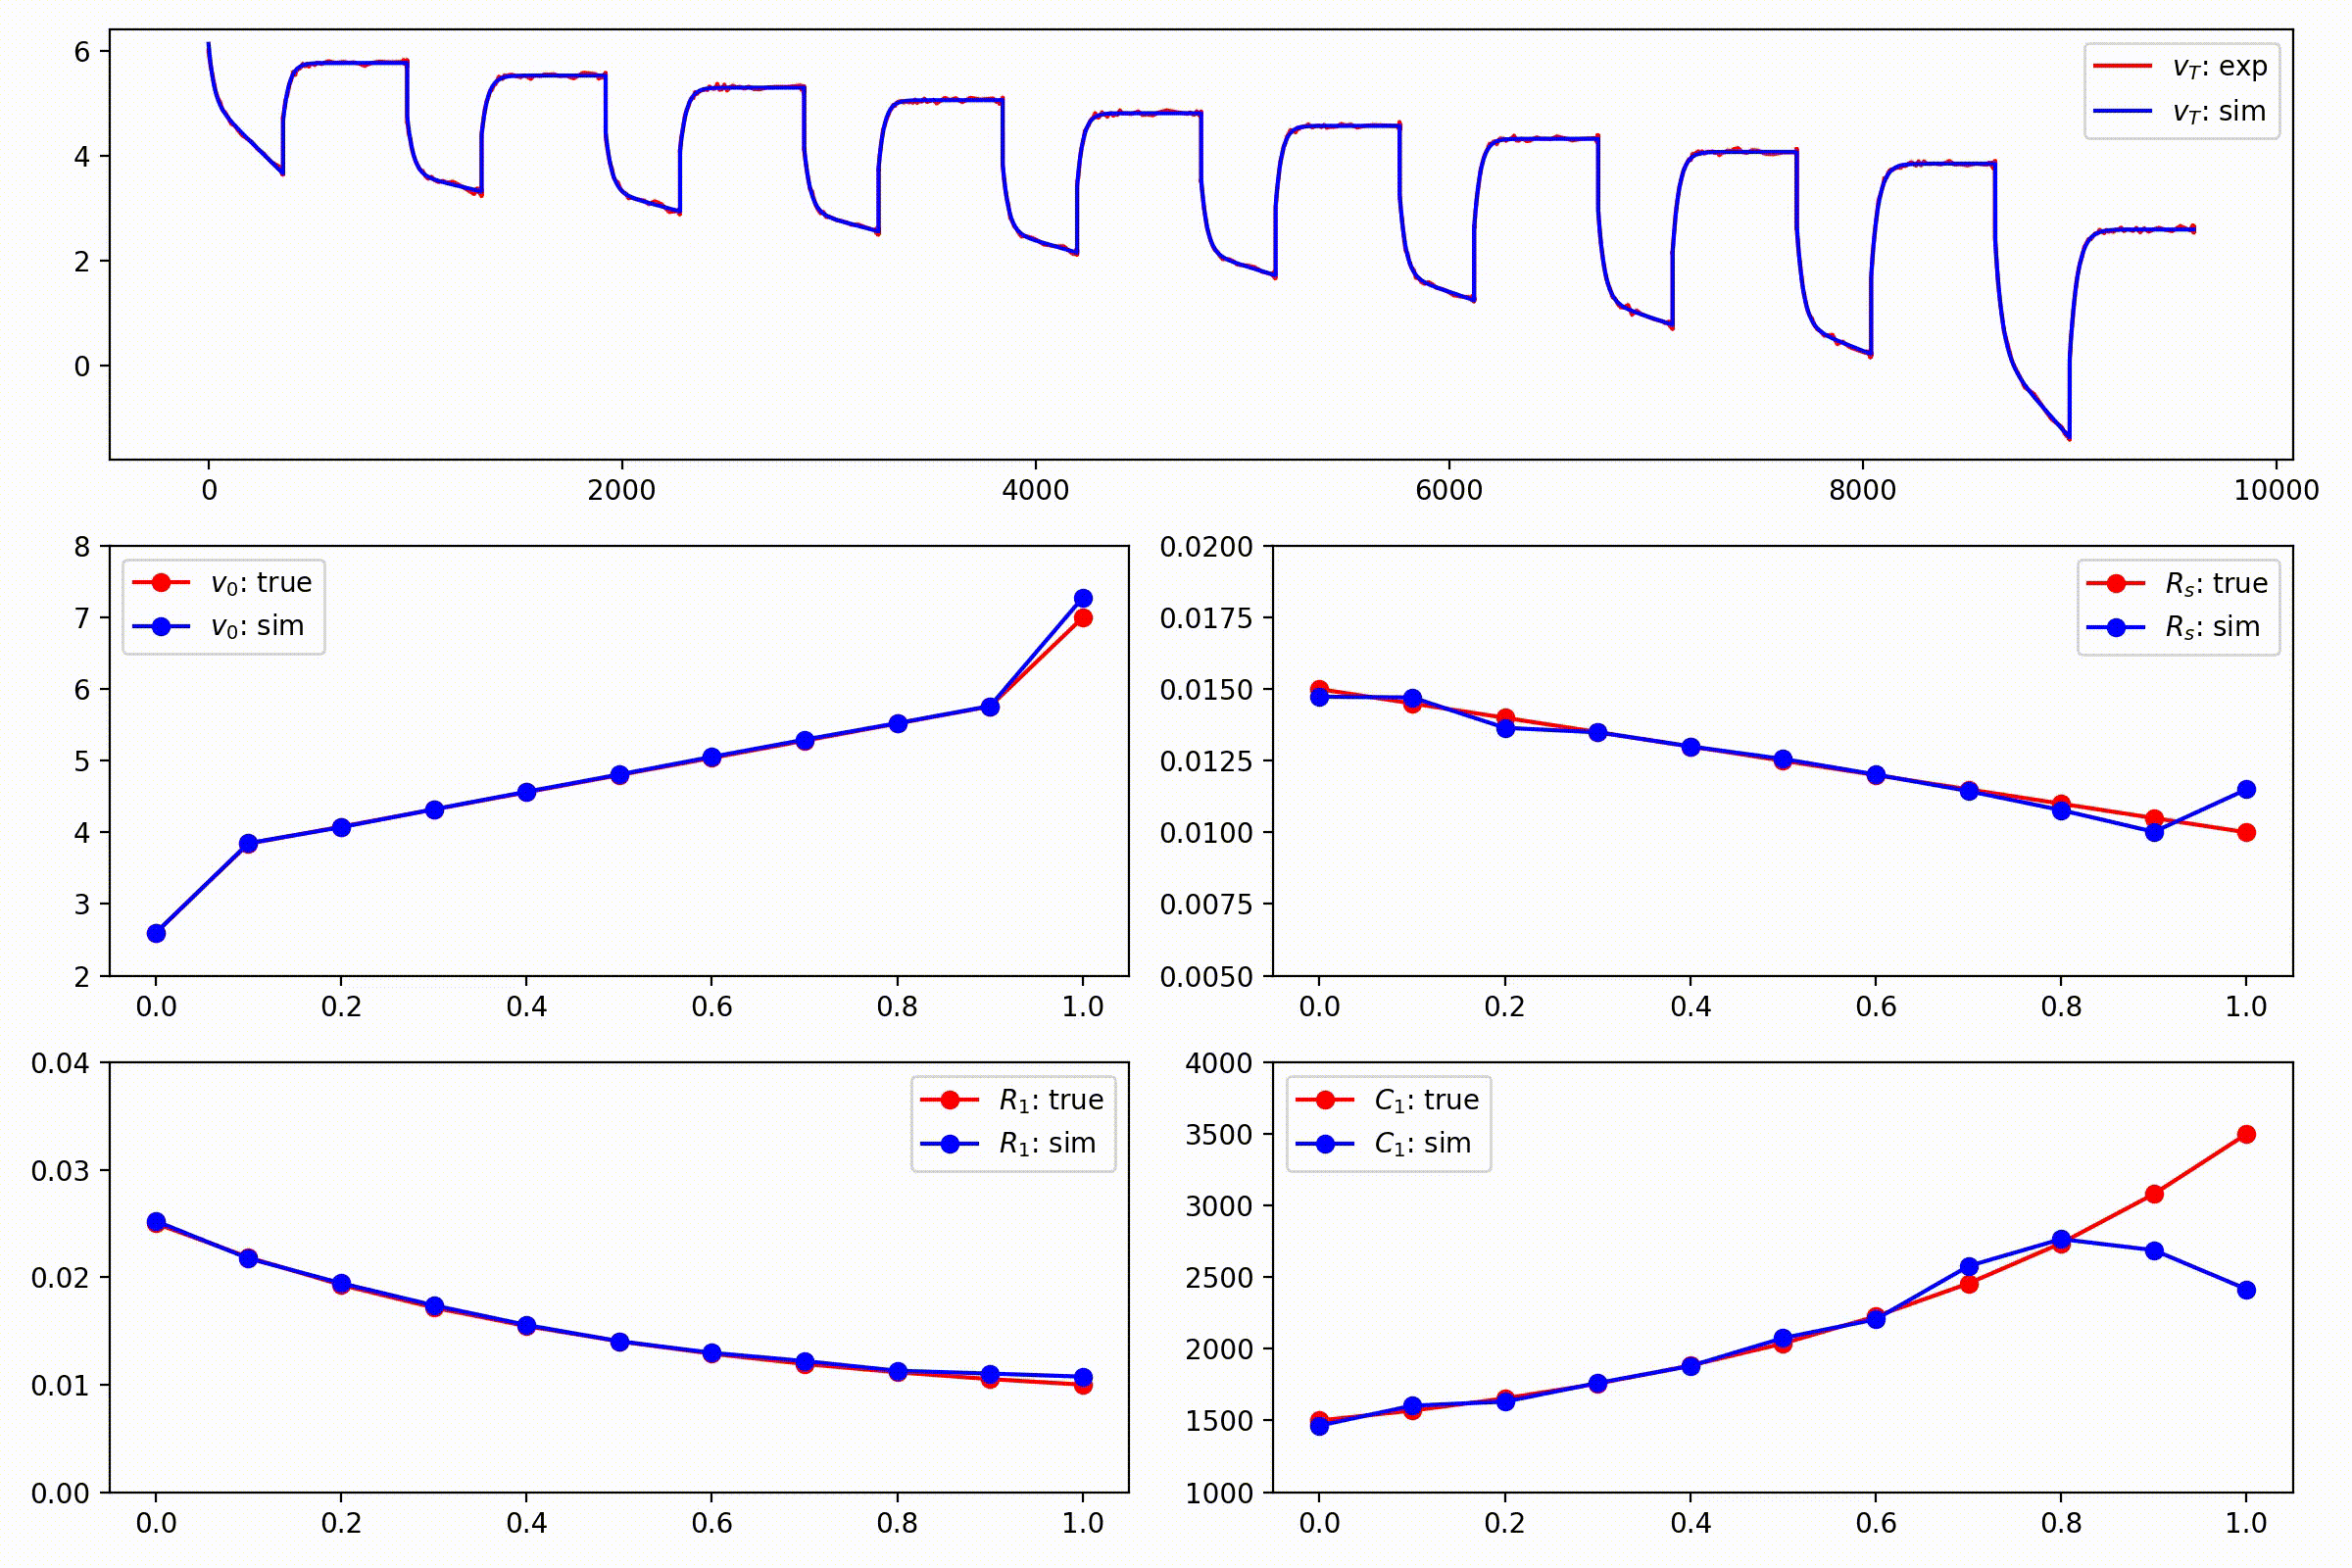
Jaxonomy can **differentiate through complete simulations** to fit model parameters to data — no finite-difference approximations, no hand-written adjoint code. Here we recover a spring–damper's stiffness and damping by differentiating the whole rollout and descending with [Optax](https://optax.readthedocs.io):
```python
import jax
import jax.numpy as jnp
import optax
import jaxonomy as jx
class SpringDamper(jx.LeafSystem):
def __init__(self, k=1.0, c=0.3, **kwargs):
super().__init__(**kwargs)
self.declare_dynamic_parameter("k", k)
self.declare_dynamic_parameter("c", c)
self.declare_continuous_state(
default_value=jnp.array([1.0, 0.0]), ode=self._ode
)
def _ode(self, time, state, *inputs, **params):
x, v = state.continuous_state
return jnp.array([v, -params["k"] * x - params["c"] * v])
sd = SpringDamper(name="sd")
opts = jx.SimulatorOptions(enable_autodiff=True, max_major_steps=200)
def final_state(theta): # theta = {"k": ..., "c": ...}
ctx = sd.create_context()
ctx.parameters["k"], ctx.parameters["c"] = theta["k"], theta["c"]
res = jx.simulate(sd, ctx, (0.0, 1.5), options=opts)
return res.context.continuous_state # differentiable final [x, v]
target = jax.lax.stop_gradient(final_state({"k": 4.0, "c": 0.5})) # "measured"
loss = lambda theta: jnp.sum((final_state(theta) - target) ** 2)
theta = {"k": 1.0, "c": 0.1}
opt = optax.adam(2e-1)
state = opt.init(theta)
grad_fn = jax.jit(jax.grad(loss)) # gradient through the ODE solver
for _ in range(300):
updates, state = opt.update(grad_fn(theta), state)
theta = optax.apply_updates(theta, updates)
# theta → {"k": 4.00, "c": 0.50}
```
`jax.grad(loss)` flows back through every ODE step automatically, so the same recipe scales to battery ECMs (above), powertrains, or any parametric model — and `jaxonomy.optimization` wraps it in a higher-level `Optimizable` API when you want bounds, transforms, and constraints.
---
### 4 · Acausal Physical Modeling
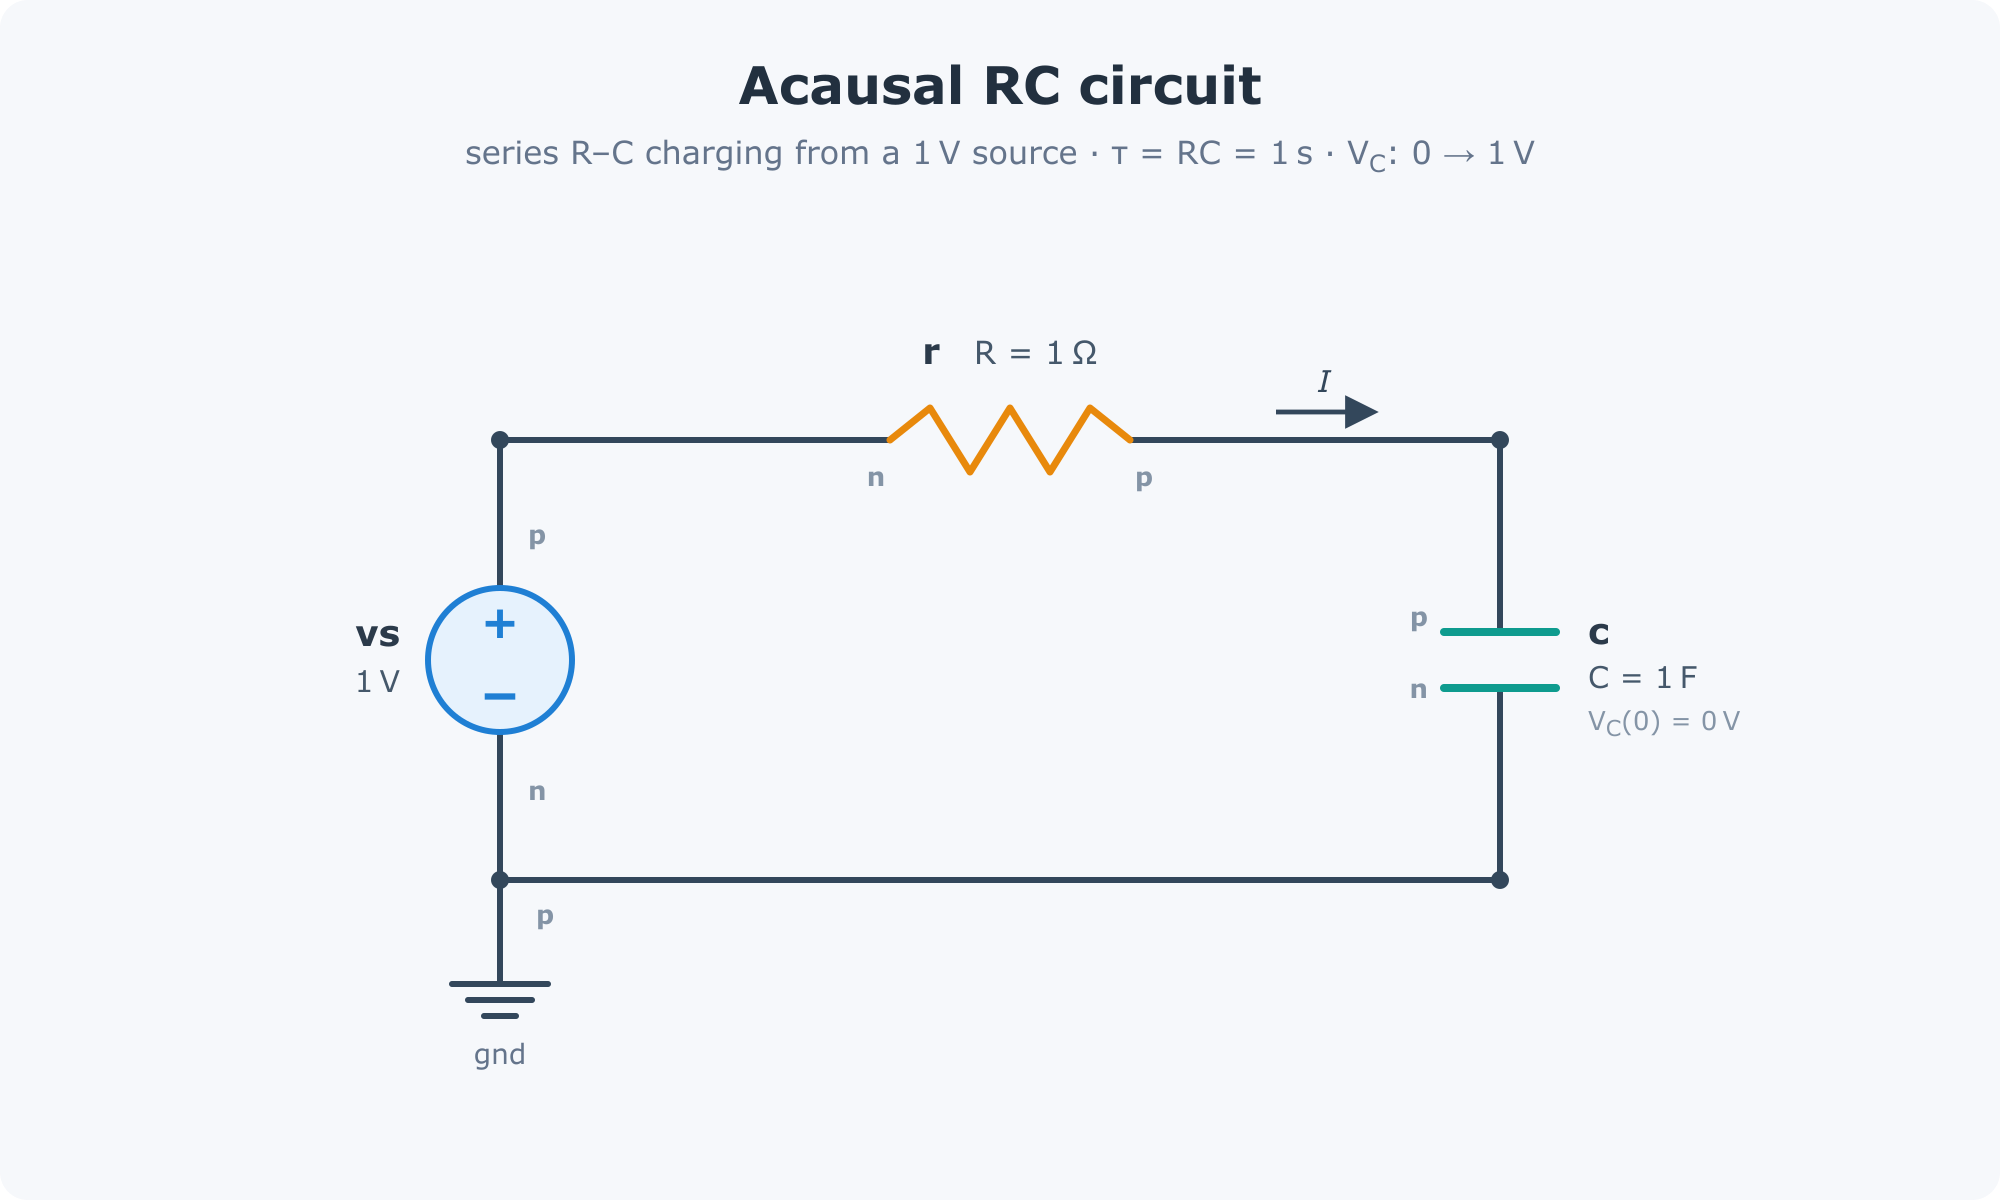
Jaxonomy includes a Modelica-inspired **acausal modeling layer** for multi-domain physical systems. You describe component connections symbolically; the compiler automatically derives the governing DAE, reduces its index, and emits a `LeafSystem` ready to drop into any diagram.
**RC circuit with initial conditions:**
$$
C\,\dot{V}_C = I, \qquad V_C(0) = 0\,\text{V}, \qquad V_{\text{src}} = 1\,\text{V}
$$
```python
import jaxonomy as jx
from jaxonomy.acausal import AcausalCompiler, AcausalDiagram, EqnEnv
from jaxonomy.acausal import electrical as elec
ev = EqnEnv()
ad = AcausalDiagram()
vs = elec.VoltageSource(ev, name="vs", v=1.0)
r = elec.Resistor(ev, name="r", R=1.0)
c = elec.Capacitor(ev, name="c", C=1.0,
initial_voltage=0.0, initial_voltage_fixed=True)
gnd = elec.Ground(ev, name="gnd")
ad.connect(vs, "p", r, "n")
ad.connect(r, "p", c, "p")
ad.connect(c, "n", vs, "n")
ad.connect(vs, "n", gnd, "p")
compiler = AcausalCompiler(ev, ad)
rc_block = compiler() # → LeafSystem, JIT-compiled ODE
builder = jx.DiagramBuilder()
rc = builder.add(rc_block)
diagram = builder.build()
results = jx.simulate(
diagram,
diagram.create_context(),
(0.0, 5.0),
recorded_signals={"rc": rc.output_ports[0]},
)
results.outputs["rc"] # capacitor charges 0 → 0.993 V over 5 τ (R = C = 1)
```
The same pipeline handles **multi-domain systems** — an electro-mechanical actuator connecting `electrical`, `rotational`, and `translational` domains compiles to a single optimized system.
Available acausal domains: `electrical` · `rotational` · `translational` · `thermal` · `fluid`
---
### 5 · Differentiable Sensitivity & Batch Simulation
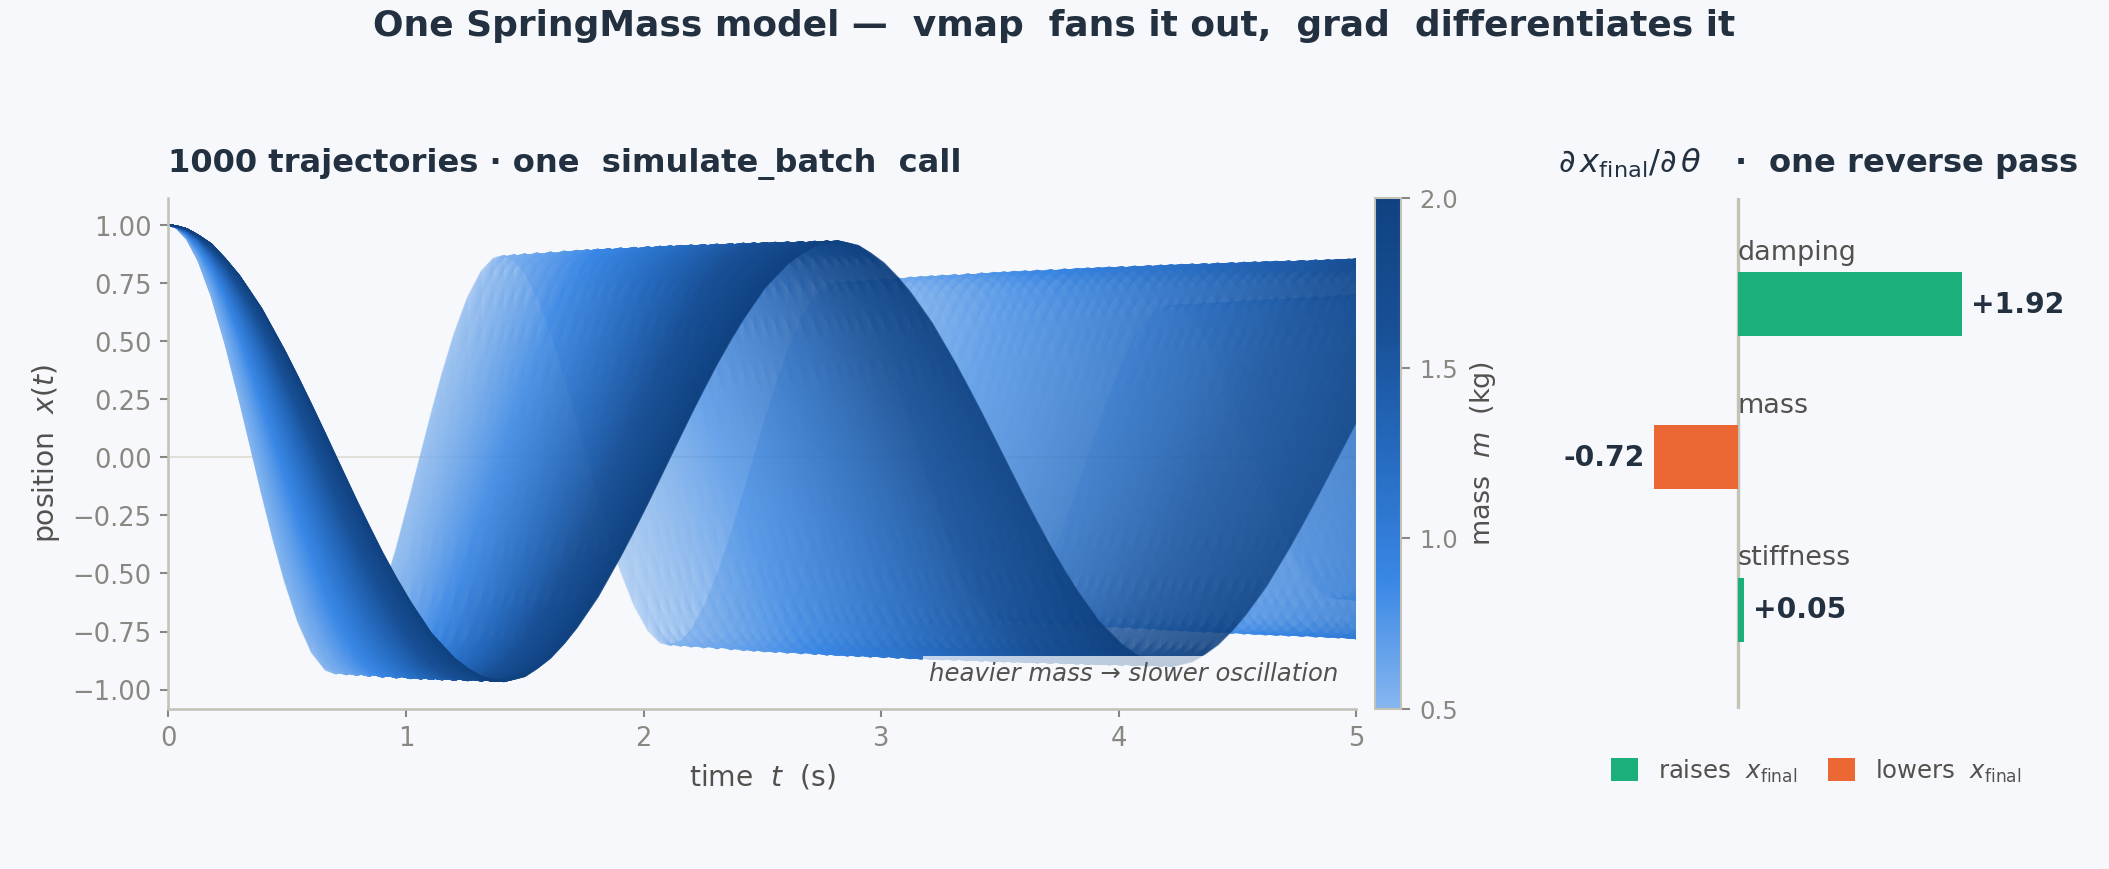
Because `jax.grad`, `jax.jit`, and `jax.vmap` all compose with `simulate`, you get powerful workflows with minimal boilerplate:
```python
import jax
import jax.numpy as jnp
import jaxonomy as jx
class SpringMass(jx.LeafSystem):
def __init__(self, mass=1.0, damping=0.1, stiffness=10.0, **kwargs):
super().__init__(**kwargs)
self.declare_dynamic_parameter("mass", mass)
self.declare_dynamic_parameter("damping", damping)
self.declare_dynamic_parameter("stiffness", stiffness)
self.declare_continuous_state(
default_value=jnp.array([1.0, 0.0]), ode=self._ode
)
self.declare_continuous_state_output(name="x")
def _ode(self, time, state, *inputs, **params):
x, v = state.continuous_state
a = -(params["stiffness"] * x + params["damping"] * v) / params["mass"]
return jnp.array([v, a])
# ── Sensitivity: ∂(final position)/∂(all parameters) in one reverse pass ─────
plant = SpringMass(name="plant")
grad_opts = jx.SimulatorOptions(enable_autodiff=True, max_major_steps=200)
def final_position(theta):
ctx = plant.create_context()
for name, value in theta.items():
ctx.parameters[name] = value
res = jx.simulate(plant, ctx, (0.0, 5.0), options=grad_opts)
return res.context.continuous_state[0]
grads = jax.grad(final_position)({"mass": 1.0, "damping": 0.1, "stiffness": 10.0})
# ── Monte Carlo ensemble: 1000 trajectories over a mass sweep (vmap) ─────────
builder = jx.DiagramBuilder()
plant_b = builder.add(SpringMass(name="plant"))
diagram = builder.build()
results = jx.simulate_batch(
diagram, t_span=(0.0, 5.0),
param_batches={"plant.mass": jnp.linspace(0.5, 2.0, 1000)},
options=jx.SimulatorOptions(math_backend="jax", max_major_steps=200),
recorded_signals={"x": plant_b.output_ports[0]},
)
# results.outputs["x"] shape: (1000, T, 2)
```
---
## 🧩 Library Overview
Over **150 built-in blocks** covering the full signal-processing and control toolkit. A representative slice — not exhaustive:
| Category | Blocks |
|---|---|
| **Sources** | `Constant`, `Step`, `Ramp`, `Chirp`, `Pulse`, `Sawtooth`, `Clock`, `DataSource` |
| **Stochastic** | `RandomNumber`, `UniformRandomNumber`, `WhiteNoise`, `BandLimitedNoise`, `PRBS`, `RandomSource` — all support `with_key` for independent noise streams under `vmap` |
| **Arithmetic & nonlinearities** | `Adder`, `Gain`, `Product`, `Abs`, `Power`, `Trigonometric`, `Saturate` / `SoftSaturate`, `DeadZone`, `RateLimiter` / `SoftRateLimiter`, `Quantizer`, `Backlash` |
| **Continuous dynamics** | `Integrator`, `Derivative`, `TransferFunction`, `LTISystem`, `PID` / `PIDContinuous` |
| **Discrete dynamics** | `IntegratorDiscrete`, `UnitDelay`, `FilterDiscrete`, `LowPassDiscrete`, `LeadLag`, `Notch`, `PIDDiscrete`, `PIDController2DOF`, `Decimator`, `RateTransition` |
| **Routing, buses, matrix** | `Mux` / `Demux`, `BusCreator` / `BusSelector` / `BusUpdate` (with `BusUnit` annotations), `Slice`, `Stack`, `Switch` / `MultiPortSwitch`, `IfThenElse`, `MatrixMultiplication`, `MatrixInversion`, `DotProduct`, `CrossProduct` |
| **Logic & state machines** | `TruthTable`, `LogicalOperator`, `Comparator`, `Relay`, `EdgeDetection`, `StateMachine` (authored via `StateMachineBuilder` DSL) |
| **Lookup tables** | `LookupTable1d` / `LookupTable2d` / `LookupTableND`, `Prelookup` / `InterpolationUsingPrelookup`, `TableSearch` — all differentiable and fittable from data via `fit_lookup_table_*` |
| **Delays & containers** | `TransportDelay`, `VariableTransportDelay`, `EnabledSubsystem`, `TriggeredSubsystem`, `ForEach`, `Conditional` |
| **Control** | `LinearQuadraticRegulator` / `DiscreteTimeLinearQuadraticRegulator` / `FiniteHorizonLinearQuadraticRegulator` / `LinearQuadraticGaussian`, `LinearDiscreteTimeMPC` (native + `LinearDiscreteTimeMPC_OSQP`), `DirectShootingNMPC` / `DirectTranscriptionNMPC` / `HermiteSimpsonNMPC` |
| **Estimation** | `KalmanFilter`, `ExtendedKalmanFilter`, `UnscentedKalmanFilter`, `InfiniteHorizonKalmanFilter`, `RecursiveLeastSquares`, `AugmentedStateEKF`, `Luenberger` |
| **Physics & coordinates** | `CoordinateRotation`, `RigidBody`, `BatteryCell` |
| **ML / Data** | `MLP` (Equinox), `Sindy`, `PyTorch`, `TensorFlow`, `ONNX` / `ONNXJax` |
| **ROM & surrogates** | `reduce(...)` → `ReducedOrderModel`; linear MOR (`balred` / `minreal` / `modal_truncation` / `residualize`), `galerkin_reduce` + `deim` (POD–DEIM), `dmd` / `dmdc` / `era`, `DMDForecaster` / `KoopmanPredictor`, and surrogate blocks `GaussianProcess` / `PolynomialChaos` / `RadialBasisSurrogate` |
| **Interop** | `ModelicaFMU` / `ModelicaFMUME` (FMI 2.0 / 3.0 co-simulation and model-exchange import) + FMU export via `build_fmu`; `MuJoCo` / `MJX`; `Ros2Publisher` / `Ros2Subscriber`; `QuanserHAL`; `PyTwin` |
| **Custom** | `CustomPythonBlock`, `CustomJaxBlock` for user-authored algorithms with persistent per-instance state |
Custom blocks are first-class beyond the wrappers above: subclass `LeafSystem`, declare ports and states, and your block integrates with the full framework including JIT, autodiff, and event detection.
---
## 🏗️ System Architecture
A Jaxonomy model is a **Diagram** — a directed graph of interconnected blocks. Blocks (`LeafSystem`) declare ports, continuous/discrete states, and event guards. The simulator orchestrates ODE integration, discrete updates, and event detection automatically.
```mermaid
graph LR
subgraph Diagram["DiagramBuilder.build()"]
direction LR
r[/"r(t)\nReference"/] --> sum(("Σ"))
sum -->|"e(t)"| ctrl["Controller\nLQR · MPC · PID"]
ctrl -->|"u(t)"| plant["Plant\nLTI · Nonlinear · Acausal"]
plant -->|"x(t)"| obs["State Estimator\nKalman · EKF · UKF"]
obs --> sum
plant -->|"y(t)"| out[/"y(t)\nOutput"/]
end
style Diagram fill:#f5f8ff,stroke:#4a6fa5,stroke-width:2px
style ctrl fill:#dbeafe,stroke:#2563eb
style plant fill:#dcfce7,stroke:#16a34a
style obs fill:#fef9c3,stroke:#ca8a04
```
The JAX backend sits underneath every simulation, giving you a clean Python API backed by XLA compilation:
```mermaid
graph TD
A["Python API\nDiagram · LeafSystem · simulate()"] --> B["JAX Backend\nJIT · vmap · grad"]
B --> C1["Dopri5\nAdaptive RK45\nnon-stiff ODEs"]
B --> C2["BDF\nImplicit solver\nstiff systems"]
B --> C3["Event Handler\nZero-crossing\nbisection"]
style A fill:#e0f2fe,stroke:#0284c7
style B fill:#fdf4ff,stroke:#9333ea
style C1 fill:#f0fdf4,stroke:#16a34a
style C2 fill:#f0fdf4,stroke:#16a34a
style C3 fill:#f0fdf4,stroke:#16a34a
```
---
## The Jaxonomy stack
Jaxonomy is the engine at the base of a three-package stack. Each package is its
own repository, MIT-licensed, and depends only on the package(s) above it:
- **Jaxonomy** — *this package.* The general-purpose, JAX-native simulation
engine for hybrid dynamical systems. Not robotics-specific; depends on nothing
else in the stack.
- **[Jaxterity](https://github.com/machinavitalis/jaxterity)** — the robotics
layer built on top of Jaxonomy: URDF/MJCF import, MJX-backed articulated
dynamics, calibrated actuators/sensors, system identification, and whole-body
control. Imports Jaxonomy; never re-implements its primitives.
- **[Jaxility](https://github.com/machinavitalis/jaxility)** — the deployment
artifact factory: compiles a calibrated robot to embedded C for Arm SoCs
(Cortex-A / Cortex-M) with a signed attestation manifest. Consumes Jaxterity.
The boundary rule: anything useful to controls engineers *outside* robotics
(HVAC, battery, aerospace, energy) belongs in Jaxonomy; anything specific to
joints, actuators, contacts, and kinematic chains belongs in Jaxterity;
embedded codegen, targets, and attestation belong in Jaxility.
What Jaxonomy does **not** yet do (or does only partially) is tracked in
[`KNOWN_GAPS.md`](https://github.com/machinavitalis/jaxonomy/blob/main/KNOWN_GAPS.md) — the public inverse of the internal evidence
ledger in `CLAIMS.md`.
## License
Released under the [MIT License](https://github.com/machinavitalis/jaxonomy/blob/main/LICENSE.md) from version 2.2.0 onward.
Derived from the MIT-licensed open-source package **pycollimator** by **Collimator, Inc.**