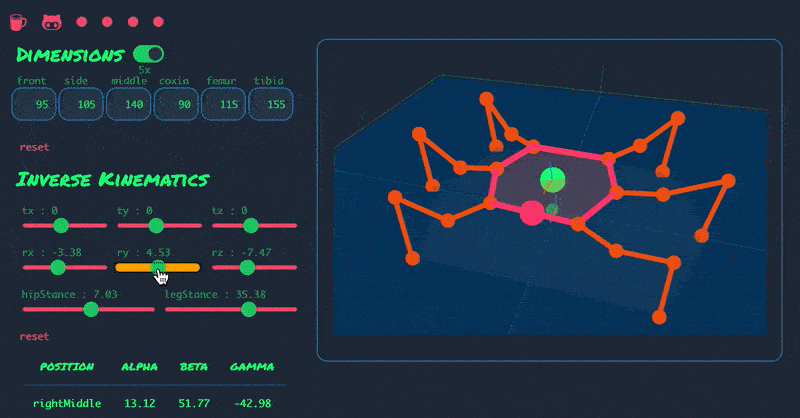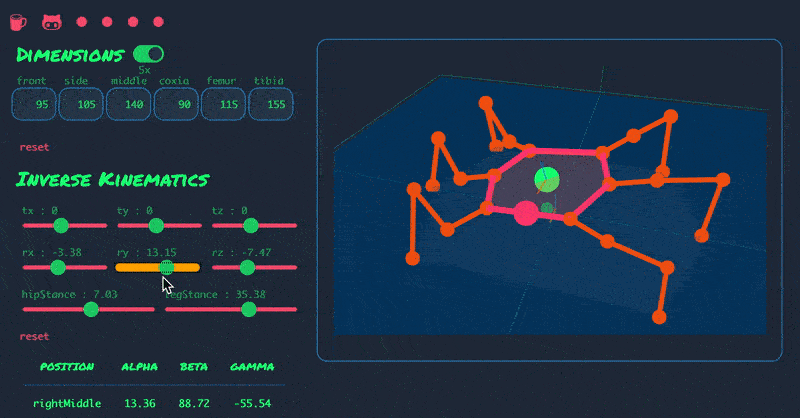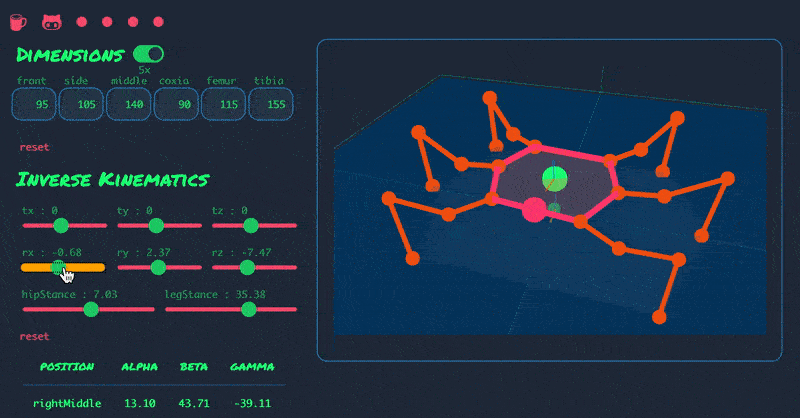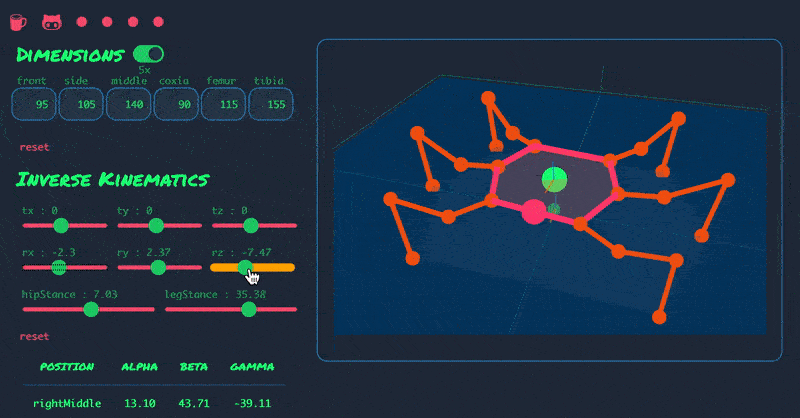
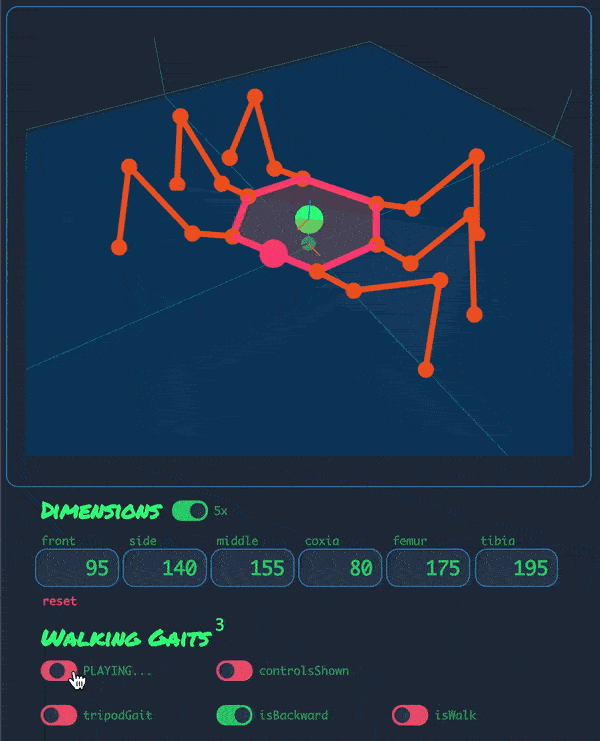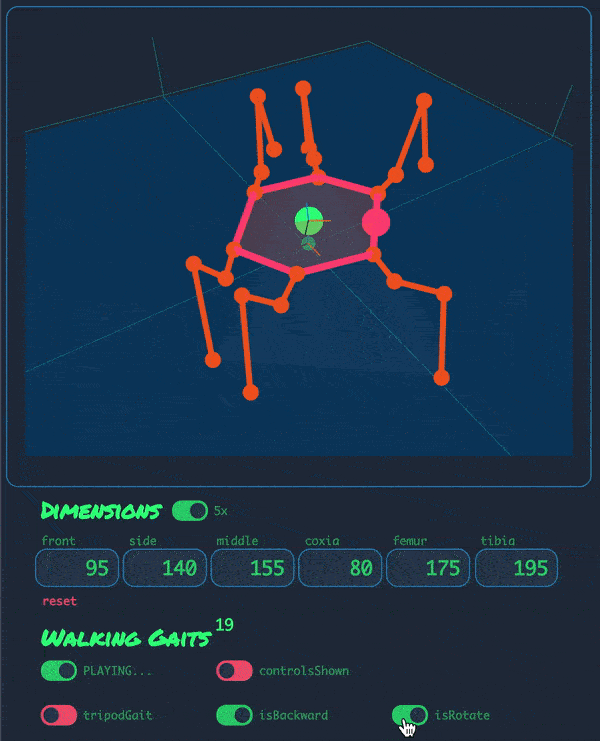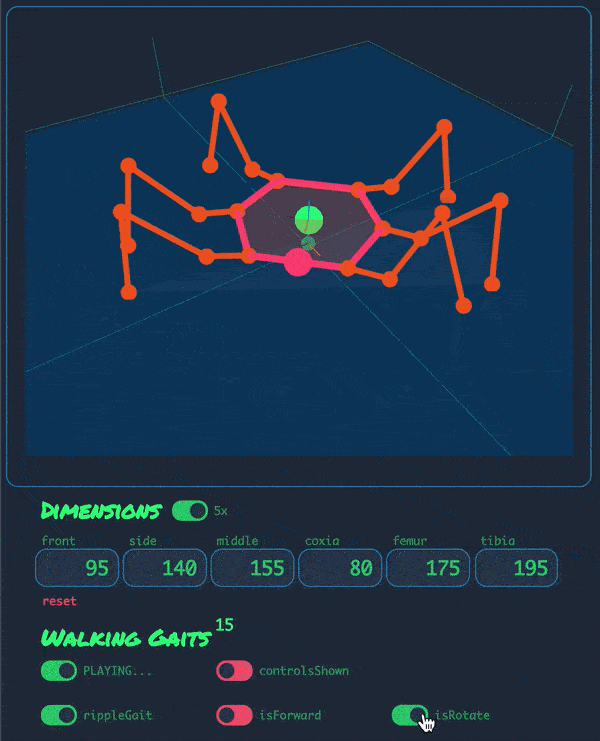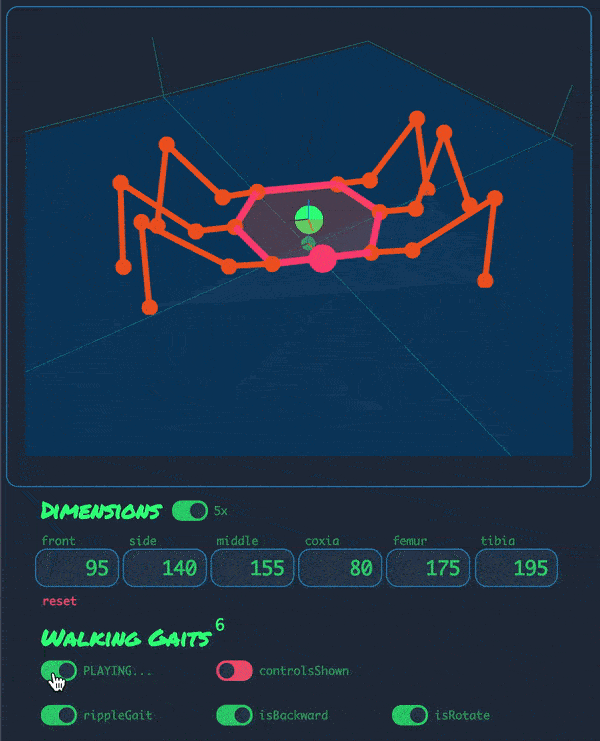
 🎉 Control
- [x] The robot's dimensions
- [x] The robot's 3d orientation, translation, stance, and more
🎉 Solve
- [x] Inverse Kinematics
- [x] Forward Kinematics
🎉 Simulate
- [x] Ripple and tripod gait variations
- [x] Walking forward and backwards
- [x] Rotating clockwise and counterclockwise
[🤖](https://hexapod.netlify.app/) [🐳](https://mithi.github.io/deep-blueberry/) [☕](https://ko-fi.com/minimithi)
## Related Things
If you'd like to build your own user interface with Node, you can download the algorithm alone as a package: [Hexapod Kinematics Library](https://github.com/mithi/hexapod-kinematics-library). There is also [a "fork" modified where you can use the app to control a physical hexapod robot](https://github.com/mithi/hexapod-irl) as you can see in the gif below.
|||
|--------|-------|
| Walking Gaits | Kinematics |
## Main Contributors [](./CONTRIBUTING.md)
Any contribution to improve the source code is always appreciated. [See contributing Guide](./CONTRIBUTING.md). I will put your name below if I've merged your PR multiple times or if you've substantially contributed to this project in other ways.
- [@mithi](https://github.com/mithi)
- [@icyJoseph](https://github.com/icyJoseph)
- [@mikong](https://github.com/mikong)
## I love badges! (Don't we all?)
[](https://github.com/mithi/hexapod/commits/master)
[](https://github.com/mithi/hexapod/graphs/commit-activity)
[](https://codecov.io/gh/mithi/hexapod)
[](https://github.com/prettier/prettier)
[](https://opensource.org/licenses/Apache-2.0)