# Reachy 2 MuJoCo Assets
This repository contains scenes and configuration files for the robot **Reachy 2** in [MuJoCo](https://mujoco.org/). These assets are used by Reachy's 2 software stack.
## Stack installation
Install the Reachy 2 software stack easily by using the [one liner](https://docs.pollen-robotics.com/developing-with-reachy-2/simulation/simulation-installation) provided in the documentation.
## Available Scenes
- `base_scene.xml`: the default empty scene
- `fruits_scene.xml`: a scene for sorting fruits on a table
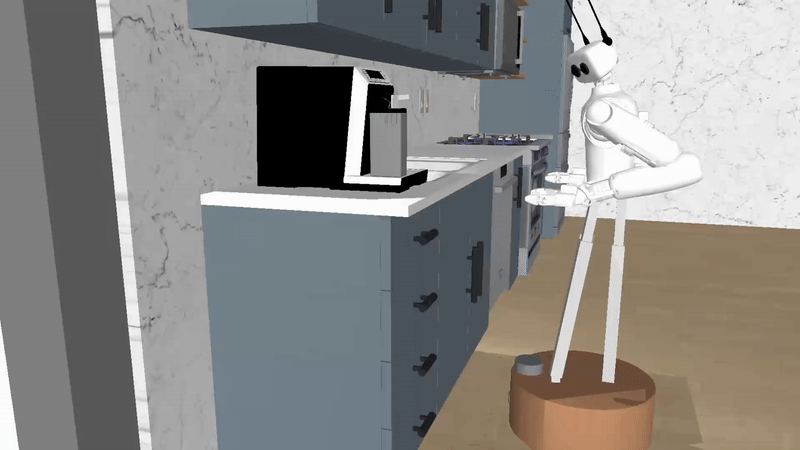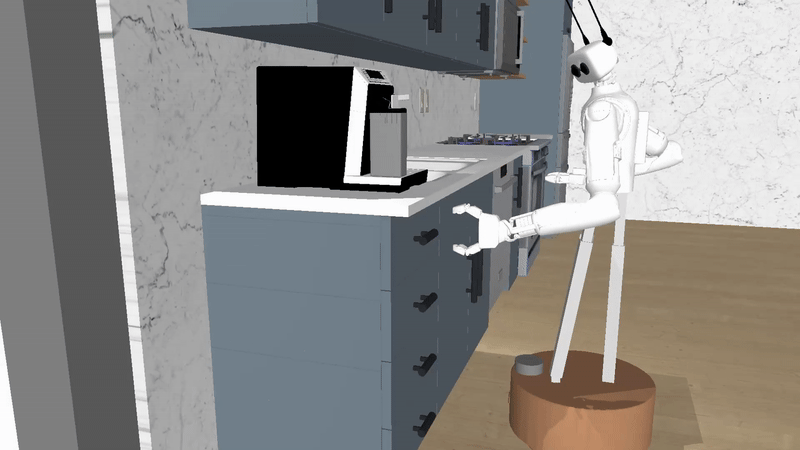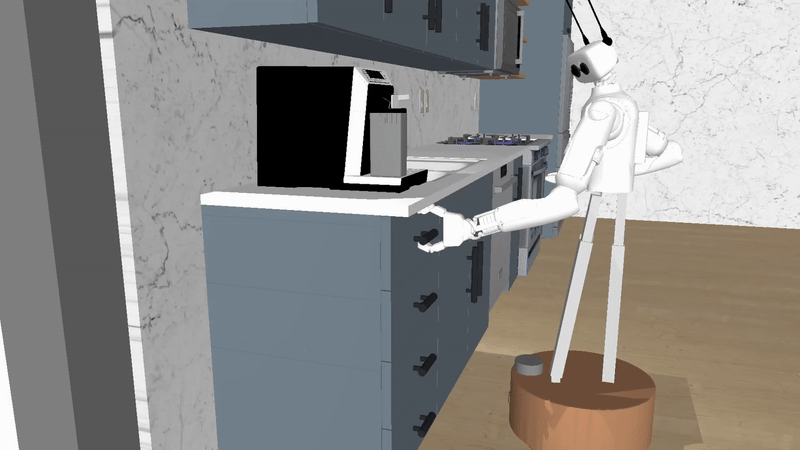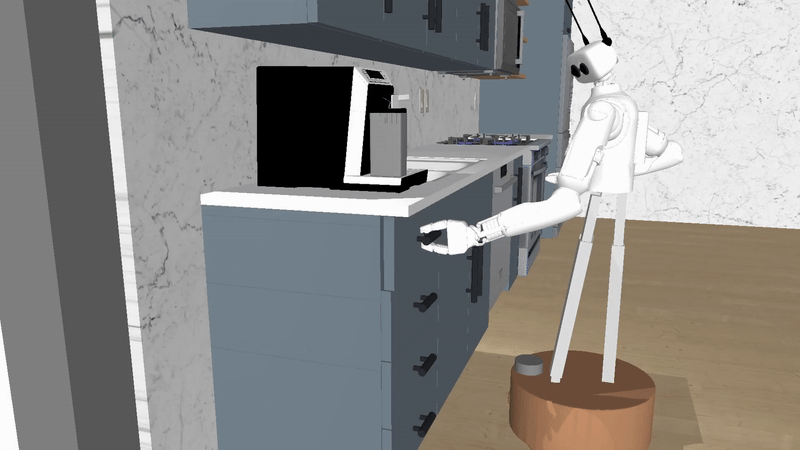
- `kitchen_scene.xml`: full kitchen for complex manipulation tasks *(adapted from [RoboCasa](https://github.com/robocasa/robocasa))*
- `table_scene.xml`: a simple scene with just one cube to manipulate on a table
### Visualization
A viewer script is provided to visualize the scenes in Mujoco. You can run it with the following command:
```bash
python viewer.py
```
**Note:** Mujoco must be installed via pip:
```bash
pip install mujoco
```
### Tracked objects
It is possible to obtain the real-time pose of objects in the Mujoco scene via the Client SDK.
To do this, you must add this parameter to the scene's XML file:
```xml
```
In the data, you can note down the body name of the objects you want to track, as many as you like.
In the available scenes, this setting is already there, but you can change the tracked objects as you see fit.
---
### Credits
The `kitchen_scene.xml` is based on assets from the [RoboCasa](https://github.com/robocasa/robocasa) project.
RoboCasa is an open-source collection of realistic home environments for robotics research, developed by the RoboCasa team.