RoboCasa
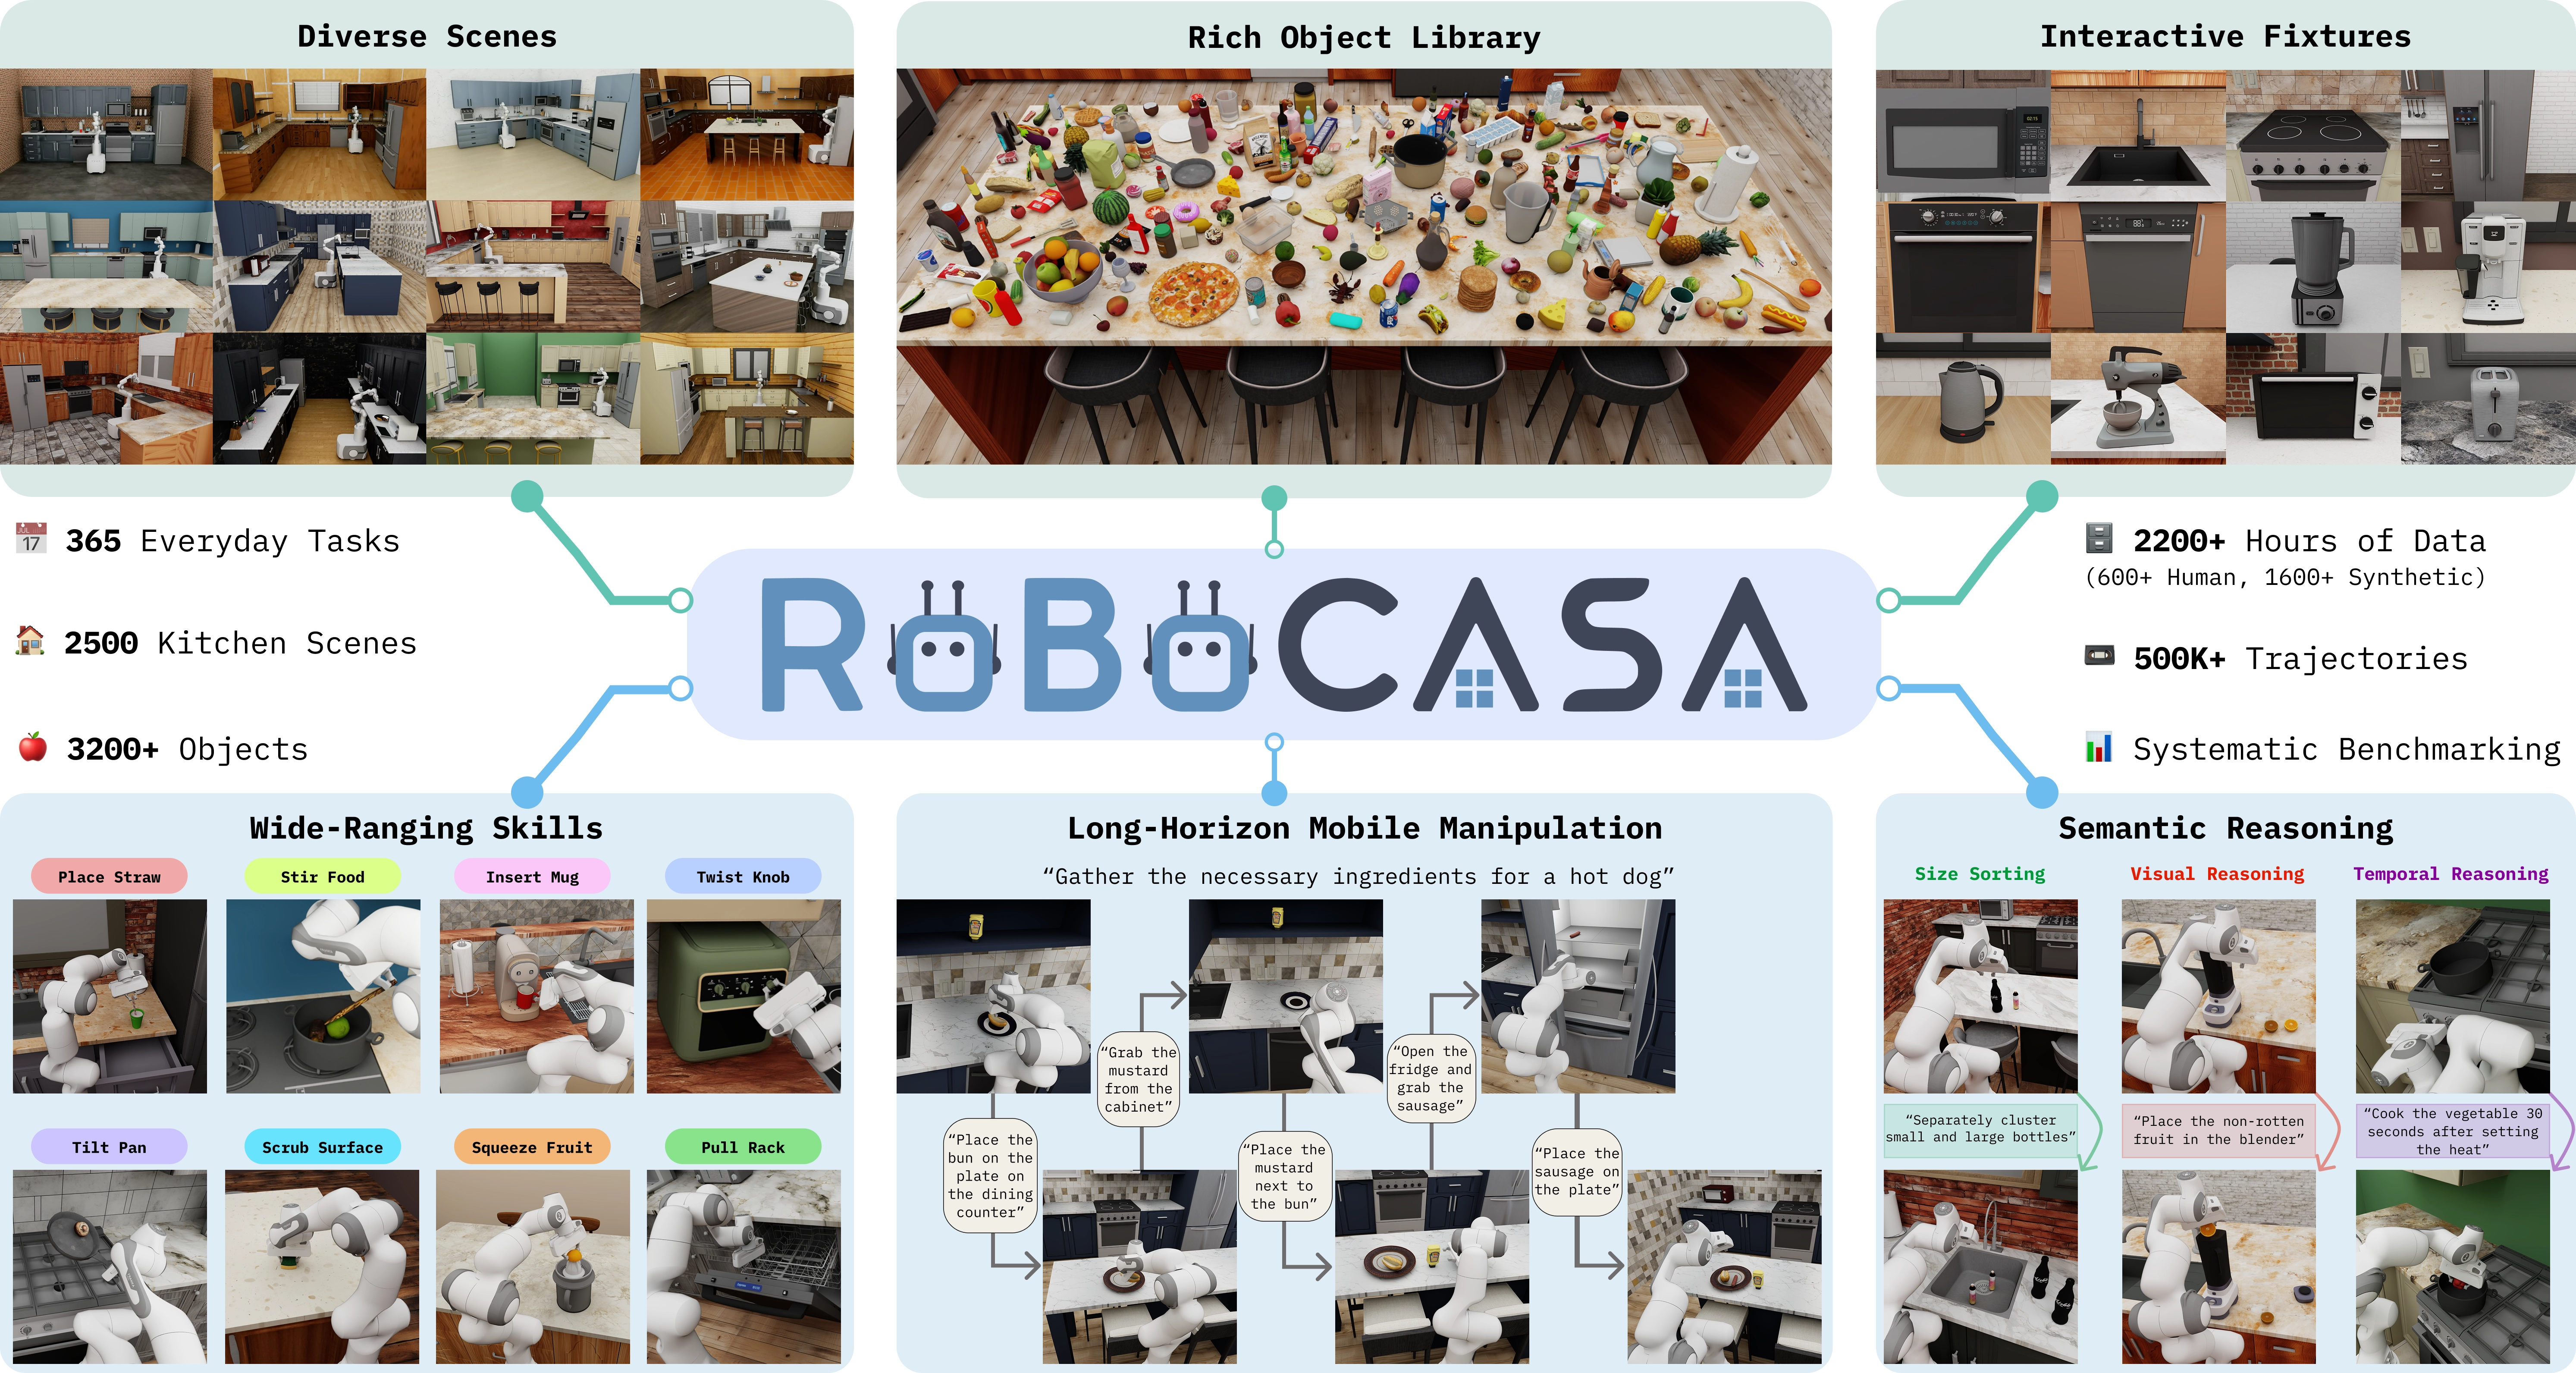 **RoboCasa** is a large-scale simulation framework for training generally capable robots to perform everyday tasks. It was [originally released](https://robocasa.ai/assets/robocasa_rss24.pdf) in 2024 by UT Austin researchers. The latest iteration, **RoboCasa365**, builds upon the original release with significant new functionalities to support large-scale training and benchmarking in sim. Four pillars underlie RoboCasa365:
- **Diverse tasks**: 365 tasks created with the guidance of large language models
- **Diverse assets**: including 2,500+ kitchen scenes and 3,200+ 3D objects
- **High-quality demonstrations**: including 600+ hours of human demonstrations in addition to 1,600+ hours of robot datasets created with automated trajectory tools
- **Benchmarking support**: popular policy learning methods including Diffusion Policy, pi, and GR00T, plus user-submitted models on the [leaderboard](https://robocasa.ai/leaderboard.html)
This guide contains information about installation and setup. Please refer to the following resources for additional information:
[**[Home page]**](https://robocasa.ai) [**[Documentation]**](https://robocasa.ai/docs/introduction/overview.html) [**[RoboCasa365 Paper]**](https://robocasa.ai/assets/robocasa365_iclr26.pdf) [**[Original RoboCasa Paper]**](https://robocasa.ai/assets/robocasa_rss24.pdf) [**[Leaderboard]**](https://robocasa.ai/leaderboard.html)
-------
## Updates
* [7/7/2026] Our target composite task datasets have been updated to include per-frame **subtask annotations**. Every timestep is labeled with a subtask index, atomic-skill name, stage (i.e. pick / place / navigate), and a natural-language instruction, to support hierarchical policy learning.
* [5/12/2026] **v1.0.1**: Updated horizon lengths (1.5x increase) across all tasks for consistency. Please update to the latest version for running evals.
* [4/6/2026] **RoboCasa365 Leaderboard** published, comparing generalist robot policies on the multi-task learning benchmark and open to community model submissions.
* [2/18/2026] **v1.0**: RoboCasa365 release, with 365 tasks, 2500+ kitchen scenes, 2200+ hours of robot demonstration data, and benchmarking support.
* [10/31/2024] **v0.2**: using RoboSuite `v1.5` as the backend, with improved support for custom robot composition, composite controllers, more teleoperation devices, photo-realistic rendering.
## Table of Contents
- [Updates](#updates)
- [Installation](#installation)
- [Basic Usage](#basic-usage)
- [Tasks, datasets, policy learning, and additional use cases](#tasks-datasets-policy-learning-and-additional-use-cases)
- [License](#license)
- [Citation](#citation)
-------
## Installation
RoboCasa works across all major computing platforms. The easiest way to set up is through the [Anaconda](https://www.anaconda.com/) package management system. Follow the instructions below to install:
1. Set up conda environment:
```sh
conda create -c conda-forge -n robocasa python=3.11
```
2. Activate conda environment:
```sh
conda activate robocasa
```
3. Clone and setup robosuite dependency (**important: use the master branch!**):
```sh
git clone https://github.com/ARISE-Initiative/robosuite
cd robosuite
pip install -e .
```
4. Clone and setup this repo:
```sh
cd ..
git clone https://github.com/robocasa/robocasa
cd robocasa
pip install -e .
pip install pre-commit; pre-commit install # Optional: set up code formatter.
(optional: if running into issues with numba/numpy, run: conda install -c numba numba=0.56.4 -y)
```
5. Install the package and download assets:
```sh
python -m robocasa.scripts.setup_macros # Set up system variables.
python -m robocasa.scripts.download_kitchen_assets # Caution: Assets to be downloaded are around 10GB.
```
-------
## Basic Usage
### Gym wrapper
You can create environments using gym wrappers and run rollouts:
```py
import gymnasium as gym
import robocasa
from robocasa.utils.env_utils import run_random_rollouts
env = gym.make(
"robocasa/PickPlaceCounterToCabinet",
split="pretrain", # use 'pretrain' or 'target' kitchen scenes and objects
seed=0 # seed environment as needed. set seed=None to run unseeded
)
# run rollouts with random actions and save video
run_random_rollouts(
env, num_rollouts=3, num_steps=100, video_path="/tmp/test.mp4"
)
```
### Play back sample demonstrations of tasks
**(Mac users: for these scripts, prepend the "python" command with "mj": `mjpython ...`)**
Select a task and play back a sample demonstration for the selected task:
```
python -m robocasa.demos.demo_tasks
```
### Explore kitchen scenes
Explore 2500+ kitchen scenes:
```
python -m robocasa.demos.demo_kitchen_scenes
```
### Explore library of 2500+ objects
View and interact with both human-designed and AI-generated objects:
```
python -m robocasa.demos.demo_objects
```
Note: By default, this demo shows objaverse objects. To view AI-generated objects, add the flag `--obj_types aigen`.
### Teleoperate the robot
Control the robot directly, either through a keyboard controller or spacemouse. This script renders the robot semi-translucent in order to minimize occlusions and enable better visibility.
```
python -m robocasa.demos.demo_teleop
```
Note: If using SpaceMouse, you may need to modify the product ID to your appropriate model, setting `SPACEMOUSE_PRODUCT_ID` in `robocasa/macros_private.py`.
-------
## Tasks, datasets, policy learning, and additional use cases
Please refer to the [documentation page](https://robocasa.ai/docs/introduction/overview.html) for information about tasks, datasets, benchmarking, and more.
-------
## License
Code: [MIT License](https://opensource.org/license/mit)
Assets and Datasets: [CC BY 4.0](https://creativecommons.org/licenses/by/4.0/deed.en)
-------
## Citation
**RoboCasa365:**
```bibtex
@inproceedings{robocasa365,
title={RoboCasa365: A Large-Scale Simulation Framework for Training and Benchmarking Generalist Robots},
author={Soroush Nasiriany and Sepehr Nasiriany and Abhiram Maddukuri and Yuke Zhu},
booktitle={International Conference on Learning Representations (ICLR)},
year={2026}
}
```
**RoboCasa (Original Release):**
```bibtex
@inproceedings{robocasa2024,
title={RoboCasa: Large-Scale Simulation of Everyday Tasks for Generalist Robots},
author={Soroush Nasiriany and Abhiram Maddukuri and Lance Zhang and Adeet Parikh and Aaron Lo and Abhishek Joshi and Ajay Mandlekar and Yuke Zhu},
booktitle={Robotics: Science and Systems (RSS)},
year={2024}
}