[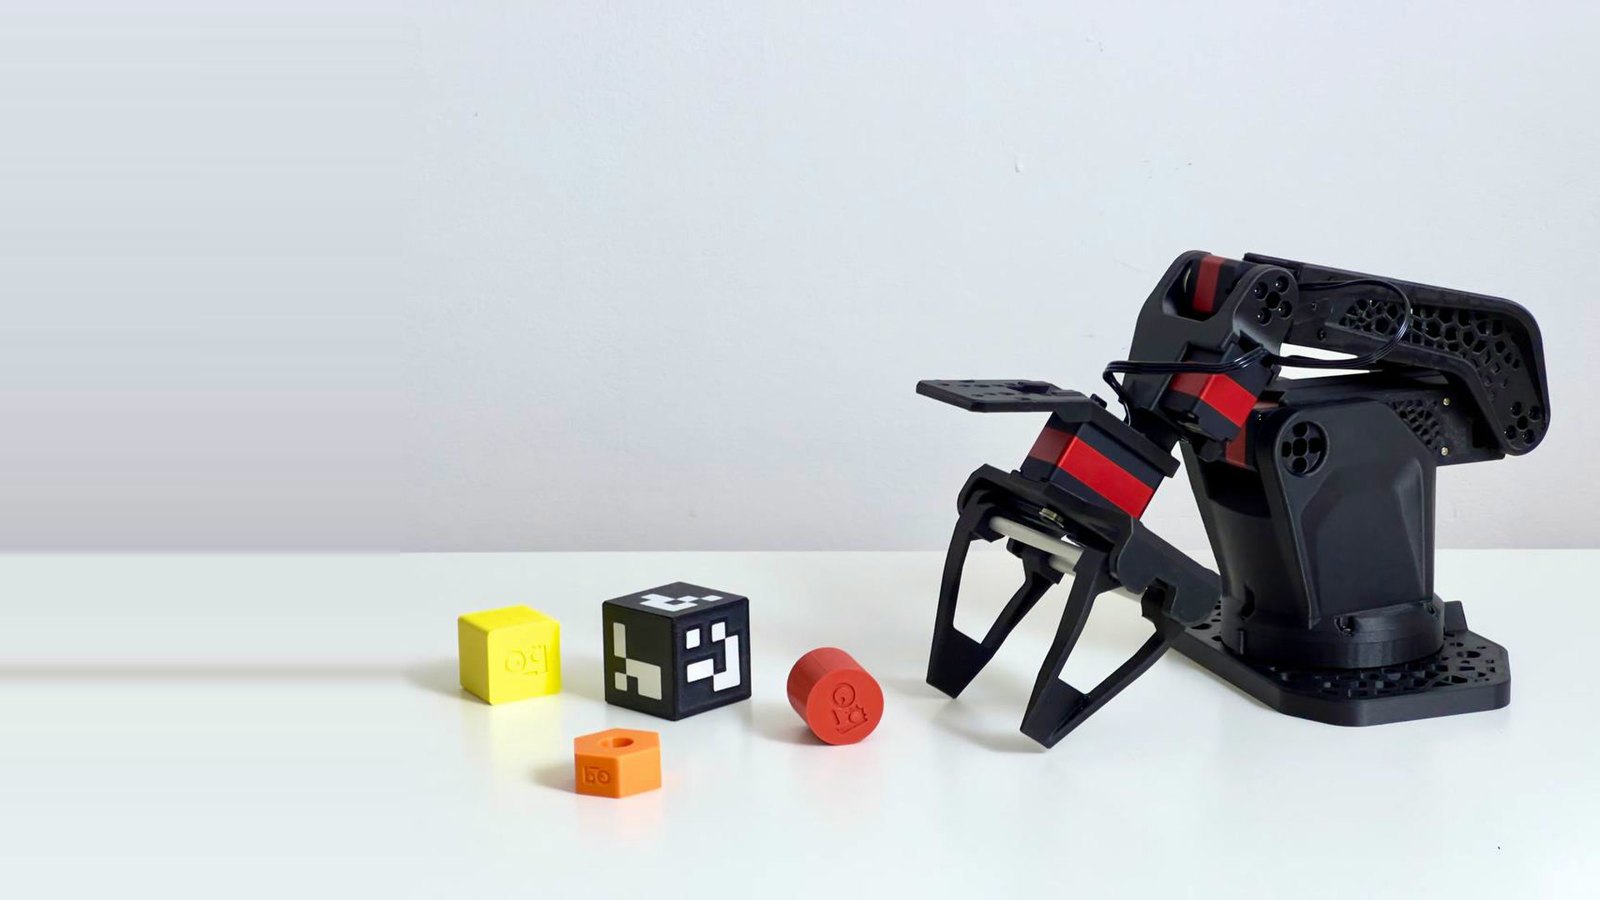](assets/video/so-arm-102-preview.mp4)
**🎥 [Watch the preview video](assets/video/so-arm-102-preview.mp4)** · **🛒 [Buy the kit](https://robonine.com/shop/so-arm102-robotic-arm-kit/)**
**SO-ARM 102 is an open-source leader–follower robot arm kit for teleoperation and imitation learning. Each arm has five degrees of freedom plus a gripper.**
Building on SO-ARM 100 and 101, it combines a stiffer PET-CF frame with a parallel gripper.
[](HARDWARE-LICENSE.txt)
[](SOFTWARE-LICENSE.txt)
[](DOCS-LICENSE.txt)
[](https://github.com/roboninecom/SO-ARM-102/releases/latest)
📩 [hello@robonine.com](mailto:hello@robonine.com)
**DIY budget: ~$342 for components, or ~$388 including printing material.**
[BOM summary](#bill-of-materials) · [Itemised costs and purchase links](docs/bom.md#estimated-kit-cost)
> Rather not source the parts and print them yourself? **[Buy the SO-ARM 102 kit](https://robonine.com/shop/so-arm102-robotic-arm-kit/)**.
[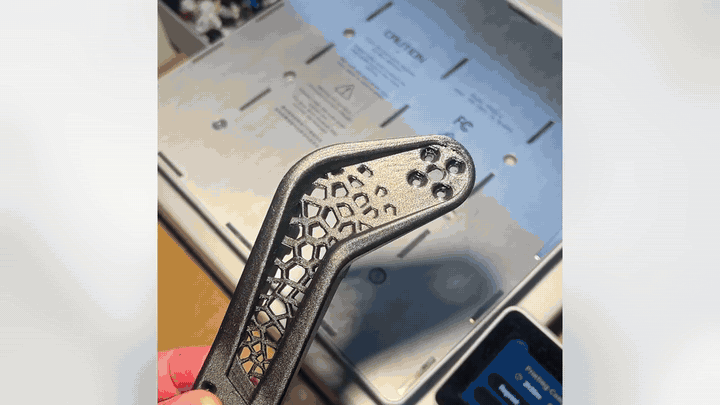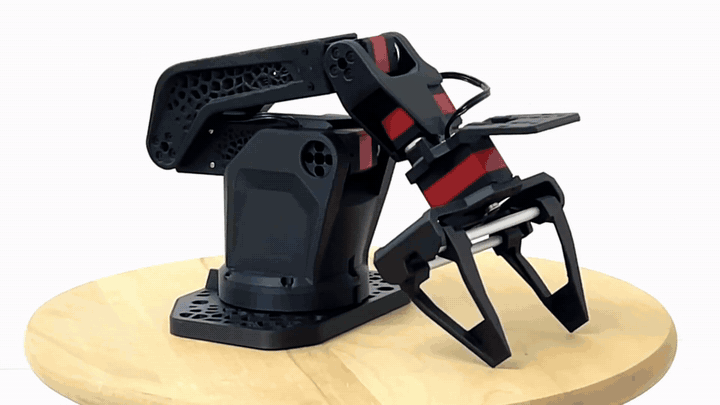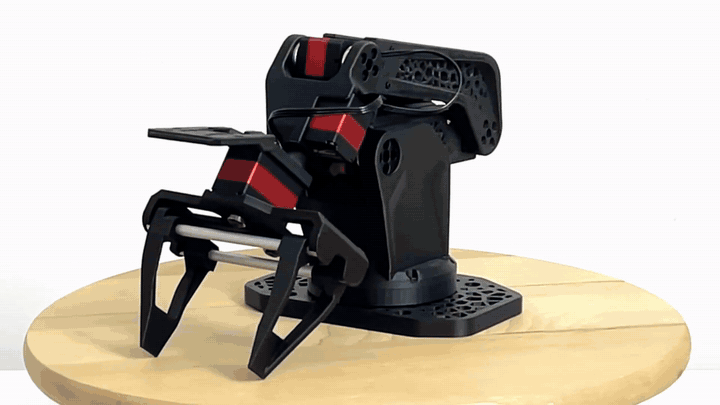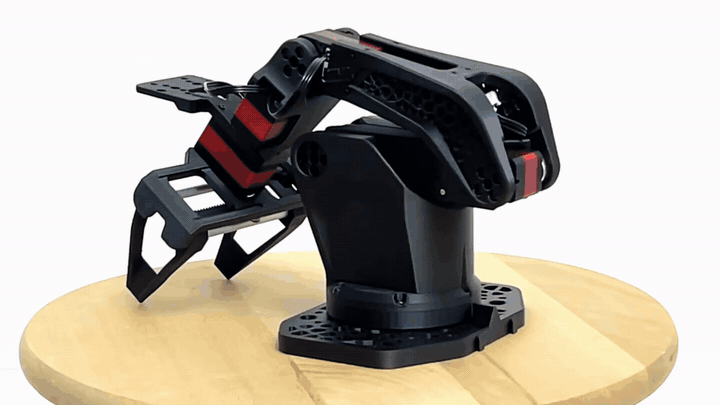](assets/video/so-arm-102-preview.mp4)
*Click for the full video, 21 s*
---
## 🤝 Configurations
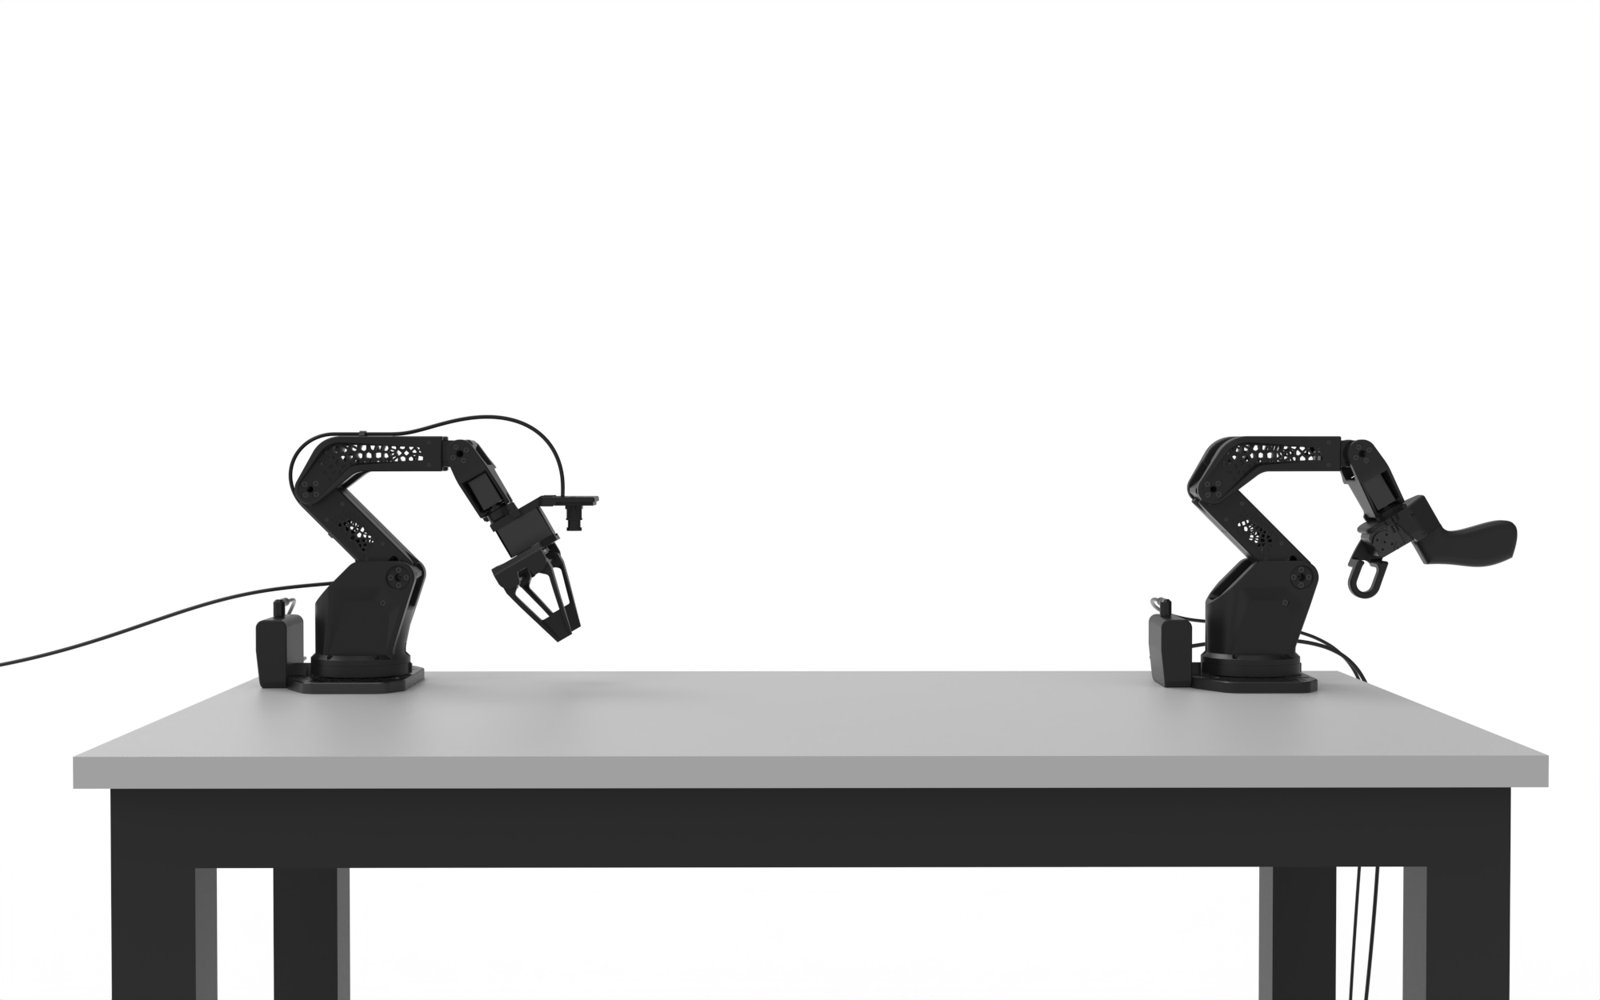
### Single-arm: one leader + one follower
The standard kit. Move the leader by hand, and the follower repeats the motion.
Use it for teleoperation and for recording demonstrations for imitation learning.
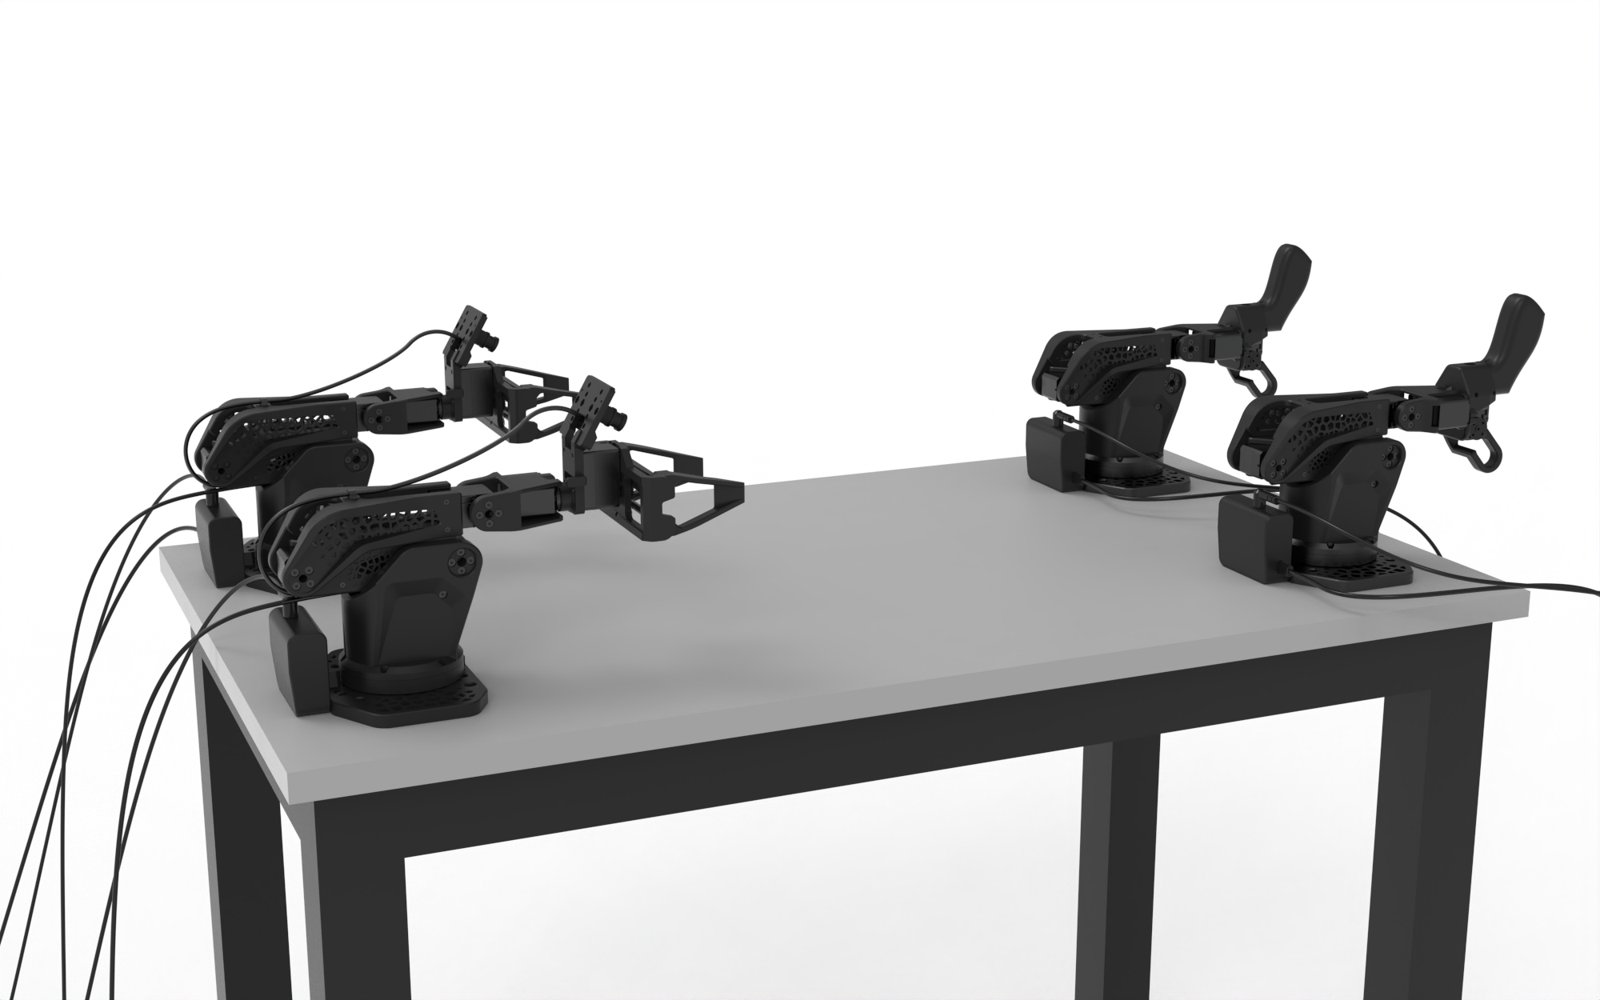
### Bimanual: two leaders + two followers
Two kits side by side. Each hand drives its own leader, so the followers can pass objects,
hold and work on a part, or do any task that needs two hands.
### The two arms
| Follower | Leader |
|:-:|:-:|
| 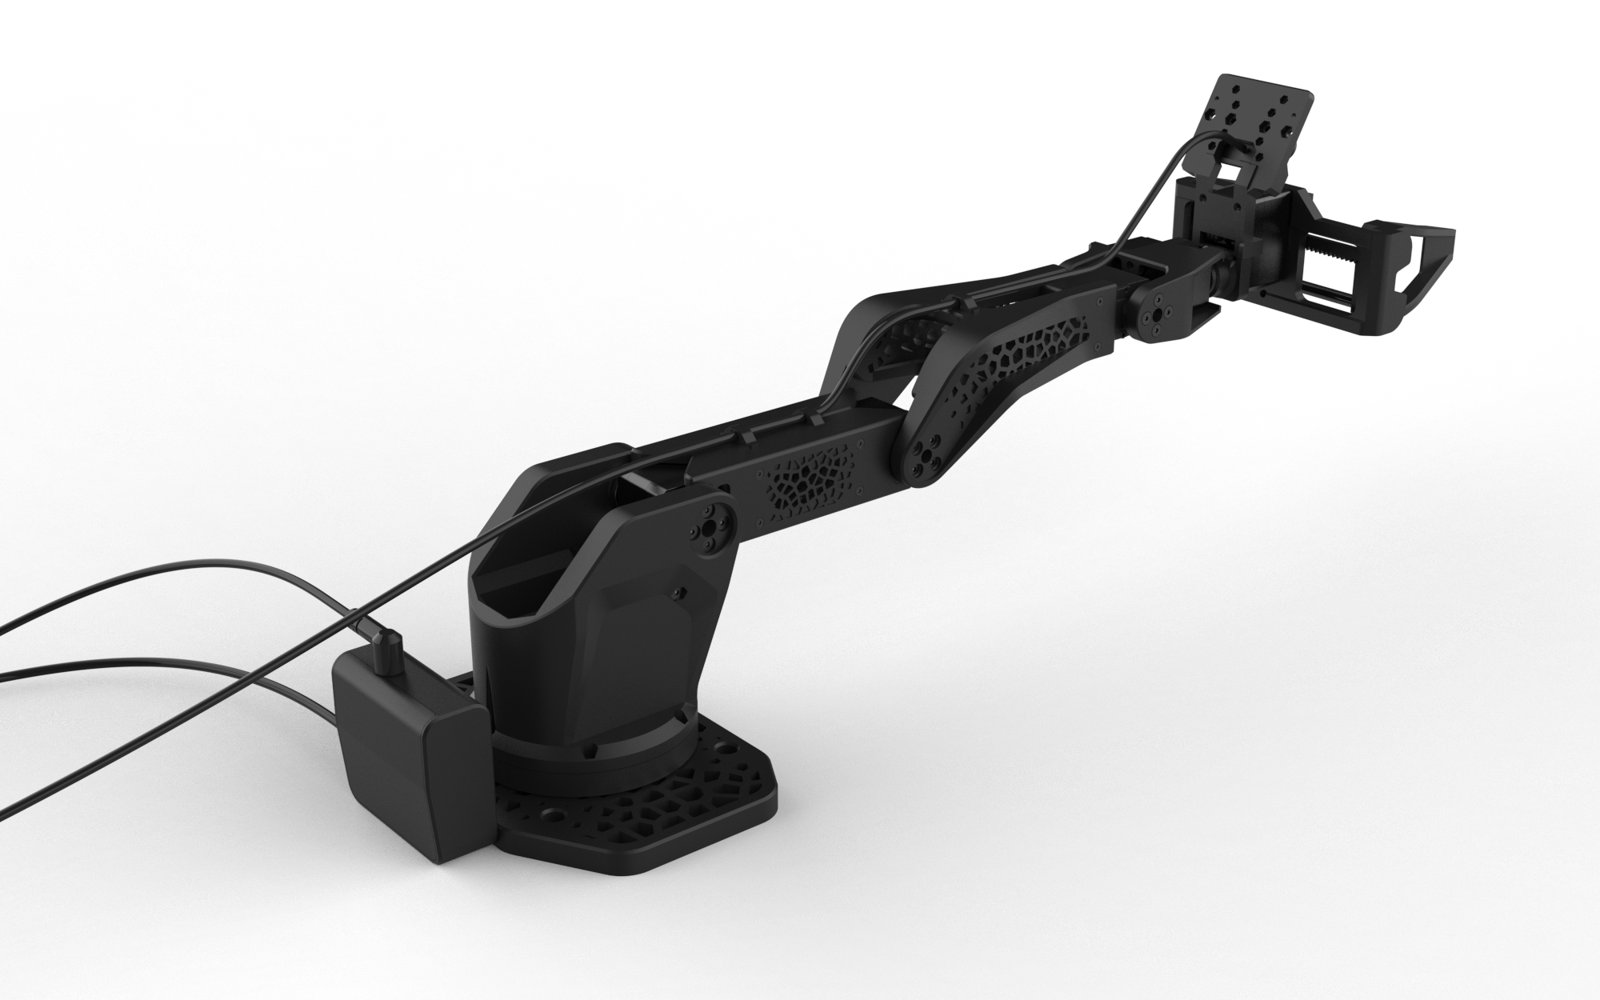 | 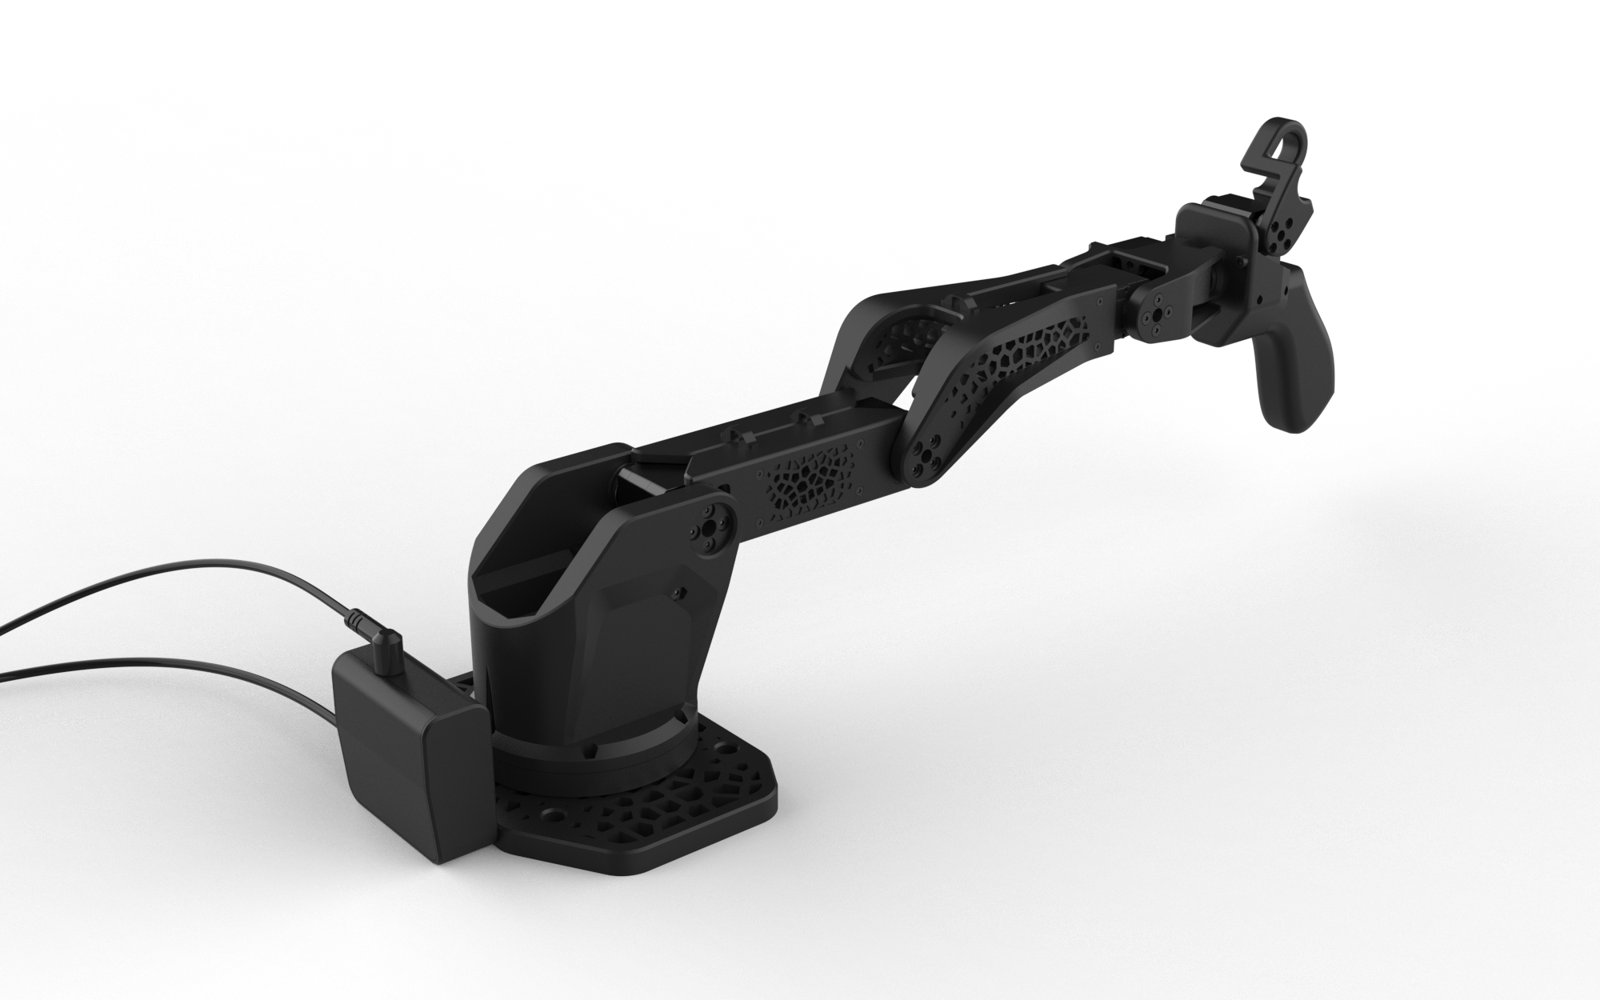 |
| Parallel gripper, wrist camera, 12 V | Handle with trigger, 5 V |
---
## 🚀 Build it in four steps
Prefer a ready kit? **[Buy the SO-ARM 102 kit](https://robonine.com/shop/so-arm102-robotic-arm-kit/)**.
### 1. Print the parts
Individual parts fit a 180 × 180 mm bed. The largest part is 160 mm long.
The supplied 3MF plate layouts use a 256 × 256 mm bed.
- 3MF slicer projects with saved orientation and support settings: [`models/3mf/`](models/3mf/)
— [leader](models/3mf/SO102.3.01_Leader_table_PLA+.3mf), [follower arm links](models/3mf/SO102.1.01_Follower_table_arm_links_PET-CF.3mf),
[follower gripper and base](models/3mf/SO102.2.01_Follower_table_base_PETG-CF.3mf)
- Project contents and printer profiles: [models/README.md](models/README.md)
- STL files, ready to slice: [`models/stl/`](models/stl/)
- STEP sources: [`models/step/`](models/step/)
- Material, settings and part quantities: [docs/printing.md](docs/printing.md)
### 2. Buy the hardware
Source the components from the [BOM summary](#bill-of-materials) and
[full BOM with purchase links](docs/bom.md). Budget **$342.4** for components,
or **$388.4** including printing material, before shipping and taxes.
| Arm | Servos | Controller | Power |
|---|---|---|---|
| Follower | 2 × STS3235, 2 × STS3250, 2 × STS3215 | Waveshare Bus Servo Adapter | **12 V** |
| Leader | 6 × STS3215 | Waveshare Bus Servo Adapter | **5 V** |
> ⚠️ **The leader runs on 5 V and the follower on 12 V.** Do not swap the power supplies.
### 3. Assemble
- Printable booklet, 32 pages A5: [docs/SO-ARM102_assembly_A5_v0.8.pdf](docs/SO-ARM102_assembly_A5_v0.8.pdf)
- Step list with parts and fasteners: [docs/assembly-guide.md](docs/assembly-guide.md)
Tools: hex keys 1.5 mm (M2 screws) and 2 mm (M3 screws).
### 4. Set up the software
Servo IDs, calibration and lessons: **[lab.robonine.com](https://lab.robonine.com)**.
Use the SO-ARM 102 follower plugin with the standard `so101_leader` type.
**[LeRobot installation and setup](docs/lerobot.md)**.
---
## Bill of materials
Quantities and reference costs for **one leader + one follower**:
| Category / purchase links | Kit contents | Total (USD) |
|---|---|---:|
| [Servos](docs/bom.md#servos) | 6 × STS3215 7.4 V, 2 × STS3215 12 V, 2 × STS3235, 2 × STS3250 | $240.7 |
| [Electronics](docs/bom.md#electronics) | 2 controllers, 2 power supplies, 2 USB cables, 1 wrist camera | $50.5 |
| [Mechanical parts](docs/bom.md#mechanical-parts) | 4 bearings, 2 steel guide rods, 4 table clamps | $40.0 |
| [Fasteners](docs/bom.md#fasteners) | Screws and nuts; specified servo-kit screws included | $11.2 |
| **Components subtotal** | | **$342.4** |
| [Printing material](docs/bom.md#printing-materials) | 0.4 kg PET-CF17 + 0.3 kg PETG-CF + 0.5 kg PLA+ | $46.0 |
| **Total with printing material** | | **$388.4** |
Buying the example full packs and filament spools from scratch costs about **$430**,
including unused spares. These are reference estimates, not new supplier quotes.
Shipping, taxes, tools, a computer, a printer, electricity and assembly labour are excluded.
Confirm supplier prices, variants and minimum order quantities before ordering;
re-slice the 3MF projects to check filament consumption.
[Full BOM, purchase links and cost assumptions](docs/bom.md#estimated-kit-cost).
---
## URDF export
The current standalone export is in [`simulation/urdf/`](simulation/urdf/):
[URDF](simulation/urdf/so_arm_102.urdf) · [Xacro](simulation/urdf/so_arm_102.xacro).
Keep `meshes/` beside the description files; mesh paths are relative to this folder.
- **Visuals:** STL meshes. **Collisions:** fitted, independently rotated boxes on all eight links.
- **Mass estimate:** PLA, 30% infill, 6 perimeters, 6 top/bottom layers,
0.2 mm layer height, and **0.4 mm extrusion width**. These are simulation
assumptions; use [the printing guide](docs/printing.md) for fabrication settings.
- **Hardware masses:** six motors at 70 g each; base bearing at 105 g.
Total estimated model mass: **0.889 kg**.
- **Gripper:** `clamp2` mimics `clamp1` with multiplier `-1`.
[Export settings](simulation/urdf/export_settings.json) and
[mass properties](simulation/urdf/mass_properties.json) record the assumptions.
Geometry and inertia checks are recorded in [export_verification.json](simulation/urdf/export_verification.json).
---
## 📁 Repository structure
```
├── models/
│ ├── 3mf/ # Slicer projects: leader, follower, gripper and board case
│ ├── stl/ # Print-ready meshes
│ │ ├── common/ # Shared parts, including controller cases
│ │ ├── follower/ # Parallel gripper and camera mount
│ │ └── leader/ # Handle, trigger and wrist roll
│ └── step/ # CAD sources, same layout as stl/
├── docs/
│ ├── printing.md # Material, slicer settings, quantities
│ ├── bom.md # Bill of materials
│ ├── assembly-guide.md # Step list with parts and fasteners
│ ├── specifications.md # Geometry, servos, measured results vs SO-ARM 101
│ └── SO-ARM102_assembly_A5_v0.8.pdf
├── assets/
│ ├── images/ # Photos, renders, booklet pages, test photos
│ └── video/ # Preview video and GIF
├── LICENSING.md # Which licence covers which file
└── NOTICE # Third-party attribution
```
---
## ⚠️ Known issues
Build notes from independent testing; check these when assembling.
1. **Use booklet v0.8.** Earlier booklets show the HAT controller and older gripper parts. v0.8 fits a Bus Servo Adapter on both arms.
2. **M2 screws are hard to reach in several places.** Expect to fight a few of them.
3. **The gripper clamps run tight on carbon rods.** The clamp bores are sized for 6.1 mm. Rod diameters vary between suppliers, so check the fit before assembly.
4. **Check the servo cable lengths** before closing each joint, especially from the base to the shoulder.
5. **The assembly order is awkward in two places** of the booklet. Read two steps ahead before fastening.
6. **Leader joints can feel loose.** Adding 8 × 2 mm rubber O-rings between each servo and its horn gives the leader smooth, silent friction. Use two per servo on joints 2–4 and one on joints 1, 5, 6.
Found something else? Please [open an issue](https://github.com/roboninecom/SO-ARM-102/issues).
---
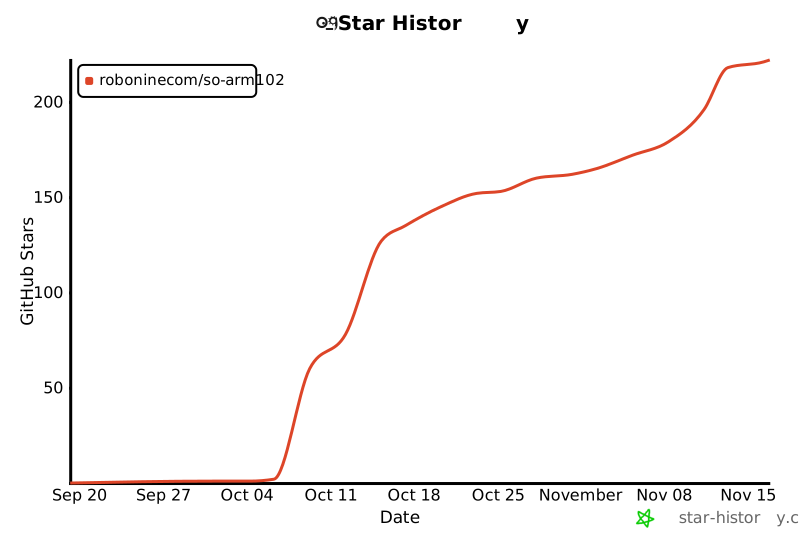
## ⭐ Star History
[](https://www.star-history.com/?repos=roboninecom%2FSO-ARM102&type=date&legend=top-left)
---
## 🔗 Related projects
- [SO-ARM100/101 Parallel Gripper](https://github.com/roboninecom/SO-ARM100-101-Parallel-Gripper), the gripper the SO-ARM 102 gripper grew from
- [SO-ARM101](https://github.com/TheRobotStudio/SO-ARM100) by TheRobotStudio, the arm this design succeeds
- [Practical comparison of smart serial servos](https://robonine.com/smart-serial-servo-motor-comparison-robotics/), the tests behind the servo choice
- [Choosing a filament for robotic arms](https://robonine.com/choosing-filament-for-robotic-arm-applications/), the tests behind PET-CF
---
## 📄 License
Copyright (c) 2026 Robonine. Different kinds of material carry different licences:
| Material | Licence |
|---|---|
| Hardware designs in `models/` | [CERN-OHL-P-2.0](HARDWARE-LICENSE.txt) |
| Software and configuration | [Apache-2.0](SOFTWARE-LICENSE.txt) |
| Documentation and images in `docs/`, `assets/`, all `README.md` | [CC BY 4.0](DOCS-LICENSE.txt) |
See [LICENSING.md](LICENSING.md) and [REUSE.toml](REUSE.toml) for the file-by-file map.
---
## 👥 Team
| Name | Role | Contact |
|------|------|---------|
| **Alan Subin** | Design Engineer: mechanical design, CAD, assembly booklet | [LinkedIn](https://www.linkedin.com/in/alan-subin/) |
| **Boris Kotov** | Software and Test Engineer: prototypes, printing, test rigs | [Telegram](https://t.me/bkotov) |
| **Nikita Bragin** | Project Manager | [LinkedIn](https://www.linkedin.com/in/nikita-bragin-82296b29/) |
| **Mikhail Chistiakov** | Industrial Designer: look and form of the arm | [Telegram](https://t.me/brrryska) |
| **Mikhail Zhmaylo** | Structural Engineer: stiffness models, design changes to cut deflection | [Telegram](https://t.me/mikhail_zhmaylo) |
| **Vladislav Eremenko** | Structural Engineer: strength and thermal analysis, topology optimisation | [Telegram](https://t.me/v1ad_eremenko) |
| **Vladimir Osipov** | Tester and Consultant: independent test build | [LinkedIn](https://www.linkedin.com/in/vladimirosipov/) |