# SO-ARM100/101/102 Parallel Gripper
[English](docs/i18n/en/README.md) · [Русский](docs/i18n/ru/README.md) · [Español](docs/i18n/es/README.md) · [Français](docs/i18n/fr/README.md) · [Deutsch](docs/i18n/de/README.md) · [Português (Brasil)](docs/i18n/pt-BR/README.md) · [简体中文](docs/i18n/zh-CN/README.md) · [日本語](docs/i18n/ja/README.md) · [हिन्दी](docs/i18n/hi/README.md) · [العربية](docs/i18n/ar/README.md)
[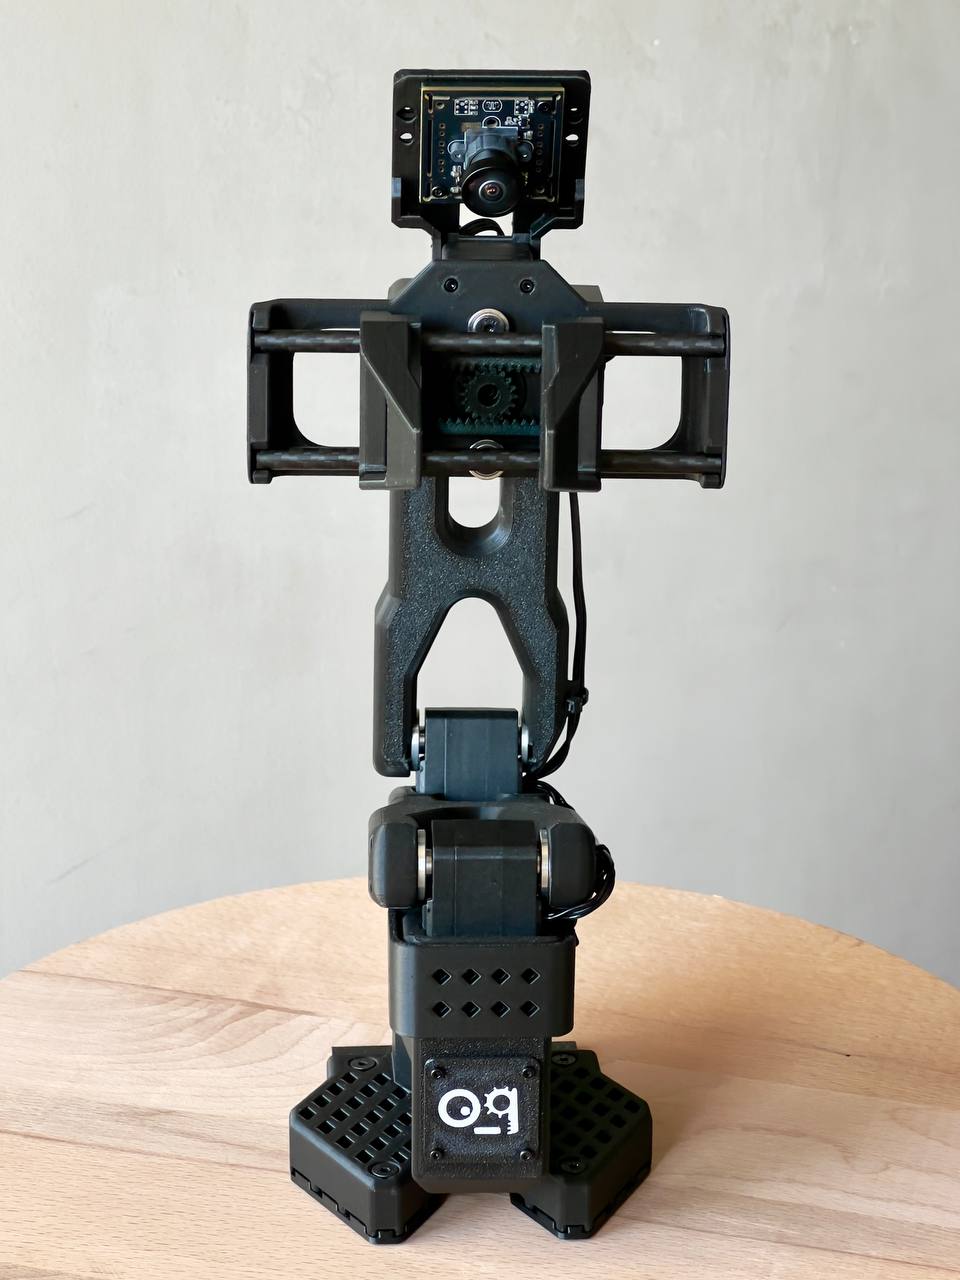](https://youtube.com/shorts/bSyXjgNGXZk)
**🎥 [Watch the gripper in action!](https://youtube.com/shorts/bSyXjgNGXZk)** · **🛒 [Buy the SO-ARM102 kit with a parallel gripper](https://robonine.com/shop/so-arm102-robotic-arm-kit/)**
A lightweight 3D-printed parallel gripper designed by **[Robonine](https://robonine.com)** for the open-source SO-ARM100/101 robotic platform.
> Prefer a complete robot arm kit with a parallel gripper? **[Buy the SO-ARM102 kit](https://robonine.com/shop/so-arm102-robotic-arm-kit/)**.
[](HARDWARE-LICENSE.txt)
[](SOFTWARE-LICENSE.txt)
[](DOCS-LICENSE.txt)
[](docs/bom.md)
[](docs/assembly-guide.md)
---
**Questions? We're here to help!**
📩 Email: [hello@robonine.com](mailto:hello@robonine.com)
---
## ✨ Key Features
| Feature | Description |
|---------|-------------|
| **120N Gripping Force** | Reliable parallel jaw mechanism |
| **14 mm/s Speed** | Gripper operation speed |
| **84mm Full Stroke** | Wide opening for various objects |
| **0.5mm Repeatability** | High precision positioning |
| **Camera Compatible** | Supports RealSense, Orbbec, USB cameras |
| **3D Printable** | All parts print on standard FDM printers |
| **~$50 Total Cost** | Affordable open-source solution |
| **Easy Assembly** | 30-45 minutes with basic tools |
---
## 📸 Gallery
### Gripper on SO-ARM101
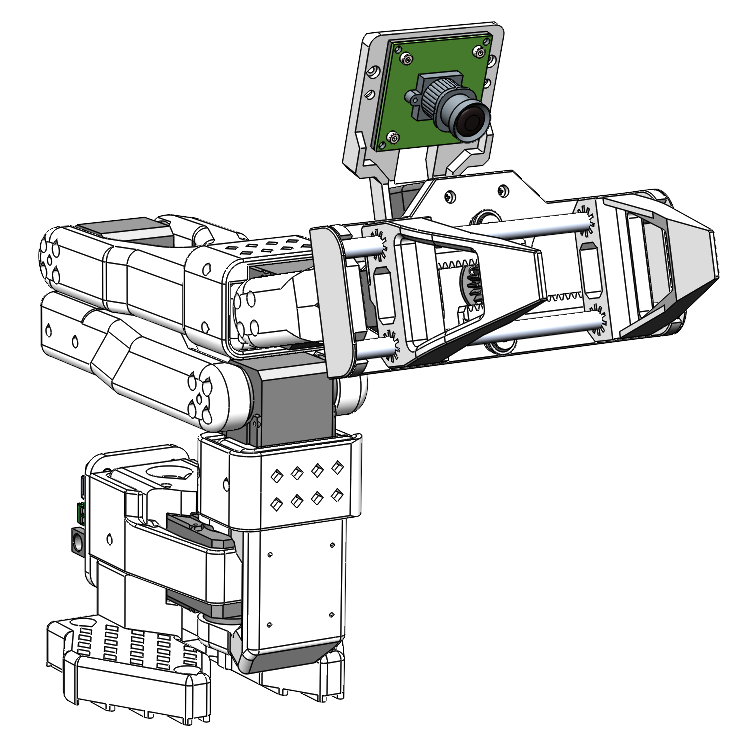
*Follower gripper integrated with SO-ARM101 robot arm*
### Dimensions
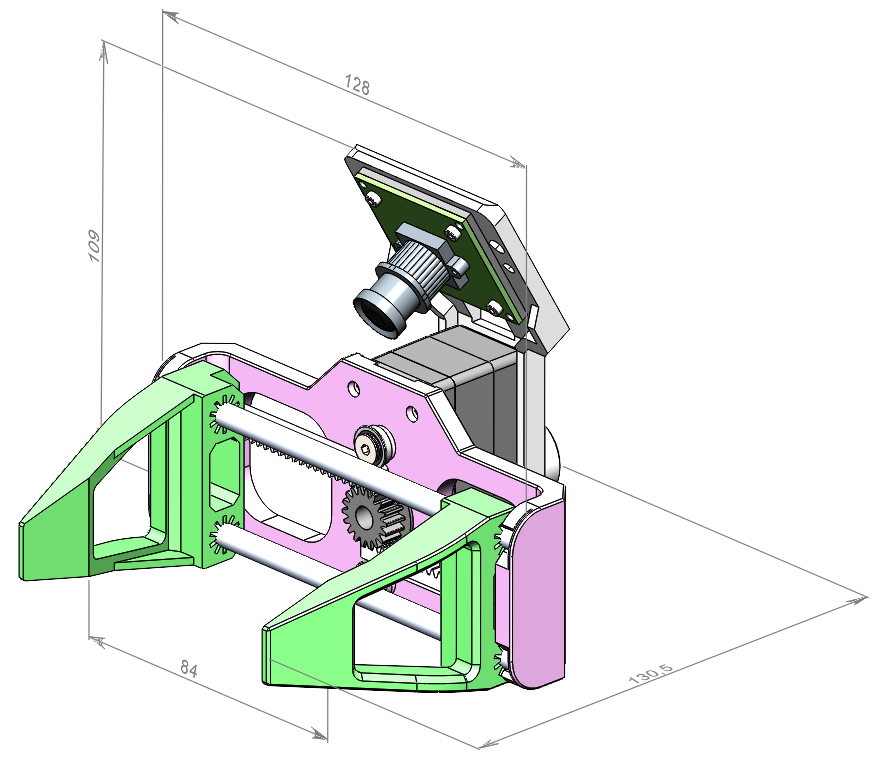
*128 × 109 × 130.5 mm, full stroke 84 mm*
---
## 📋 Specifications
### Gripper Parameters
| Parameter | Value |
|-----------|-------|
| Maximum gripping force | **120 N** |
| Maximum gripping speed | **14 mm/s** |
| Full stroke | **84 mm** |
| Repeatability | **0.5 mm** |
| Assembly mass (PLA, 30% infill) | **170 g** |
| DOF | **1** |
### Dimensions
| Dimension | Value |
|-----------|-------|
| Width | 128 mm |
| Depth | 130.5 mm |
| Height | 109 mm |
### Servo Parameters (Feetech STS3215)
| Parameter | Value |
|-----------|-------|
| Operating Voltage | 12V |
| Stall torque | 30 kg·cm |
| Speed (no load) | 45 RPM |
| Encoder | Absolute magnetic 12-bit |
| Protocol | RS485/TTL up to 1 Mbps |
| Operating temperature | -20°C ~ 60°C |
---
## 📷 Camera Compatibility
The gripper supports multiple cameras via interchangeable camera holder:
| Camera | Type | Use Case |
|--------|------|----------|
| IMX335 5MP USB | RGB | Basic vision tasks |
| GC2093 2MP USB | RGB | Budget option |
| Orbbec Gemini 2 | RGB-D | 3D perception |
| RealSense D405 | RGB-D | Close-range depth |
| RealSense D435/D435i | RGB-D | General purpose |
| RealSense D455 | RGB-D | Long-range depth |
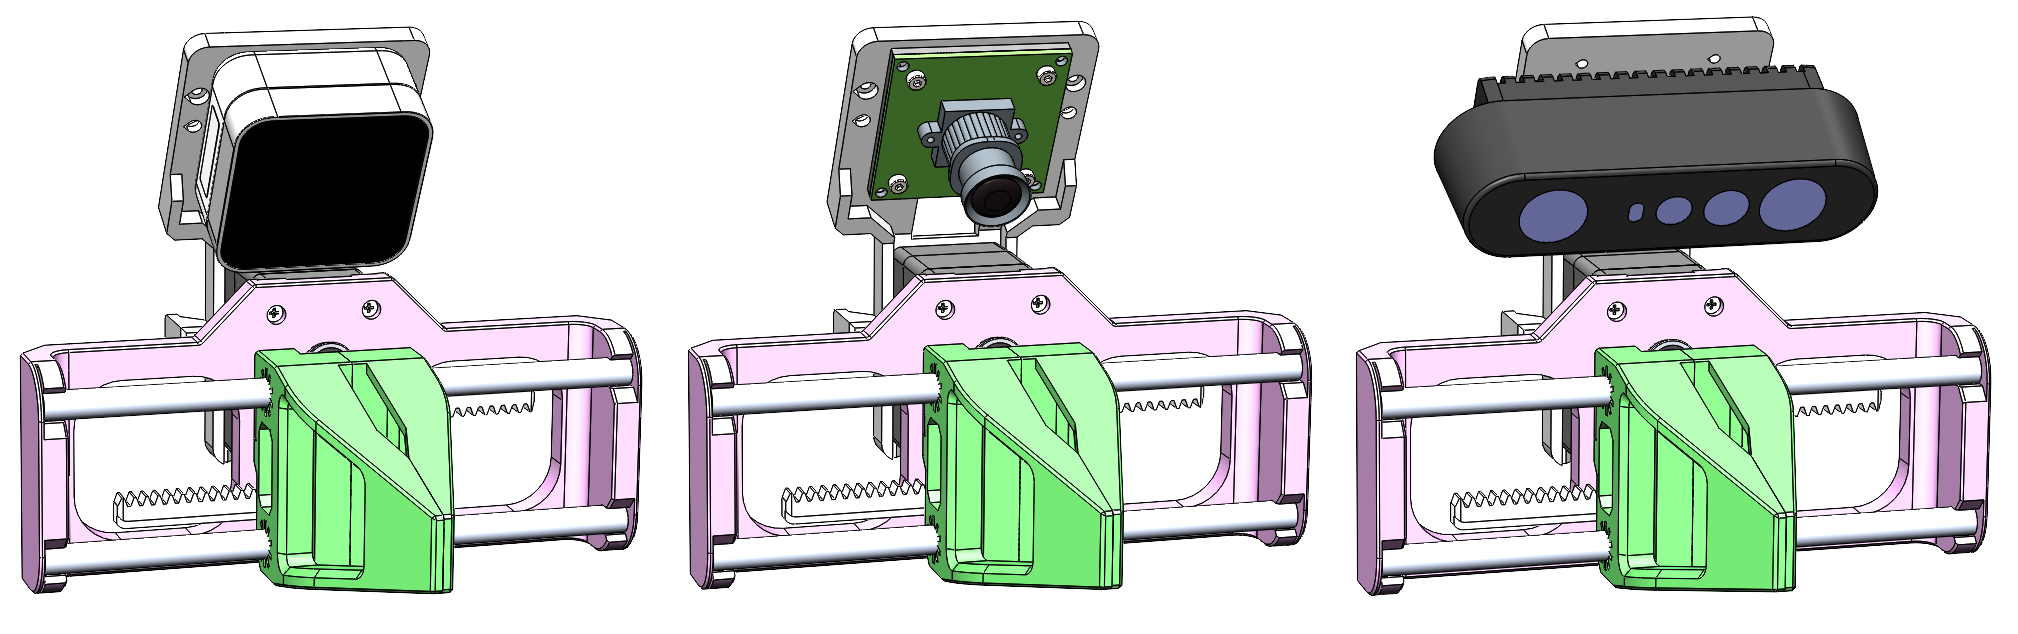
*RealSense, USB camera module, Orbbec Gemini 2*
---
## 💰 Bill of Materials
**Total Cost: ~$50** ([Full BOM with Amazon links](docs/bom.md))
| Category | Components | Est. Cost |
|----------|------------|-----------|
| Electronics | Feetech STS3215 Servo | ~$29 |
| Bearings | MF106ZZ (x2) | ~$2 |
| Aluminium/Carbon Tubes | D6x1×125mm (x2) | ~$4 |
| 3D Printing | 8 parts (~100-150g PLA) | ~$12 |
| Fasteners | M2/M4 screws, M2 nuts, M3 set screws | ~$3 |
---
## 🚀 Quick Start
For a complete robot arm kit with a parallel gripper, **[buy the SO-ARM102 kit](https://robonine.com/shop/so-arm102-robotic-arm-kit/)**. To build the SO-ARM100/101 gripper yourself, follow the steps below.
### 1. Print the Parts (2-4 hours)
Download STL files from [`models/parts/`](models/). Compatible with popular printers like **Bambu Lab A1 mini**, **Prusa MINI+**, and any printer with ≥180×180mm bed.
| Part | Qty | Settings |
|------|:---:|----------|
| Main frame (RB9.01.062.010) | 1 | 20% infill |
| Clamp (RB9.01.062.020) | 2 | 20% infill |
| Gear rack (RB9.01.062.030) | 2 | 100% infill |
| Gear (RB9.01.062.040) | 1 | 100% infill |
| Camera holder (RB9.01.060.074) | 1 | 20% infill |
| Holder (RB9.01.060.080) | 1 | 20% infill |
| Camera Spacer (RB9.01.060.090) | 1 | 20% infill |
| D405 holder (RB9.01.060.110) | 1 | 20% infill |
### 2. Order Components (1-2 days)
See [Bill of Materials](docs/bom.md) for direct Amazon links.
### 3. Assemble (30-45 minutes)
Follow the [Assembly Guide](docs/assembly-guide.md) with step-by-step images:
1. Mount gear on servo disc, install this assembly on servo
2. Insert servo cable
3. Using Feetech software move servo to its minimal position (move the slider in the software to the left)
4. Attach gear racks to clamps
5. Inserts the rods into both clamps
6. Install bearings on main frame and fix with srews
7. Snap the rods into the frame
8. Spread the clamps to the extreme positions on the left and right
9. Insert servo and fix it with screws
10. Attach Camera Spacer and UVC camera, fix with 4x screws and nuts M2 (optional)
11. Mount to robot arm (optional)
### 4. Software
```bash
# Configure servo motor if necessary
https://lab.robonine.com/tools/robonine/feetech-bus
# Control gripper
https://lab.robonine.com/tools/robonine/control-robot
```
---
## 📁 Repository Structure
```
├── assets/
│ └── images/
│ ├── assembly/ # Assembly step images
│ └── specification/ # Technical drawings
├── docs/
│ ├── assembly-guide.md # Step-by-step assembly
│ ├── bom.md # Bill of materials with links
│ ├── Parallel gripper by Robo9.pdf # Gripper product specification
│ ├── quick-start.md # Getting started guide
│ ├── SO-ARM101 by Robo9.pdf # SO-ARM101 product specification
│ └── specifications.md # Technical specifications
├── models/
│ ├── parts/ # Individual STL files
│ └── Follower gripper (165x165 bed size).STL # Complete assembly (165×165mm bed)
├── community/
│ └── histology-slide-gripper/ # Community variant (CAD, MuJoCo model)
├── simulation/
│ ├── README.md # Simulation overview
│ ├── gazebo/ # Gazebo guide
│ ├── mujoco/ # MuJoCo guide
│ ├── webots/ # Webots guide
│ ├── coppeliasim/ # CoppeliaSim guide
│ ├── isaac_sim/ # Isaac Sim guide
│ └── so_arm_101_description/ # ROS2 package (URDF, launch, Docker)
├── software/
│ └── python/ # Control software
├── examples/ # Usage examples
├── HARDWARE-LICENSE.txt # CERN-OHL-P-2.0 (CAD, geometry)
├── SOFTWARE-LICENSE.txt # Apache-2.0 (code)
├── DOCS-LICENSE.txt # CC BY 4.0 (docs, images)
├── LICENSING.md # Which licence covers what
├── NOTICE # Third-party attribution
├── REUSE.toml # Machine-readable licence map
├── RELICENSING.md # Record of the 2026 relicensing
└── CONTRIBUTING.md
```
---
## 📖 Documentation
| Document | Description |
|----------|-------------|
| [Quick Start Guide](docs/quick-start.md) | Get running in 30 minutes |
| [Assembly Guide](docs/assembly-guide.md) | Step-by-step with images |
| [Gripper Assembly Guide (PDF)](docs/Assembly%20Guide%20Follower%20Gripper.pdf) | Printable gripper assembly instructions |
| [SO-ARM101 Assembly Guide (PDF)](docs/Assembly%20Guide%20SO-ARM101.pdf) | Full SO-ARM101 arm assembly instructions |
| [Bill of Materials](docs/bom.md) | Parts list with Amazon links |
| [Specifications](docs/specifications.md) | Technical details |
| [3D Models](models/README.md) | Print settings and files |
| [Parallel Gripper Product Spec (PDF)](docs/Parallel%20gripper%20by%20Robo9.pdf) | Parallel gripper product specification by Robo9 |
| [SO-ARM101 Product Spec (PDF)](docs/SO-ARM101%20by%20Robo9.pdf) | SO-ARM101 robot arm product specification by Robo9 |
---
## 🔧 Hardware Requirements
### Electronics
- 1× Feetech STS3215 Servo Motor
Connect the gripper to the existing SO-ARM100/101 servo bus and controller.
The robot controller and power supply are part of the arm setup, outside the gripper BOM.
### Mechanical
- 2× MF106ZZ Bearings (6×10×3 mm)
- 2× Aluminium/Carbon Tubes D6x1×125 mm
### Fasteners
- 2× M4×8 DIN 7991 screws
- 4x M2x8 DIN 912 screws
- 4× M2 DIN 934 nuts
- 4× M3×4 DIN 913 set screws
### Tools Required
- Phillips head screwdriver (PH1)
- Hex keys M2 (H1.5) and M4 (H2.5)
---
## 🖥️ Simulation
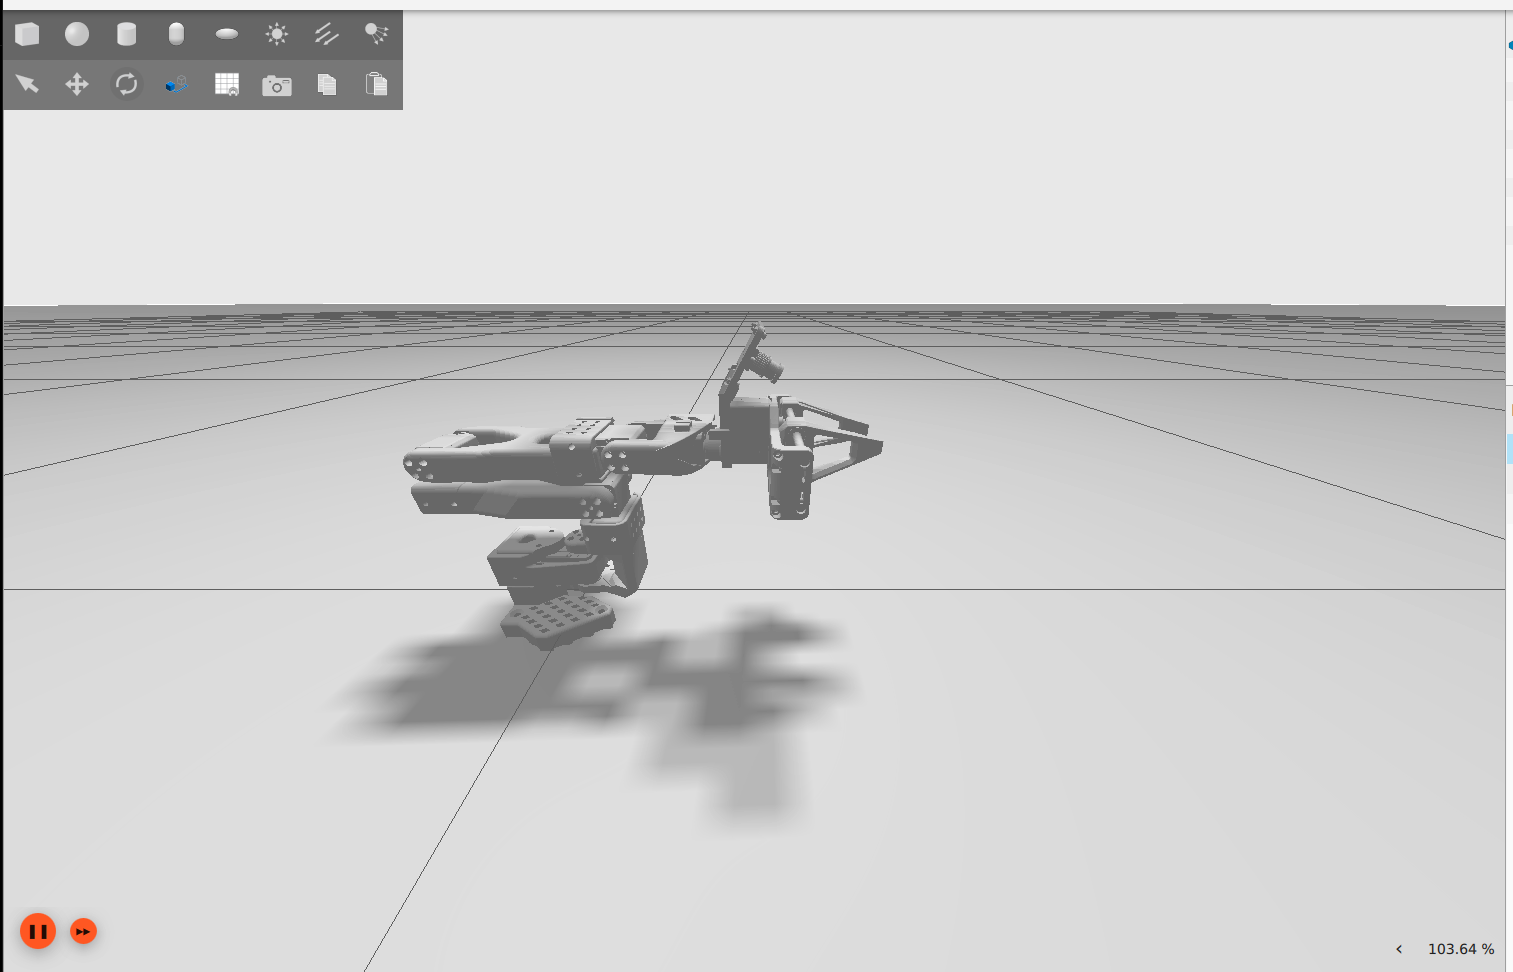
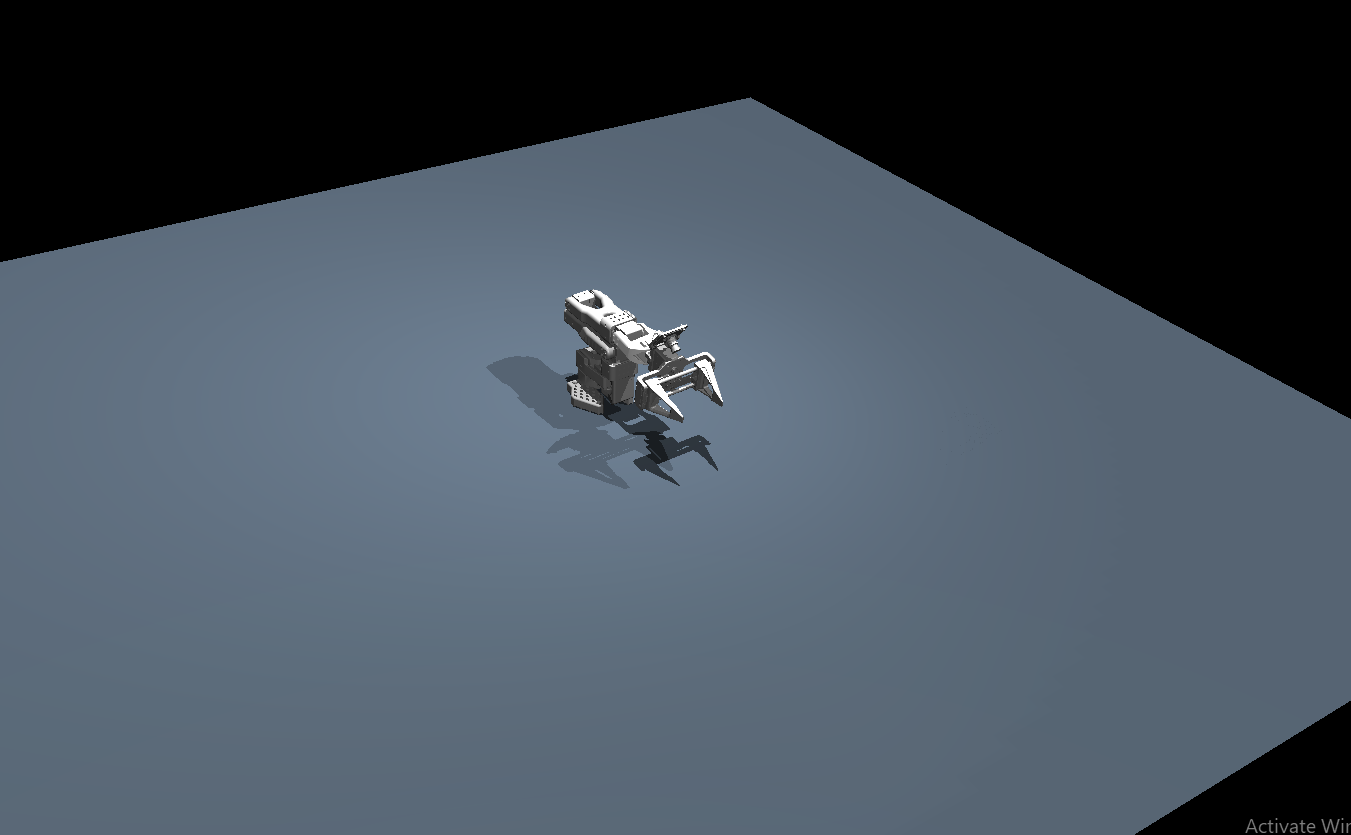
The SO-ARM101 can be simulated in 5 physics engines using a ROS2 description package with a single parameterized URDF. No ROS2 installation required -- Docker handles everything.
| Gazebo (Ignition Fortress) | MuJoCo |
|:-:|:-:|
|  |  |
| Simulator | Status | Docker |
|-----------|--------|--------|
| [Gazebo](simulation/gazebo/README.md) | Ready | `docker compose run gazebo` |
| [MuJoCo](simulation/mujoco/README.md) | Ready | `docker compose run mujoco` |
| [Webots](simulation/webots/README.md) | Unstable | `docker compose run webots` |
| [CoppeliaSim](simulation/coppeliasim/README.md) | Not tested | External simulator |
| [NVIDIA Isaac Sim](simulation/isaac_sim/README.md) | Not tested | External simulator |
**Quick start (Docker):**
```bash
cd simulation/so_arm_101_description
docker compose run gazebo # or mujoco, webots
```
See the [Simulation Guide](simulation/README.md) for full setup, architecture details, and robot commanding.
---
## 🔬 Community Mods
Variants of the gripper built by the community, each self-contained in [`community/`](community/):
| Mod | Author | Description |
|-----|--------|-------------|
| [Histology Slide Gripper](community/histology-slide-gripper/) | [Michael Viacheslavov](https://github.com/histochemichael) | Clamps for 75 x 25 mm microscope slides and staining dippers/racks, plus an angled Arducam holder for monitoring the grasp. |
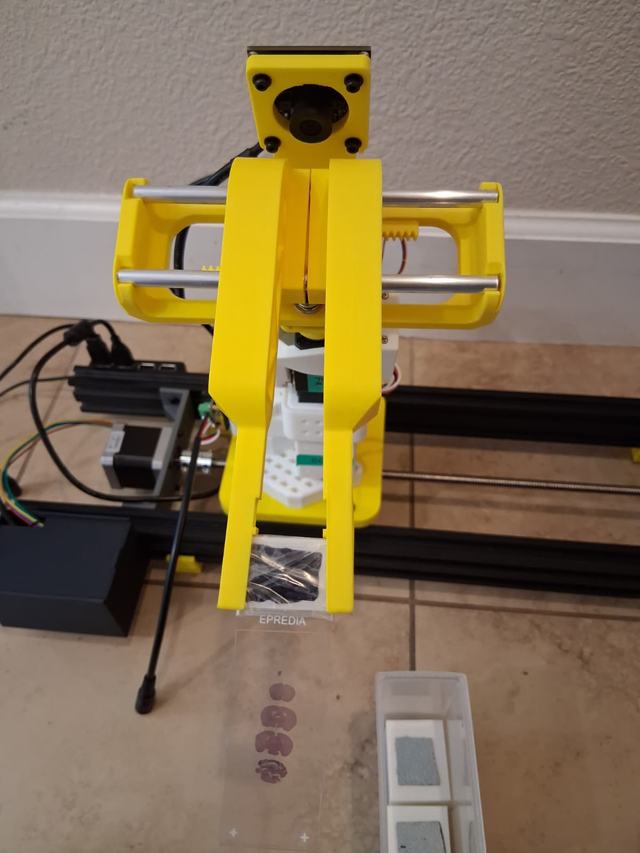
*Histology Slide Gripper mod — click for full description, CAD files, and demo*
---
## ⭐ Star History
[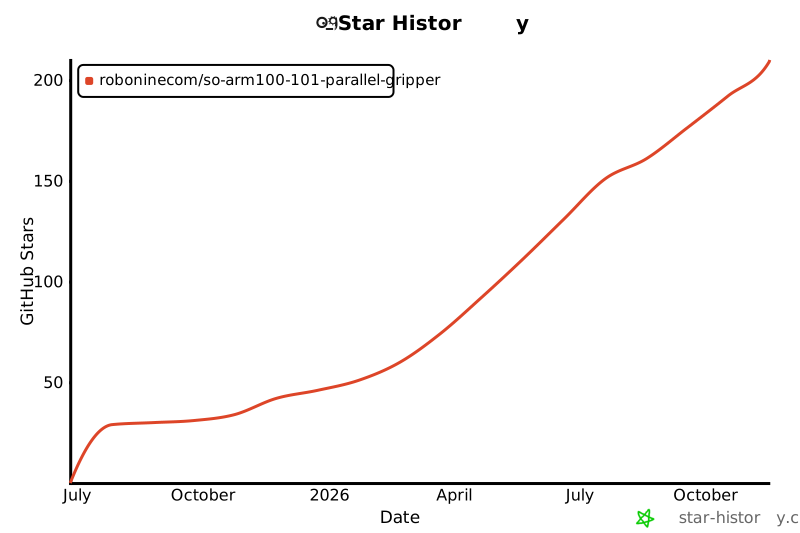](https://www.star-history.com/?repos=roboninecom%2Fso-arm100-101-parallel-gripper&type=date&legend=top-left)
---
## 🤝 Contributing
We welcome contributions! Please feel free to:
- 🐛 Report bugs and issues
- 💡 Suggest new features
- 🔧 Submit pull requests
- 📖 Improve documentation
---
## 📄 License
Copyright (c) 2025 Robonine. This project is multi-licensed — different kinds of
material carry different licences:
| Material | Licence |
|---|---|
| Hardware designs — `models/`, community CAD, gripper meshes | [CERN-OHL-P-2.0](HARDWARE-LICENSE.txt) |
| Software — `software/`, `examples/`, `simulation/`, simulation code in `community/` | [Apache-2.0](SOFTWARE-LICENSE.txt) |
| Documentation and images — `docs/`, `assets/`, all `README.md` | [CC BY 4.0](DOCS-LICENSE.txt) |
See [`LICENSING.md`](LICENSING.md) for the exact file-by-file map and
[`REUSE.toml`](REUSE.toml) for the machine-readable version.
**Not everything here is Robonine's work.** The SO-ARM101 arm meshes are derived
from [TheRobotStudio's upstream project](https://github.com/TheRobotStudio/SO-ARM100)
and remain Apache-2.0; the histology slide gripper was contributed by
[@histochemichael](https://github.com/histochemichael). See [`NOTICE`](NOTICE)
before reusing any mesh.
Releases up to and including `v0.3.1` were published under GPL-3.0 and remain
available under those terms — see [`RELICENSING.md`](RELICENSING.md).
---
## 🔗 Links
- [Feetech STS3215 Servo](https://www.feetechrc.com/525603.html)
- [STServo Python SDK](https://github.com/FEETECH-RC/STServo_SDK_Python)
---
## 👥 Engineering Team
| Name | Role | Contact |
|------|------|---------|
| **Boris Kotov** | Software Engineer | [Telegram](https://t.me/bkotov) |
| **Alan Subin** | Design Engineer | [LinkedIn](https://www.linkedin.com/in/alan-subin/) |
---
**Built for the robotics community by [Robonine](https://robonine.com)** 🤖
**Questions? We're here to help!**
📩 Email: [hello@robonine.com](mailto:hello@robonine.com)