# Isaac Sim MCP Server
[](https://pypi.org/project/isaacsim-mcp-server/)
[](https://developer.nvidia.com/isaac-sim)
[](https://www.python.org/downloads/)
[](https://opensource.org/licenses/MIT)
[](https://archestra.ai/mcp-catalog/api/badge/quality/whats2000/isaacsim-mcp-server)
[](https://glama.ai/mcp/servers/whats2000/isaacsim-mcp-server)
> Natural language control for NVIDIA Isaac Sim through the [Model Context Protocol](https://modelcontextprotocol.io/) (MCP).
Connect any MCP-compatible IDE (Cursor, VS Code, Claude Code, Windsurf, Antigravity, JetBrains) to a running Isaac Sim instance and control it with plain-English prompts -- create robots, build scenes, run simulations, and debug physics all from your editor.
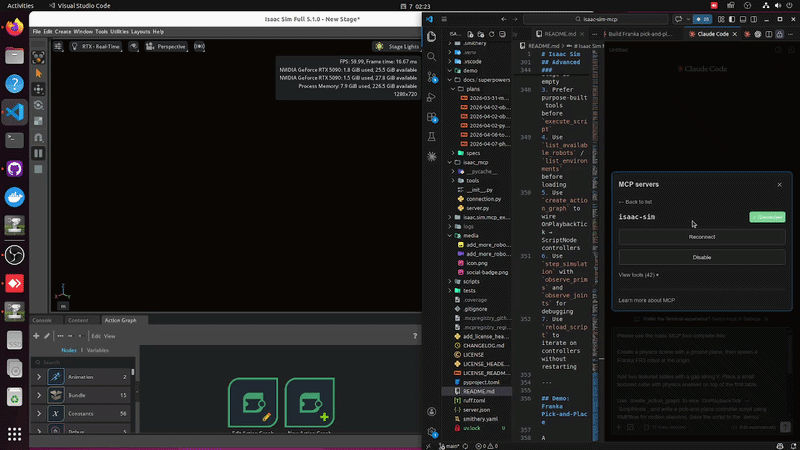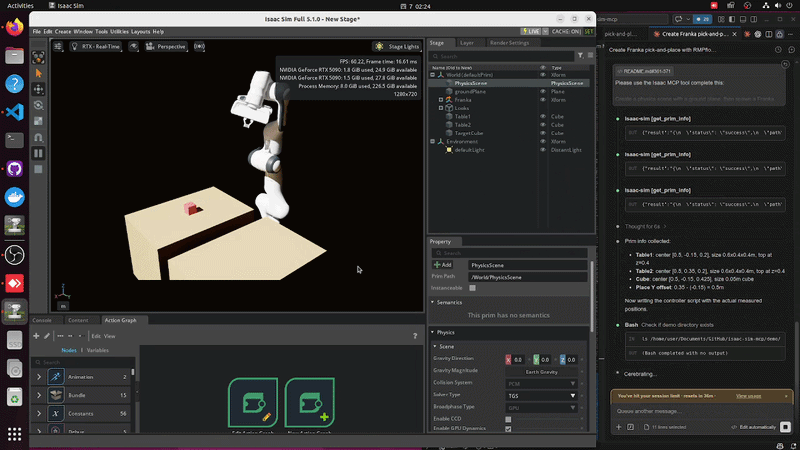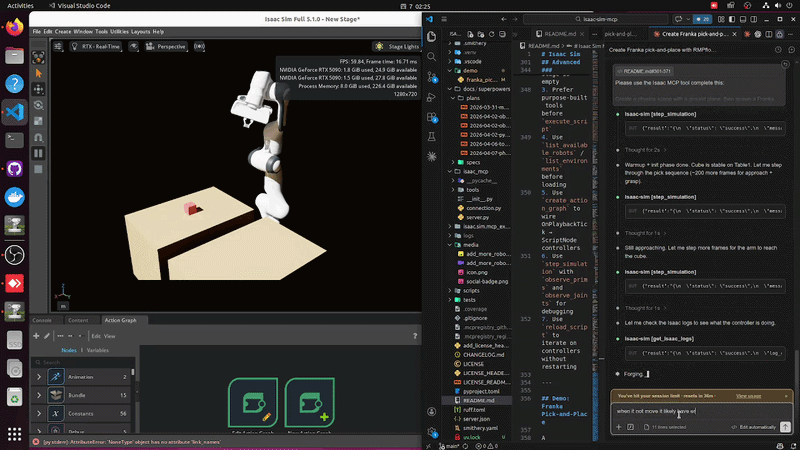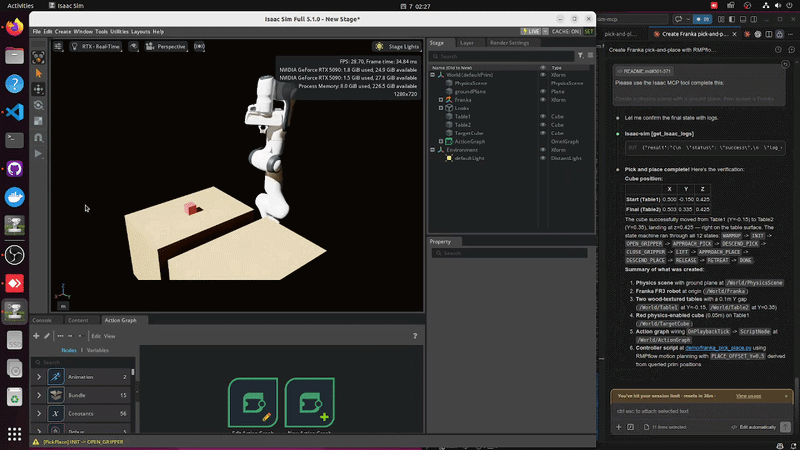
---
## Highlights
- **43 tools** across 9 categories -- scene, objects, lighting, robots, sensors, materials, assets, simulation, graphs
- **107+ robots** auto-discovered from the Isaac Sim asset library (Franka, UR, Unitree, Boston Dynamics, and more)
- **Step-and-observe** debugging -- step the simulation and inspect prim positions, joint states, and physics in one call
- **Hot-reload** -- iterate on Python controllers without restarting Isaac Sim
- **Multi-instance** -- run multiple Isaac Sim sessions side by side on different ports
- Built for **Isaac Sim 5.1.0 - 6.0.1** (PhysX + Newton) with a modular adapter layer for version isolation
---
## Installation
### Option A: pip install (recommended)
```bash
pip install isaacsim-mcp-server
```
This installs the MCP server and the `isaacsim-mcp-server` CLI. You still need the Isaac Sim extension from the repo (see [Launching Isaac Sim](#2-launch-isaac-sim-with-the-extension) below).
### Option B: From source
```bash
git clone https://github.com/whats2000/isaacsim-mcp-server
cd isaacsim-mcp-server
./scripts/setup_python_env.sh
```
### Requirements
| Requirement | Version |
|-------------|---------|
| NVIDIA Isaac Sim | `5.1.0` - `6.0.1` (PhysX or Newton) |
| Python | `3.10+` |
| `uv` | latest (for source install) |
| Platform | Linux (Ubuntu 22.04+) or Windows 10/11 |
> [!IMPORTANT]
> **Linux** and **Windows** are supported. On Windows, use the PowerShell
> launcher `scripts/run_isaac_sim.ps1` in place of the `.sh` scripts (see below).
> macOS is not supported because NVIDIA Isaac Sim does not run on macOS.
> [!NOTE]
> We are welcoming contributions to support other Isaac Sim versions.
> The adapter layer is designed for easy version isolation.
---
## Quick Start
### 1. Set up the environment
If you installed from source:
```bash
./scripts/setup_python_env.sh
```
**On Windows**, `uv sync` creates the virtual environment (`.venv`) and installs
the package plus its dependencies:
```powershell
uv sync
```
### 2. Launch Isaac Sim with the extension
```bash
./scripts/run_isaac_sim.sh
```
You should see in the logs:
```
Registered 43 command handlers
Isaac Sim MCP server started on localhost:8766
```
The script looks for Isaac Sim in `$HOME/isaacsim`; set `ISAACSIM_ROOT` to use a
different install.
**Choosing the physics engine.** Isaac Sim 6.0+ ships PhysX (default) and Newton
backends. Select one with `--newton` / `--physx`, or `ISAACSIM_ENGINE`:
```bash
./scripts/run_isaac_sim.sh # PhysX (default)
./scripts/run_isaac_sim.sh --newton # Newton
ISAACSIM_ENGINE=newton ./scripts/run_isaac_sim.sh
```
The same flags work with `scripts/launch_isaac_sim_mcp.sh`. Everything else on
the command line is forwarded to Kit untouched. The server auto-detects the
active engine, so no MCP-side configuration changes. Newton requires 6.0 or
newer; asking for it on 5.1.0 fails with a clear message.
**On Windows**, use the PowerShell launcher instead. It takes the same engine
selection and forwards extra arguments to Kit:
```powershell
.\scripts\run_isaac_sim.ps1 # PhysX (default)
.\scripts\run_isaac_sim.ps1 -Engine newton # Newton
$env:ISAACSIM_ENGINE = 'newton'; .\scripts\run_isaac_sim.ps1
```
The script resolves the install from `-IsaacSimRoot`, then `$env:ISAACSIM_ROOT`,
then a local source build, then `C:\isaacsim`, then `%USERPROFILE%\isaacsim`. It
also creates a writable USD working directory (`.cache\usd`) since Windows has no
`/tmp`.
Optional: Beaver3D / NVIDIA API keys for 3D generation
```bash
export BEAVER3D_MODEL=""
export ARK_API_KEY=""
export NVIDIA_API_KEY=""
```
On Windows (PowerShell):
```powershell
$env:BEAVER3D_MODEL = ""
$env:ARK_API_KEY = ""
$env:NVIDIA_API_KEY = ""
```
### 3. Connect your IDE
Add the MCP server to your editor. Replace the path with your actual repo location.
The `command` examples are for **Linux/macOS**; each guide shows the **Windows**
equivalent, which wraps the PowerShell launcher `scripts\run_mcp_server.ps1`.
Claude Code (CLI)
```bash
claude mcp add isaac-sim /path/to/isaacsim-mcp-server/scripts/run_mcp_server.sh
```
Or edit `~/.claude.json` / `.mcp.json`:
```json
{
"mcpServers": {
"isaac-sim": {
"command": "/path/to/isaacsim-mcp-server/scripts/run_mcp_server.sh"
}
}
}
```
On Windows, wrap the PowerShell launcher:
```bash
claude mcp add isaac-sim -- powershell -NoProfile -ExecutionPolicy Bypass -File C:\path\to\isaacsim-mcp-server\scripts\run_mcp_server.ps1
```
```json
{
"mcpServers": {
"isaac-sim": {
"command": "powershell",
"args": ["-NoProfile", "-ExecutionPolicy", "Bypass", "-File", "C:\\path\\to\\isaacsim-mcp-server\\scripts\\run_mcp_server.ps1"]
}
}
}
```
VS Code
Create `.vscode/mcp.json` in your workspace:
```json
{
"servers": {
"isaac-sim": {
"command": "/path/to/isaacsim-mcp-server/scripts/run_mcp_server.sh"
}
}
}
```
On Windows, wrap the PowerShell launcher:
```json
{
"servers": {
"isaac-sim": {
"command": "powershell",
"args": ["-NoProfile", "-ExecutionPolicy", "Bypass", "-File", "C:\\path\\to\\isaacsim-mcp-server\\scripts\\run_mcp_server.ps1"]
}
}
}
```
Cursor
Open **Cursor Settings > MCP**, or edit `~/.cursor/mcp.json`:
```json
{
"mcpServers": {
"isaac-sim": {
"command": "/path/to/isaacsim-mcp-server/scripts/run_mcp_server.sh"
}
}
}
```
On Windows, wrap the PowerShell launcher:
```json
{
"mcpServers": {
"isaac-sim": {
"command": "powershell",
"args": ["-NoProfile", "-ExecutionPolicy", "Bypass", "-File", "C:\\path\\to\\isaacsim-mcp-server\\scripts\\run_mcp_server.ps1"]
}
}
}
```
Claude Desktop
Edit the config file for your platform:
- macOS: `~/Library/Application Support/Claude/claude_desktop_config.json`
- Windows: `%APPDATA%\Claude\claude_desktop_config.json`
- Linux: `~/.config/Claude/claude_desktop_config.json`
```json
{
"mcpServers": {
"isaac-sim": {
"command": "/path/to/isaacsim-mcp-server/scripts/run_mcp_server.sh"
}
}
}
```
On Windows, wrap the PowerShell launcher:
```json
{
"mcpServers": {
"isaac-sim": {
"command": "powershell",
"args": ["-NoProfile", "-ExecutionPolicy", "Bypass", "-File", "C:\\path\\to\\isaacsim-mcp-server\\scripts\\run_mcp_server.ps1"]
}
}
}
```
Windsurf
Open **Windsurf Settings > MCP** or edit `~/.codeium/windsurf/mcp_config.json`:
```json
{
"mcpServers": {
"isaac-sim": {
"command": "/path/to/isaacsim-mcp-server/scripts/run_mcp_server.sh"
}
}
}
```
On Windows, wrap the PowerShell launcher:
```json
{
"mcpServers": {
"isaac-sim": {
"command": "powershell",
"args": ["-NoProfile", "-ExecutionPolicy", "Bypass", "-File", "C:\\path\\to\\isaacsim-mcp-server\\scripts\\run_mcp_server.ps1"]
}
}
}
```
Antigravity
Open the agent side panel, click **…** > **MCP Servers** > **Manage MCP Servers** >
**View raw config**, or edit `~/.gemini/config/mcp_config.json` (global) or
`.agents/mcp_config.json` (workspace):
```json
{
"mcpServers": {
"isaac-sim": {
"command": "/path/to/isaacsim-mcp-server/scripts/run_mcp_server.sh"
}
}
}
```
On Windows, wrap the PowerShell launcher:
```json
{
"mcpServers": {
"isaac-sim": {
"command": "powershell",
"args": ["-NoProfile", "-ExecutionPolicy", "Bypass", "-File", "C:\\path\\to\\isaacsim-mcp-server\\scripts\\run_mcp_server.ps1"]
}
}
}
```
JetBrains IDEs
Go to **Settings > Tools > AI Assistant > MCP Servers** and add the server, with
the command `/path/to/isaacsim-mcp-server/scripts/run_mcp_server.sh`. See the
[JetBrains MCP docs](https://www.jetbrains.com/help/ai-assistant/configure-an-mcp-server.html) for details.
On Windows, set the command to `powershell` and the arguments to
`-NoProfile -ExecutionPolicy Bypass -File C:\path\to\isaacsim-mcp-server\scripts\run_mcp_server.ps1`.
### 4. Start prompting
```text
Check the connection with get_scene_info.
If the scene is empty, create a physics scene.
Add a Franka robot at the origin and a Go1 quadruped at [2, 0, 0].
```
---
## Architecture
```text
MCP Client (IDE)
|
v
isaacsim-mcp-server (PyPI package / CLI)
|
v TCP socket (localhost:8766)
|
isaac.sim.mcp_extension (Omniverse extension)
|
v
Handlers -> Adapter -> Isaac Sim 5.1 / 6.0 APIs
```
---
## Tools
43 tools across 9 categories:
| Category | Count | What you can do |
|----------|------:|-----------------|
| **Scene** | 7 | Inspect scenes, create physics, list/load environments, browse prims |
| **Objects** | 4 | Create, delete, transform, and clone primitives |
| **Lighting** | 2 | Create and tune lights |
| **Robots** | 6 | Spawn 107+ robots, inspect joints, set positions, refresh library |
| **Sensors** | 4 | Create cameras/LiDAR, capture images, get point clouds |
| **Materials** | 2 | Create and apply materials |
| **Assets** | 4 | Import URDF, load/search USD, generate 3D models |
| **Graphs** | 2 | Build and edit Action Graphs (OnPlaybackTick, ScriptNode, script file attachment) |
| **Simulation** | 11 | Play/pause/stop/step, execute Python, inspect physics, hot-reload |
Full tool list
**Scene:** `get_scene_info` `create_physics_scene` `clear_scene` `list_prims` `get_prim_info` `list_environments` `load_environment`
**Objects:** `create_object` `delete_object` `transform_object` `clone_object`
**Lighting:** `create_light` `modify_light`
**Robots:** `create_robot` `list_available_robots` `refresh_robot_library` `get_robot_info` `set_joint_positions` `get_joint_positions`
**Sensors:** `create_camera` `capture_image` `create_lidar` `get_lidar_point_cloud`
**Materials:** `create_material` `apply_material`
**Assets:** `import_urdf` `load_usd` `search_usd` `generate_3d`
**Graphs:** `create_action_graph` `edit_action_graph`
**Simulation:** `play_simulation` `pause_simulation` `stop_simulation` `step_simulation` `set_physics_params` `get_isaac_logs` `get_simulation_state` `get_physics_state` `get_joint_config` `set_drive_params` `execute_script` `reload_script`
---
## Known Limitations
Open defects a normal session can hit. Each is warned about at the
point of use where that is possible; this list is for choosing a runtime before
you start.
| Affects | What happens | Issue |
|---|---|---|
| 6.0 Newton | Joint drives do not converge — a commanded target is overshot and the joint keeps going, and joint limits are not enforced. Scene setup, stepping and inspection are fine; run motion work on PhysX (`isaac-sim.sh`). | [#21](https://github.com/whats2000/isaacsim-mcp-server/issues/21) |
| 6.0 | The first RTX camera created in a session cannot be removed. `create_camera` warns once when it hands you that camera. | [#20](https://github.com/whats2000/isaacsim-mcp-server/issues/20) |
| 5.1 | `get_lidar_point_cloud` fills on roughly a third of reads, so a caller must retry. A lidar created while the timeline is running never fills at all — create it stopped. | [#31](https://github.com/whats2000/isaacsim-mcp-server/issues/31) |
| 5.1 | An RTX lidar prim cannot be deleted; the prim is left behind as a `Camera`. `create_lidar` refuses such a path and names a free one. | [#25](https://github.com/whats2000/isaacsim-mcp-server/issues/25) |
---
## Example Prompts
**Scene bootstrap**
```text
Check the connection with get_scene_info. If the scene is empty, create a physics scene.
Add stronger lighting and place a camera that looks at the workspace.
```
**Robot layout**
```text
Create three Franka robots in a row at [0,0,0], [2,0,0], and [4,0,0].
Then add a Go1 robot at [1, 3, 0].
```
**Environment loading**
```text
List available environments, choose a warehouse-like one, and load it.
Create a camera and capture an image.
```
**Asset search and 3D generation**
```text
Search for a rusty desk, load the best result near [0, 5, 0], scaled to [2, 2, 2].
```
---
## Advanced Usage
### Multiple Instances
Run multiple Isaac Sim sessions side by side. Each uses a different port (auto-assigned from `8766`).
```bash
# First instance (default port 8766)
claude mcp add isaac-sim /path/to/isaacsim-mcp-server/scripts/run_mcp_server.sh
# Second instance (port 8767)
claude mcp add isaac-sim-2 -e ISAAC_MCP_PORT=8767 -- /path/to/isaacsim-mcp-server/scripts/run_mcp_server.sh
```
JSON config for multiple instances
```json
{
"mcpServers": {
"isaac-sim": {
"command": "/path/to/isaacsim-mcp-server/scripts/run_mcp_server.sh"
},
"isaac-sim-2": {
"command": "/path/to/isaacsim-mcp-server/scripts/run_mcp_server.sh",
"env": { "ISAAC_MCP_PORT": "8767" }
}
}
}
```
### Desktop Launcher (Linux)
Install a dedicated **Isaac Sim MCP** application icon:
```bash
./scripts/install_desktop_entry.sh
```
This creates a launcher that auto-assigns ports, waits for the extension socket, and cleans up on exit.
### Recommended Workflow
1. Start with `get_scene_info` to verify the connection
2. Create a physics scene if the stage is empty
3. Prefer purpose-built tools before `execute_script`
4. Use `list_available_robots` / `list_environments` before loading
5. Use `create_action_graph` to wire OnPlaybackTick → ScriptNode controllers
6. Use `step_simulation` with `observe_prims` and `observe_joints` for debugging
7. Use `reload_script` to iterate on controllers without restarting
---
## Demo: Franka Pick-and-Place
A ready-to-run demo at `demo/franka_pick_place.py` using RMPflow for motion planning:
```text
Please use the Isaac MCP tool complete this:
Create a physics scene with a ground plane, then spawn a Franka FR3 robot at the origin.
Add two textured tables with a gap along Y. Place a small textured cube with physics enabled on top of the first table.
Use `create_action_graph` to wire `OnPlaybackTick` → `ScriptNode`, and write a pick-and-place controller script using RMPflow for motion planning. Save the script to the `demo/` directory.
Use `get_prim_info` to query actual positions and sizes of the tables and cube before writing the controller — do not hardcode coordinates.
Start the simulation with Play. The robot should pick the cube from table 1 and place it on table 2. Verify the process using `step_simulation` with `observe_prims` on the cube to confirm it reaches table 2.
```
Uses `create_action_graph` with `script_file` for one-step Action Graph + ScriptNode setup, plus the observability tools: `get_joint_config`, `step_simulation` with `observe_prims`, `get_physics_state`, and `edit_action_graph` for script hot-reload.
---
## Development
```bash
# Run the MCP inspector
./.venv/bin/python -m mcp dev ./isaac_mcp/server.py
```
The inspector is available at `http://localhost:5173`.
### Setup Notes
| Script | Purpose | Default |
|--------|---------|---------|
| `setup_python_env.sh` | Create venv and install package | Python 3.10 |
| `run_isaac_sim.sh` | Launch Isaac Sim with extension (Linux) | `$HOME/isaacsim` |
| `run_isaac_sim.ps1` | Launch Isaac Sim with extension (Windows) | `C:\isaacsim` |
| `run_mcp_server.sh` | Start the MCP server (Linux) | Port 8766 |
| `run_mcp_server.ps1` | Start the MCP server (Windows) | Port 8766 |
| `launch_isaac_sim_mcp.sh` | Combined launcher | Auto-assigns port |
| `dev_mcp_server.sh` | Dev server with hot-reload | Port 8766 |
Override defaults:
```bash
PYTHON_SPEC=3.11 ./scripts/setup_python_env.sh
ISAACSIM_ROOT=/opt/isaacsim ./scripts/run_isaac_sim.sh
ISAACSIM_ENGINE=newton ./scripts/run_isaac_sim.sh
```
Engine selection lives in `scripts/lib/isaac_launcher.sh`: each engine maps to
the launcher script Isaac Sim ships for it. Adding an entry to that map is all a
new backend needs — it enables both `ISAACSIM_ENGINE=` and `--` in
every launcher script.
Troubleshooting
If Isaac Sim says `Can't find extension with name: isaac.sim.mcp_extension`:
```bash
# Make sure you're in the repo root
pwd
test -f ./isaac.sim.mcp_extension/config/extension.toml && echo OK
```
Note: `--ext-folder` must point to the **repo root**, not to `isaac.sim.mcp_extension/` directly.
---
## Contributing
Pull requests are welcome. Improvements to tools, docs, adapters, and tests are all useful.
## License
MIT License. Copyright (c) 2023-2025 omni-mcp, Copyright (c) 2026 whats2000. See [LICENSE](LICENSE).