# Robots and Maps
XXG is hidden in open-source mode and is not a selectable robot in this release. The default model is `xgb`.
[README](../README.md) | [中文](Robots_and_Maps_CN.md)
This page describes the MATRiX v1.1.2 Linux release. DLCs must match this release and its Unreal Engine build.
## Robot models
| Model key | MJCF assets | Embedded motion core | Notes |
|---|---:|---:|---|
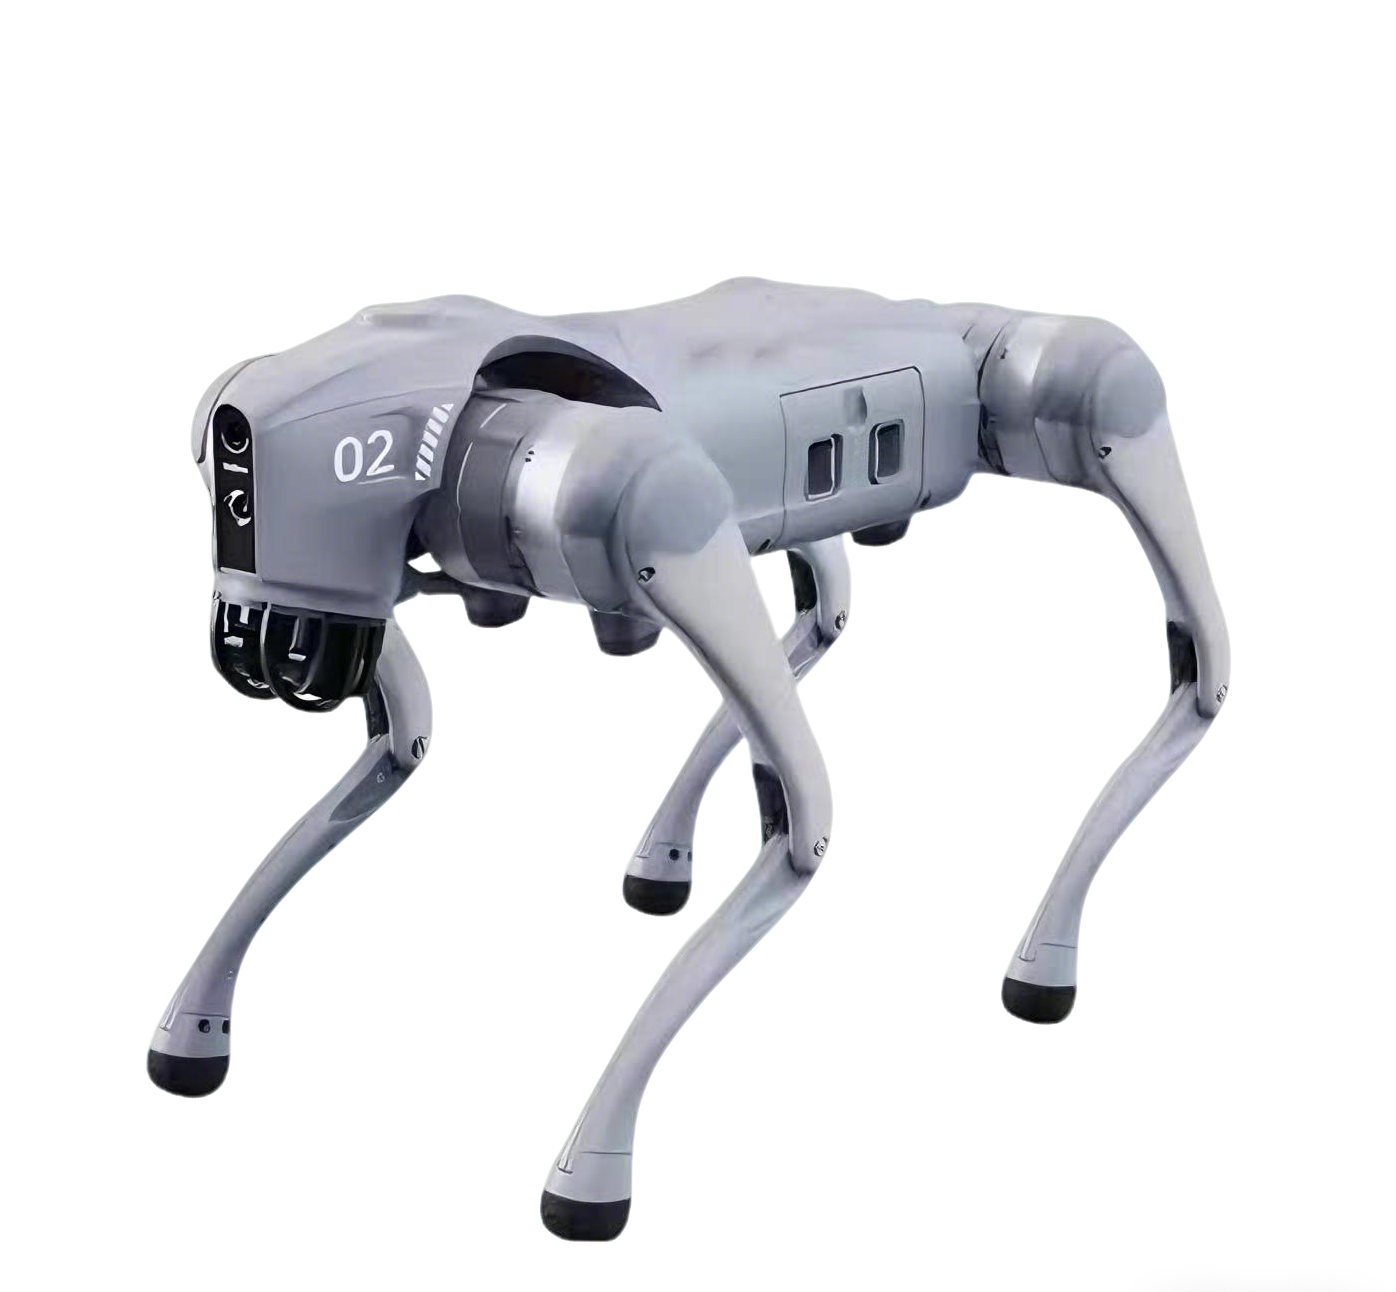
| `go2` | Yes | No | Unitree Go2 model |
| `go2w` | Yes | No | Wheeled Go2 variant |
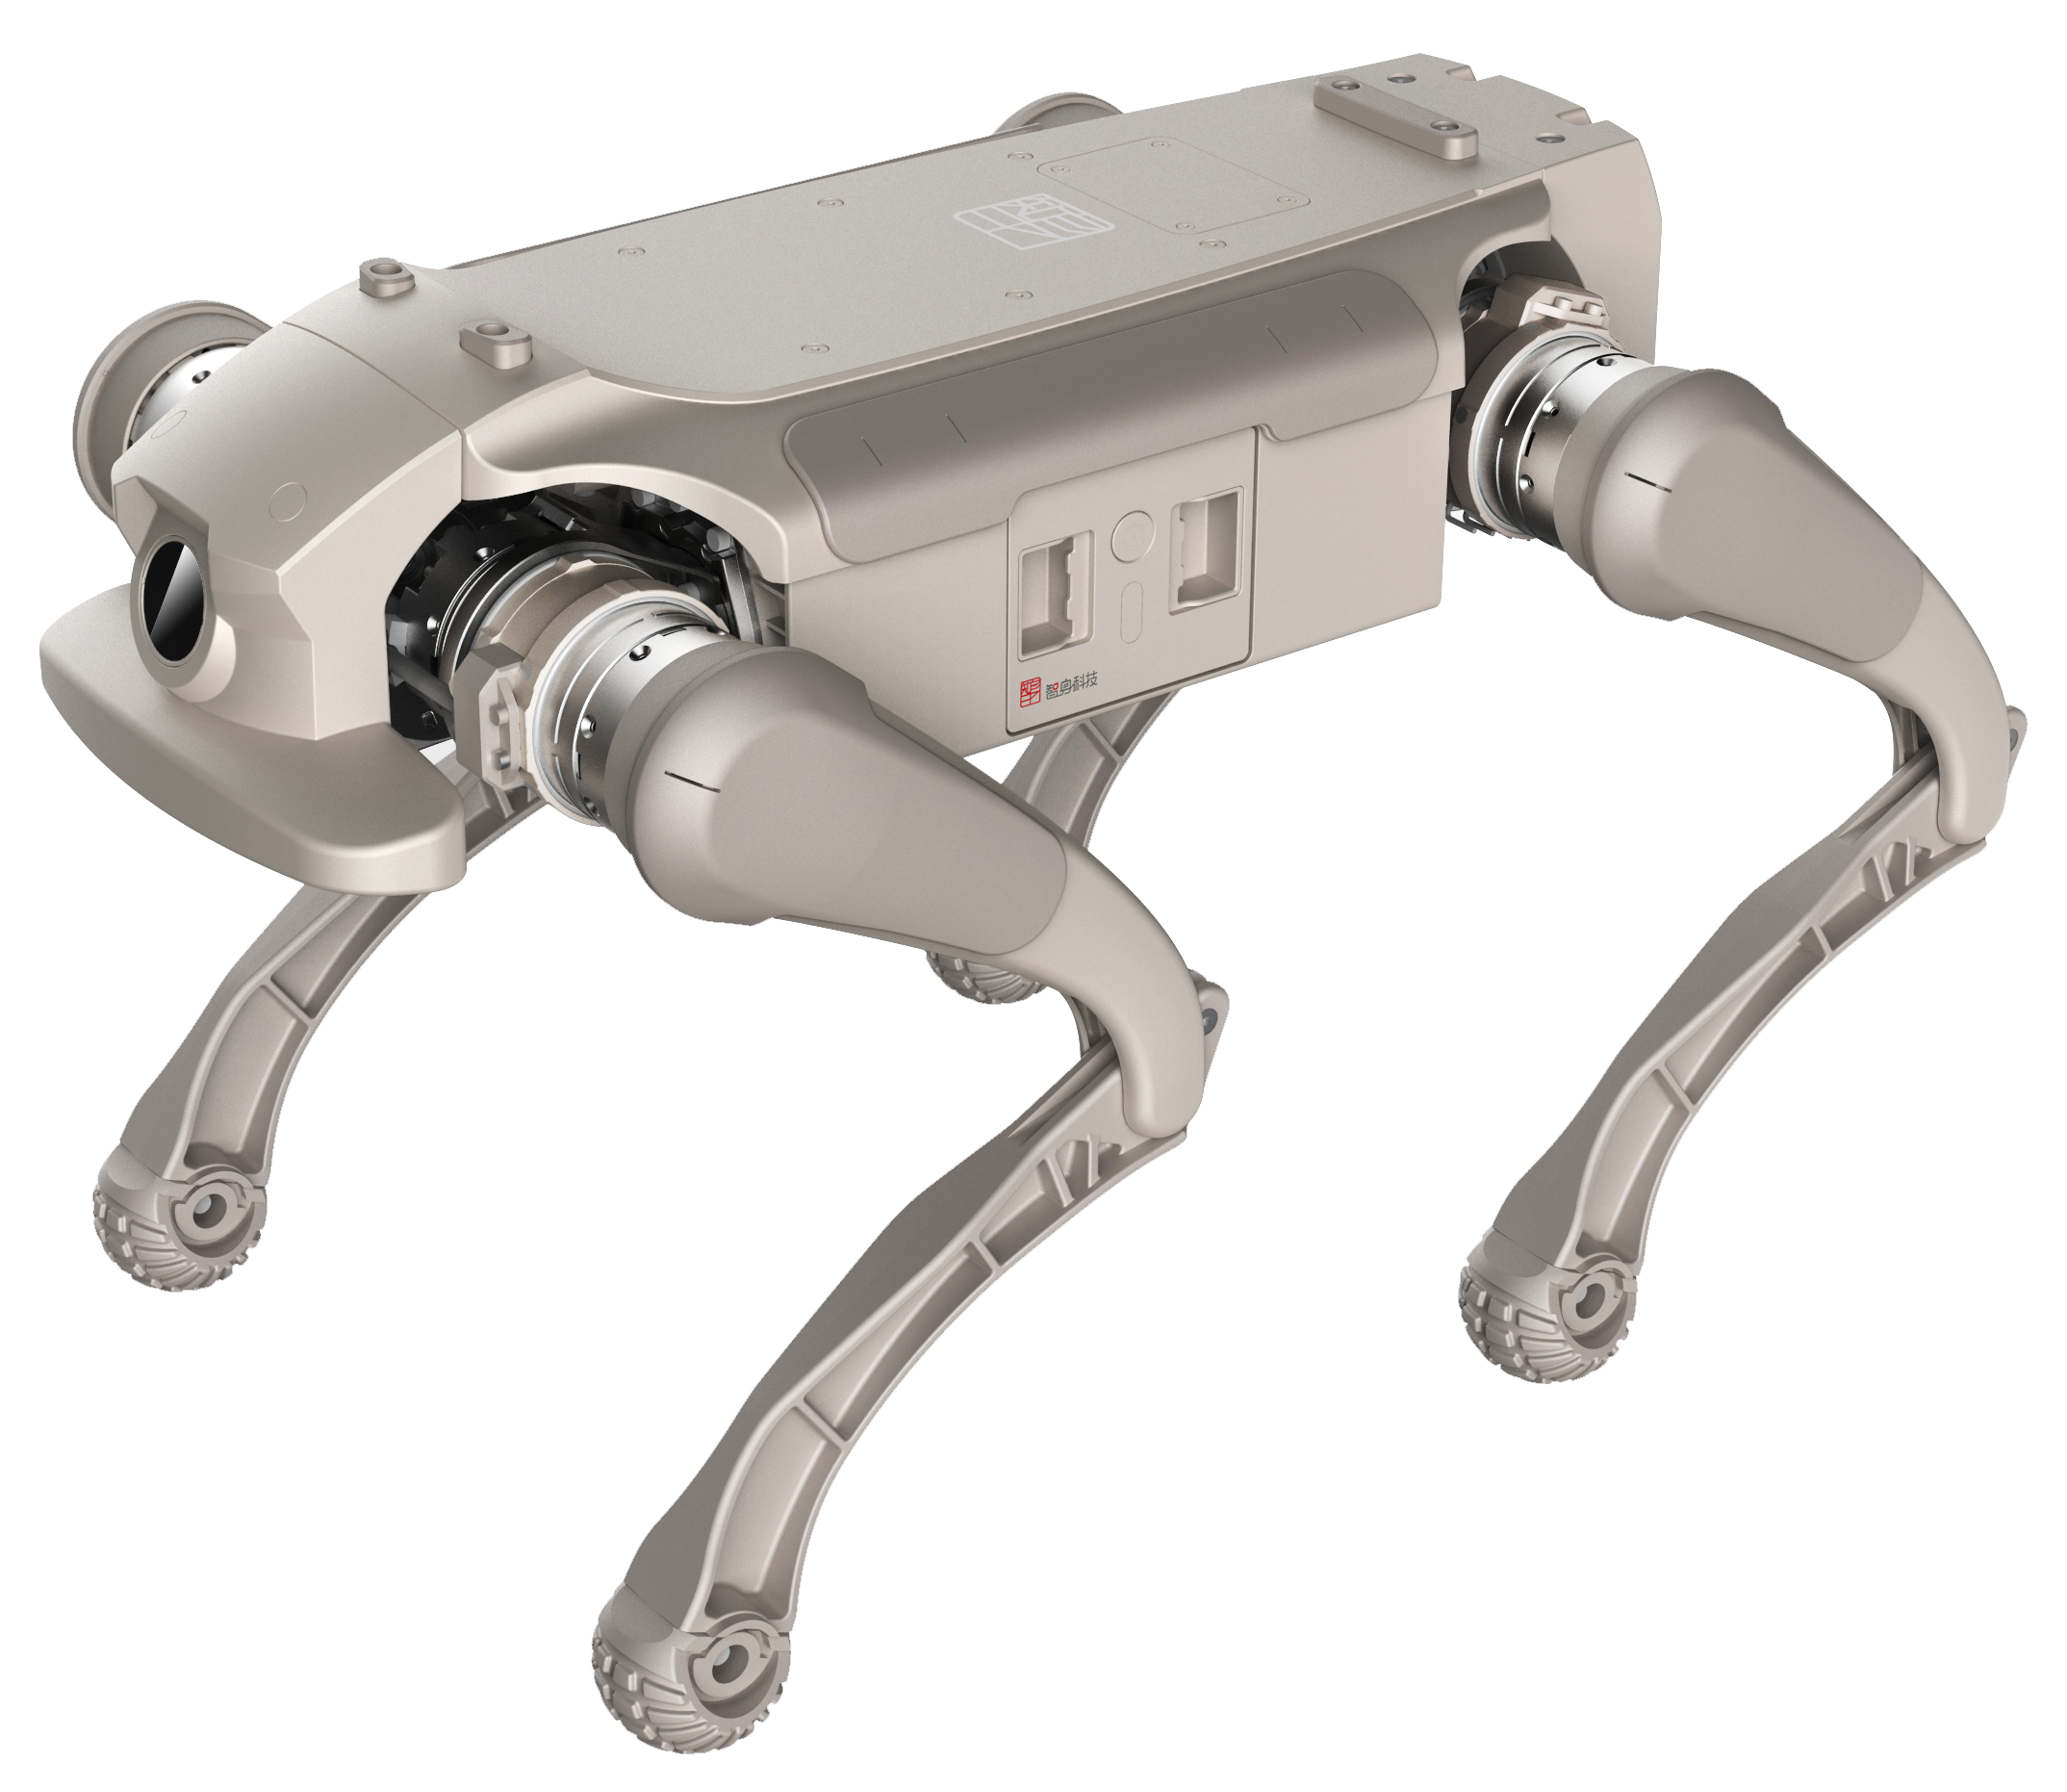
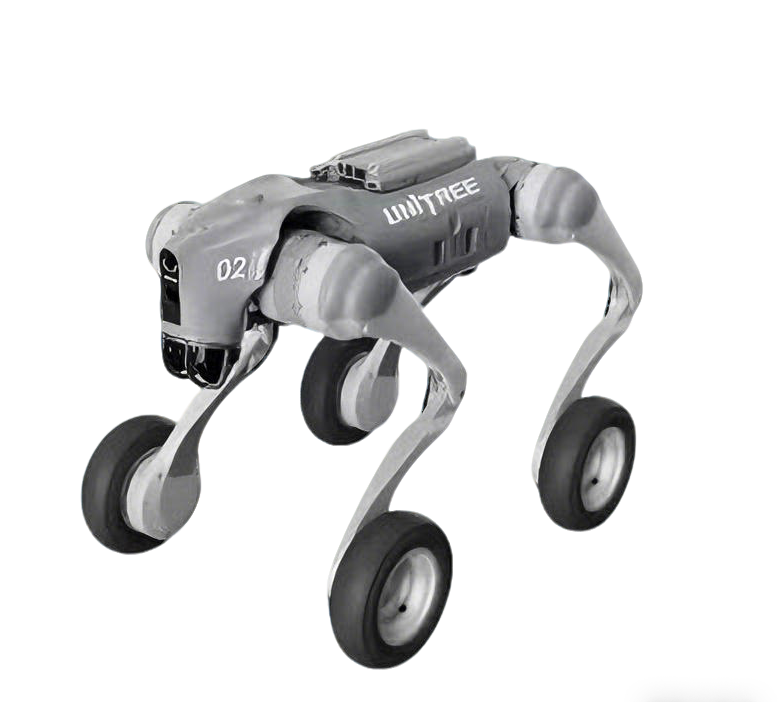
| `xgb` | Yes | Yes | UI/protocol label may appear as `xg`; supports jump actions |
| `xg2` | Yes | Yes | Second XG quadruped |
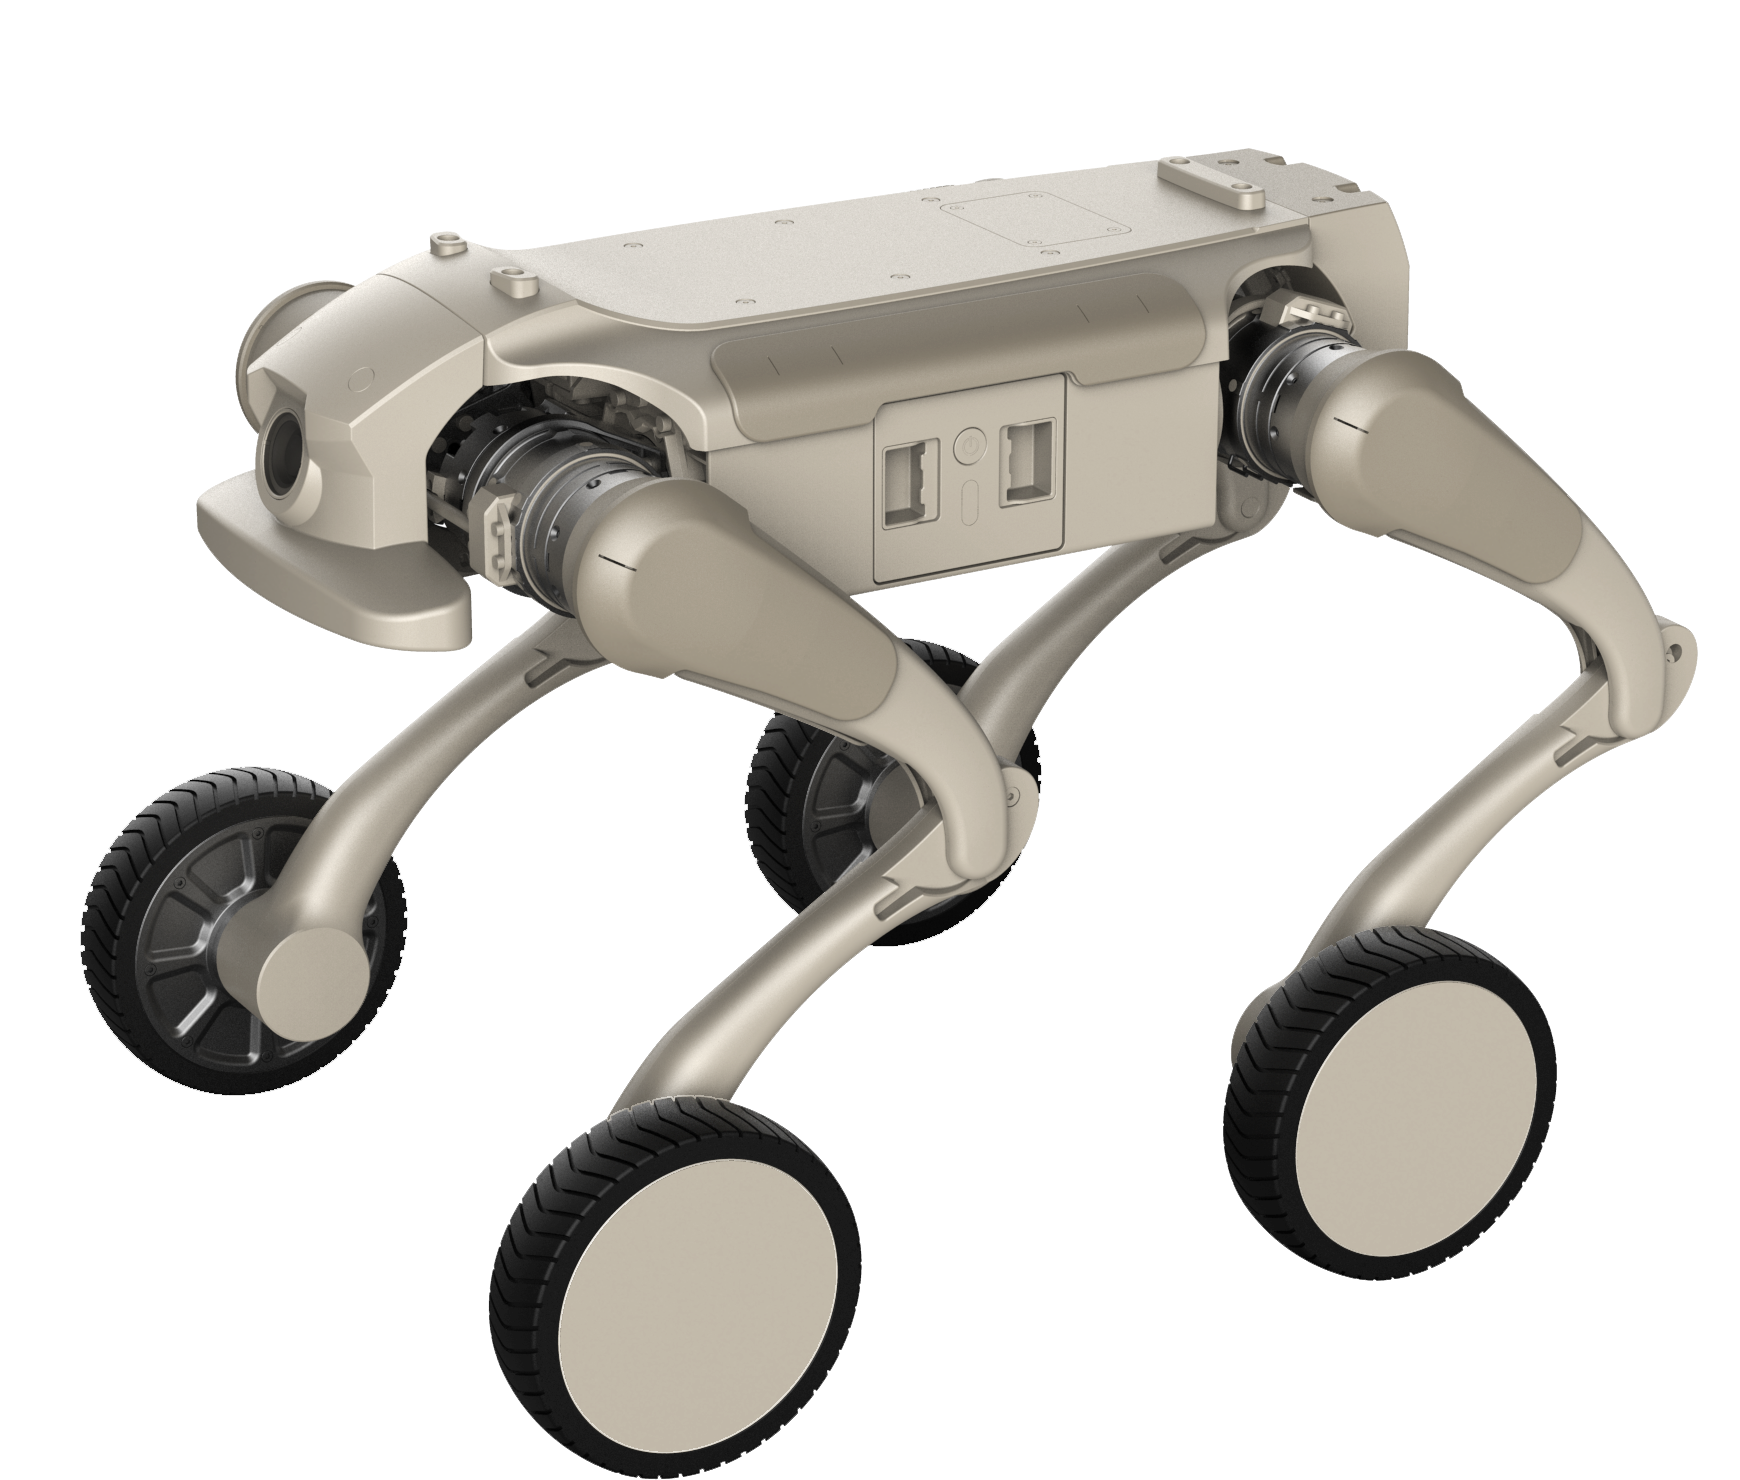
| `xgw` | Yes | Yes | Wheeled XG variant |
| `xgw2` | Yes | Yes | Second wheeled XG variant |
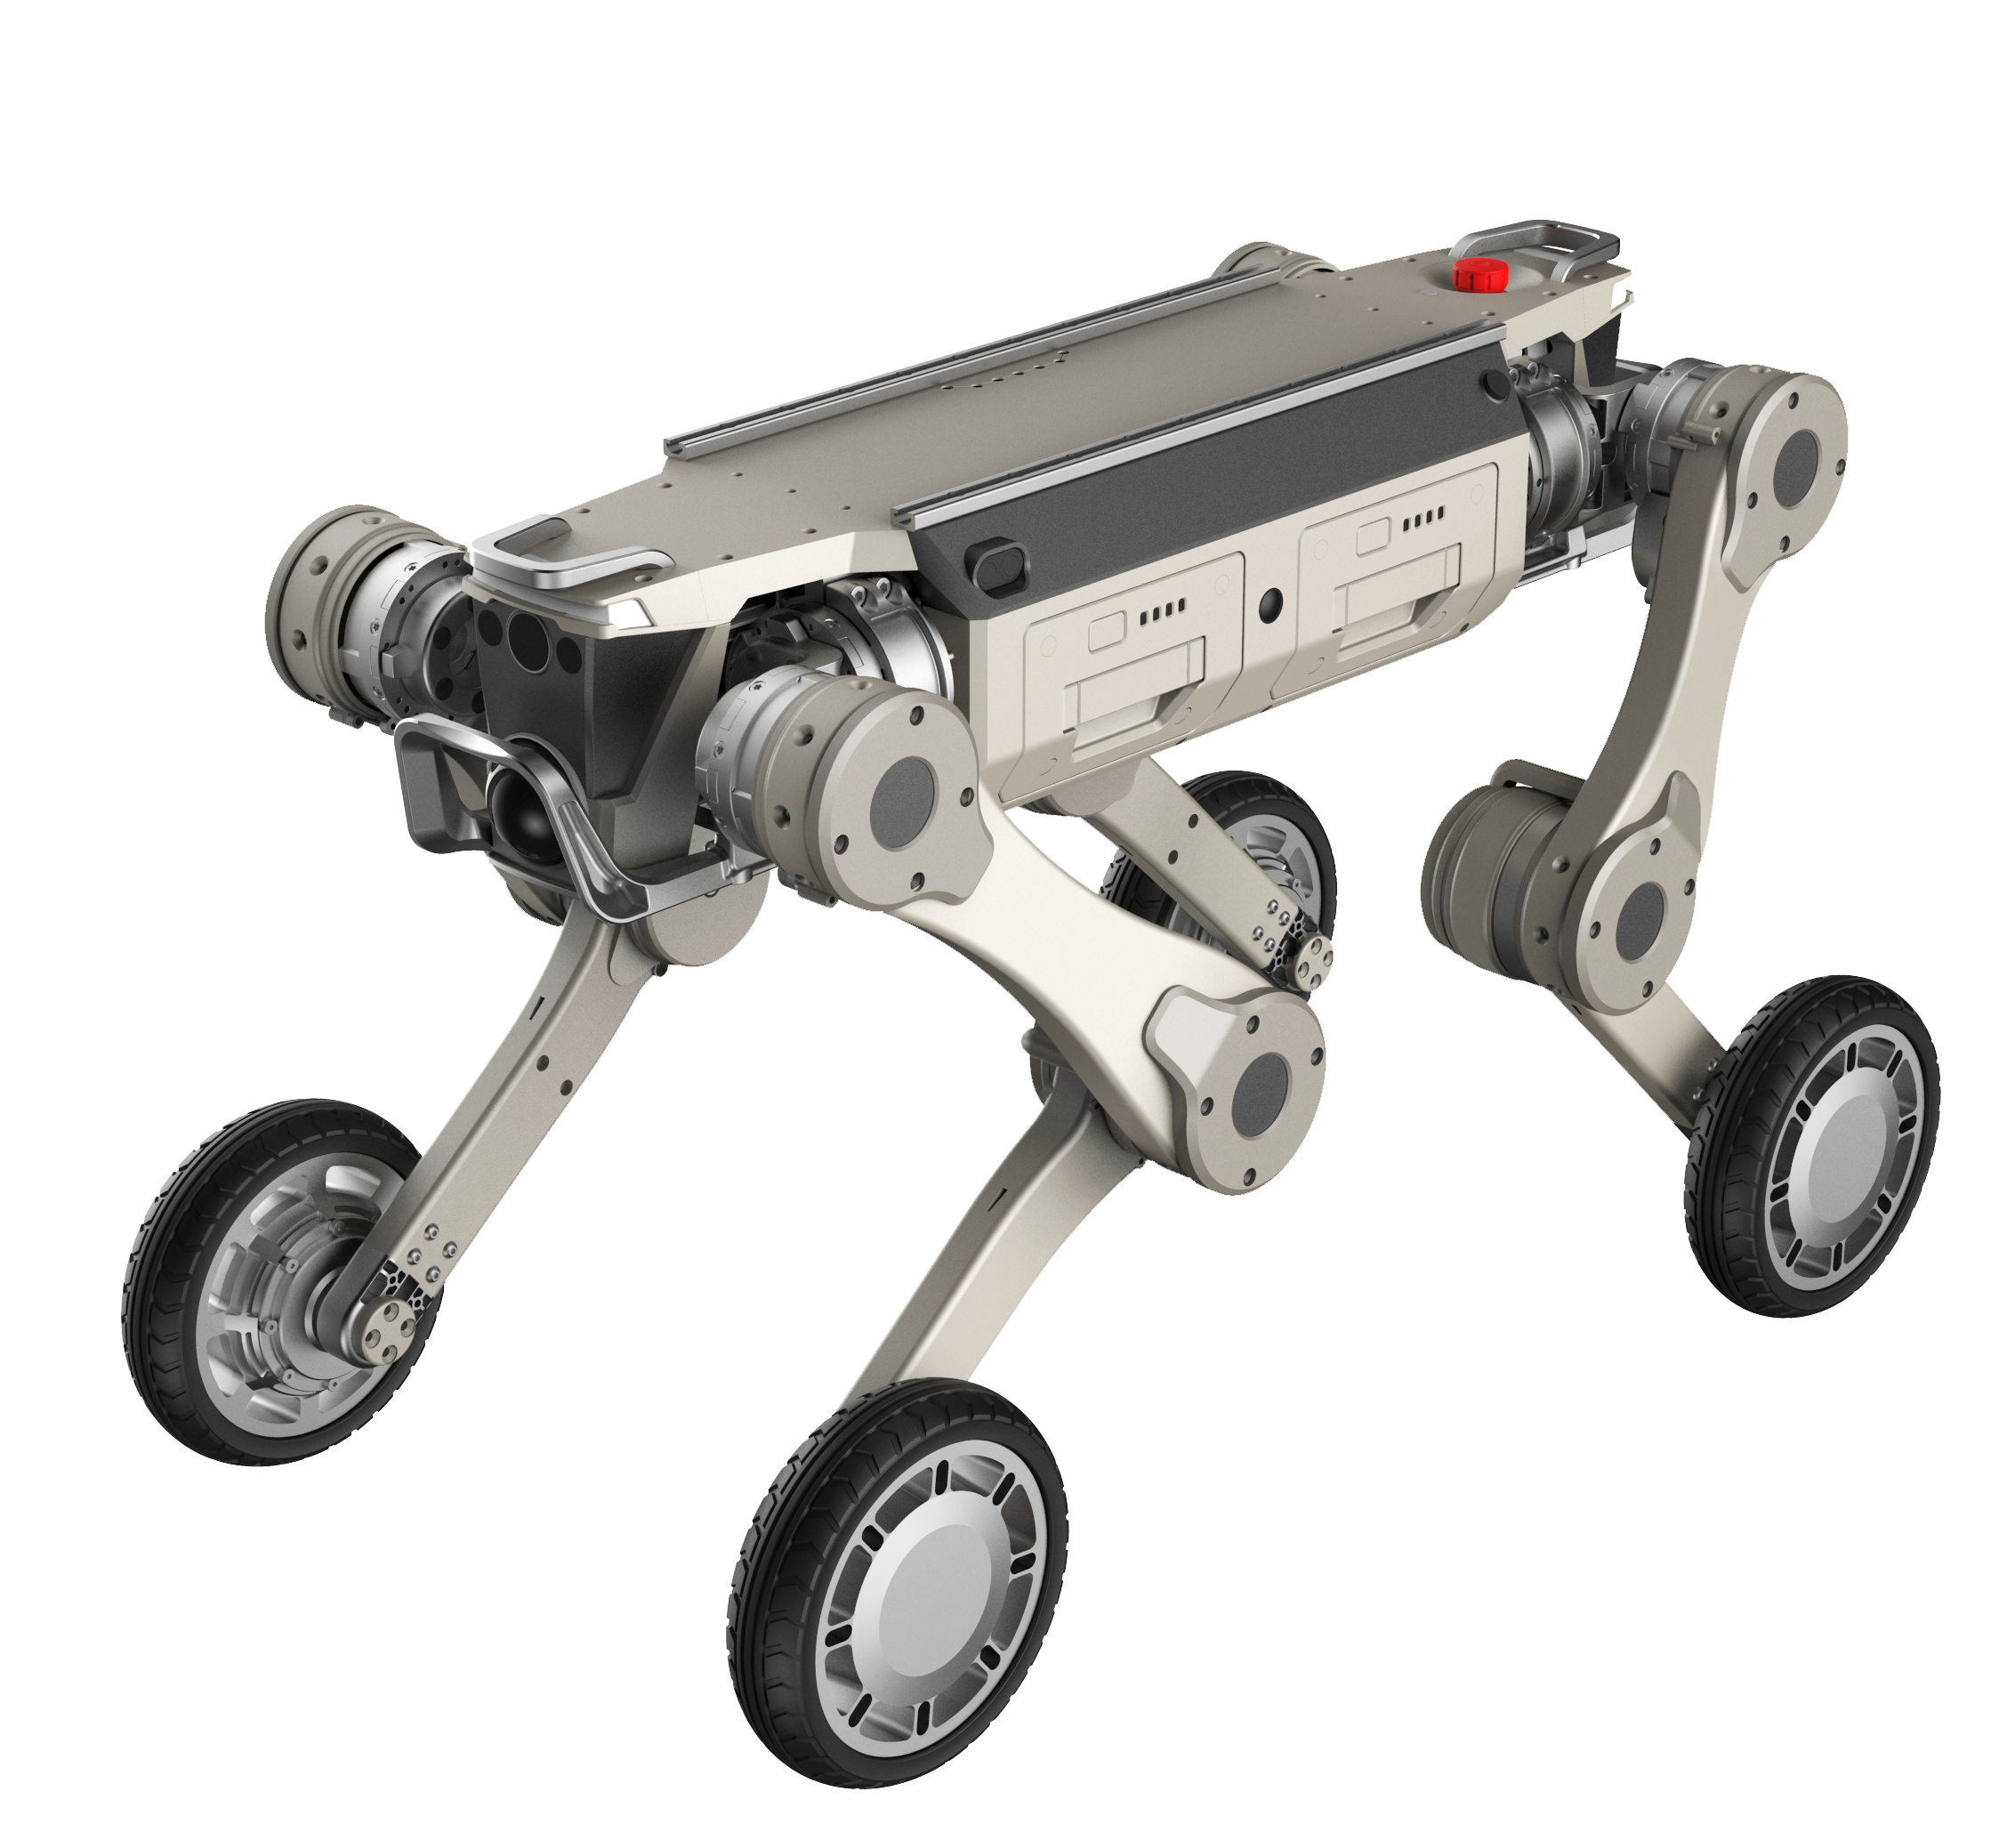
| `zgws` | Yes | Yes | Embedded Passive / Stand / Walk |
| `zgwt` | Yes | Yes | Embedded Passive / Stand / Walk |
| `zgwsarm` | Yes | Yes | UI label may appear as `zgws_arm` |
The model key must match the model directory and MJCF selected by `mujoco_model`. The embedded controller is registered for `xgb`, `xg2`, `xgw`, `xgw2`, `zgws`, `zgwt`, and `zgwsarm`. `go2` and `go2w` are simulation assets without a v1.1.2 built-in motion core.
### Robot previews
## Dynamic map catalog
The open base package intentionally starts with an empty `UeSim/Content/model/MapDataTable.json`. On the map-selection screen:
1. select **UPDATE LIST** to retrieve the current catalog;
2. select **DOWNLOAD** below the required map;
3. wait for the DLC download and mount to complete;
4. enter the map when its card is marked ready.
The catalog is the source of truth for the maps currently offered for v1.1.2. Do not rely on old numeric IDs or copy a catalog from another release.
## DLC locations and loading
For manual installation, download the required DLC from the [Baidu Netdisk mirror (code: `6sth`)](https://pan.baidu.com/s/1I87hQ9C8XzIGXgbyWk3i9A?pwd=6sth#list/path=%2F), extract the `.pak`, and place it in the preferred directory:
```text
UeSim/Saved/DLCs/*.pak
```
The runtime also scans `UeSim/Content/DLCs/*.pak`. Restart UeSim after manual installation. A `.pak` without a matching current catalog entry may be mounted but not shown as a card.
See [Map_DLC.md](Map_DLC.md) for the complete automatic and manual workflow.
## Map previews
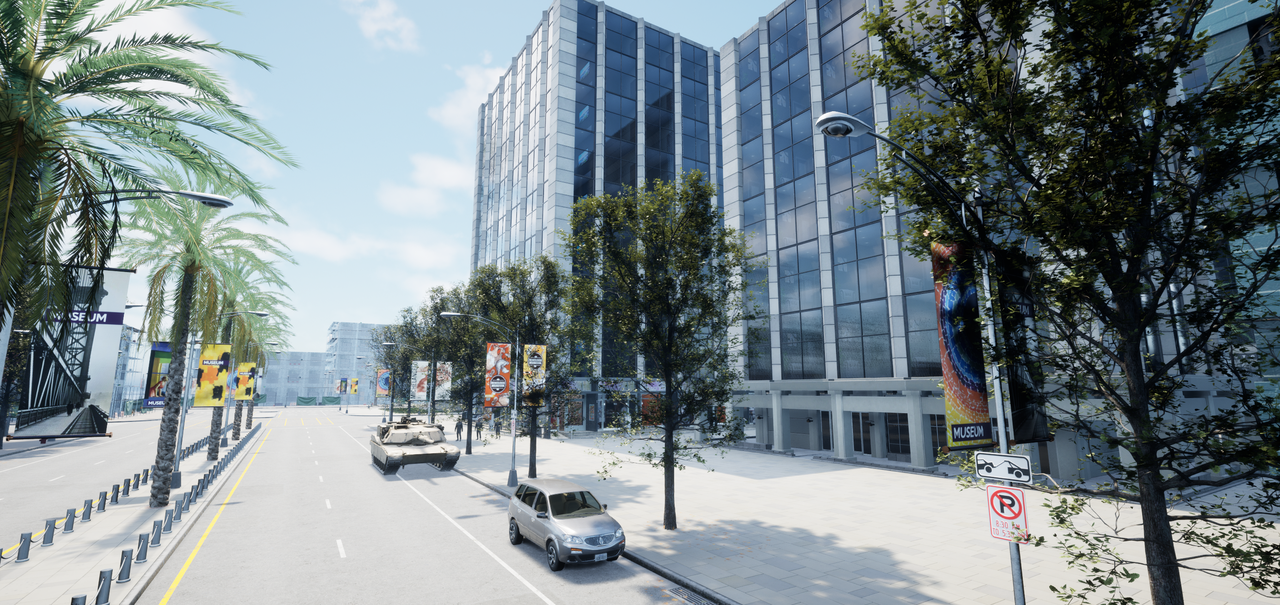
Town10World |
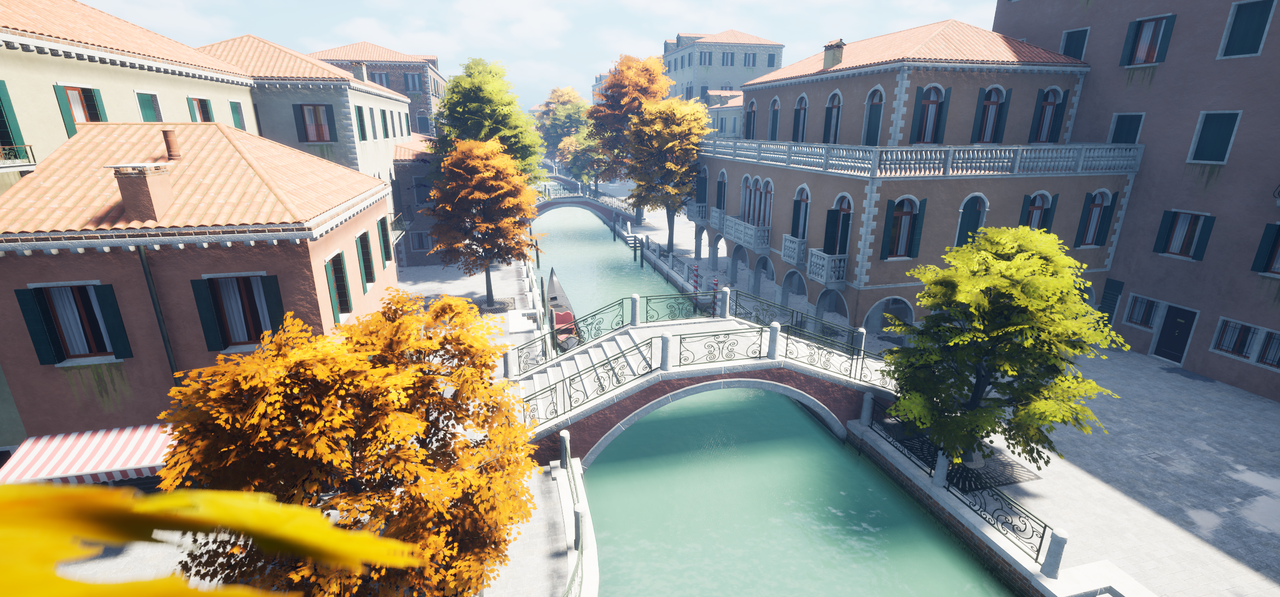
VeniceWorld |
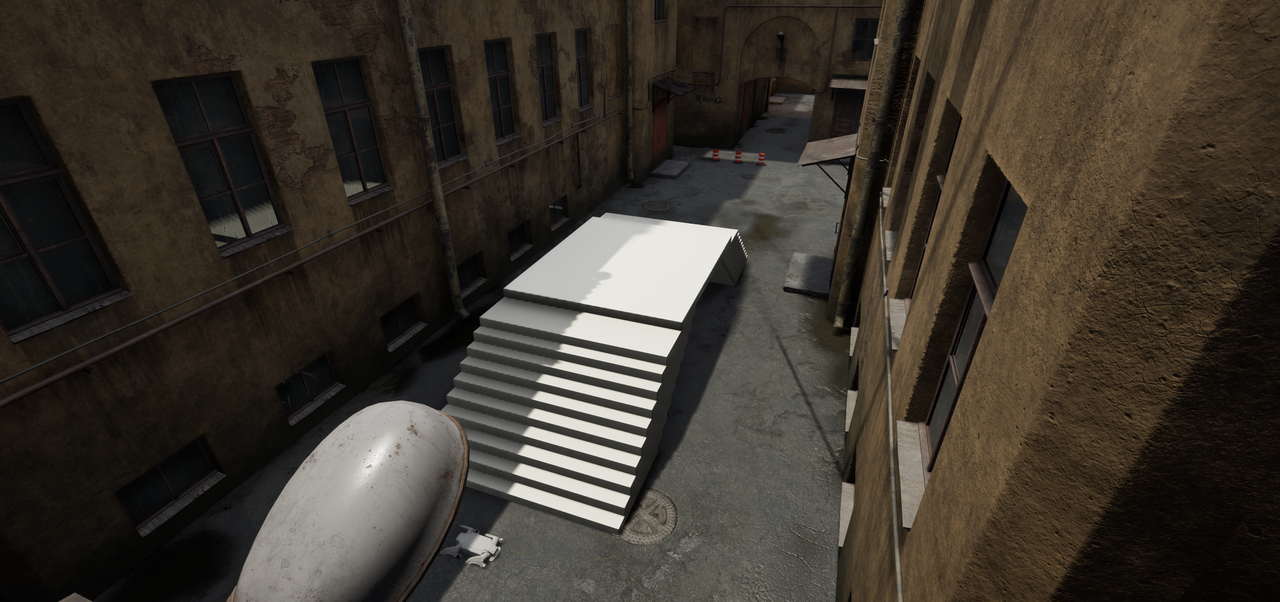
YardWorld |
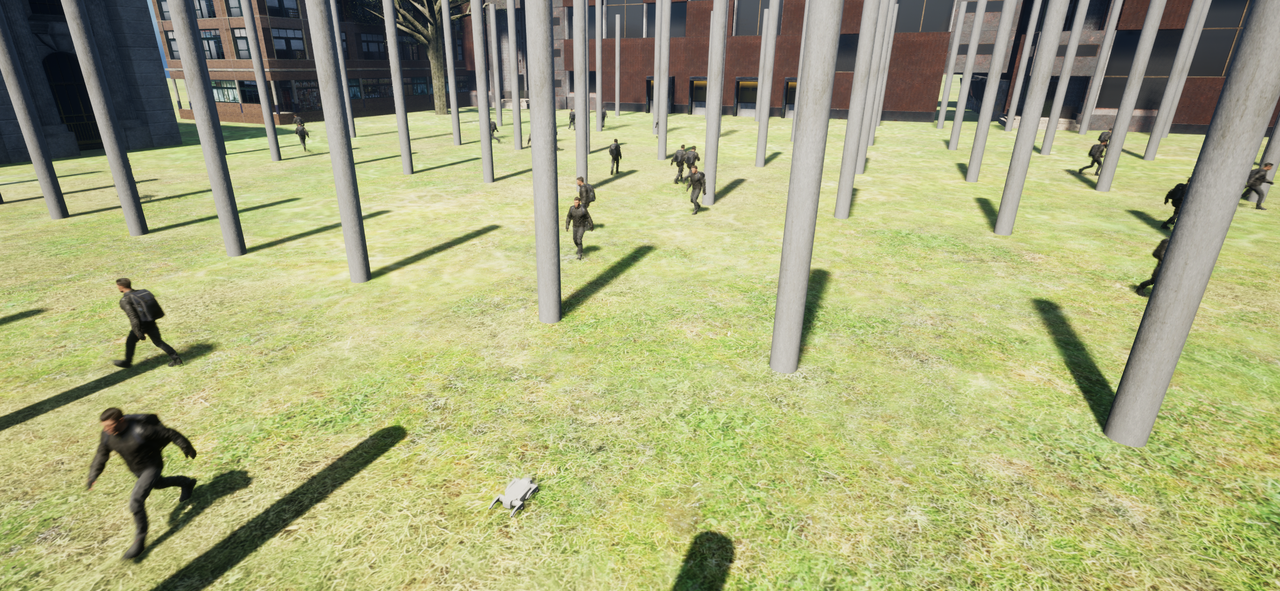
CrowdWorld |
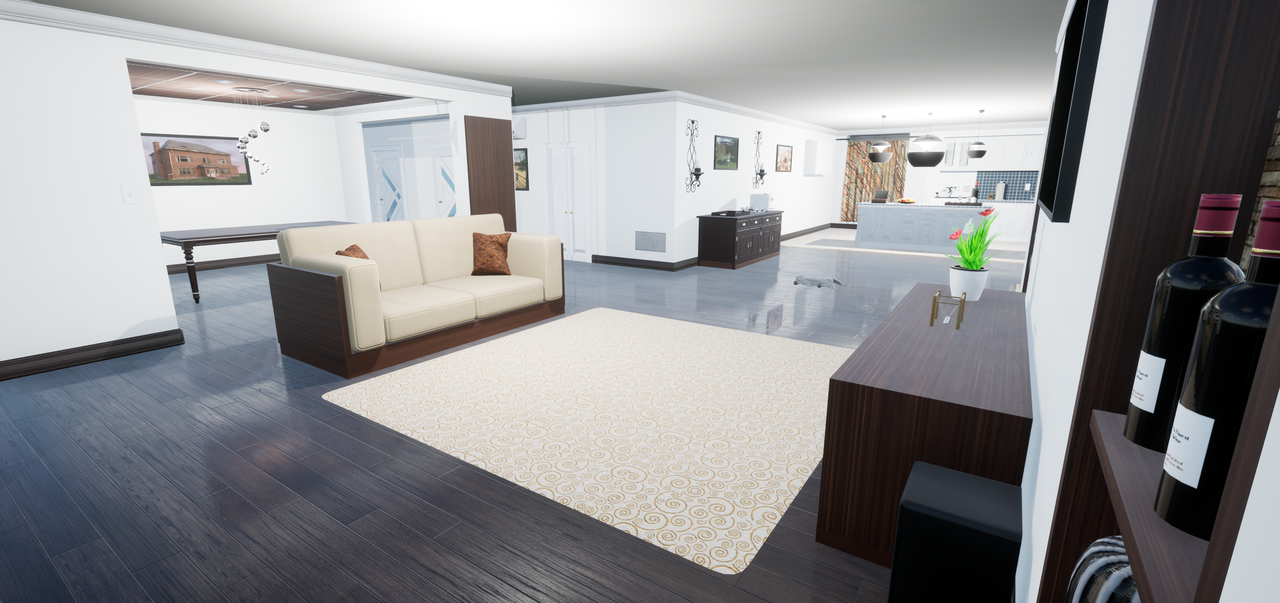
HouseWorld |
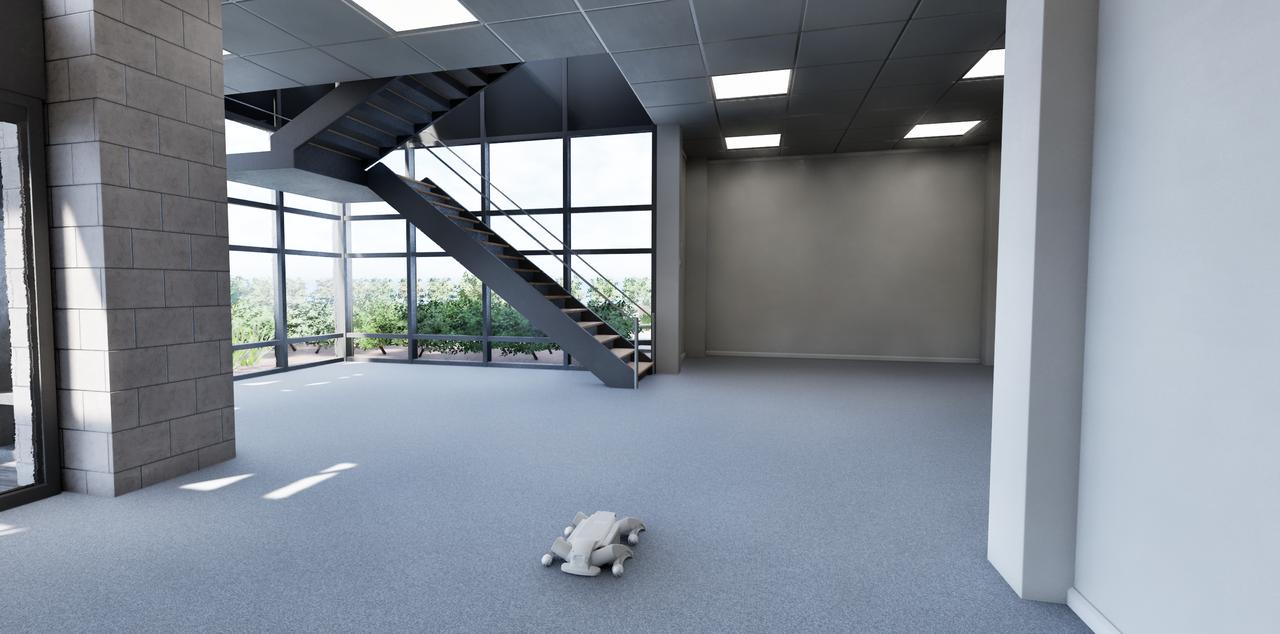
OfficeWorld |
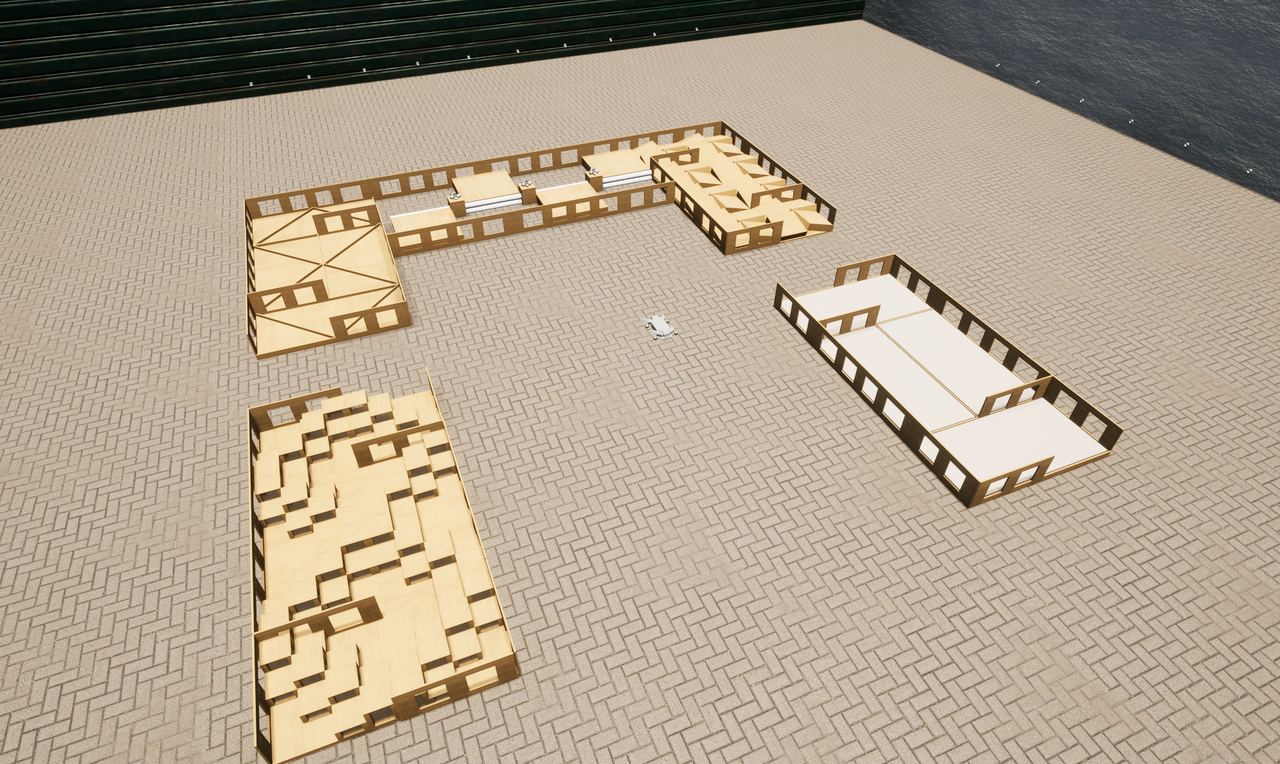
IROSFlatWorld2025 |
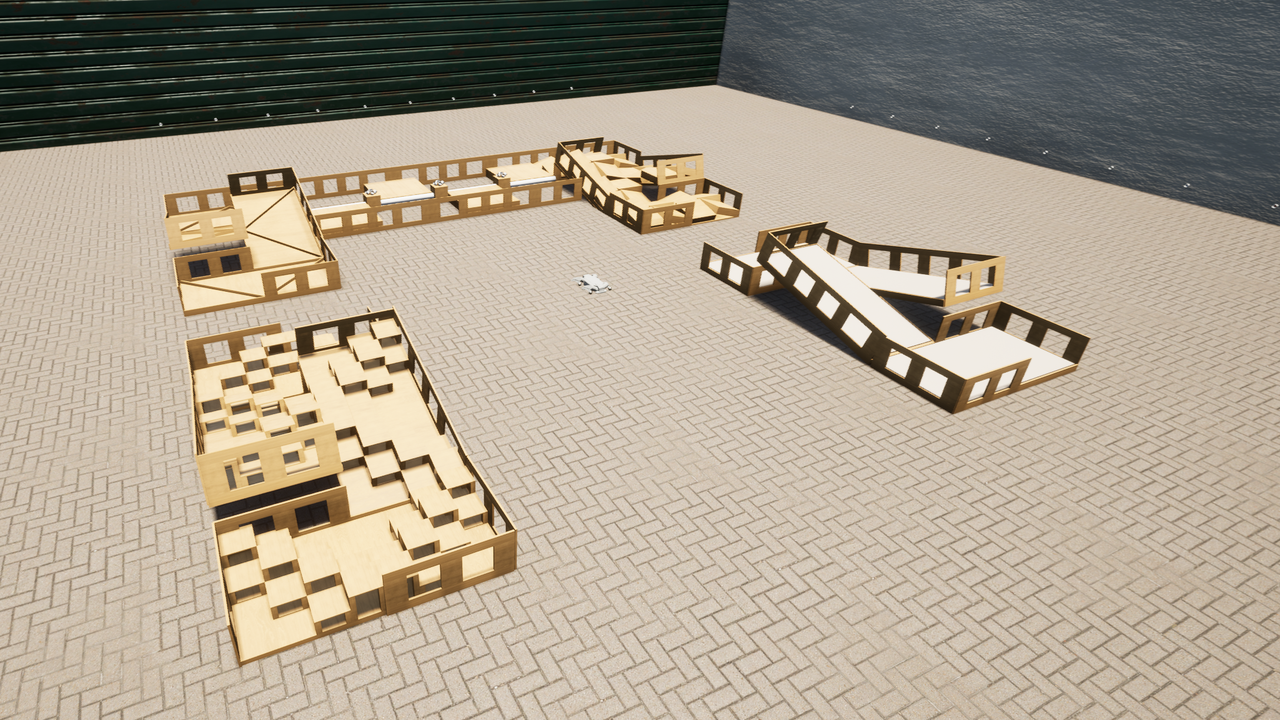
IROSSloppedWorld2025 |
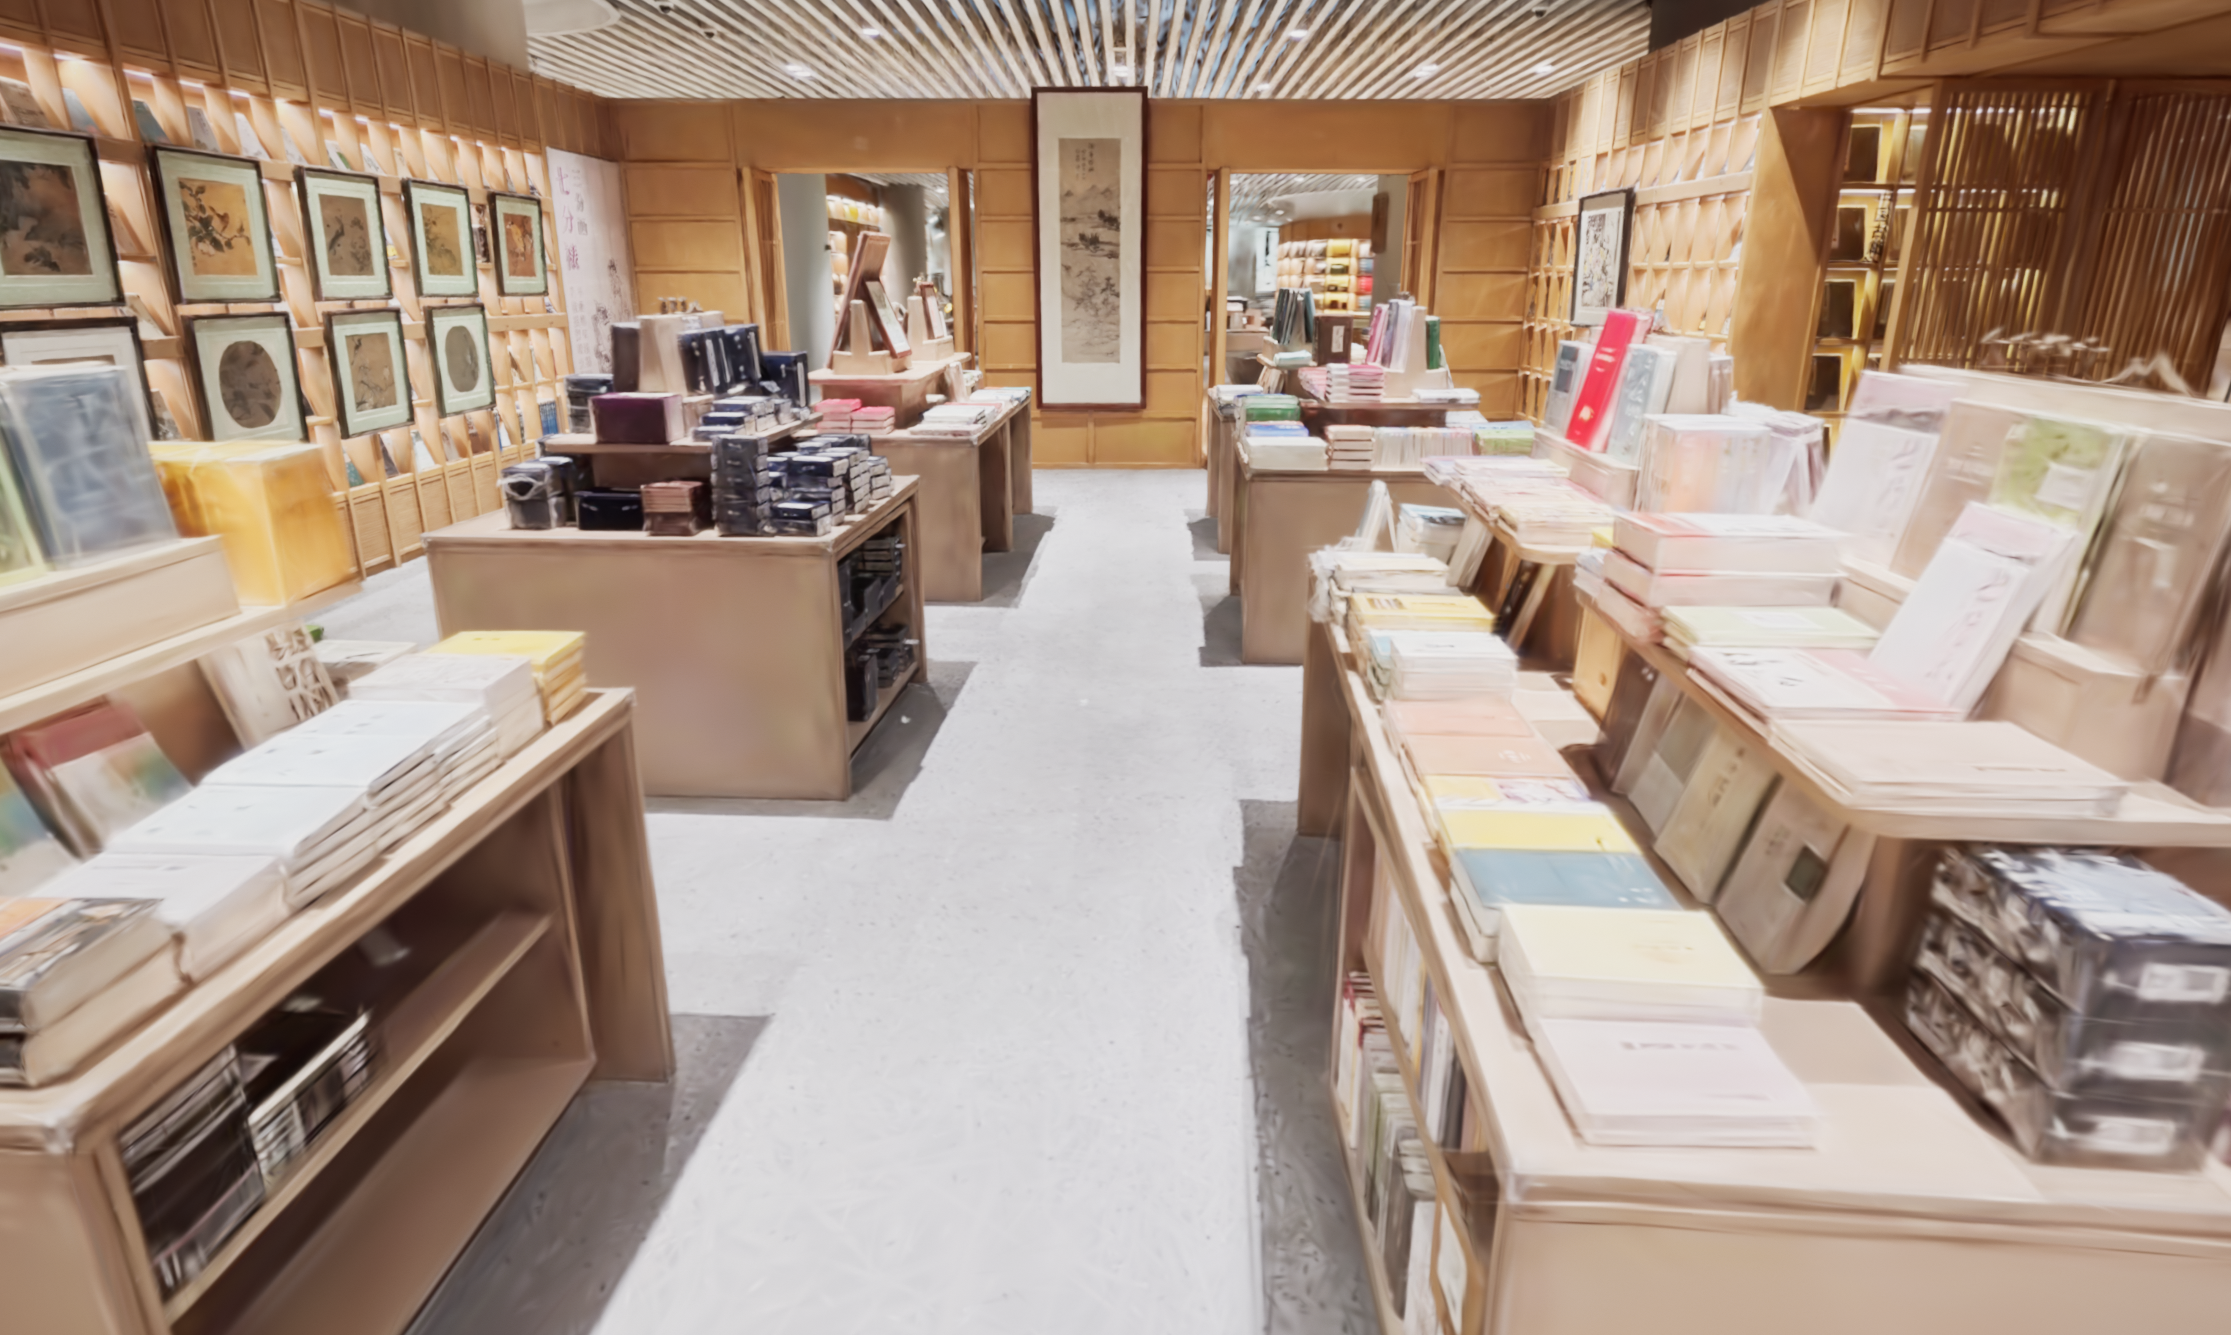
3DGSWorld |
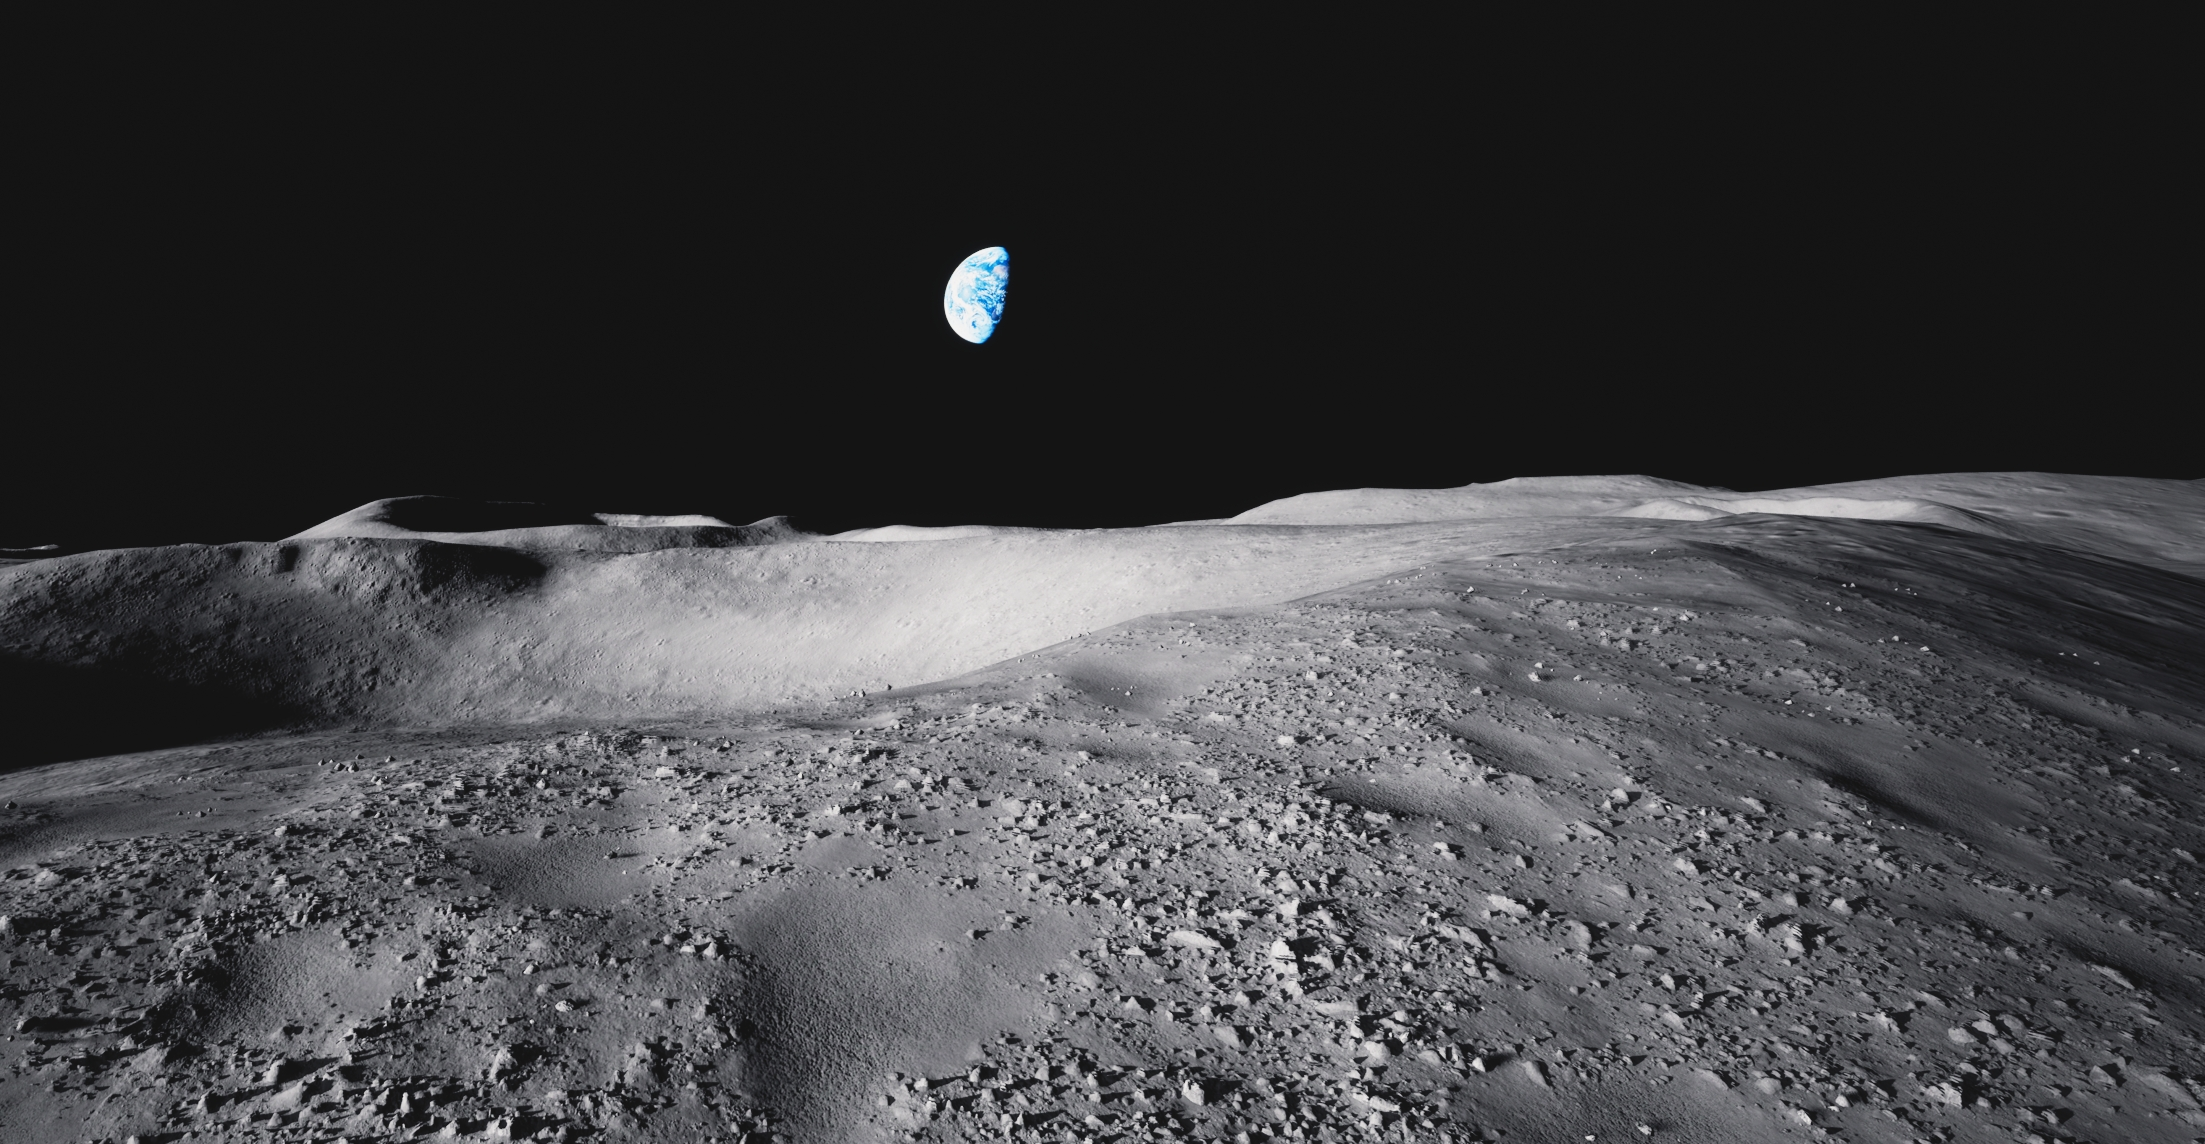
MoonWorld |
The open-source runtime excludes `UeSim/Content/model/xxg`.