
🌎English | 🇨🇳中文
 |
 |
|:---:|:---:|
|
 |
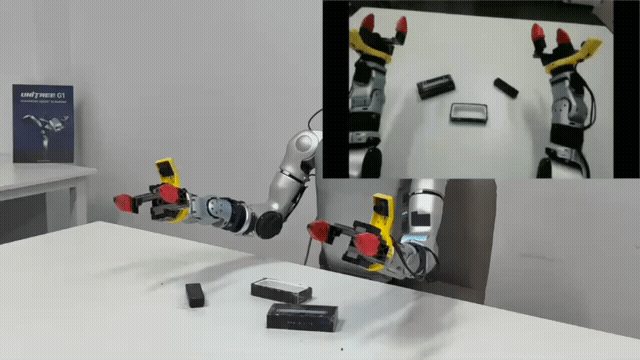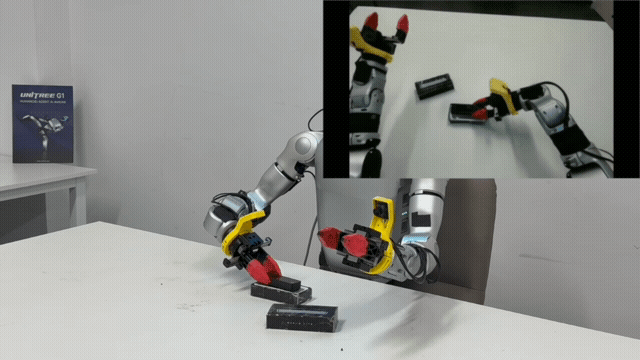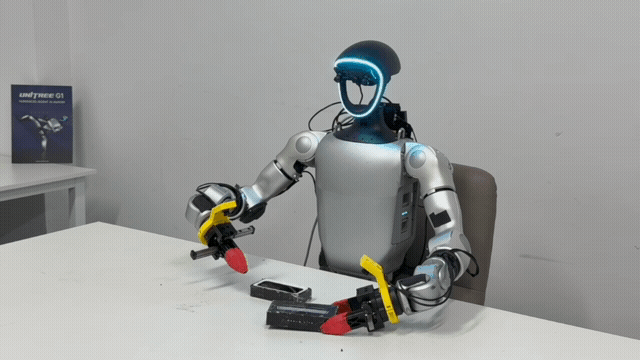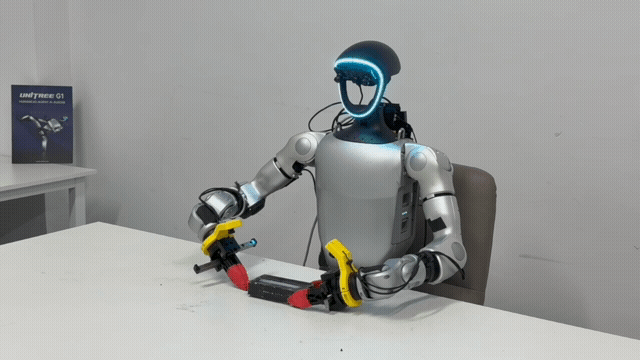 |
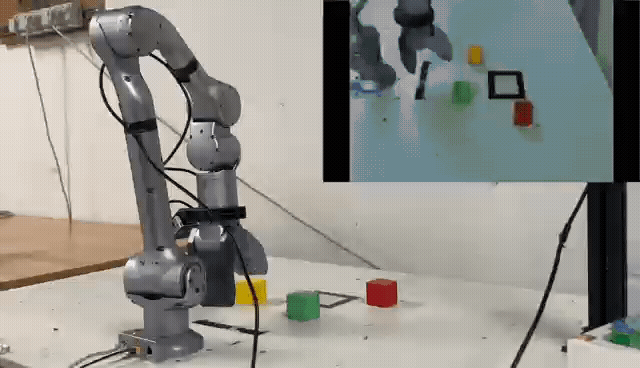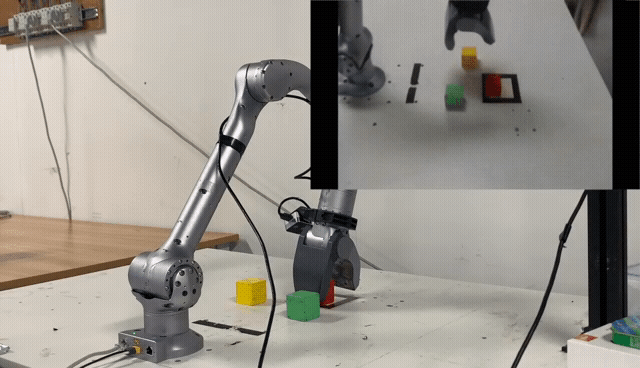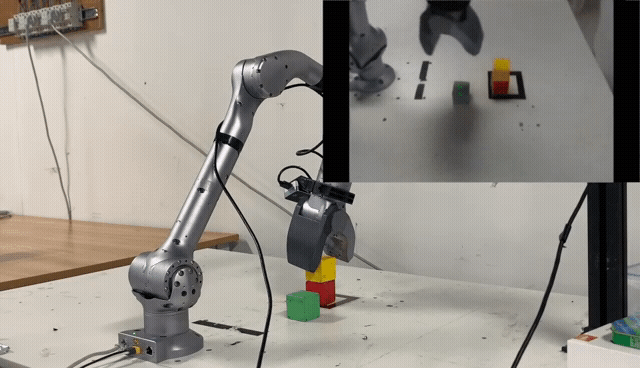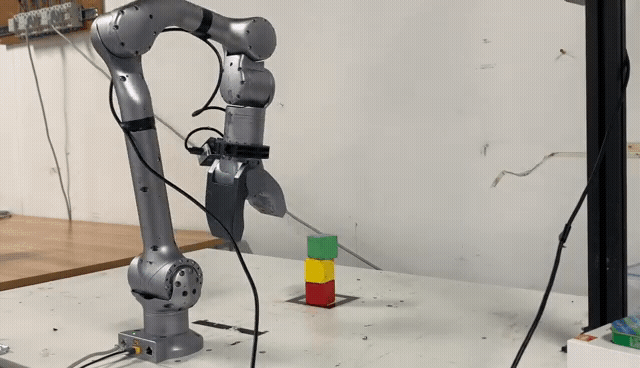
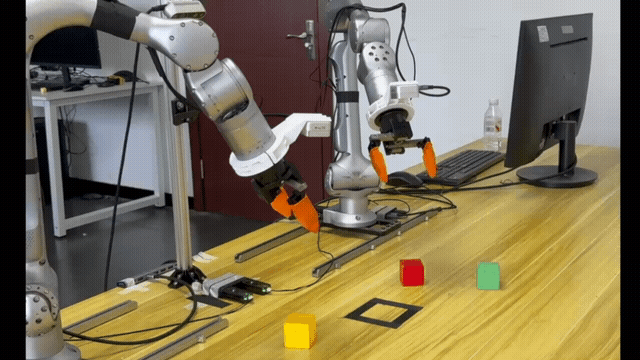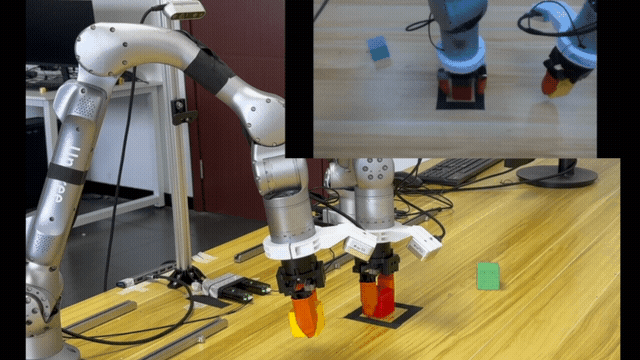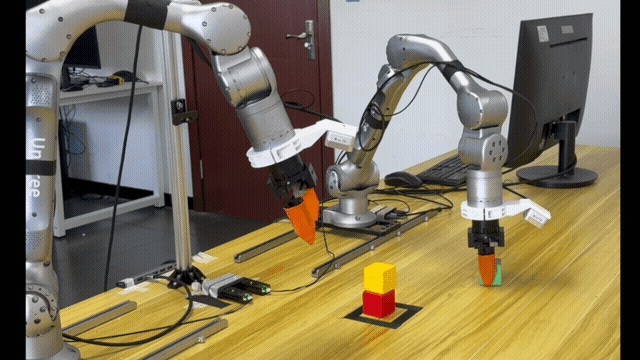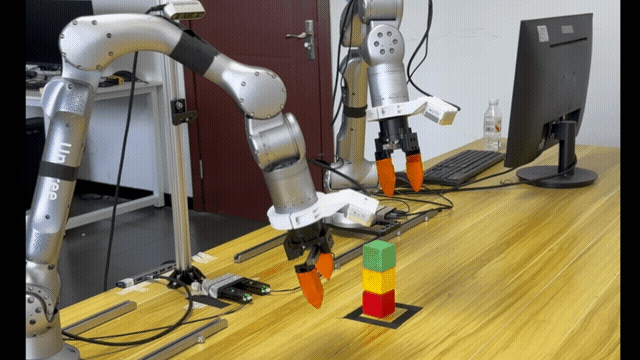
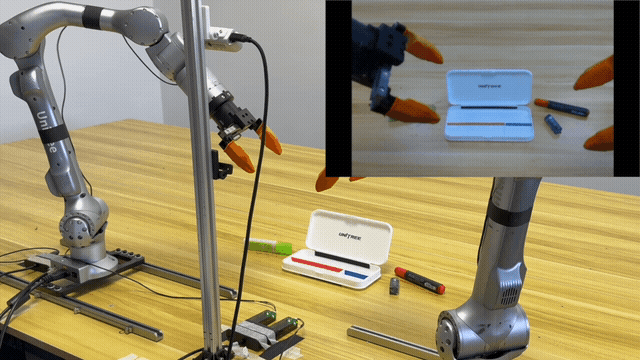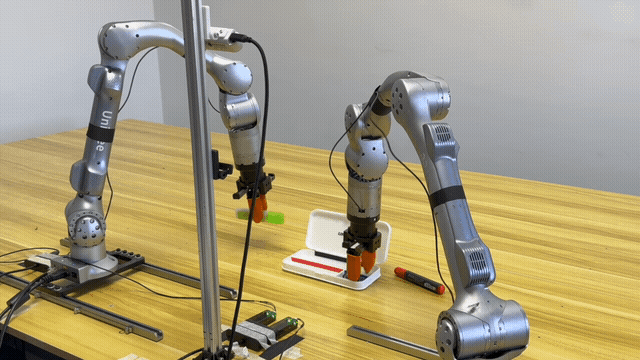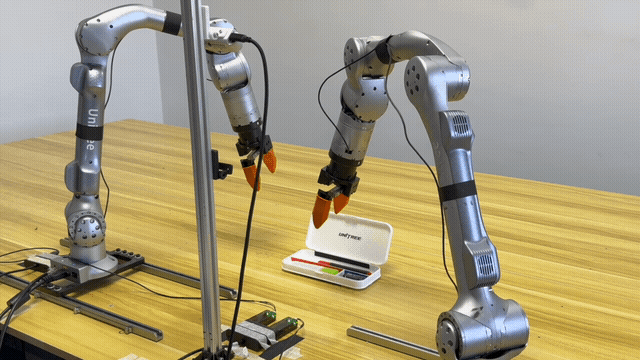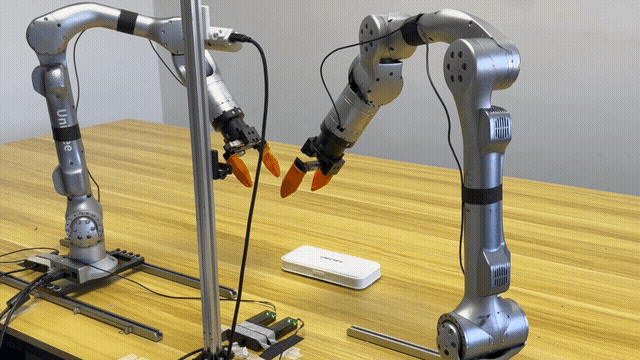
**注:右上角小窗口显示世界模型对未来动作视频的预测。**
## 新闻
* 2025年9月22日: 🚀 我们发布了应用宇树科技机器人进行真机实验的部署代码.
* 2025年9月15日: 🚀 我们发布了 **UnifoLM-WMA-0** 的训练与推理代码,以及对应的模型权重.
## 📑 开源计划
- [x] 训练代码
- [x] 推理代码
- [x] 模型Checkpoints
- [x] 真机部署代码
## ⚙️ 安装
```
conda create -n unifolm-wma python==3.10.18
conda activate unifolm-wma
conda install pinocchio=3.2.0 -c conda-forge -y
conda install ffmpeg=7.1.1 -c conda-forge
git clone --recurse-submodules https://github.com/unitreerobotics/unifolm-world-model-action.git
# If you already downloaded the repo:
cd unifolm-world-model-action
git submodule update --init --recursive
pip install -e .
cd external/dlimp
pip install -e .
```
## 🧰 模型 Checkpoints
| 模型 | 描述 | 链接 |
|---------|-------|------|
|$\text{UnifoLM-WMA-0}_{Base}$| 在 [Open-X](https://robotics-transformer-x.github.io/) 数据集微调后的模型 | [HuggingFace](https://huggingface.co/unitreerobotics/UnifoLM-WMA-0-Base)|
|$\text{UnifoLM-WMA-0}_{Dual}$| 在五个[宇树科技开源数据集](https://huggingface.co/collections/unitreerobotics/g1-dex1-datasets-68bae98bf0a26d617f9983ab)上,决策和仿真双模式,联合微调后的模型 | [HuggingFace](https://huggingface.co/unitreerobotics/UnifoLM-WMA-0-Dual)|
## 🛢️ 数据集
实验中,我们训练测试了如下五个开源数据集:
| 数据集 | 机器人 | 链接 |
|---------|-------|------|
|Z1_StackBox| [Unitree Z1](https://www.unitree.com/z1)|[Huggingface](https://huggingface.co/datasets/unitreerobotics/Z1_StackBox_Dataset/tree/v2.1)|
|Z1_DualArm_StackBox|[Unitree Z1](https://www.unitree.com/z1)|[Huggingface](https://huggingface.co/datasets/unitreerobotics/Z1_Dual_Dex1_StackBox_Dataset/tree/v2.1)|
|Z1_DualArm_StackBox_V2|[Unitree Z1](https://www.unitree.com/z1)|[Huggingface](https://huggingface.co/datasets/unitreerobotics/Z1_Dual_Dex1_StackBox_Dataset_V2/tree/v2.1)|
|Z1_DualArm_Cleanup_Pencils|[Unitree Z1](https://www.unitree.com/z1)|[Huggingface](https://huggingface.co/datasets/unitreerobotics/Z1_Dual_Dex1_CleanupPencils_Dataset/tree/v2.1)|
|G1_Pack_Camera|[Unitree G1](https://www.unitree.com/g1)|[Huggingface](https://huggingface.co/datasets/unitreerobotics/G1_Dex1_MountCameraRedGripper_Dataset/tree/v2.1)|
#### Extra available dataset
该数据集是通过使用 Unitree G1 机器人及其具有 7 个自由度的灵巧手臂收集而成的,涵盖了单臂和双臂设置下的多种桌面操作任务。它适用于视频生成模型、世界模型以及其他下游应用。每个回合持续约 30 秒。可用的图像分辨率:256×256 和 128×128。
| 数据集 | 机器人 | 链接 |
|---------|-------|------|
|G1_Dex1_DiverseManip_DualArm_256x256|[Unitree G1](https://www.unitree.com/g1)|[Huggingface](https://huggingface.co/datasets/unitreerobotics/G1_Dex1_DiverseManip_DualArm_256x256)|
|G1_Dex1_DiverseManip_DualArm_128x128|[Unitree G1](https://www.unitree.com/g1)|[Huggingface](https://huggingface.co/datasets/unitreerobotics/G1_Dex1_DiverseManip_DualArm_128x128)|
|G1_Dex1_DiverseManip_SingleArm_256x256|[Unitree G1](https://www.unitree.com/g1)|[Huggingface](https://huggingface.co/datasets/unitreerobotics/G1_Dex1_DiverseManip_SingleArm_256x256)|
|G1_Dex1_DiverseManip_SingleArm_128x128|[Unitree G1](https://www.unitree.com/g1)|[Huggingface](https://huggingface.co/datasets/unitreerobotics/G1_Dex1_DiverseManip_SingleArm_128x128)|
