RLark — Cross-Cluster Embodied Intelligence Cloud-Native Platform
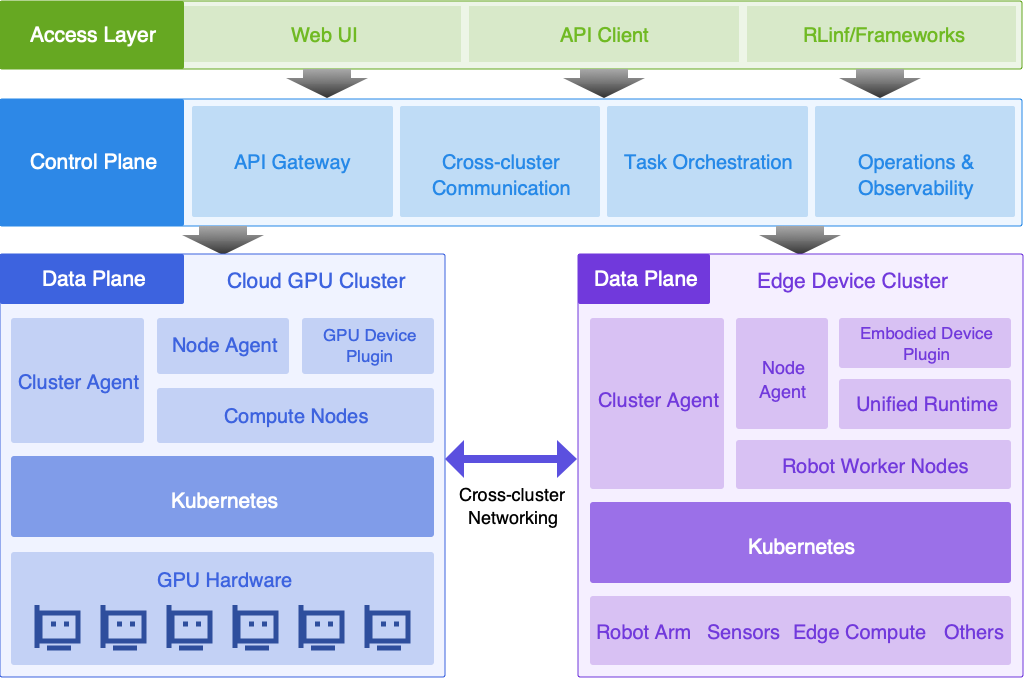
Manage cross-cluster embodied intelligence workloads through a unified cloud-native platform spanning cloud GPU training, cross-cluster collaboration, and edge device deployment across heterogeneous resources such as GPU clusters, robot arms, sensors, and cameras.
> **Explore the complete documentation on [Read the Docs](https://rlark.readthedocs.io/en/latest/)** — start with the [Quick Start](https://rlark.readthedocs.io/en/latest/quickstart/), then continue with the [platform user guide](https://rlark.readthedocs.io/en/latest/user-guide/) or [administrator guide](https://rlark.readthedocs.io/en/latest/admin-guide/).
## What's NEW!
- [2026/09] RLark is now open-source.
## Key Capabilities
- **Embodied AI Workload Orchestration**: From cloud GPU training (RL/LLM) to edge deployment (robot arm, sensor, camera), unified declarative Job/Task abstraction across the full pipeline
- **Multi-Runtime Data Plane**: Kubernetes provides unified management for cloud GPU clusters and edge devices across the complete training-to-deployment lifecycle; Docker and Raw runtime support will extend coverage to lightweight edge scenarios where Kubernetes is not suitable
- **Cross-Cluster Resource Abstraction**: Unify multi-site GPU clusters and edge devices via Domain (virtual network domain) and Node (compute node) CRDs, with the control plane running on kcp
- **Declarative Training Jobs**: Job/Task abstraction with declarative distributed training and Ray cluster definition
- **Cross-Cluster Pod Networking**: Virtual network based on TUN devices + gVisor netstack + SSH tunnels, enabling Pod-to-Pod communication without NAT traversal — cloud GPUs and edge robots communicate directly
- **Certificate System**: Dual-layer X.509 + SSH certificates for Agent access, Domain-scoped cross-cluster forwarding authentication, and user SSH authentication
- **Observability**: Prometheus metrics, real-time Pod log streaming, and web management UI
## Roadmap
See the [RLark Roadmap](ROADMAP.md) for planned runtime, account management, and custom workload resource improvements.
## Architecture Overview
## Quick Start
Follow the [Quick Start Guide on Read the Docs](https://rlark.readthedocs.io/en/latest/quickstart/) to choose one of the verified flows:
- **One-click CLI**: deploy the control plane and two kind data-plane clusters, then verify cross-cluster Pod networking.
- **UI-based flow**: create clusters and a Domain in the web console, deploy two kind data planes, schedule a Job across them, and verify connectivity.
## Documentation
The complete, searchable, and versioned documentation is published on **[Read the Docs](https://rlark.readthedocs.io/en/latest/)**. Use these rendered guides as the primary entry points:
| Guide | Description |
|-------|-------------|
| [Quick Start](https://rlark.readthedocs.io/en/latest/quickstart/) | Verified one-click and UI-based local deployment flows |
| [Core Concepts](https://rlark.readthedocs.io/en/latest/concepts/) | Domain, Job, Task, and other concepts |
| [Platform User Guide](https://rlark.readthedocs.io/en/latest/user-guide/) | Web console, clusters, jobs, storage, and SSH keys |
| [Administrator Guide](https://rlark.readthedocs.io/en/latest/admin-guide/) | Control plane, data plane, networking, security, and operations |
| [Developer Guide](https://rlark.readthedocs.io/en/latest/developer-guide/) | Local development, project layout, debugging, and extensions |
| [API Reference](https://rlark.readthedocs.io/en/latest/api/reference/) | Gateway REST API routes and behavior |
| [Architecture](https://rlark.readthedocs.io/en/latest/architecture/) | Components, interactions, and data flows |
Repository-specific references remain available alongside the code:
| Reference | Description |
|-----------|-------------|
| [Embodied Runtime](apps/embodied-runtime/README.md) | Robot (ROS) and camera hardware management on edge nodes |
| [Web UI](apps/rlark-ui/README.md) | Frontend management console |
| [Python SDK](sdks/embodied-runtime-python/README.md) | Python client for robot/camera gRPC services |
| [Go SDK](sdks/embodied-runtime-go/README.md) | Go client for embodied-runtime gRPC stubs |
| [Proto Definitions](proto/embodied-runtime/README.md) | gRPC service definitions for embodied-runtime |
> Prefer Chinese? Visit the **[中文 Read the Docs 站点](https://rlark.readthedocs.io/zh-cn/latest/)**.
## Tech Stack
- **Language**: Go (control plane/agent) + TypeScript (frontend)
- **Orchestration**: Kubernetes (kcp + kind)
- **Networking**: TUN device + gVisor netstack + SSH tunnel
- **Certificates**: X.509 mTLS + SSH certificates
- **Database**: PostgreSQL (Bun ORM)
- **Monitoring**: Prometheus
- **Frontend**: React + Vite + TypeScript
## Contributing
We welcome contributions! Please see [CONTRIBUTING.md](CONTRIBUTING.md) for guidelines, and [CODE_OF_CONDUCT.md](CODE_OF_CONDUCT.md) for our community standards.
## License
RLark is licensed under the [Apache License 2.0](LICENSE).