RP1 Humanoid / RP Hand / SDK
A compact five-finger dexterous hand for humanoid robots.
Six active axes. CAN-FD connectivity. Product and development resources in one place.
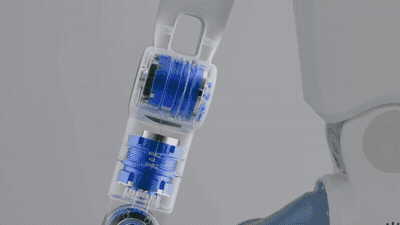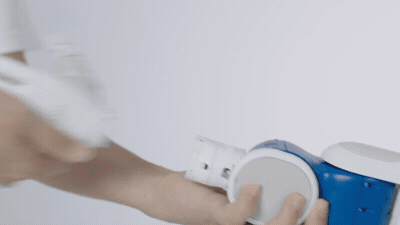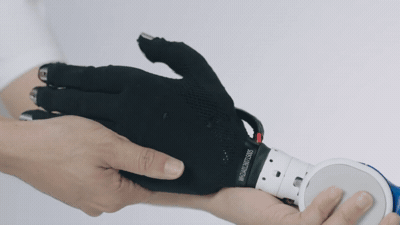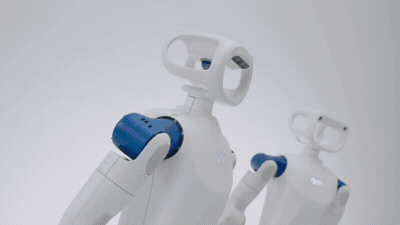
RP Hand quick-change installation on RP1.
## Overview RP Hand provides five-finger manipulation for small and medium humanoid robots. It has **11 mechanical degrees of freedom, including 6 actively controlled axes**, in a compact worm-gear mechanism. On RP1, the matching CAN-FD connection supports internal cable routing. - **Robot integration** — dimensions, connector pinout and left/right CAD for mechanical and electrical integration. - **Device setup** — a Windows configuration application for debugging and parameter setup. - **Visual hand control** — gesture-recognition demo packages for Windows and Linux. - **Application development** — a Linux CAN-FD SDK with C++, Python and bundled ROS 2 interfaces, plus URDF and MJCF models. ## Specifications | Property | Value | | --- | --- | | Fingers | 5 | | Mechanical DoF | 11: 6 active axes and 5 passive / coupled DoF | | Dimensions | 147.54 × 73.53 × 26.35 mm | | Mass | 379 ± 10 g | | Transmission | Worm gear | | RP1 communication | CAN-FD | [Hardware guide: dimensions, power and pinout →](docs/en/hardware.md) ## Start with your task | Set up the hand | Develop an application | Integrate the hardware | | --- | --- | --- | | Configure the device and try the gesture demo. | Build a C++, Python or ROS 2 application over CAN-FD. | Check the installation space and use the left/right robot models. | | [Companion software](docs/en/software.md) · [Downloads](docs/en/downloads.md) | [Quick start](docs/en/quickstart.md) · [SDK repository](https://github.com/Roboparty/roboparty_dexhand) | [Hardware](docs/en/hardware.md) · [CAD / URDF / MJCF](docs/en/models.md) | For a first robot integration, check the [wiring](docs/en/hardware.md), bring up one hand with the [quick start](docs/en/quickstart.md), then add [ROS 2](docs/en/ros2.md) if needed. The ROS 2 package is included in the SDK repository at `ros2/rphand_ros`. ## Documentation | Guide | Contents | | --- | --- | | [Quick start](docs/en/quickstart.md) | Linux environment, SDK build, CAN-FD setup and first connection | | [C++ / Python SDK](docs/en/sdk.md) | Control flow, axis order, units and state feedback | | [ROS 2 integration](docs/en/ros2.md) | Jazzy setup, dual-hand launch, commands and recording | | [Hardware](docs/en/hardware.md) | Dimensions, power, connectors and wiring | | [Companion software](docs/en/software.md) | Configuration application and gesture-recognition demos | | [Models](docs/en/models.md) | Left/right CAD, URDF, MJCF and joint mapping | | [Downloads](docs/en/downloads.md) | Applications, models and protocol files | | [Troubleshooting](docs/en/troubleshooting.md) | Build, communication and motion checks | ## Support and contributions Use [rp_dexhand Issues](https://github.com/Roboparty/rp_dexhand/issues) for product documentation and resources, and [SDK Issues](https://github.com/Roboparty/roboparty_dexhand/issues) for C++, Python and ROS 2 code. [Contributing](CONTRIBUTING.md) · [Licensing](LICENSES.md) · [Source attribution](NOTICE.md) · [Back to top](#top)